88 posts

Pre-SVR Day 16: Open Field

2013 FRC Build SeasonFIRST Robotics

Open Field

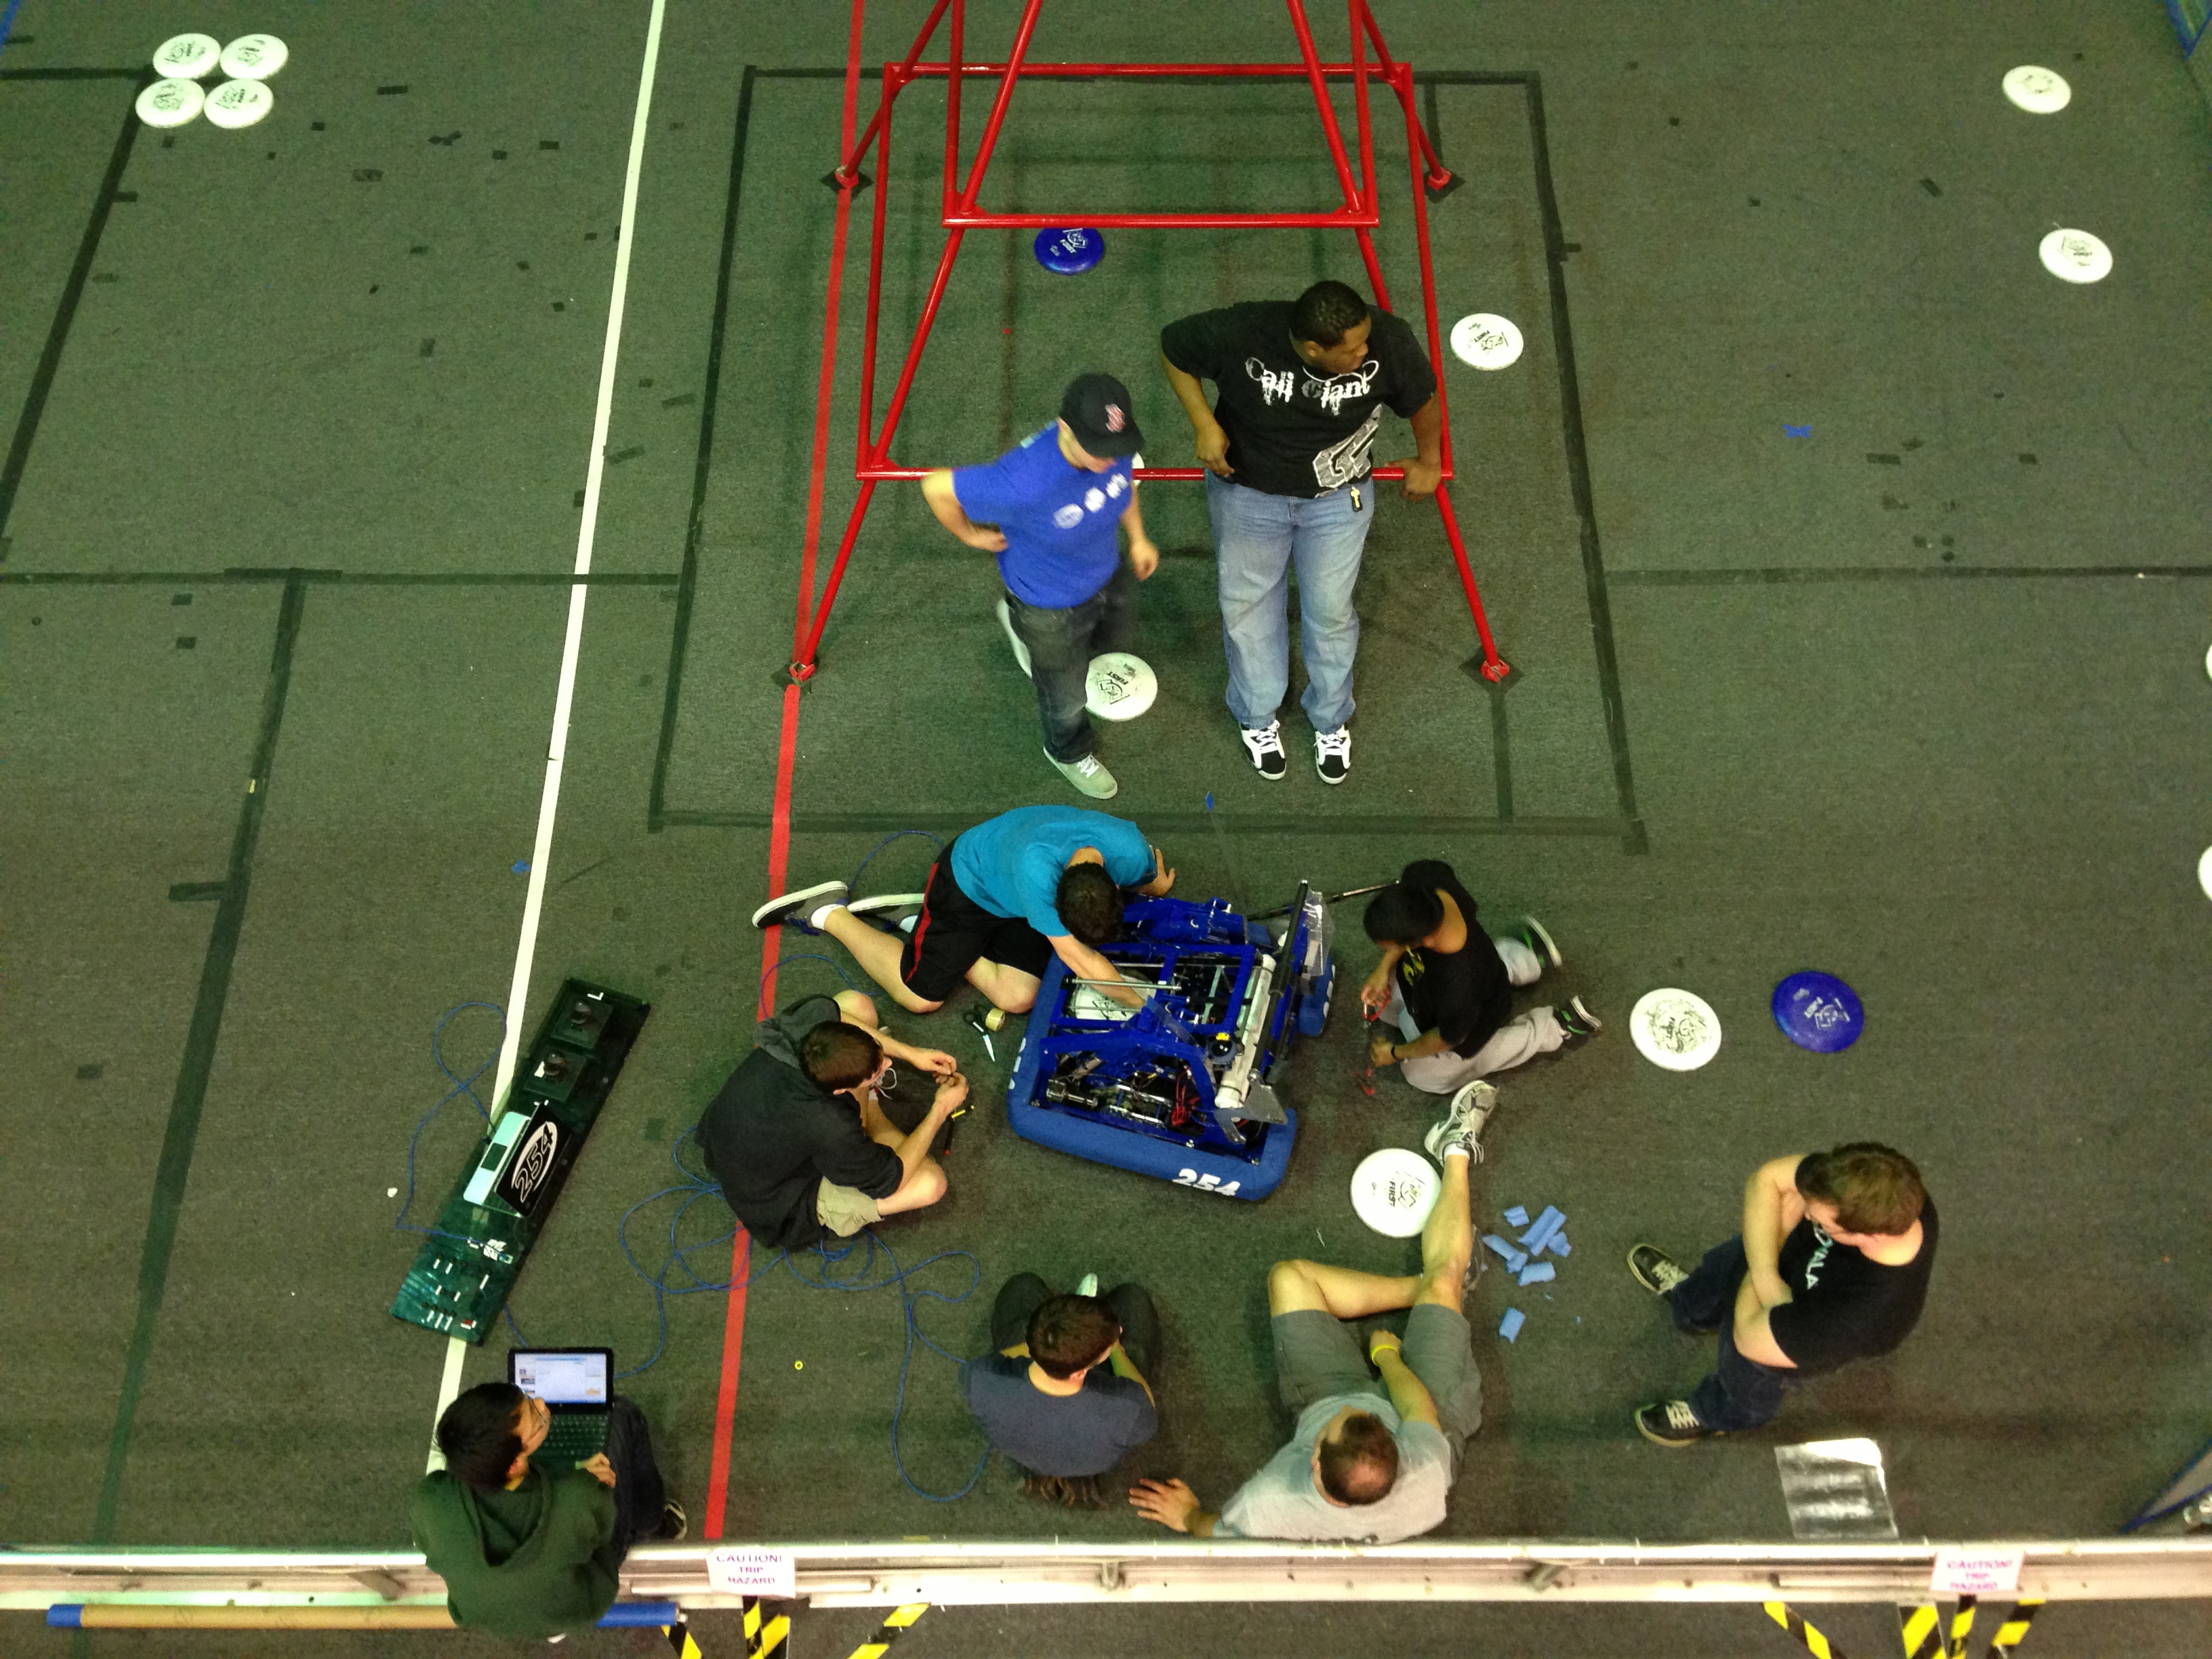
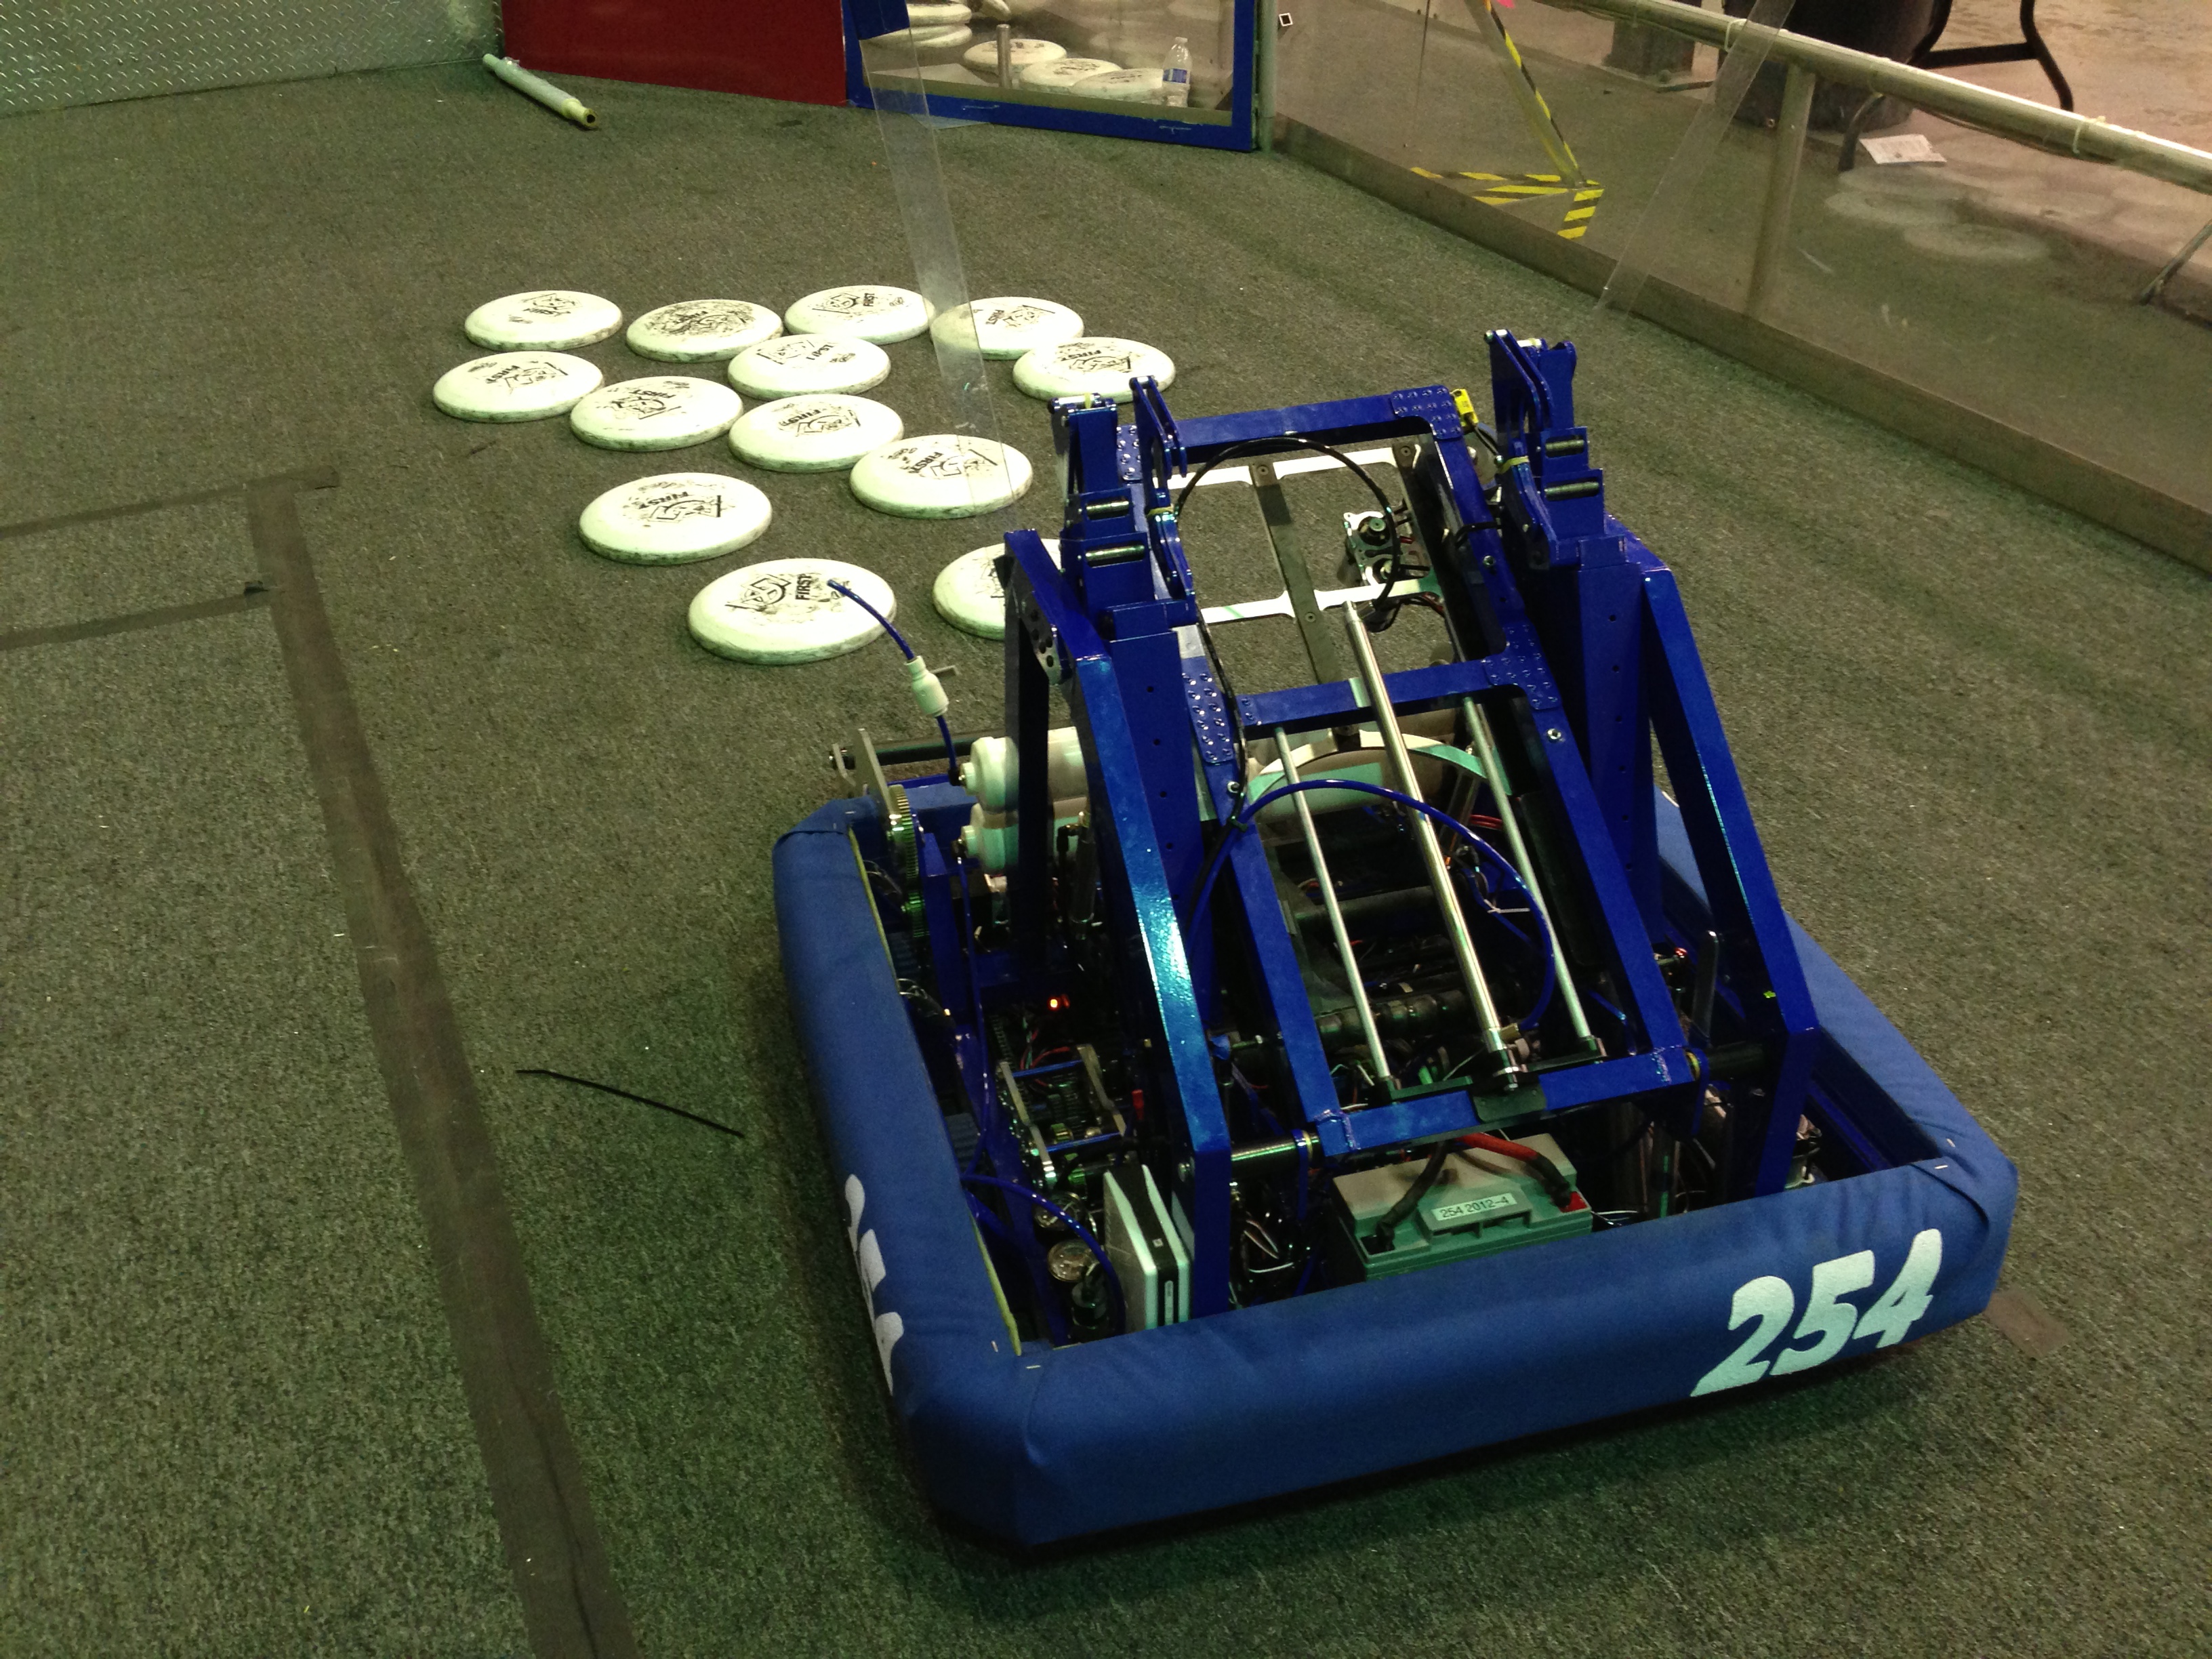
Today the lab was opened for Teams 4543 (Apollo High School) and Team 971 to use our field for calibration and driver practice, while working on bugs in preperation for SVR (where both robots will be competing).

Driver Practice

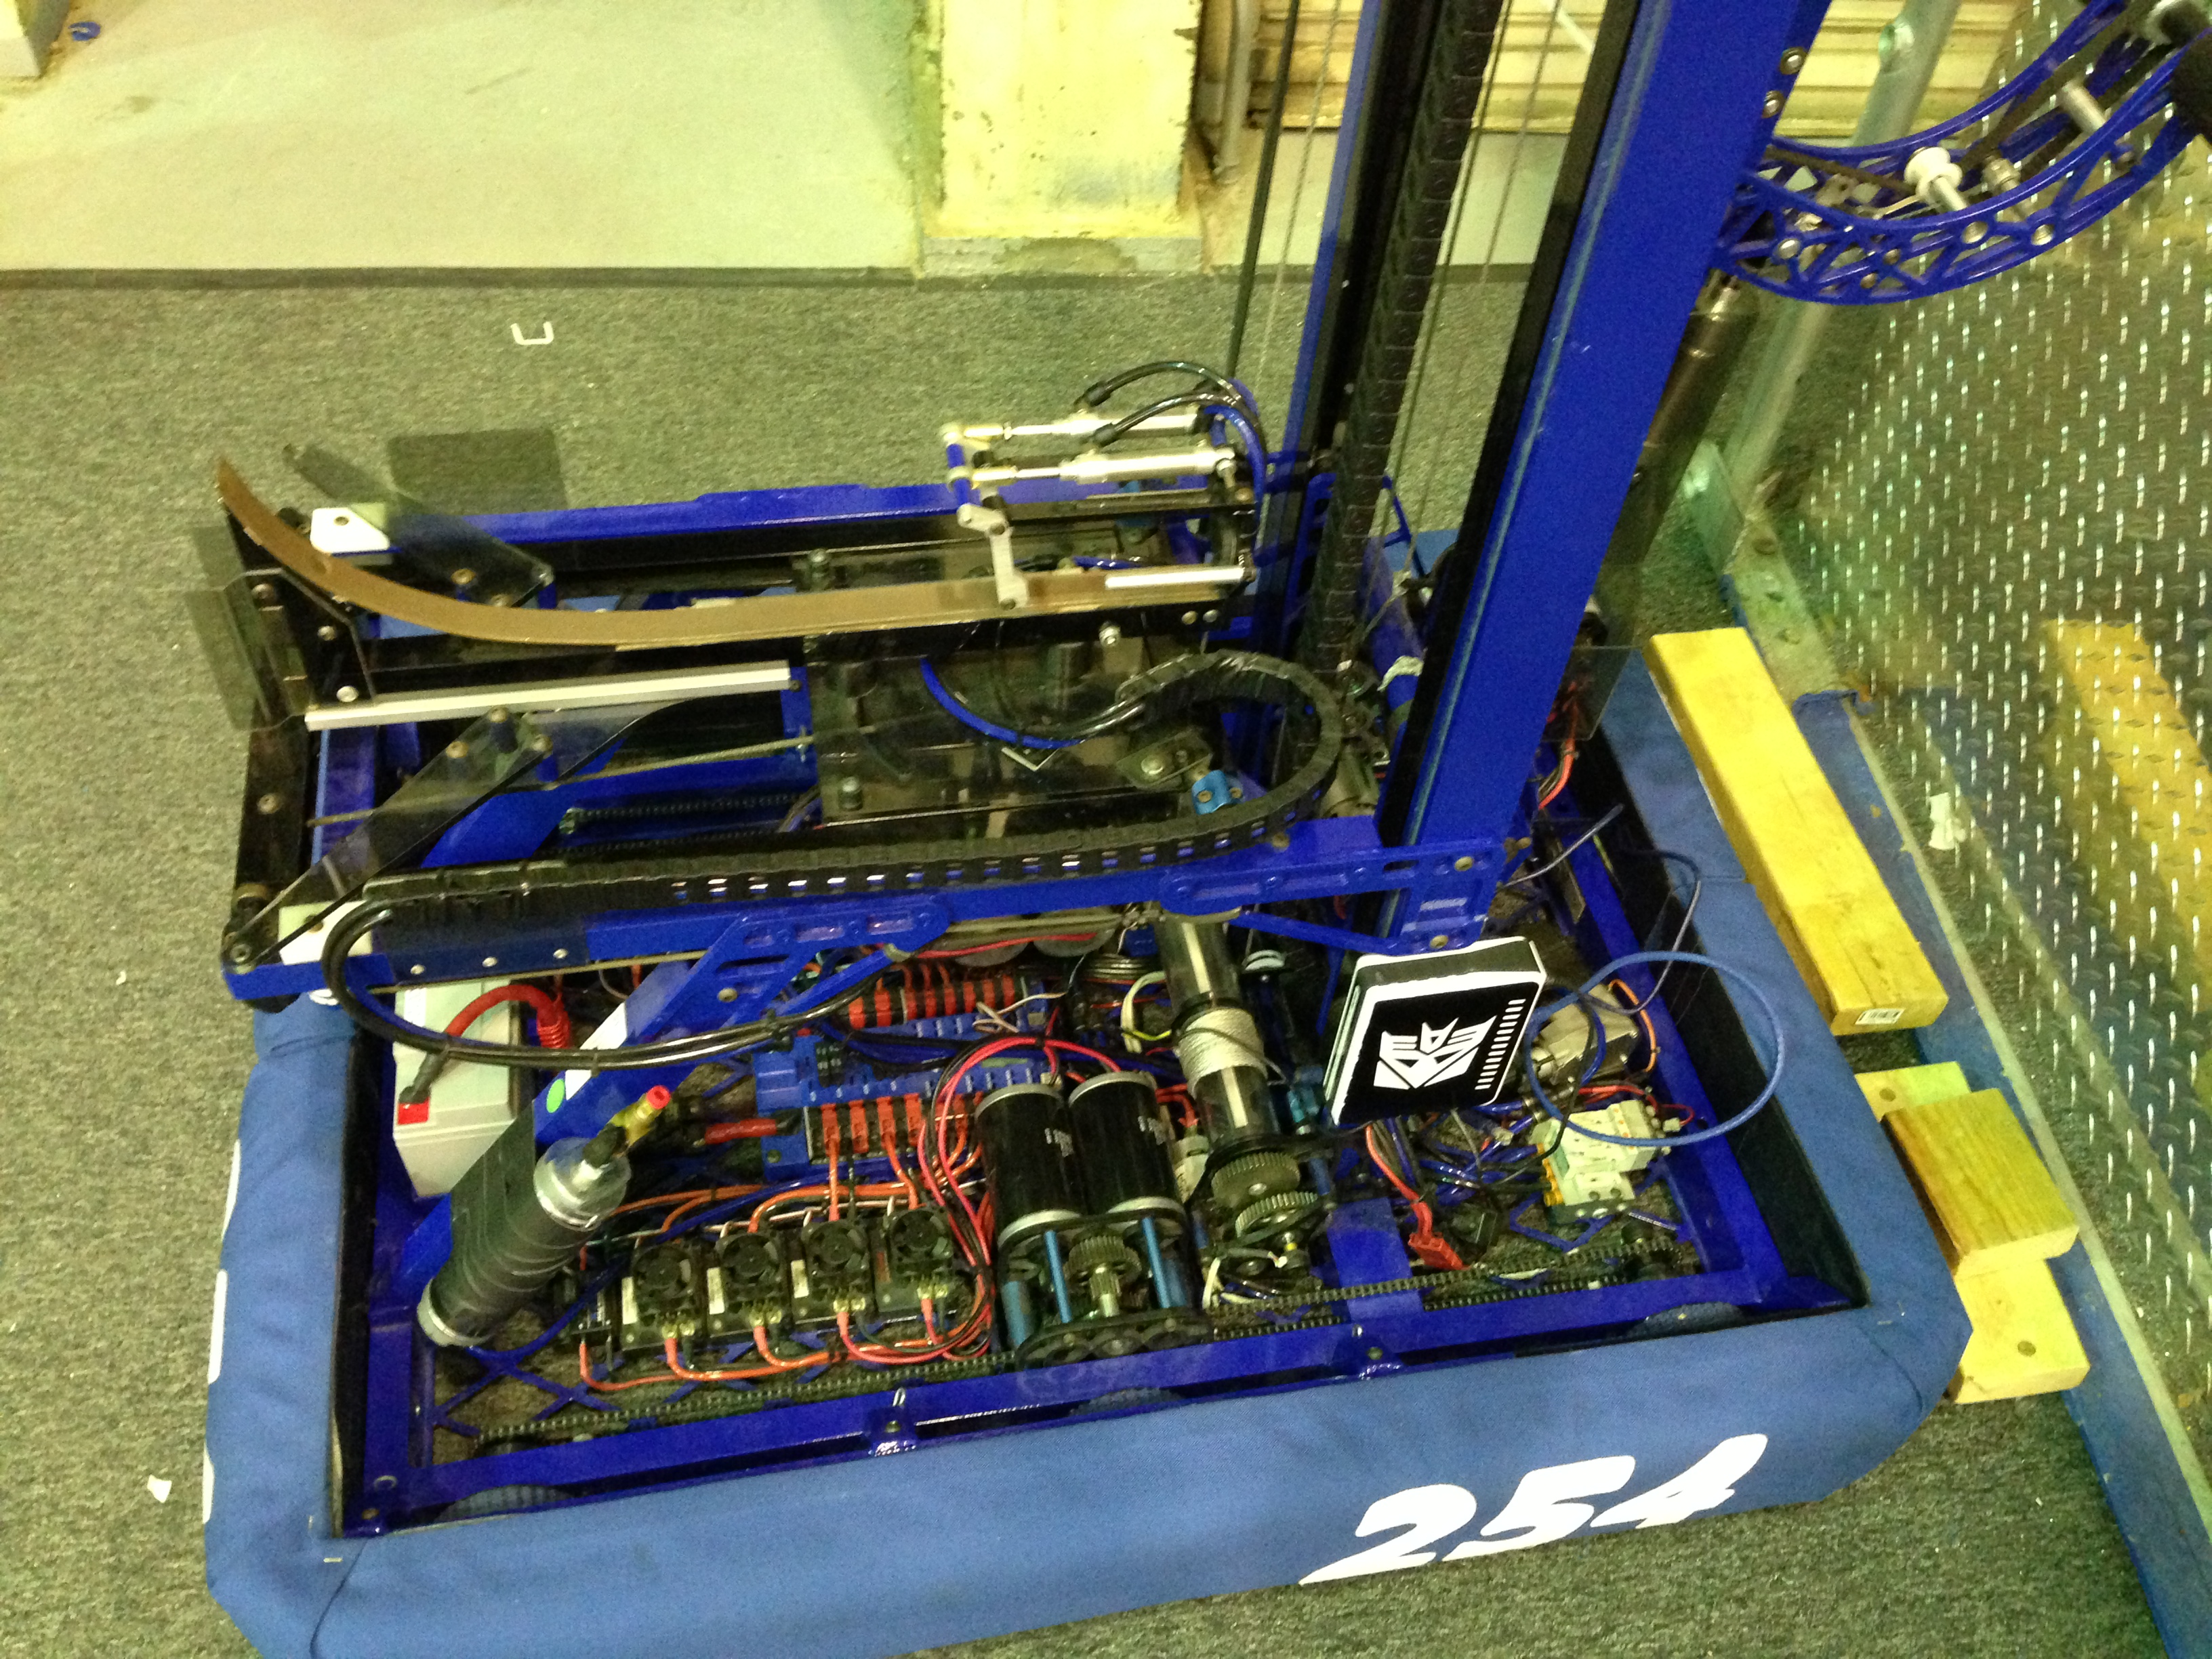
Today Driver Abhi Kumar, and Operators Chris Sides and Scotty Cardona all practiced on the field, specifically picking up discs from the area around the pyramid and shooting into the high goal from the pyramid. The robot was about 76% accurate (data taken by scouts). We hope to improve accuracy to over 90% before SVR. One of the main points of improvements are the BaneBot shooter wheels that need replacing.

Team 254 Blog_April 1_by Chanan Walia_004
Nick Mercadante replacing the battery

Chairman's Award

Today students took many major steps in preparation to present the Chairman's Award at SVR. One aspect of this work was the development of the the team binder, with students formatting the various pages of the binder. Additionally the presenters (Richard Lin, Alex Powers, and Nagy Hakim) prepared for the judges interview, working on the power point and the question and answer section.

Manufacturing

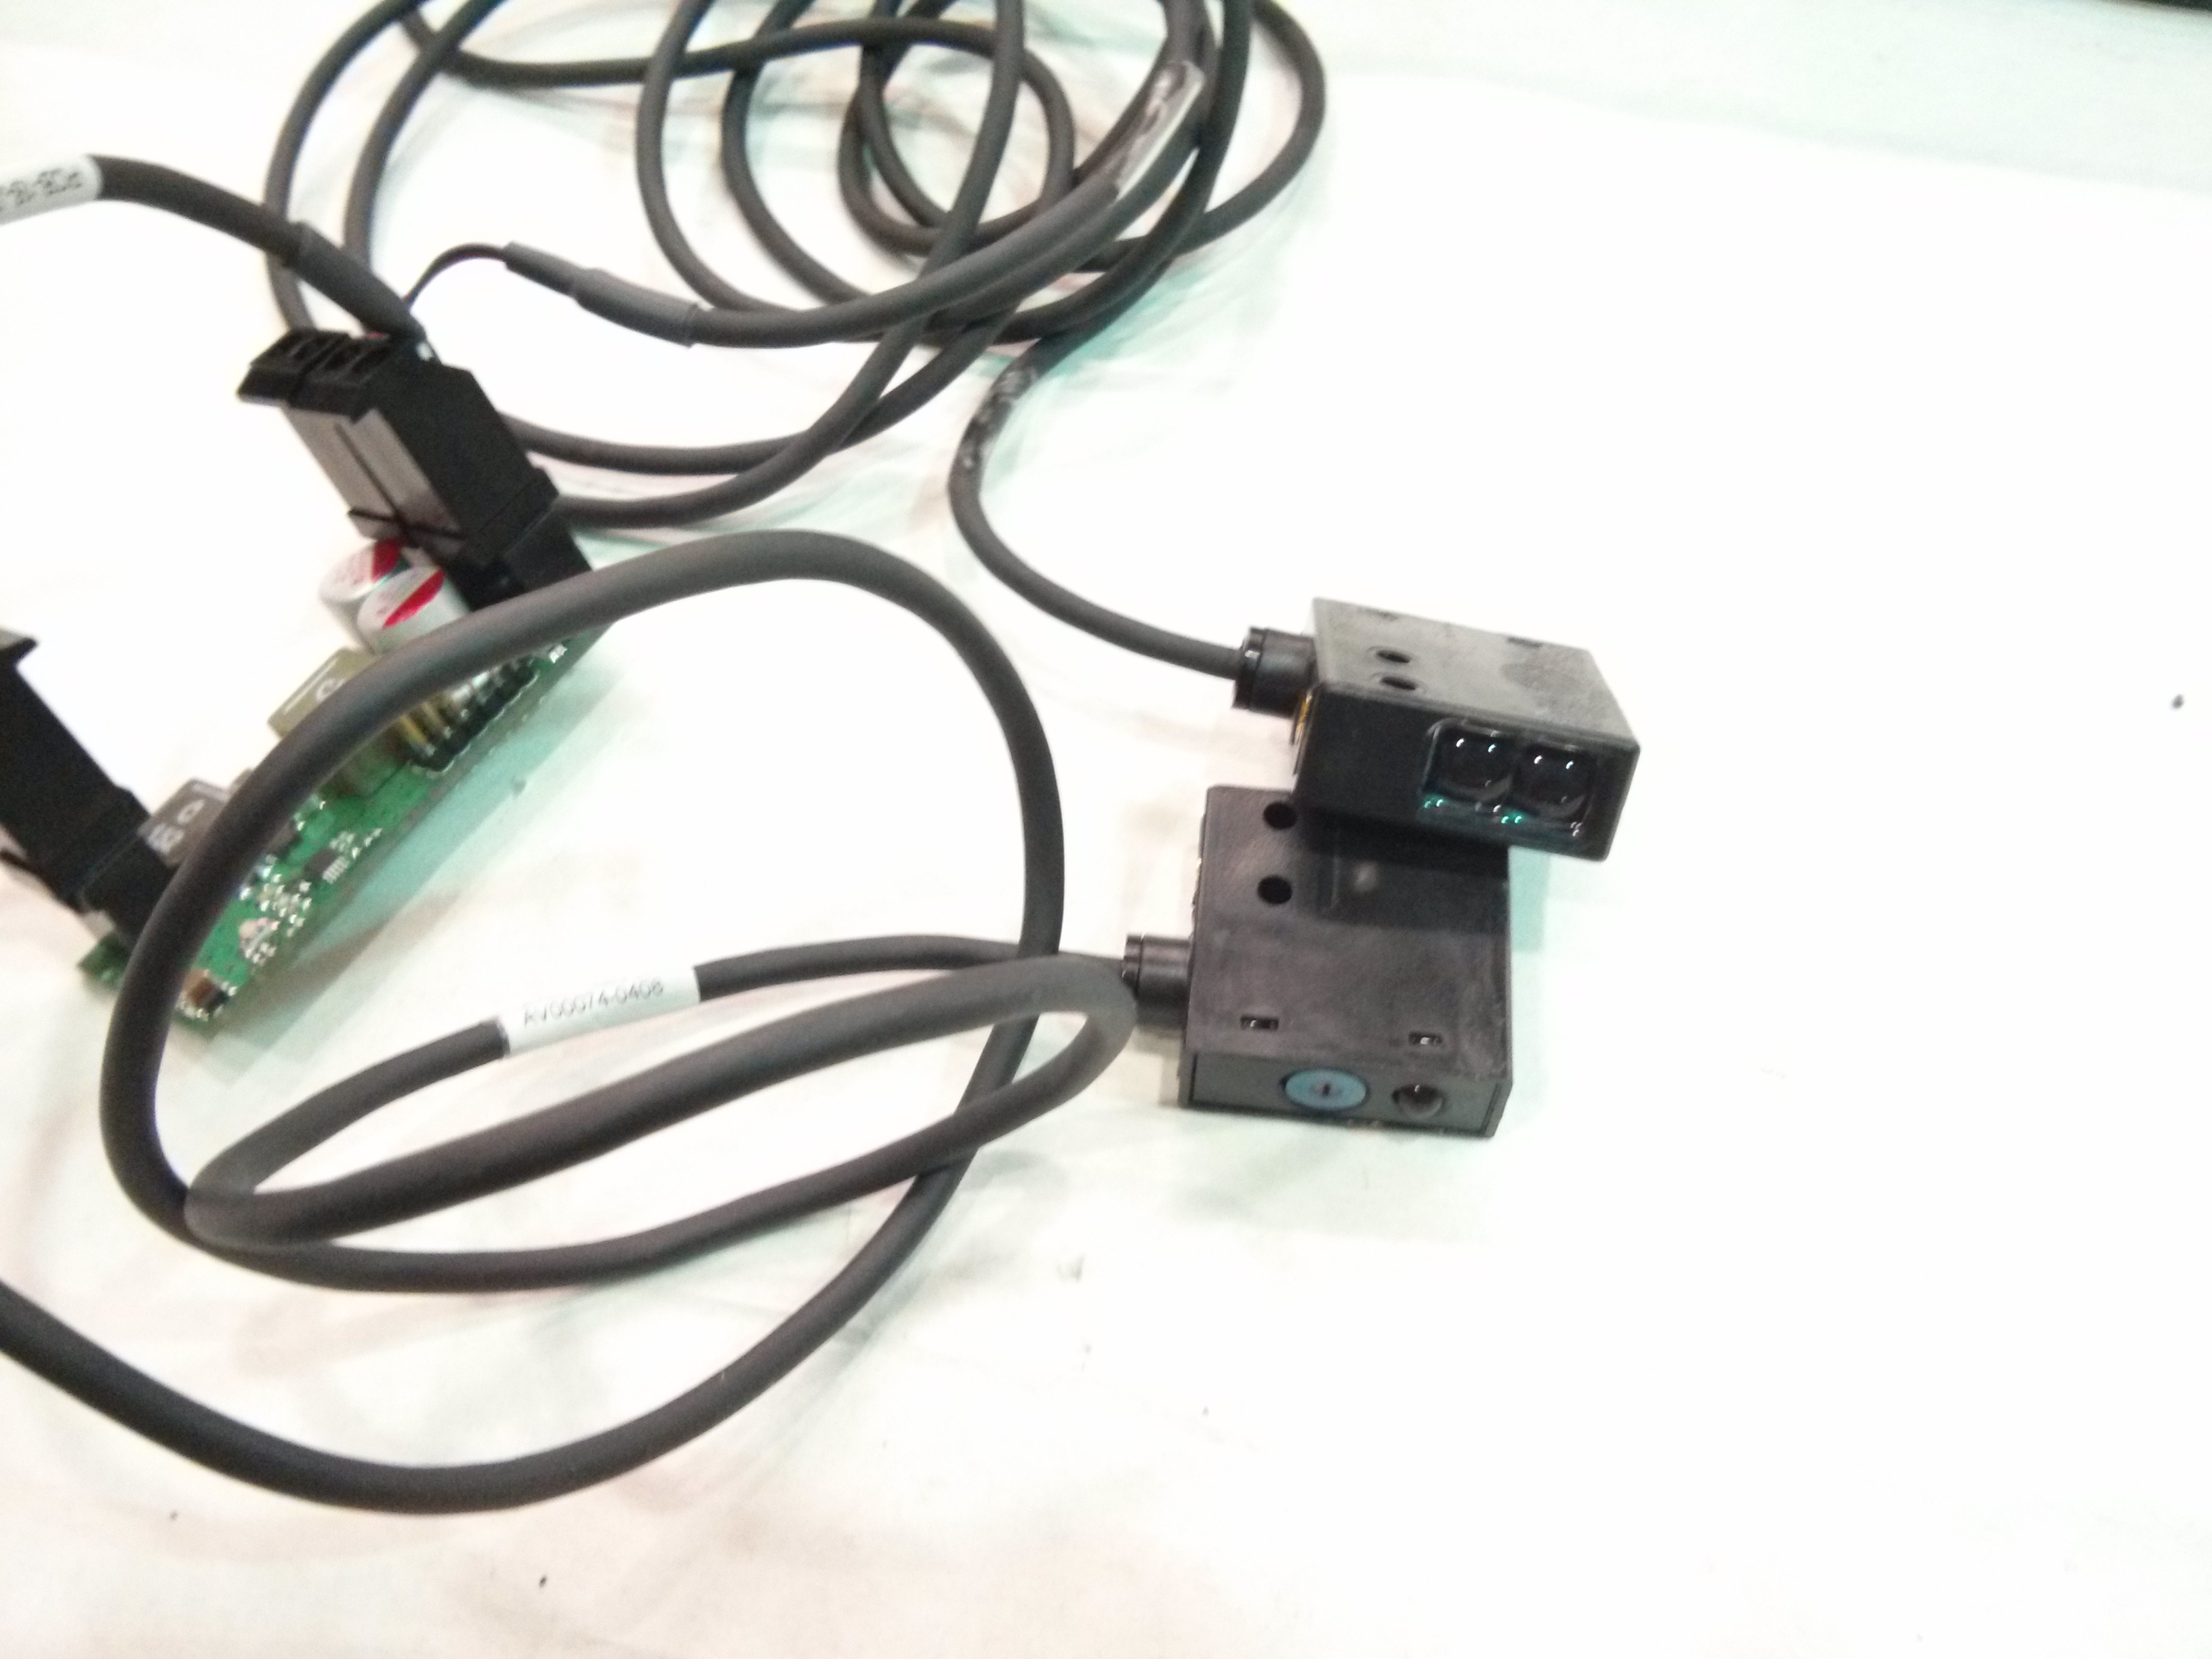
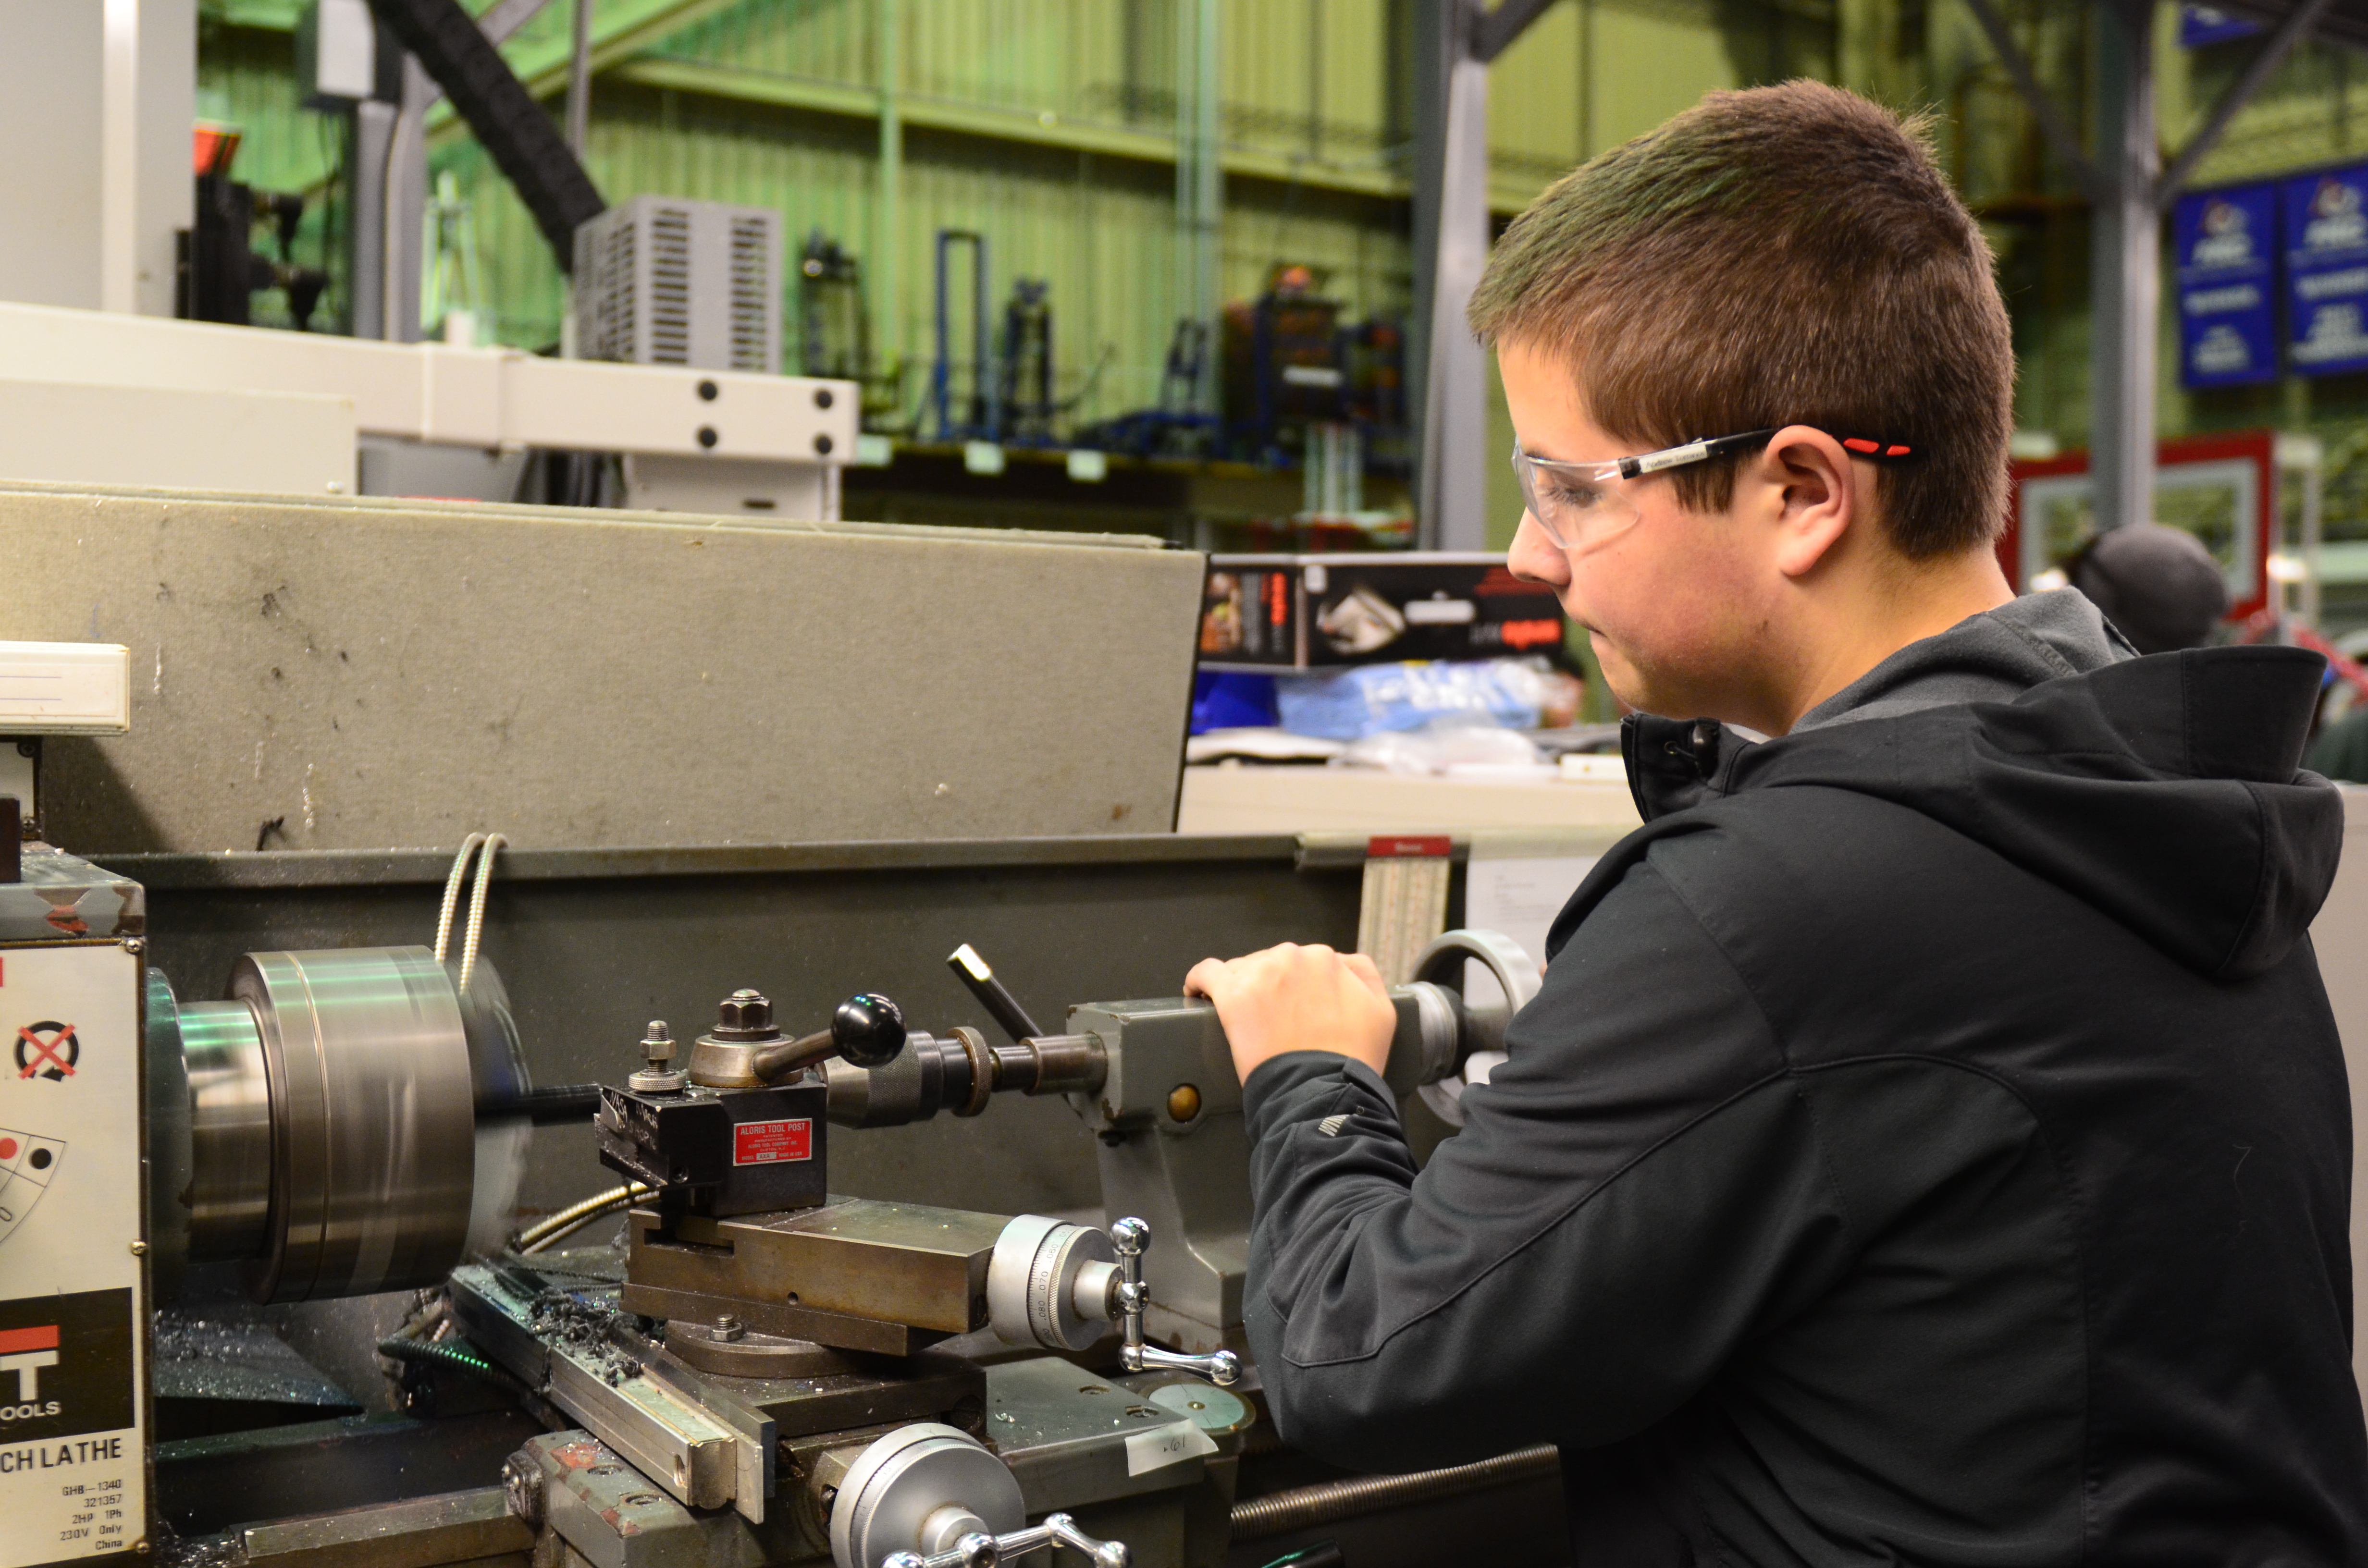
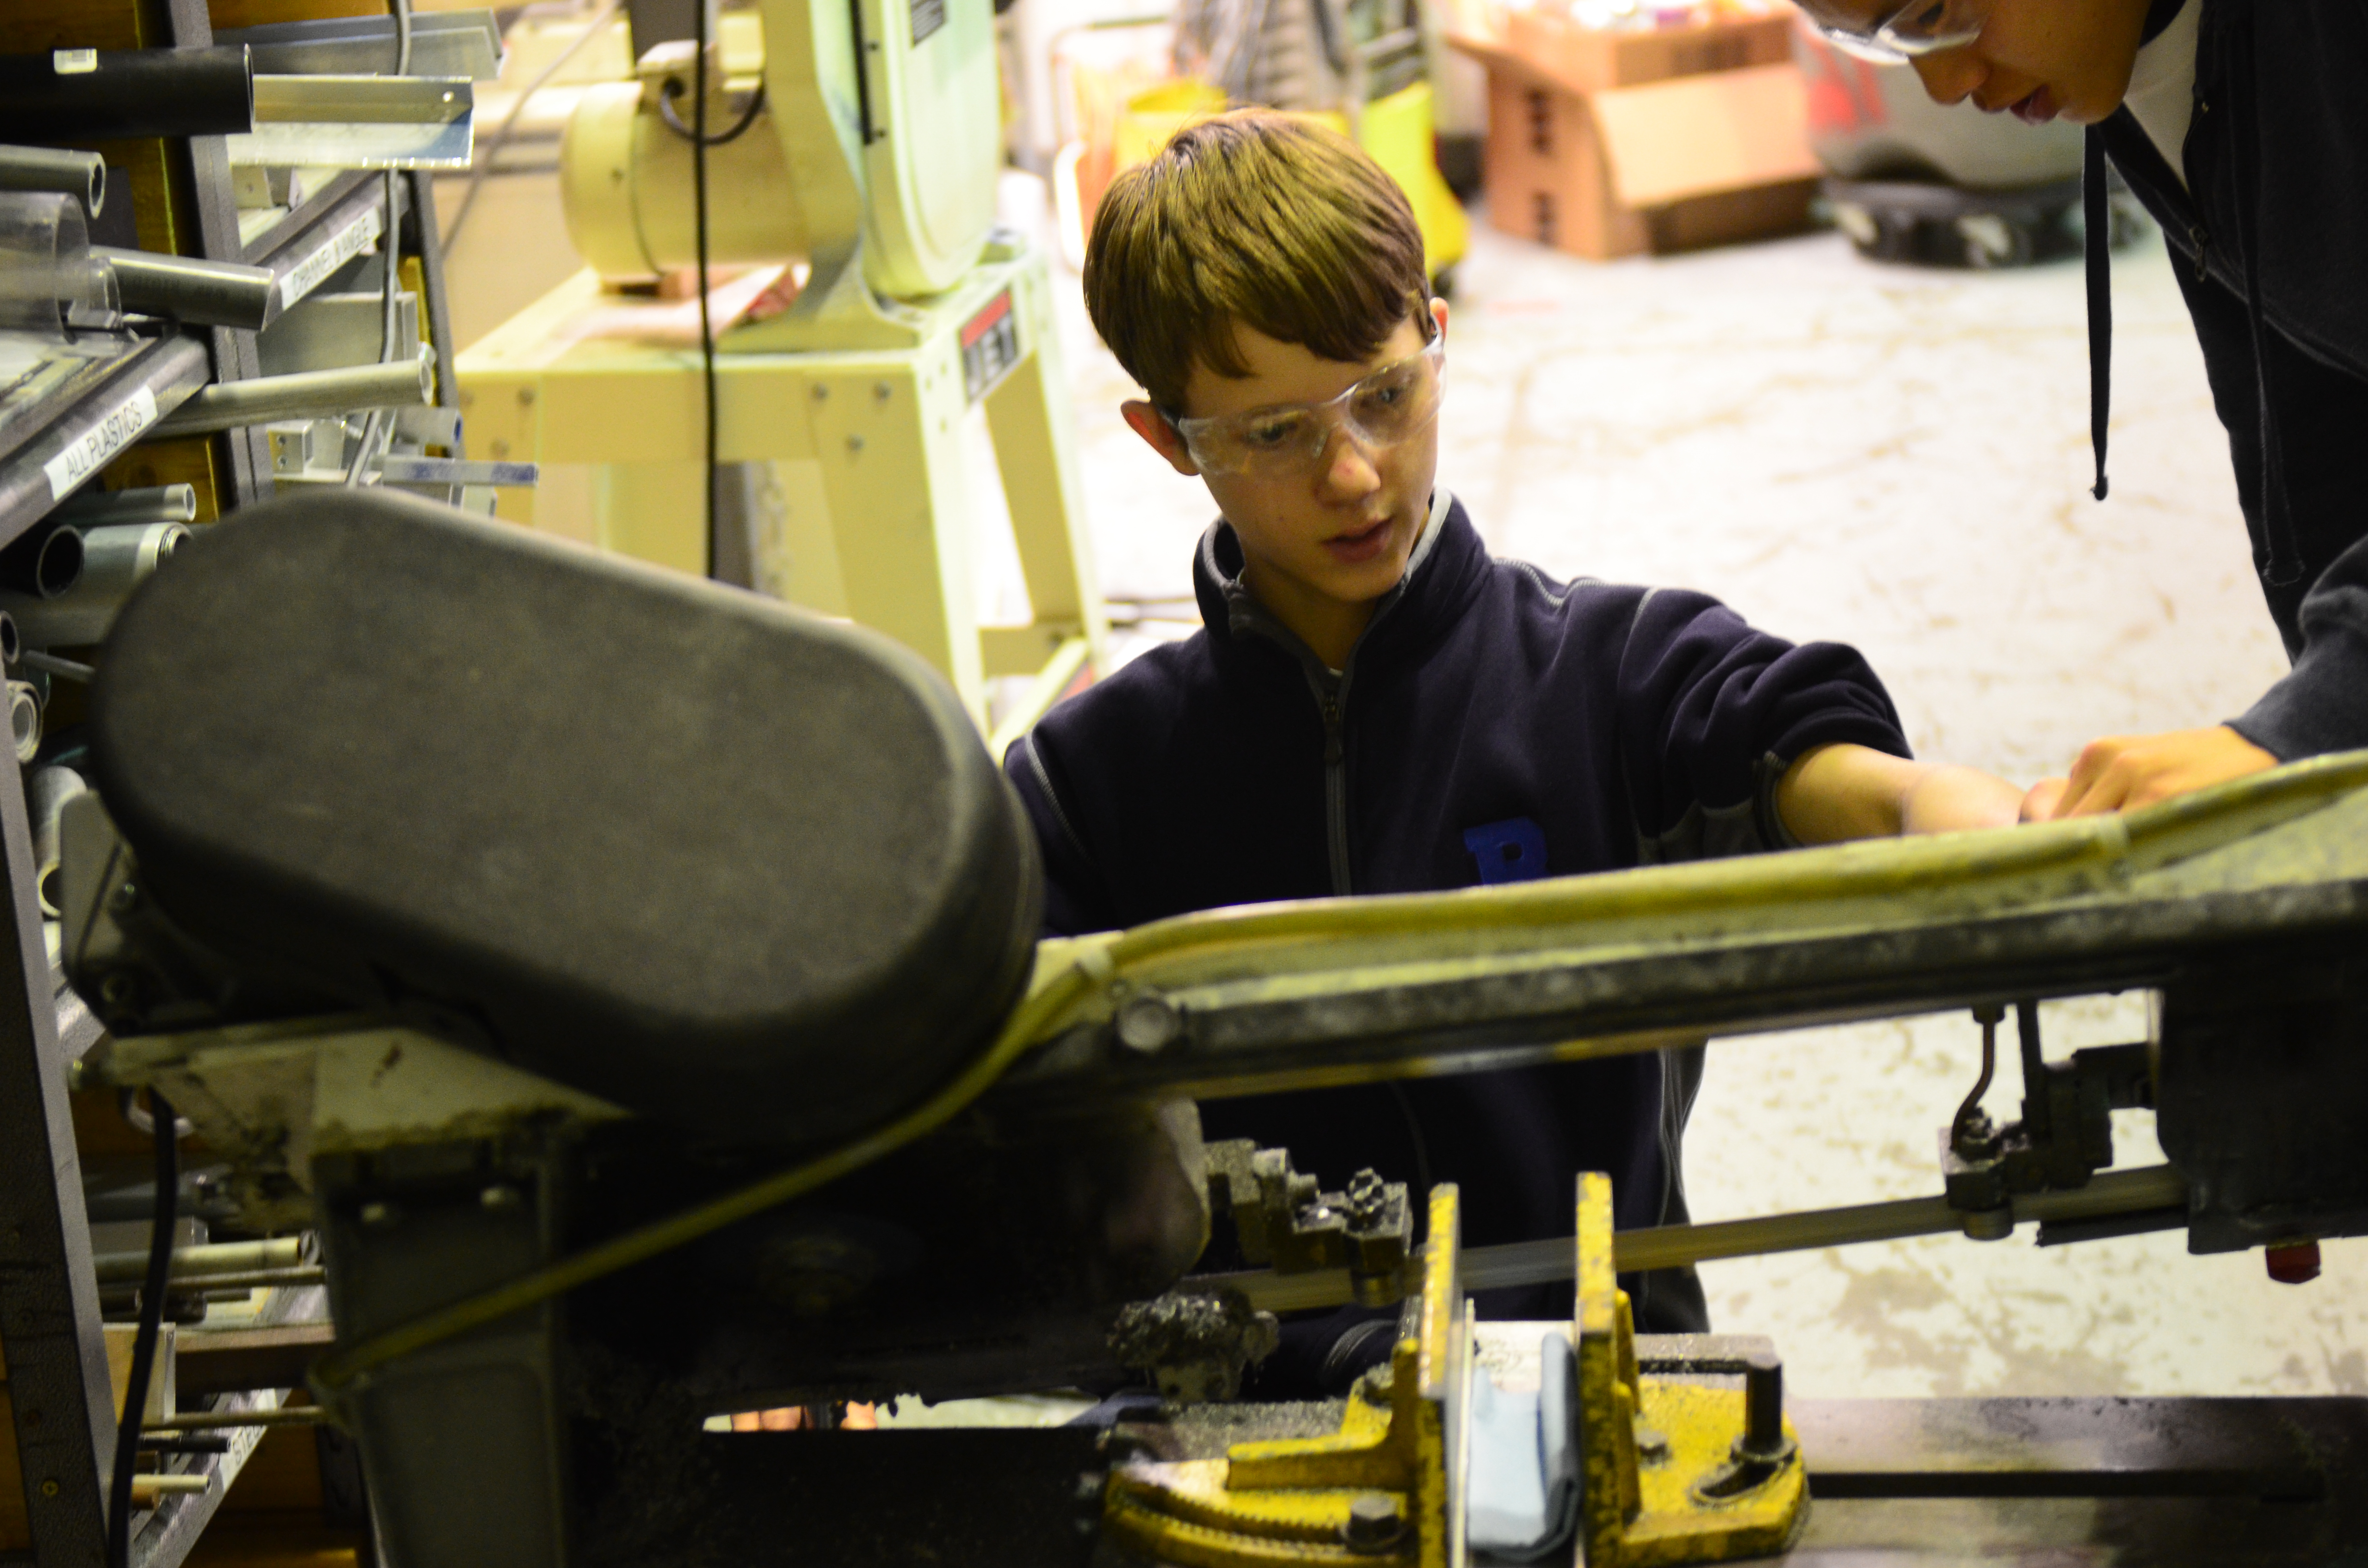
Students constructed beam sensor mounts for the robot. These beam sensors will be used to determine whether or not a disc has reached the back of the conveyor to be properly indexed.
Team 254 Blog_April 1_by Chanan Walia_002

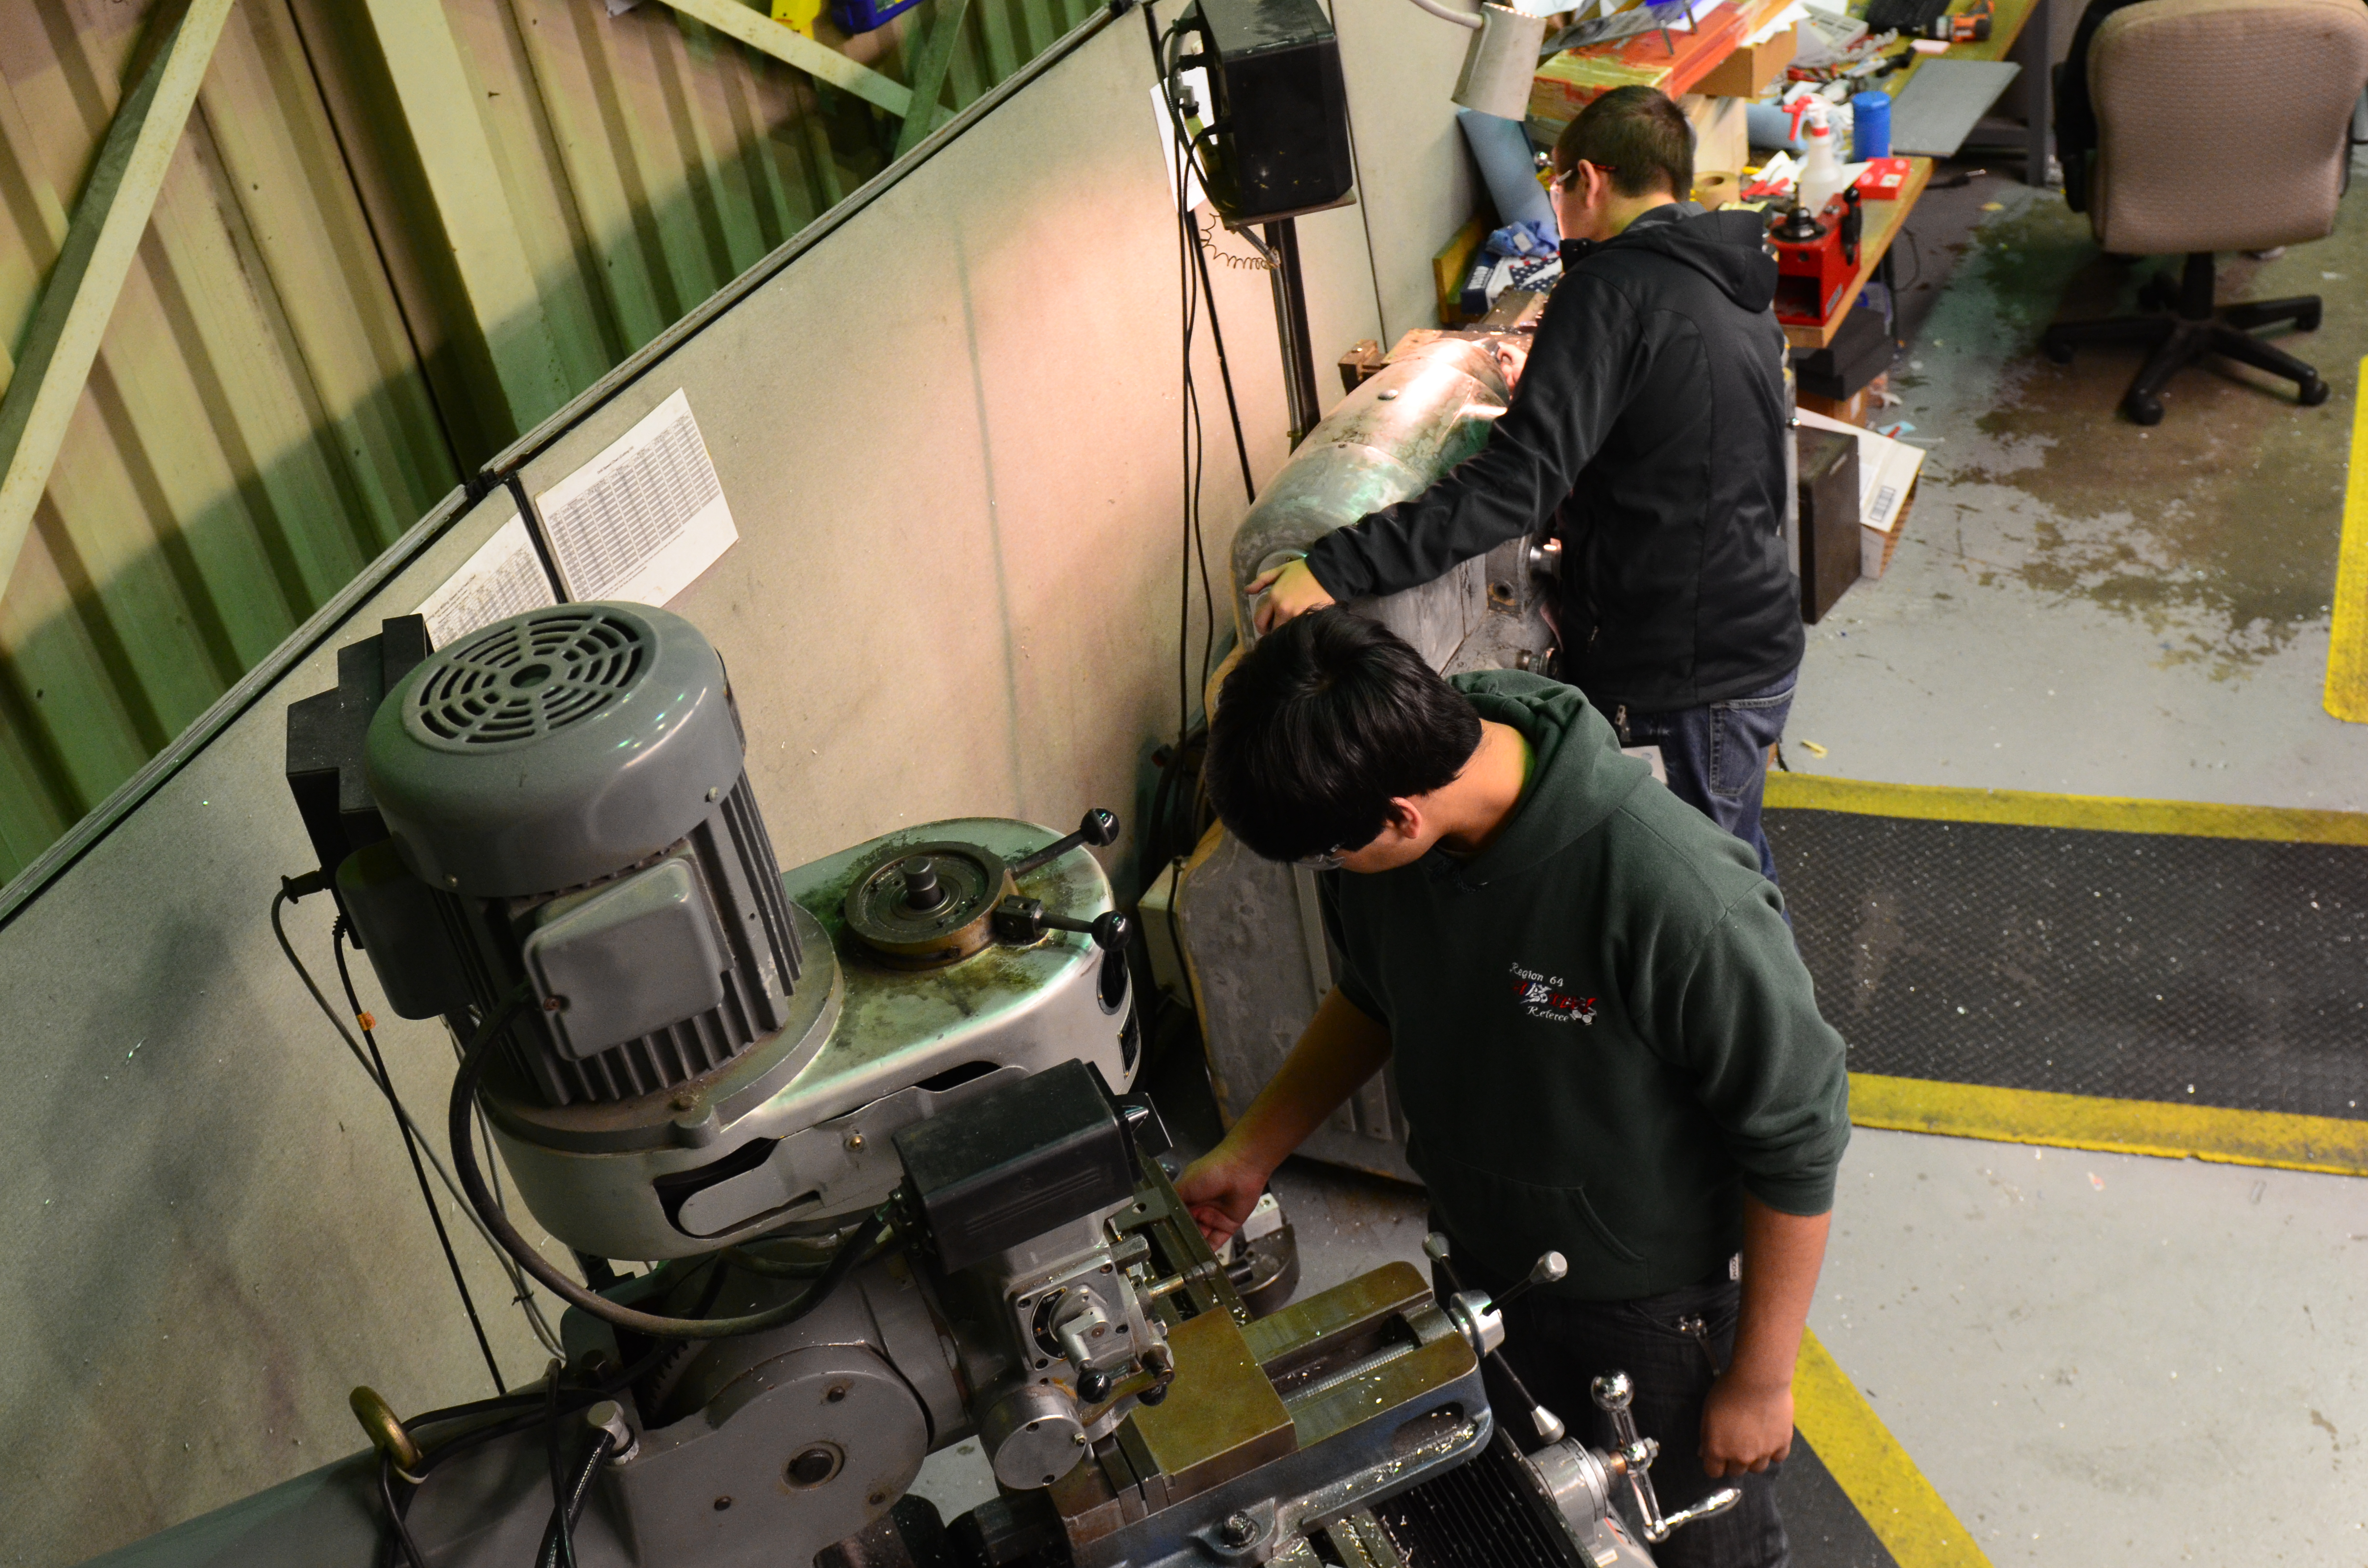
Andrew Torrance machining shafts
Team 254 Blog_April 1_by Chanan Walia_003

Joshua Vincent cutting sensor mounts
Team 254 Blog_April 1_by Chanan Walia_005

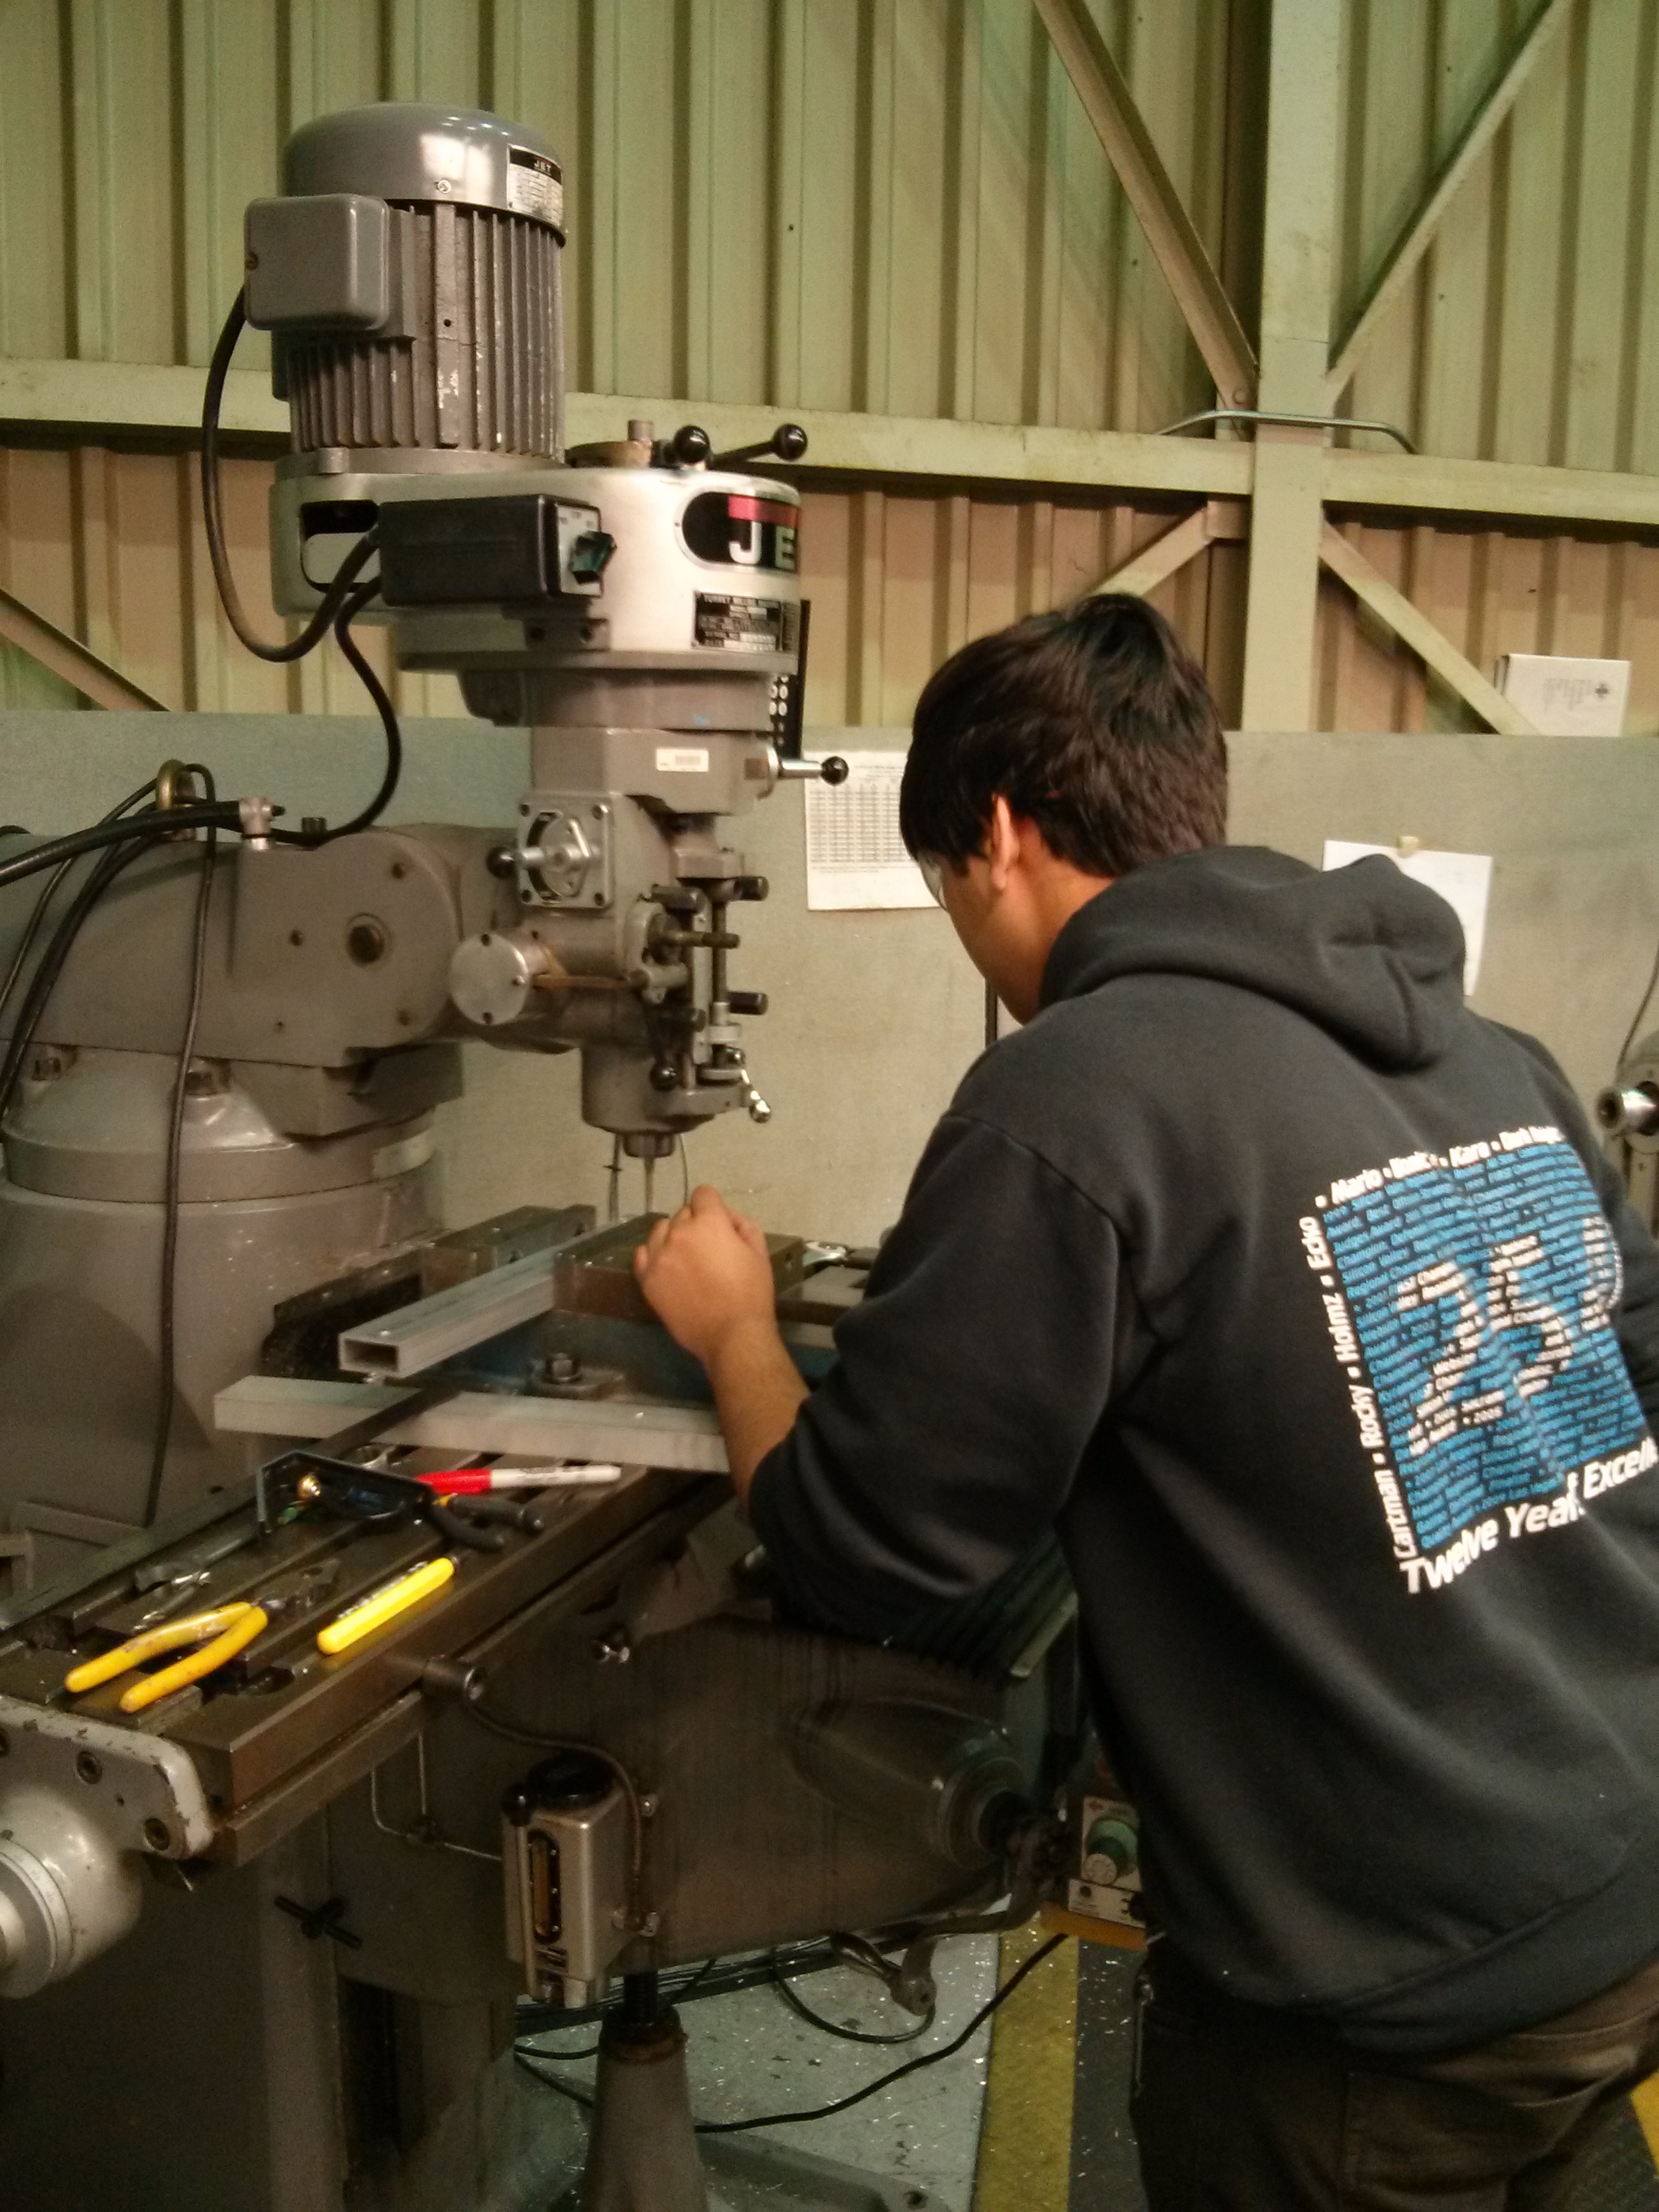
Mani Gnanasivam milling parts

Hanger

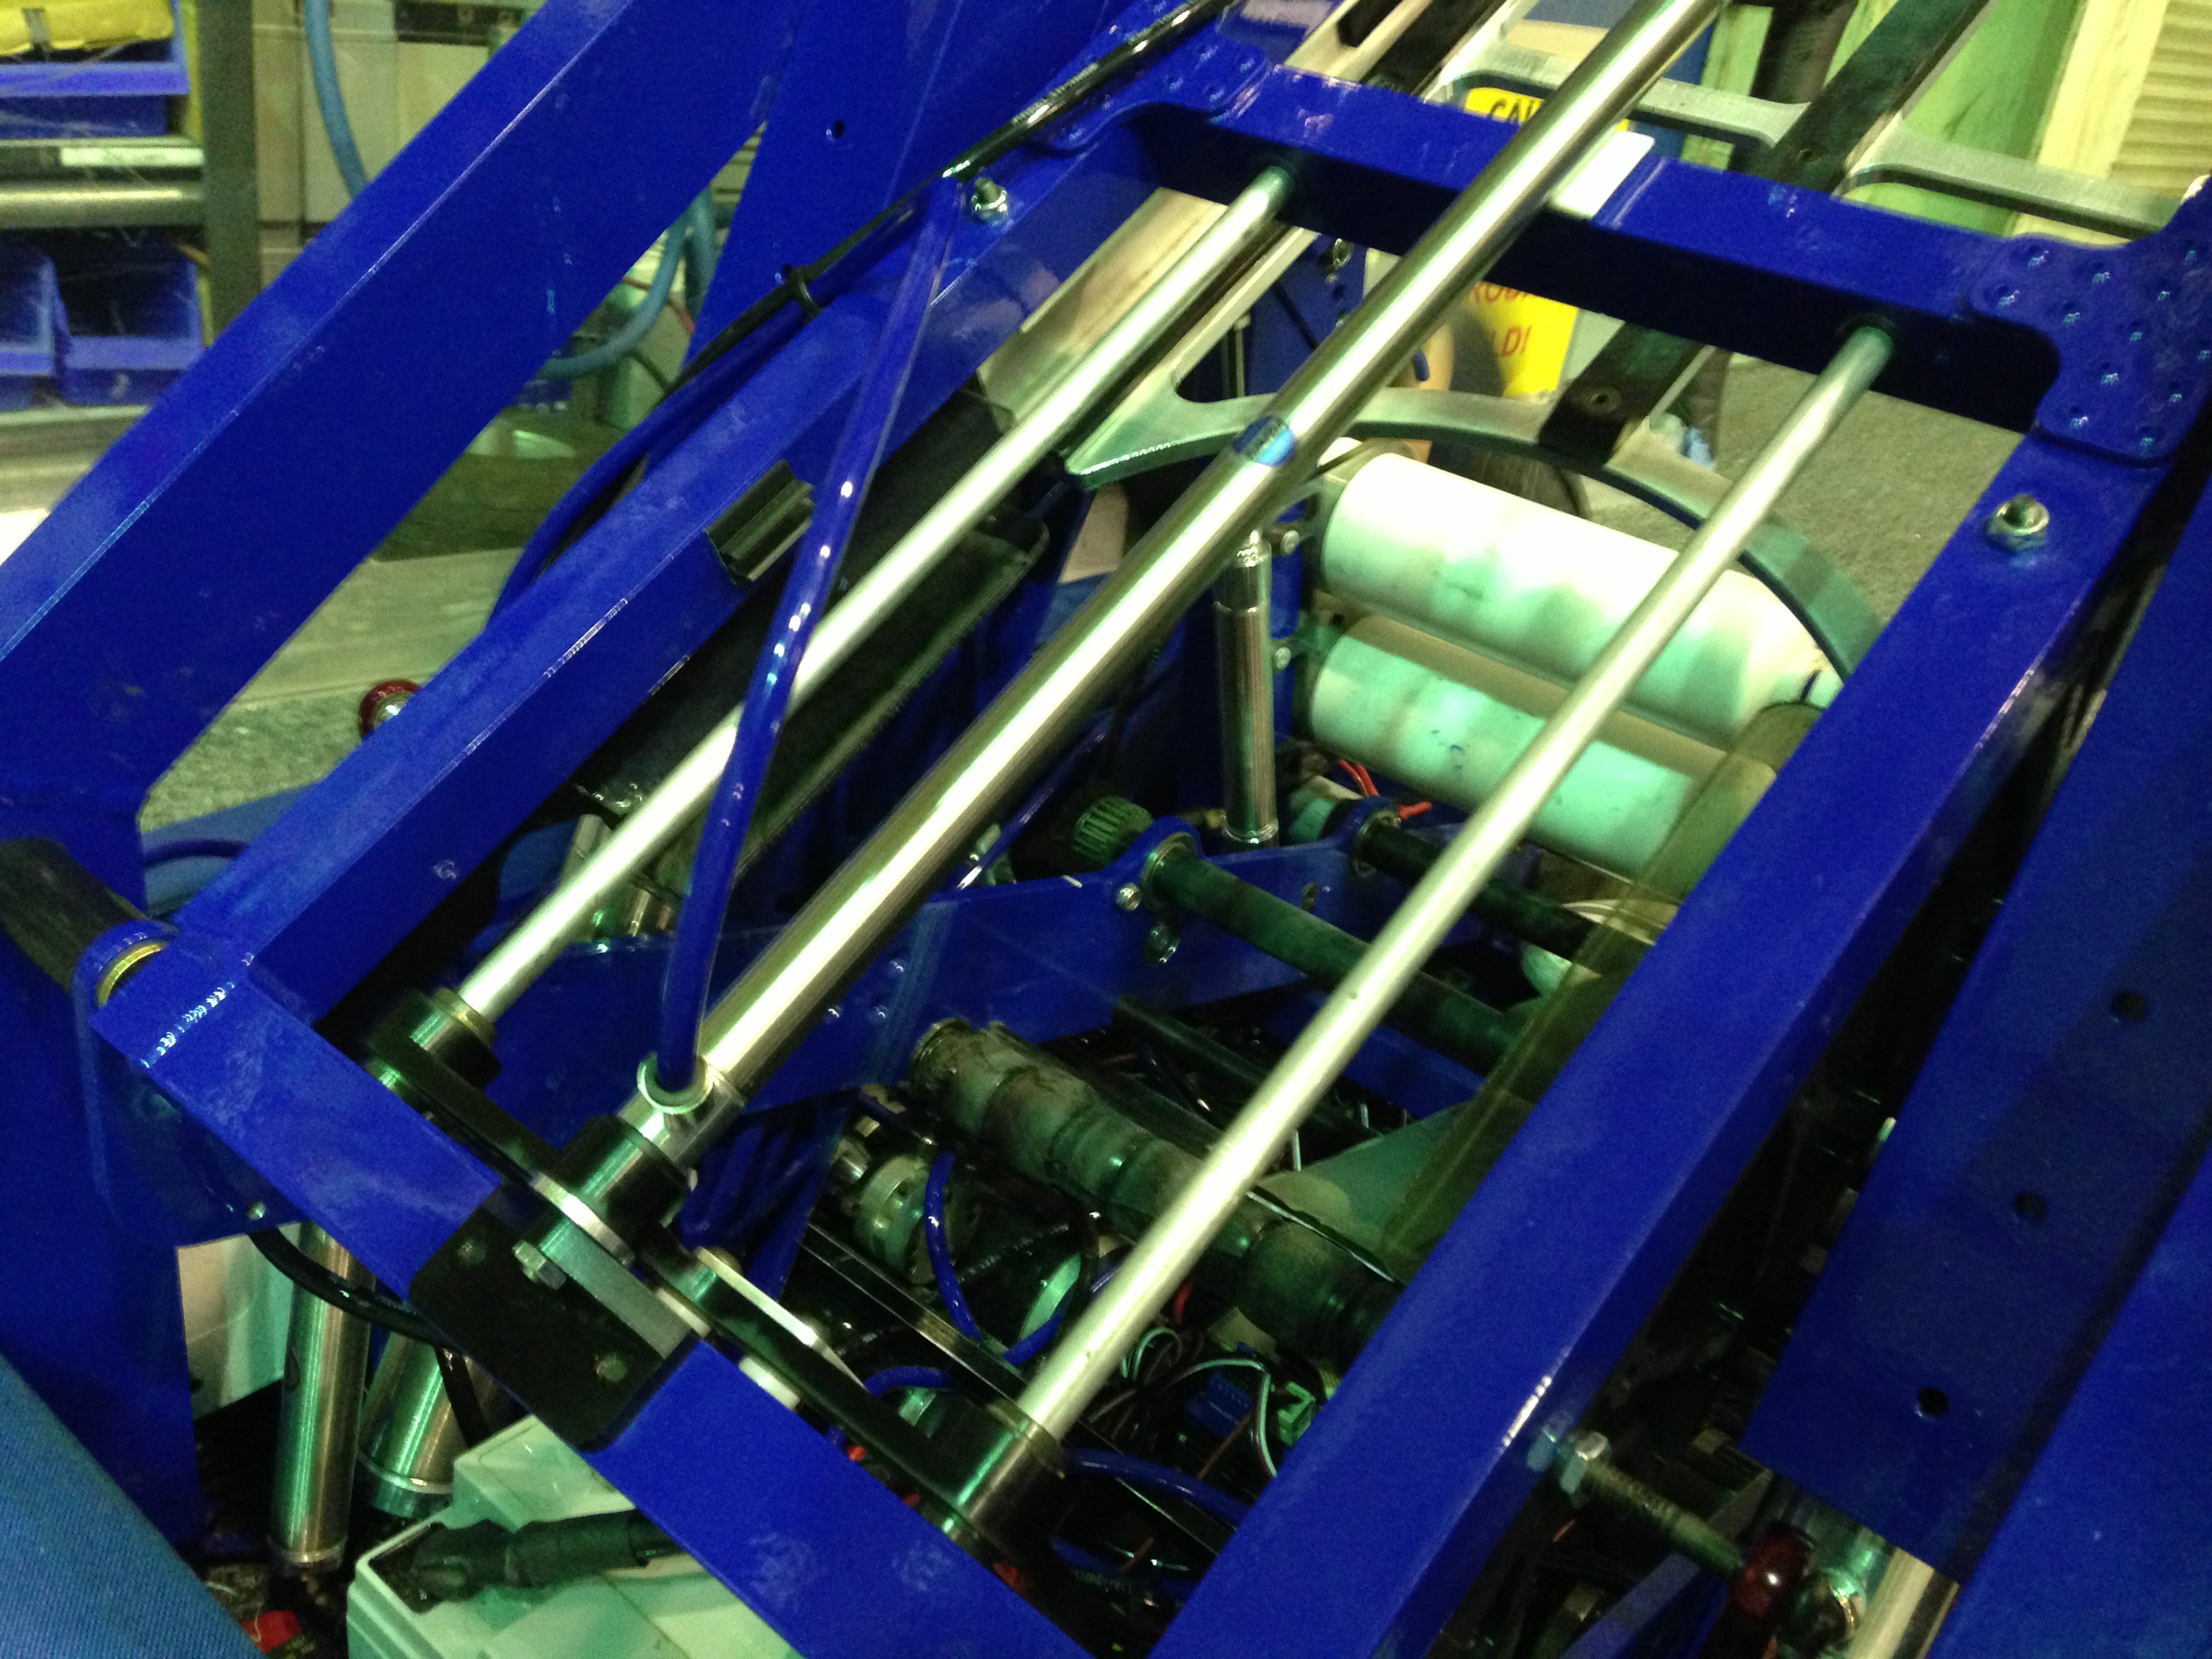
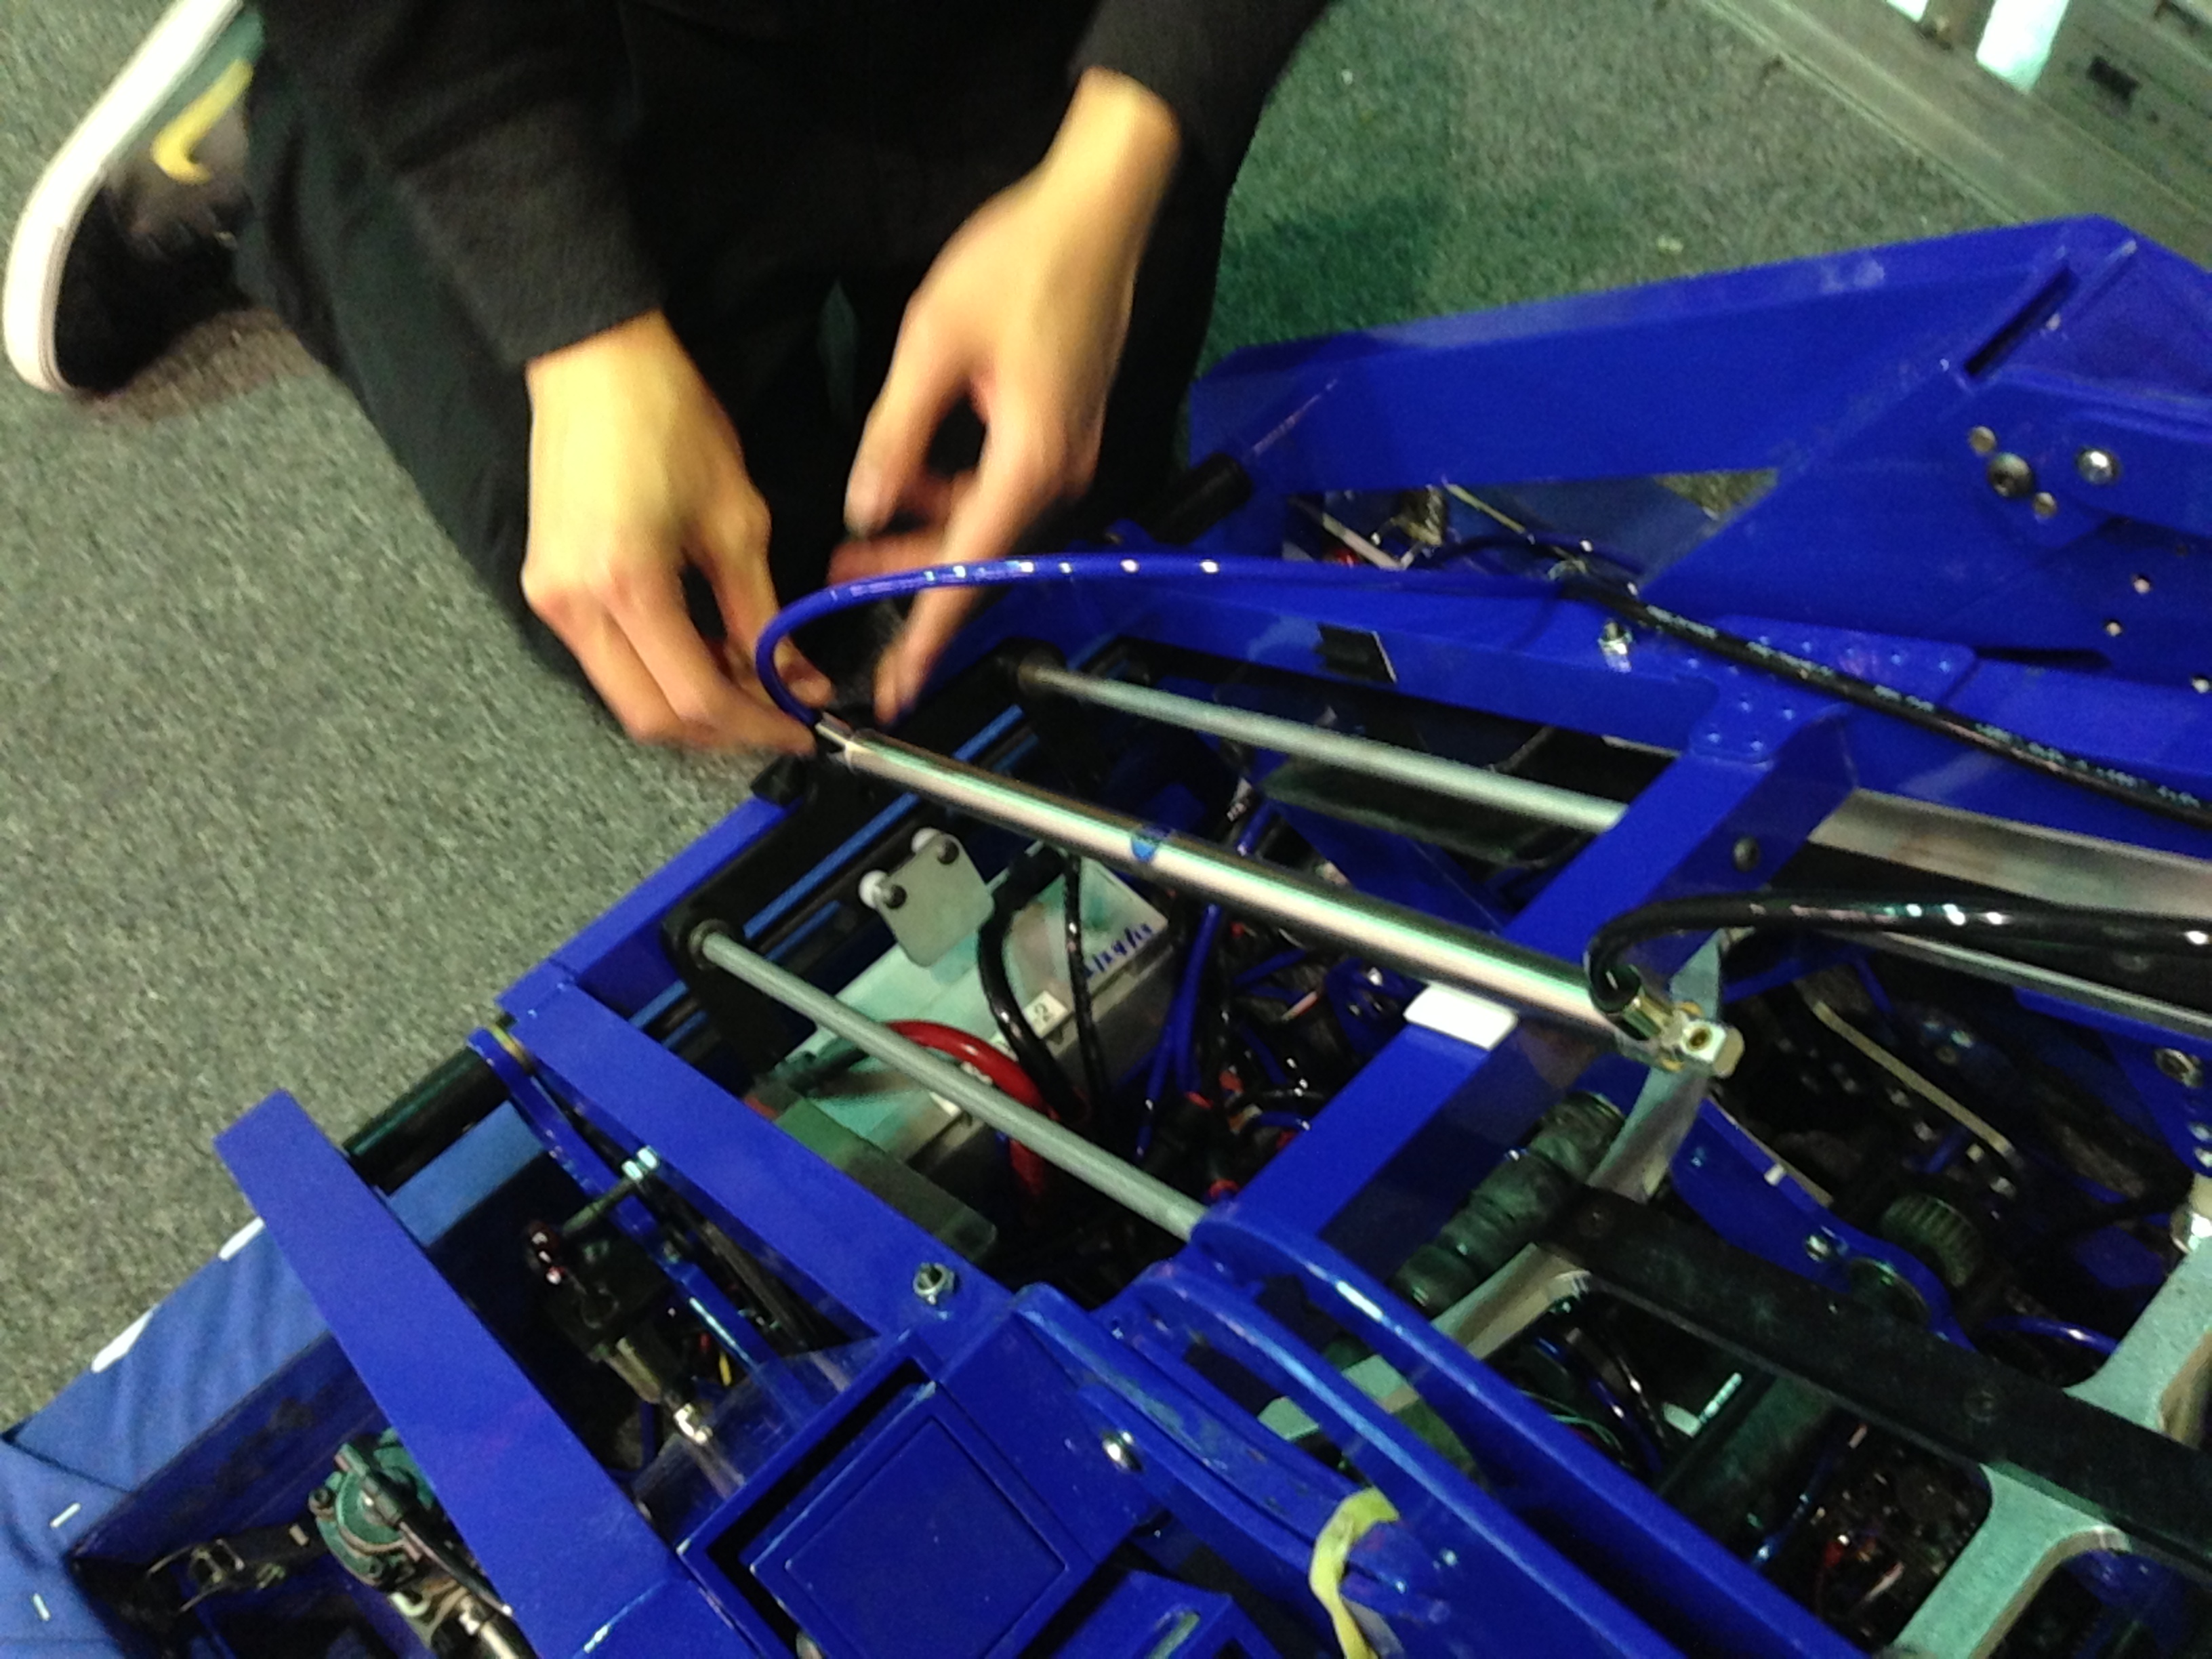
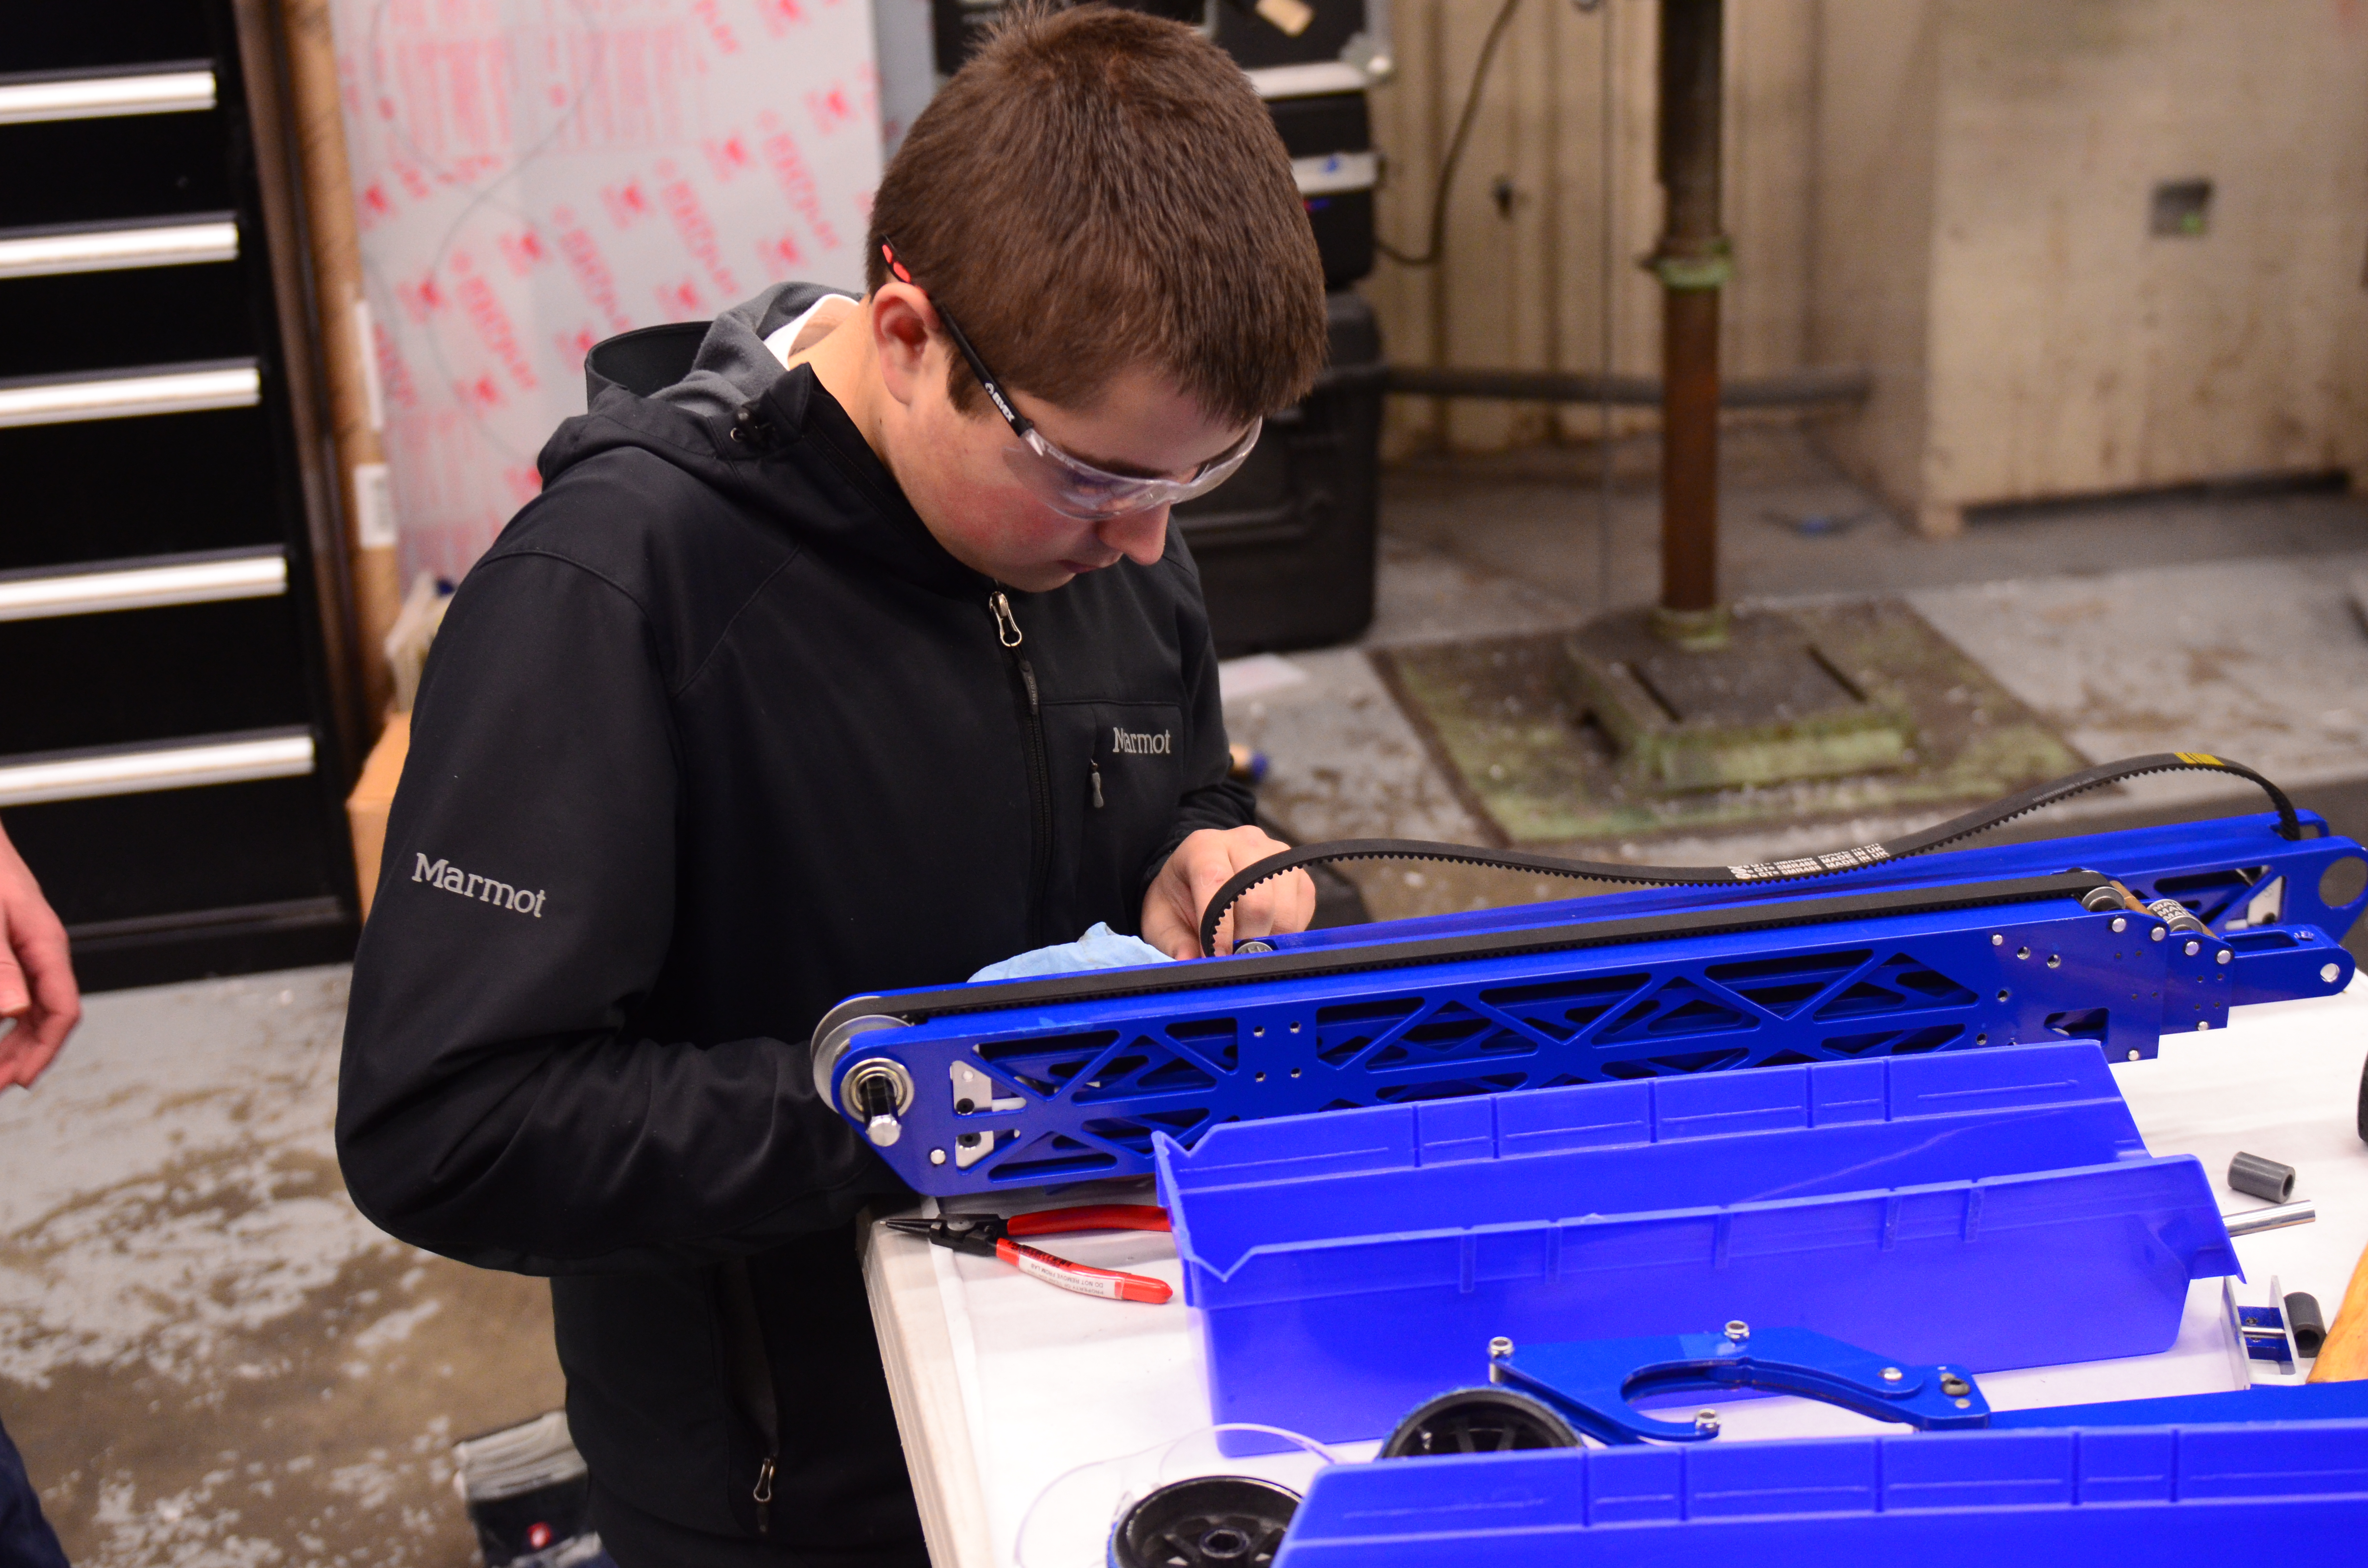
Furthermore, the development of the hanger continued, with elevator belts being tensioned, and manufacturing shafts for the belt. Two of the three new hangers are ready to be attached to the competition bot, with the third functioning as a spare to be put on either side; due to this orientability, it will not be fully assembled until it is attached.
Team 254 Blog_April 1_by Chanan Walia_001

Andrew torrance assembling the hanger

 Lab closing time was: very late.
Pre-SVR Day 15: Hanger Assembly

2013 FRC Build SeasonFIRST Robotics

Hanger

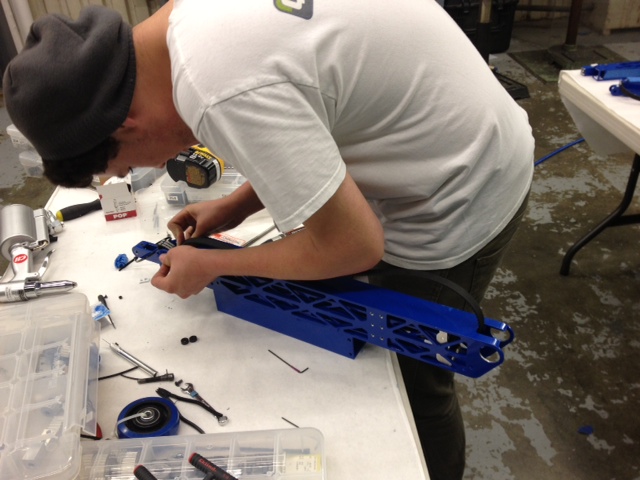
The highlight of today was beginning assembly of the hangers for the competition robot. We plan to finish fully assembling these soon. We are constructing 3 identical hanger assemblies so as to have one extra.

photo
Jonathan Lee working to assemble the hanger.

Machining

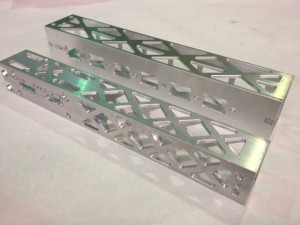
We also made some new parts for the level one hanger on the CNC. This will soon be sent for powercoating  The pocketed first stage parts are significantly lighter than they previously were. They also look quite pretty.

image

Some cool new parts for the level one hanger.

SVR Preparations

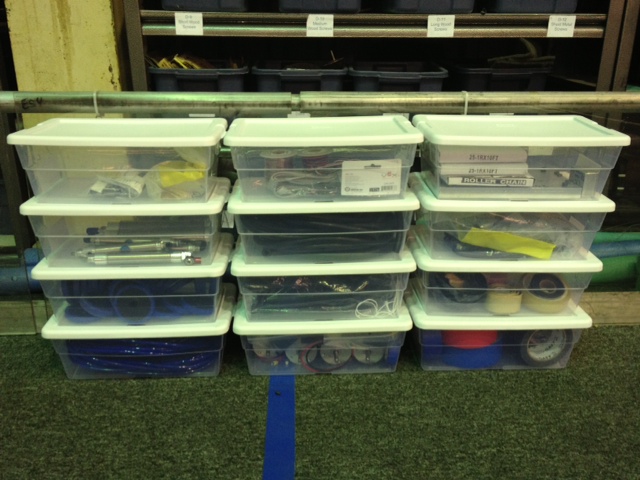
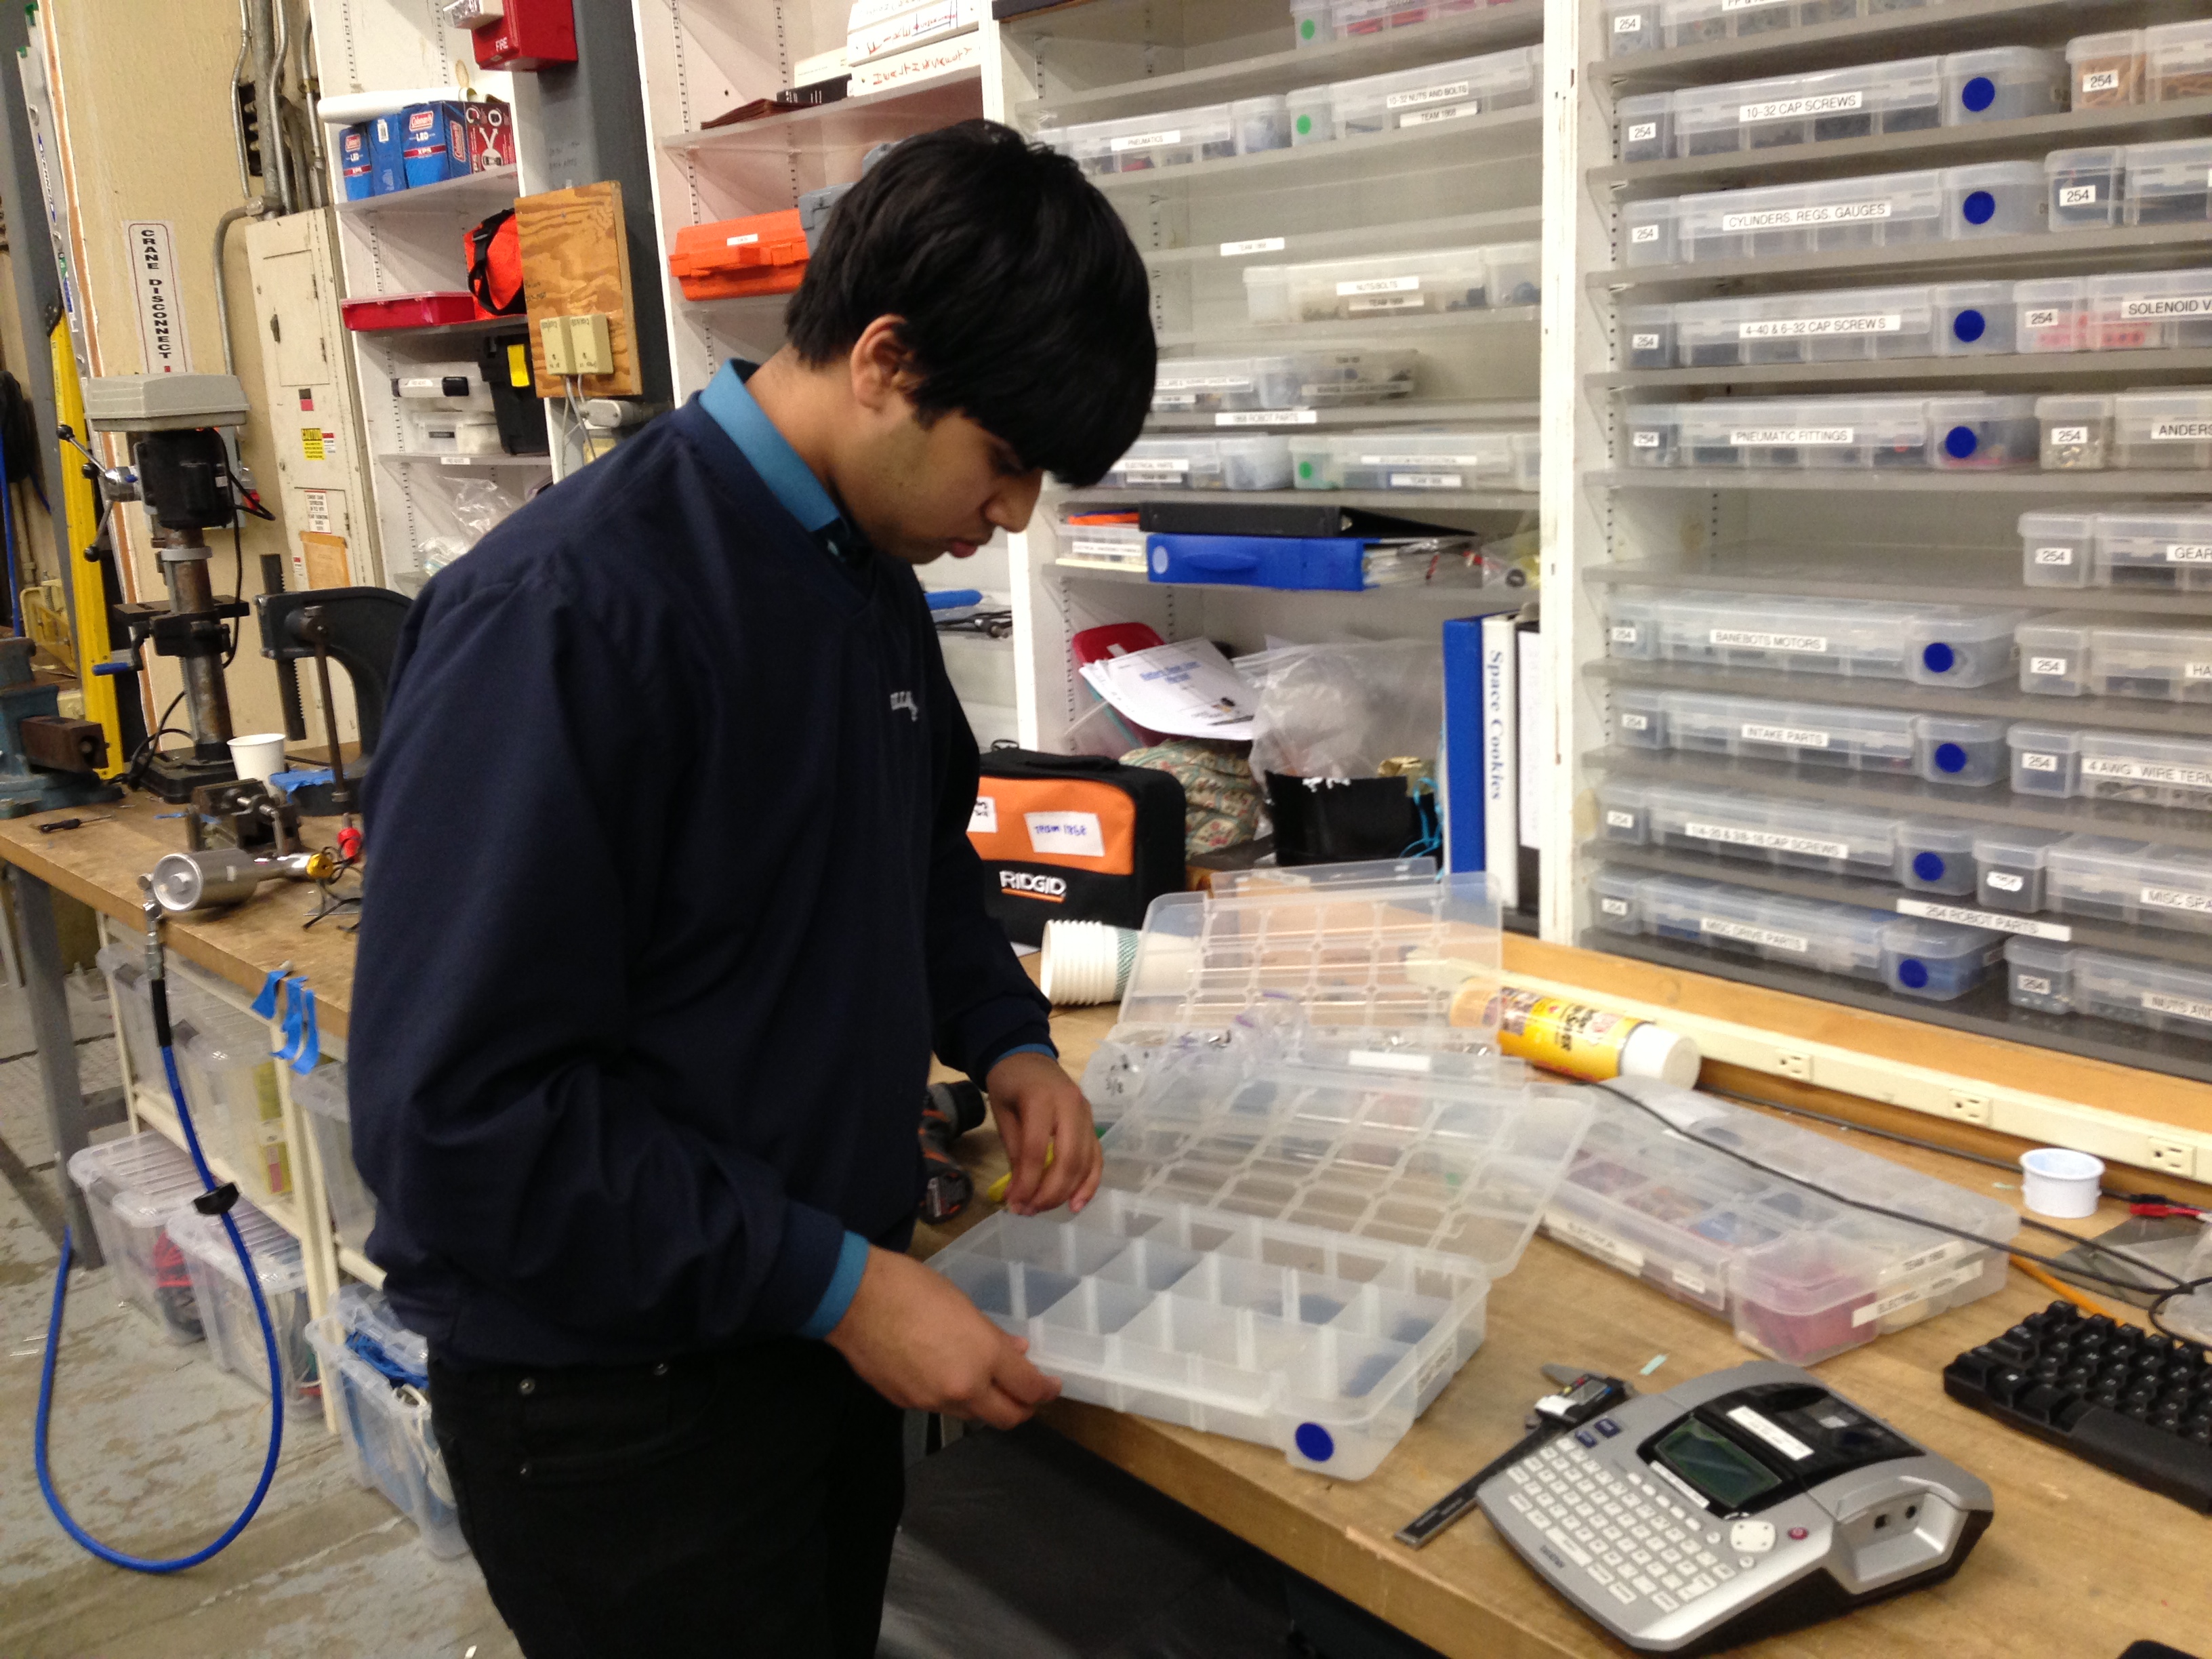
Students also worked on organizing supplies, tools, and equipment for SVR. The new clear bin system will make the pit significantly cleaner and easier to work in. We love organization (thanks T-Dog).

image

Supplies are packed and ready to go.

Programming

The programmers worked on fine tuning all of the autonomous modes: five-disc, four-disc, seven-disc, and center-disc.  With a lot of tweaking, the consistency of the various autonomous sequences have improved greatly.  However, late into the night, a shifting dog on the left gearbox of the drive train was completely shattered (yet again).  As a result, the robot's left drive won't work until the dog is replaced.


Lab closing time: 2:00 AM

Pre-SVR Day 14: Hanger Repair

2013 FRC Build SeasonFIRST Robotics

Hanger

While testing the hang speed late yesterday, the hanger malfunctioned. While it was on the third level hang, one of the arms bounced and did not latch, leaving the robot hanging from one arm. This torqued that arm at an angle, the belt snapped, and left other minor damages. Today, the students and the mentors worked to put it back together. The belt was replaced, and it is back on the robot, and working well.

5431

Shooter/Indexer

After a lot of driver practice lining up to take shots, the shooter's consistency started to go down. Upon further inspection, one of the belts that was linking the two shooter shafts snapped and fell off the robot. In addition, the back shooter motor is shot. The robot still shoots the frisbees, but not up to the speed and distance it should be at.

photo 5

Slipstream

Slipstream is now fully functioning. It will be used for programming purposes, sensor verification, and demonstrations.

photo 1

Pre-SVR Day 13: Defense

2013 FRC Build SeasonFIRST Robotics

photo 5After a quick driver's practice today, a programming issue occured with the autofire shooting. With the indexer physically jamming as well as the software causing jamming while shooting, practice was stopped and efforts were put towards making sure the robot was fully functional. After the programming and hardware issues were solved, drivers continued practicing.

Intake

Last night, wooden support blocks were added to the practice robot's intake to help keep the polycarbonate bottom plate pushed to the ground. No other modifications were made to the intake, and in its current state it is working moderately well.

photo 4

Shooter/Indexer

The new indexer system that feeds one frisbee at a time has eliminated the issue of the indexer not fully engaging over the frisbee, which caused jamming (such as in San Diego). While testing today, frisbees were jamming below the indexer, which students quickly discovered was caused by a loose piston Tightening the piston solved any jamming issues. Continued testing of the shooter proved extremely improved consistency and power while using the new banebot motors.

Slipstream

Slipstream was brought to NASA from its home at the Bellarmine Robotics lab and repaired by students today. After being restored to driving condition and reprogrammed by students, it is up and running and ready to be used to practice defense. Students and mentors will drive Slipstream as a defensive robot while the drive team runs drills with Overkill to give a more realistic situation and challenge them to adapt to a multitude of different scenarios.

photo 1

Competition Preparation

In preparation for SVR, students populated a list of supplies to buy, as well as continued to organize the current list with new bins that were bought. By separating the different supplies into individual bins the process of pit setup will be streamlined, as well as creating a more organized pit overall.

photo 1 (1)

Pre-SVR Day 12: Regroup and Rethink

2013 FRC Build SeasonFIRST Robotics

34After ten minutes of driver practicing, the team still determined that one glaring problem still exists that currently precedes all others: the robot's intake system inconsistently picks up frisbees. 

Intake

The team technical leaders gathered to decide on a solution for the intake problem.

Issues:

leedle
The daunting issue ahead
  • Frisbees stack on top of each other inside shooter indexer
  • Intake shelf/ramp causes discs to stall
  • Whether or not bottom roller should be used

 After a comprehensive discussion about the next step, the team concluded that the next step would be to revert back to the old intake and iterate from there.

​Solution to test:

  • Remove frisbee ramp 
  • Replace bottom roller​

Shockwave

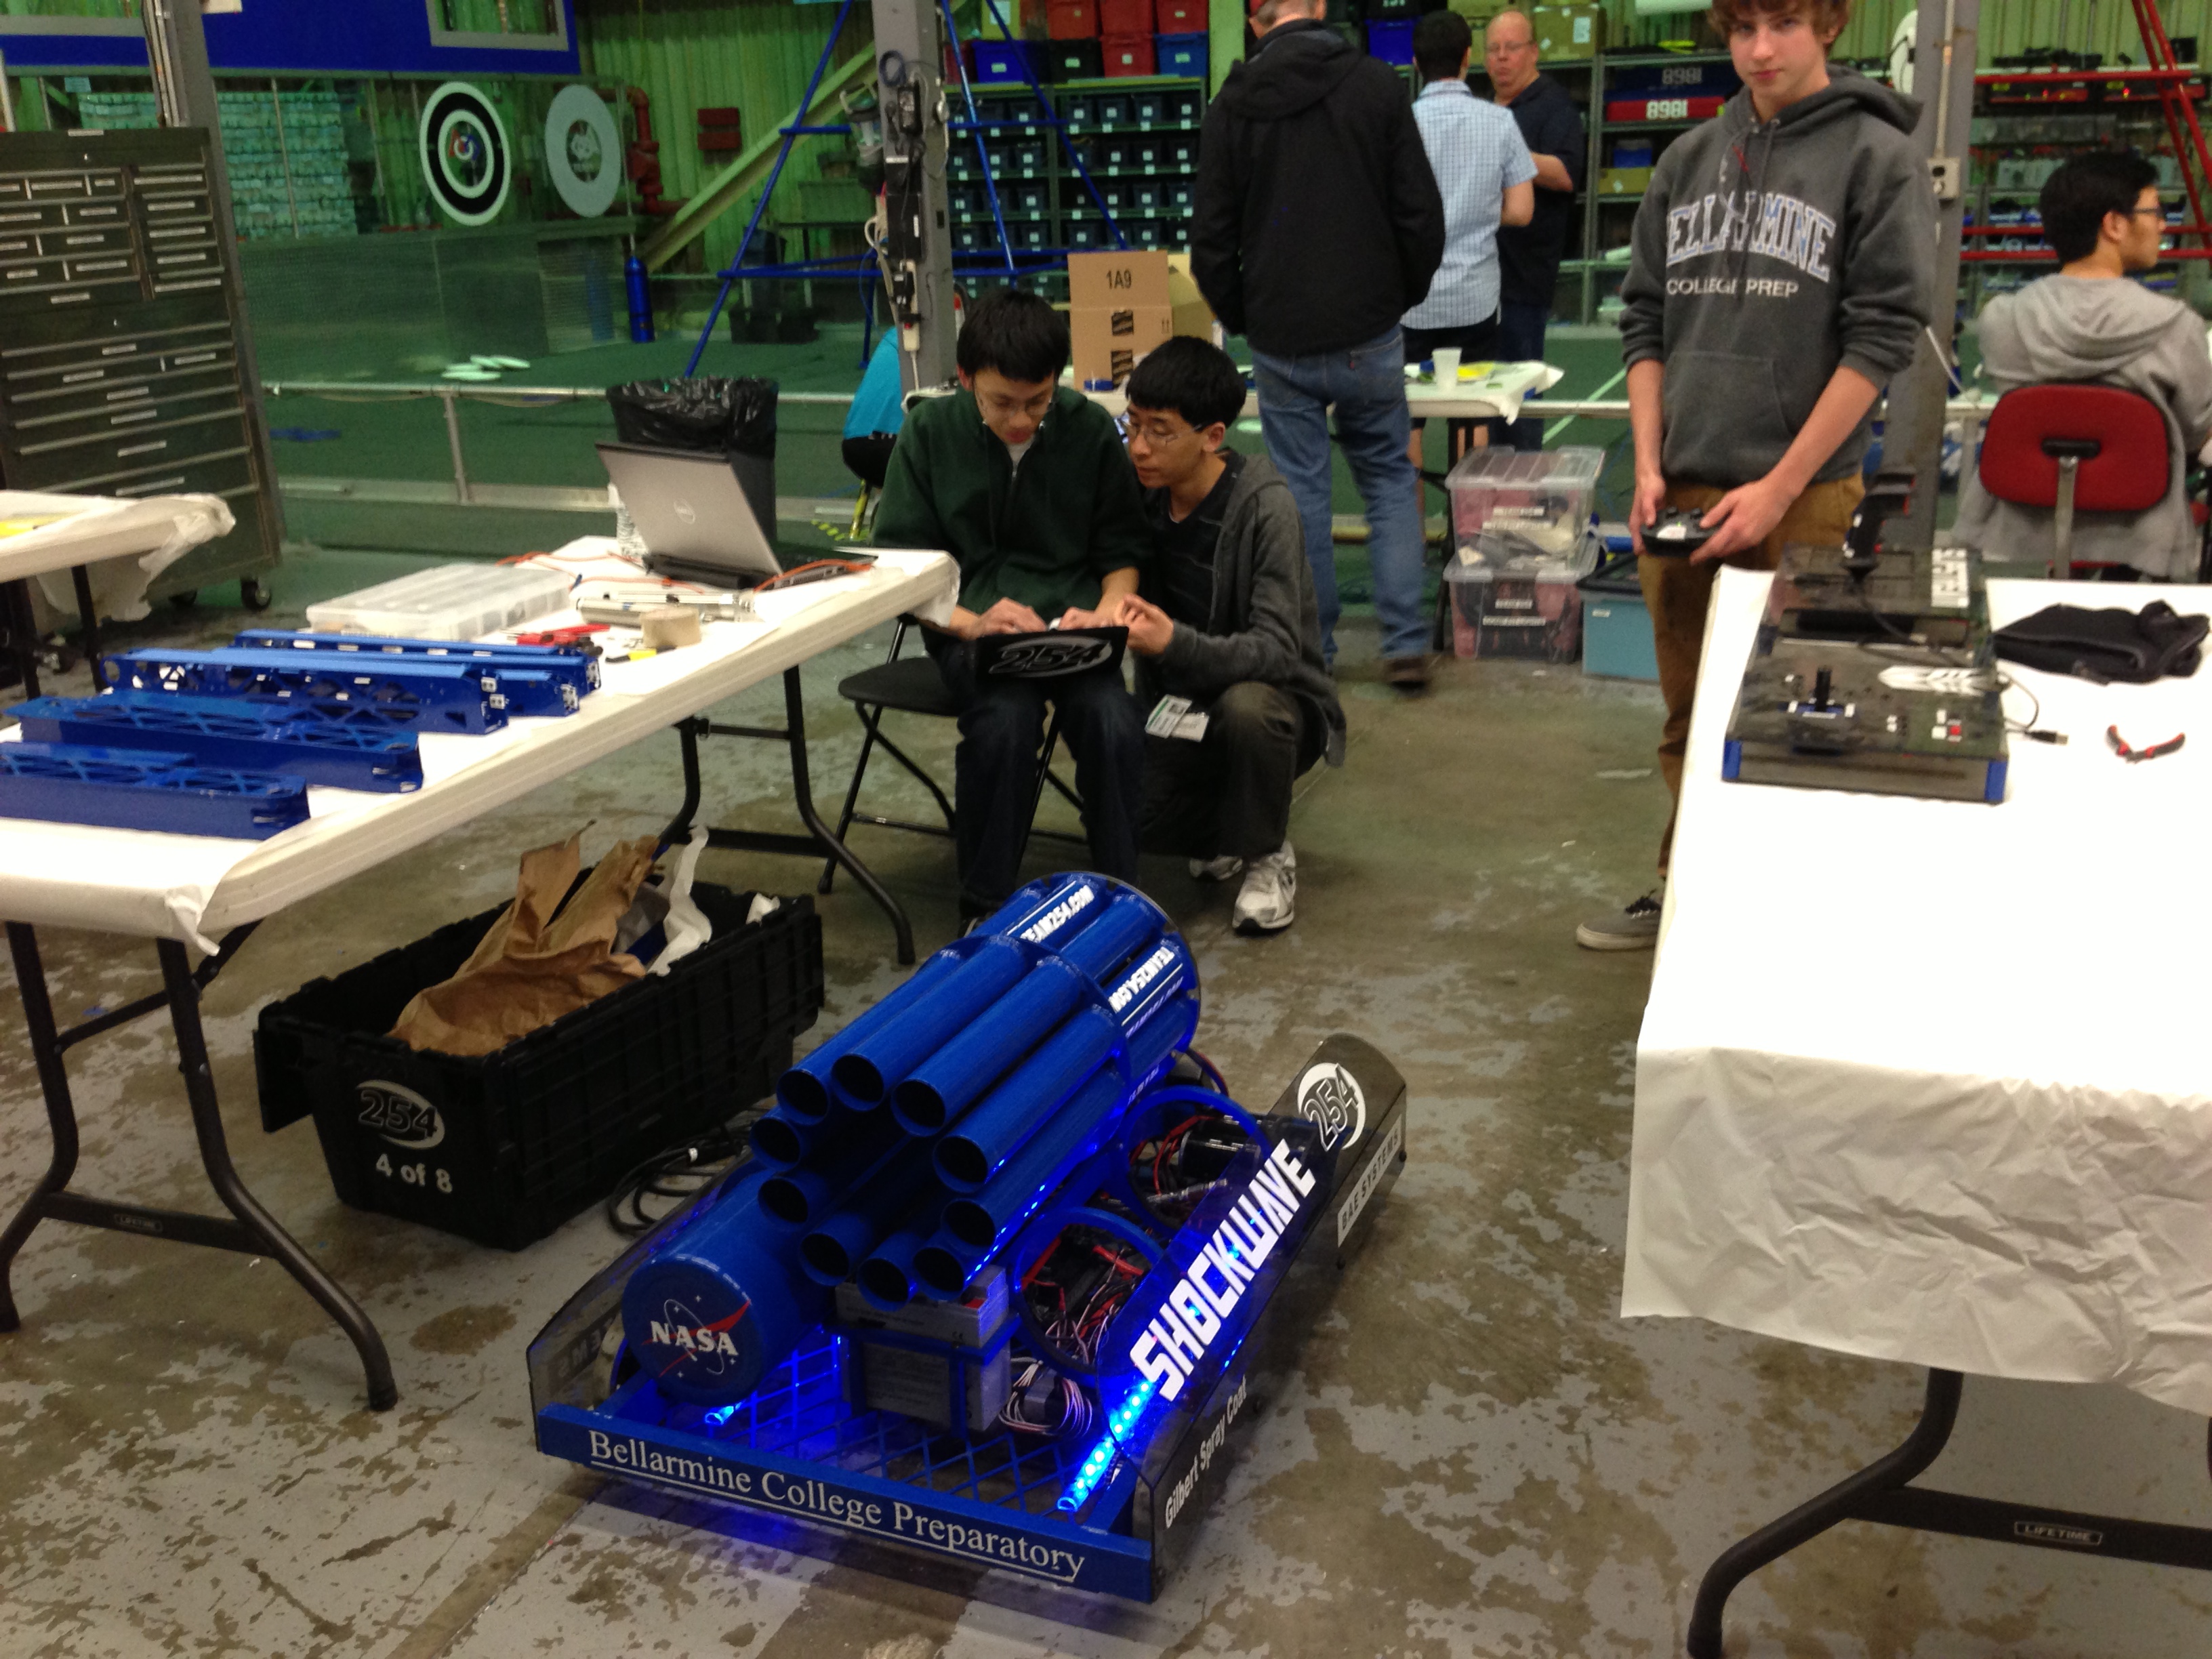
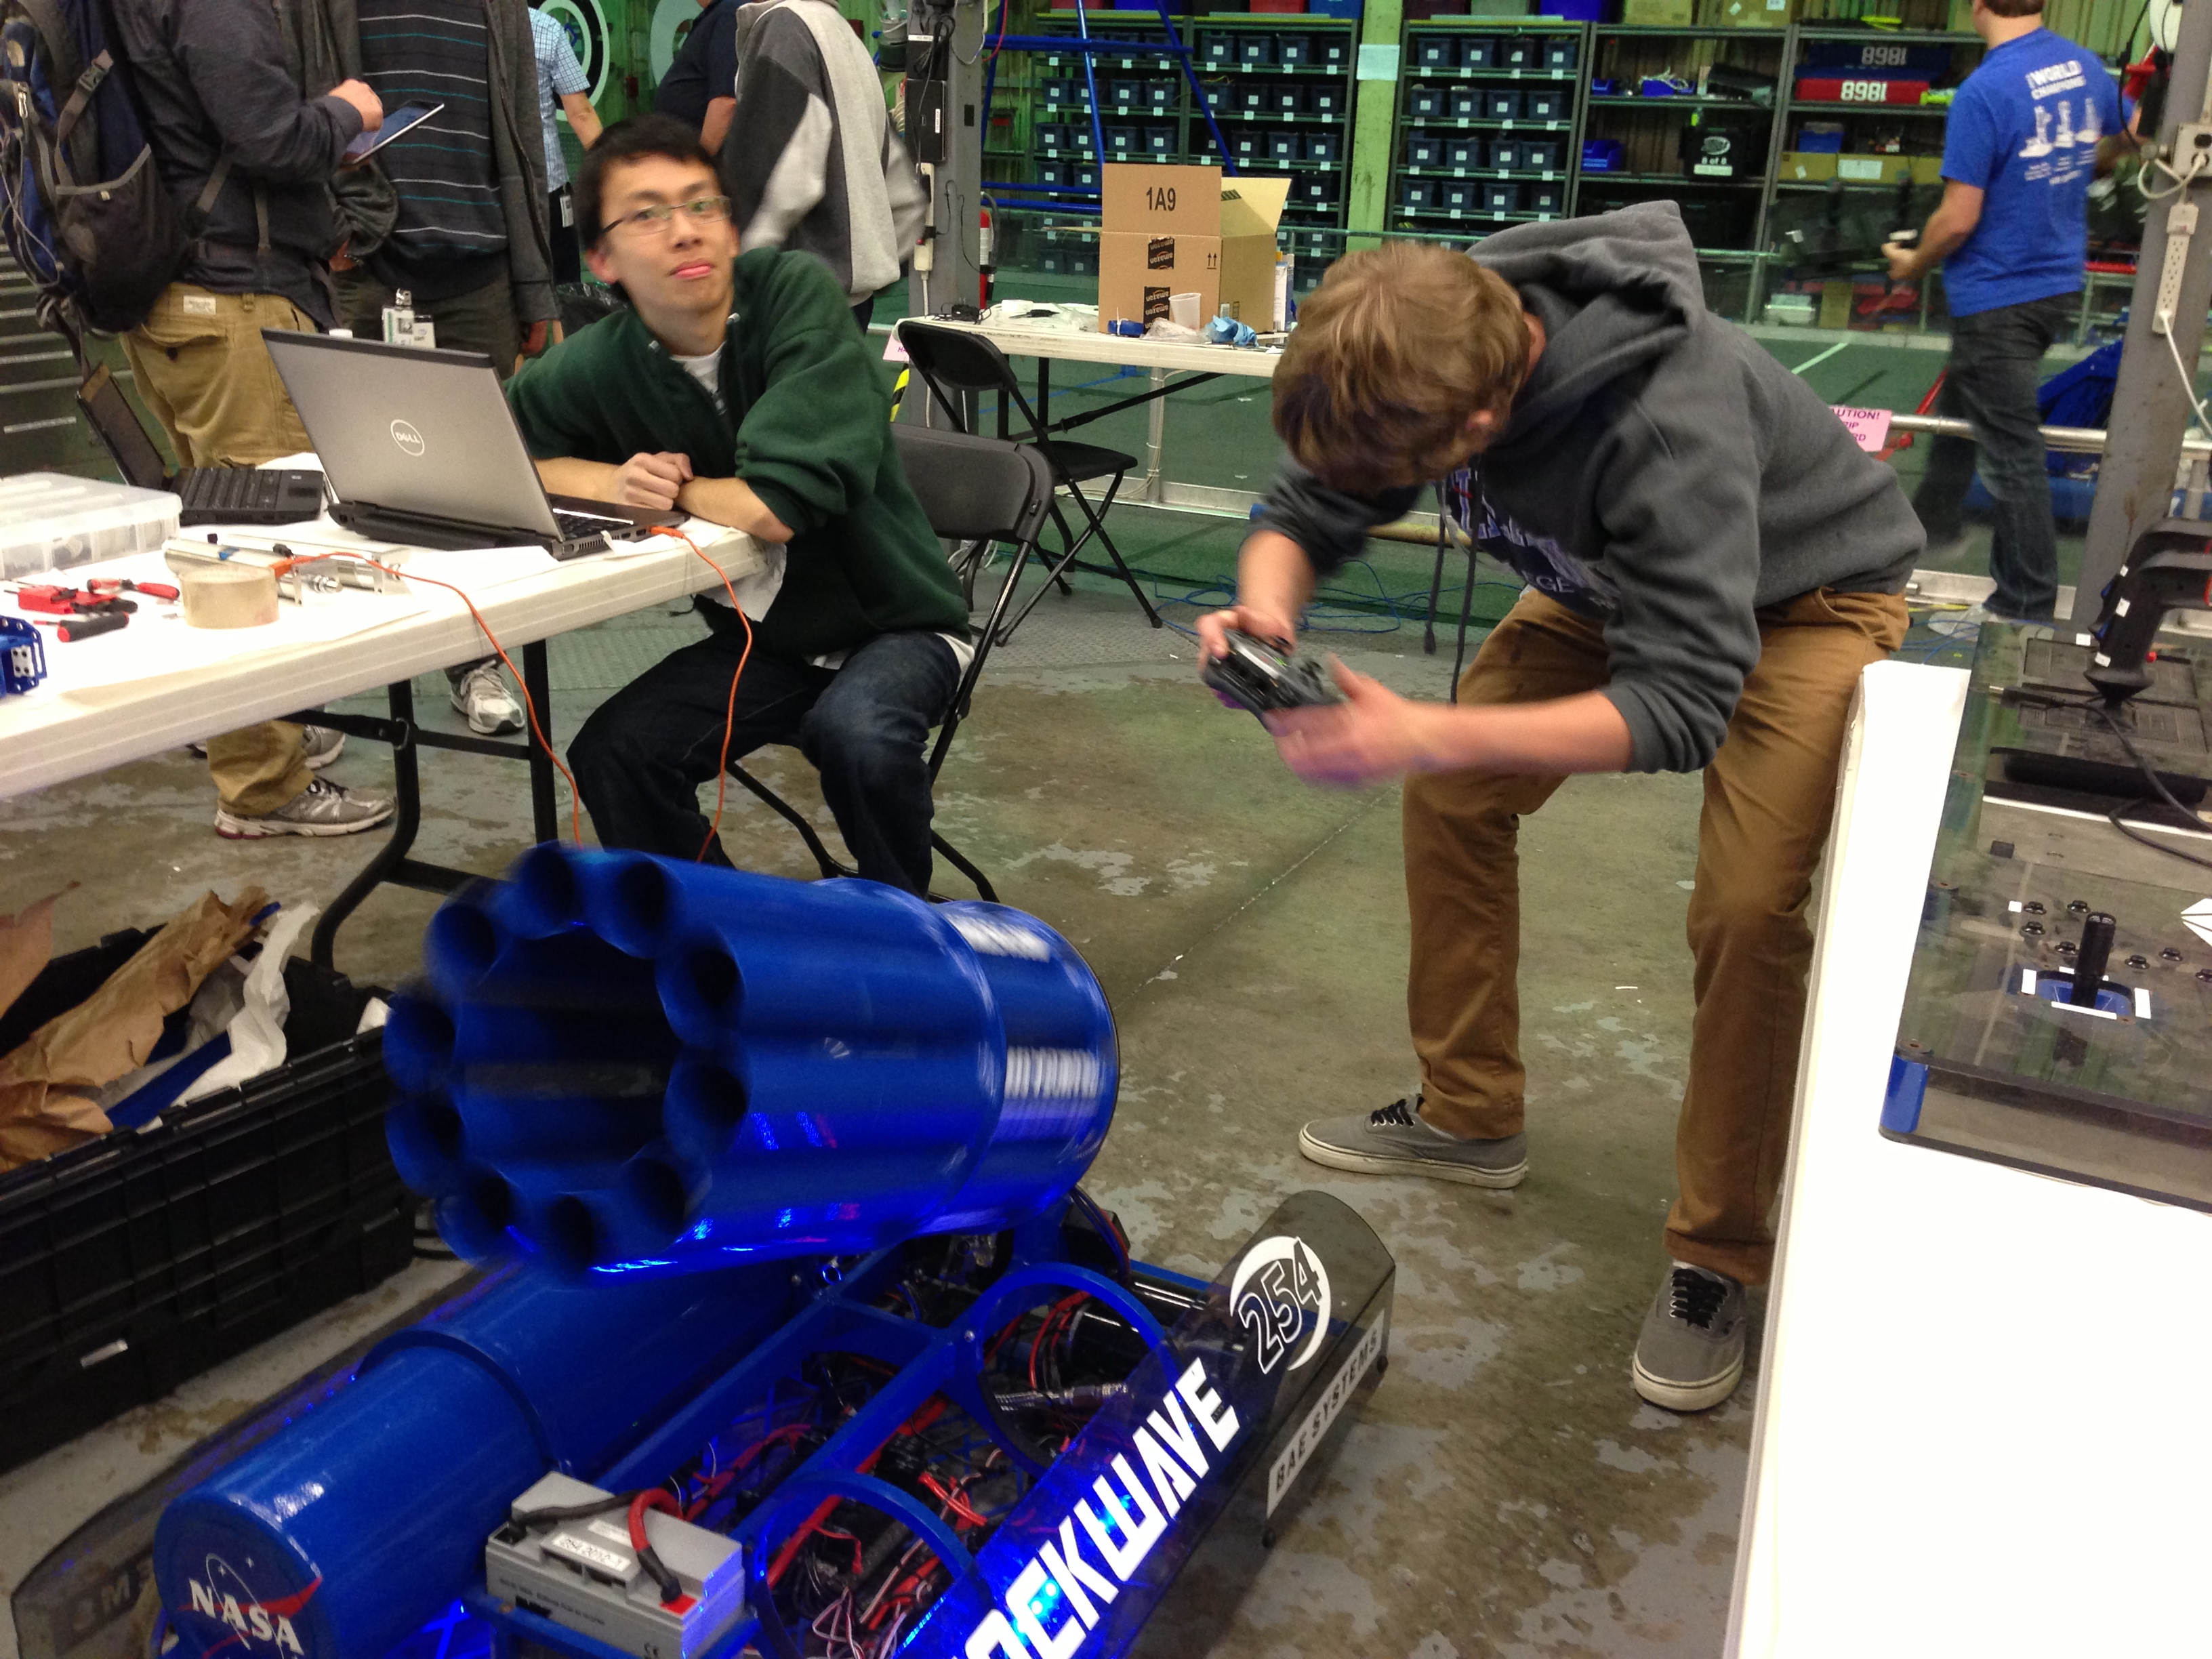
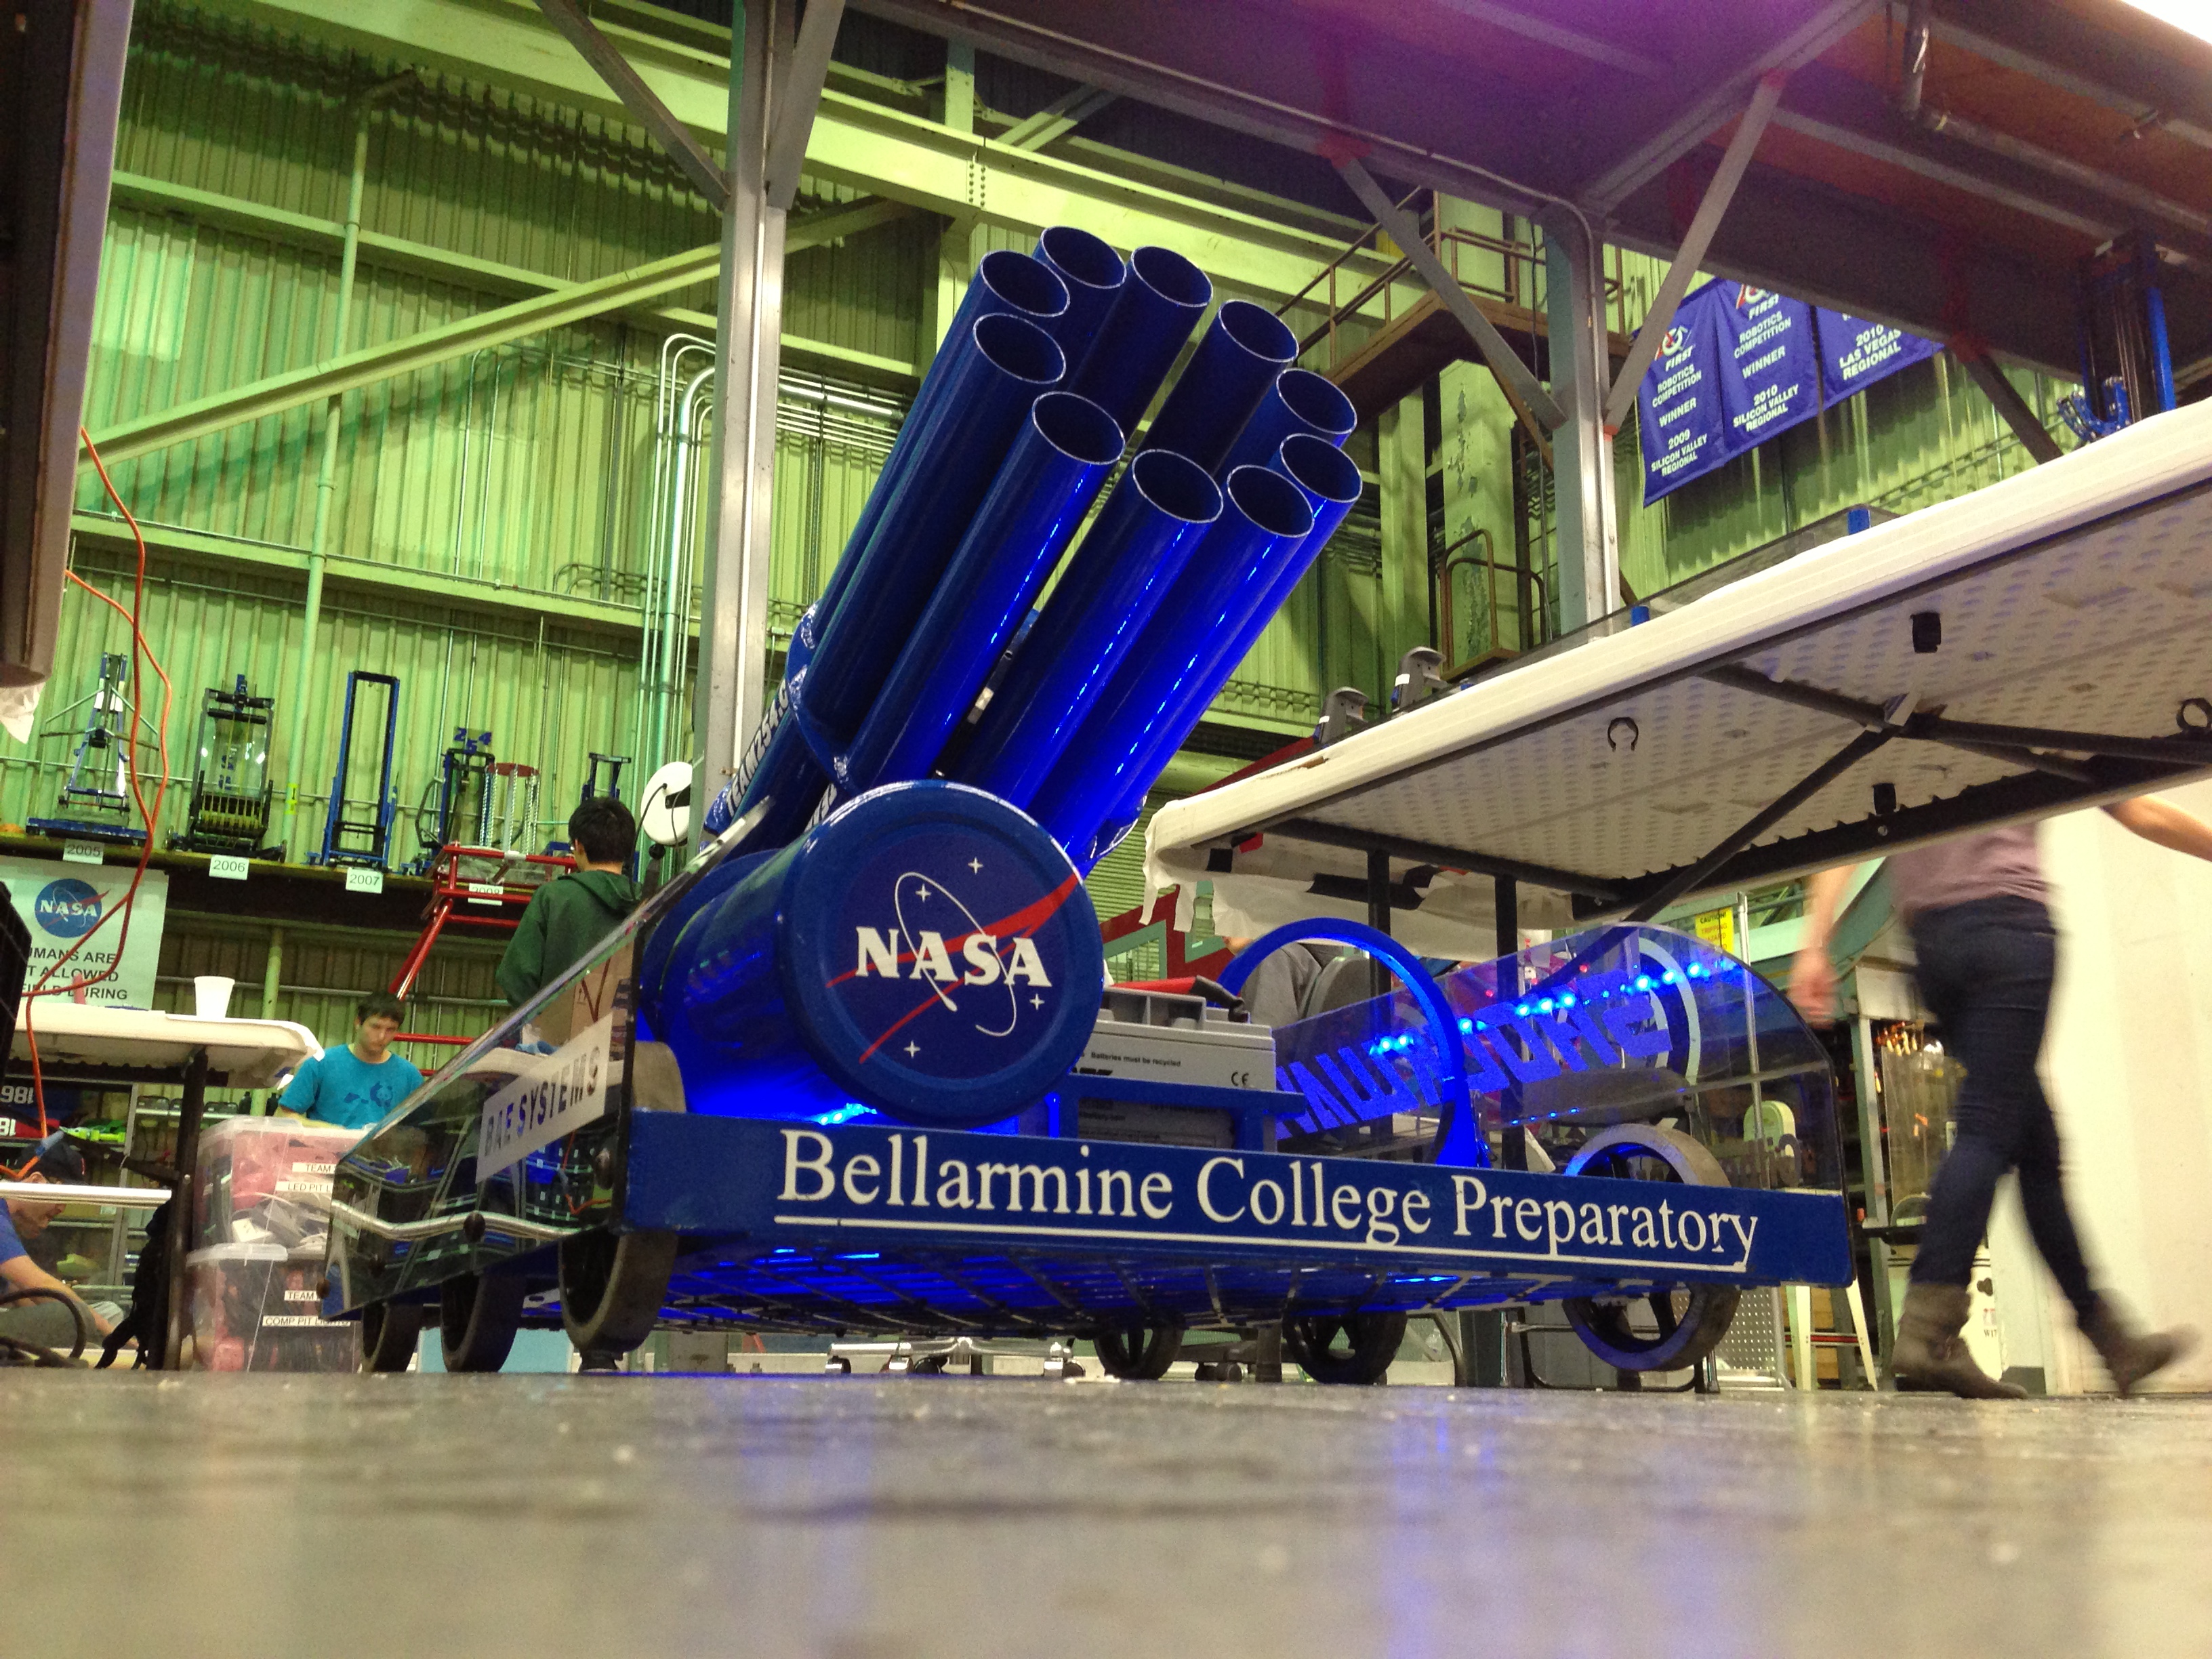
Further development of the T-shirt cannon, Shockwave, was continued today, led by Richard Lin. The programming team added the indexing code which rotates the barrels for the next shot. Controls are still under maintenance to ensure safe and proper performance during exhibitions. This will require extensive robot testing by mentors before it can be used in public. 

dfgs

Students developing the controls
image_4

Code Testing
image_5

A heroic perspective of Shockwave 
dgfs

Tom is impressed

Pre-SVR Day 11: Intake Redesign

2013 FRC Build SeasonFIRST Robotics

Intake

The team is currently working on redesigning the intake to intake discs more effectively.  There are multiple issues with the current iteration, such as stacking when intaking multiple discs.  As of now, students are experimenting by attaching two small Banebots wheels in the front roller shaft.  In addition, they have added a polycarbonate ramp that slants upward into the robot.  Once the intake is fully designed and works reliably, the programmers can test their autonomous modes.

Shooter

The shooter is currently under construction, and removed from the robot.  Students manufactured more parts for the shooter.  For instance, they created shafts using the lathe and bandsaw.

Programming

The programmers continued to fine-tune and modify the seven-disc autonomous sequence.  Specifically, they made adjustments to the robot's driving and intaking.  Since the shooter is currently detached, no shooting was done or tested.

In other news, the programmers had some connection and network troubles with robot, driver station laptop, and programming laptops.  The robot's connection with the driver station occasionally drops for about a second.  Additionally, the programmers were unable to FTP to the robot to deploy code while the driver station laptop was connected to the robot.  Students and mentors tried to debug the situation for a long time, but were unable to pinpoint the issue.  They will look further into the problem in the coming days.

Food

The students also enjoyed some delicious BBQ for dinner, as well as ice cream for a late night delight.

Pre-SVR Day 10:

2013 FRC Build SeasonFIRST Robotics

IMG_20130322_210214

Indexer

The polycarb flap that indexes the frisbee was modified to be thicker. The indexer superstructure was changed and we reverted to old butcher knife plates to lower compression on the disc. The default state of the indexer was also changed from the bottom to the top. The team is making these modifications to increase the rate at which the robot shoots discs.

Wheels

Team members took apart old wheels, cleaned them up and removed old rivets and tread. The wheels were not re-treaded.

Sensors

Members started wiring the photoelectric sensors for the shooting and indexing sequence.  This would optimize and speed up rapid firing as well as autonomous mode.IMG_20130322_210552IMG_20130322_210934

Pre-SVR Day 9: Edgy Intake

2013 FRC Build SeasonFIRST RoboticsPublic Relations

Overkill:

Tests were conducted using a knife-edged polycarbonate sheet added to the bottom of the intake tonight in order to improve the effectiveness of the intake system. New rails have been integrated into the shooter system. The tests are still underway and there have not been any conclusive results yet.

Shockwave:

Due to issues with establishing connection to the robot students replaced the old cortex and troubleshooted faulty wiring. There is still work to be done and students will continue to work to make Shockwave functional again.

Sponsor Invites:

Invitations to the Silicon Valley Regional were sent to almost all of our sponsors tonight.

Pit Lighting:

Pit members worked on creating an easier means to set-up and transport the LED strips used for Pit lighting. Their fragility and difficulty to set up significantly complicates setting up the pit Thursday morning.

Pre-SVR Day 8: New Shooter

2013 FRC Build Season

Driver Practice

Today Driver Abhi Kumar and Backup Operator Jonathan Lee were able to get a lot of practice with the robot. Additionaly, Human Player Aaron Johnson was also able to practice with the drive team.

New Shooter

Students and Mentors began manufacturing and assembling the new shooter today. This shooter incorporates BaneBots 550 motors instead of Mini-CIMs, which were previously used on the shooter before. Students began by manufacturing spacers for the motor housing plate using the lathe and spare spacers from last year's gearbox. They then worked on manufacturing the shafts for the wheels on the shooter. The components of the shooter were then put together and tested using the new shooter plates that were manufactured today.