38 posts

2017 Winners of Chezy Champs!

2017 FRC Build SeasonTournaments

A Brief Summary

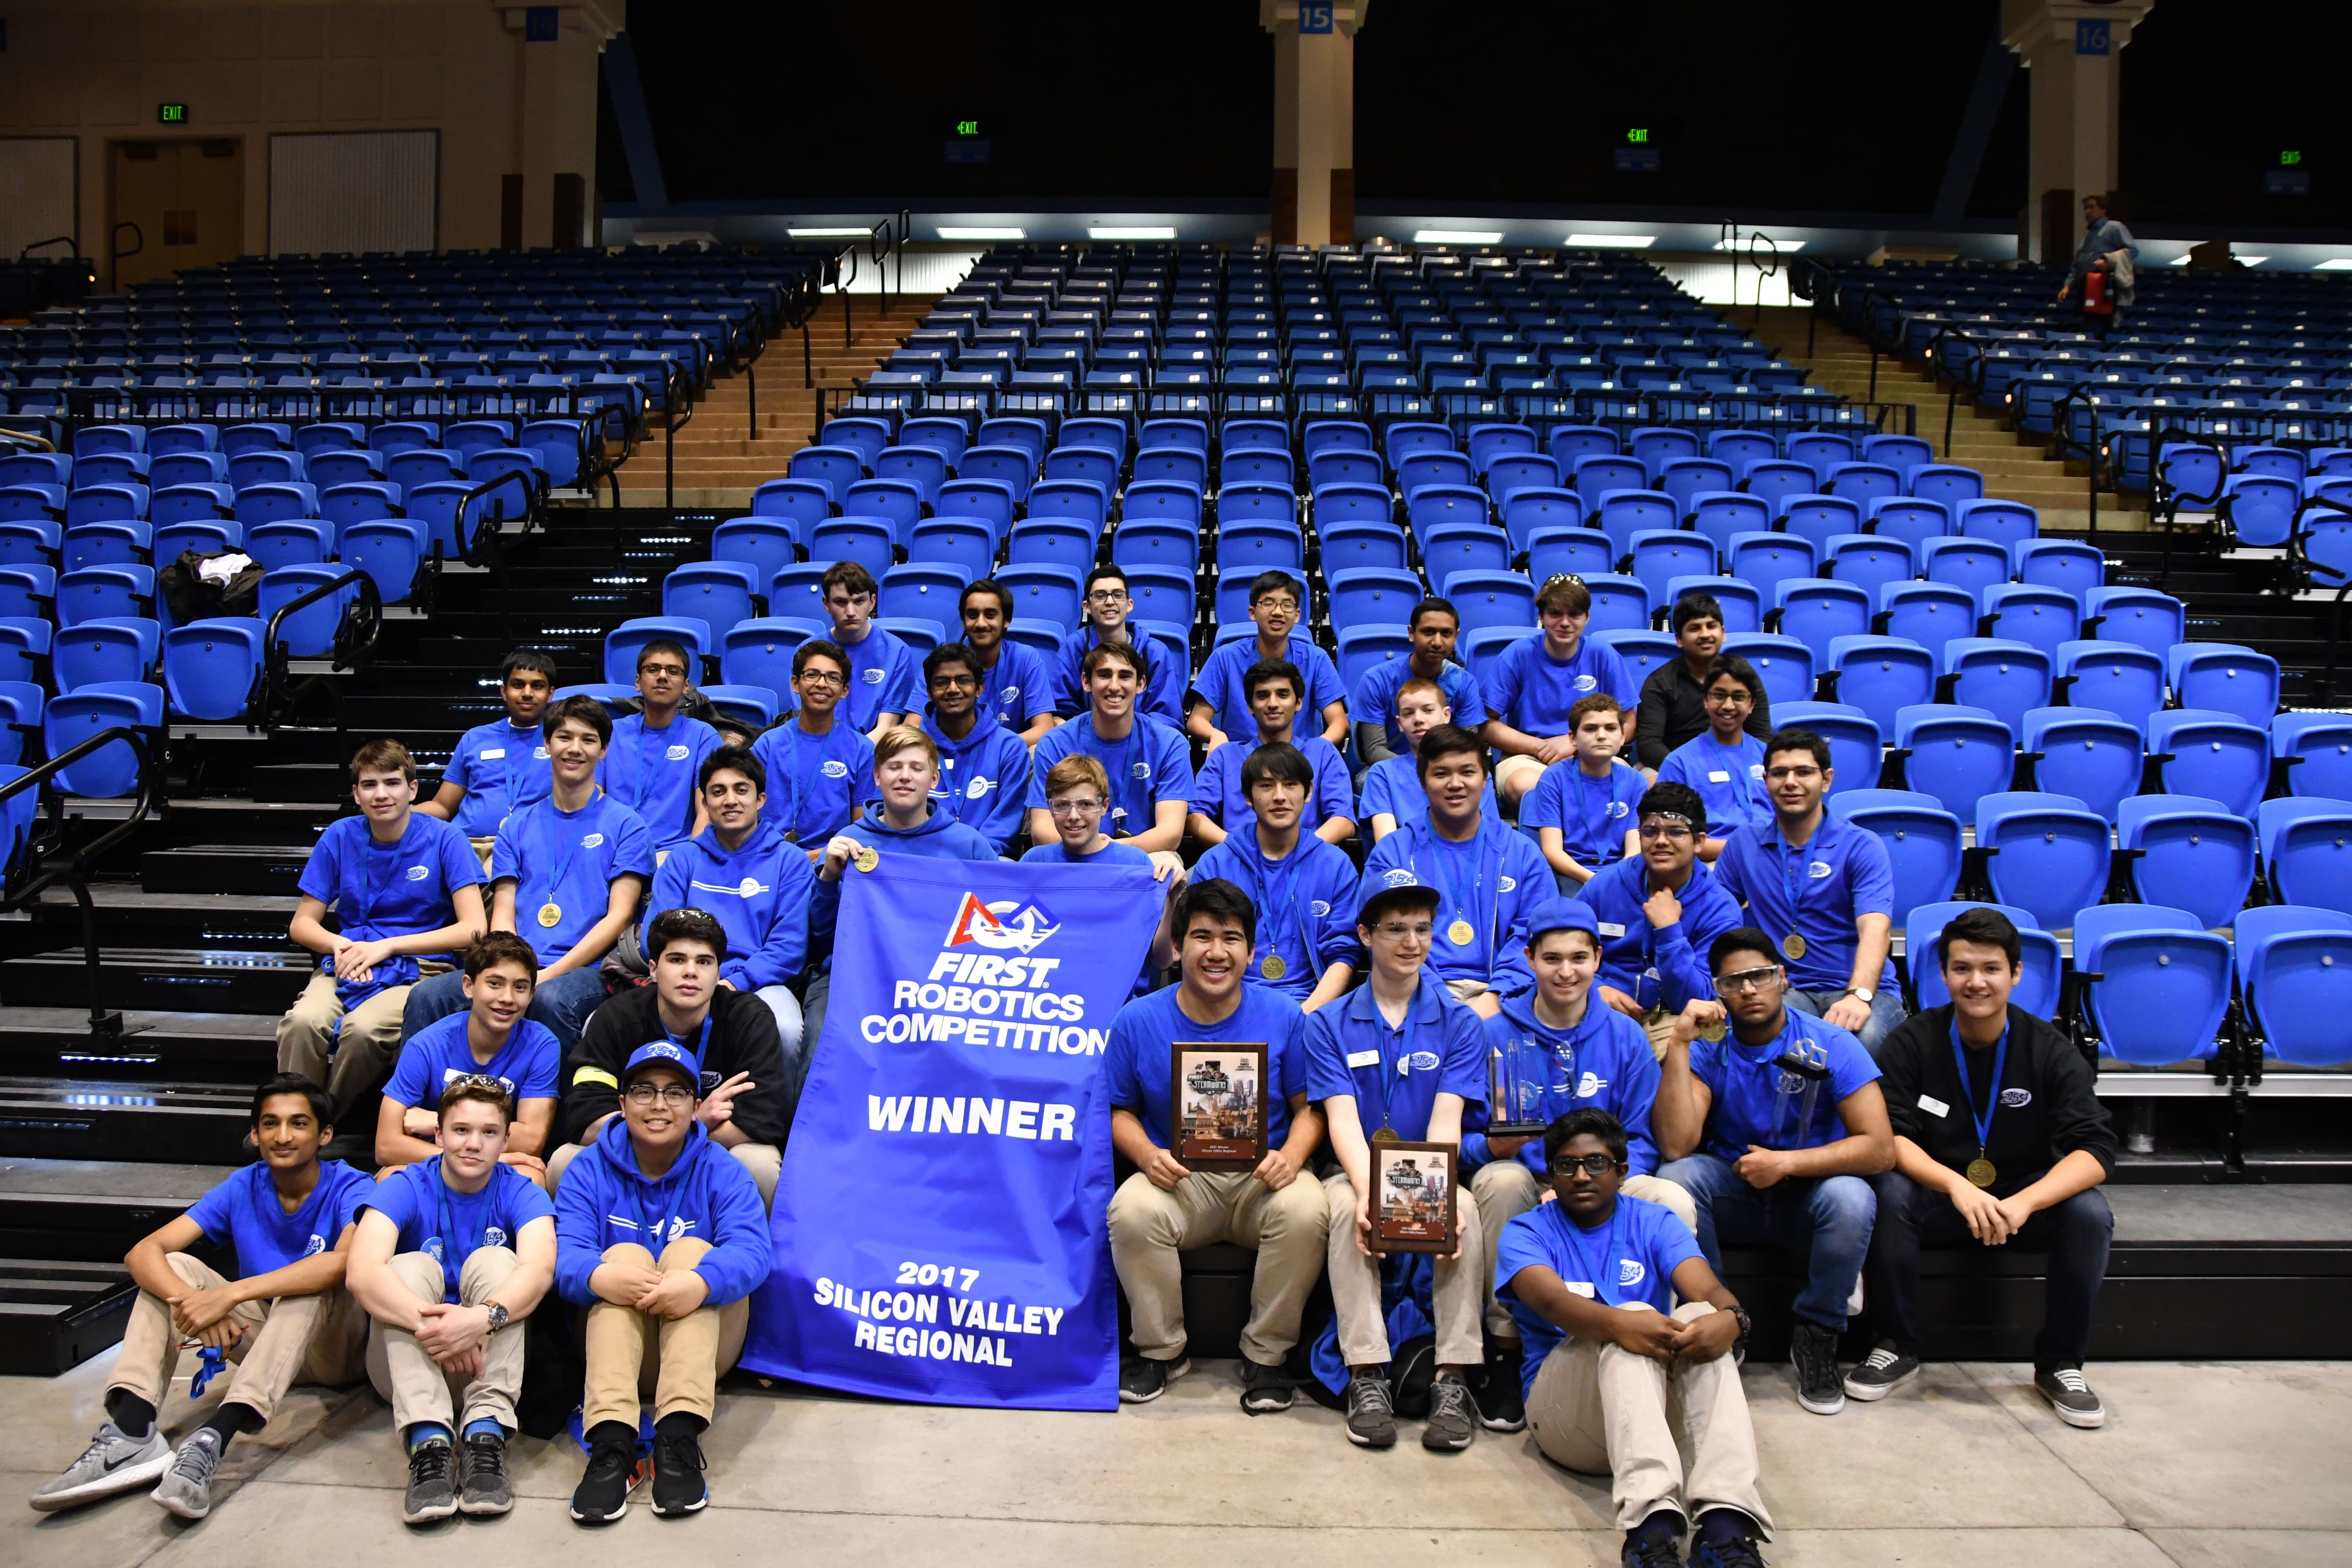
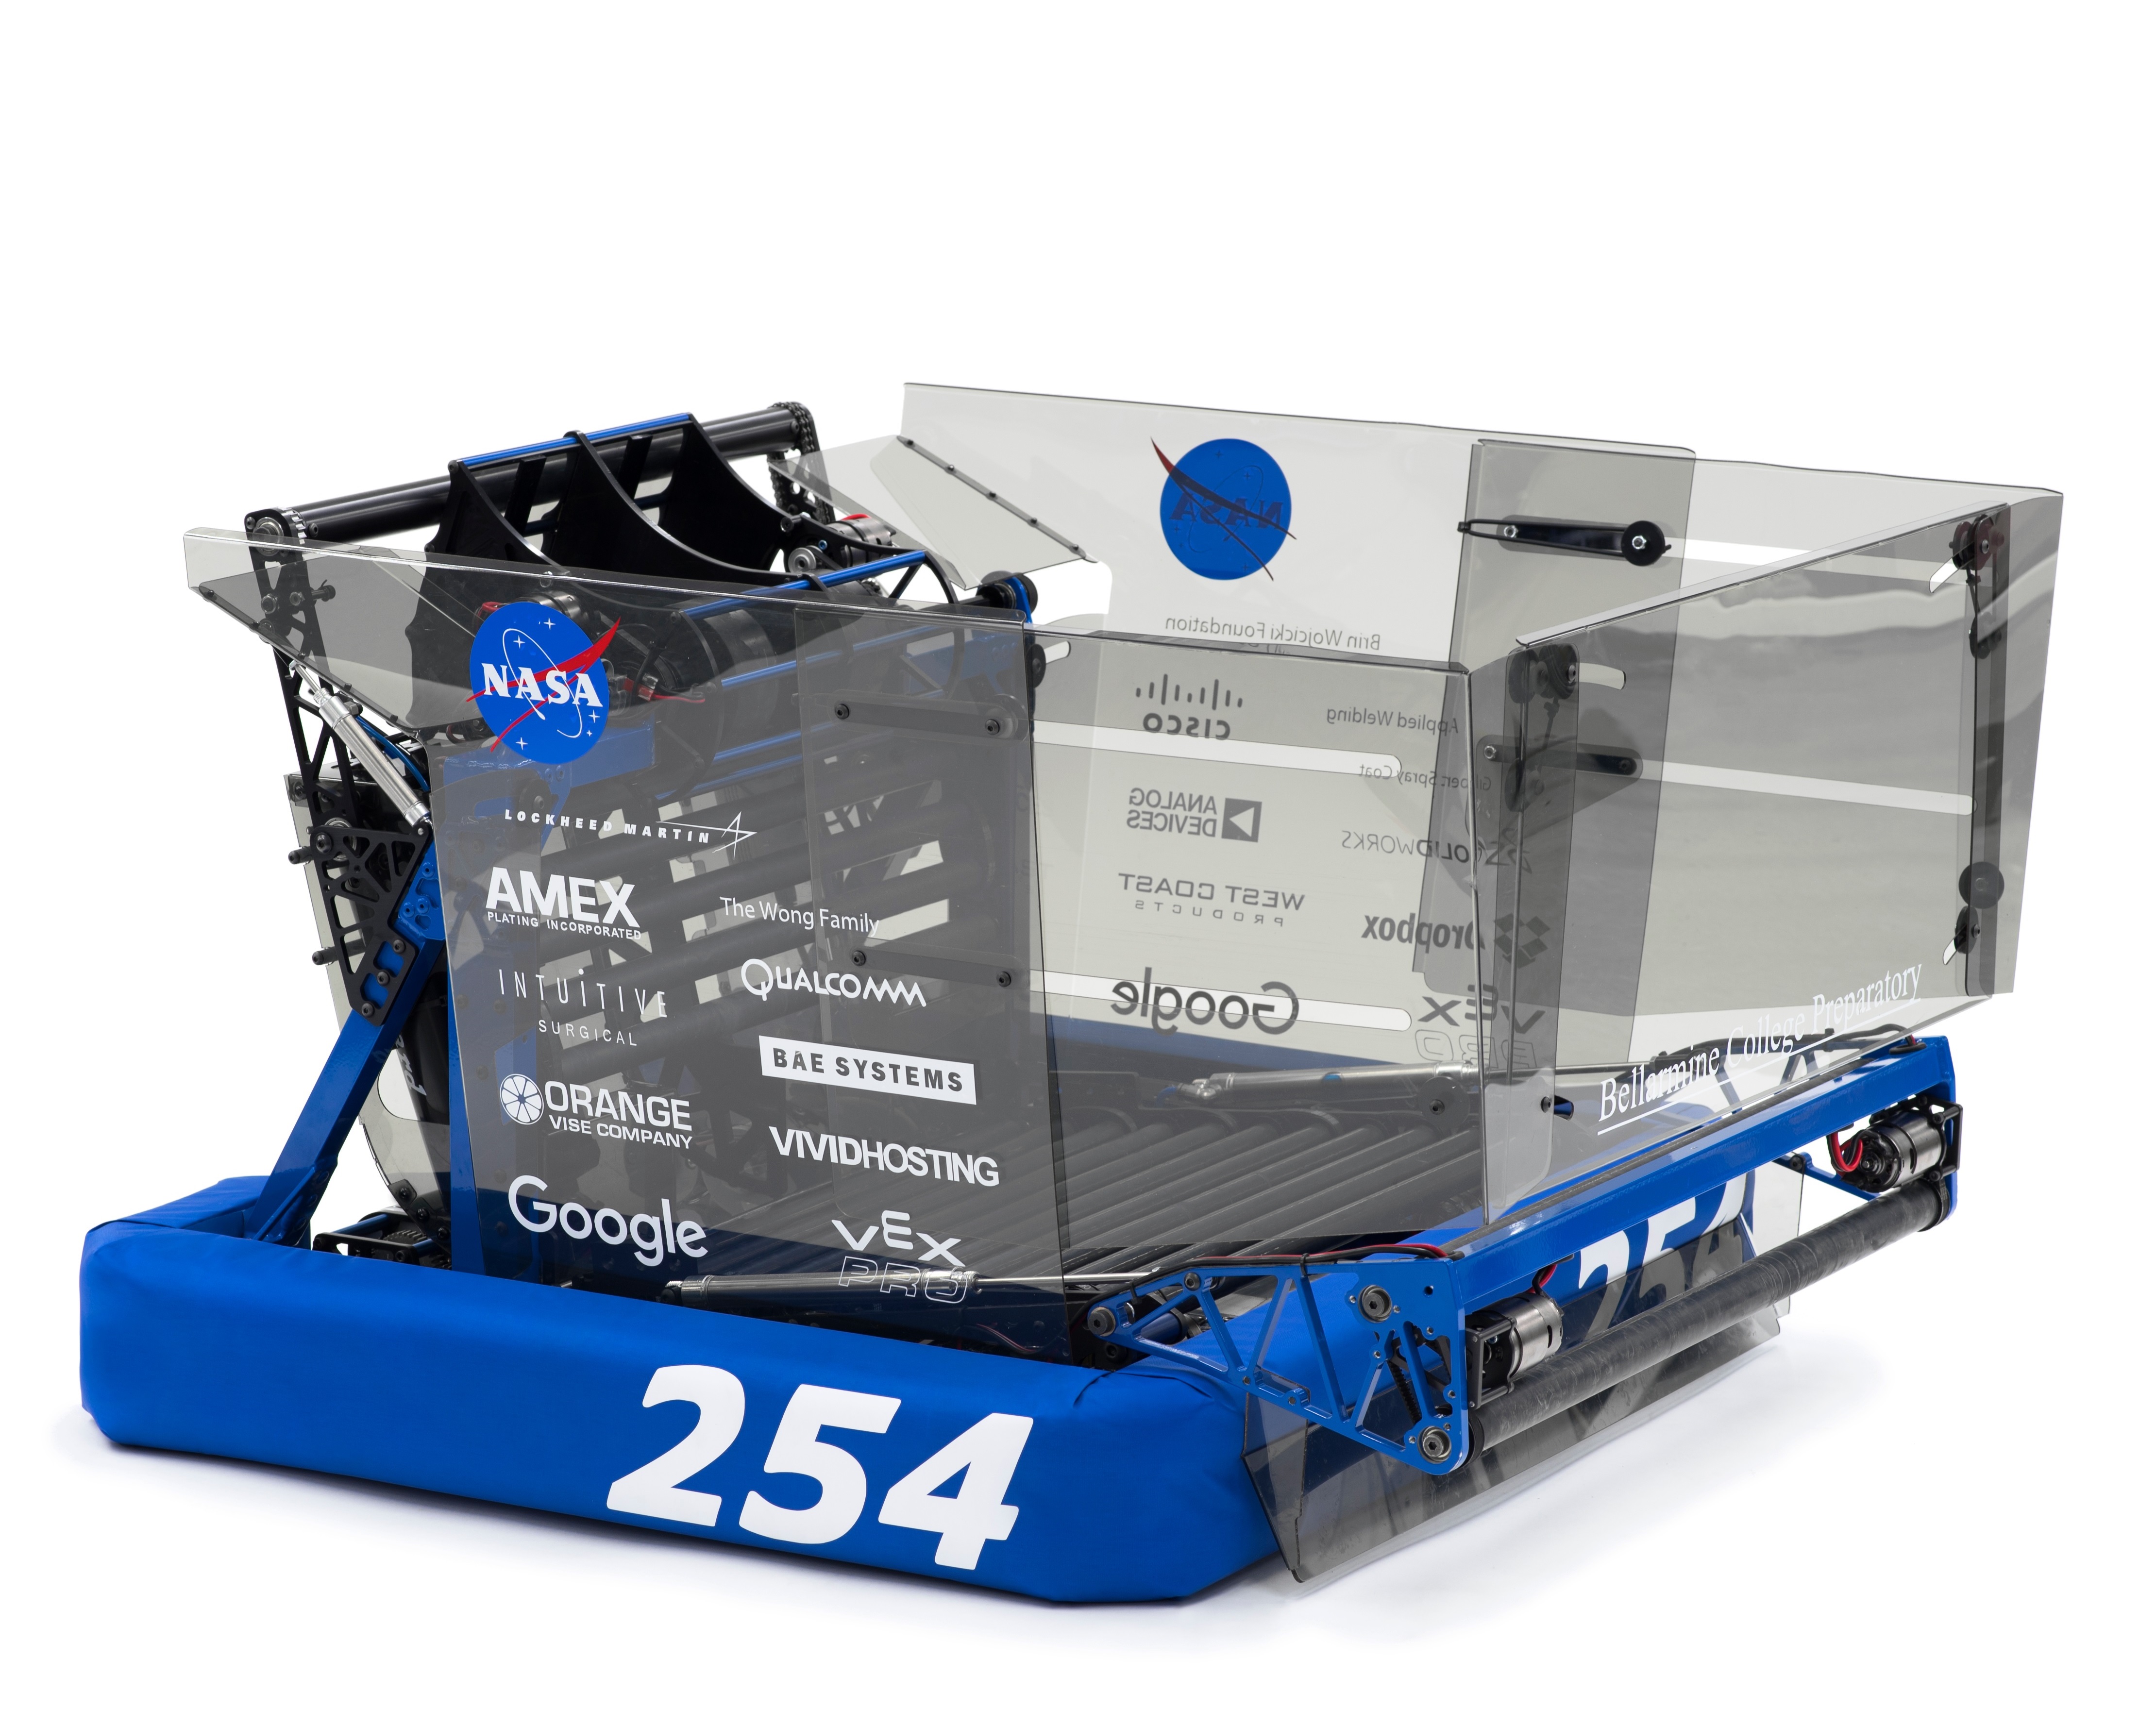
As part of an eventful weekend, we hosted Chezy Champs, our annually hosted offseason FRC tournament at Bellarmine College Preparatory, in our hometown of San Jose, CA. We had a great time jumping back into action with our robot, Misfire, before the start of the 2018 FRC Season. Alongside, FRC Team 1011 Team CRUSH, FRC Team 696, Circuit Breakers, and FRC Team 5104 BreakerBots, we were able to win the tournament!
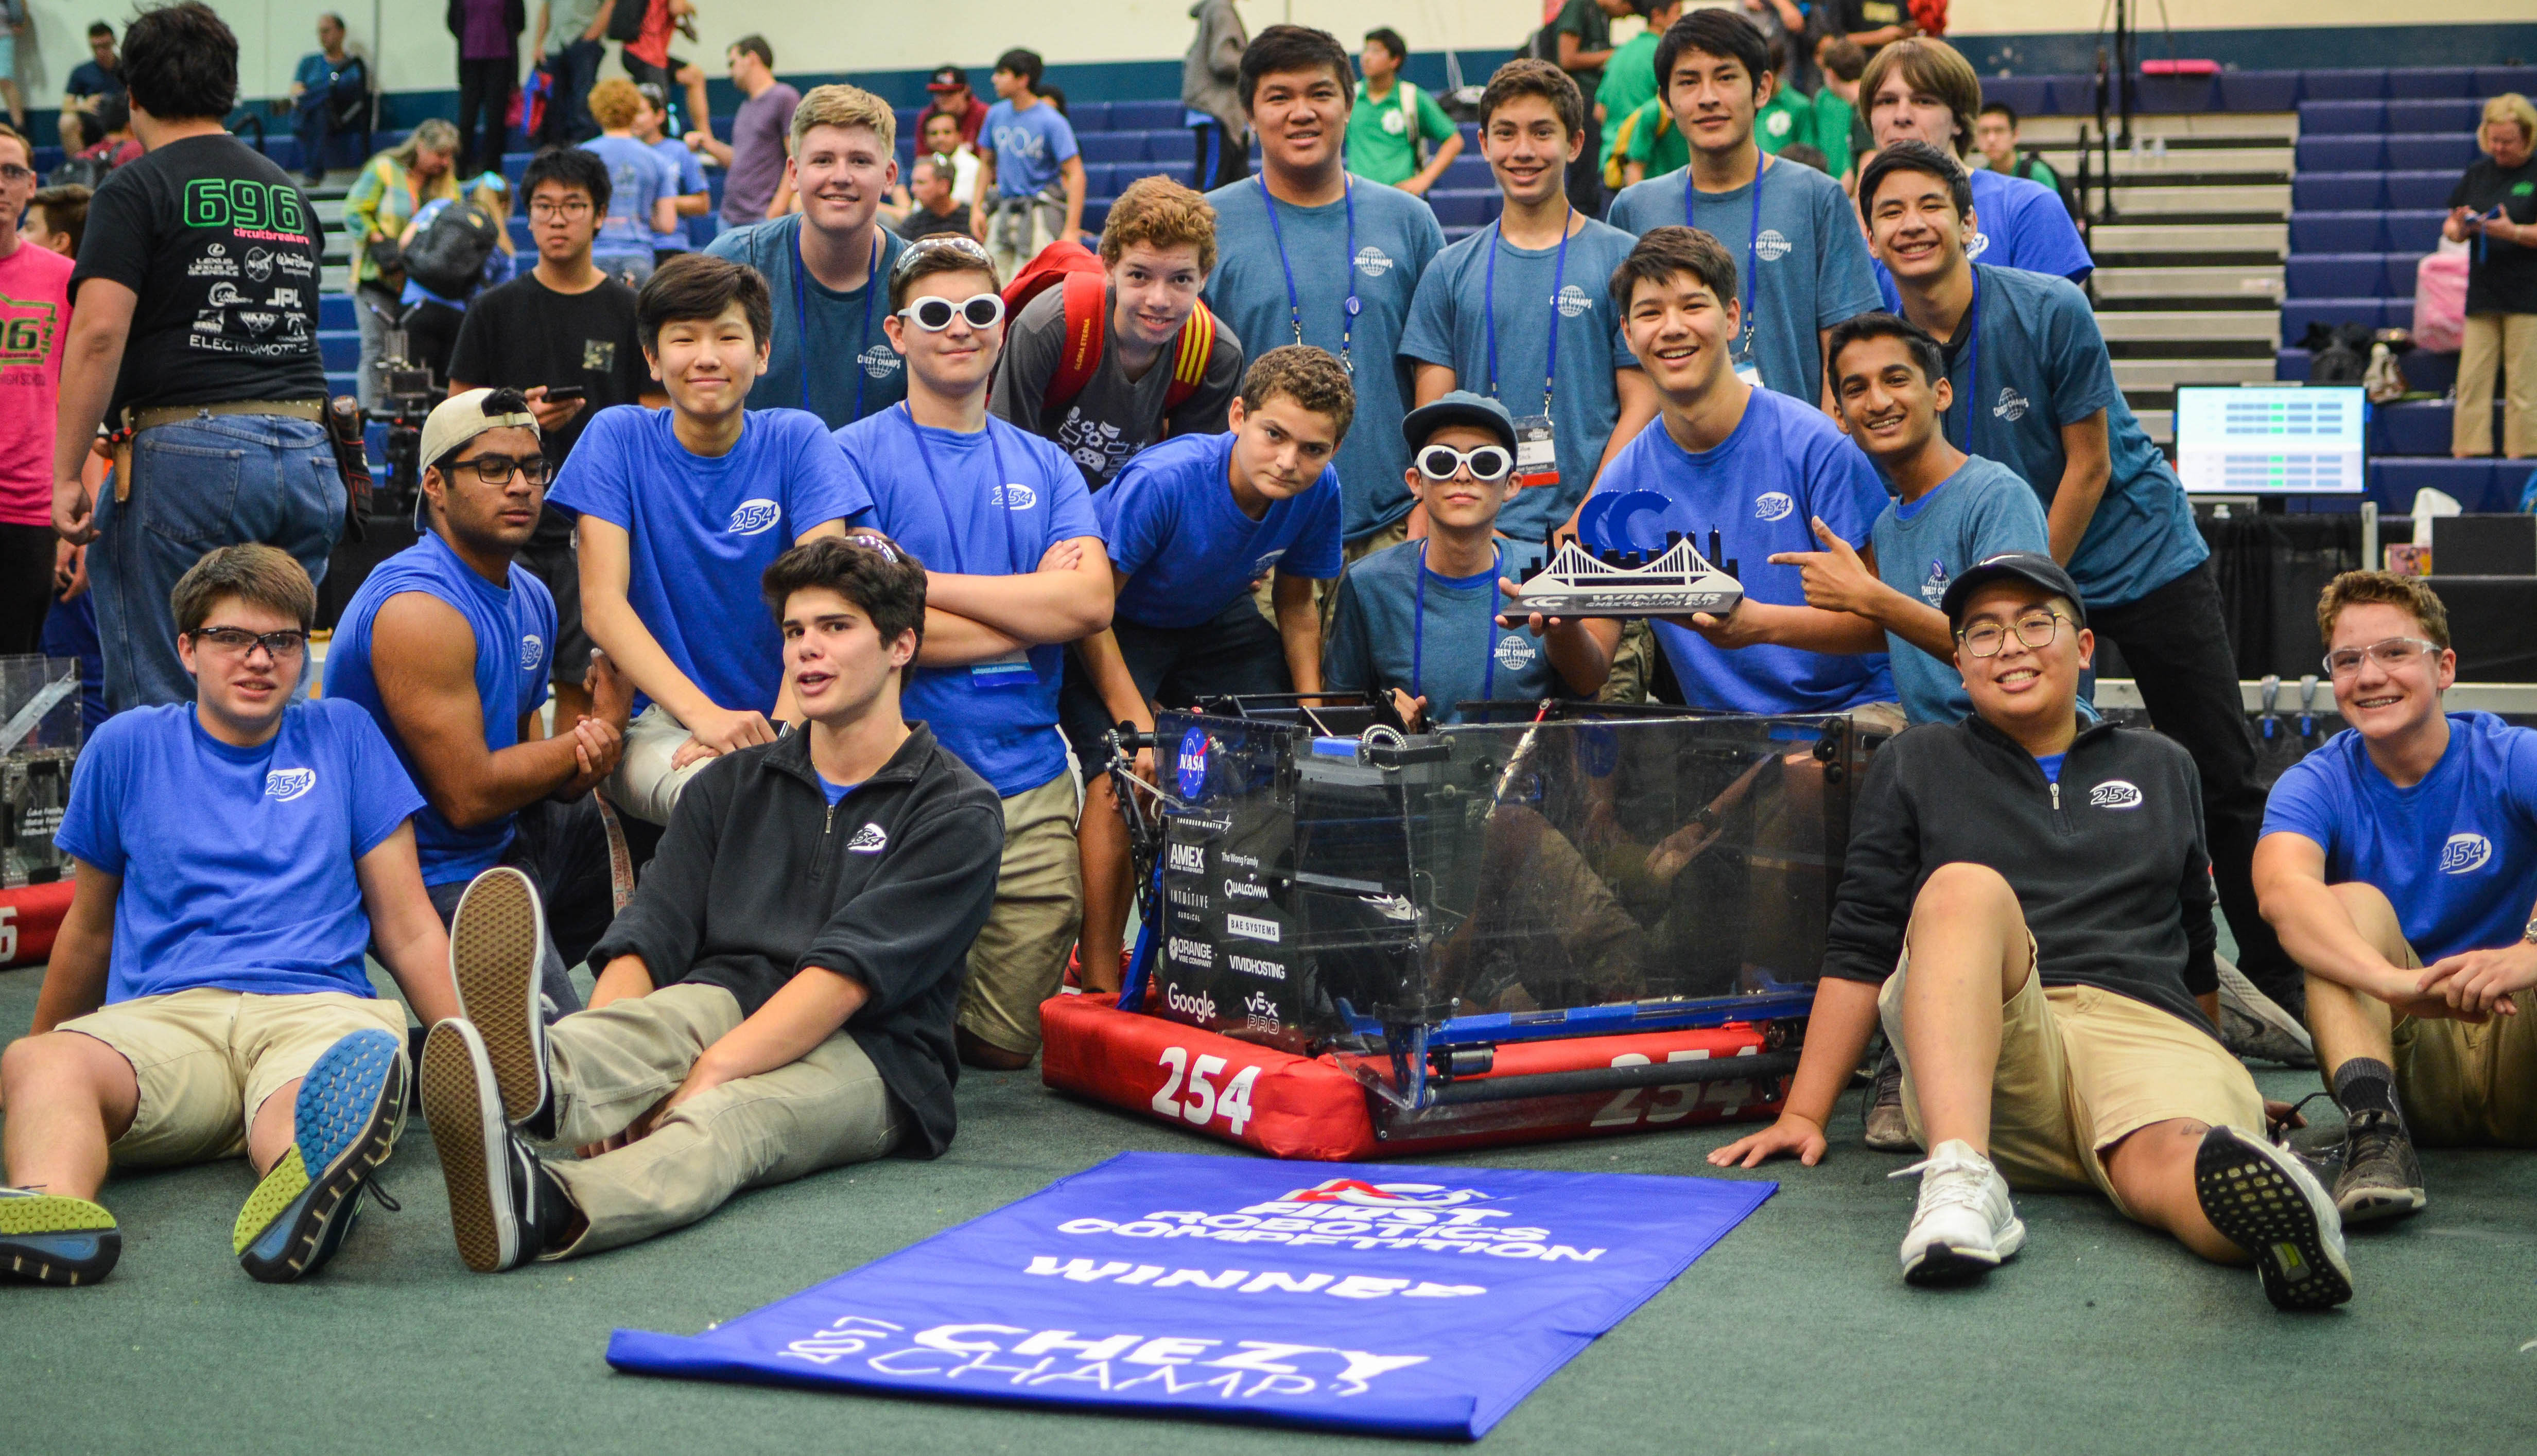
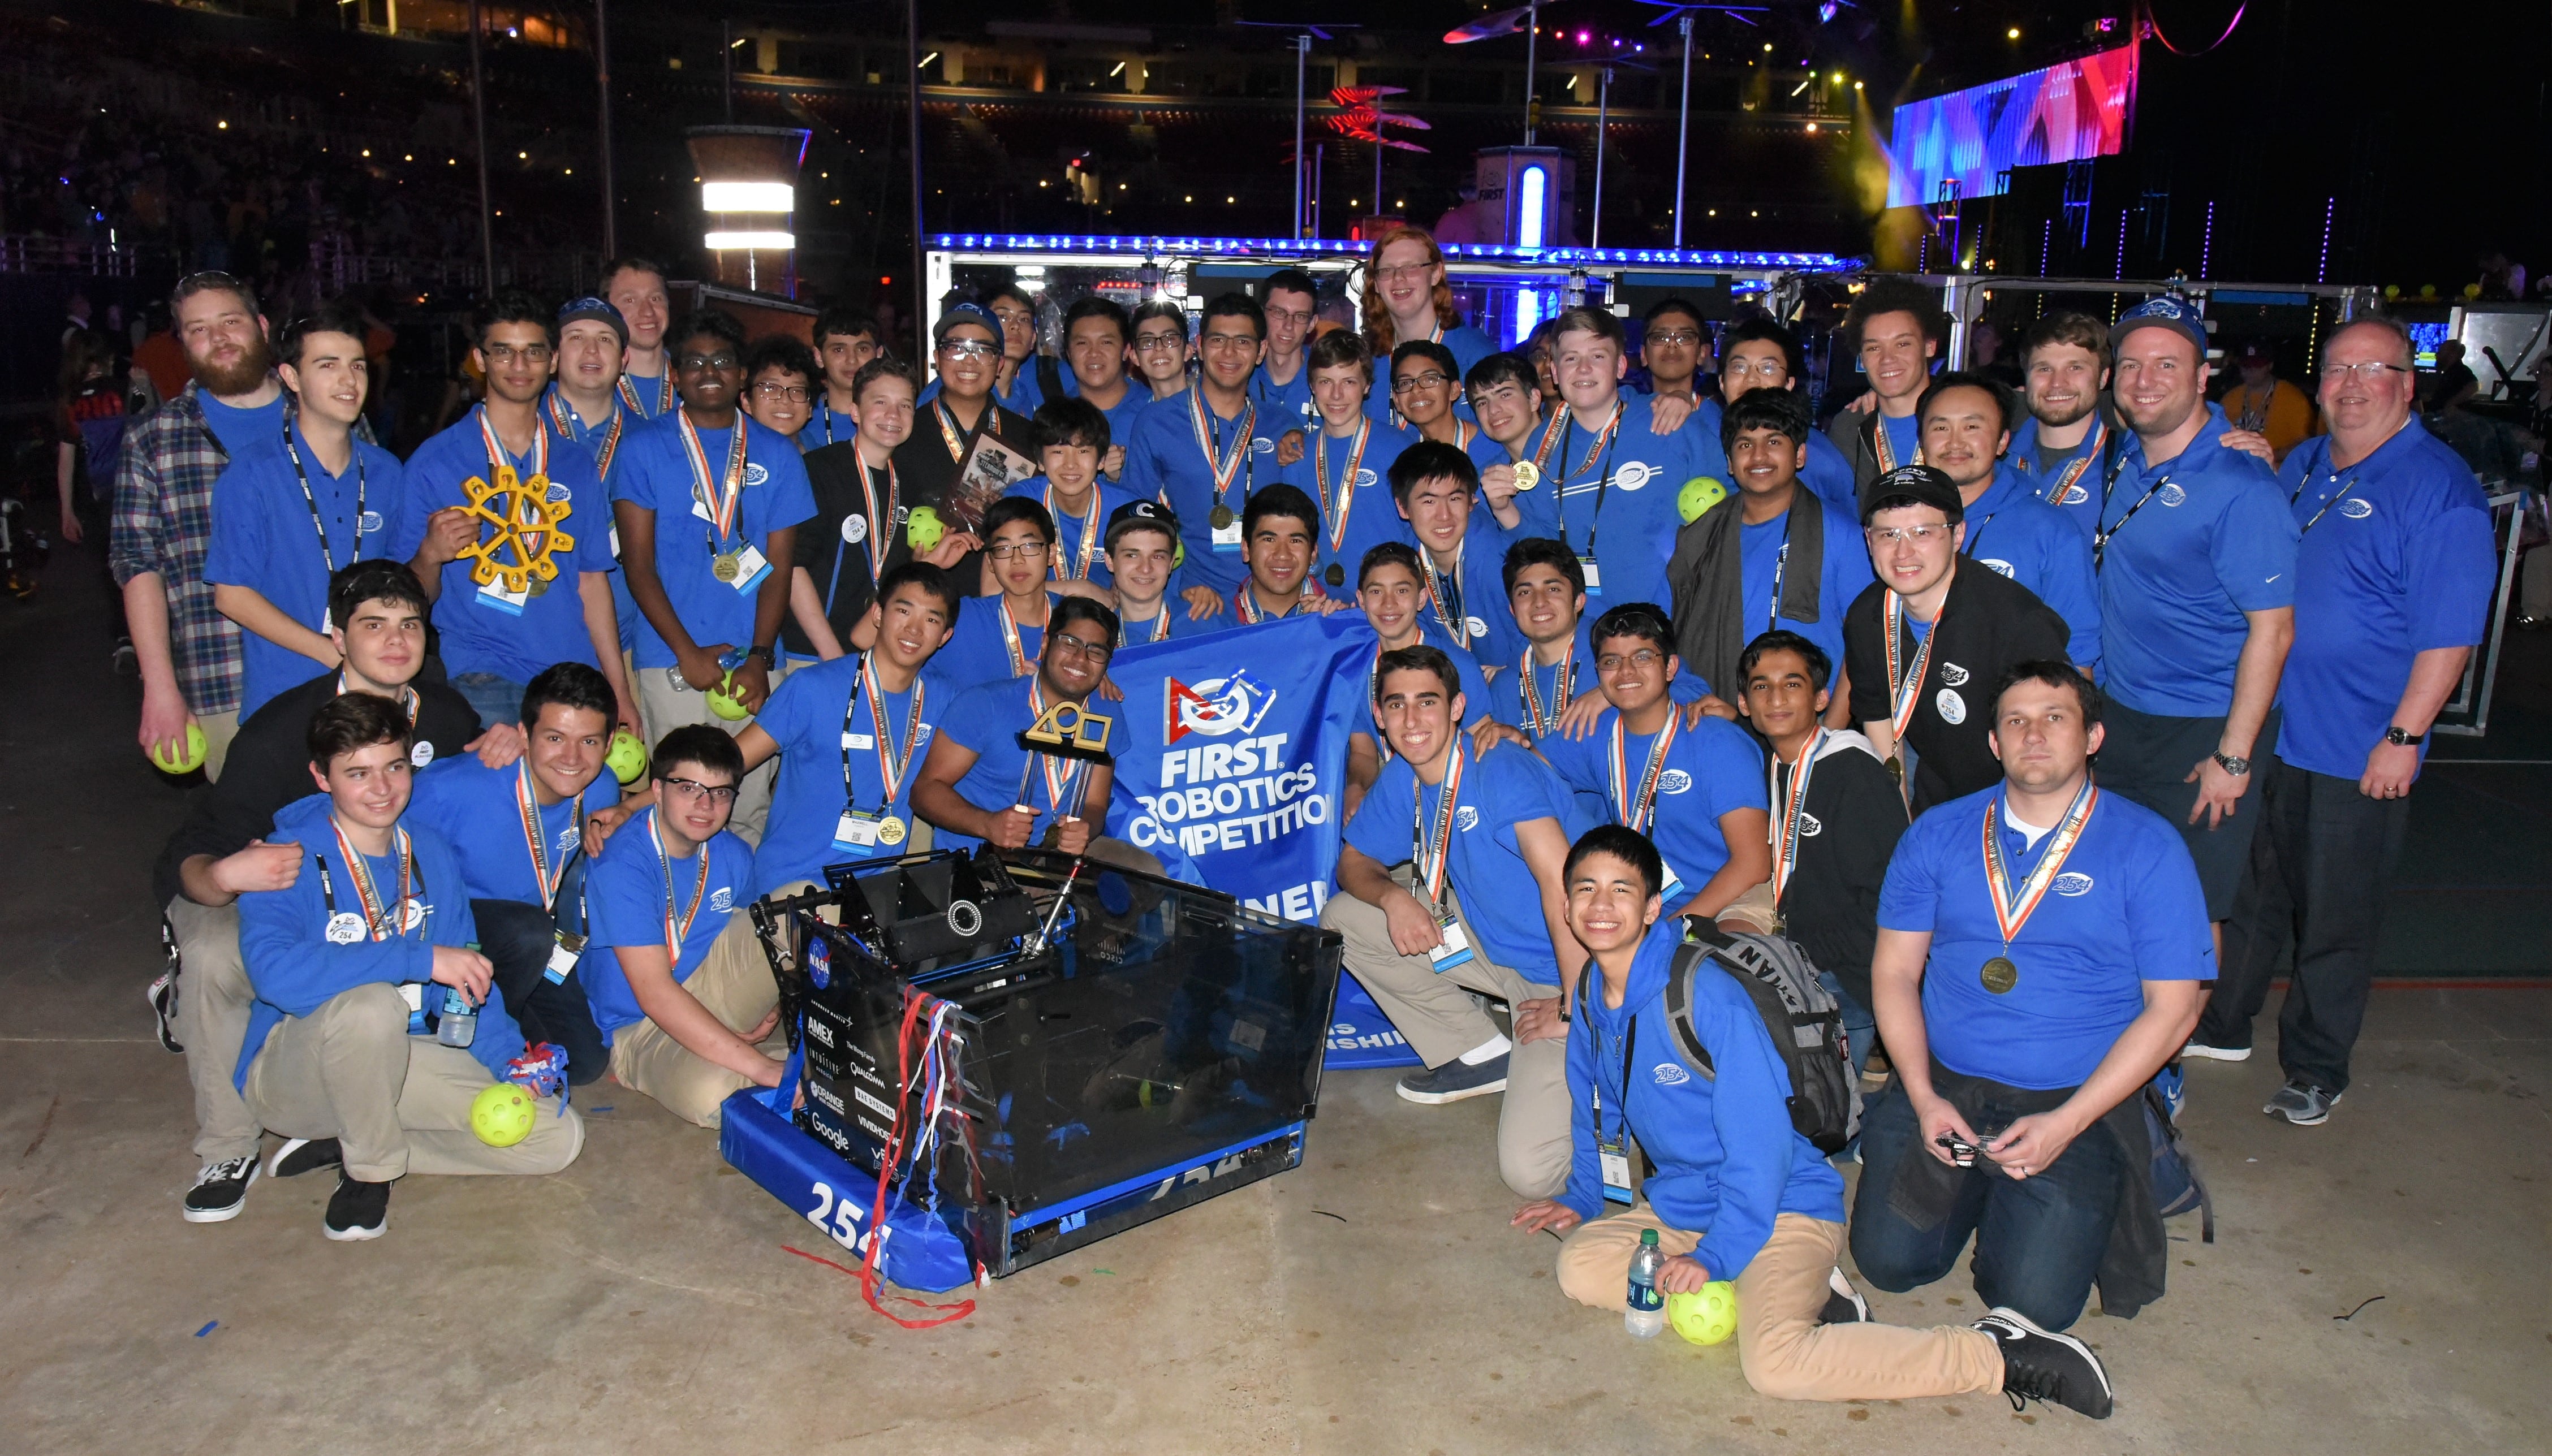
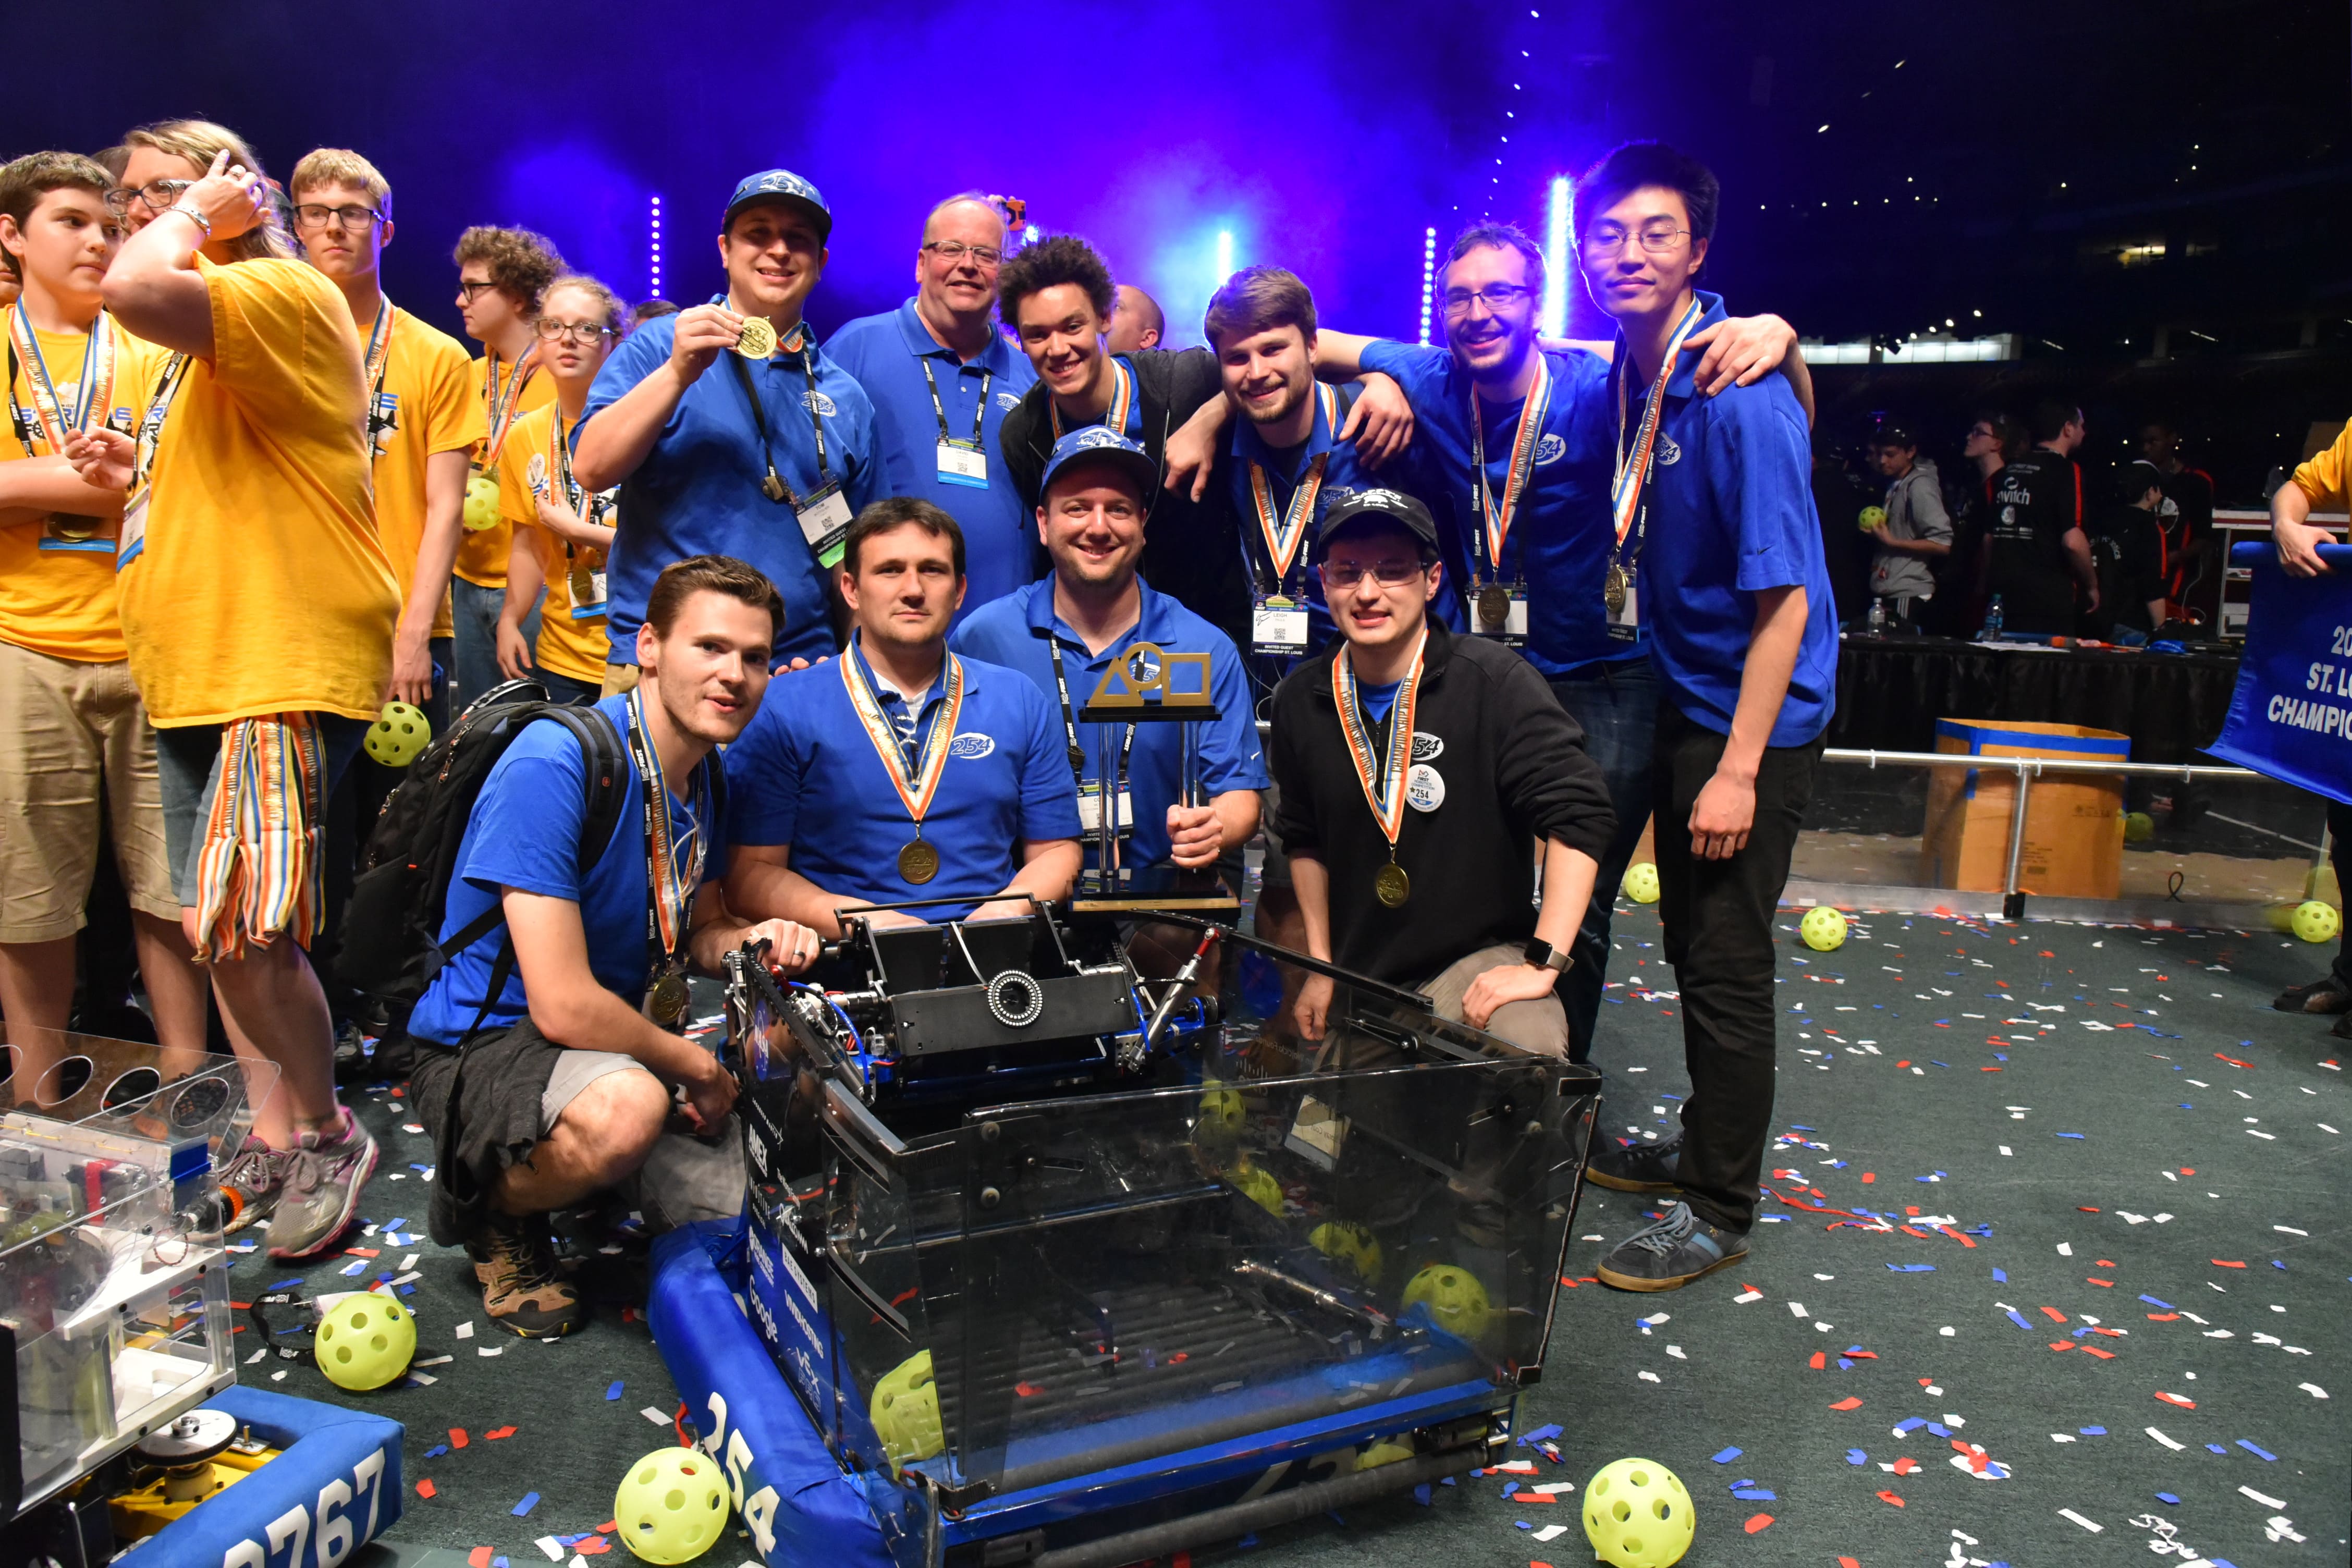
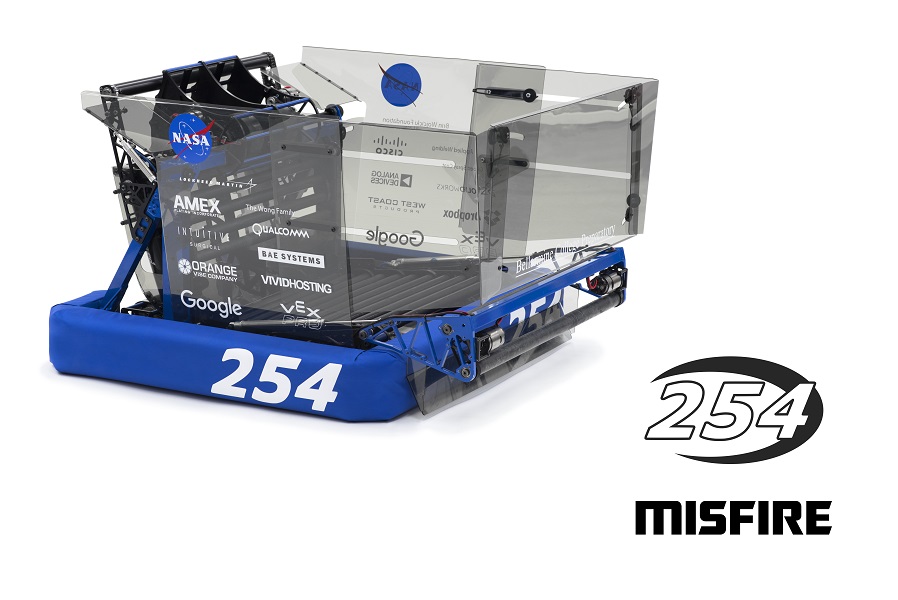
Team 254 Members pose for a picture with Misfire after winning at Chezy Champs 2017

Event Highlights

General Highlights

Check out this great highlight reel made by RoboSports Network (RSN)!

Exhibition Match

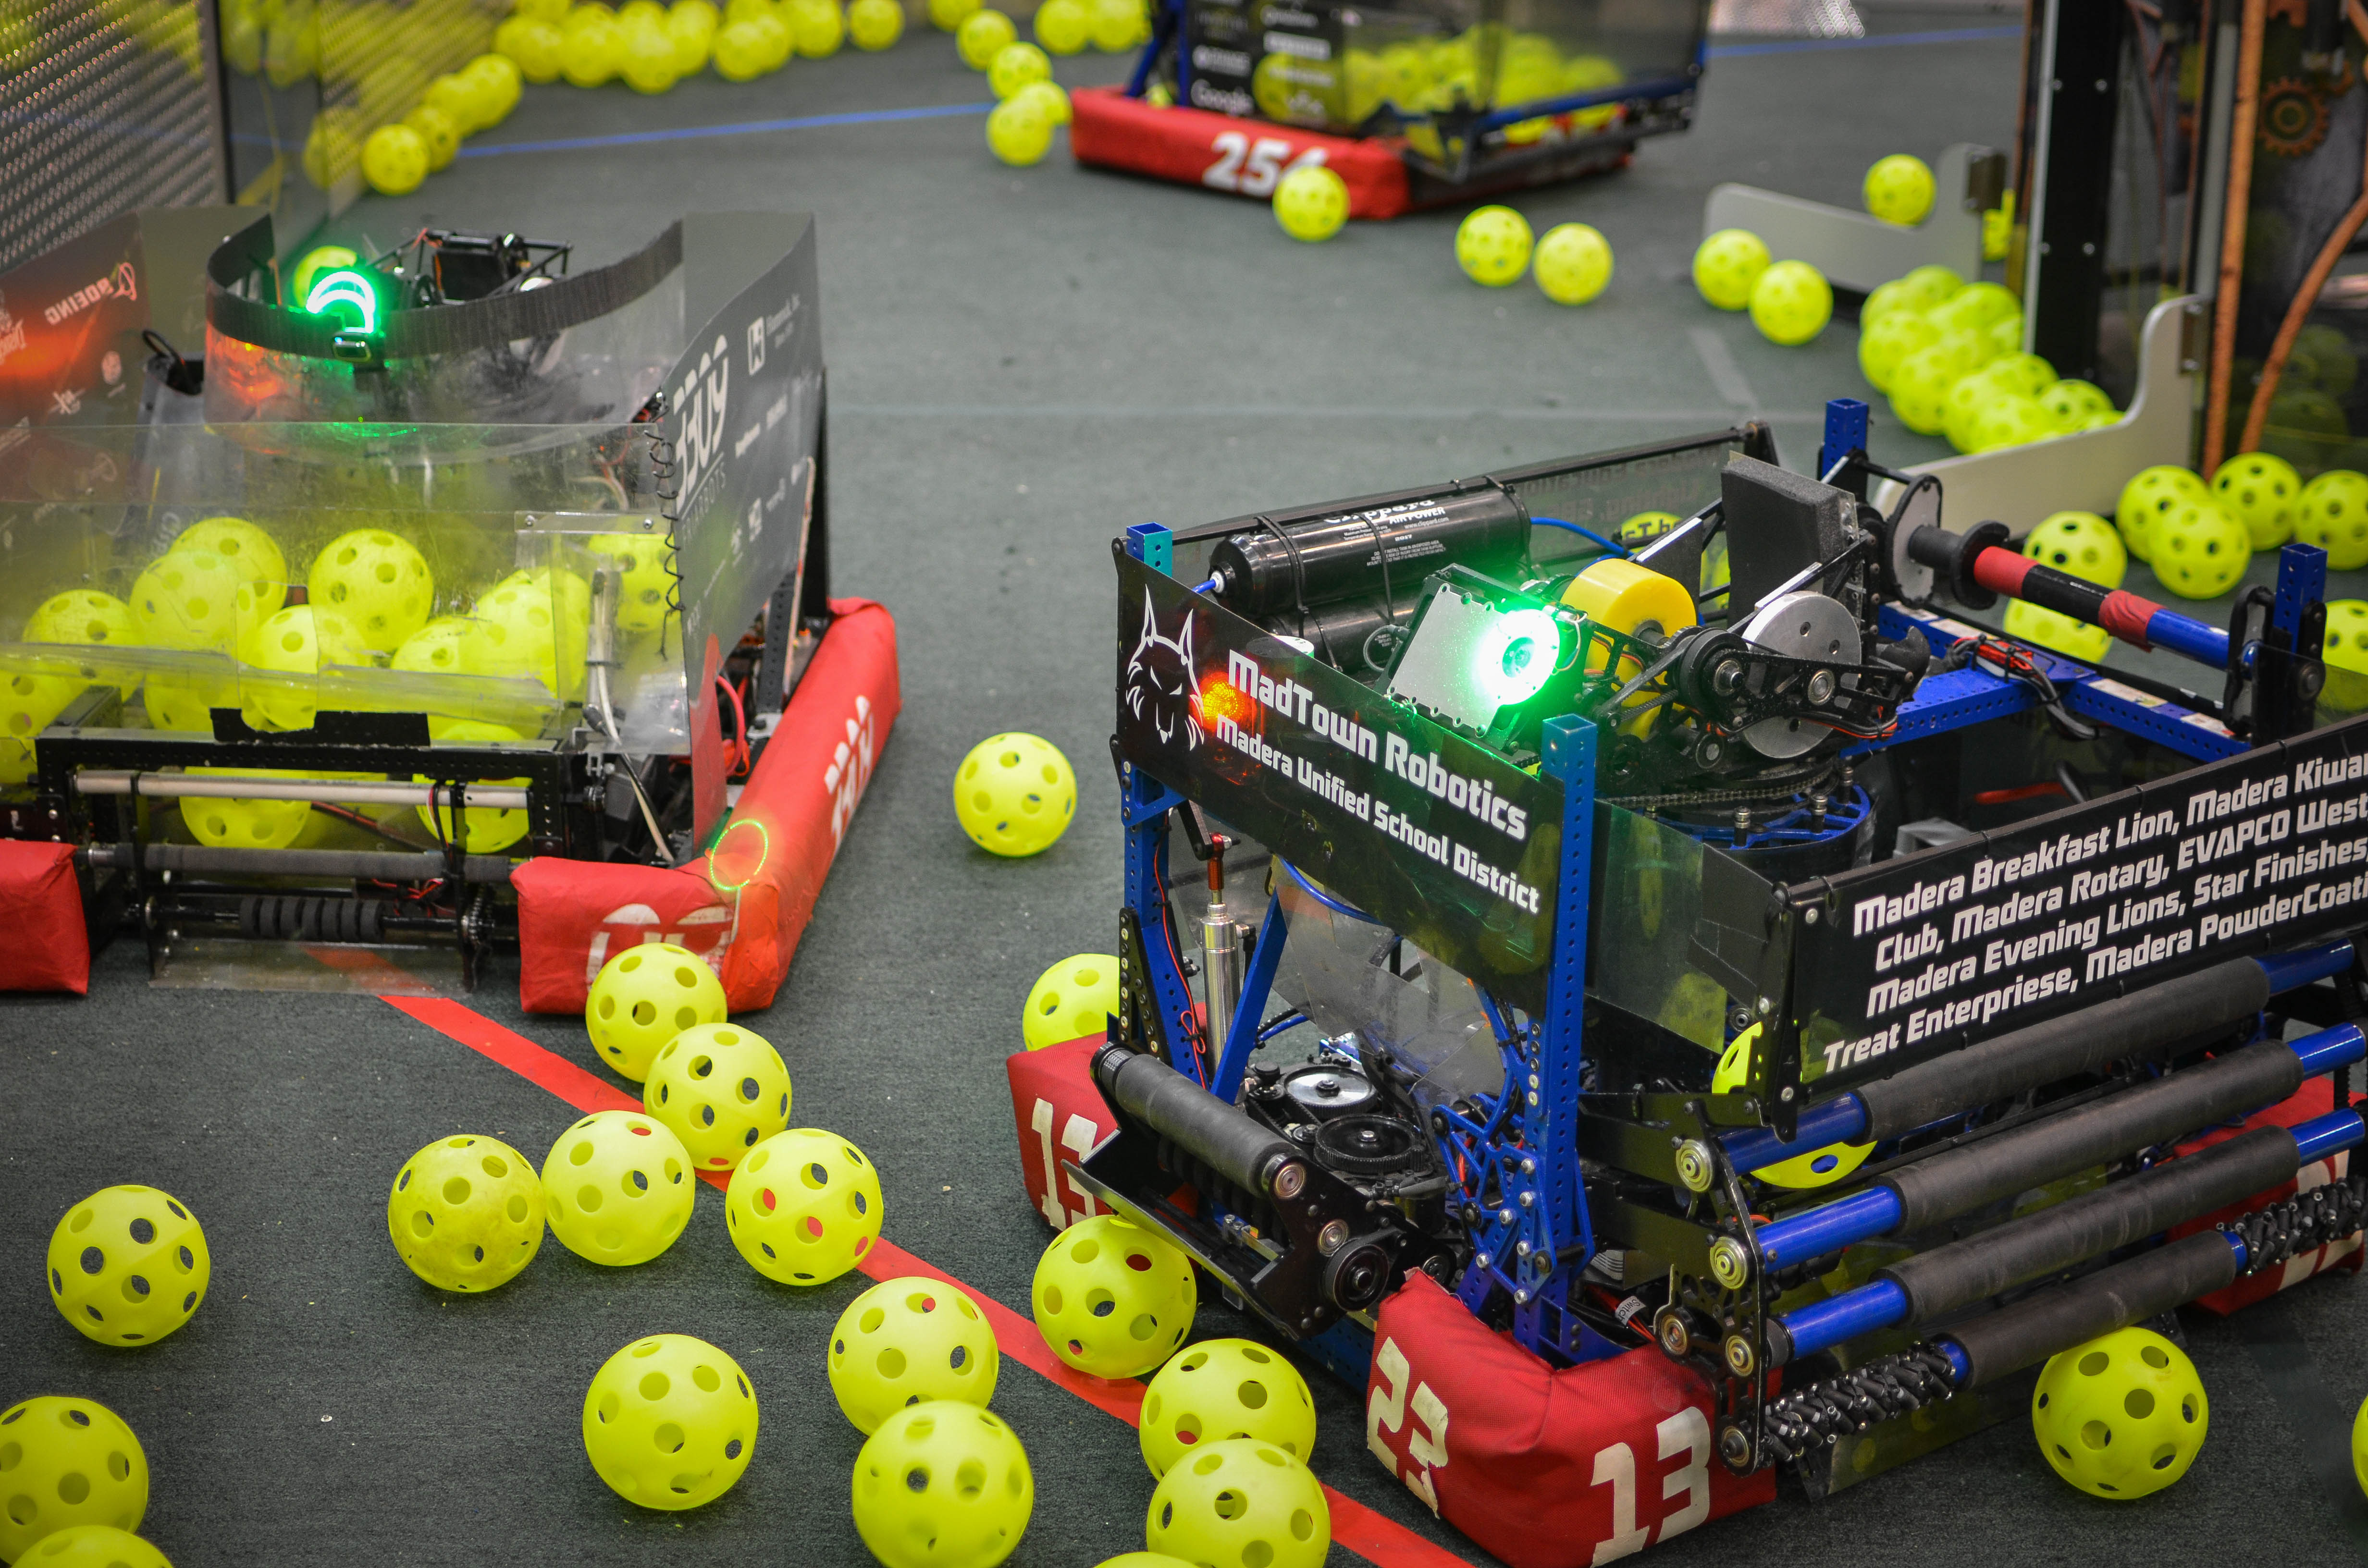
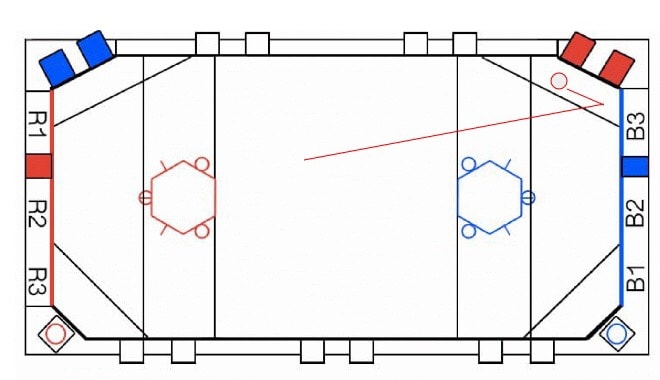
At the tournament, we hosted an exhilarating exhibition match, which included the several teams with highly skilled shooting robots. The standard rule for this match was that the only way to score points was to shoot fuel into each alliance’s respective boiler. The teams which participated in the exhibition match:

The Blue Alliance

  • Team 971 Spartan Robotics
  • Team 973 Greybots
  • Team 1678 Citrus Circuits

The Red Alliance

  • Team 254 The Cheesy Poofs
  • Team 1323 Madtown Robotics
  • Team 3309 Friarbots

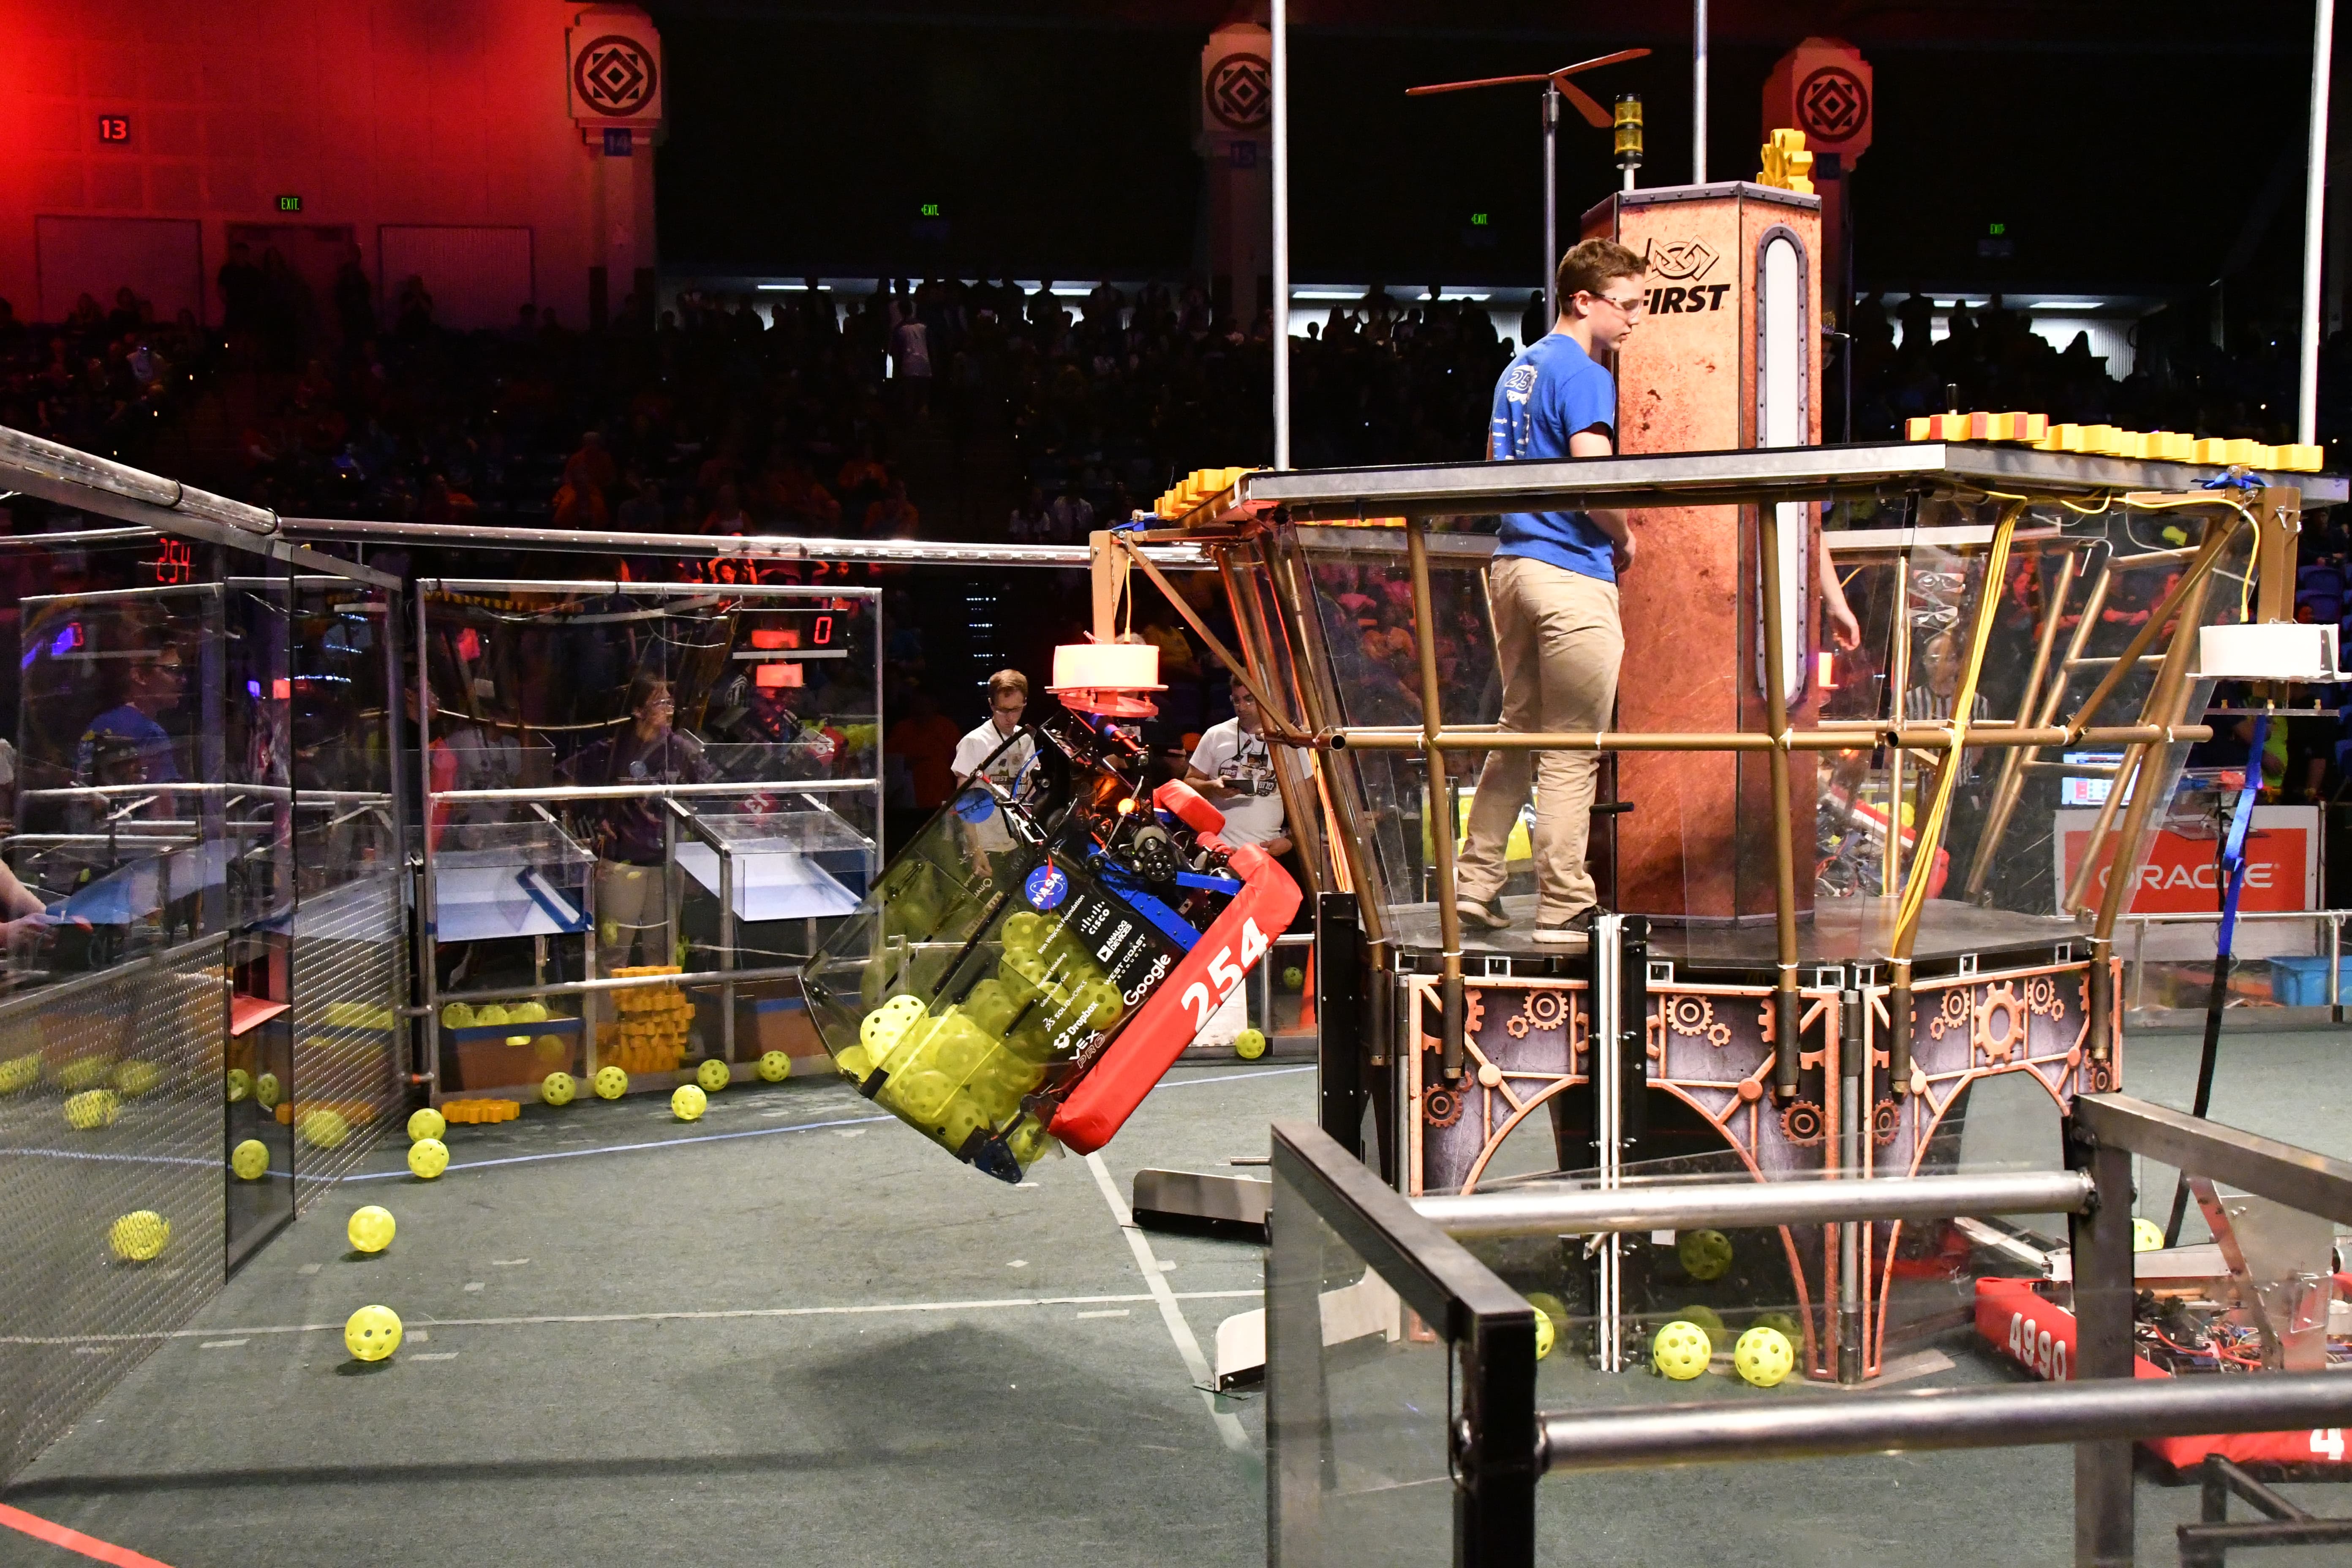
Team 1323, Team 3309, and Team 254 work together to gather fuel to shoot into the boiler

The Red Alliance started off with a significant lead by scoring 50 fuel balls into the boiler, making it an amazing show for the audience to see 3 robots scoring fuel into one boiler at once! Eventually, the Blue Alliance slowly started catching up with the Red Alliance by consistently scoring their collected fuel into their boiler. With a minute left in the match, the our friends from Team 973 displayed their true defensive skill by blocking Team 1323’s path across the field. Though the Blue Alliance’s efforts were equal to that of the Red Alliance, the Blue Alliance was unable to keep up with the pace of the Red Alliance. After the great efforts shown by both alliances, the Red Alliance came out to be the winner scoring 203 kPa compared to the 97 kPa scored by the Blue alliance. The Exhibition Match Video can be viewed here.

A Special Thanks

Chezy Champs was very special this year due to the efforts of so many people and organizations. Team 254 would like to thank our friends from RoboSports Network (RSN) for providing our audience with such a great analysis of each match and team at the tournament. We would also like to thank all the volunteers, who helped make Chezy Champs possible. It was truly an incredible experience to host an offseason tournament attended by so many talented teams, even those who chose to attend from out of state, and to make new friends and catch up with old ones too!

Robot Performance

Throughout the qualification matches, we encountered a few mechanical problems with our gear grabber, hopper, and drivetrain and a few problems with Misfire’s autonomous performance. After some careful observation, we realized that our gear grabber’s knife-edge was worn out, so we replaced it with a new piece of polycarb. Our stationary hopper panel kept colliding with the field hoppers, which tore our hopper wall. We replaced the broken hopper panel to solve this problem. We also noticed a crimp lodged between our chain and sprocket on our drivetrain, so we removed it to make our drivetrain function normally. Overtime, our autonomous performance improved after our mechanical changes. Thus, we were able to seed first for alliance selection after having a qualification match record of 7 wins and 3 losses.
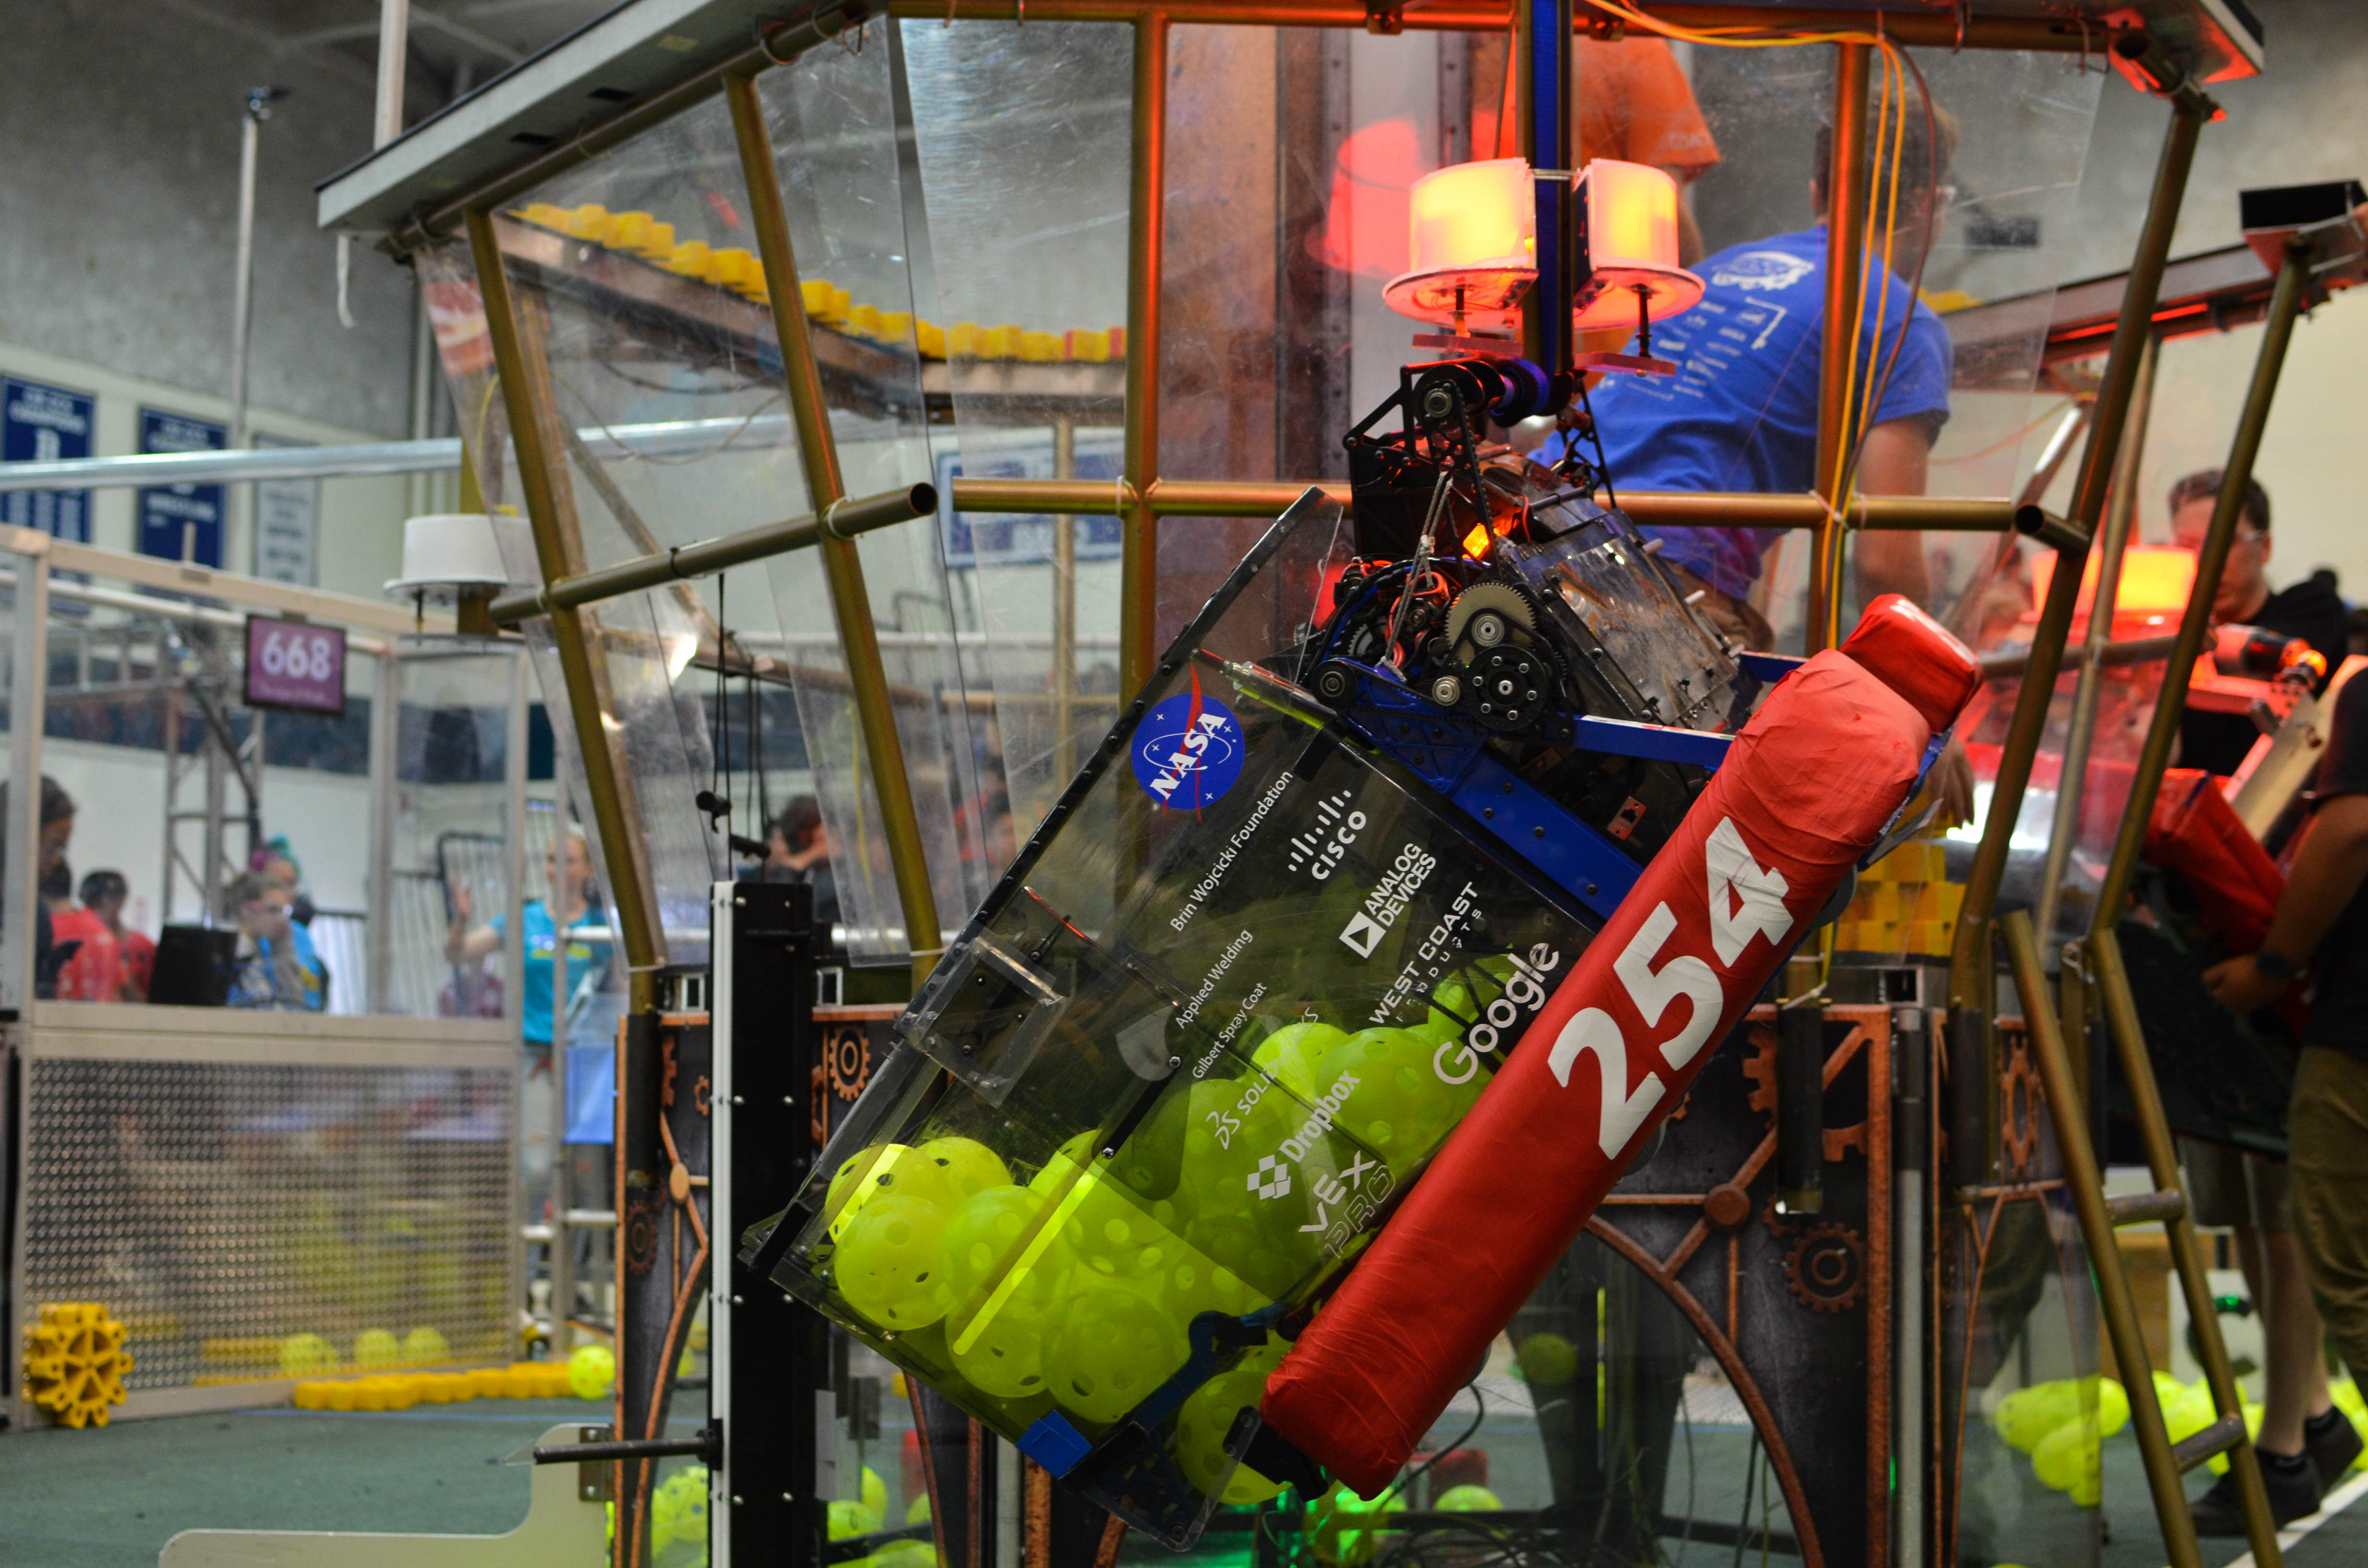
Misfire successfully hangs within the last few seconds of a Qualification Match

During elims, we faced some fierce competition during our Semifinal and Final Matches. We ended up having to compete in a third tiebreaker match in semifinals and finals. In Semifinals Match 2, the opposing alliance of Team 973 Greybots, Team 1538 The Holy Cows, Team 604 Quixilver, and Team 2135 Presentation Invasion, scored a large amount of kPa during auton and kept their lead up by activating all 4 rotors! In Finals Match 2, the opposing alliance of Team 1323 Madtown Robotics, Team 3309 Friarbots, Team 5026 Iron Panthers, and Team 2073 EagleForce, displayed their true skill, by keeping a consistent lead, from the start of the match. By the end of our elimination matches, we won all of our tie breaking matches, allowing us to win the event with our alliance. We wouldn’t have been able to accomplish such a victory if it weren’t for our amazing alliance partners - Team 1011 CRUSH, Team 696 Circuit Breakers, and Team 5104 BreakerBots.
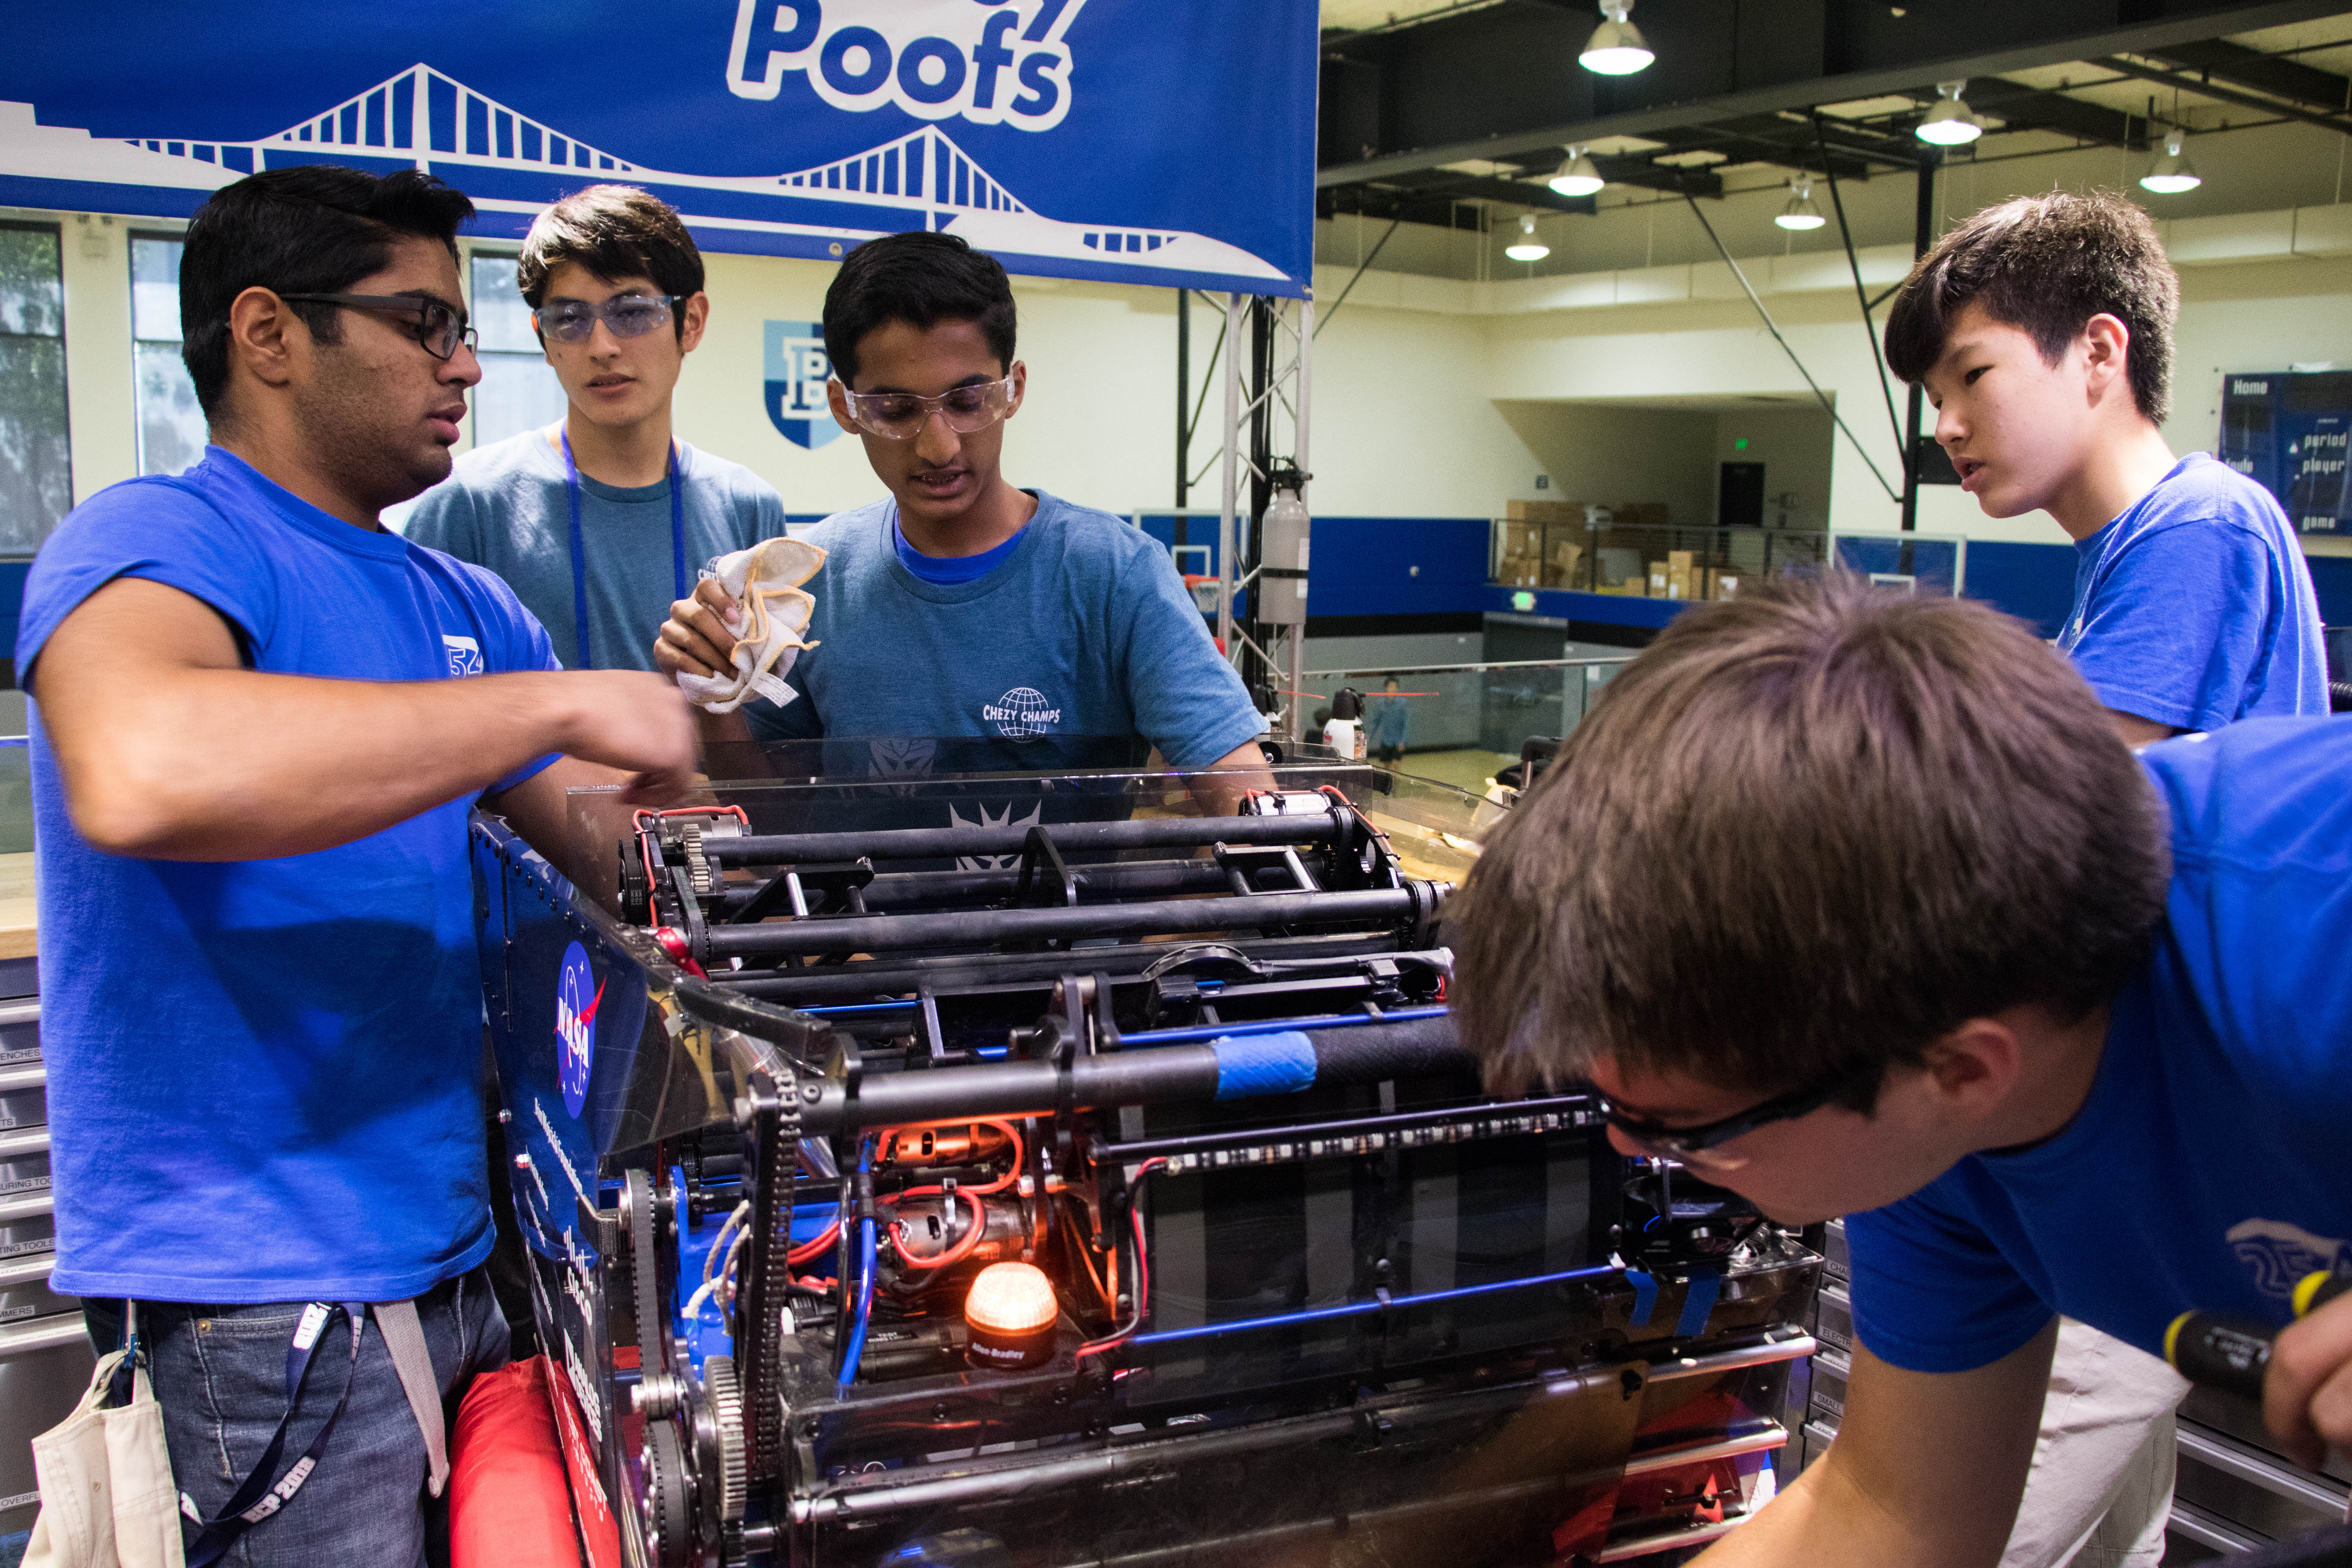
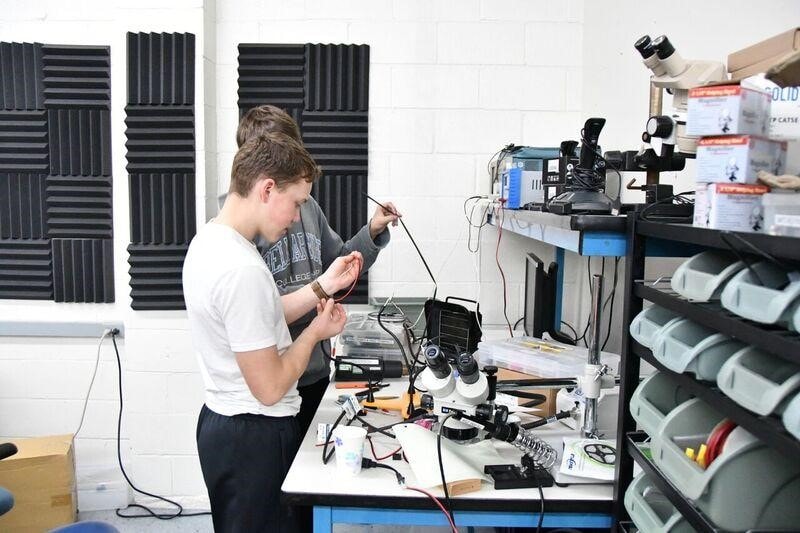
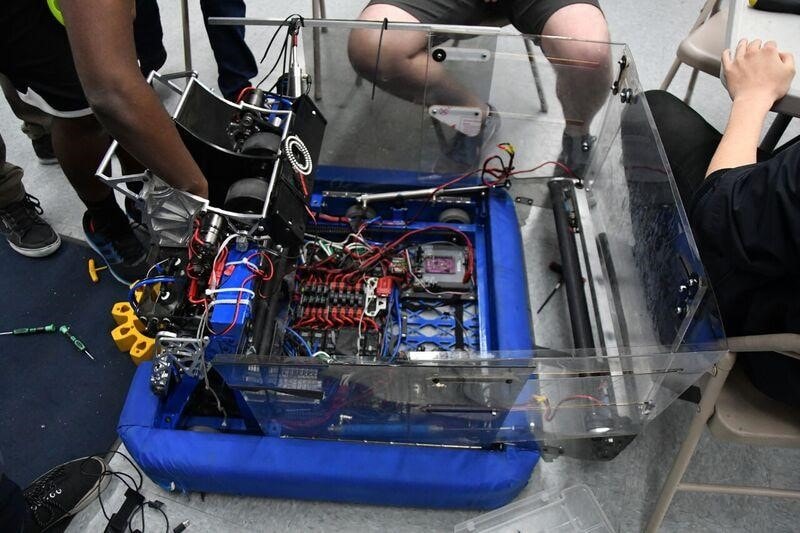
Members of the Team 254 Pit Crew repair Misfire before an upcoming Finals Match
Festival of Champions

2017 FRC Build Season

2017 FRC Class of FIRST Champions

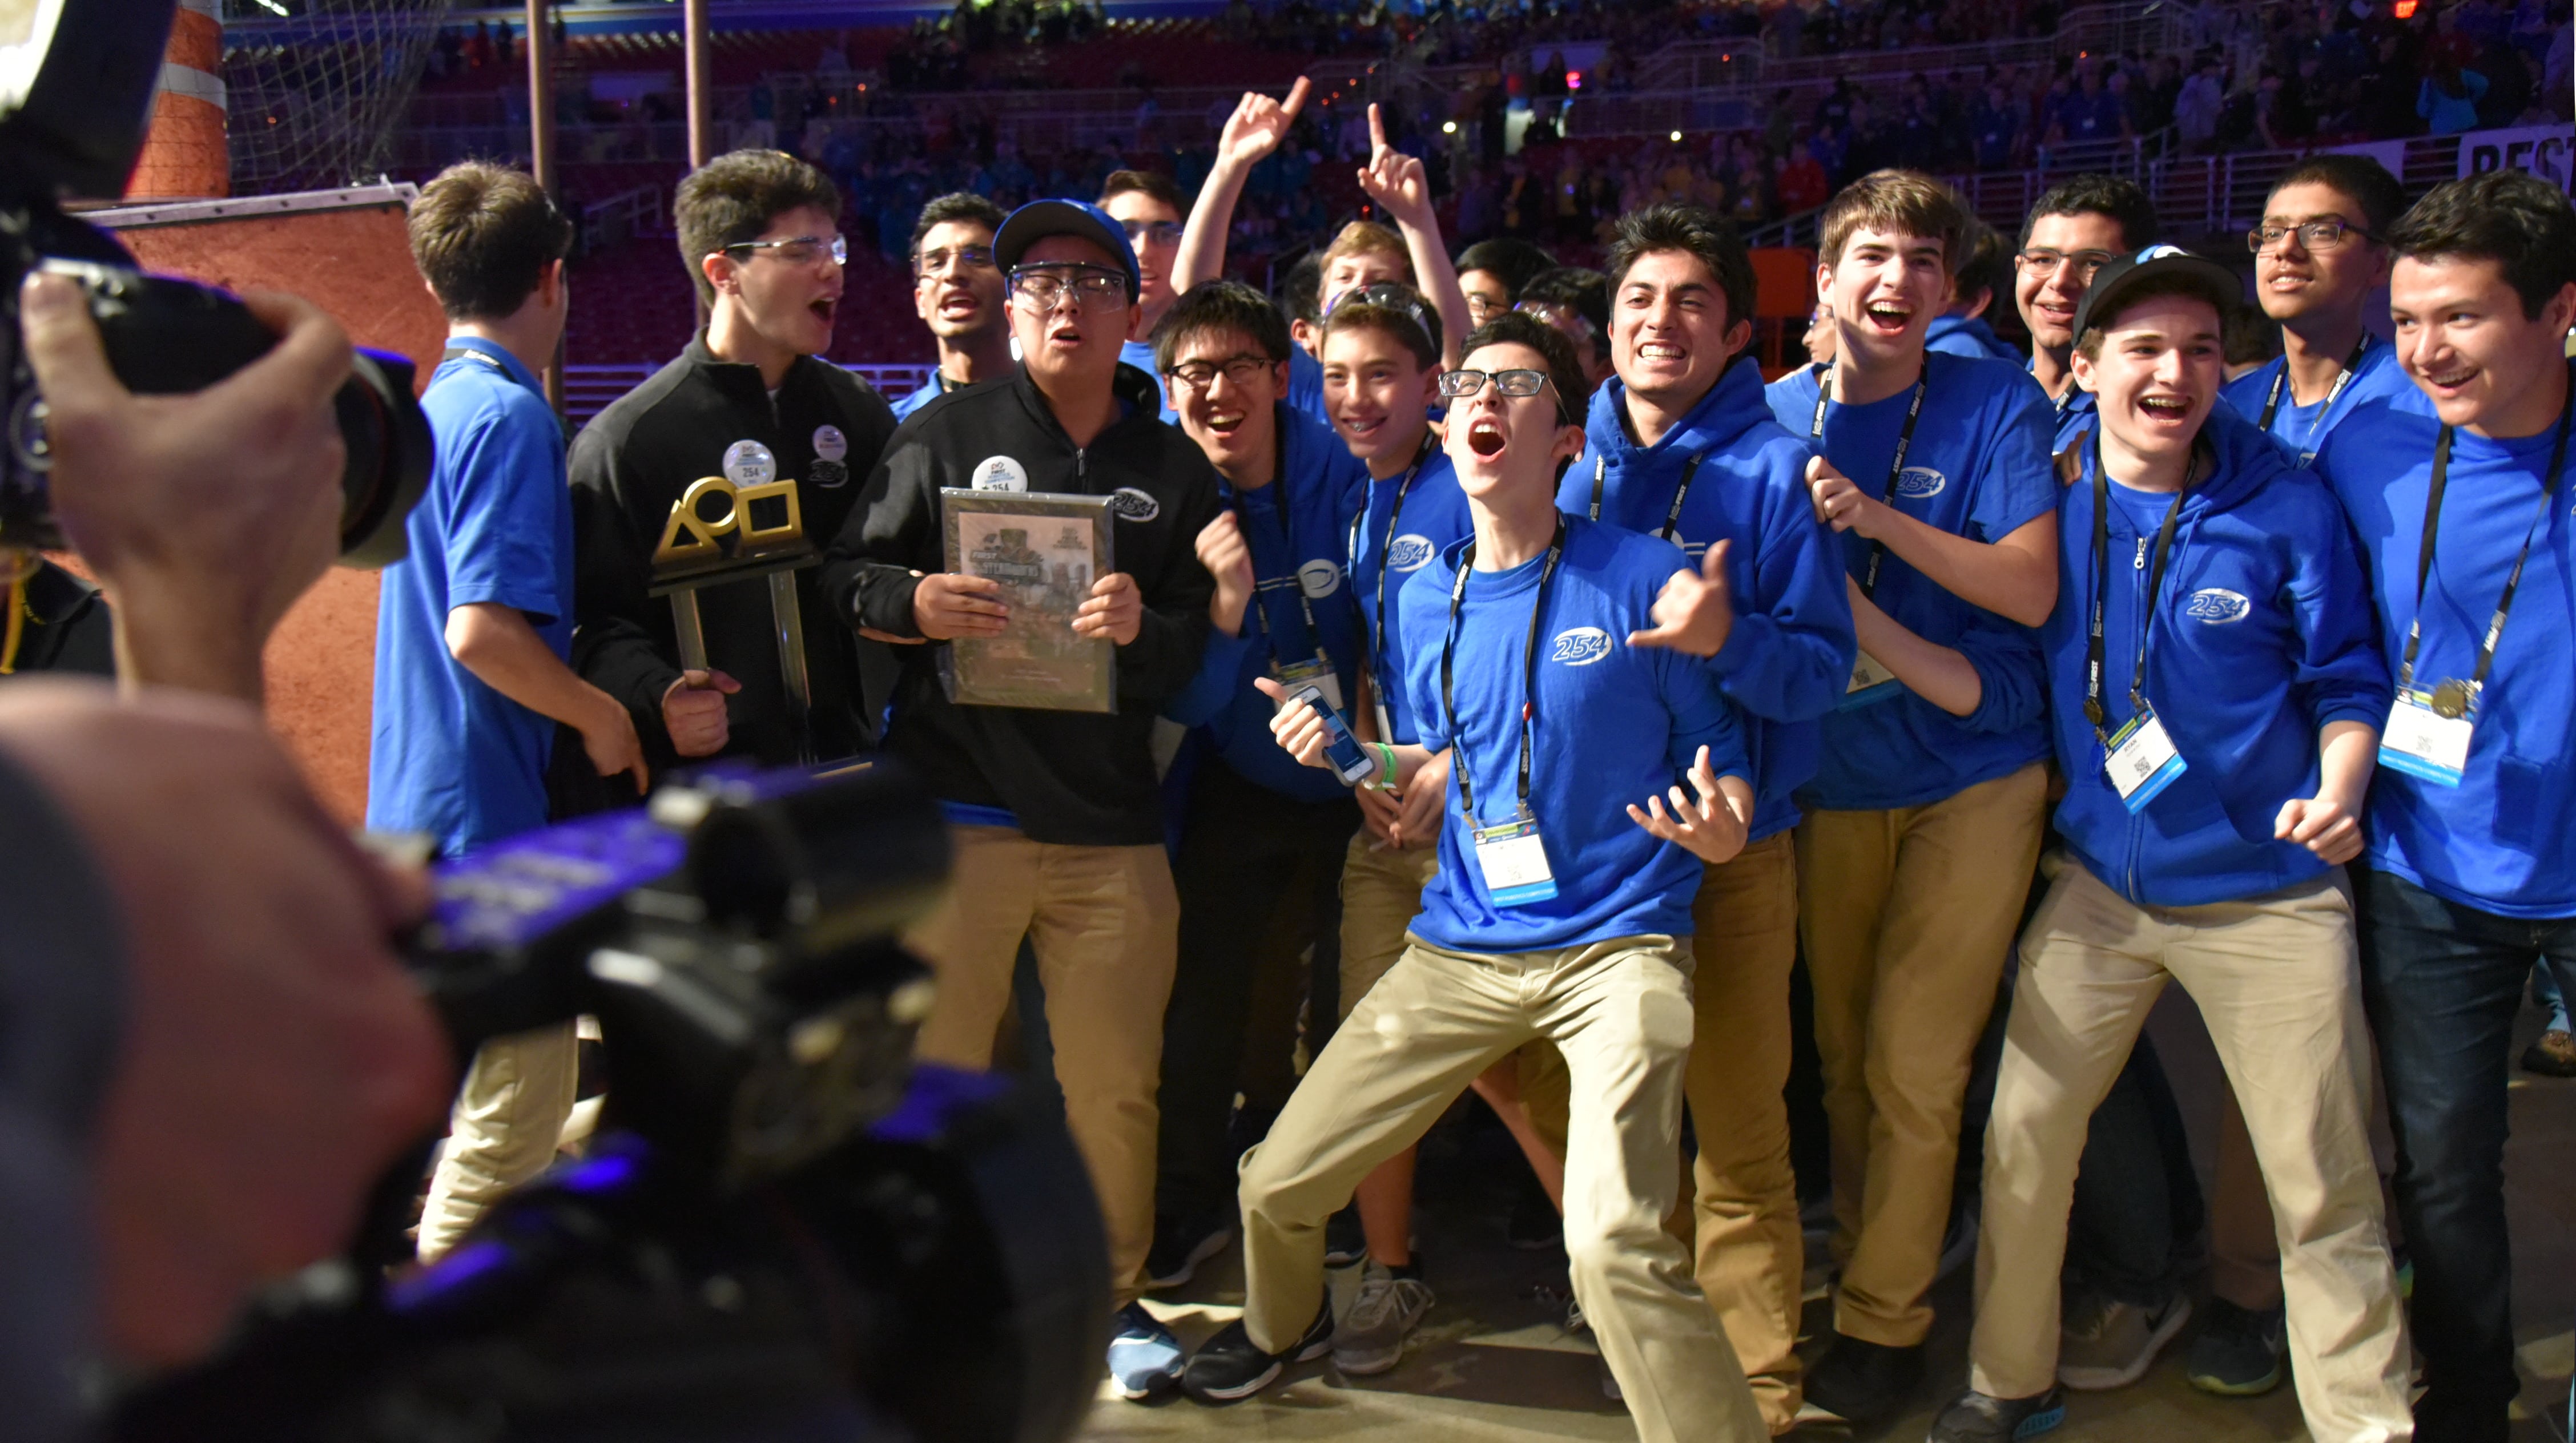
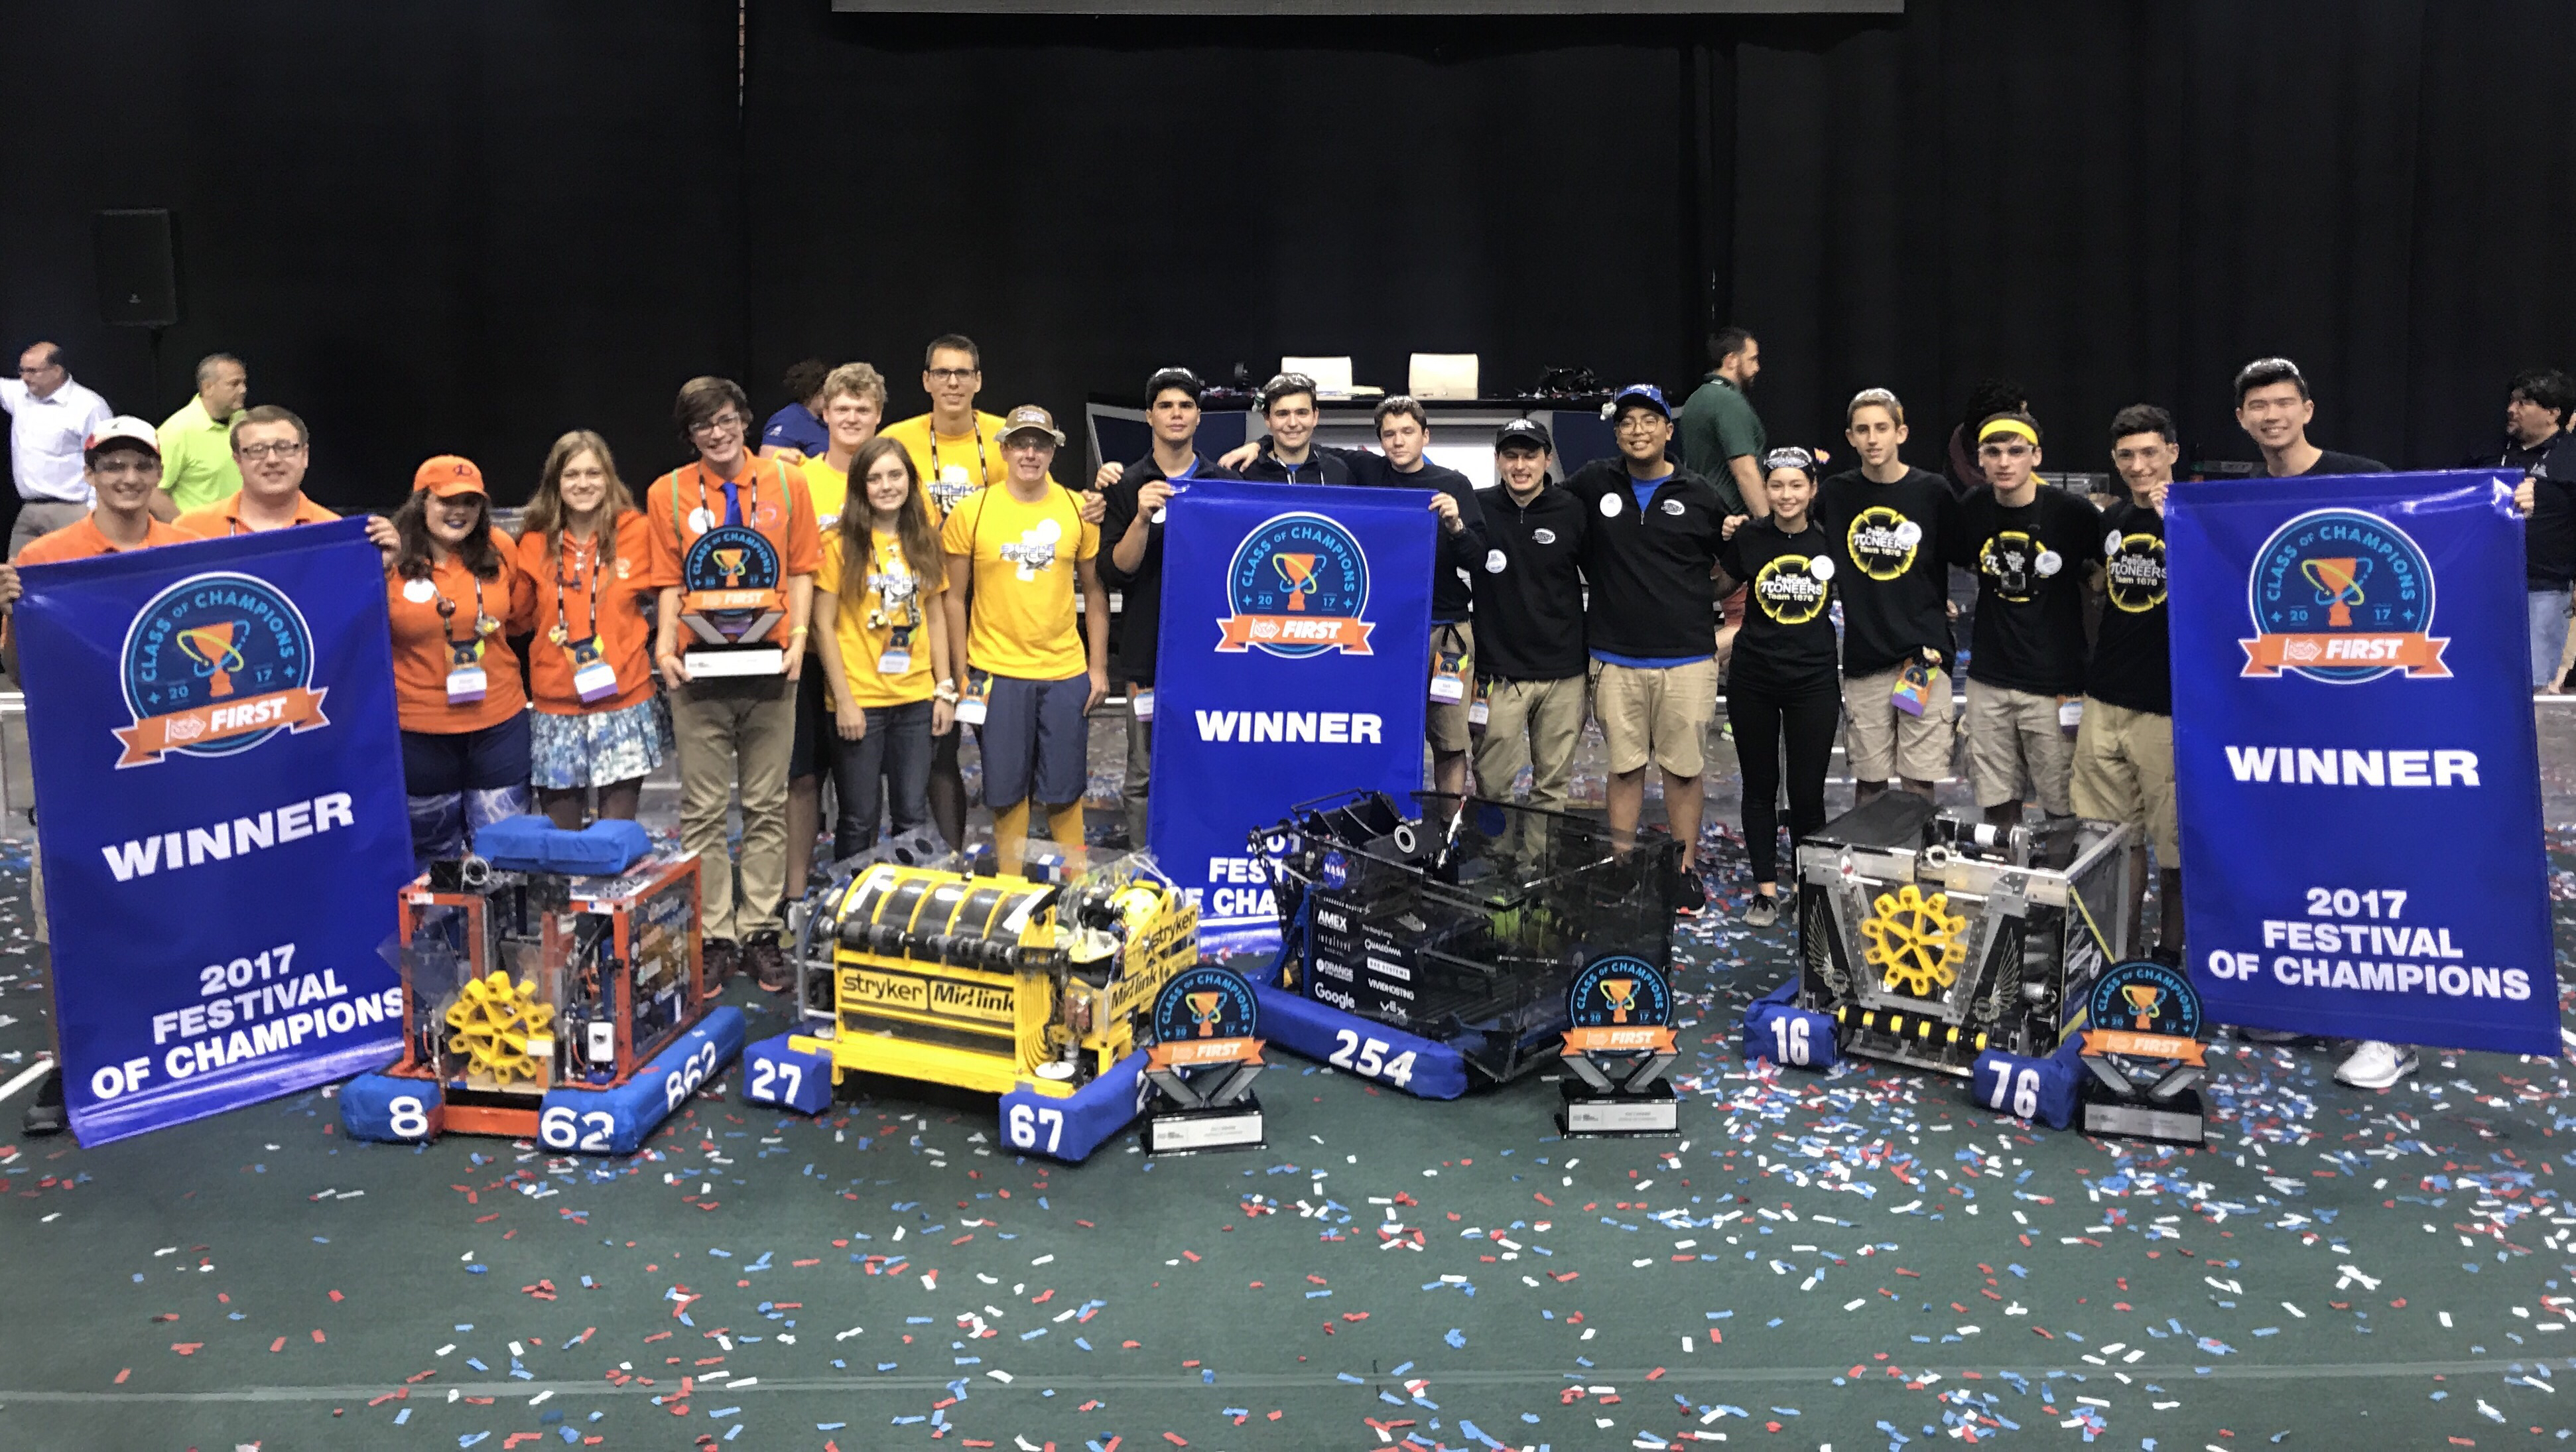
Recently, we attended the first ever FIRST Festival of Champions in Manchester, NH. After winning the St. Louis Championship with our extraordinary alliance partners, we faced the Houston Championship winning alliance in an intense series of 5 matches. Alongside Team 2767 Stryke Force, Team 862 Lightning Robotics, and Team 1676 The Pascack PI-oneers, we were able to win the Festival of Champions Event. We enjoyed a tour of DEKA and a great potluck at Dean Kamen’s home. We would like to say thank you to FIRST for giving us the amazing opportunity to participate in this event!

“Thanks to the phenomenal performance by our alliance partners!”

Championship Matches

In the most intense games we’ve played all season, the Houston alliance won the first two matches. Our alliance won the third and fourth to stay in the game. In Match 4, our alliance partners helped us win against the Houston alliance by a margin of only 16 points. In the final match, our alliance capped a great season with one last win. We won the match, and the festival championship, setting a record high score for this year's game of 588. We’ll let the video speak for itself, as our last finals match was certainly one of Team 254’s best performance of the season.

We would like to honor our alliance partners because of how far we all came, from St. Louis to Festival of Champions. We would also like to thank Team 973 Greybots, Team 5499 The Bay Orangutans, Team 1011 CRUSH, and Team 2928 Viking Robotics from the Houston Alliance for setting the bar high and making all our matches an intense, and great experience. We’re excited to meet other FRC teams at our annual offseason event, Chezy Champs, and to kick off next year’s season!

2017 World Champions!

2017 FRC Build SeasonTournaments

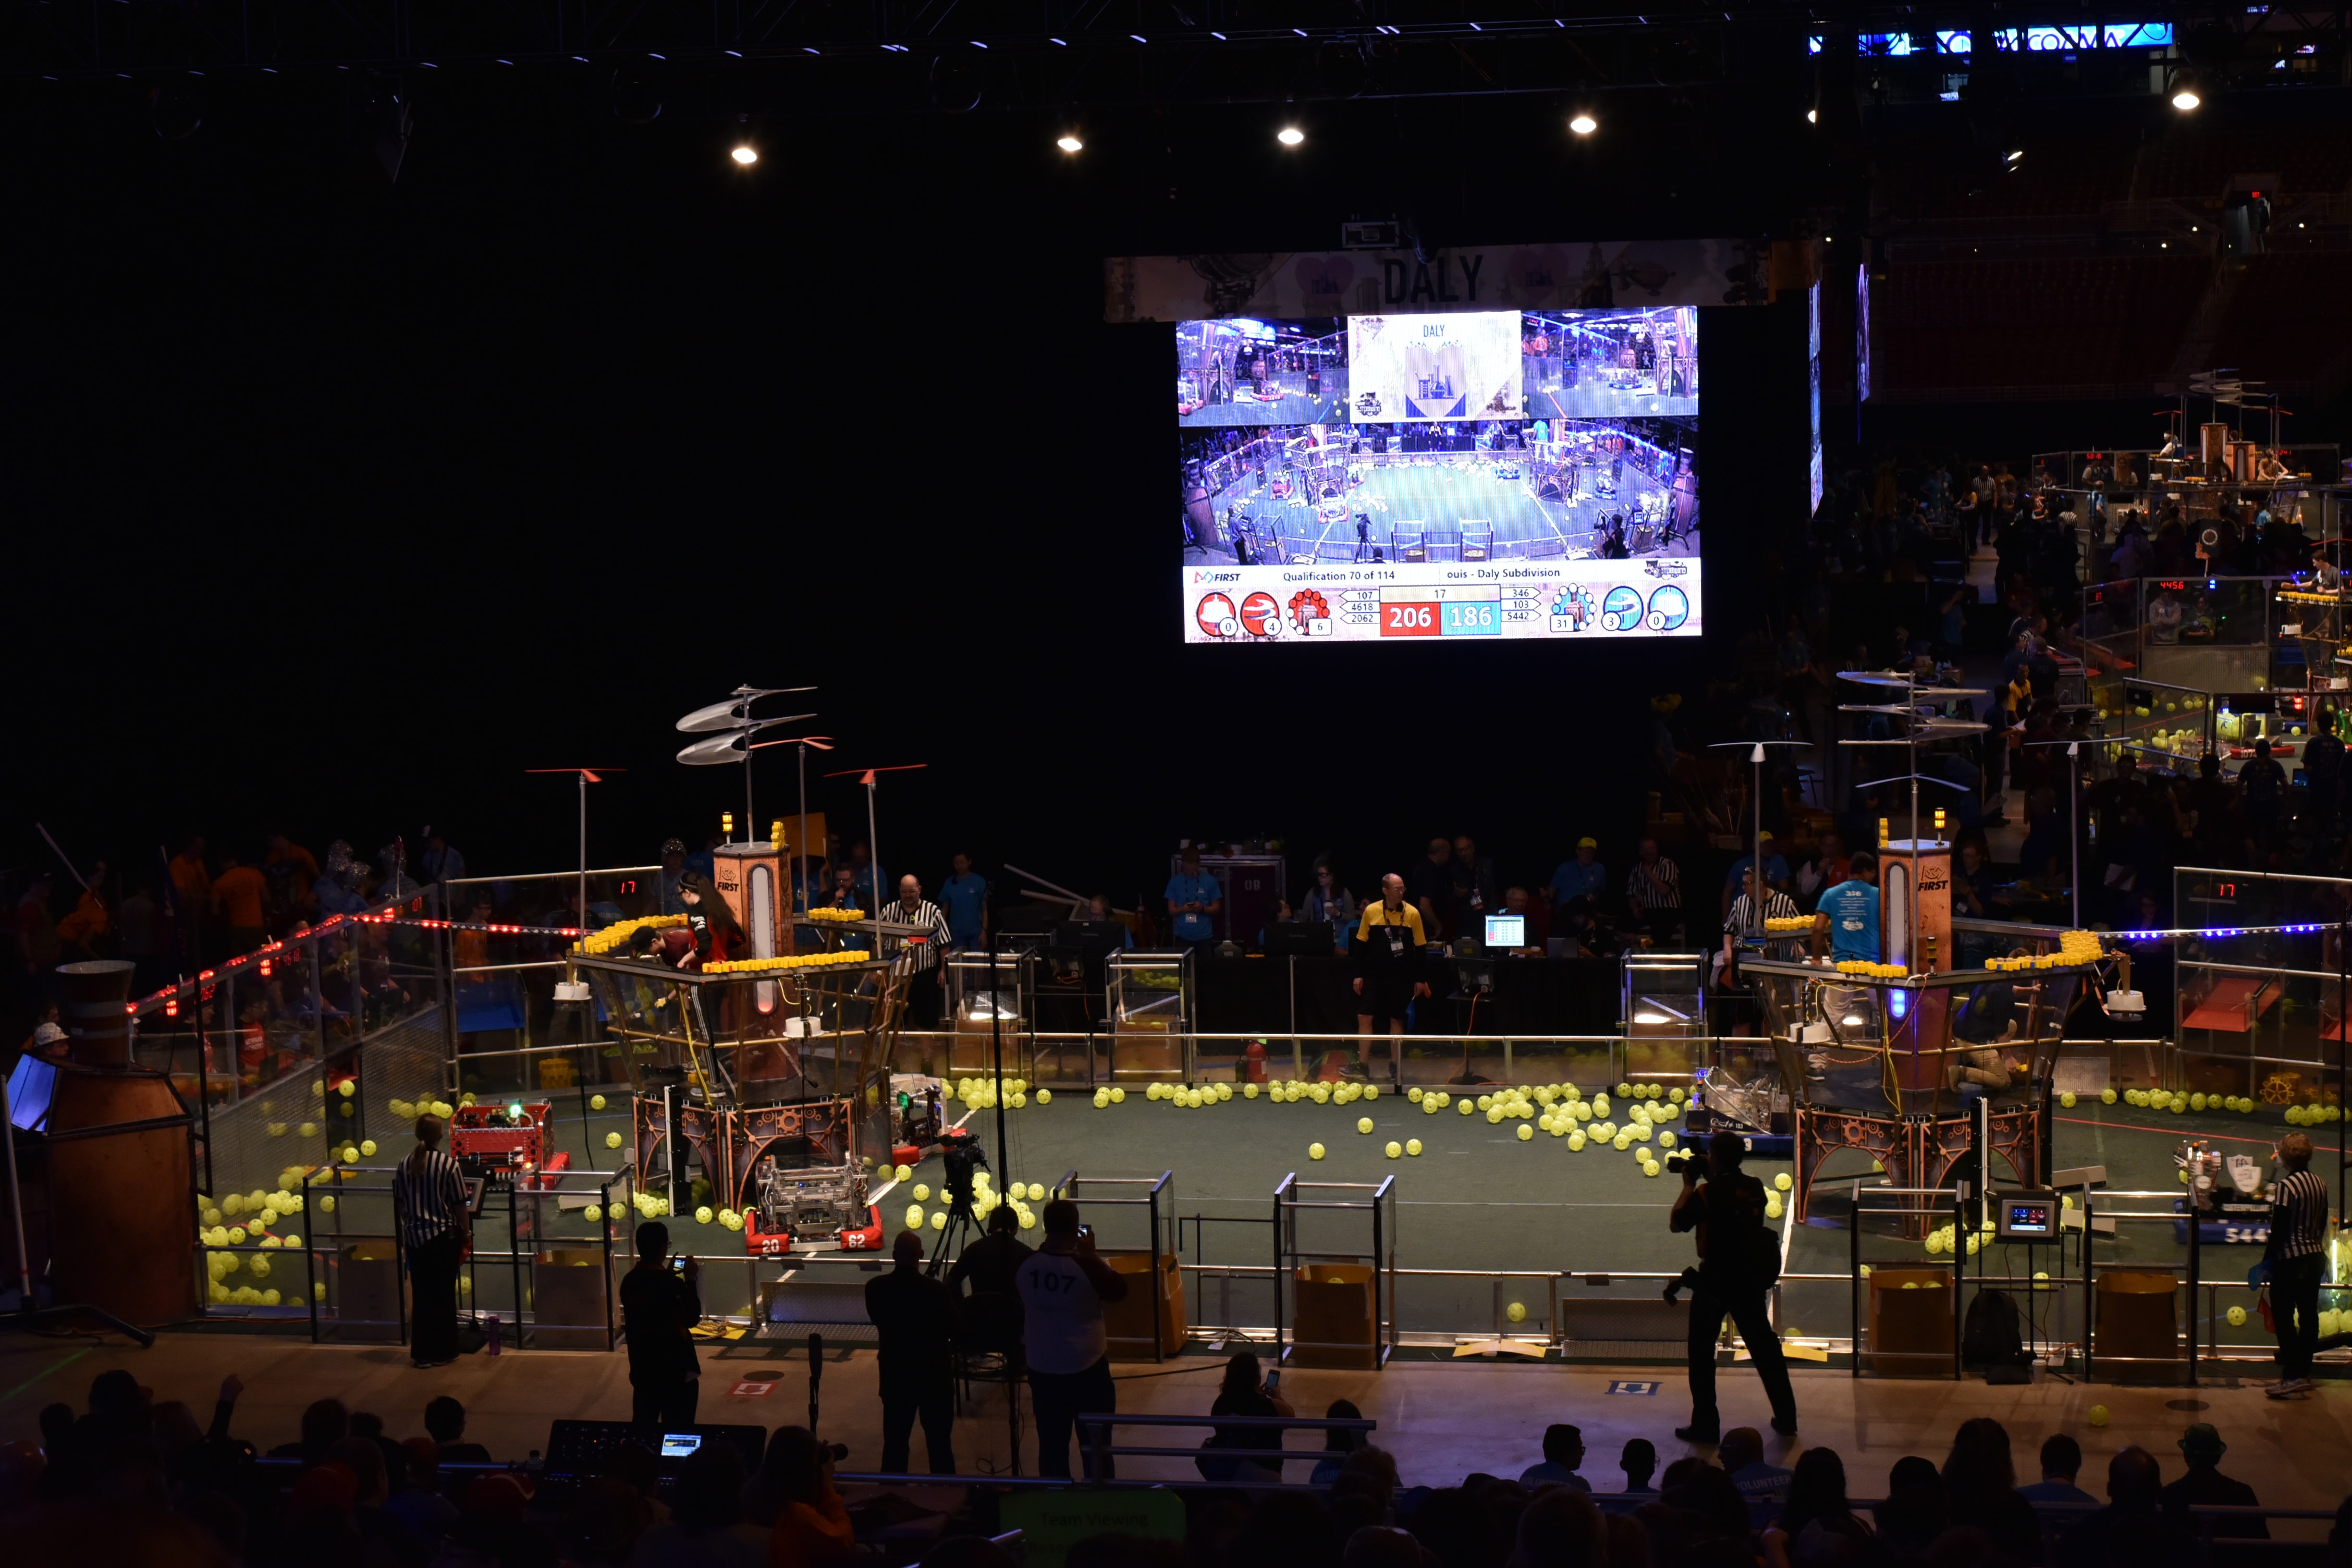
This past week, we attended the FIRST Robotics Competition Championship in St. Louis. With two Championship events this year, it was hard to decide which to compete at, but we had a great time facing off against teams from the east coast, Canada, and more. Alongside, Team 2767 Stryke Force, Team 862 Lightning Robotics, and Team 1676 The Pascack PI-oneers, we were able to win the Daly Subdivision finals before continuing on to win the Championship at Einstein.

Daly

In our qualification matches, we went 7-3 overall and seeded second, with Team 2767 holding first seed. The improvements we made since the Silicon Valley Regional payed off as we hit over 100 kPa during our second qualification game and managed an average of about 381 points per match. Throughout qualifications, we were also regularly able to achieve 40 kPa and activate 4 rotors, giving us enough ranking points to propel us into a high seed.

Moving into alliance selection, we joined Team 2767 alongside Team 862 and Team 1676. With a balance of gear and fuel scoring ability, we planned to maximize our points by hopefully achieving 40+ kPa and activating 4 rotors every match. Throughout the Daly finals, we remained undefeated and won against incredibly fierce competition. In our first semifinals match, we managed to score a personal record of 550 points! We were also very grateful to have received the Innovation in Control Award, an award we had also received back at the San Francisco Regional. After winning Daly with some very close matches, we were anxious to see how we would perform at Einstein.

Einstein

In a round robin style tournament, we competed against every other subdivision champion throughout 5 matches. We ended up going 3-2 here and seeded second, giving us the opportunity to compete in the grand finals as the blue alliance against the Darwin champions, who had beaten us in the round robin tournament.

In the most intense games we’ve played all season, our alliance pulled ahead in the finals, winning the second match by only 3 points. We’ll let the video speak for itself, as the second finals match was certainly many on 254’s favorite game of the season:

We are so grateful to our alliance partners for playing such a huge role in our success, and to every team that attended the Championship for competing with us and making it such an amazing experience. Special mention to the Einstein teams for going all the way and challenging us in ways we hadn’t previously been. We’re looking forward to facing off against the Houston alliance at the Festival of Champions!

“Thanks to our mentors for such a great season!”

“Post-Einstein excitement”

FRC Day 42 Build Blog

2017 FRC Build SeasonEmailStudents#FRC Build Blog

Day 42: Preparing for World Championships

Quick Summary

Everything that we need at competition, which includes the pit, was packed and prepared for being shipped to St. Louis.

Robot Progress

Shooter

We worked on some hood geometry and started to look at the placement of the hanger tube and different sizes. We also finished the design of the new hood and CNCed the new hood plates. We laser-cut a new center divider for the hood. Everything was assembled at on Monday’s build.

Hopper/Intake Ramp

The old hopper broke on the practice bot, so we laser cut new plates and assembled them onto the robot. We also cut spare hopper plates and spare intake ramps in case we need them during champs.

Driver Practice

We started practicing a new kind of gear cycle called the check mark cycle, which we plan will probably use from here on out.

Image uploaded from iOS (3)-min.jpg

Programming

Today, we worked on shooter tuning and semi-automated gear placement in teleop using an ultrasonic sensor.  For shooter tuning, we worked on fixing a problem where our stream will begin to walk backwards over long periods of time.  We believe this is a result of the system becoming more efficient over time as the bearings on our flywheel heat up.  To solve this problem, we tried compensating for the increased flywheel speed over time by taking an average speed of the flywheel between shots and using it to adjust our voltage..  For teleop gear placement, we tried to use the ultrasonic sensor to limit the amount the robot can drive backwards when scoring gears to prevent it from driving too far back and bending the spring.  However, we found that the ultrasonic sensor updates far too slowly for this to actually work right now, so we are investigating ways to speed up the ultrasonic sensor and use our drivebase encoders to compensate for this lag.

FRC Day 41 Build Blog

2017 FRC Build SeasonEmailParentsStudents#FRC Build Blog

Day 41: Improving Gear Scoring


Gear Grabber

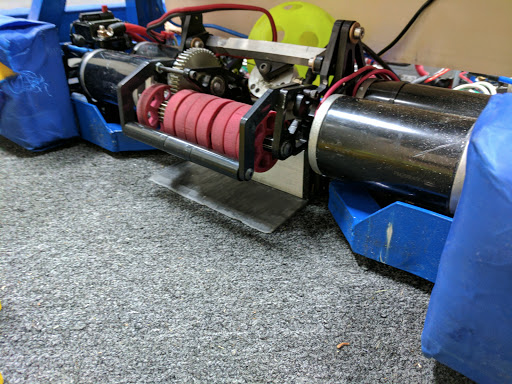
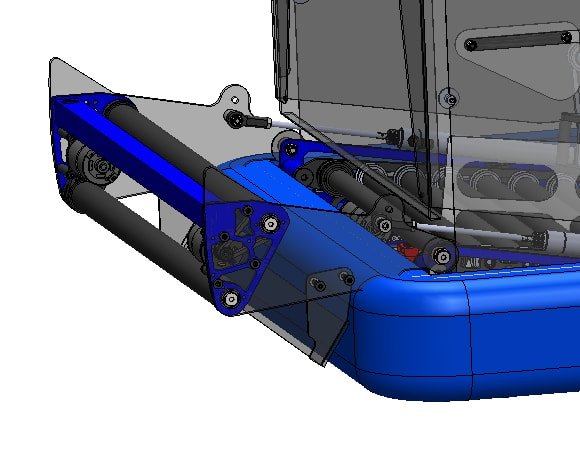
Today we worked on the Cow Catcher, or an assembly that prevents balls from getting stuck in the Gear Grabber and pushes balls out of the way. We began with prototyping with two delrin side plates and a 3/8" standoff, and while the results were promising, balls still got caught in the general vicinity, affecting its performance. To solve this issue, we prototyped the cow catcher with a longer standoff, which prevented balls from getting caught.

Inline image 1

Having determined the relative effectiveness of the Gear Grabber, we began to design a deployment mechanism such that the cow catcher fits in the framer perimeter at the start of the match. We came up with the use of a torsion spring and hardstop to deploy the cow catcher at the start of the match. Due to the limited availability of springs at the lab, we used rubber bands instead, but the deployable cow catcher was ultimately too weak. Thus, we added standoffs and reinforcing plates to increase rigidity.

Inline image 2

Robot Progress

We worked on fixing up our practice bot, making a new intake ramp and straightening out our hopper flanges. We also did a lot of shooter testing and were able to significantly improve the accuracy of our shots.

Silicon Valley Regional Tournament

2017 FRC Build SeasonTournaments

This past weekend, we competed at the Silicon Valley Regional at San Jose State University.

Qualifications

Throughout the qualification matches, Misfire performed very well, despite bearing one loss, going 8-1 overall and scoring an average of about 300 points. We focused on a strategy of reaching 40kPa along with delivering a couple gears to maximize the amount of ranking points we would receive, which worked out as we were seeded first heading into eliminations


Eliminations & Awards

In our alliance, we picked Team 604 “Quixilver Robotics” and Team 4990 “Gryphon Robotics.” With this alliance, we aimed to focus both on fuel and gears, hoping to reach 40kPa+ in the boiler, 4 rotors spinning, and all robots hanging in an ideal game. During quarterfinals, we beat the prior record of 506 points with no penalties by scoring 507 points and later in semifinals we scored 509 points. During finals we finished off with scoring 522 points (517 without penalties)!


Through the eliminations, we ended up winning the tournament after an exciting final match! We won the Quality Award and were recognized for being captain of the winning alliance. It was a great experience playing against all these teams and we hope to see some of them again at World Championships in St. Louis.


FRC Day 40 Build Blog

2017 FRC Build SeasonEmailParentsStudents#FRC Build Blog

Day 40: Improvements for SVR


Driving Improvements

We added additions to our robot in order to create an easier and more efficient driving environment. We have placed a blue LED strip on the back of the hood to let drivers know whether or not they are in a good shooting proximity. To do so, we wired up MOSFETS to control the LED strip, which will plug into the DIO port on the roborio.

Inline image 3


CamerasfAutono

At SFR, we found that installing “back-up cameras” would help with gear placement. Therefore, we worked on optimizing the camera placement, as well as finding a way to widen the narrow field of view (currently 70 degrees) to better capture the gear’s location.

Inline image 2

Autonomous

After the post-mortem we worked to improve the robot's turning during autonomous. We prototyped small Delrin sliders that didn't quite work when sliding on carpet. We anticipate that the best solution will be to try to implement drop-down omni wheels that we can turn on. However, if that does not work either we will resort to changing the autonomous routine itself.

Inline image 1


FRC Day 37-39 Build Blog: Preparing for Competition

2017 FRC Build SeasonEmailParentsStudents#FRC Build Blog

Days 37, 38, & 39: Preparing For Competition


Intake

Today, we worked on fixing the intake after it broke earlier this week. After analyzing the strength of our current weldment and modifying it slightly, we decided that simply strengthening it would not help the fundamental problems existing in the design. We took one of the broken intakes and attached it to new polycarb side plates hoping that this would decrease impact forces by increasing the time of impact (change in momentum = force * time). We drove around and crashed the intake several times with minimal damage occurring, and we are proceeding with the new design.

Inline image 1

Hopper

Today, we worked on the Hopper and testing the fully assembled redesign. After fixing some initial discrepancies in the real life assembly, we tested out deployment and stowing. As of a few tests, the intake deployed well (after modifying the intake ramp slightly to have slightly deeper notches to fit the constraint screws in) and we will be updating the CAD with these changes on Friday. We will also laser cut a new intake ramp to get definitive results. If all systems work well after that, we will begin assembling the new parts for comp as well as a back up.

Between, Friday and Saturday, we were able to finalize the hopper design. After some CAD work on the redesign and some troubleshooting after assembly, we were able to make a solid hopper. More testing will continue to confirm consistency, but we will be moving forward with the Comp set soon.

Shooter Flywheel

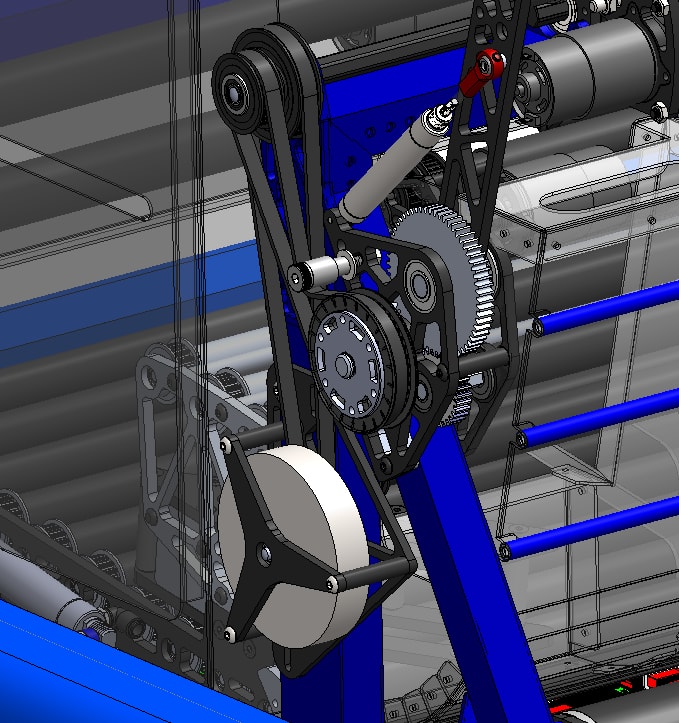
In the last week, we explored the use of a large flywheel to help increase the consistency of the shooter. A flywheel dramatically increases the kinetic energy of the shooter wheel system, hopefully reducing the amount that the wheel slows between shots. We designed a steel flywheel with about 4 lb*in2 of inertia. It is geared up 2.5:1 from the shooter wheel to increase the kinetic energy. Preliminary testing shows that adding the flywheel may not actually achieve the desired result. The elasticity of the timing belt caused some controllability challenges that the programming team worked on this weekend. Each time the direction of tension in the belt switched (from energy going into the flywheel to energy leaving the flywheel), there was a little bit of elastic movement which added oscillations to the shooter wheel system. The plots looked like the typical mass/spring/damper plots for a 2nd order system from a controls or dynamics class.

Climber

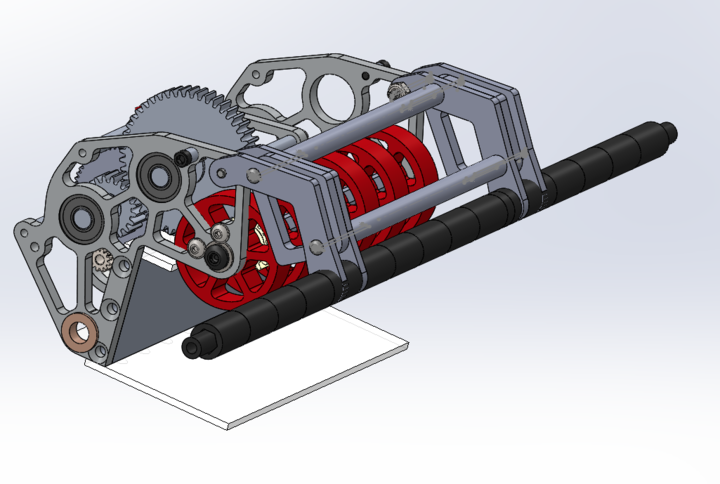
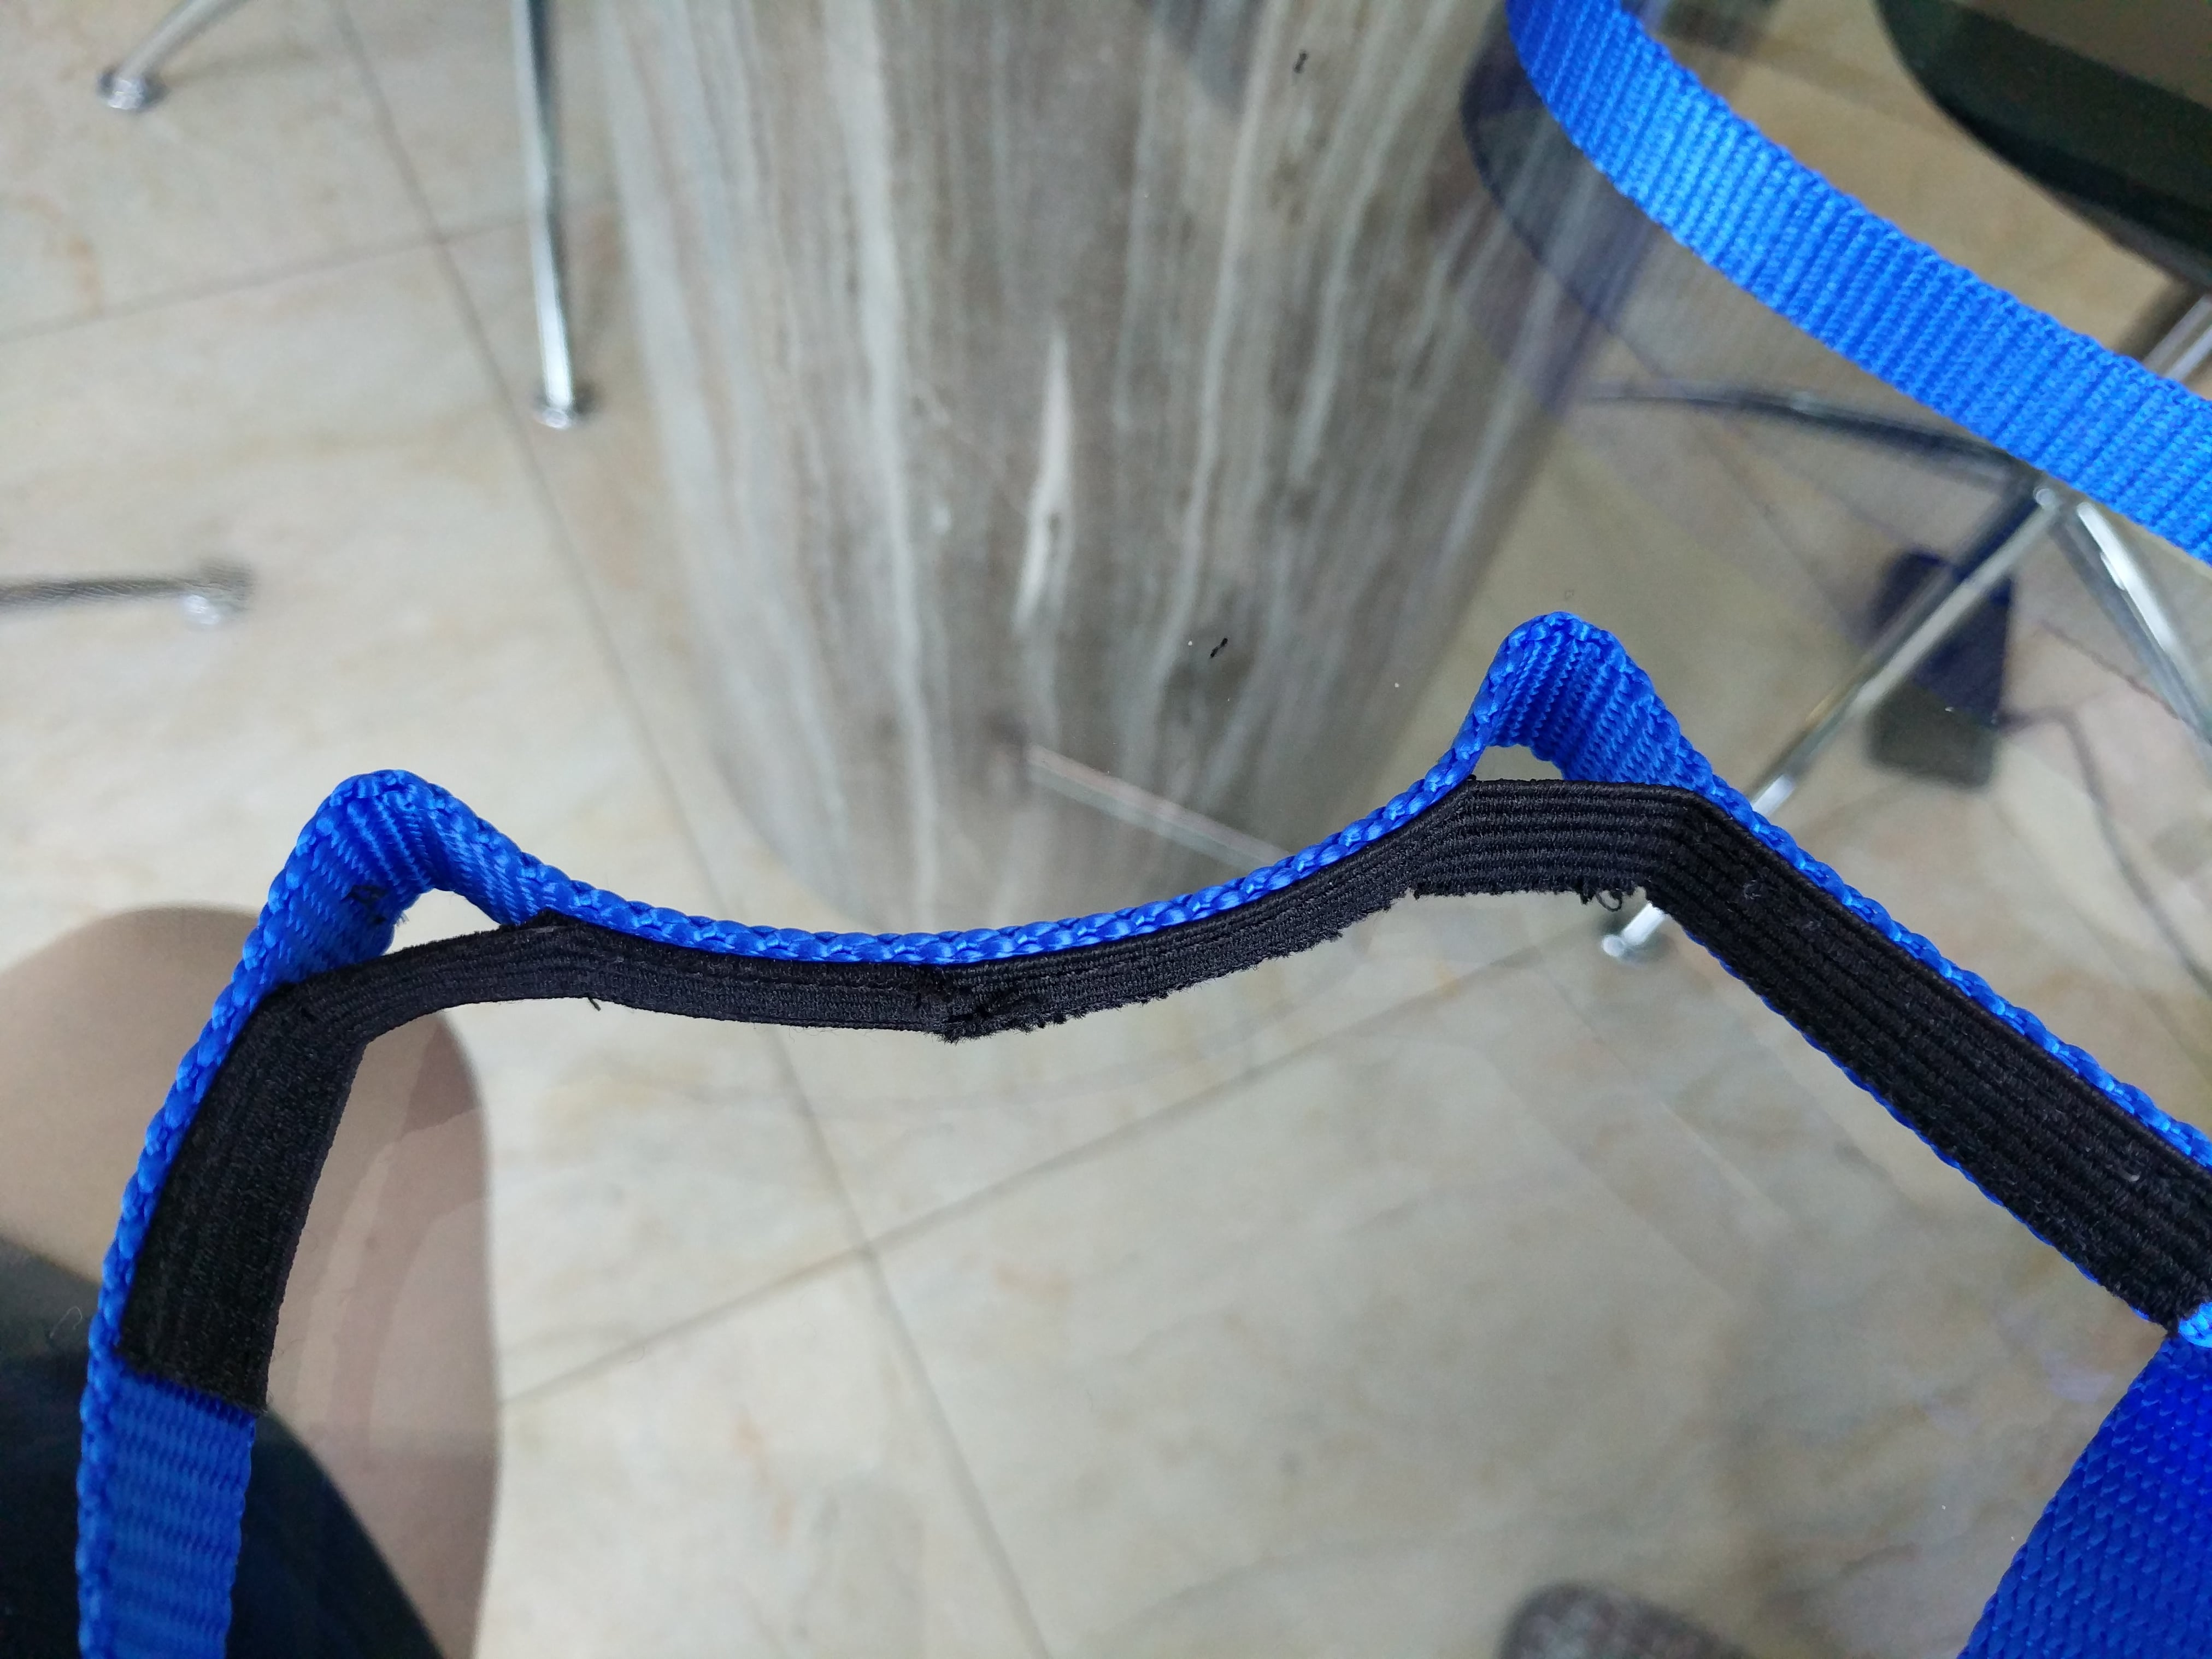
We are using inline elastic to add stretch to the rope. This will allow the robot to pull the rope down with a low amount of force at first, getting some wrap before beginning to lift the robot off the ground. This is important because the Velcro that engages the climber drum is strong in shear - and its strength is proportional to surface area. Once the rope has wrapped around the drum enough, the load transfer switches to Capstan forces. We are assembling several ropes, each with a number of pockets like the ones shown below.

A video is linked below of the climber being tested. Note that in this test case, we were pulsing the motors. Typically, the climb is much faster.

https://youtu.be/UYMntdI0CPo

Gear Grabber

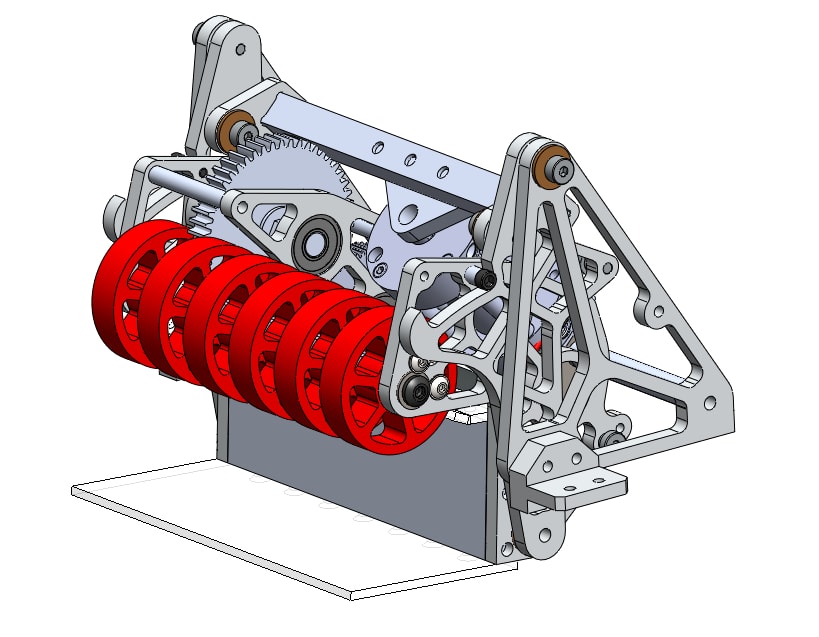
The latest iteration of the gear grabber has a dual pivot design - the whole mechanism pivots from a pickup configuration to a scoring configuration with one pivot, and a second lower pivot is sprung to allow the wedge to conform to the floor without digging in. We built this prototype last week out of delrin on the laser cutter and used it for driver practice over the weekend. We moved forward with making this out of metal and sent the parts to Anodize on Monday morning.

Check out the video below for pickup and scoring performance of the current prototype:

https://youtu.be/Oj6FkjkXHtM


Driver Practice

We practiced driving by cycling gears with and without defense, climbing, and intaking balls off the floor. We are much better now at quickly scoring gears, and in one practice match we scored 9 gears and climbed when no defense was played on us. The gear grabber is much more reliable, and consistently picks up gears off the ground the second we touch them. Scoring is still tricky, but we are getting better at finding the right depth at which we need to drive into the spring.

Programming

Autonomous Program

Today, we worked on finding and fixing a bug in our Adaptive Pure Pursuit controller.  The bug was causing arc lengths in the controller to be calculated incorrectly in some cases, resulting in a value much higher than it should have been.  This would in turn cause the robot to drive way too fast and shoot past the end point in the path.

Gear Grabber State Machine

Today, we worked on implementing a new Gear Grabber state machine. The new gear grabber code greatly simplifies the operator controls. Now, there are only 2 buttons used for intake and release. The state machine uses output current to determine when a gear has been picked up and will activate the piston automatically.

More Information

We also found two bugs resulting in the robot not turning left and twisting along an autonomous routine, and we were able to fix these edge cases.

The hardware team began crimping and attaching 15 battery leads and running battery tests to determine true battery capacity.