Day 12.5 - Testing the Lidar
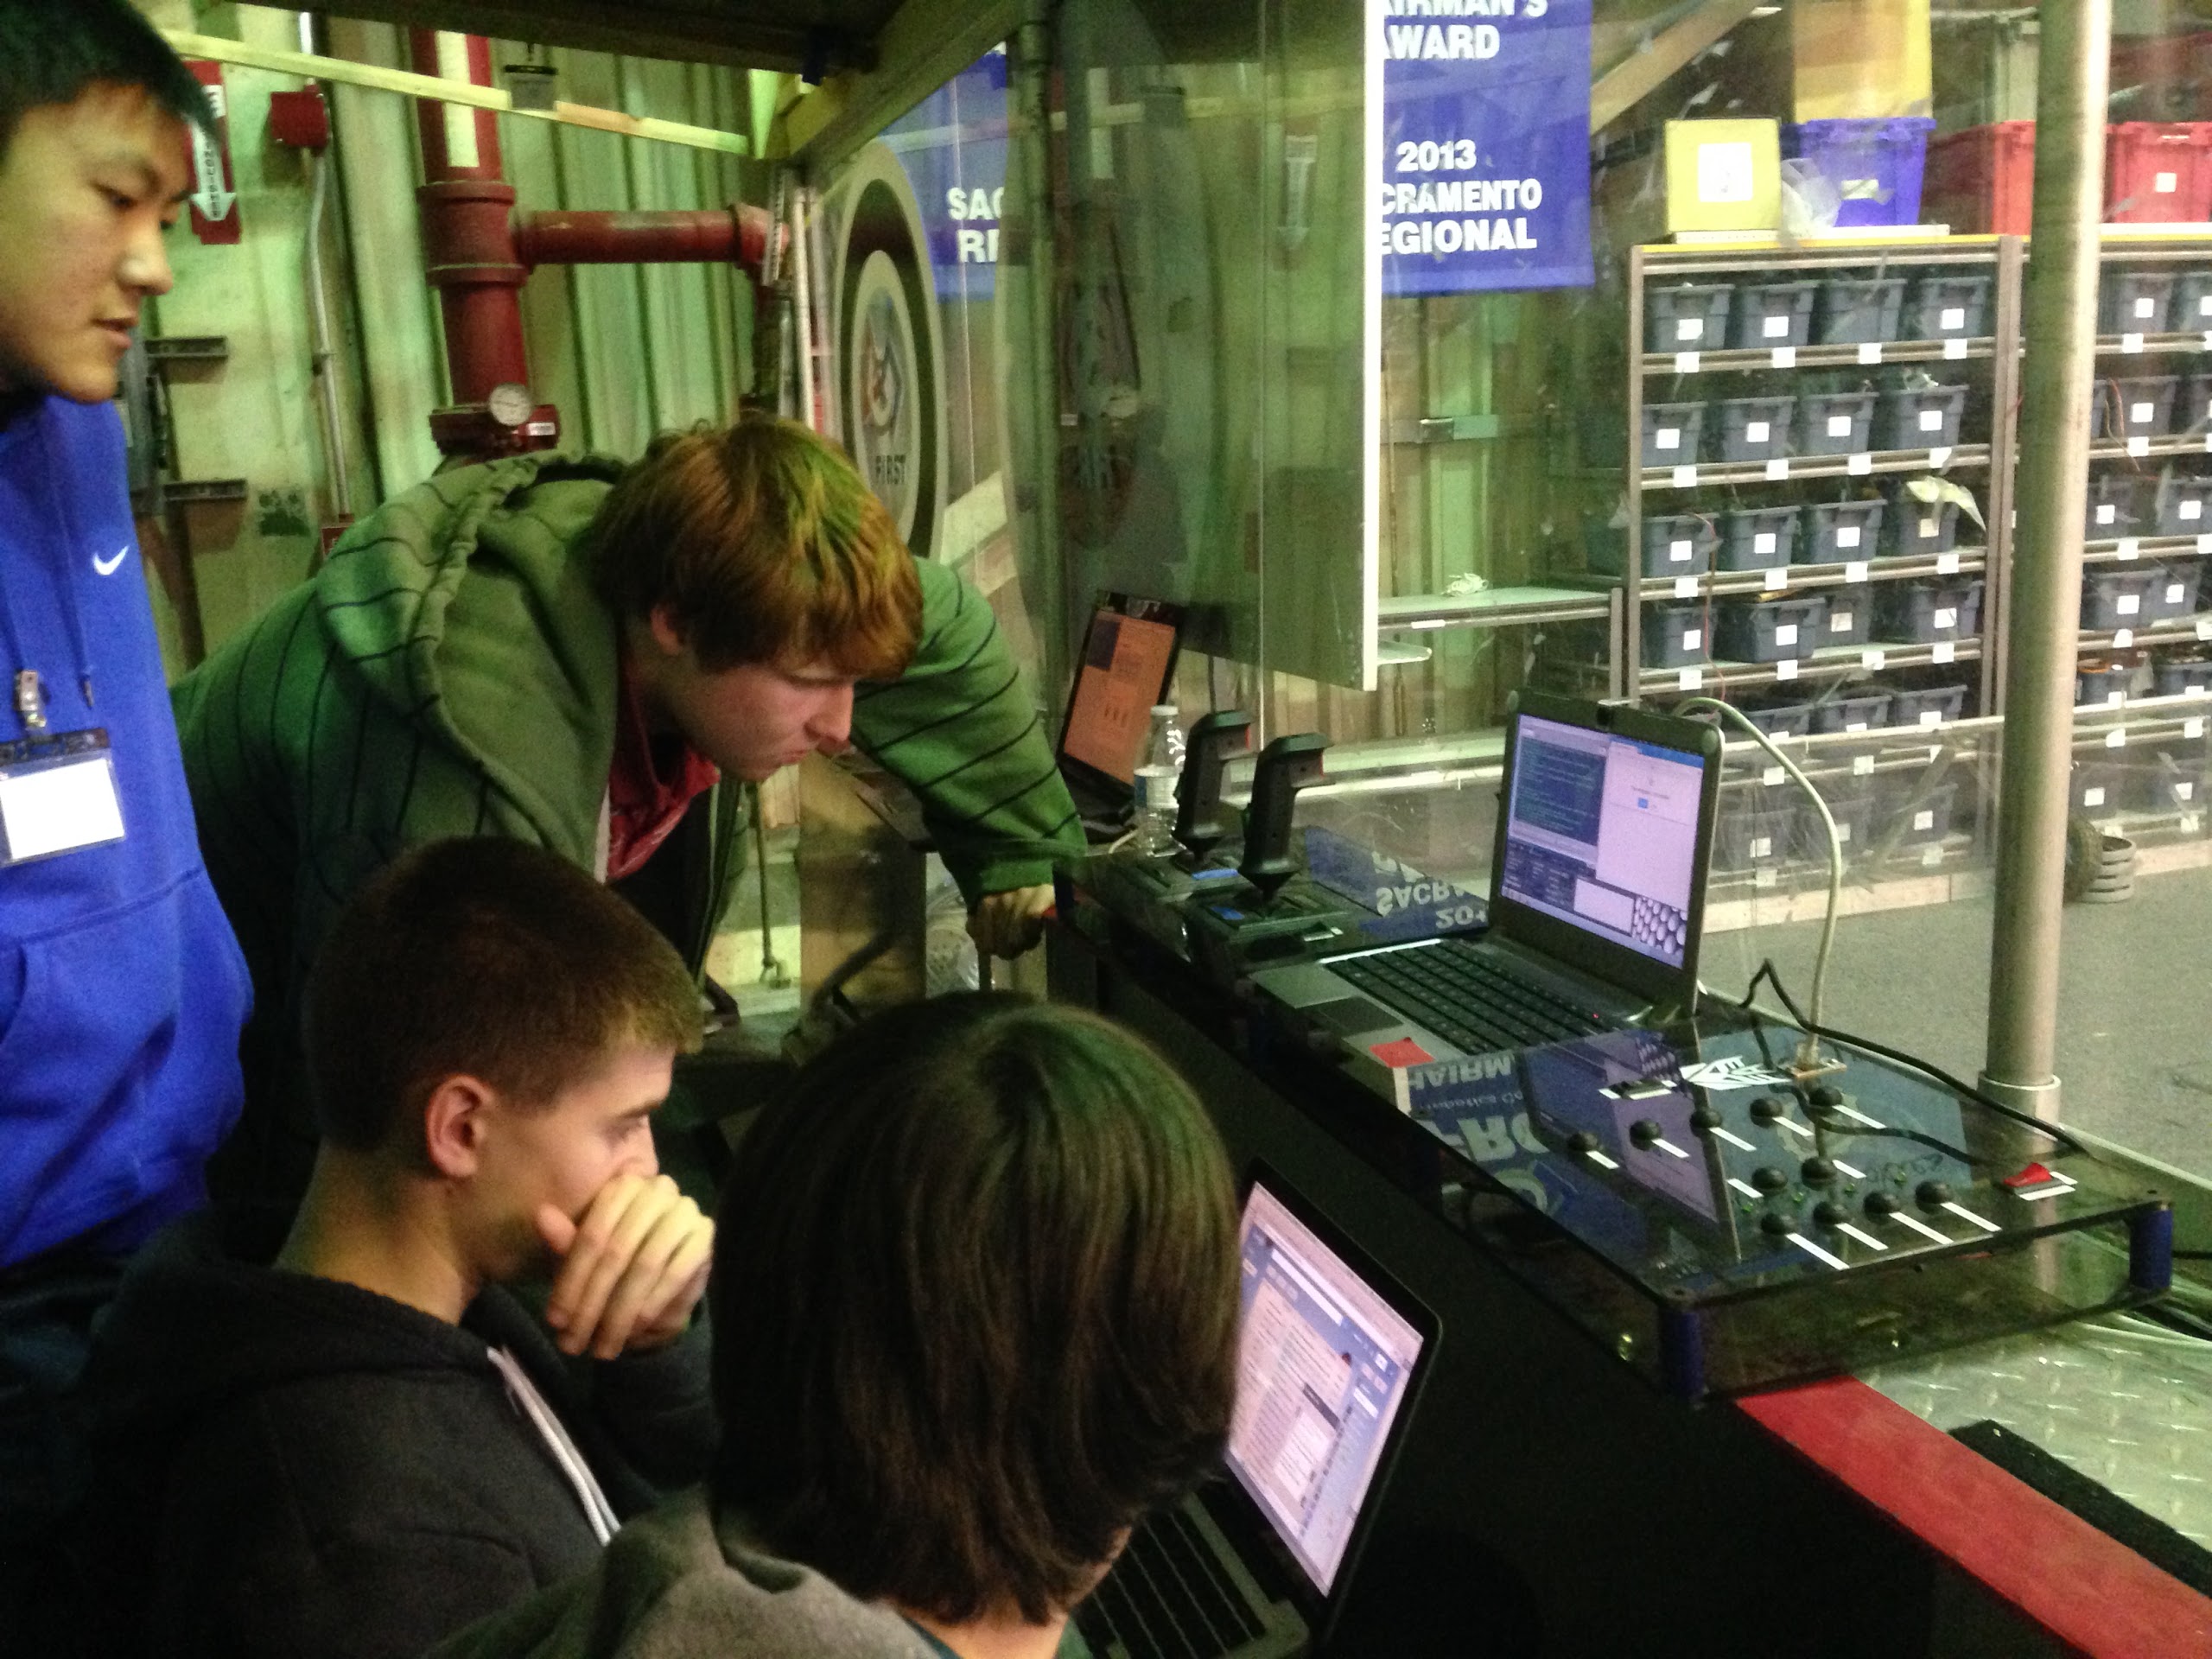
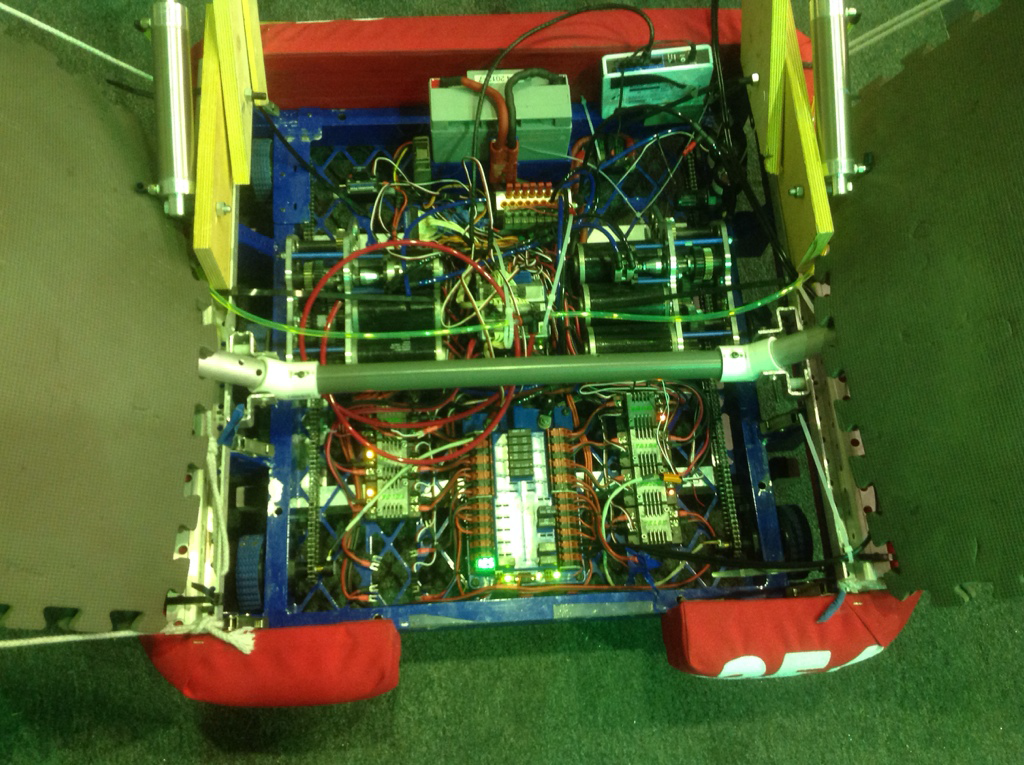
Today, the team tested an advanced Lidar Sensor solution. Extensive testing was performed (approx 30 min). Please enable Javascript to watch this video
Read post
News, events, and updates from Team 254.
Today, the team tested an advanced Lidar Sensor solution. Extensive testing was performed (approx 30 min). Please enable Javascript to watch this video
Read postby Dan Ngo '17 Design Review The highlight of the day was the design review, during which the team congregated to discuss and possibly finalize the strategy and conceptual robot design thus far. The team decided that its overall strategy would be aimed at…
Read postby Trevor Salom '17 Programming Today, the programmers worked on testing a VEX ultrasonic sensor to see whether the robot could use it to gauge its distance from the wall of the field. The VEX sensor was used as a temporary stand-in while the programming team…
Read postIn honor of our first day of rest of the season, here's a GIF of the season's latest dance craze. Today, we didn't meet at the lab. Some team members worked on CAD on their own.
Read postby Christian and Michael Simeon Catcher Prototype Today, students lined the catching prototype with VEX field flooring tiles to help keep balls in the catcher by preventing them from bouncing off the PVC pipes and rope. Students also improved on the attached…
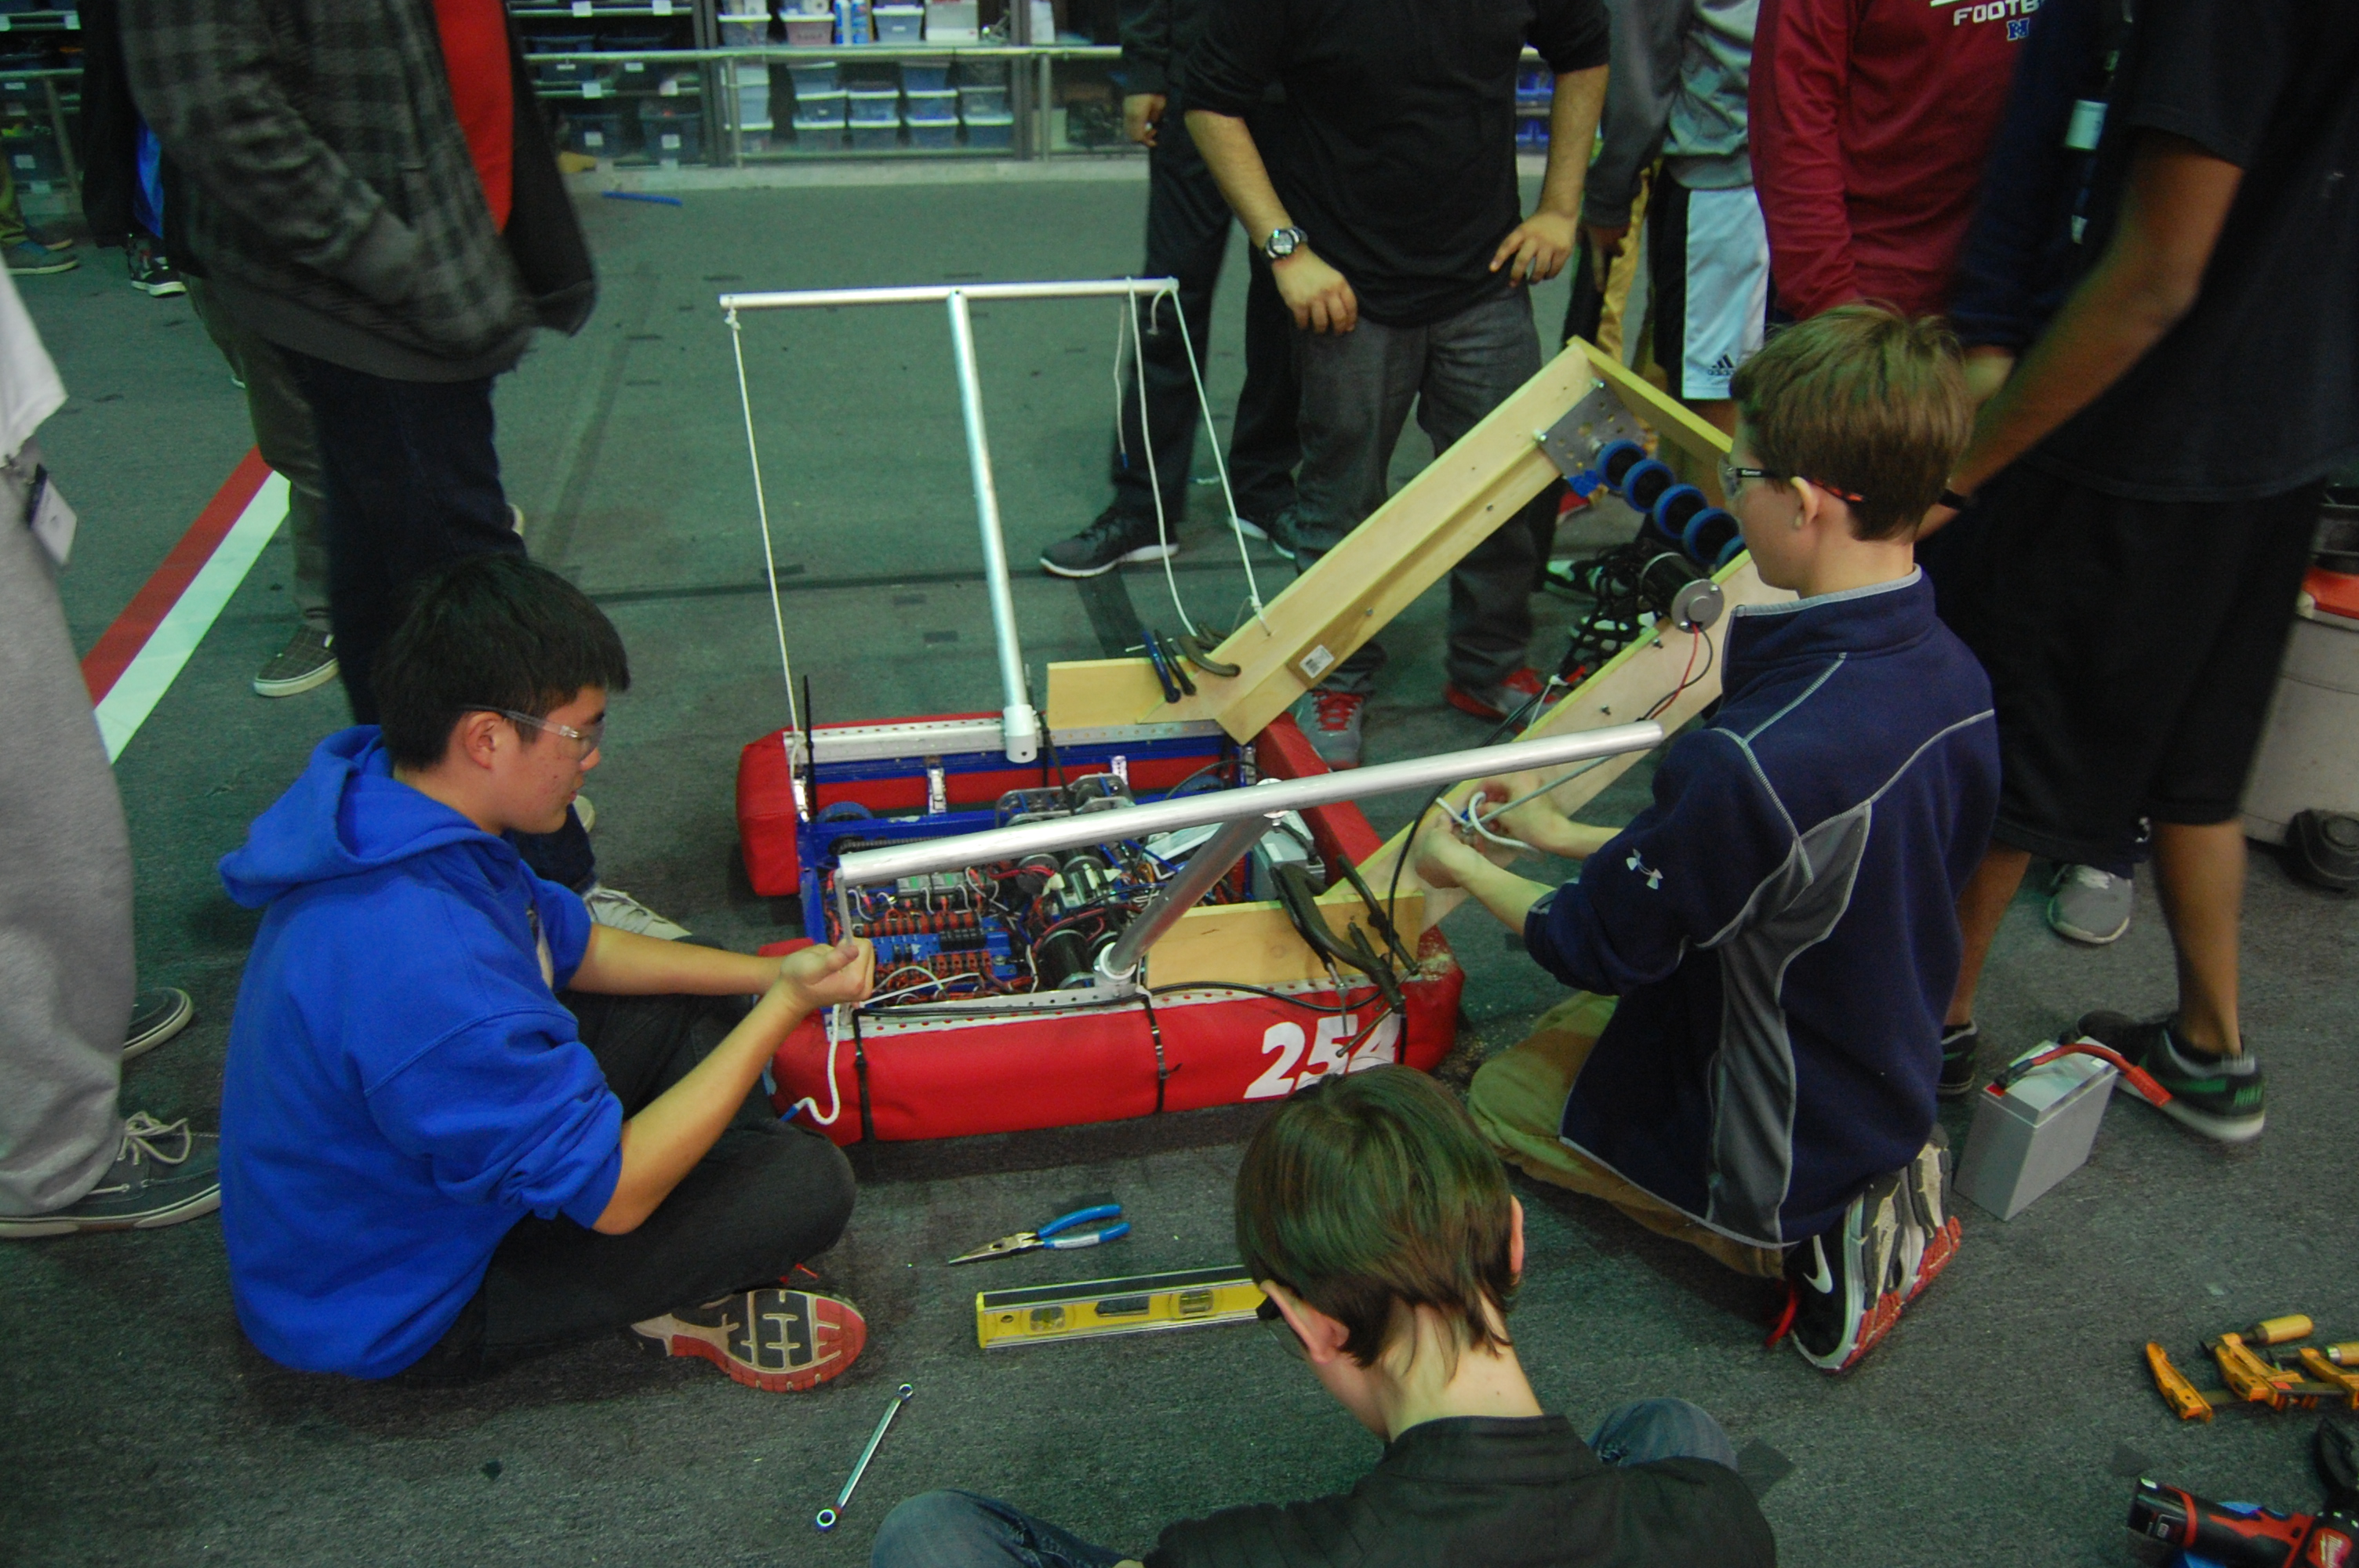
Read postCatcher & Intake Prototype Today, several team members integrated the intake and catcher prototypes with the 2013 practice robot drive base to create a prototype robot that can catch and intake the balls. They removed the catcher arms from the back and front…
Read postby Jeffrey Kaufmann New Flywheel Prototype A team of students worked on the updated prototype of the flywheel shooter. The new prototype can shoot at an almost vertical angle, enabling the robot to toss the ball over the truss. It also allows for easier…
Read postFlywheel Shooter Prototype Today, we continued work on a new flywheel shooter prototype. The team determined that smaller shooter wheels would make the shooter more packagable in the robot. We made some great progress and we should be able to complete it…
Read postCatcher Prototype Today, we continued work on the catcher prototype, making it higher and wider so that it can better catch balls from all angles. Although the catcher is promising, its large size may be a problem when packaging mechanisms for the robot.…
Read postAutonomous Strategy Today, we discussed scoring all three balls in autonomous. In autonomous, only the area directly in front of the low goal is guaranteed to be undefended. The strategy would involve starting with one ball in the robot, one in front and one…
Read post