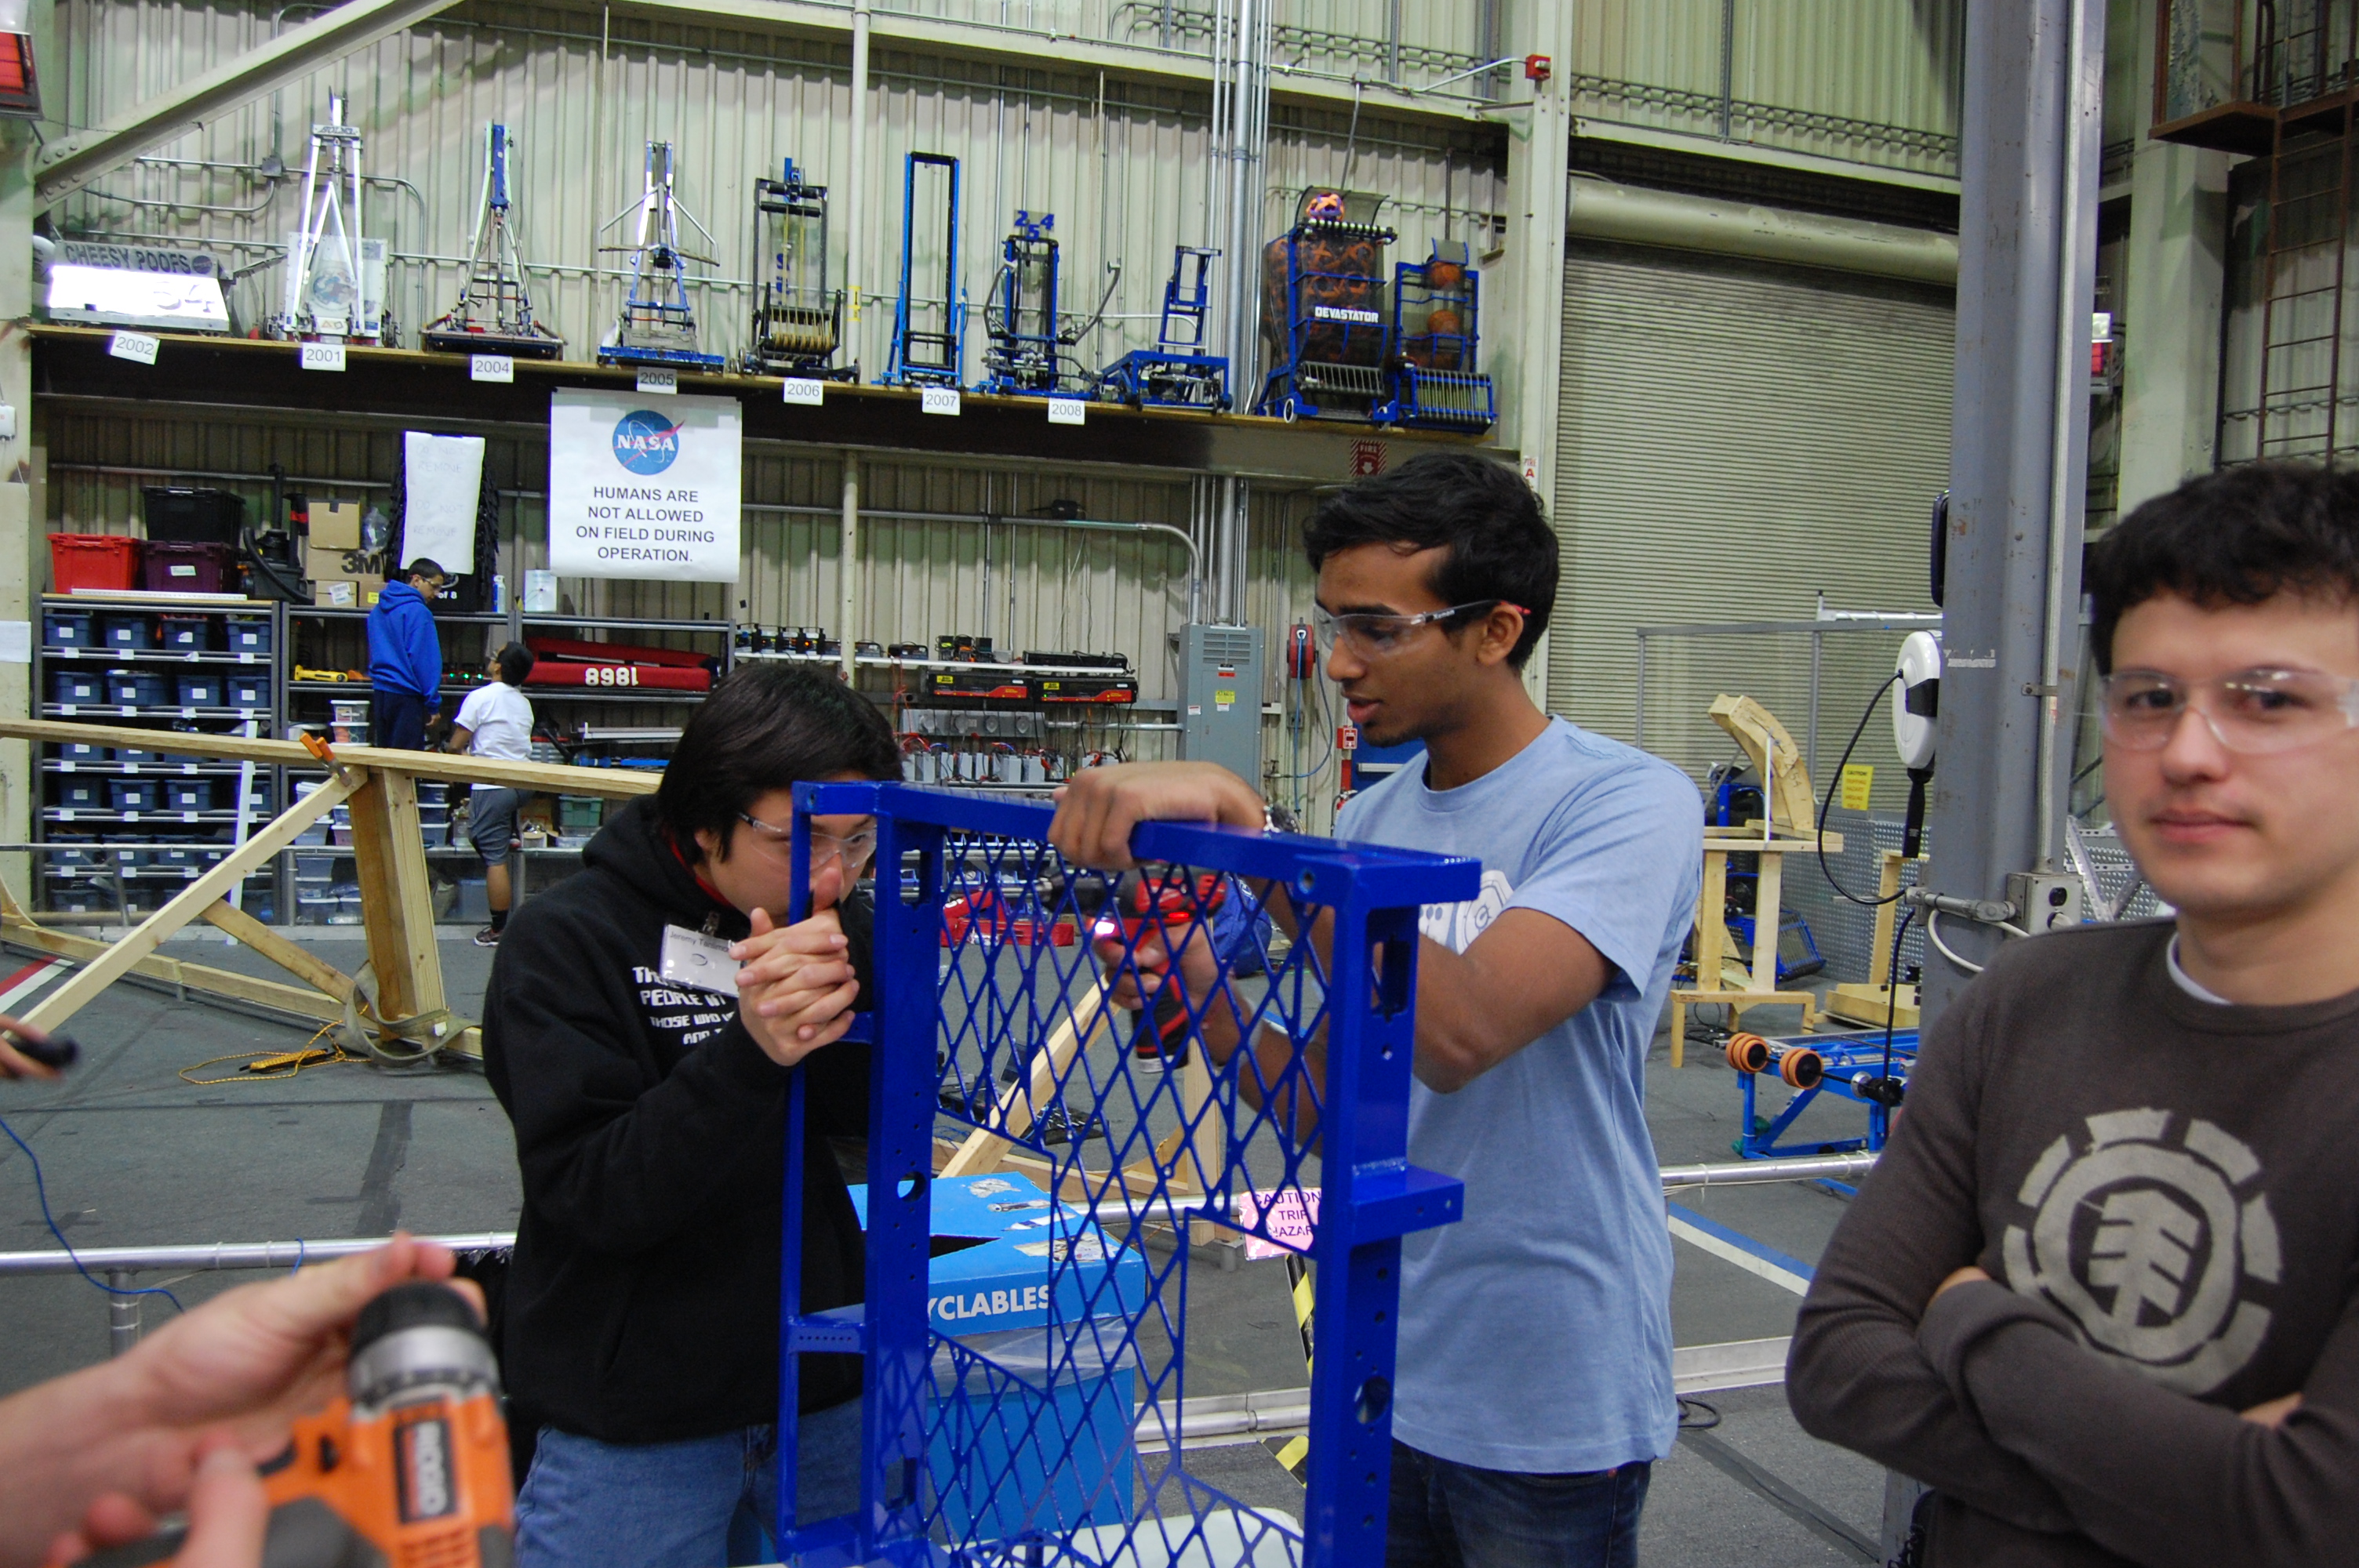
By Clay Rosenthal Manufacturing: Lots of parts were manufactured today. The gussets for the superstructure were machined on the CNC and scotch brited by hand. Axle plugs were turned on the lathe. Pieces to be CNC milled later for the intake and the hood were…
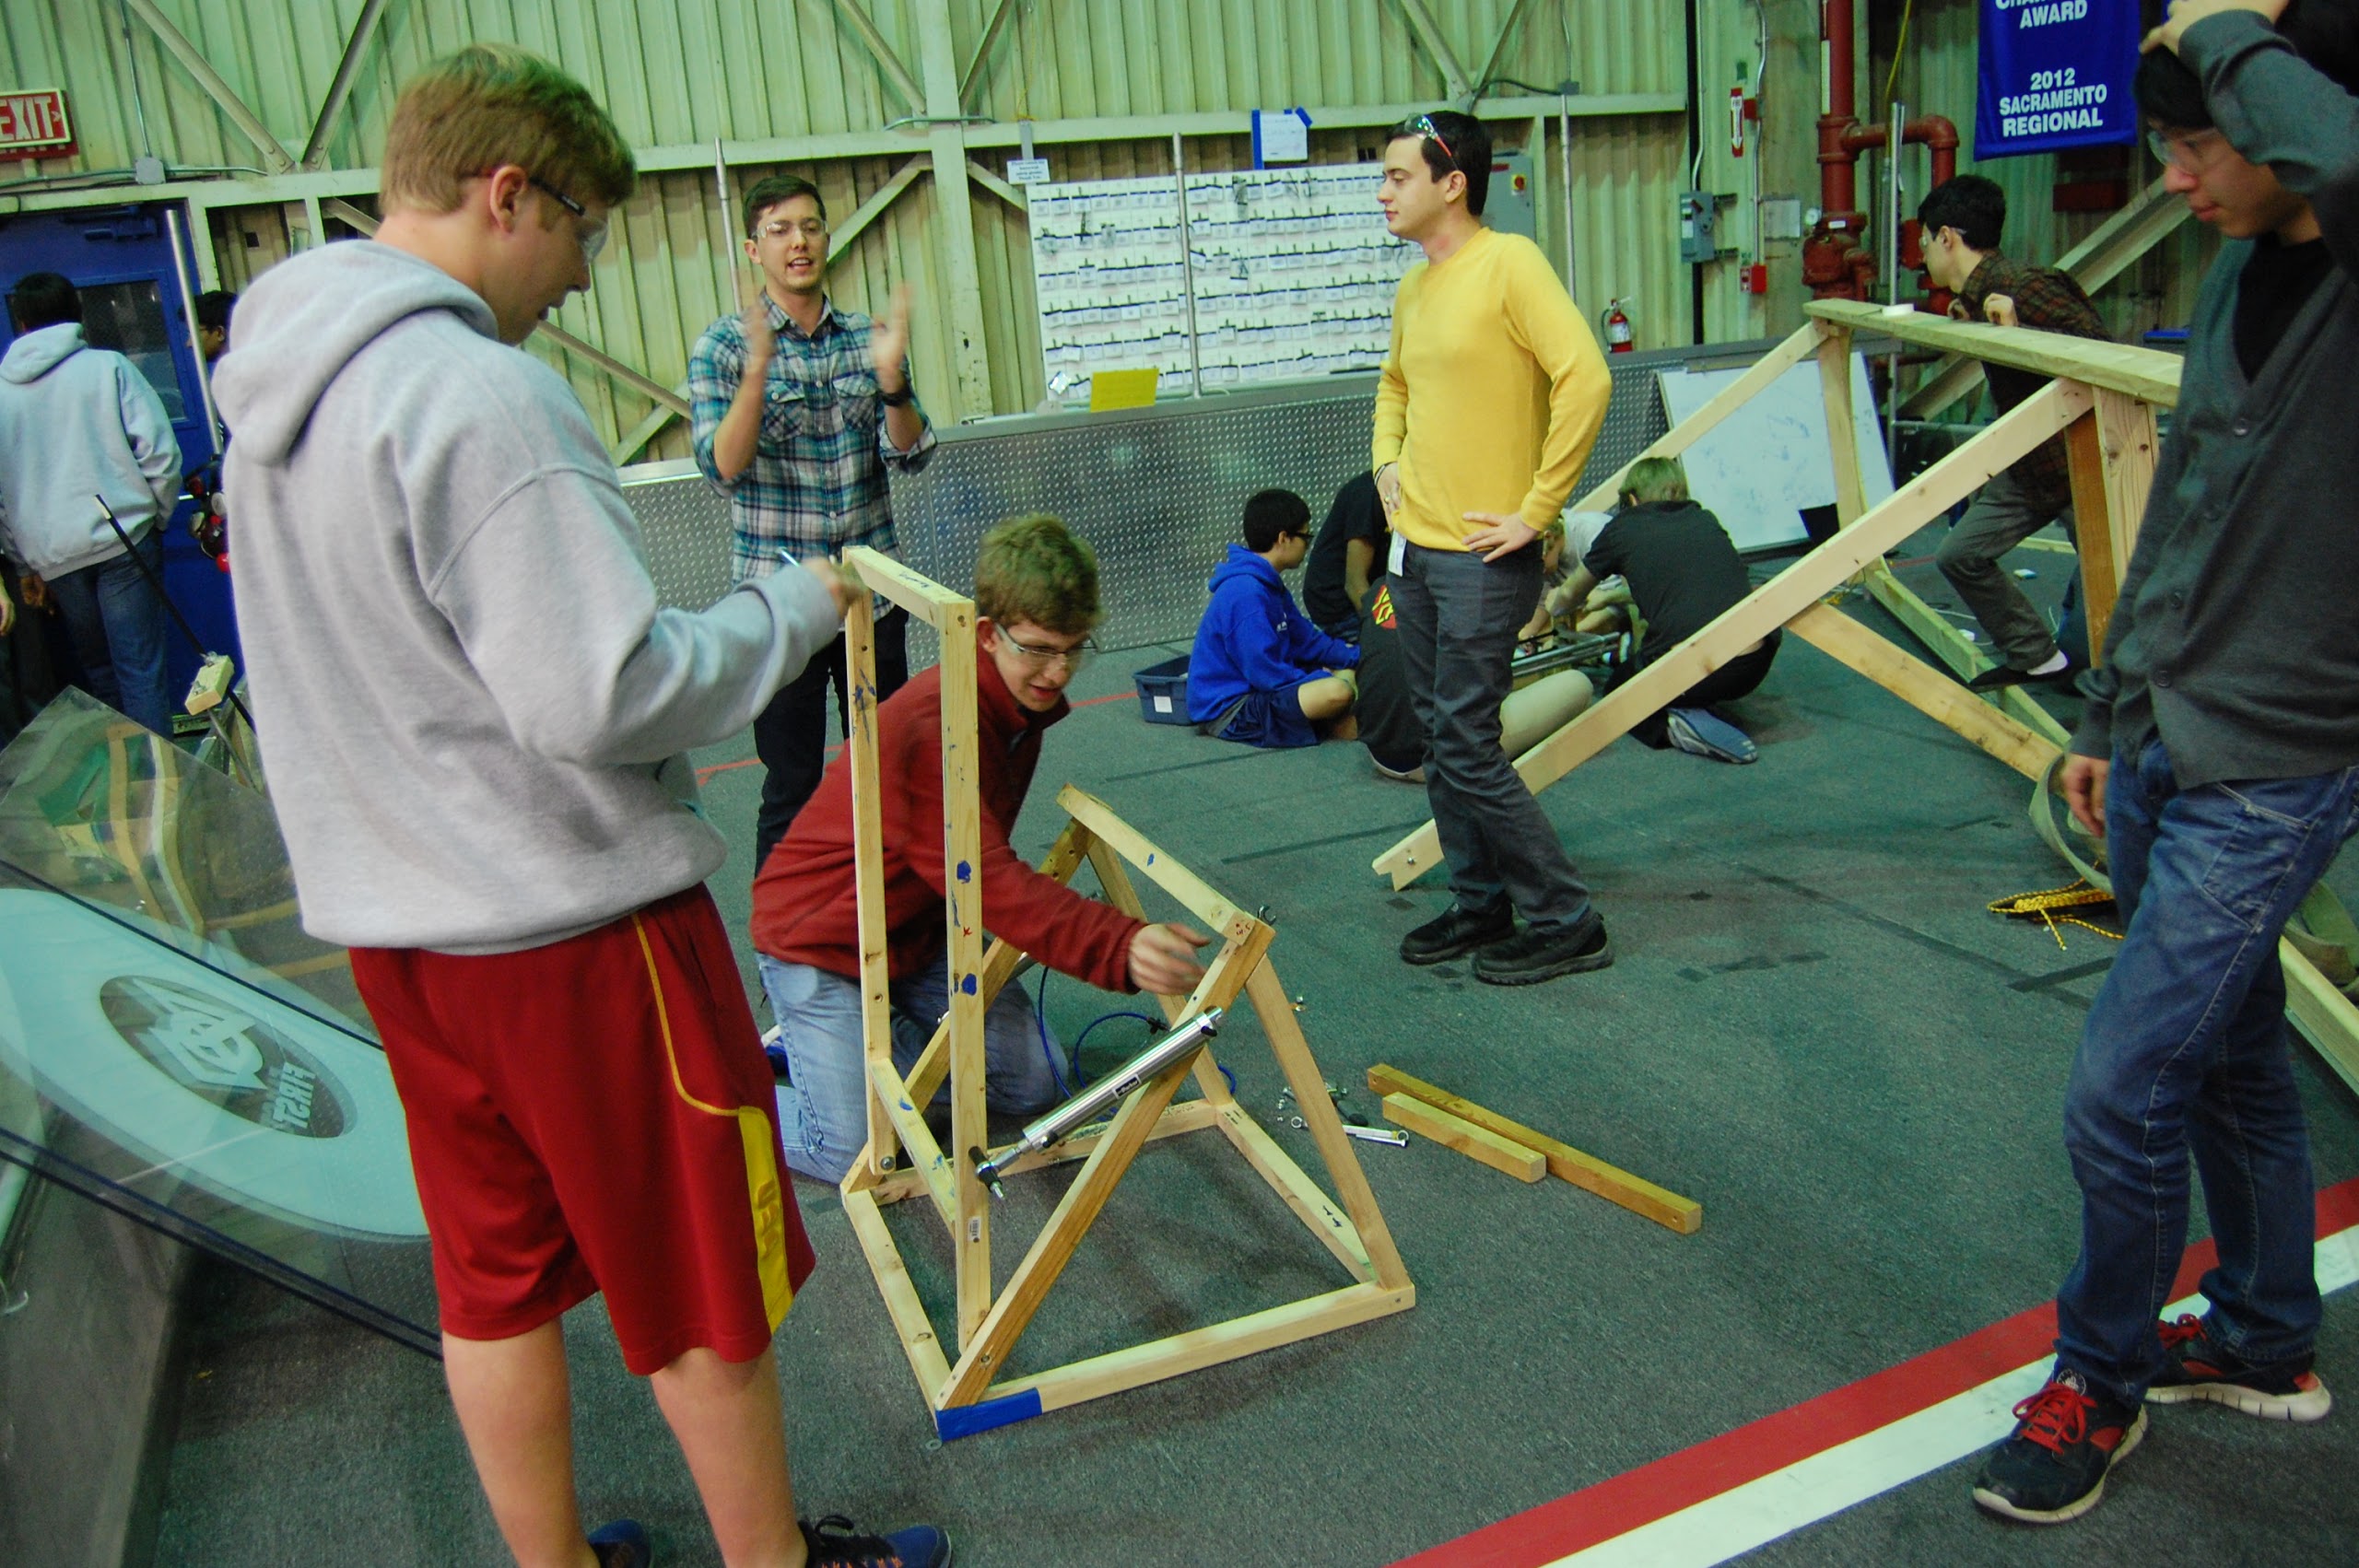
Trussing Several students worked on building the trussing for the field. They started with 1.5 x 1.5 inch wood struts and spent all day constructing the various portions of the truss. They are on track to complete the main trussing framework tomorrow. Wiring…
by James "Mikey" Carroll ’15 Prototyping Today, a group of students continued to work on and improve the indexer prototype. The indexer, the mechanism used to raise balls into the flywheel shooter, features a claw-like design that lifts the ball as the two…
by Joncarlo Avila and Brandon Wui Prototyping Today, we worked on prototyping an improved catcher and ball indexer. Our new catcher consists of 2 pistons that open and close the catching mechanism. We also removed the intake and shooter from the Overkill…
by Chris Powers and Jack Lee Prototyping Today, work continued on testing the prototype robot’s lift mechanism, which uses pneumatic pistons to lift the ball from the intake of the robot to the flywheel shooter. This lift worked successfully during most of…
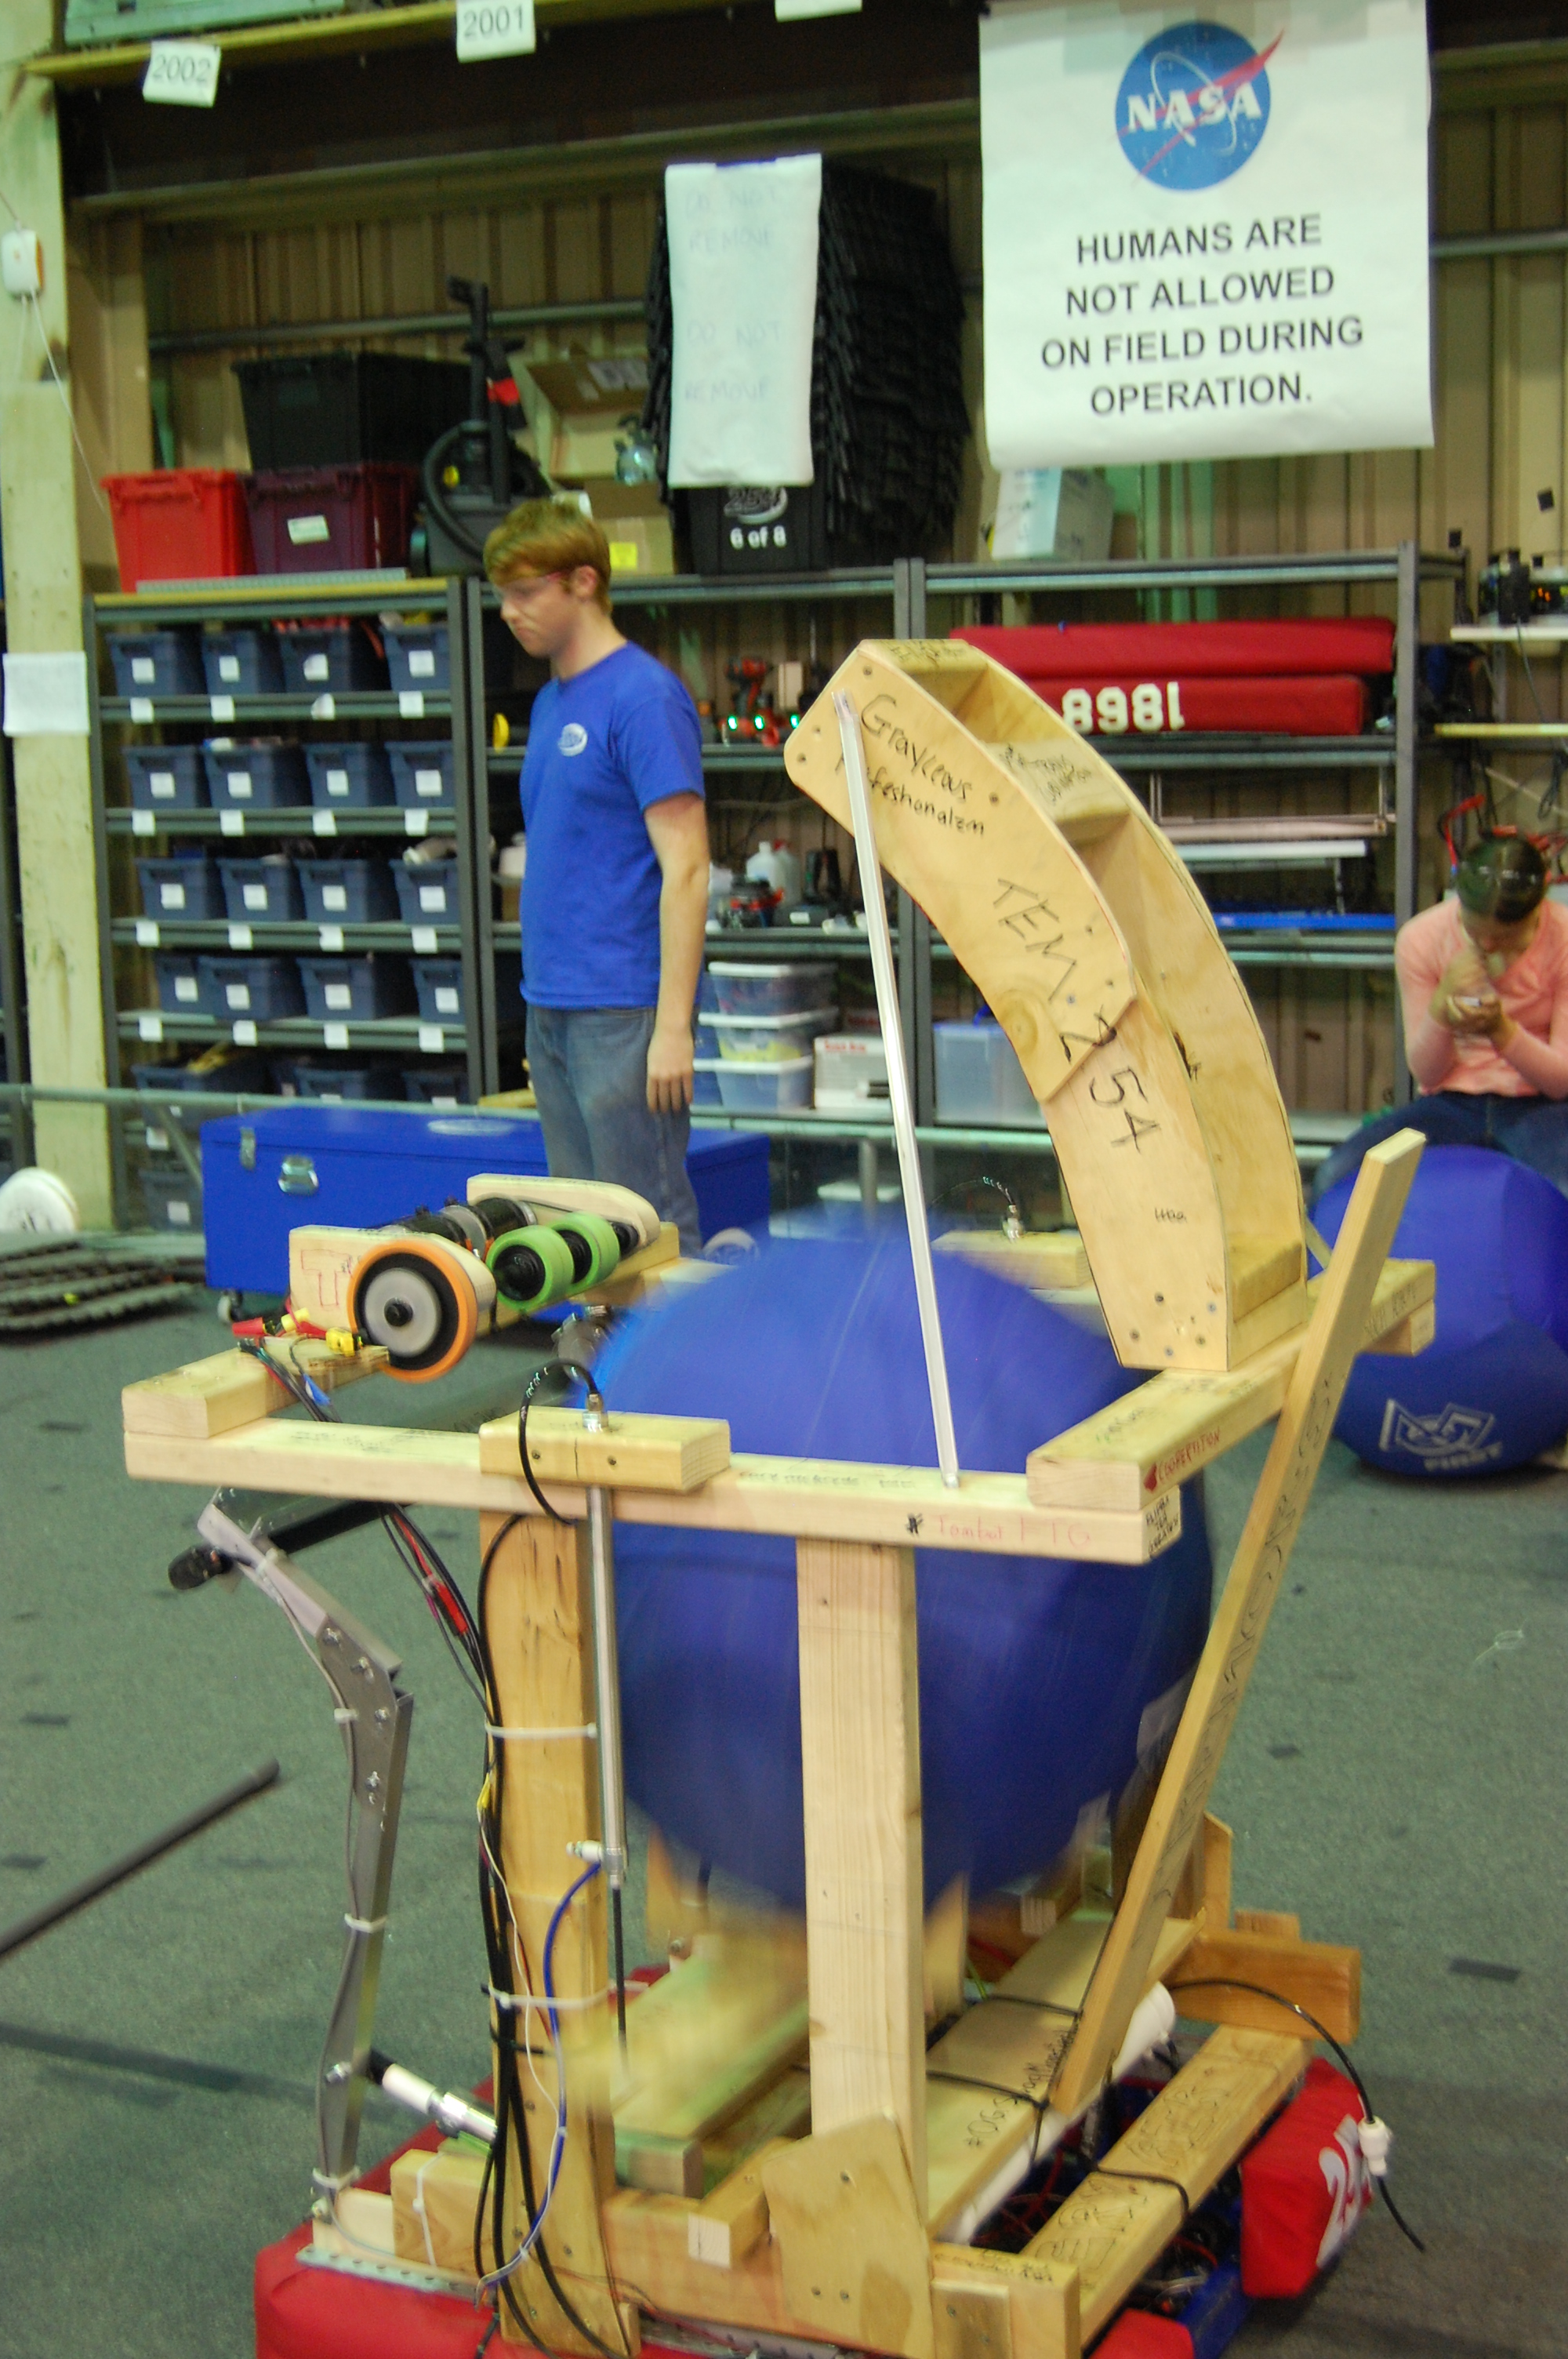
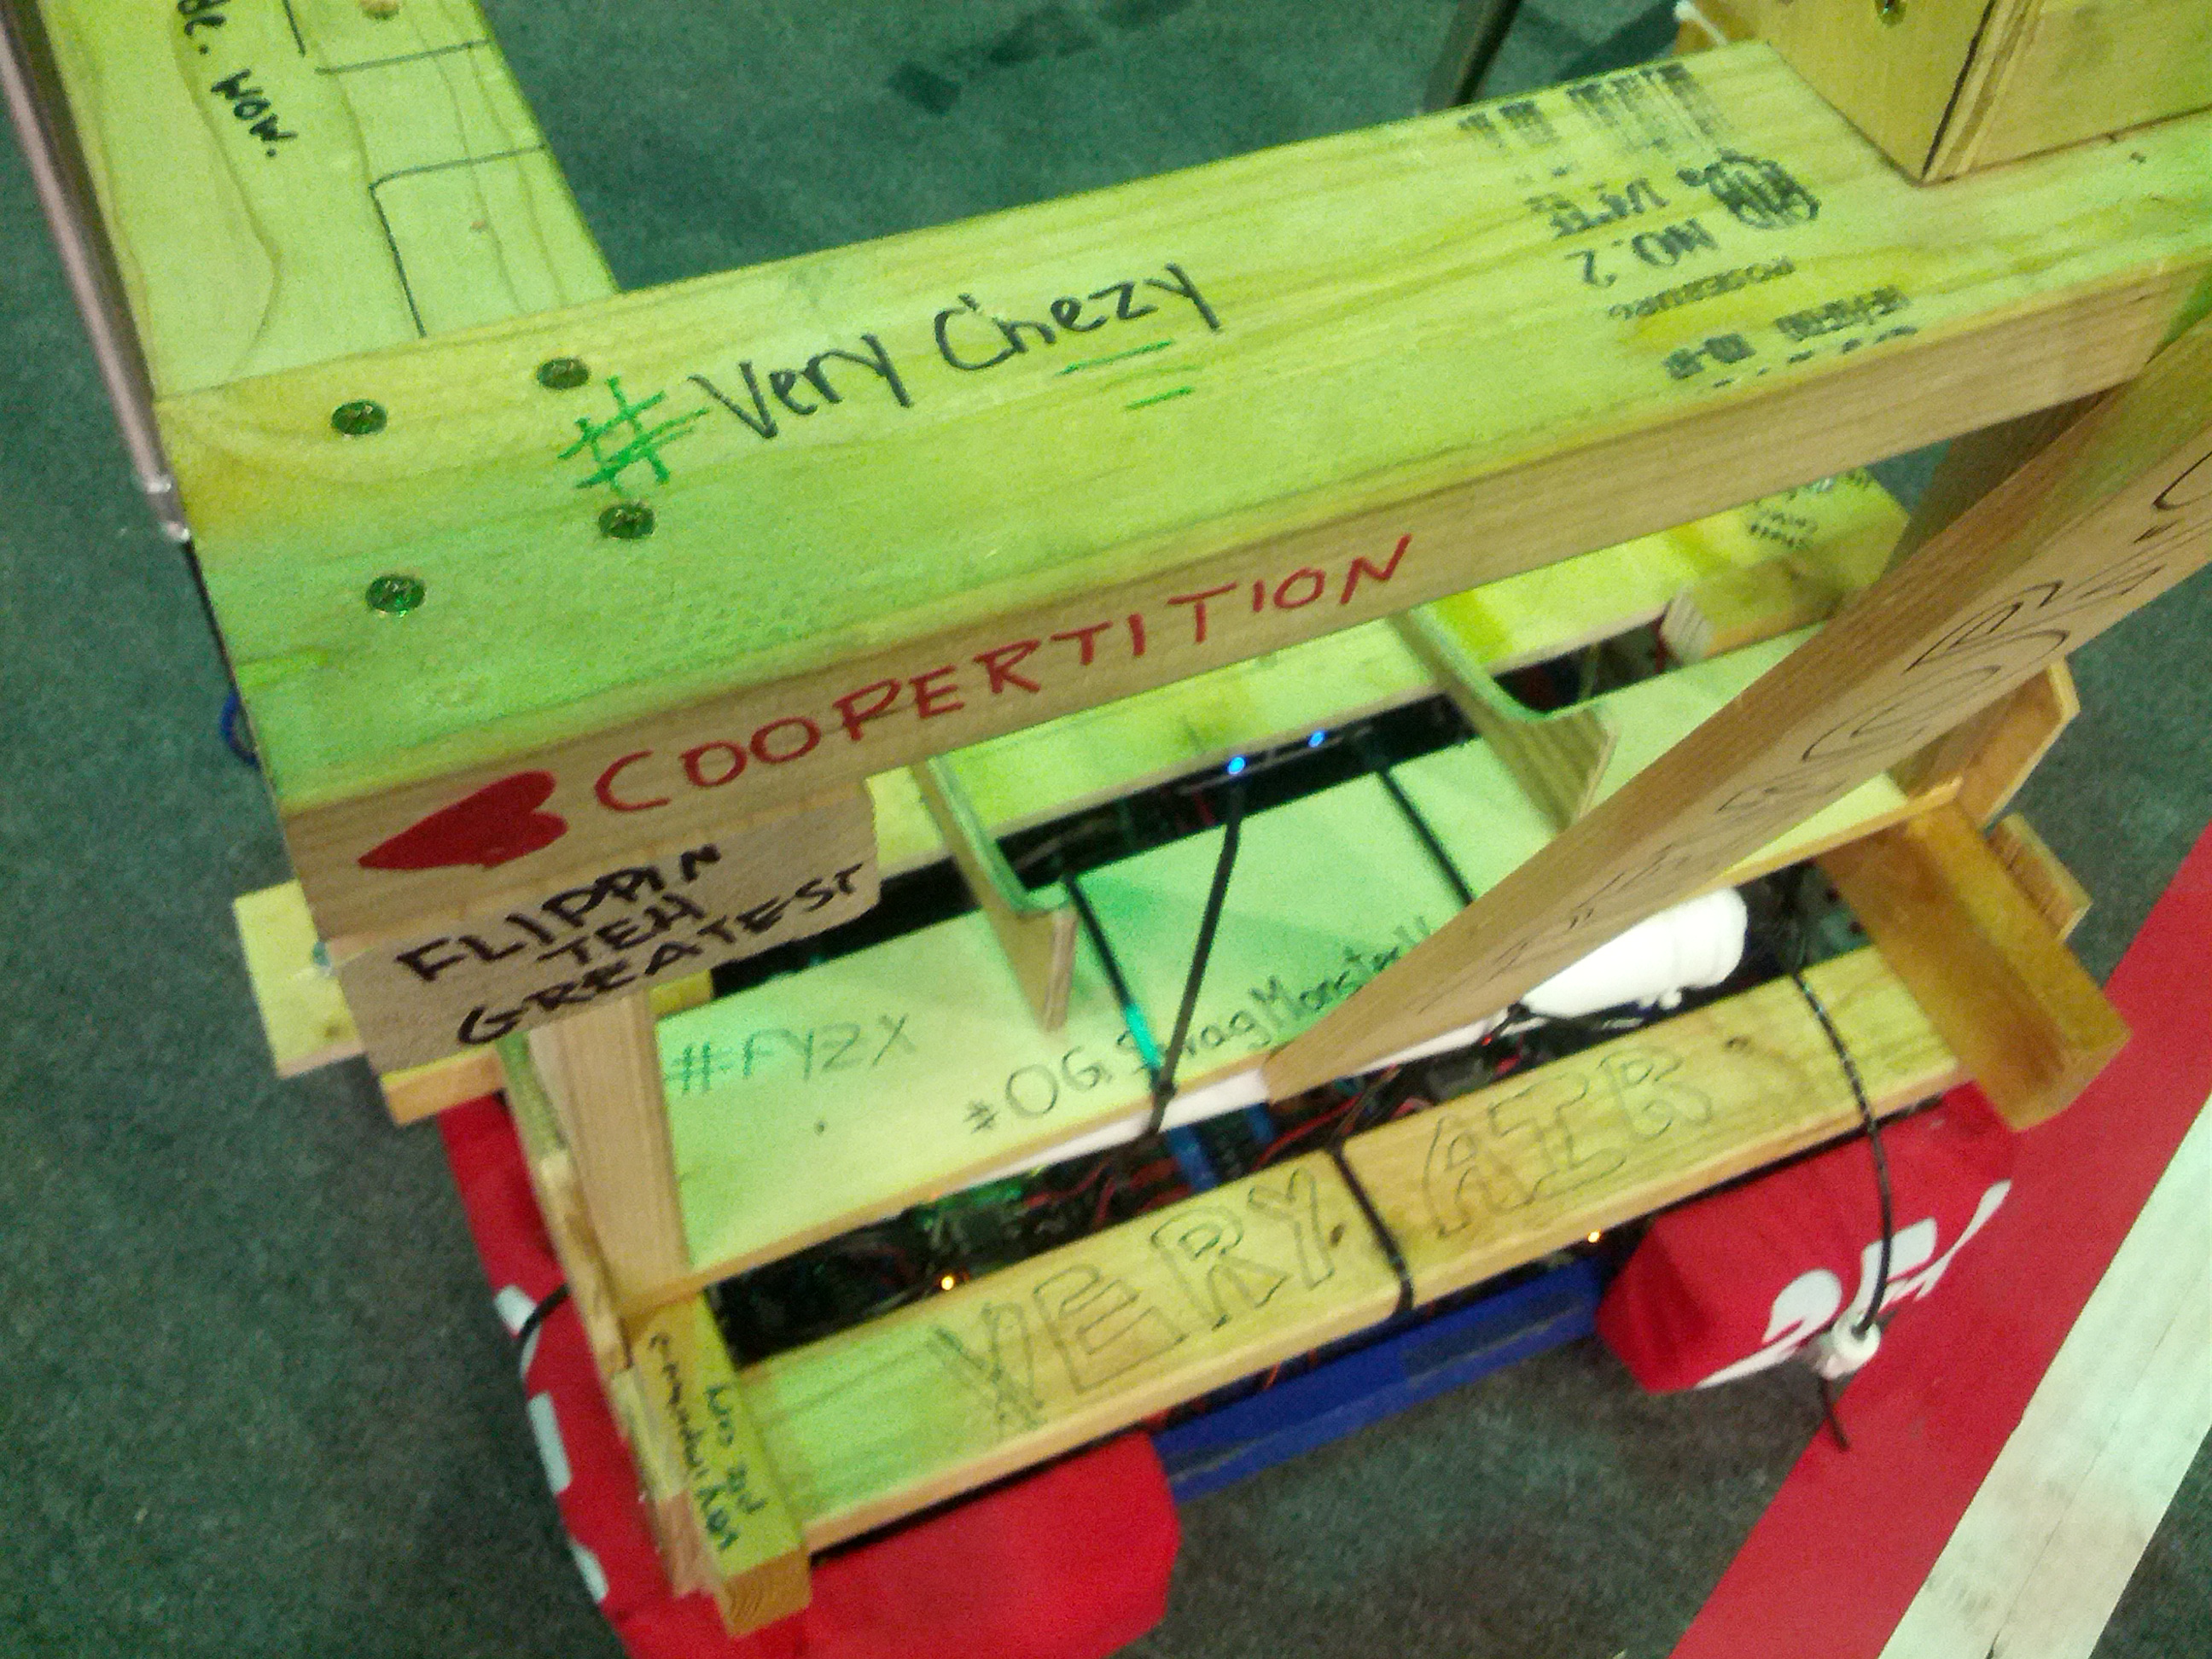
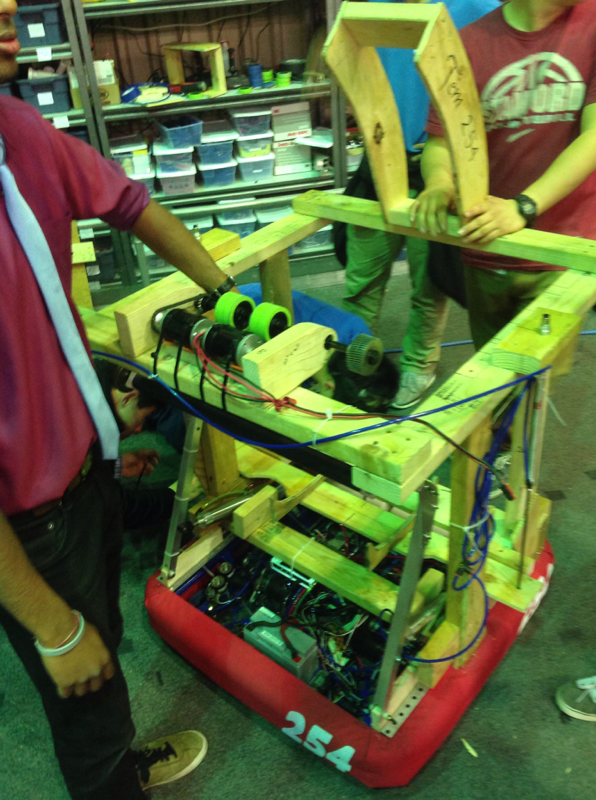
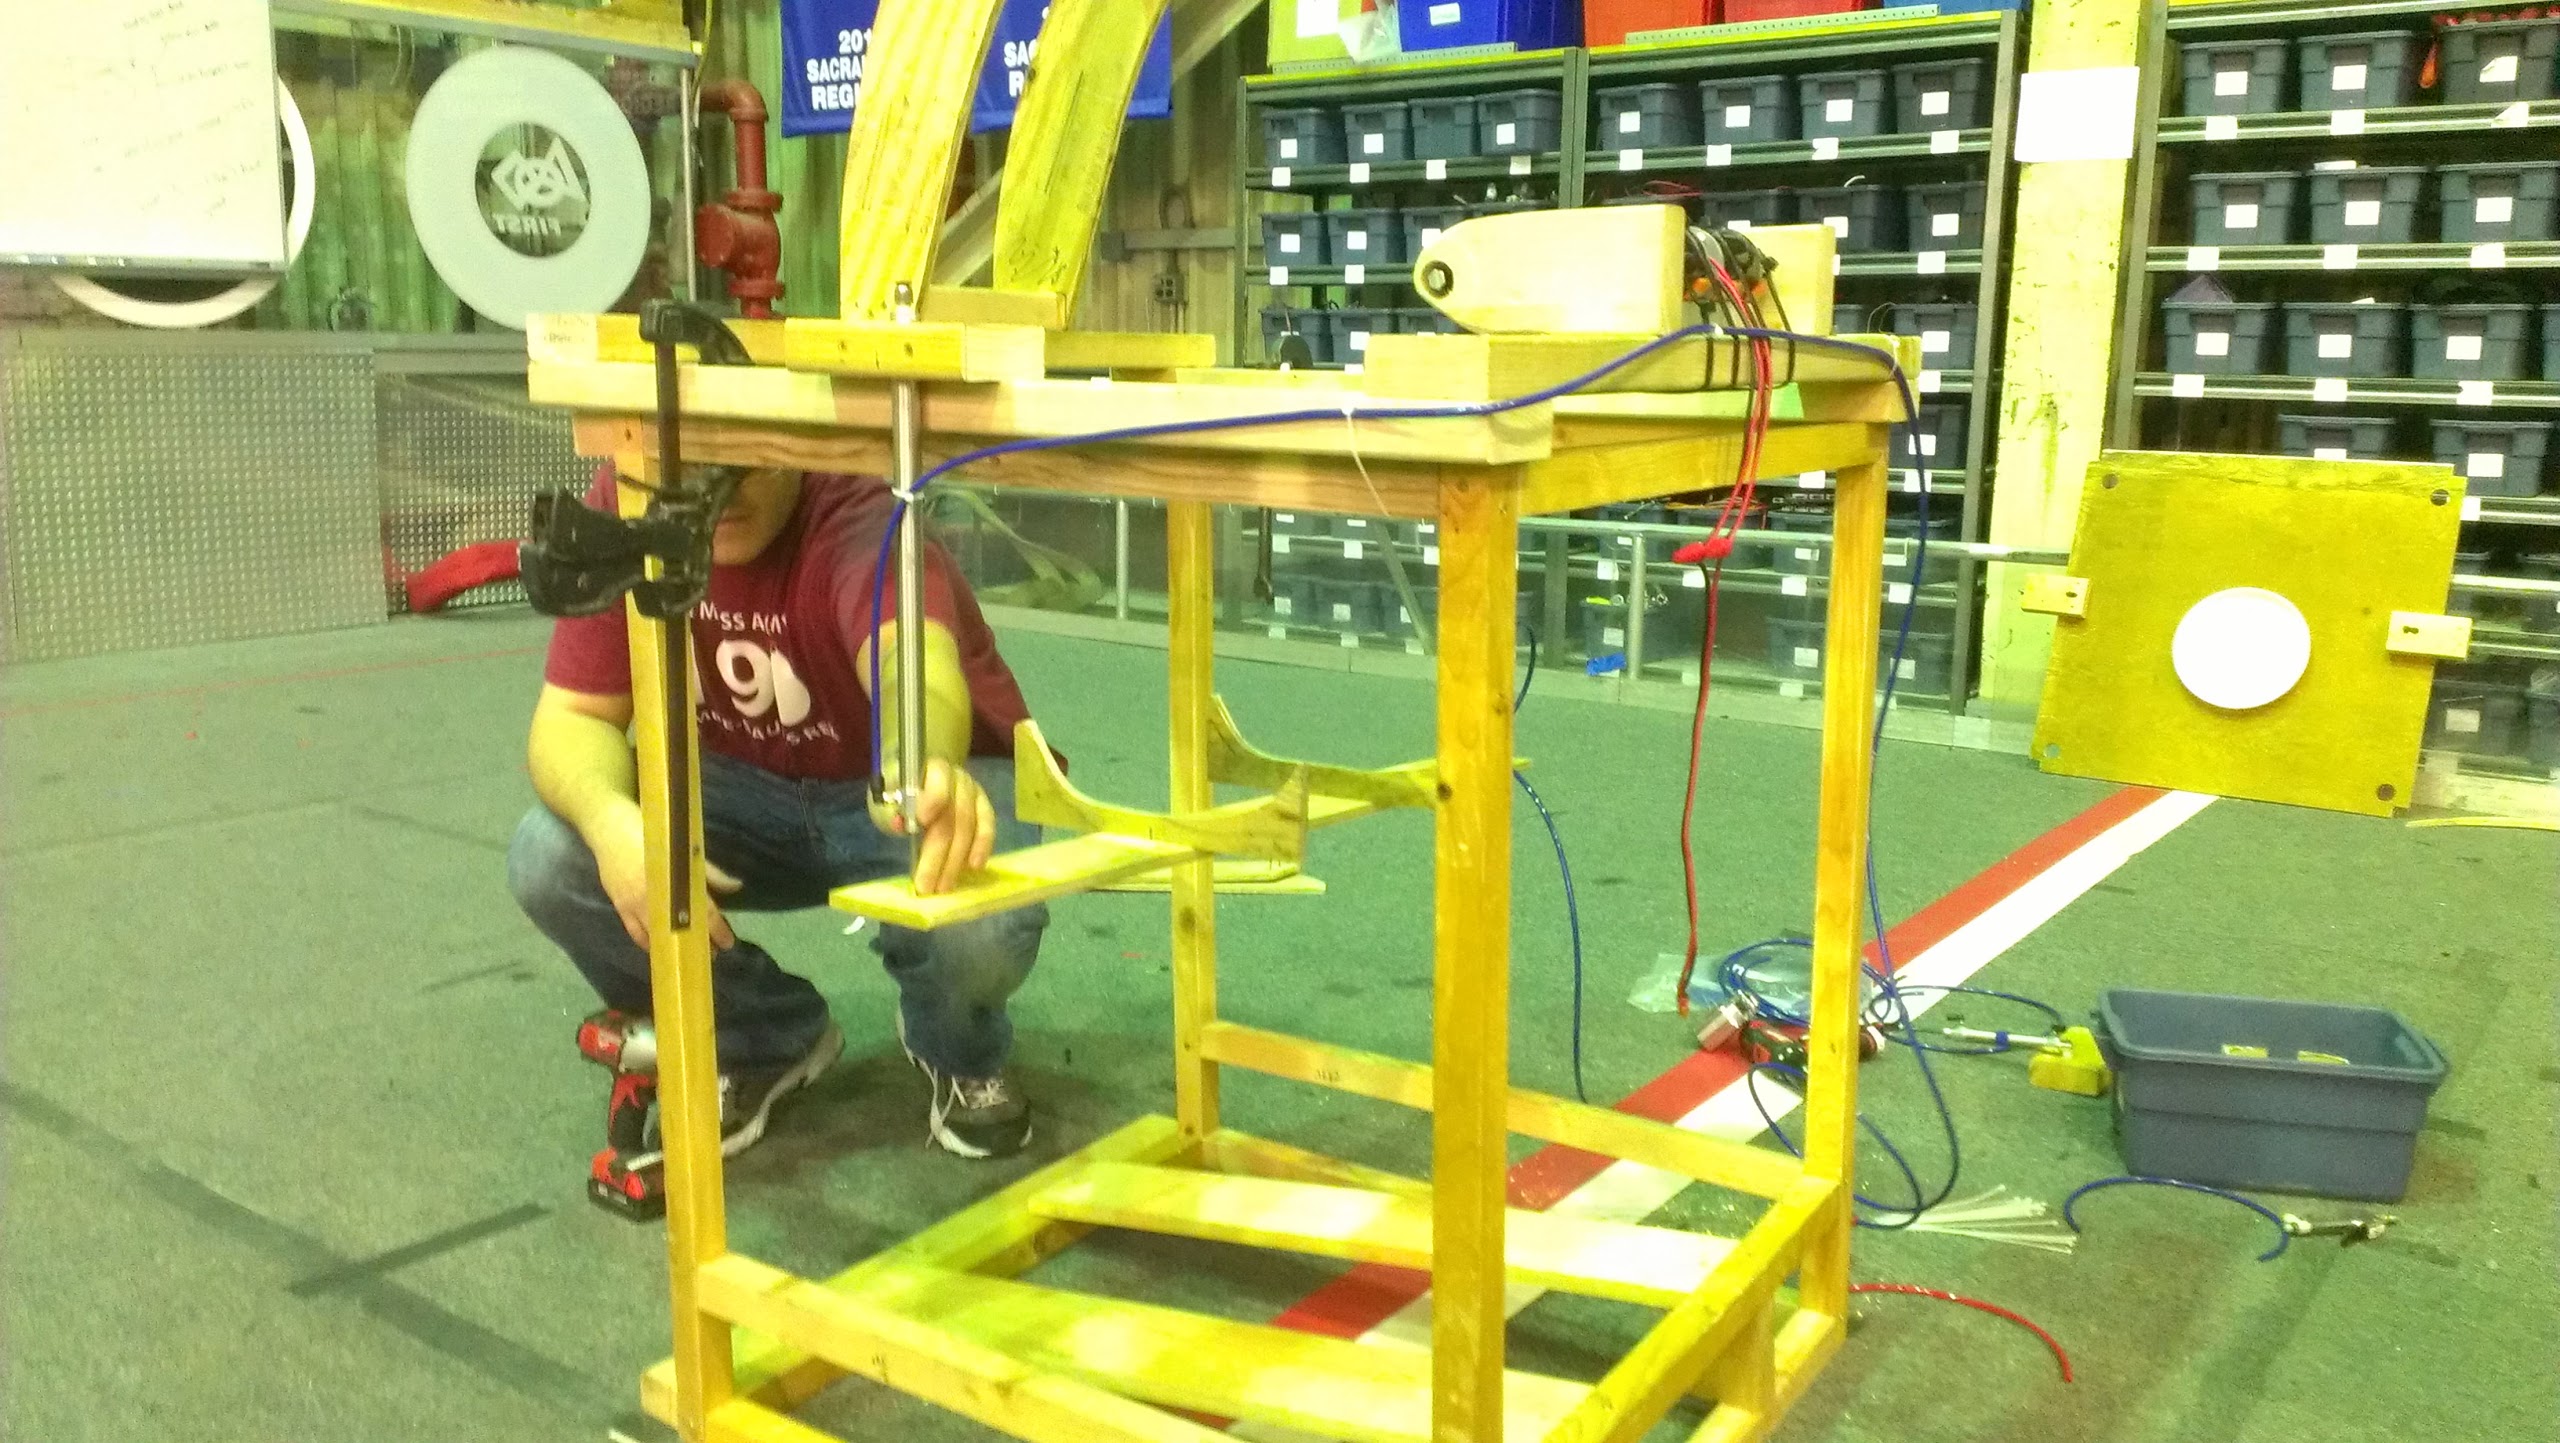
Today, there was no official meeting at the lab. However, several team members continued to work on robot design. Instead of a normal blog post, have some pictures of the latest prototype (sponsored by Tem 254: Teh Chezy Pofs). As you can see, the students…
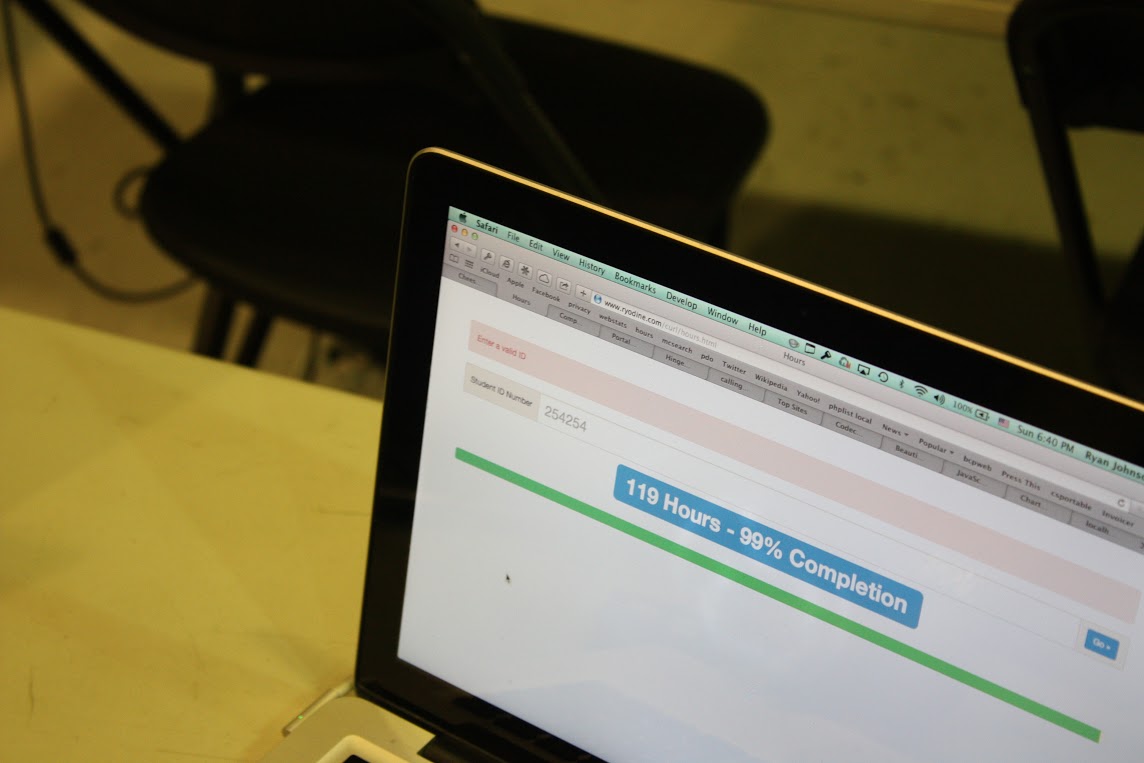
Programming Today, the programmers worked on two major projects and a smaller one. The two larger projects were a data logger for the robot and an app for members to check their FRC Hours. The smaller project was to get Adobe products which had been…
by Clay Rosenthal Important Reminder Wear safety glasses on bottom floor of lab at all times! Even if you are not machining or there are few people in the lab this is a requirement. CAD Today, work continued on the design of the inner plates of the hood. We…
by Christian Bagamaspad and Michael Simeon Robot Prototype The robot prototype changed considerably today. First, the shooter prototype was mounted to the 2013 drive base. The robot can now drive, intake, load the ball, and shoot in one test. Results were…
by Jeffrey Kaufmann Flywheel Prototype Today, work continued on the automated ball loading mechanism for the flywheel prototype. This "popper" will use two pneumatic pistons to quickly and precisely load balls into the shooter for more consistent and…