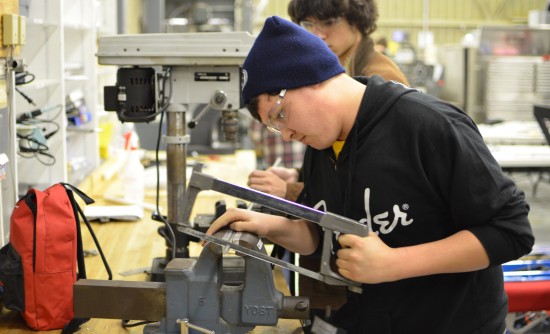
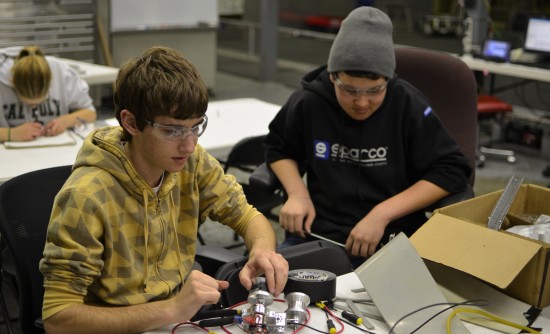
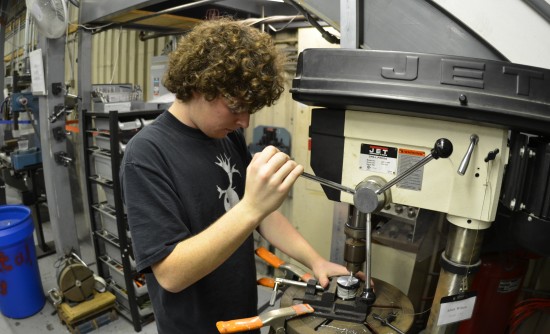
Manufacturing The manufacturing team was hard at work today on the mill, lathe and CNC mill. We made countless shafts and spacers, several major CNC'd parts that need to be powdercoated and worked on endcaps and the elevator second stage side rails on the…
Today was our second day off of the season. We're trying to take Sundays off so that team members have time to get all their homework done and just take a break from robotics. Although there was no regular meeting at the lab, our sister team 1868 was meeting,…
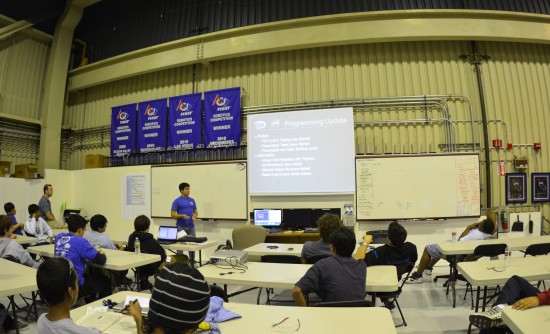
Programming Today, the programming team was hard at work on a number of projects. Their PID control of the robot is starting to work aweseome and the robot is at the point where it can traverse the whole field while only turning 1° (this translates to a ~1"…
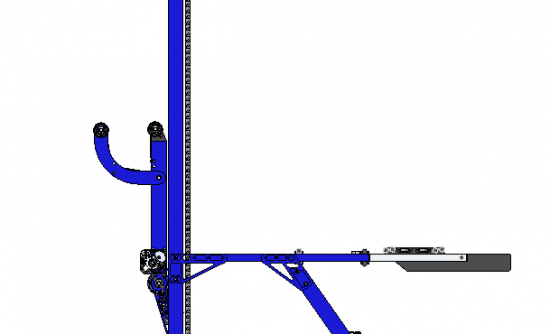
Design Today, the minibot group worked to put their minibot design into the computer. Furthermore, another group worked on finalizing the arm design. It was decided that the arm would need to be longer in order to properly grab the tube. Manufacturing The…
Prototyping Today, the minibot prototyping group continued to work on their small prototype utilizing small, machined concave-style wheels. They attached tread to the wheels and worked on weight distribution. Manufacturing Today, the manufacturing team was…
Prototyping Today, the prototyping team was hard at work on another minibot prototype. This prototype has had much of the weight removed in order to speed ascension times. Manufacturing Today, the manufacturing team worked to finish the drivetrain cams and…
Critical Design Review Today was our 2011 Critical Design Review (CDR). The CDR follows the Preliminary Design Review and includes nearly completed detailed designs. Many of the items presented may already be complete or in progress. This review phase is…
Design The design of the robot is coming along spectacularly. Since Saturday, we have continued the detail work on the various robot gearboxes and have continued on into Subsystem #4: Minibot Deployment. We have decided to build a secondary linear slider that…
Robot Group: Things we have accomplished so far: Basic Tele-op drive. Motors have been linearized. Travel exact distance almost works. Current things we are working on/To-Do: Pneumatics control/Gear Shifting PID/control driving Turn Exact angle Support for…