522 posts

Frame Ready for Welding

Shockwave Build

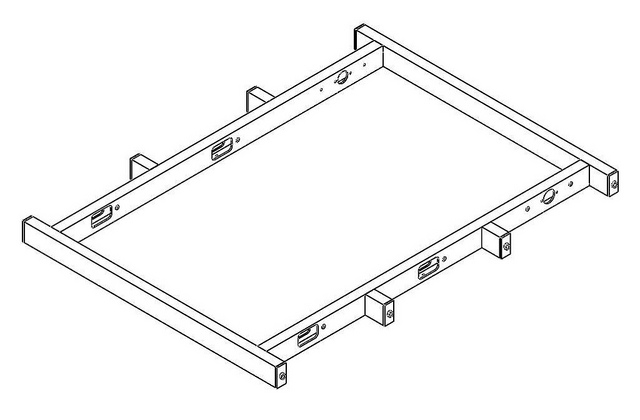
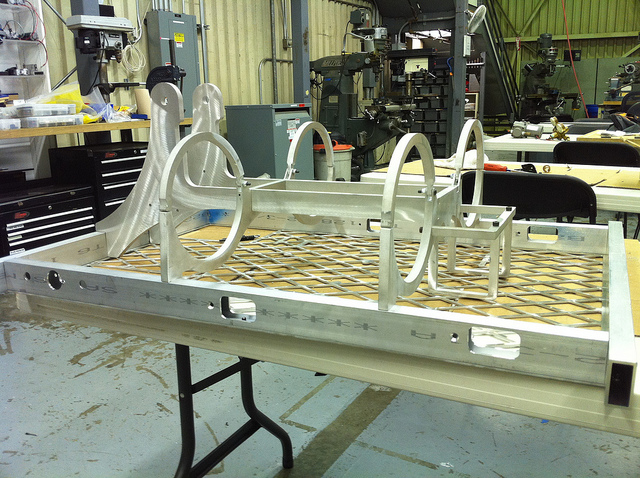
After several days of hard work, the frame of the T-Shirt Cannon is ready to be welded. The framerails have been machined and riveted onto the baseplate.  The superstructure frame has been pinned to the drivebase.  Finally, the mounting blocks for the sideshields have been cut and a welding jig to hold them in place has been made.

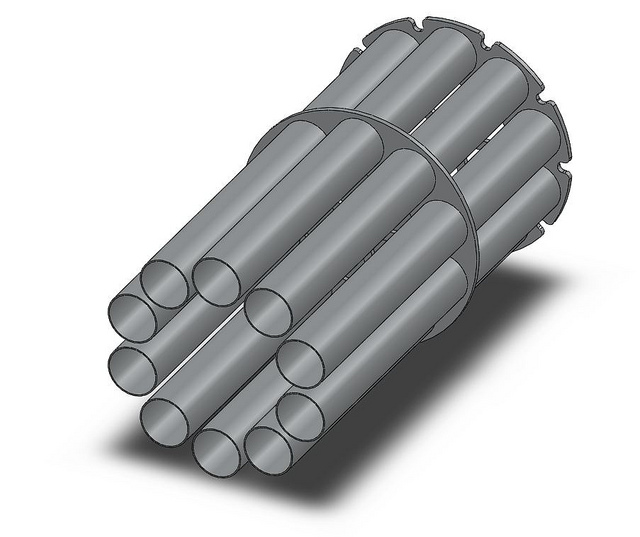
The revolver plates have been machined and the tubes inserted between the plates.  Once standoffs to go between the plates are machined, the assembly will be ready to weld.

We will hopefully get welding done early next week.
9409290103_c1b6fe5453_z

Frame Assembly

Shockwave Build

Today, we received our parts from BAE Systems, one of our sponsors who generously provided machining for this project.  After bringing the parts to the lab, we started assembly.  Furthermore, we cut the stock for the round barrels and began to assemble the revolver assembly, which will be welded next week.

Metal Arrives

Shockwave Build

The metal arrived at school today and we delivered the aluminum plate to BAE Systems, one of our sponsors.  BAE has generously offered to provide waterjet cutting for our project.  The parts are expected to get cut on Monday.

Meanwhile, at the lab, machining has started on the chassis rails.  They are expected to be complete by next Thursday.

Ordering Material

Shockwave Build

Today, we compiled the master list of the material that we need to purchase for the robot.  We already have some of the metal at the lab but most needs to be purchased.

After the list was completed, we ordered material which is expected to arrive on Friday.

Final Design

Shockwave Build

Today, we were able to bring all of the parts of the design together into one completed robot design.

We will be taking a short break from the build of the robot as school starts up again and will resume again during the first week of September.


Superstructure Design

Shockwave Build

Today, we went through and designed the superstructure frame that would hold the robot together.  We started by looking at our objectives for the superstructure:

  • The superstructure needs to support the revolver and the valve block.
  • The superstructure needs to support the SCUBA tanks.
  • The superstructure should hold the battery.

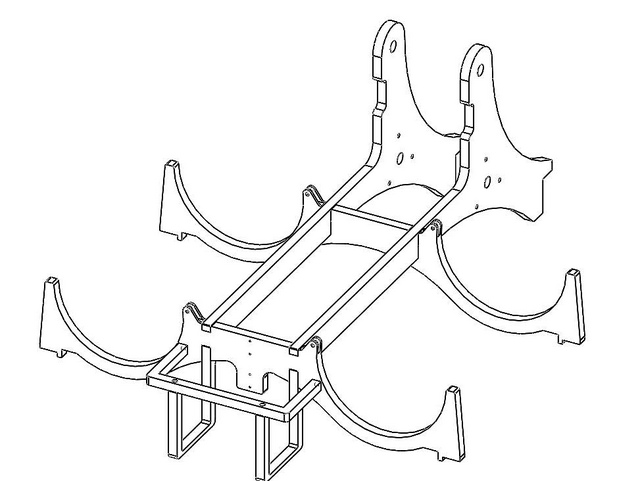
We took our design objectives and decided that building a frame out of 1/2" aluminum plate would allow us to build a very strong and light frame.  We designed several interlocking 1/2" aluminum plates which will be welded to form the superstructure chassis.  The frame will contain cradles to contain the SCUBA tanks as well as bars that will close down on top of the tanks to lock them in place.

9408245259_130e65d4e5_z

Electronics Board Layout

Shockwave Build

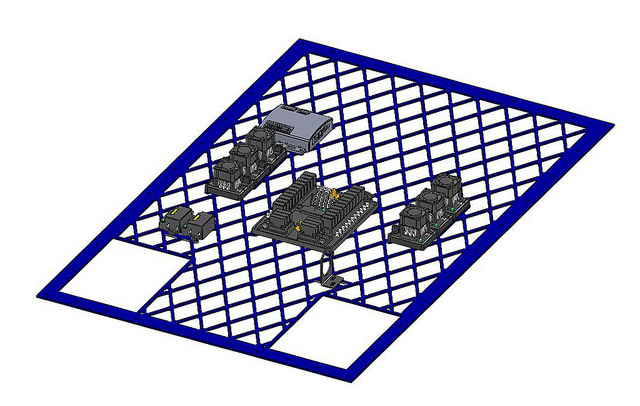
Today, we focused on the design of the electronics board, trying to get the board finalized.  We spent some time physically laying out the electronics, trying to find the best configuration to optimize our wire paths.  Also, we worked extensively on the design of the baseplate to which the electronics mount, finishing its design.

All of the electronics for this robot are made by VEX Robotics, taken from both the VEX Design System and the VEXPro line.

9410832478_bfdfa046e5_z>

Valve Block Design

Shockwave Build

The design for the T-Shirt Cannon is coming along great.  Today, one group of students started working on a preliminary version of the baseplate that will be used to mount the robot's electronics.

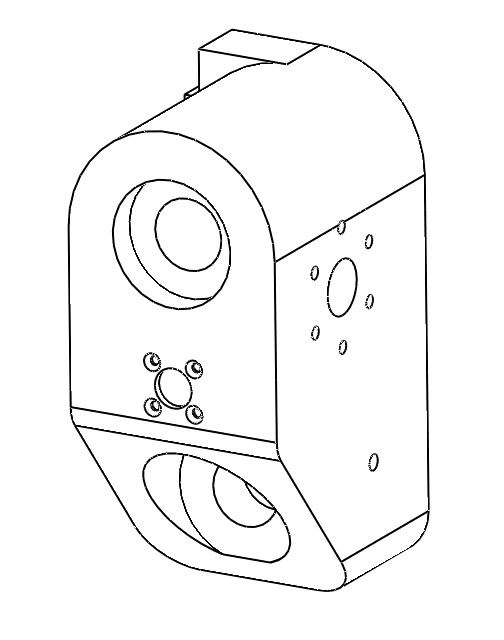
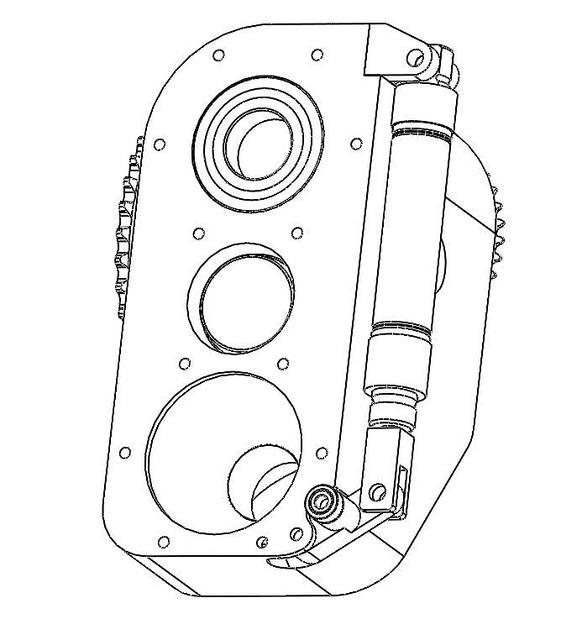
Another group of students continued to work on the robot's superstructure, starting to design a block that will serve as the mounting point for the revolver as well as the interface between the air hose and the revolver.  Part of this endeavor was to design an indexing mechanism.  The mechanism envisioned will have a lever with a bearing on the end that will roll into a slot on the revolver to lock it in place.

9408252559_2bfa75975e_z9408342977_a06b1372ab_z

Chassis & Revolver Design

Shockwave Build

The design for the drivebase is coming along great.  The frame members are mostly modeled and we have started to create the baseplate to which the electronics will mount.

9410857490_ffe99f81c2_z

Today, a separate team broke away from the drivetrain team and started to model the superstructure.  We started with the revolver, modeling a ten-barreled revolver with ten aluminum tube barrels connected with two aluminum plates.  The assembly will be welded.

9408180181_758293edb8_z

Design

Shockwave Build

Today, we continued to work on the conceptual design of the robot.  Some ideas we had:

  • It is necessary for the robot to be relatively narrow (<30") so that it can fit through a standard doorway.  We do not have any real restrictions on the length and height of the robot, but to keep it relatively manageable, we intend to keep it under 42" long.
  • If we moved the drive gearboxes from the center wheels to the back wheels, we could potentially move the scuba tanks lower to the ground and make the whole robot more compact.
In addition to working on general conceptual ideas, we started on the CAD design.  Several students worked to begin modeling the robot's drivebase.  The plan right now is to build a custom chassis specifically for this robot but to integrate some of the drivetrain components that we already have.