At the proving grounds, multiple teams worked on various parts of the robot to ensure that major components will be complete by the weekend. In the design department, students and mentors completed the PCB design for both the gyroscope carrier and a revised…
Due to a manufacturing error we are issuing an immediate recall of part no. 1010081. We apologize for the inconvenience this may have caused you. The part requires a bore to .722 in order to fit onto the 5/8 hex shaft. If you lack the tools necessary to carry…
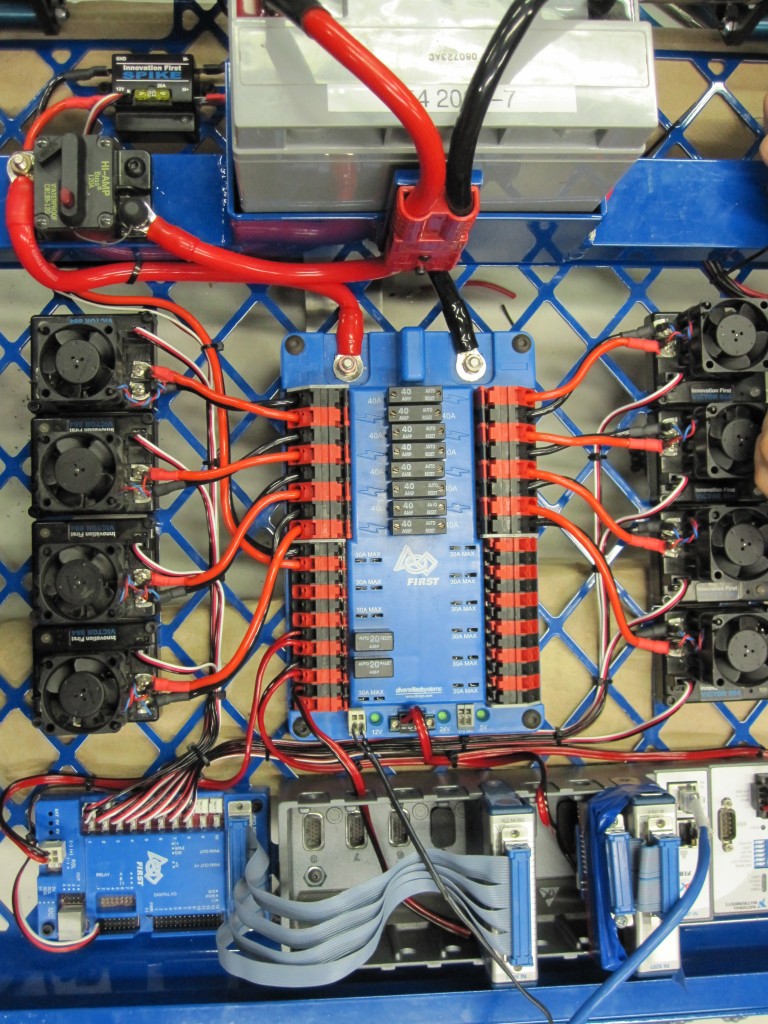
Today, wiring was done on the practice robot. PWM Mapping PWMs are labeled in a counterclockwise fashion, starting with PWM #1 in the upper left corner of the above picture and finishing with PWM #8 in the upper right corner of the picture above.
Today our procurement personell spent the day picking up several parts and materials, including plywood for the bumpers and switches, wire, and LEDs for the control boards. The plywood selected for the bumpers is a premium quality 12-Ply 3/4" Russian Baltic…
DESIGN The design is coming along and is almost finalized. The roller assembly is completely finalized and several small details need to be ironed out elsewhere on the robot. MANUFACTURING The manufacturing team worked hard today to produce several lathe…
After an all-night machining marathon last night, the arm parts were completed to be welded today. Our generous supporter Foes Racing was able to align and tack weld all the pieces into place this evening. Foes did the welding for the launcher and top arm in…
The official FIRST field components arrived today and were taken inside to be inventoried (and played with). Field setup will begin in the next few days, as soon as we determine which building we will be setting it up in. If you get the chance, please thank…
MANUFACTURING The manufacturing team has been working hard to produce a myriad of parts. The CNC has been running to finish the Dogs and start on parts for the Kicker. The lathe has been working to produce all of the shafts and spacers needed in the kicker.…
Today we were able to cut out the polycarbonate for a control board on the CNC router at Glendale Community College. It took much longer than expected, due to the polycarb melting at any feed rate over 18 IPM, even with a constant cool air blast on the…