The Cheesy Poofs
2010 Teams 254/968 Collaborative Build Blog
News, events, and updates from Team 254.
78 posts
Control Board
Roller Prototyping Progress
Today, we continued prototyping dual roller systems. We worked hard to emulate the drawings we had, but still found minimal success with the belt-driven systems. The faster the rollers were moving, the better the results. However, if the rollers were moving too fast, the window motors would stall and be damaged.
At the end of the evening, we strapped a Dewalt 3 Speed Drill onto the robot. With the shifter on middle or high speed and the clutch set very low, we were able to obtain and hold the ball extremely well. Videos of this system at work are below.
Original video unavailable.
Original video unavailable.
Robot Chassis Ground
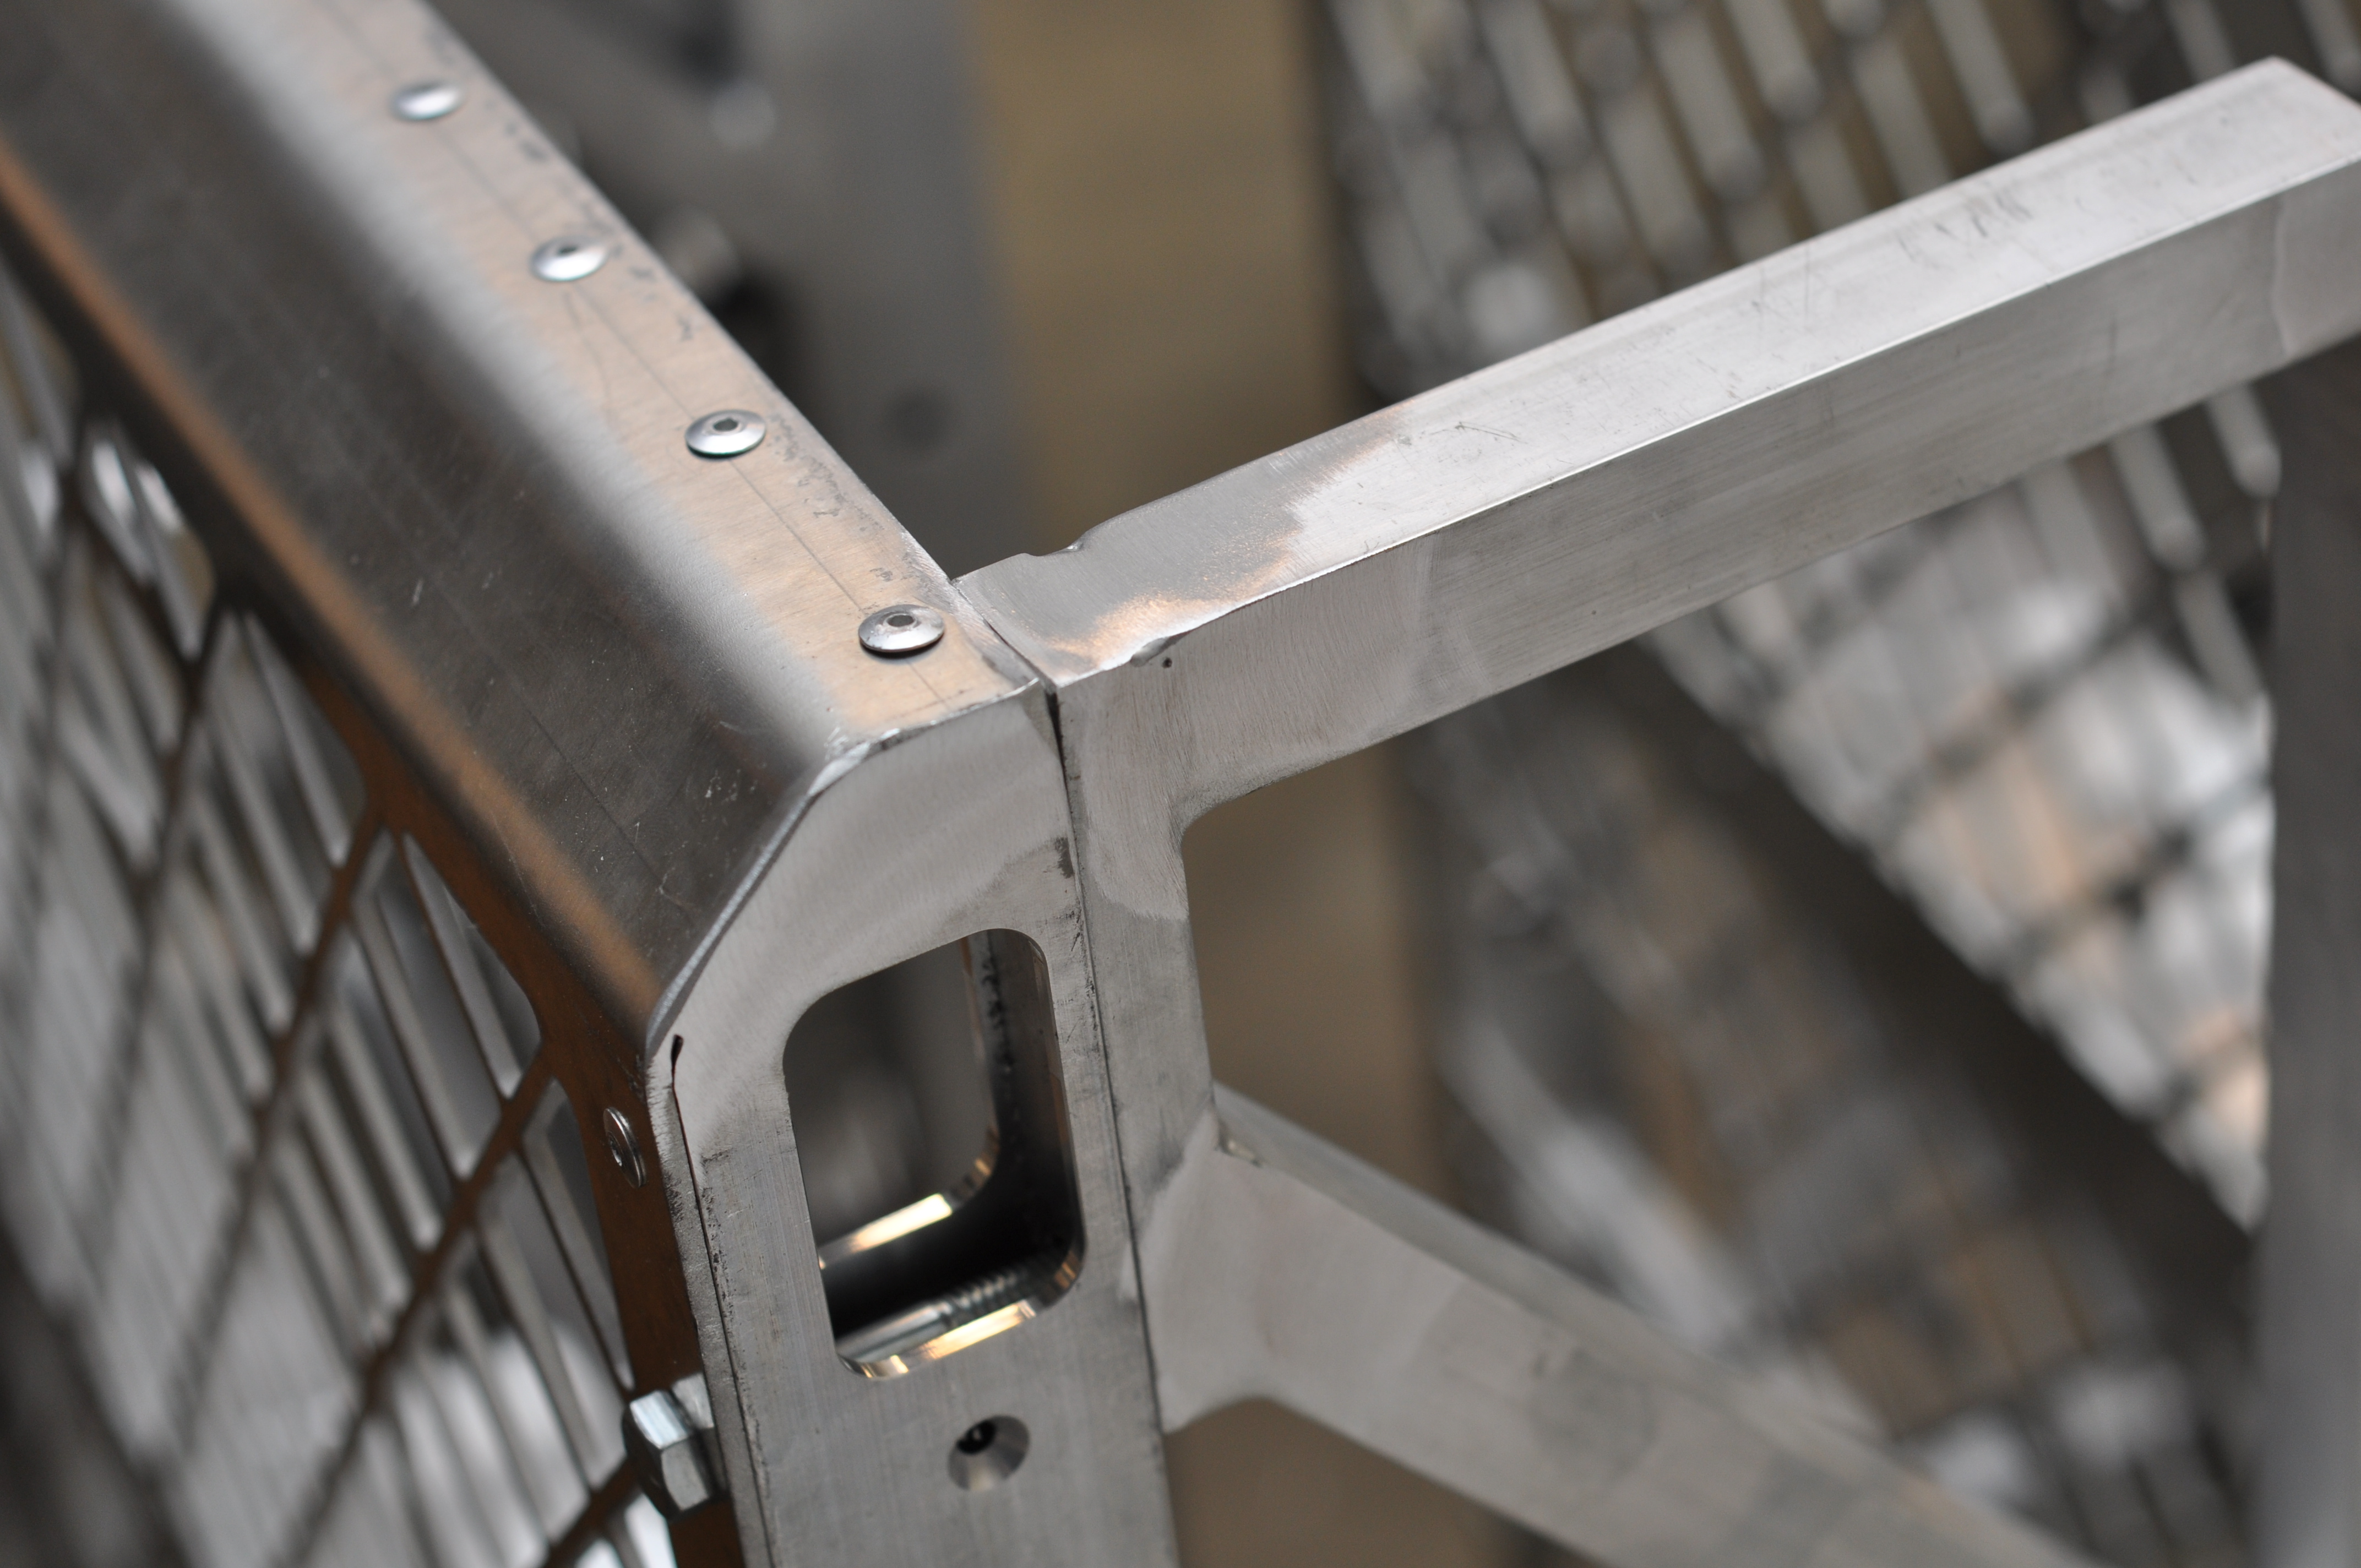
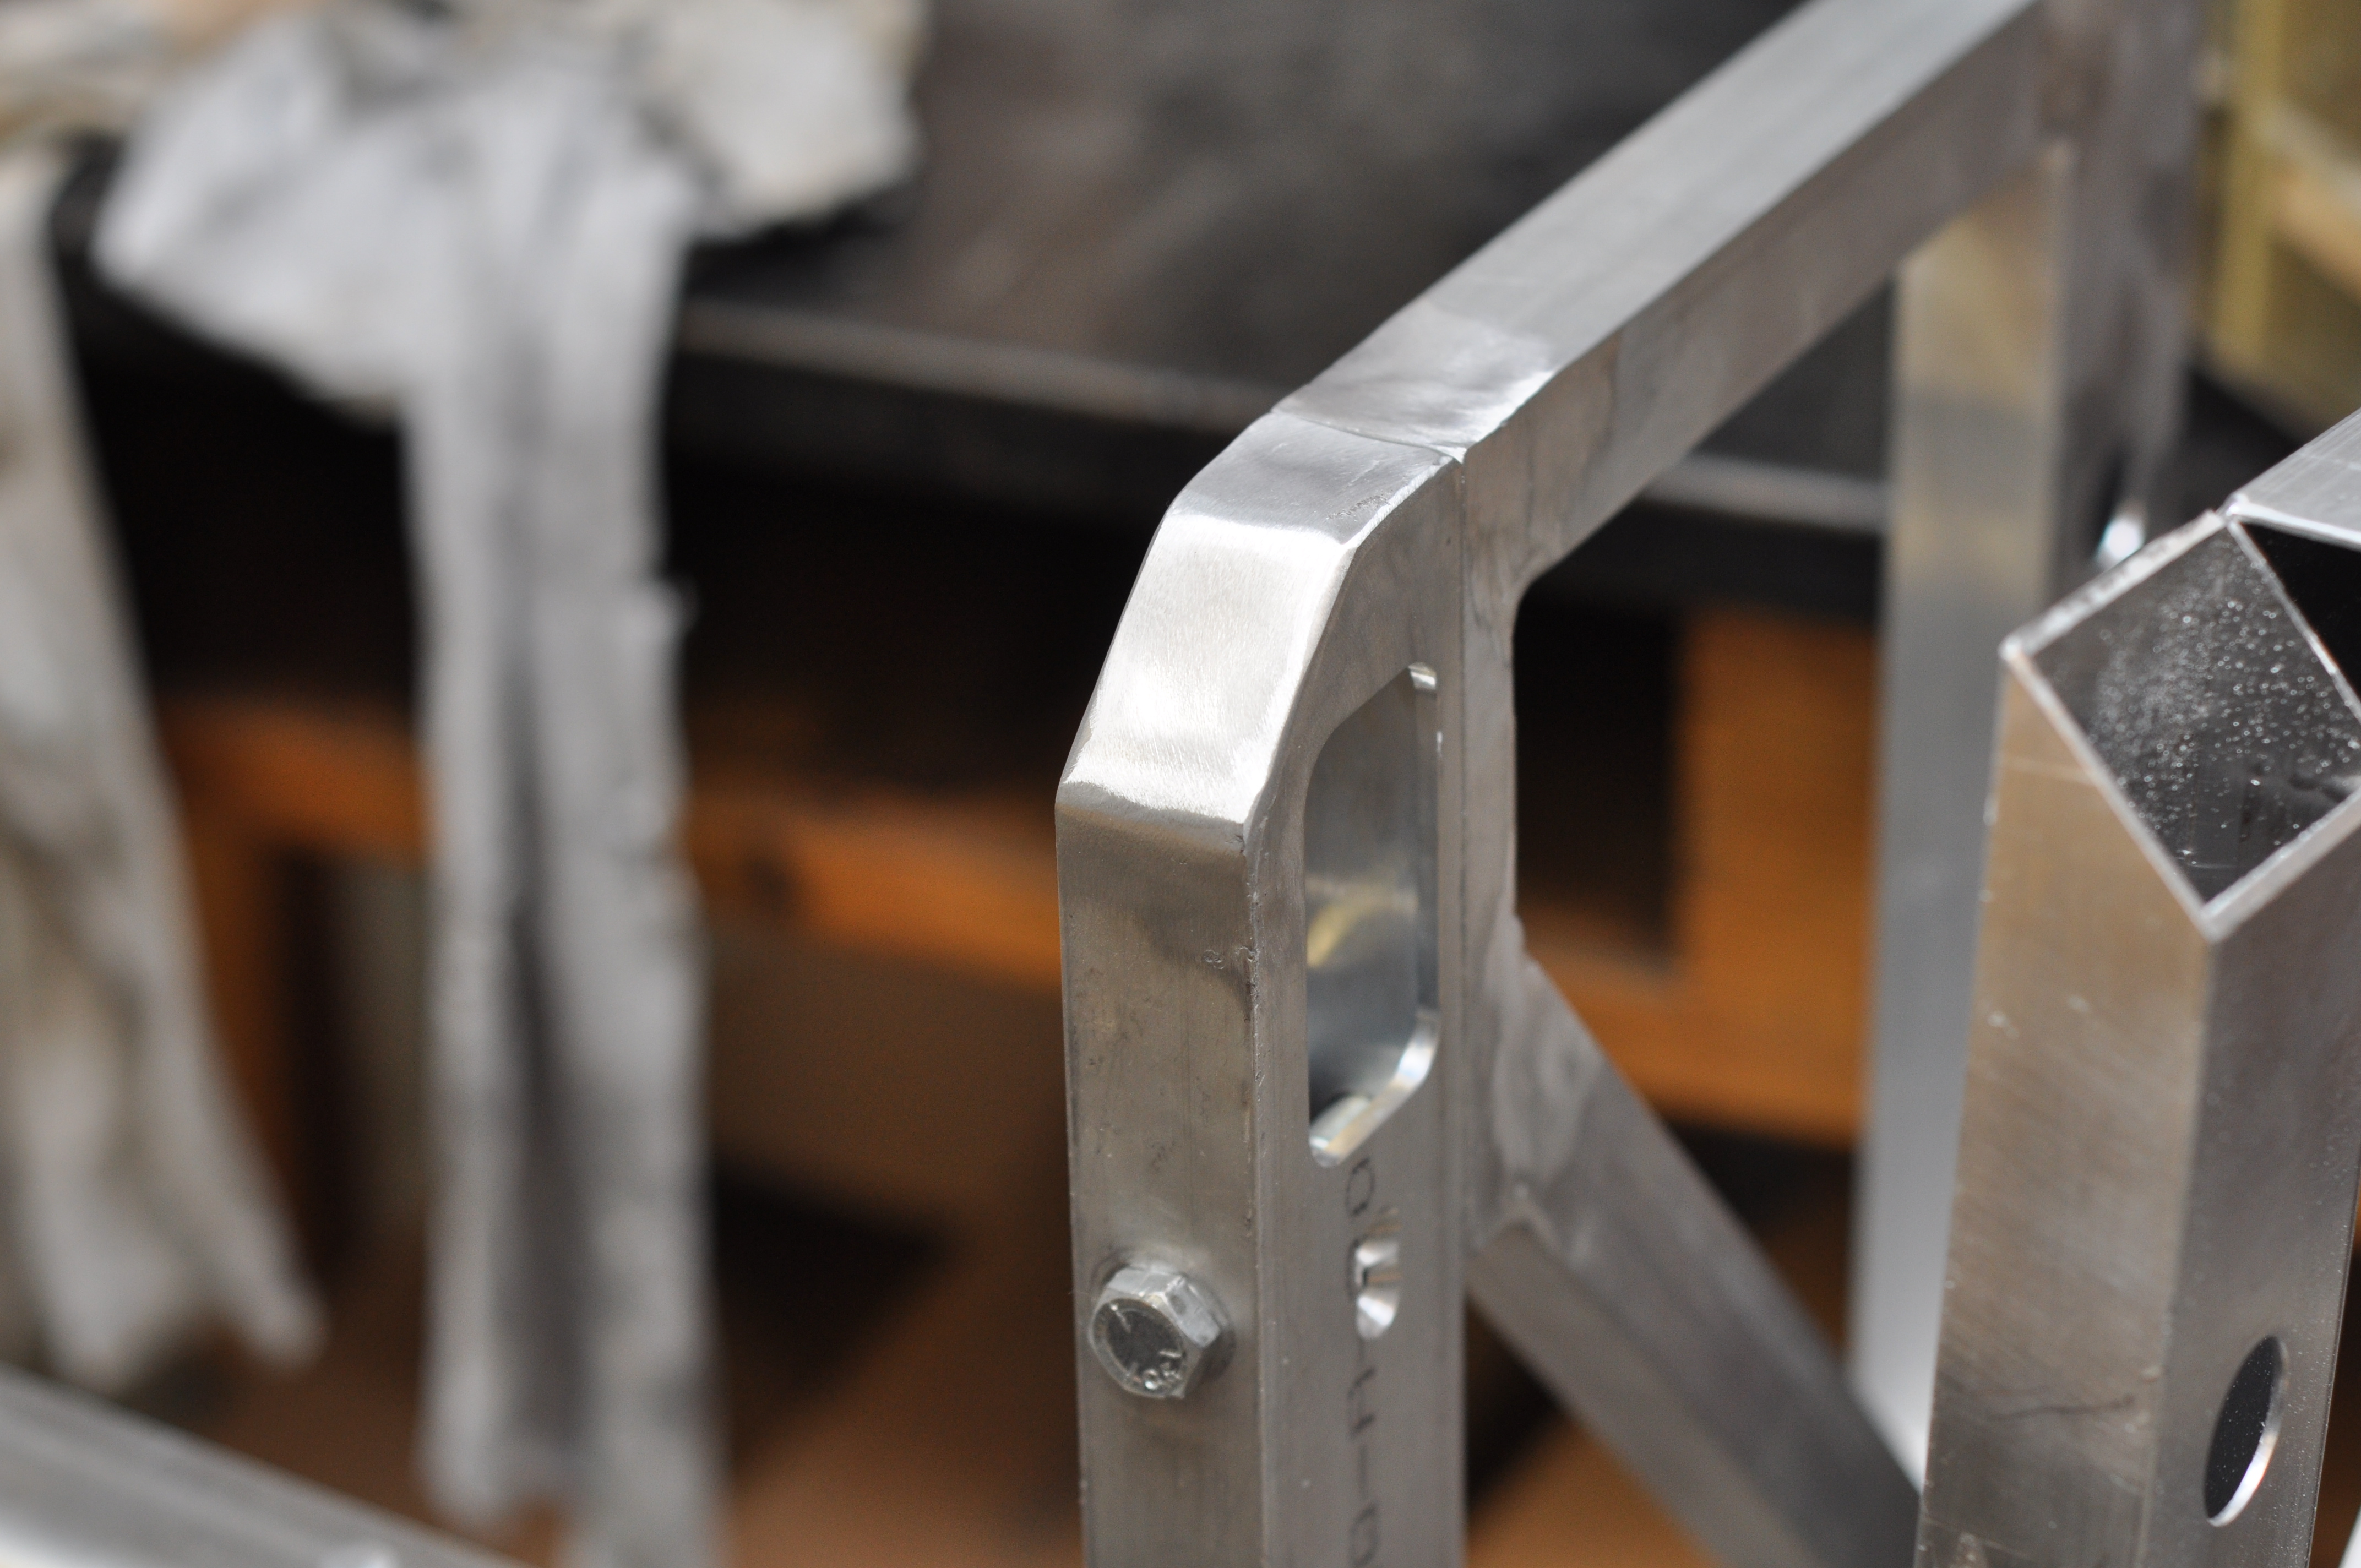
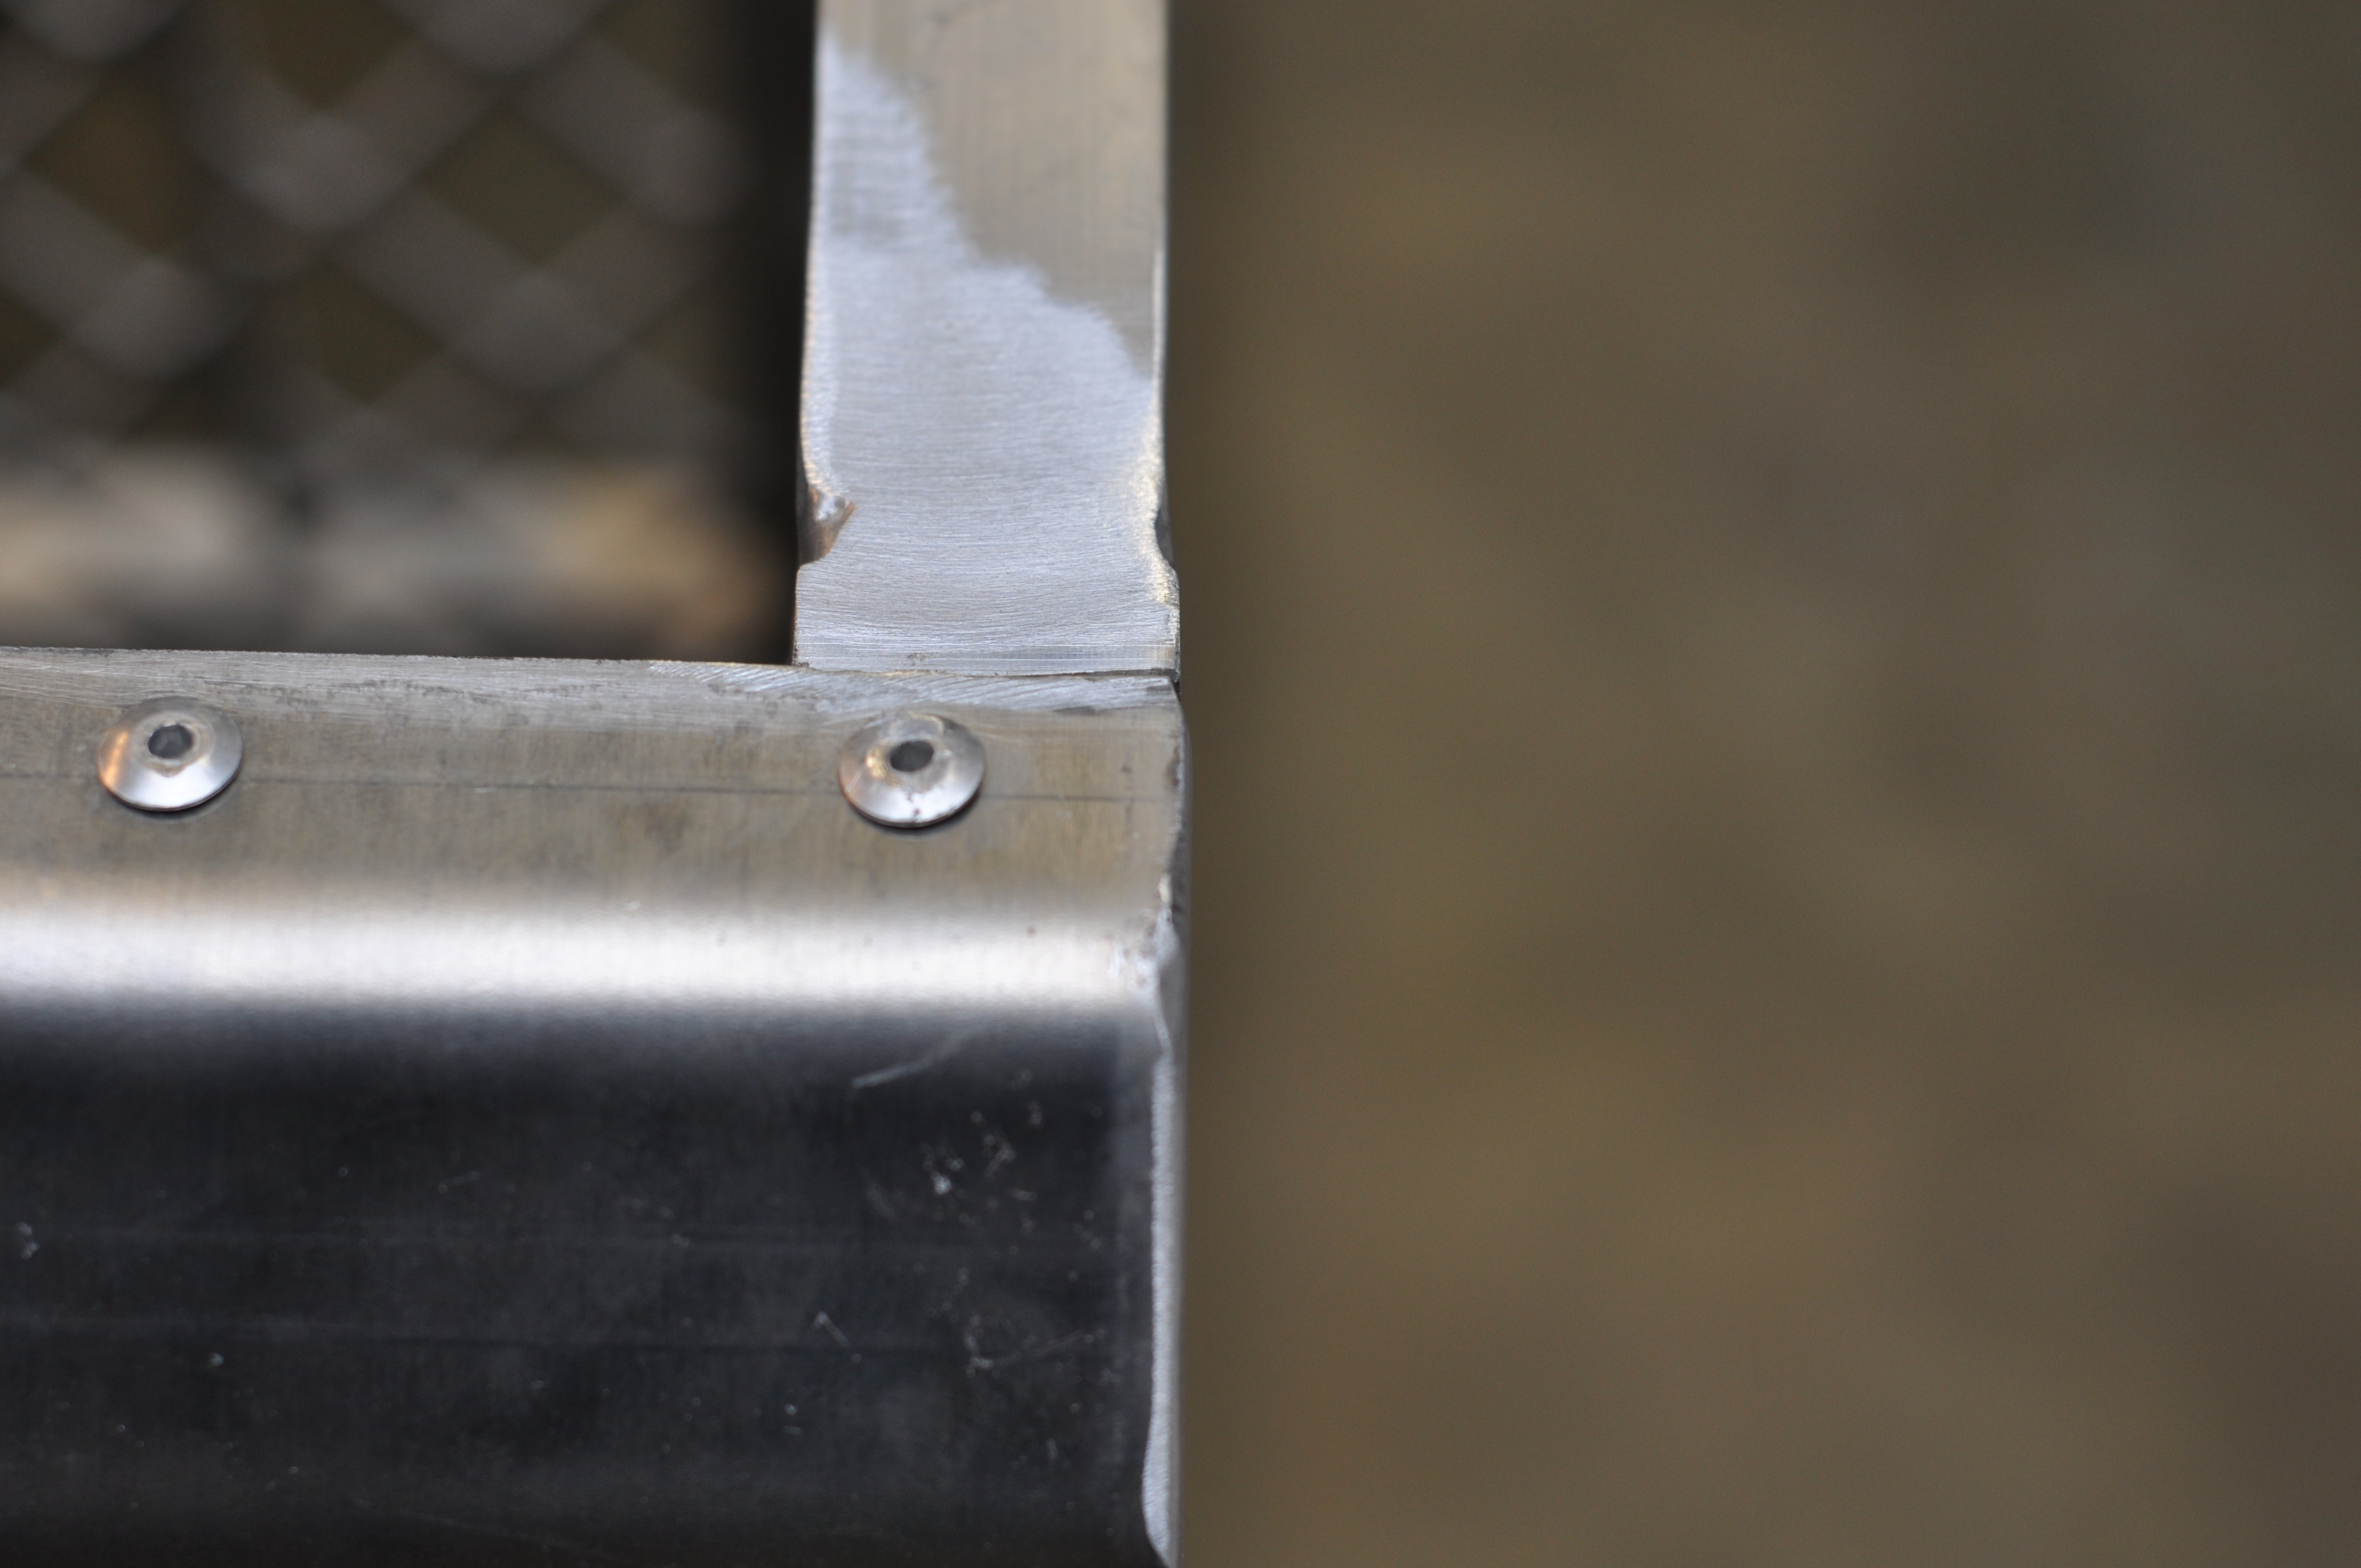
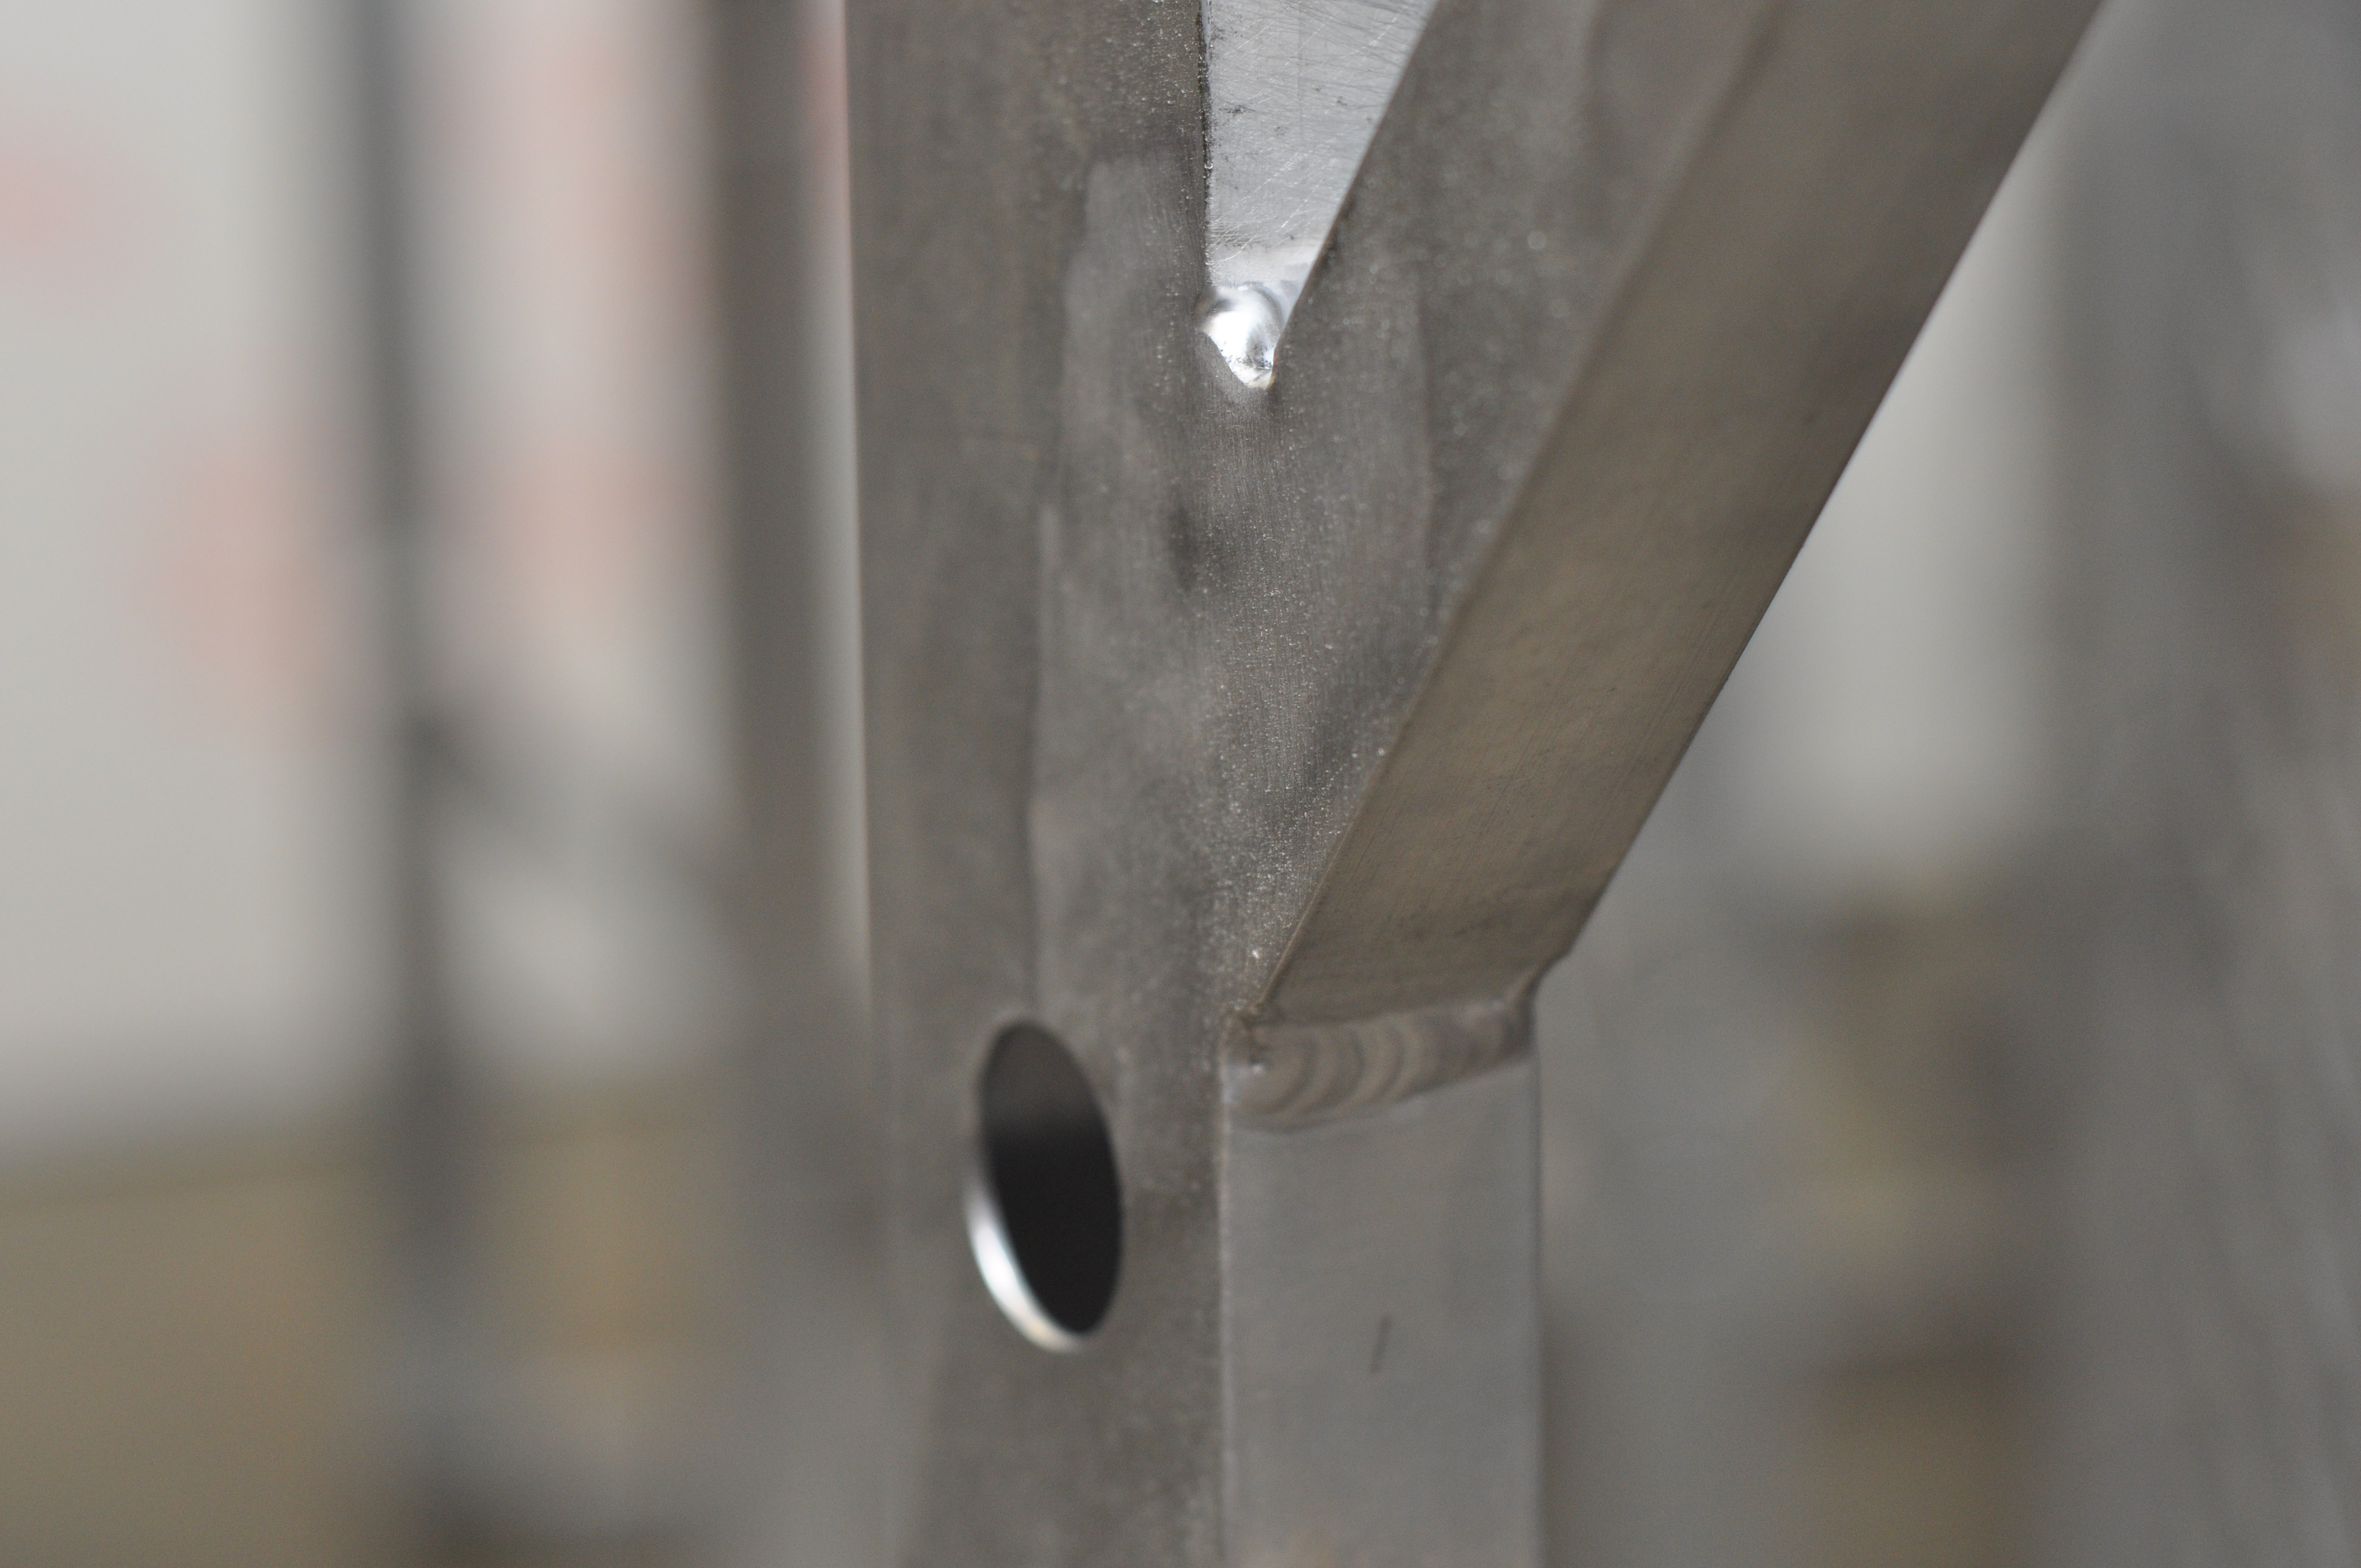
Here's a few shots of the welded base after having the welds ground flush.
General Update
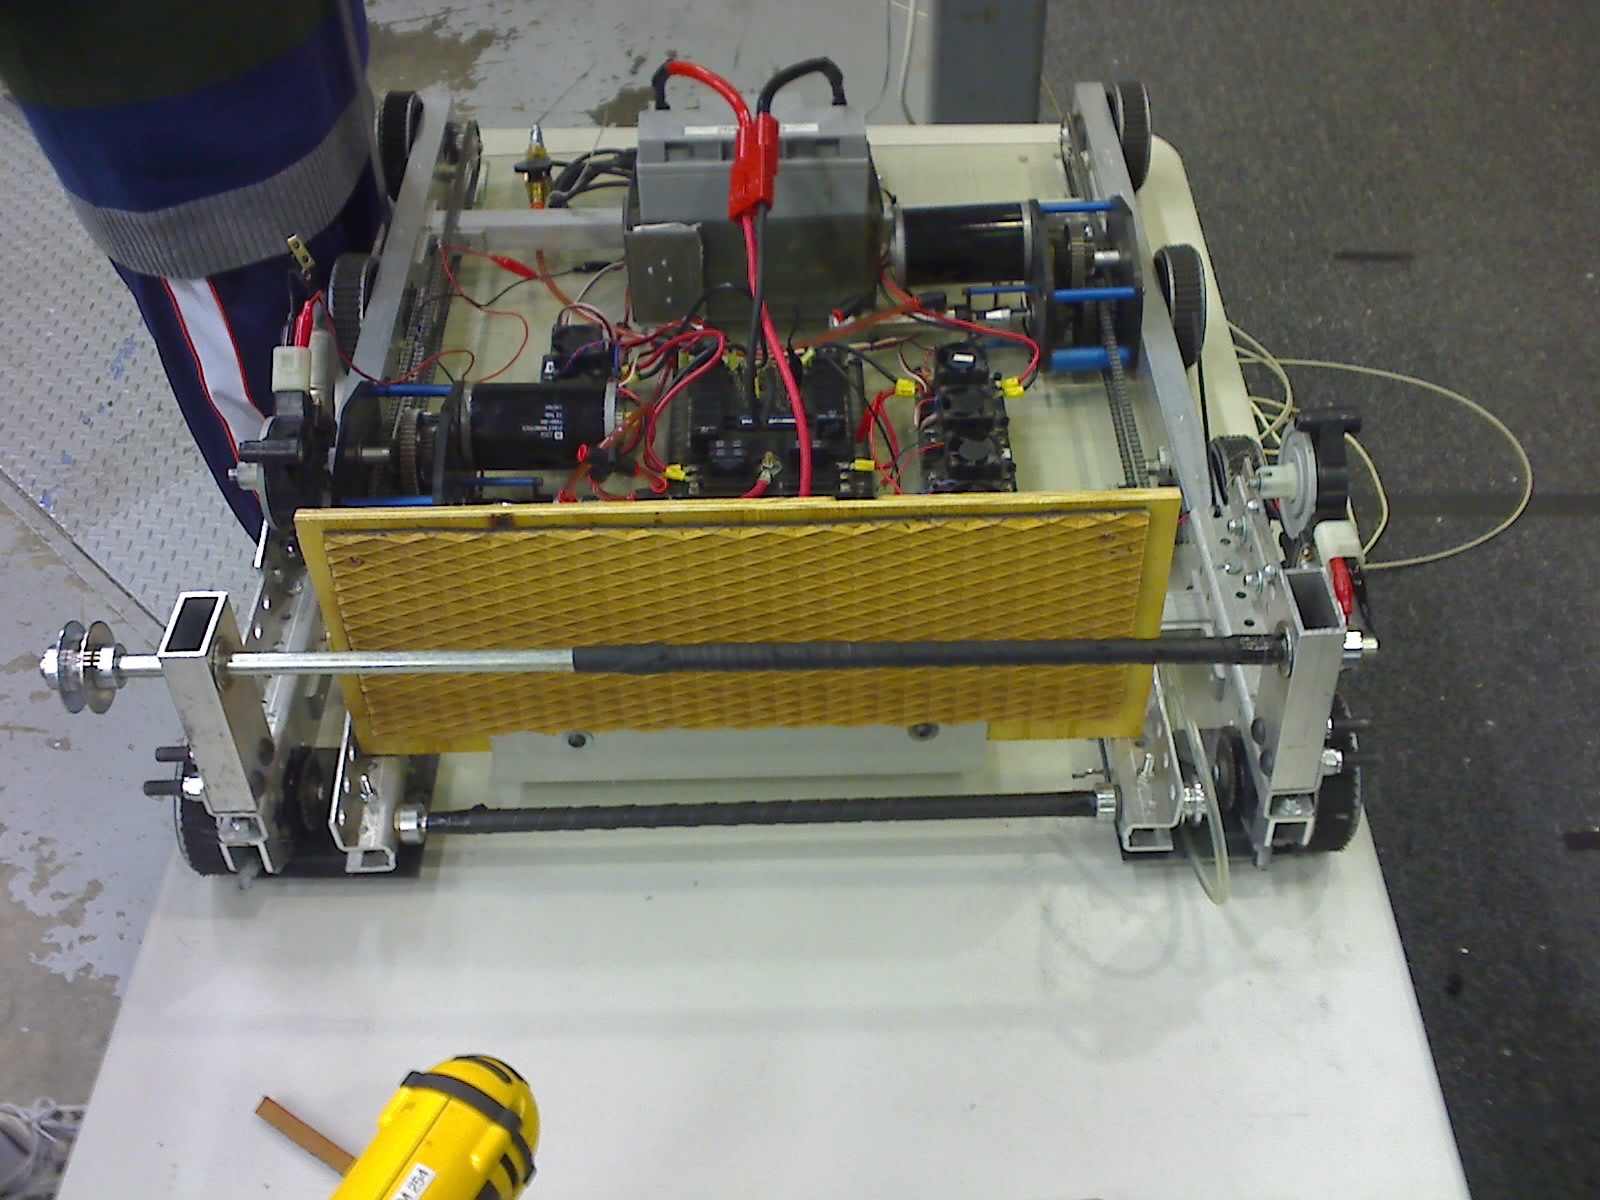
We continued to revise the two horizontal-rollers prototype so that it would be ready for proper implementation on the final design. Some of the most recent changes made include a stop, so that the ball is physically limited from entering more than 3 inches into our robot. Unfortunately in the earlier tests the ball actually entered 4 inches into our robot and roughly 1/16 inch off the ground. We also shifted the upper roller as forward as possible while retaining space for the bearing and moved the lower roller forward. The roller speed was also increased from the window motors with a 4 to 1 pulley reduction Videos should follow tommorrow after the design is perfected further.
Down in the shop we continued to pocket gears on the CNC and several sets for both the drive-train gearbox and the shooter winch gearbox have been manufactured already. Hopefully by the end of tommorrow we will be for the most part done pocketing the gears (at least the ones finalized on the design). They will be ready for ship by Monday or Tuesday.
Prototyping Progress
Dual horizontal rollers with tennis racquet grip tape = money.
Team 254 finally finished the initial prototype for dual horizontal rollers this evening (Based on 148's prototype) and after much tweaking we found that the rollers held the ball securely and within the limits of the rules. The mechanism uses two small window motors running continuously (at least in this prototype), and it has little difficulty with picking up a ball on the go. For a final design, the rollers should spin faster to ensure that the ball is picked up 100% of the time, and actual placement of the rollers will need to be tweaked to perfection.

Original video unavailable.
Original video unavailable.
On the third day...
After calling many fabrication shops in Southern California within a radius of 45 miles, we ended up at the California Polytechnic University, Pomona shop. Our metal forming division was lucky enough to find the proper die to create the 45 degree bends on a 100 ton press brake. Setting up the machinery and completing the bends took 6 hours.
Our newly acquired sponsor, TOMCO Products in Azusa, was able to perform the 90 degree bends with a very quick turn around.
Below are our newly trained press brake operators holding the first bent plate

Here's one of our highly skilled operators hard at work(or hardly working)

Here's a plate being formed

Here's another photo of a plate being formed

Here's our assembly and inspection division test fitting the formed pieces

Here's where Jesus joins metal with all his might

Oh, for your enjoyment
Original video unavailable.
Oh, and uhh.. here's the current status of the parts:
We currently have one fully welded base, two tacked bases, and one base waiting to be welded.
Jesus needs to take a break, so, he'll be back on Friday to complete joining metal.
Finally, below is an artist depiction of our team's weekly activities courtesy of our comic division:

The work of Jesus
Today, the battery boxes and superstructure sides were welded. We're attempting to bend the base plates before we go ahead and begin to weld the drive base.
In the meanwhile, here's some photos of Jesus and his special touch.
Jesus welding a battery box

The completed welds on the superstructure sides

Here's another shot of the superstructure sides

Here's the battery box plates before they're welded.

Attempting to center the battery connector tabs

Here's the jig that we used

Here are two almost-complete battery boxes(tack welds need to be filled in)

In the hands of Jesus
The events portrayed in this post are from 10:30 PM to 6:47 PM. Events occur in real time. (Que 24 music)
10:30 PM: Kiet and Richard leave West Covina to meet Kirk in Kettleman, CA.
1:40 AM: Goods are exchanged (as pictured)
Loading the goods to the Prius

All the goods are accounted for
8:00 AM: Arrive at Ride and Show with robot parts. Assemble the superstructure sides and Jesus tack welds all 8 pieces.
Three superstructure sides that were just tack welded

These superstructure sides cleaned up and ready to be welded


Jesus welding a superstructure piece


3:00PM: Shafts are picked up from Pacific Precision
3:30PM: Jesus welds 4 superstructure sides and the other 4 are ready for tomorrow morning.
Four fully welded superstructure sides

Four fully welded superstructure sides and the other four are ready to be welded

3:40 PM: Picked material to make the back tube for the robot chassis and will be machined later today.
4:00 PM: Shafts from Pacific Precision are picked up.
5:20 PM: Battery Box Side Plates are finished and prepped for welding tomorrow.
Battery Box Side Plates

5:40 PM: The Battery Tabs are prepped to be drilled and tapped at Ride & Show tomorrow
Battery Tabs Queued For Machining

6:47 PM: Shafts are packaged and shipped to 254
Kiet will be escorting the box to shipment location
Zero to Robot Parts in 6 Hours (or so)
All of the robot chassis and super structure parts were completed today and are on their way to West Covina to be welded and then powercoated. The front plugs will be machined tomorrow and will be mailed down to arrive on Tuesday at the same time that the base plates that Mike D from team 233 made for us.
Here is a picture of the 12 different sets of pieces that are on their way down.

Here is a picture of the pieces set next to each other to give you an idea of what it will look like completed.