88 posts

Day #5: Continued Prototyping

2013 FRC Build SeasonFIRST Robotics#FRC Build Blog

Today was a very productive day at the lab. There was a lot of progress made in many areas.

Prototyping

Shooter Prototype

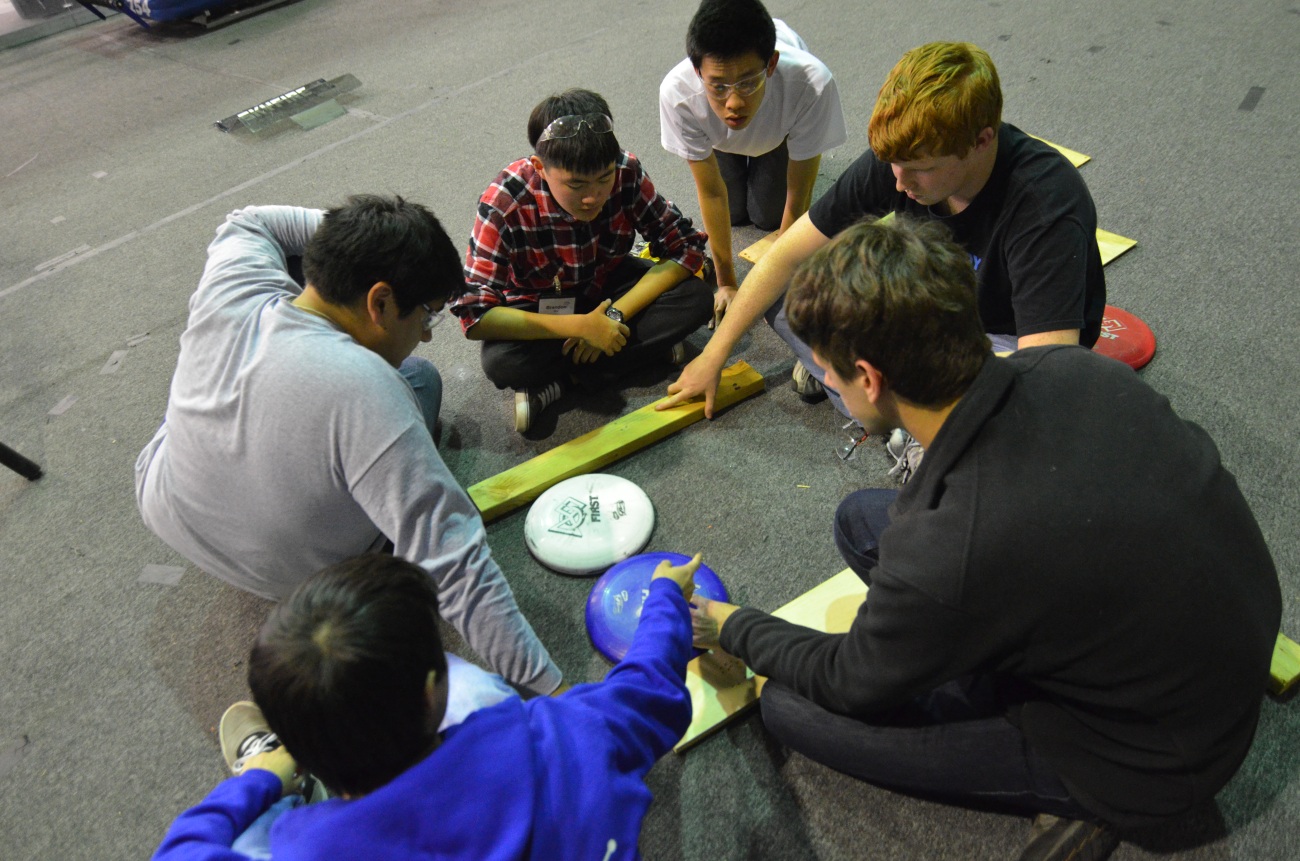
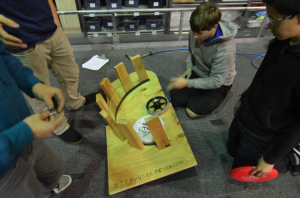
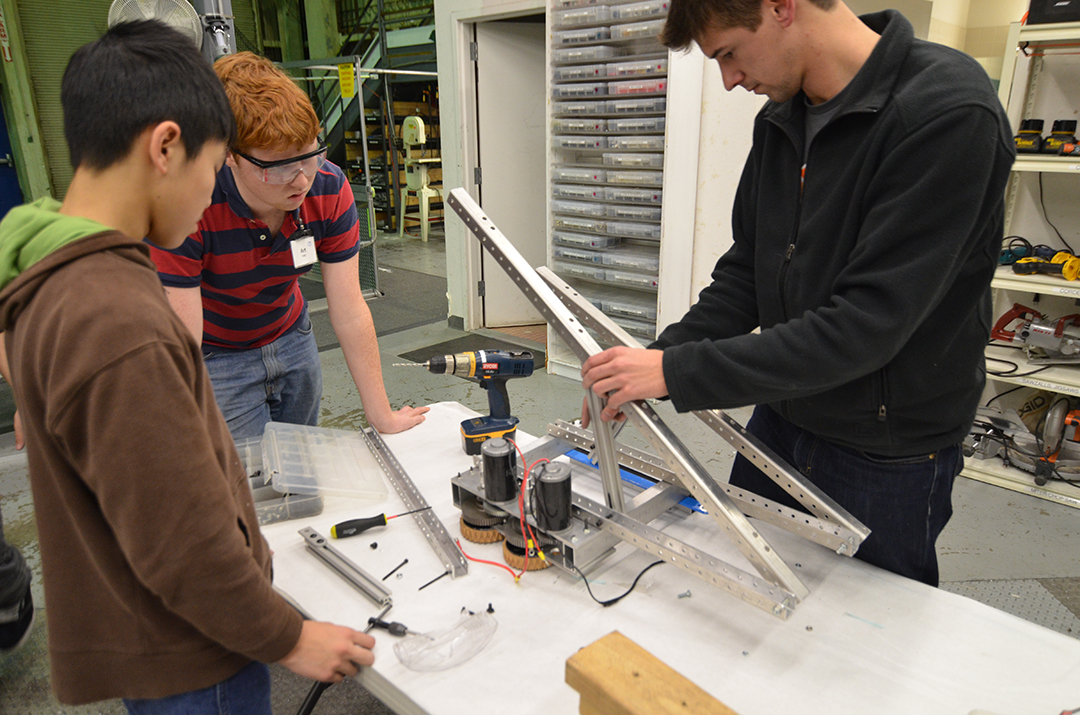
Improvements were made to the shooter prototype. After students replaced a faulty CIM motor, an adjustable base was added to the linear shooter to allow testing at multiple angles. This base will help optimize the perfect angle for shooting a frisbee. The base was constructed out of kitbot parts and 80-20 extrusion.
D7K_3464

Richard assisting students with the adjustable shooter platform assembly

Intake Prototype

Students worked on improving the roller-intake prototype by testing different kinds of tread spinning at different speeds. It was found (unsurprisingly) that the roller must be spinning very quickly (about 2,000 RPM) to intake the frisbee. Long rough-top tread attached as "fingers" did not work well. A piece of rough-top tread that was wrapped around the roller worked the best.

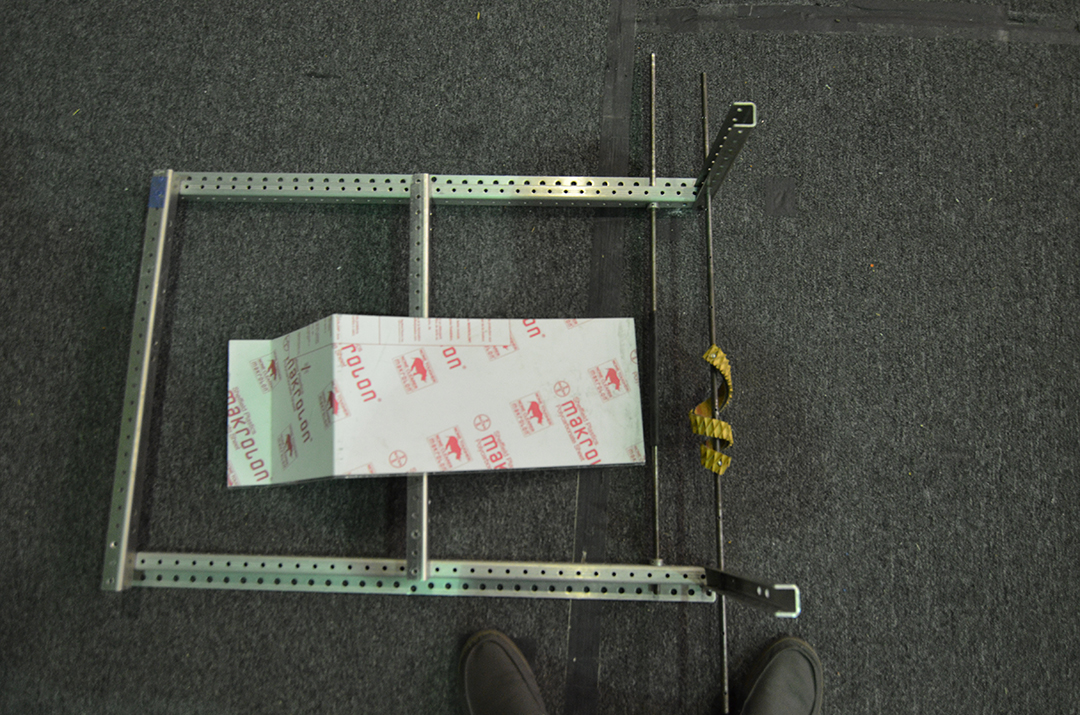
After determining this improved treading configuration, students and mentors worked on setting up the prototype as an over-the-bumper intake. Rather than sucking-in the frisbee horizontally, tests were conducted to see if the frisbee could make a smooth and easy transition from a horizontal position on the ground to an angled position over the bumper.
D7K_3465

Updated Intake prototype

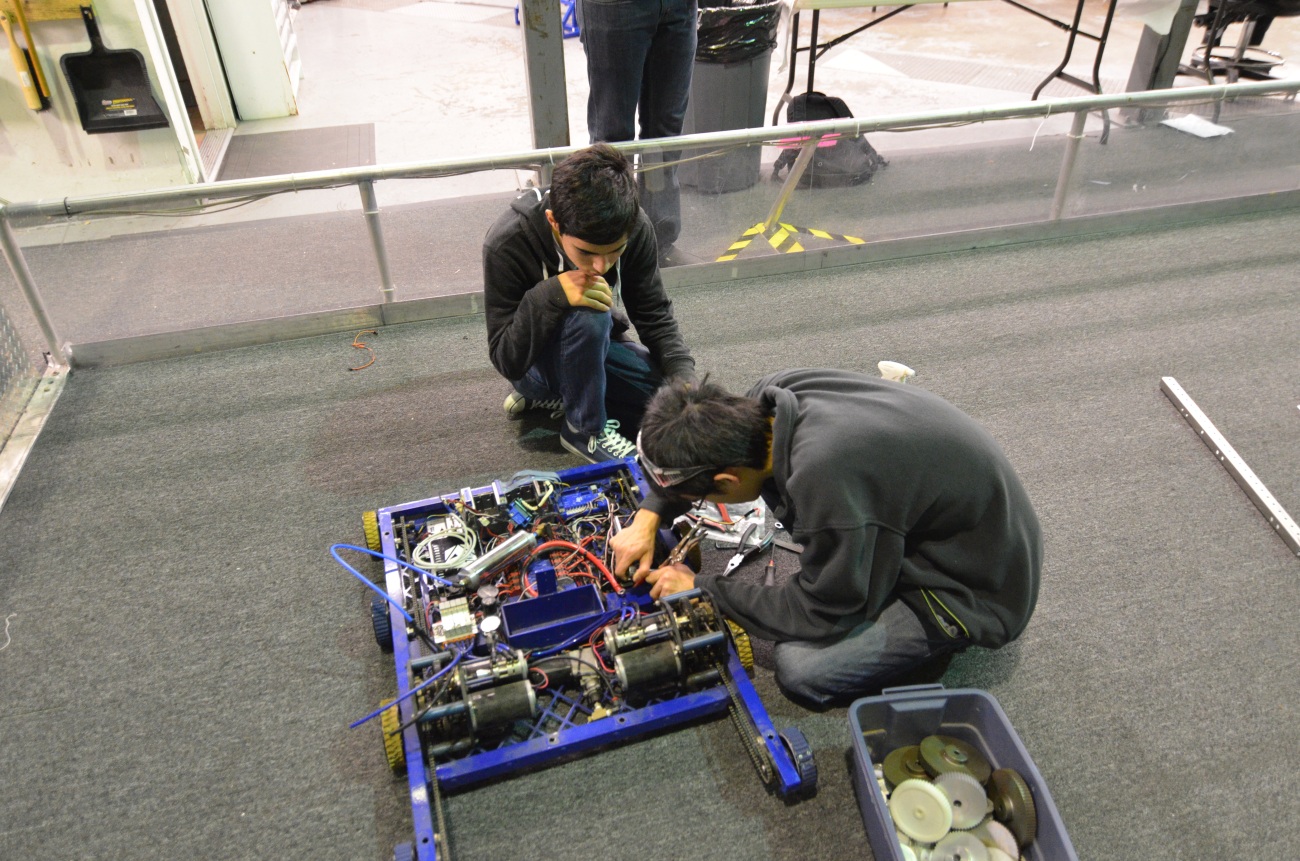
Restoring the 2010 drivebase

Students continued to attempt to restore the 2010 drive base, in order to attach prototypes and drive around. After an hour of debugging, it was concluded that a faulty cRIO was on the robot. The efforts were abandoned because of a lack of replacement cRIO. Hopefully, a new cRIO is acquired soon in order to continue testing.

Restoring the drivebase was also supposed to be an excercise for the new programmers, so they could practice writing brand new code and uploading it to a functioning robot.

Programming

Tom dropped some knowledge bombs on the programmers today.

Constants


Students continued to brainstorm and discuss possible ways of updating values without having to re-compile or re-deploy the code.  Some ideas that was brought up was having a text file for each constant, or having an "isModified" boolean value somewhere.


Action Item List


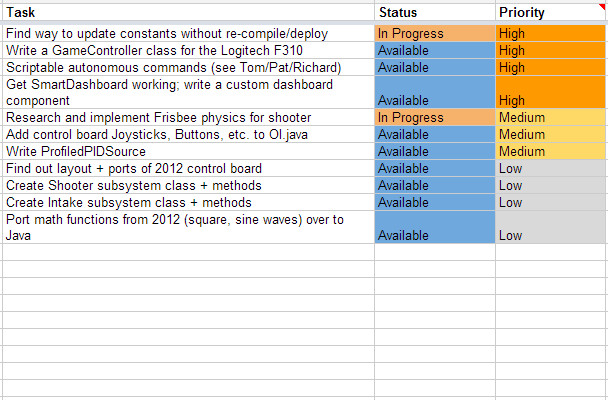
An action item specific to programming was created yesterday.  This is essentially a to-do list, which organizes and tracks tasks what need to be completed and the priorities of tasks.  This list should make it easier for students at the lab to more easily contribute to programming effort.


Miscellaneous

Light Control Box

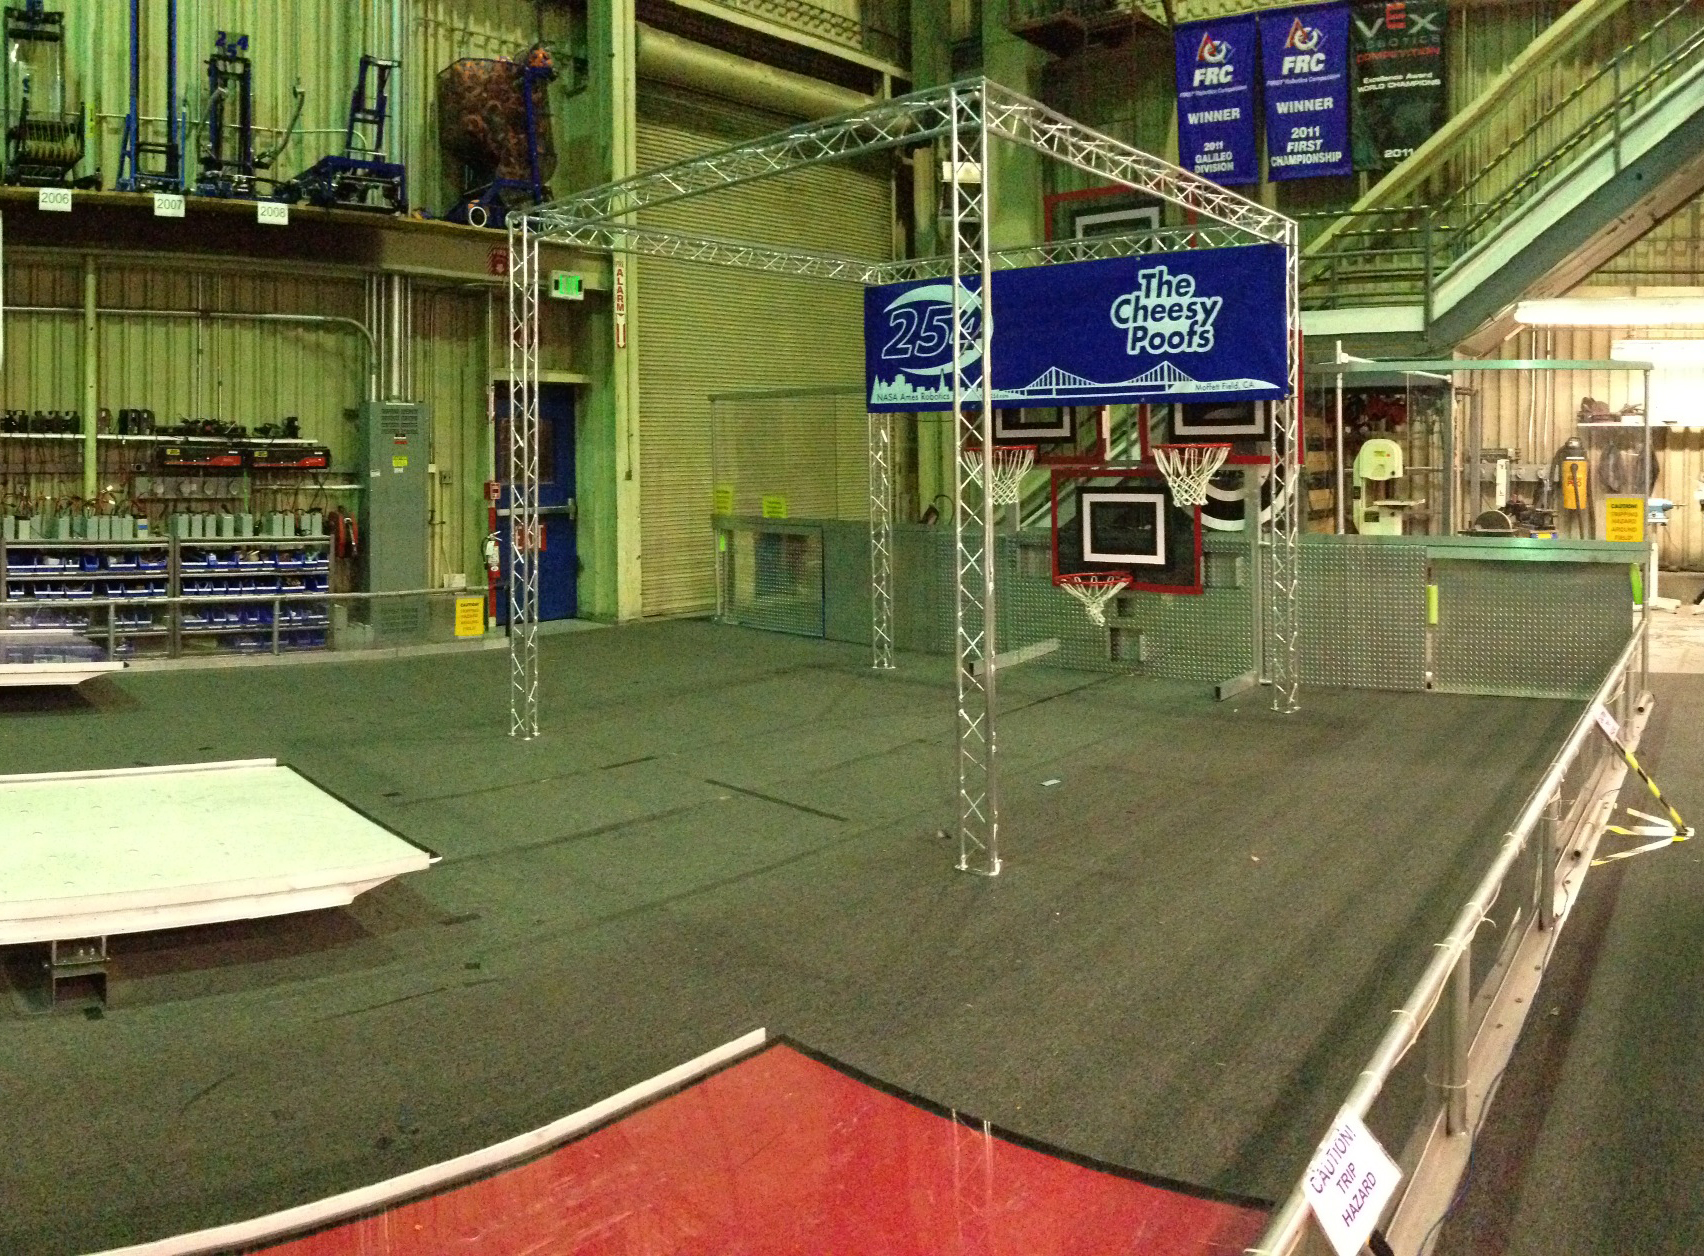
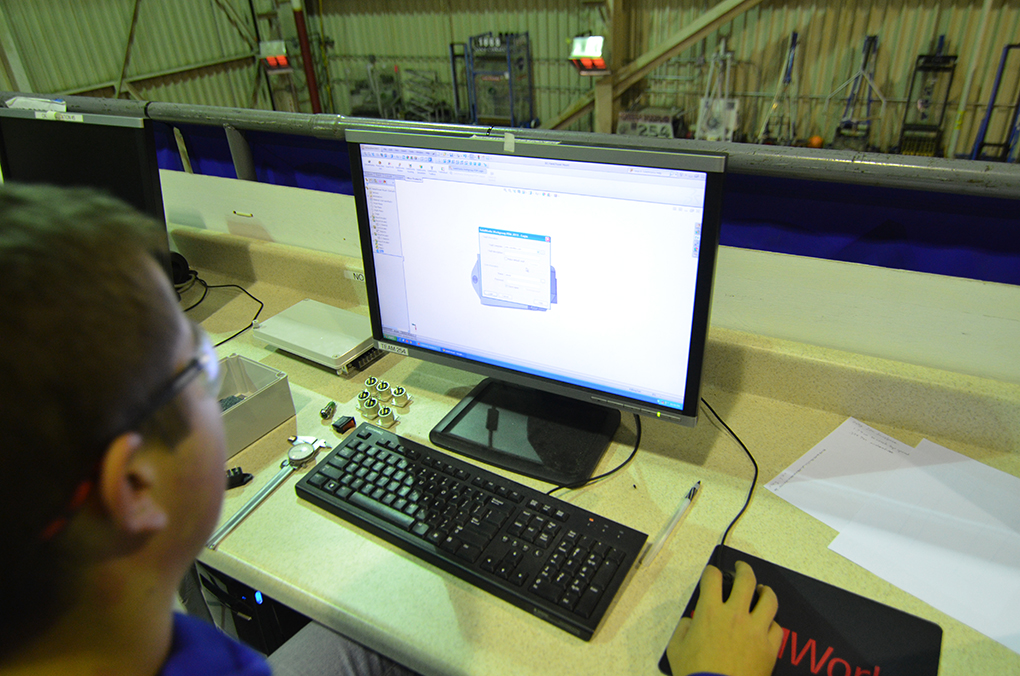
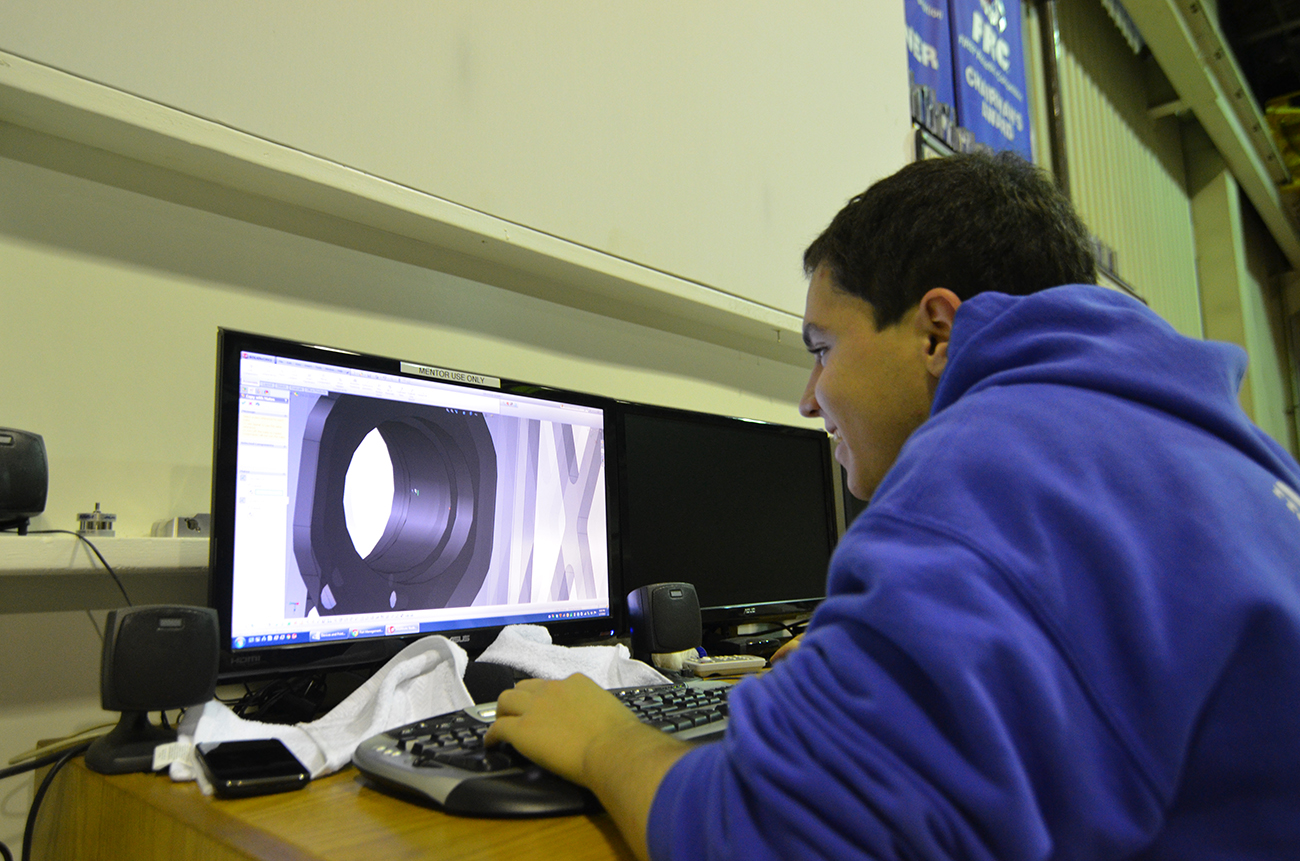
Two students worked on modeling a project box and the components to go inside it. This project box will house a power supply and will be the control box for the lights hanging on the trussing in the pit area.
image

Pit Area trussing for banners, lighting, and monitor mounting
D7K_3466

A student modeling the project box in SolidWorks.

Action Items for Tomorrow

  • Fix the wiring to the cRIO on the 2010 robot; flash new image to cRIO

  • Work on and test prototype for intake

  • Work on and test linear shooter prototype

  • Complete drivetrain design. Deadline is Friday.

Lab closing time was 11:00 pm
FRC Programming - Action Items

2013 FRC Build SeasonFIRST RoboticsProgramming

In order to keep track of programming-related action items for FRC, we've created a spreadsheet with tasks that are sorted by priority.  If you're ever at the lab and want to do some programming, swing by and choose a task that interests you.  We hope that this list will make it easier for you to find a cool project to work on while in the lab.  


todo

The action item list, as of Day 5


As always, you can let Richard, Stephen, Tom, or Pat if you have any questions or need clarification.  Be sure to read the blog often to check out our programming progress!

Day #4: Success with Intake and Shooter!

2013 FRC Build SeasonFIRST Robotics#FRC Build Blog

Today was a huge improvement in student attendance over yesterday. With our first active weekday build, a majority of the time was spent designing and beginning initial prototyping of an intake mechanism.

Prototyping

Intake Prototype

Students worked in a group to brainstorm ideas for an intake mechanism that will allow the robot to take in discs from the ground.  One of the several ideas brought up include horizontal rollers to roll the discs in.  However, the orientation of the disc (facing upwards or downwards) and friction between the carpet and the disc are challenges.  Currently, one new intake prototype has been constructed that can take in discs on the ground from either orientation. 

intake

Students brainstorming ideas for the intake

Shooter Prototype

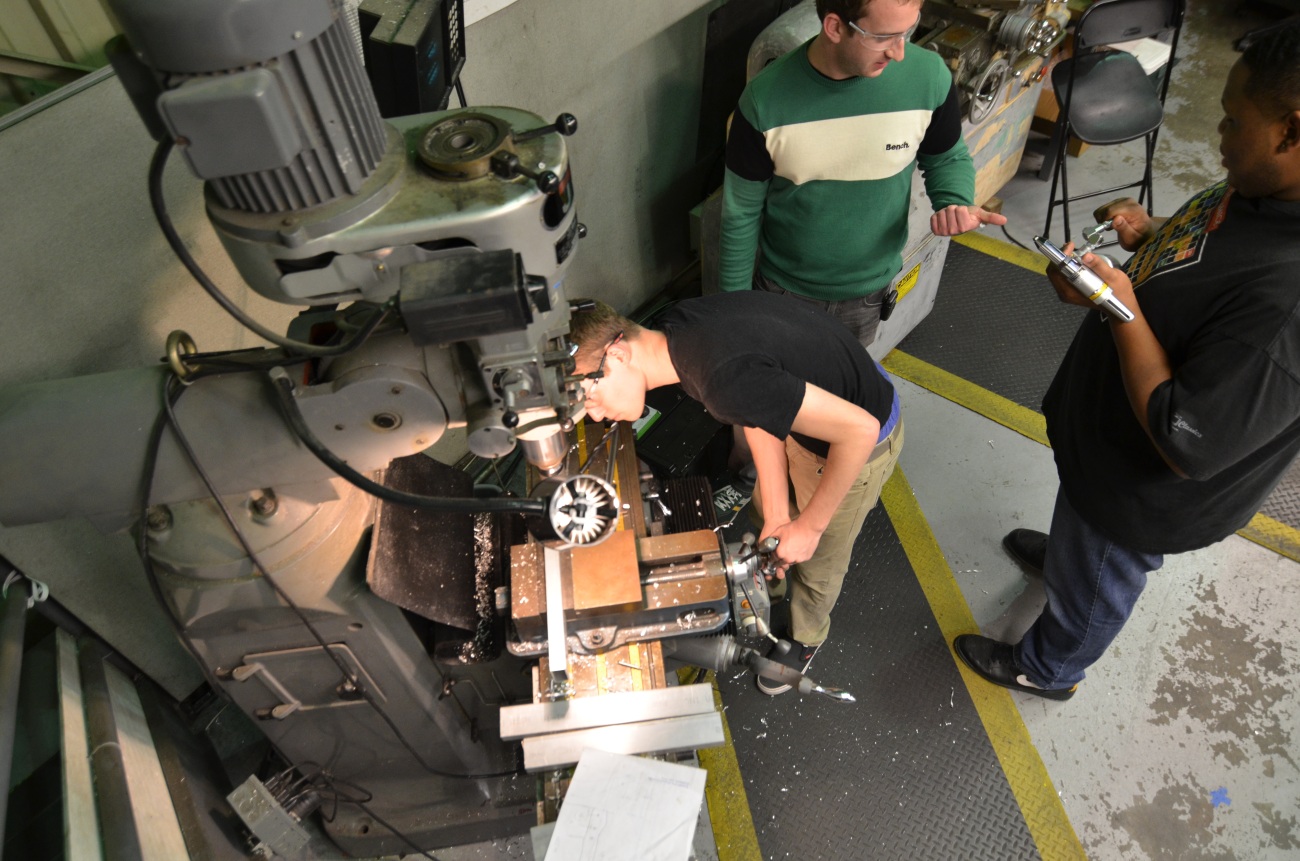
Additionally, some students are continuing work on manufacturing parts for shooter prototypes.  

One new shooter prototype that is under construction is a linear shooter, powered by two wheels.  One wheel will be powered such that it is faster than the other.


manufacturing

Manufacturing parts to build a shooter prototype

Testing Prototypes

Some students are using the drivebase of the 2010 robot, Onslaught, in order to test shooting and future intake prototypes.  Currently, there is a problem with power to the cRIO, which prevents controlling or deploying code to the robot.  Once the 2010 robot is up and running, the team will attach prototypes to the robot to test out prototypes on the field, while driving.


onslaught

Drivebase of the 2010 robot, Onslaught

Programming

Reading Constants

The programmers discovered that original idea to use Java reflection will not work because the robot uses Java ME (mobile edition), which does not support this feature. They brainstormed some other possible solutions including using a hash map for storing variables read from a file, but it is likely unfeasible due to its heavy computational expense. Another idea is to use a flat text file with constant values that can be transferred to the robot without re-compiling and re-deploying code. 

Controls

In addition, the programming team tested out a Logitech game controller as a way of driving the robot.  The analog sticks on the controller were successfully used to control the drive.  More comparisons and tests between joysticks and the game controller will occur later on in the season.

Action Items for Tomorrow

  • Fix the wiring to the cRIO on the 2010 robot; flash new image to cRIO

  • Work on and test prototype for intake

  • Work on and test linear shooter prototype

Lab closing time for the night was 12:30am

Part Management System

2013 FRC Build SeasonFIRST Robotics

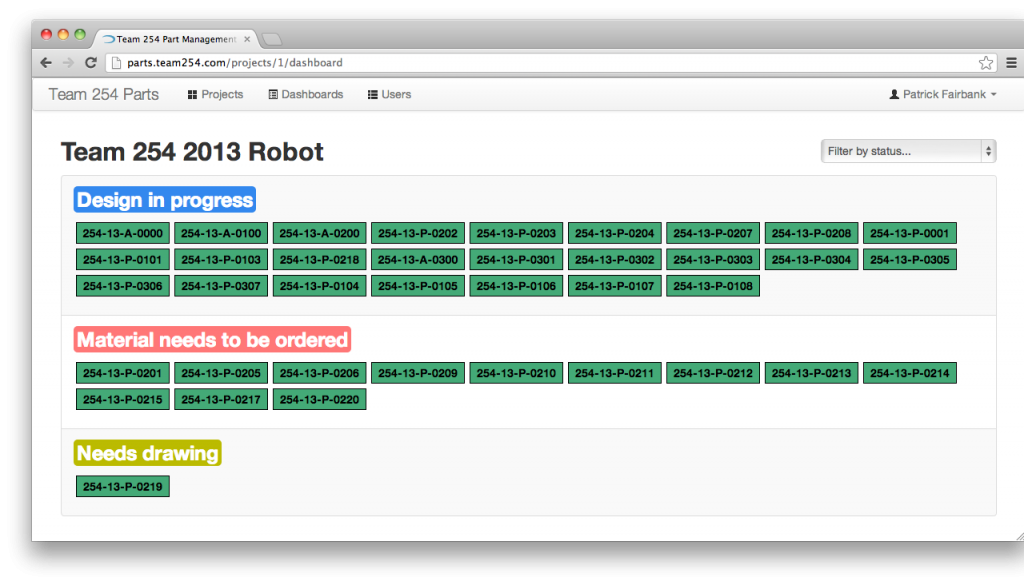
To help manage the robot parts in CAD and their manufacturing status, there is a new web-based part management system located at parts.team254.com. This system assigns official part numbers, stores information about parts and the materials required to make them, and shows the current manufacturing status of each part.

Parts currently in the manufacturing pipelineParts currently in the manufacturing pipeline
Build Season Recipes: Week 0

2013 FRC Build SeasonFIRST Robotics

I received a couple of requests for the cookie recipe from Kickoff weekend, so I'll just post it here on the build blog. Stay tuned for future weekly deliciousness and nutritiousness!

Double Chocolate Cookies

  • 1 cup butter

  • 1 cup sugar

  • 1/2 cup brown sugar

  • 1 tsp. vanilla extract

  • 1 egg

  • 1/3 cup cocoa powder

  • 2 tbsp. milk

  • 1 3/4 cups flour

  • 3/4 tsp. baking soda

  • 3/4 cup chocolate chips

Cream butter, sugars and vanilla extract. Add egg, milk and cocoa; beat. Add flour and baking soda and mix just until blended. Stir in chocolate chips. Drop on cookie sheet and bake at 350°F for 12 minutes.

Day #3: Design Discussion

2013 FRC Build SeasonFIRST Robotics

Today was the first weekday of build and with fewer member attendances, there was a lot of individual work getting done. Majority of time was spent in conversation between students and mentors on design decisions.

Prototyping

Three different designs are continuing to be prototyped:

  • Arm design
    • Started installing a longer piston
    • Increase range of motion to have greater spin
    • Extended arm length
  • Linear Design
    • Wood bottom plate removed because of warping
    • Bottom plate replaced with metal bars to reduce bend
    • Added electrical tape to increase traction
    • Adjustments made to effectively improve consistency
  • Radius design
    • No work was done on the radius design today

Design

Mentors and students continued designing the robot baseplate and the drivebase in Solidworks. The drivebase was completed before Nagy lost all his work. It will be completed tomorrow at school.

New discussion outcomes:

  • 32" x 24" frame

nagy

Additional testing

Students began to install 4 new Talon speed controllers on the 2012 robot Skyfire drive motors to replace the Victor speed controllers. Later on, the Talons will be tested and then based on results, the team can decide which speed controller to use for competition.

talons


Programming

The programming team worked on implementing a trapezoidal motion profile to accompany PID control, which involved quite a bit of math. Meanwhile, other programmers continued working on a way to read constants' values from a text file, and update the constants accordingly. Tomorrow, we hope to make adjustments to the code to use Talons instead of Victors, and test drive the 2012 robot.

Action Items for Tomorrow:

  • Finish drivebase CAD (restore Nagy's lost work)
  • Continue Prototyping
  • Add support for Talon speed controllers in code, test, and compare with Victor speed controllers

 Lab closing time for the night was at  10:30pm

Day #2: Finished Pyramid!

2013 FRC Build SeasonFIRST Robotics#FRC Build Blog

Today the team got a great start as soon as we could access the lab, making substantial progress on a multitude of projects.

Prototyping

Today in prototyping the team pursued our 3 designs decided yesterday for shooting mechanisms which are:

  • Radius design

    • Continued to try and make shots using the pneumatic air wrench to

      drive the flywheel

    • Used the strategy of touching the pyramid to take shots without being hit by opponent robots

    • Created a feeding device to automatically load frisbees into the shooter


Radial shooter

  • Linear Design

    • CNC machined part of the belt mechanism to create a tensioned timing belt system to launch the frisbee

    • Added guide rails to create a solid static wall opposing the timing belt to create spin on the frisbee

    • Added flanges to the pulleys to help guide the timing belts

    • The pulleys are powered by a direct mounted CIM Motor running at 5300 RPM

    • Shows promising capabilities both in power and spin and is being pursued in greater depthLinear

  • Arm Design

    • Completed initial prototype design

    • Mechanism is powered by a 1 stroke piston

    • Semi-effective at short range

    • Needs to be modified to increase range and spin to be able to get a better understanding of its capabilitiesFlinger

Design

The decision was made to build a modified version of the 2011 drive system which operated a 6 Wheel Drivetrain System with two speed gearboxes (high gear at 19.8fps, low gear at 7fps). Center wheels are lowered to allow for maximum maneuverability. 3.5″ wheels keep the robot center of gravity very low to the ground. Additional design improvements have been pushed to tomorrow for final decisions. The team is still in the process of brainstorming designs for both intake and climbing/hanging mechanisms.

Gearbox

The part drawings for the main shafts in our drivetrain are completed and ready to be sent out to sponsors. The completed drawings are for the following parts:

  • Drive Gearbox Output Shaft

  • Drive Gearbox Intermediate Shaft

  • Wheel Shaft Medium

  • Wheel Shaft Short

Screen Shot 2013-01-07 at 10.45.25 AM

Output shaft drawing


Field Construction

Students completed all components and assembly of the pyramid, creating a solid basis for hanging prototype testing.

sketchpyramid

Machining

The CNC mill was used to mill components for the linear shooter prototype and is prepared to be in around-the-clock machining as soon as the preliminary metal shipment has arrived.

Programming

The programmers began to write some code in Java to deploy to the 2012 robot. They used the CommandBasedRobot structure for the code, and fixed all previous errors that popped up before during deployment.  The code was deployed and ran successfully. Currently, the team has a completed drive subsystem and a couple drive commands.  In addition, some students worked on a system to read values from a file for on-the-go constants editing.

 Lab closing time for the night was at  1:00am

FRC Season Day #1: Kickoff

2013 FRC Build SeasonFIRST Robotics#FRC Build Blog

After the whole team kickoff-unveiling event at BCP, students came to the NASA lab at 1:00pm to begin discussing game strategy, going over the new game rules in detail, and began numerous design, prototyping and field assembly tasks throughout the course of the day. Prototyping A couple of groups were created which began making prototypes to test the fundamental concepts of shooting Frisbee discs. A few objective requirements that are being looked at in these designs include:

  • Accuracy
  • Precision
  • Size/Volume occupied
  • Power requirements
  • Design integration ease
  • Feeding/indexing/loading ease
  • Need for adjustability

Three different designs are currently being prototyped:

Radius Design

Radial Design

  • The radial design uses a fixed wheel spinning on an axle surrounded by a circular track for a frisbee. By doing this there it simultaneously adds speed to the frisbee using the rotating wheel and spin using the far wall of the track that is padded with self-insulating electrical tape for increased grip.
  • We used many different iterations of motors starting with Dewalt drills, but opted for more power using pneumatic drills running off shop air spinning the wheel at 5250 RPM.
  • Using the higher RPM we were able to semi-accurately shoot from 10ft away from the high goal.
  • A working prototype was created and tested today as shown in the video above

Linear Design

  • This design is an iteration of the Radius design, but packaged more tightly to accelerate the Frisbee disc linearly, instead of around a radiused backboard
  • The idea was created as a derivative of the Radius design, coming from the need for a compact shooting mechanism. Utilizing the same idea of a static surface combined with a spinning propellant, we designed a system that uses a direct mounted CIM motor to power a timing belt pulley system to increase speed of the frisbee in a single linear movement.
  • CAD models of this design were completed and fabrication was started today

Thrower Arm Design

  • This design is most similar to a clay pigeon device
  • The main mechanism of this design is a flinging arm that propels the frisbee as it travels from the center of the device towards the outer most edge
  • Fabrication of this design was started and photos will be added when a preliminary model is created

Design Preliminary design decisions were briefly discussed regarding drivetrain configuration, wheel size, and speeds/ratios.  Final drivetrain decisions and preliminary designs for some drive components will be decided and completed at tomorrow's meeting.  Gearbox and wheel shaft models and drawings are scheduled to be completed by Sunday night, to deliver for manufacturing at our sponsor on Monday morning. Preliminary discussion outcomes:

  • 6WD with 3.5" Wheels
  • 2-speed WCD (West Coast Drive)
  • ~2011 speeds (with the capability to swap in a smaller pinion to go slower)
  • Flat base plate
  • 2011 style bumper mounts

Field Construction Students began working on building and assembling the high goal and the pyramid field objects.  The High Goal stand was completed and mounted onto the game field. The assembly of the pyramid is underway, with its top goal almost complete; all components are made, but still need to be assembled together. Screen Shot 2013-01-06 at 9.59.50 PM Manufacturing Final machine set-up and warm-up procedures were completed today which should allow us to start machining competiton parts tomorrow. Action Items for Tomorrow

  • Acquire missing pyramid parts, assemble pyramid base and goal, assemble pyramid.
  • Complete linear Frisbee shooter prototype & test
  • Begin intake design and prototyping discussions
  • Start and complete drivetrain gearbox designs and shaft drawings
  • Discuss merits and perform objective analysis/ranking on hanging mechanisms & feasibility

 Lab closing time for the night was at  12:30am