177 posts

FRC World Championships

FIRST RoboticsTournaments

Thursday: Day 1

On Thursday, students were up bright and early, leaving for the Dome at 5:00. Students waited in line for the event center to open up, as getting to the stands first is very important for scouting. Students ran to the seats in the Archimedes division. They sat next to Team 987, The High Rollers, who we won the San Diego regional with. Practice matches continued throughout the day, and the Cheesy Poofs played one, which they won. Their first match was qualification match 16, which they lost 162-170. Part of the intake polycarb got stuck in carpet, and dangled below the 30 point level. If it hadn’t, Team 254 would have won 172-170, but the day goes on! Team 254 then went on to qualification match 24, which the they won 190-58, ironing out the kinks from the first match. They went on to match 34, and unfortunately lost 107-115.

After the matches concluded, the students walked to Joe-Bucks, a phenomenal BBQ joint near the hotel. There, they met Team 233’s mentor Mike D, who helped liven up the night. The students walked back to the hotel, where they relaxed in their rooms and went to bed early, as the next day they’d have to wake up early again.

Friday: Day 2

The students woke up around 4:30 and went off to wait for the stadium to open up. In line, they hung out with Team 233, Team 987, and a couple others. They got the same seats as the day before, right next to 987. The first match was another qualification one (#63). Team 254 won with 152 points compared to the 87 the opponents scored. Team 254 didn’t manage to cling to the 30 point level, but they still won. The next match was 79, which the teams won 164-77. The Cheesy Poofs hung at the 10 point level, as their teammates hung at the 30 point level. Match 91 followed, and resulted in another win, 172-152. Team 254 pulled off another 30 point hang this match. The final match of the day was match 102, which the team miraculously won 179-69. This match, one of The Cheesy Poof’s alliance partners didn’t function, so the Poofs won a 2v3 match. After the matches, the students made a quick trip home to change, and went out with Team 233, the Pink Team to a Chinese restaurant. There, they also met up with Team 1515 and 1717. The team had an all you can eat buffet, and had a great time.

Saturday: Day 3

Saturday, the Cheesy Poofs got an extra hour of sleep. They waited in line with Team 233 again, playing music and singing together. They got the same seats as before, but didn’t scout, as the decisions were figured out the day before. Team 254 had one qualification match left, which they unfortunately lost 109-157. This resulted in 5 wins and 3 losses, and a final rank of 24th out of 100. Team 254 was picked by Team 2468, and ended up having Team 11 as the final alliance partner. The team won their first Quarter Final match, scoring an all time high of 236-175. They went on to win the next quarter final, 220-206, pushing them forward to semi-finals. They lost their first semifinal 203-222, but spirits remained high. But unfortunately, Team 254 also lost their second semifinal match 216-266 and were eliminated.

The students then went on to the Einstein field to cheer on the winners of each division. They also helped continue the tradition of competitive paper airplane making. Afterwards, they packed up crates in the pit and returned to the hotel.

Sunday: Day 4

In the morning, Mike D. from Team 233 went room to room and woke up the team, singing and chanting students awake. Team members packed up their bags and went to the land prepared for the baseball game. They walked to the Cardinal’s stadium and watched the Cardinal’s vs. Pirates game. Then, Team 254 left for the airport and returned back to sunny San Jose, California.

Qualification Matches

Qualification 16 Loss 170-162

Qualification 24 Win 190-58 Video

Qualification 34 Loss 125-107

Qualification 63 Win 152-87

Qualification 79 Win 164-77

Qualification 91 Win 172-152

Qualification 102 Win 179-69

Qualification 131 Loss 157-109

5-3-0 Record in Qualifying with 18 Qualifying Points, Ranked 23 of 100 Teams

Elimination Matches

Alliance: 254, 11, 2468

Quarterfinal 4-1 Win 236-175 Video

Quarterfinal 4-2 Win 220-206 Video

Semifinal 2-1 Loss 222-203 Video

Semifinal 2-2 Loss 266-216 Video

Eliminated in Semifinal 2-2
Pre-STL Day 9: Step into High Gear

2013 FRC Build SeasonFIRST Robotics

Manufacturing

Students started organizing new parts into their respective bins. Most of these parts will be spares for competition. In addition, a few mentors and students worked on deburring, polishing, and touching up parts which will be sent in for powder coating and anodizing.

Drivetrain

Students contine to fix the drivetrain. A dog gear broke yet again. Students worked on taking apart the drivetrain gearbox to replace it.

Intake

Students made new parts for the intake, including new mount side plates. Additionally, students began assembling the intake support gearbox.

Shooter

Students designed a one way valve in the shooter. This stop, made from a simple piece of bent polycarbonate, will allow the frisbee to leave the shooter in only one direction and prevent it from falling backwards. This stop is a simple mechanism to further eliminate possible jams that have plagued the robot for the better part of the season.

Other

Teams 973 and 846 stopped by to the lab for practing and tuning in preparation for the World Championship next week.

Pre-STL Day 8: Rolling with It

2013 FRC Build SeasonFIRST Robotics

Shooter/Indexer 

Students and mentors worked diligently to replace one of the intake rollers with a BBD. Students also worked to troubleshoot an issue with the new intake hardstop that was causing hang-ups on the intake system.

Manufacturing

Working diligently to manufacture new intake gearbox plates to save weight, students cut stock metal to be milled in the CNC.


Pre-STL Day 7: Maintenance & Anticipation

2013 FRC Build SeasonFIRST Robotics

Intake

Wooden blocks were added tonight to the practice robot to keep the polycarbonate base of the intake from touching the ground. This is one of a series of adjustments to the intake to make it more efficient, fluid, and functional. The polycarbonate base often gets caught in the carbonate causing jams and reduced mobility.

Shooter/Indexer

WP_000373
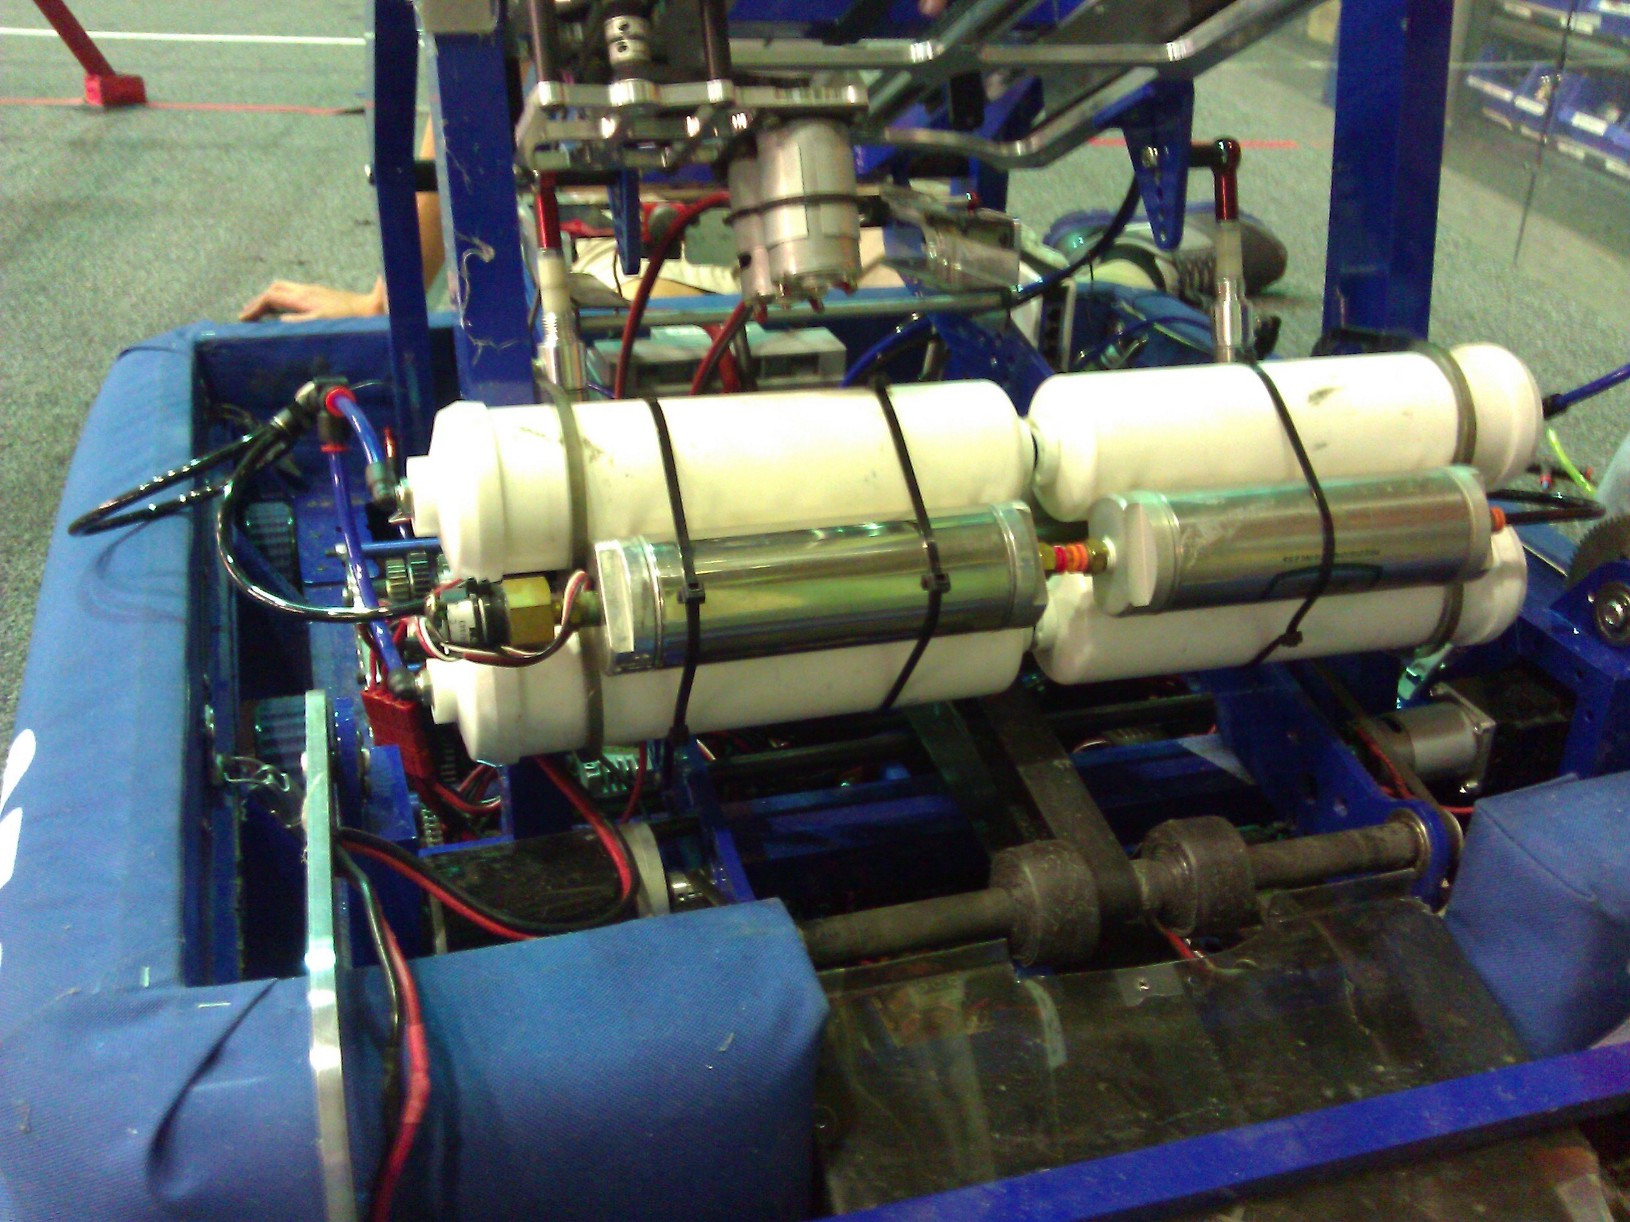
Overkill with all of the tanks.

Even though the Frisbee hard stop was working last night, it was not today with the pin having trouble sliding the stopping plate up and down. This was solved by changing the hard stop to delrin and maintaining the mounting plates to aluminum. Also, students and mentors created two cross bars for the indexer. They also worked on shooter wheel mounting plates. Lastly, the team added temporary air tanks to the practice robot to allow for more shooting cycles and less refilling.

Drivers

Abhi and Jonathan Lee continued driver practice in preparation for the upcoming competition.

Sensors & Programming

Students and mentors tested hall effect sensors using Slipstream as a power source, because of drivers using Overkill to practice. The hall effect sensors would detect the presence of a magnetic field. When magnets are placed on the indexer mechanism, a feedback mechanism is created to determine whether or not the indexer mechanism is completely engaged in the correct position. On the programming side, programmers fine tuned various code for indexing and shooting.

Pre-STL Day 6: Packing

2013 FRC Build SeasonFIRST Robotics

2013-04-16 18.20.24Today, students built a pallet to ship large items to St. Louis. They packed some very crucial items needed for Championship, including the robot cart, pit shelving, batteries, and lights for the trussing.

Lastly, programmers debugged some issues with the pit lights. The color effects no longer spawn new processes and overlap each other. Although pit lights are not a priority at the moment, students are making strong effort to make these functional to give the best appearance at the Championship event.

Pre-STL Day 5: Shopping Spree & Dieting

2013 FRC Build SeasonFIRST Robotics

CAD

Today, students and mentors worked together to design new subsystems of the robot.  For instance, a new gearbox was designed for the intake lowering and raising, which would replace the current VEX planetary gearbox.  The VEX planetary was very inefficient and quite heavy. The new gearbox with its motor will be marginally heavier than the previous setup, and it has the benefit of a more favorable gear reduction. After the design work was completed and verified, the team went online to sites like AndyMark and McMaster to order these new necessary parts.  It is essential that these parts are ordered and arrive quickly, as time is running out before World Championships.


Dieting

The team is scrambling to find places to trim weight on the robot.  The new shooter wheels and intake gearbox are adding some weight to the robot, so the team trimmed some fat by removing the side panels, removing the pressure gauge support plate, and other areas. The 1/16" side panels will eventually be replaced by side panels made of 1/32" polycarb. Together, all the weight reductions will put us under weight. Although we are cutting it very close, we will eventually get to where we want to be.


Programming and Sensors

The programmers experimented with VEX bumper sensors as a means of detecting whether or not the frisbee is fully loaded in the indexer, and thus ready to transfer up to the shooter.  They attached two bumper sensors via double stick tape on either side of the hard-stop plate.  The next step of this is to wire the sensors to the digital sidecar and write up some codes.  When completed, the bump sensors will allow for increased speed of rapid fire. Tests will determine the reliability and durability of this setup to ensure it can survive the stresses of competition.

Pre-STL Day 4: Engineering Priorities for Time Constraints

2013 FRC Build SeasonFIRST Robotics

Intake

Students worked to carefully repair the intake when it broke this morning. They had to pause momentarily to remove the intake and fix it on the side.

IMAG0063
Fixing the Intake
IMAG0064

Jonathan Lee debugging the robot

Design

Due to the fact that there are only two weeks remaining before World Championships in St. Louis,  a lot of the team's new redesign ideas needed to be reconsidered realistically. While the progress of designing a bucket indexer seemed promising for spectacular scoring, it needed to be put on hold so that the team could focus on other important design tasks. In addition, it would require a major redesign or would bring up weight issues easily. The team decided to refine and work out the issues it currently has. The benefits of the major redesigns are not worth their risks, and it will be a much better use of time to work out the small issues the robot currently has.

Currently, the team is using Solidworks to design a new intake gearbox that would not make the motor burn out as quickly as the Banebot motor does now. In addition, the new gearbox will eliminate a VEX planetary from the robot.

IMAG0065

Testing the intake Banebot motor

Another important task includes making indexer hard-stop mechanism to prevent frisbees from jamming and stacking inside the indexer. This addition is a major improvement that is a top priority. This hard stop needs to be simple, passive, and reliable. Most likely, the stop will be mounded to the conveyor side plates. The stop itself will be lowered as the indexer mechanism is lowered. As the indexer is raised, so will the hard stop to forbid the frisbee from moving forward.

Driver Practice

Abhi Kumar and Jonathan Lee practiced driving the robot around to improve positioning consistently and prepare for competition scenarios.

IMAG0066

Abeek and JLee driving abhsentmindedlee


Pre-STL Day 3: Final Cleanup and Bucket Design Incorporation

2013 FRC Build SeasonFIRST Robotics

Cleanup/Unpacking

Students finally finished unpacking from SVR. All of the competition crates were unpacked and bins were restored to their original places. The lab is now fully equipped and ready for robot iterations and improvements.

Buckets

2f9305fd-photo-1-300x22
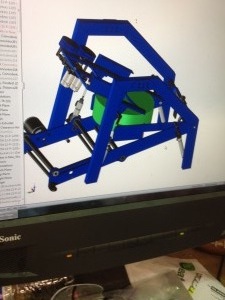
A modified design with the green cylinder representing the bucket.

The bucket design was worked on today in great detail. Parts from the indexer, shooter, and conveyor were changed in CAD today. The conveyor side plates were shortened to reduce weight and accomodate the large bucket. The indexer side plates(butcher knives) were made longer to account for the buckets new position in the robot. Finally changes were made to the shooter parts to accomodate the width of the buckets and frisbees that currently fit from wall to wall of the insides of the hanger. These design changes are still being considered and evaluated.

Programming

Brogrammers know what was done.


Pre-STL Day 2: Cleanup and Buckets

2013 FRC Build SeasonFIRST Robotics

Cleanup

Students started today's build session with a general clean up after dinner, including a full cleanup of the upstairs area and a more specific unpacking.

Buckets

After the cleanup, investigation on the buckets continued, and it was learned that if a bar applies pressure on the bucket in the part nearest to the conveyor, a system is created which prevents upside down frisbees from joining the stack. However, this only works if the first disc is intaked right side up. Furthermore, work was done on a system which gets discs from the human player.

Programming

The programmers worked on a couple of classes which allow for certain buttons to take effect, even when the robot is disabled. These buttons include ones which reset the gyros in the robot and select autonomous code. In addition, there were minor refactorizations of the code.

Pre-STL Day 1: Unpacking and Buckets

2013 FRC Build SeasonFIRST Robotics

Unloading

The team members helped unload the many items into the lab that were brought to the Silicon Valley Regional, such as the black crates, the robot, the bumpers, tool chest, robot cart, and carpets.  After most of the luggage was placed on the field, students helped move the large rolls of carpet into the sheltered area outside. This carpet will replace the current carpet on the field because it is getting torn.

After unloading from the truck, students helped pack necessary items into a giant, wooden 254 crate that will be shipped to St. Louis, MO in time for the FRC World Championships.  They helped by loading in the robot, bumpers, tool chest, trussing, pit lighting, foam tiles, sunglasses, and other important items.  The giant crate is all sealed up and ready to ship.


Buckets

The team is looking into some pretty significant redesigns of certain subsystems of the robot in preparation for World's.  They purchased a 5-gallon white bucket and cut off the top portion, placing it in place of the practice robot's indexer.  After securing it into position with tape, the students tested the bucket "magazine" system by intaking and exhausting frisbees, which worked much better than expected.  The discs glide cleanly under the bucket to form the four-disc stack.  This approach will allow the robot to accept discs directly from the feeder station, while allowing for rapid shooting and less potential for jamming (hopefully). While we are heavily weighing the implications of such a major design change, students are preparing designs and prototypes to accurately measure the risks involved.


We also enjoyed some delicious chocolate cake, made by the one and only Esteban Parker.