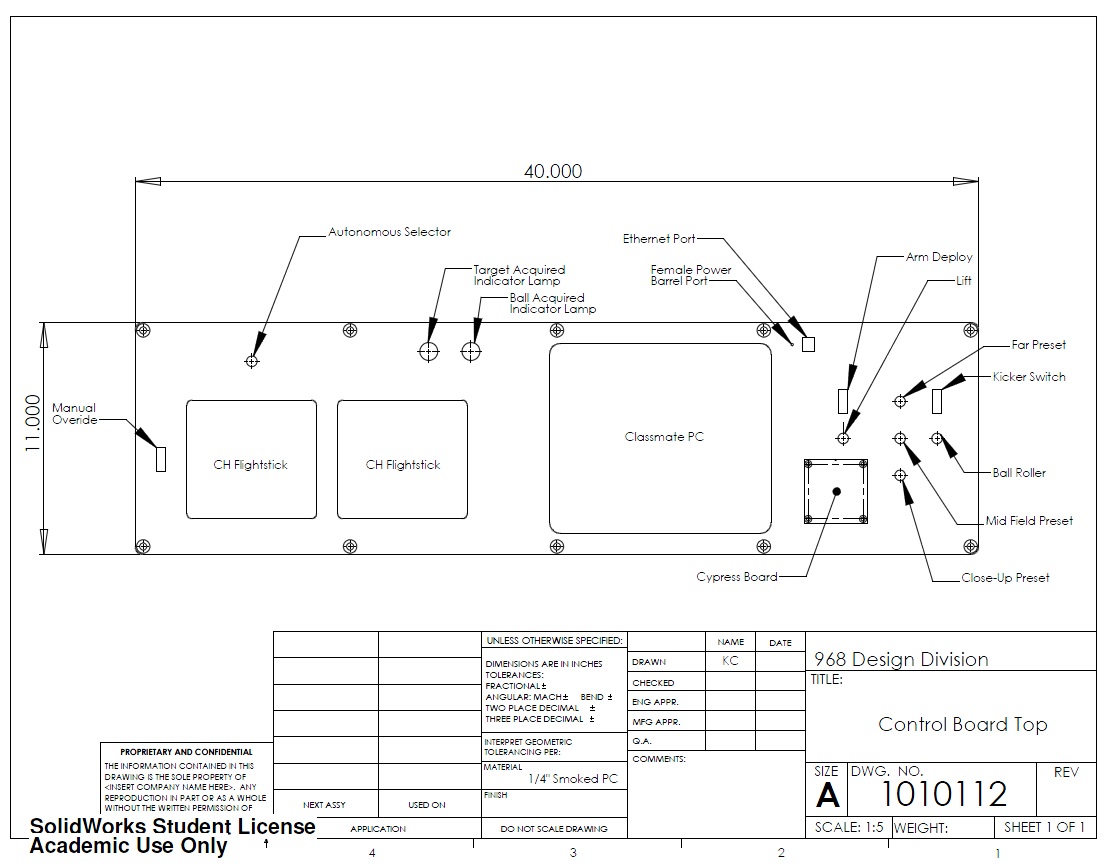
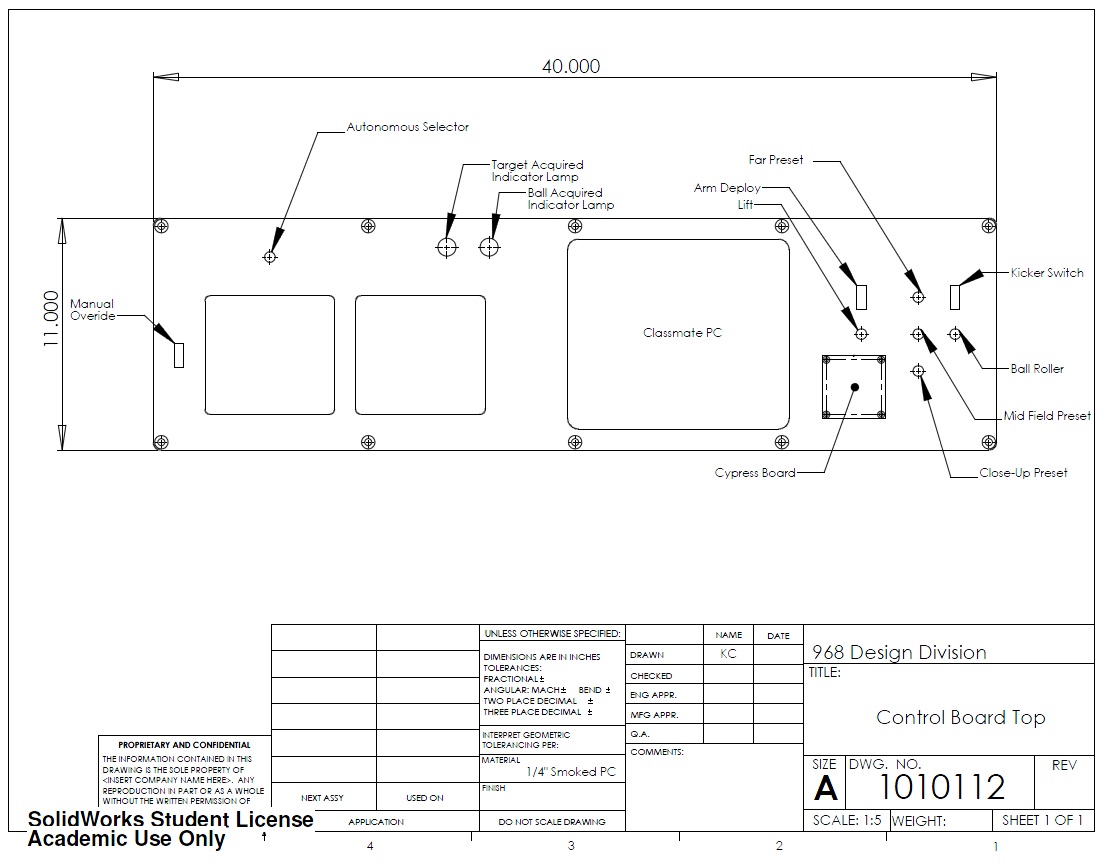
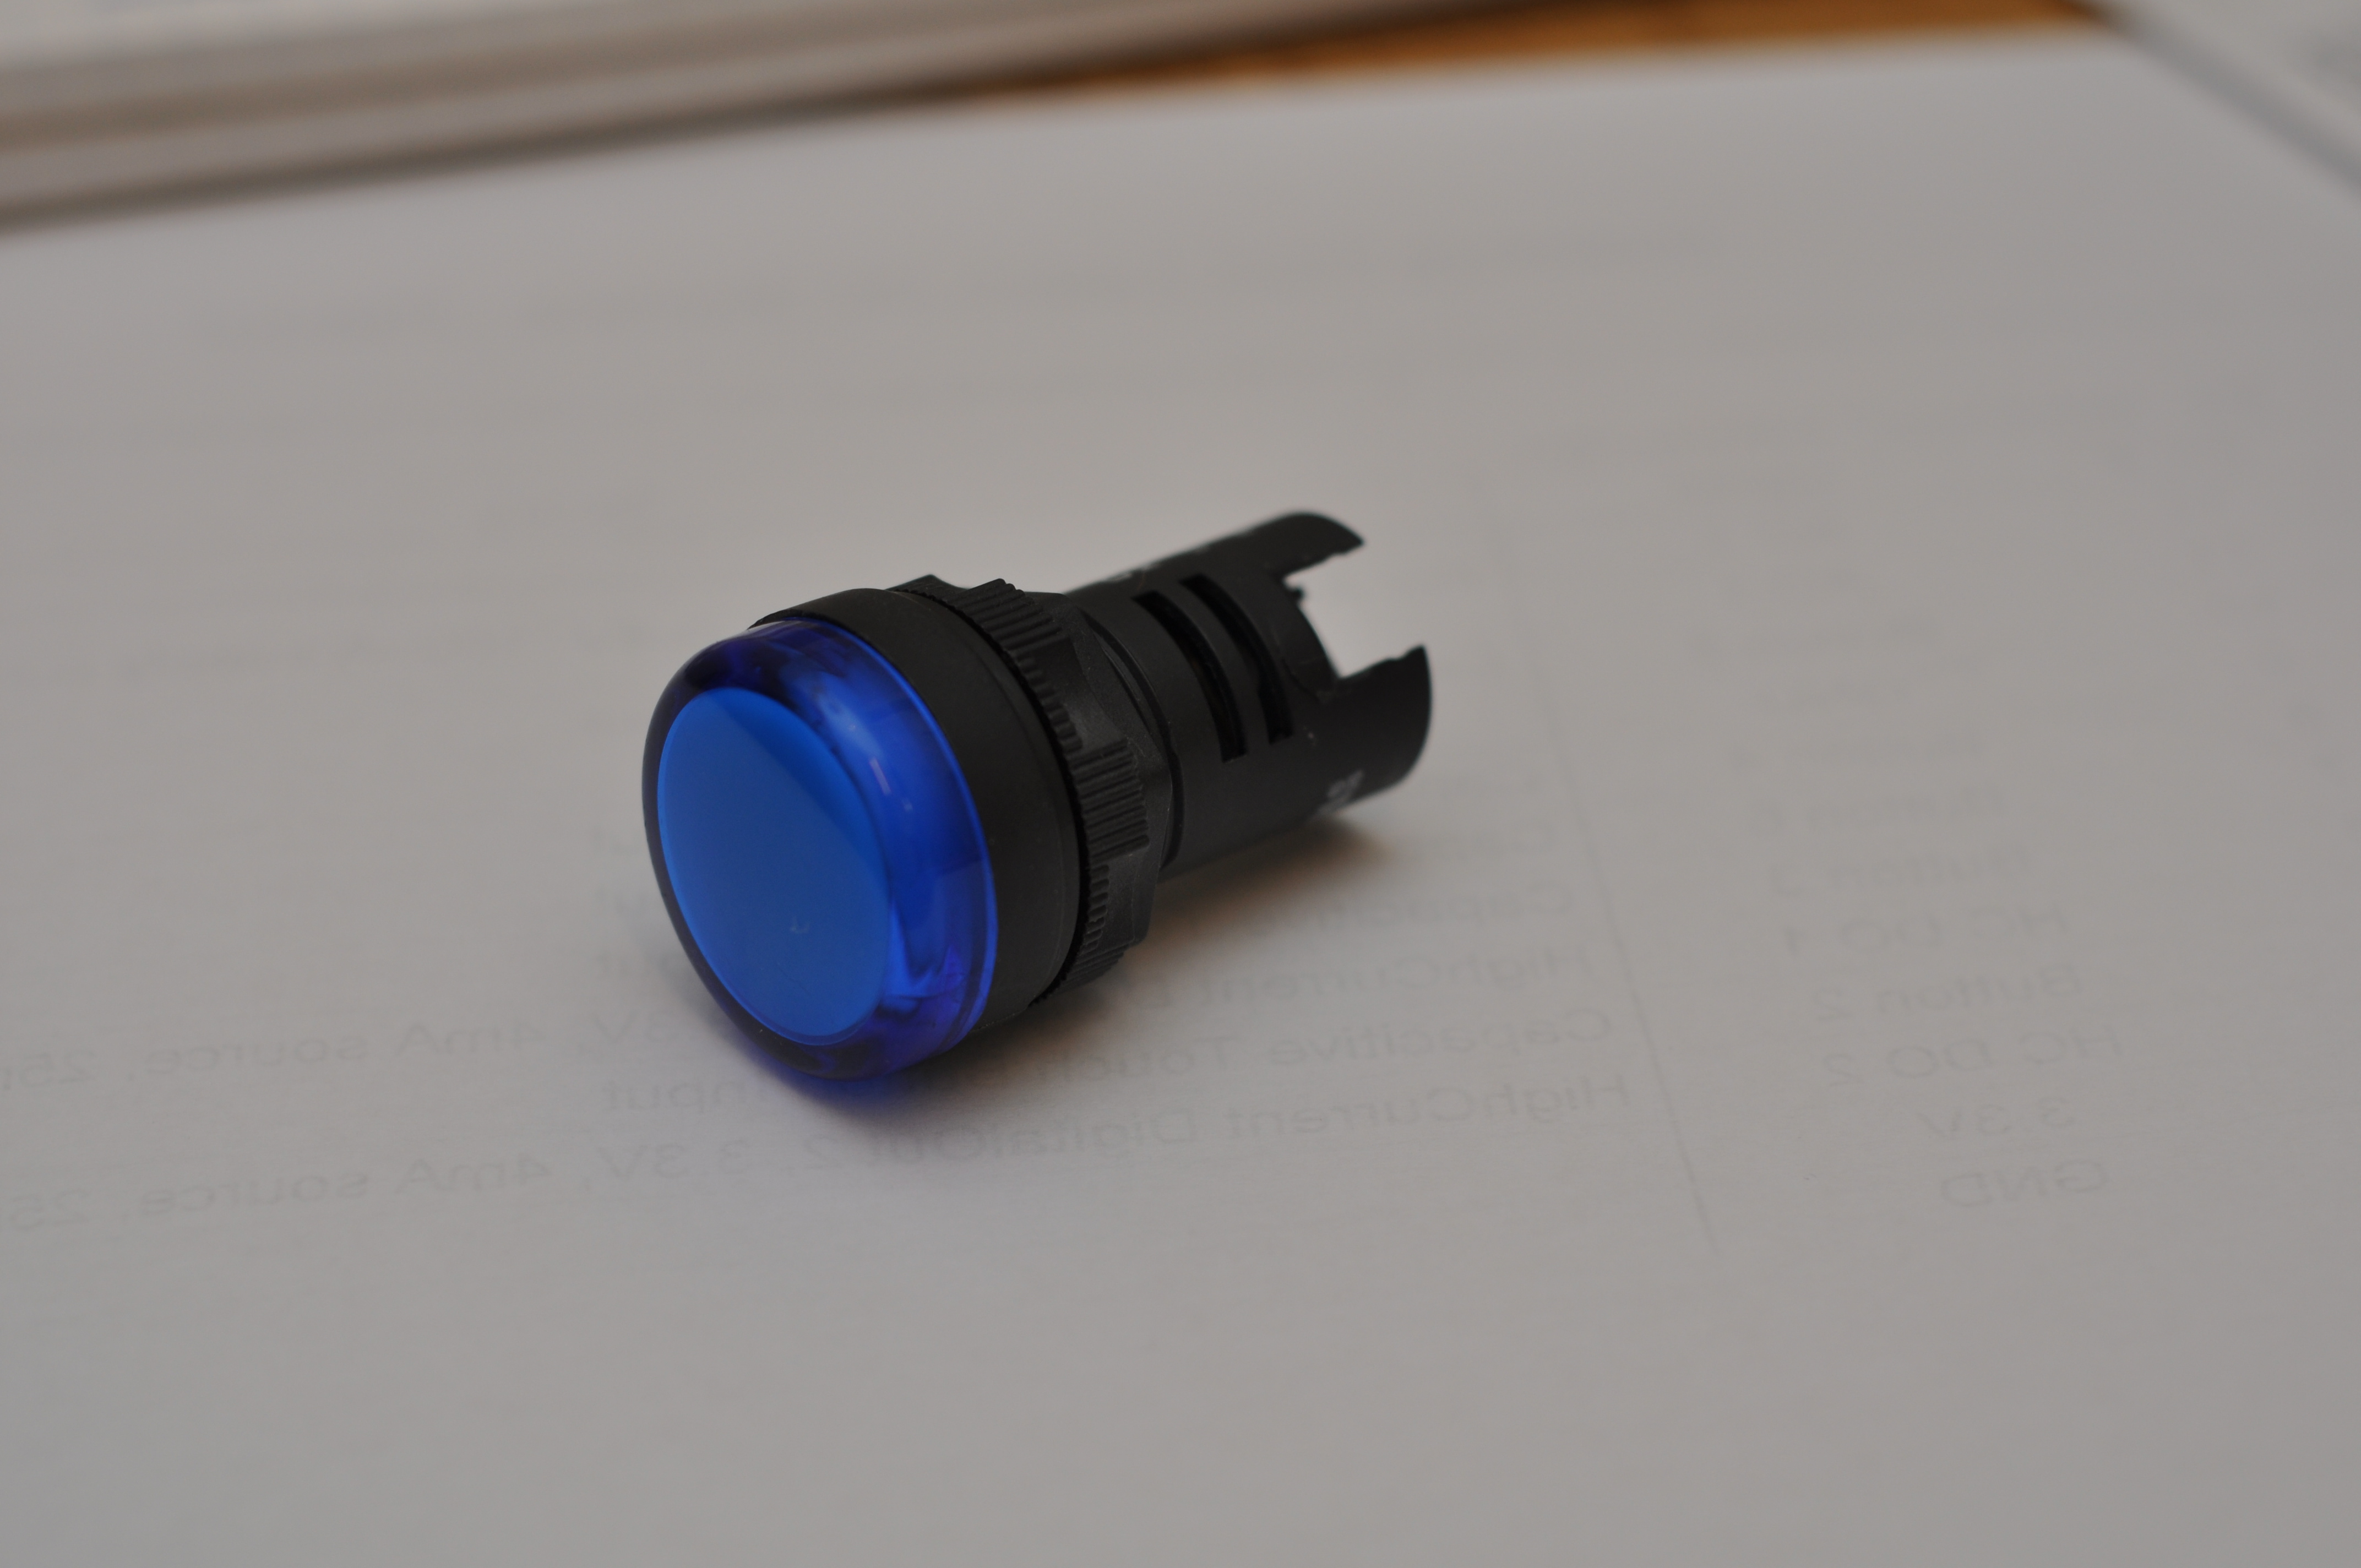
This revision includes the cutout for the Classmate pc, contours and filets for the ethernet jack, holes for the LED mounts, screwdriver slots for the Cypress board and finally, an additional cutout that replaced the roller button.
News, events, and updates from Team 254.
This revision includes the cutout for the Classmate pc, contours and filets for the ethernet jack, holes for the LED mounts, screwdriver slots for the Cypress board and finally, an additional cutout that replaced the roller button.
Manufacturing
Pacific Precision is able to make the output shafts; unfortunately they will not be done until late next week. We also confirmed that the robot frames will be ready to be picked up from Central Powder Coating at the end of business day Thursday. We continued progress on machining the bumper mounting pins, and will begin on the kicker piston bearing cones once the bumper mounting parts are complete.
Design
The control board CAD is being revised and we purchased all of the components for the boards.
Other News
We secured a local embroidering shop to make the team numbers on the bumpers.
We have contacted Motion Industries for a quote for all the ball bearings, and are currently awaiting word back.
MANUFACTURING
The manufacturing team has been working hard to complete parts for the drivebase. After completing gears and sprockets, we have moved onto the construction of the shifting dogs for both the drivetrain and the kicker winch.
DESIGN
The design team has been working to finalize a myriad of parts so that manufacture can begin. The plates for the kicker winch and arm have been finalized, and will begin being waterjet at BAE Systems tomorrow after the material is delivered. Design on the rollers is continuing, implementing the Clutch that we have purchased from McMaster-Carr.
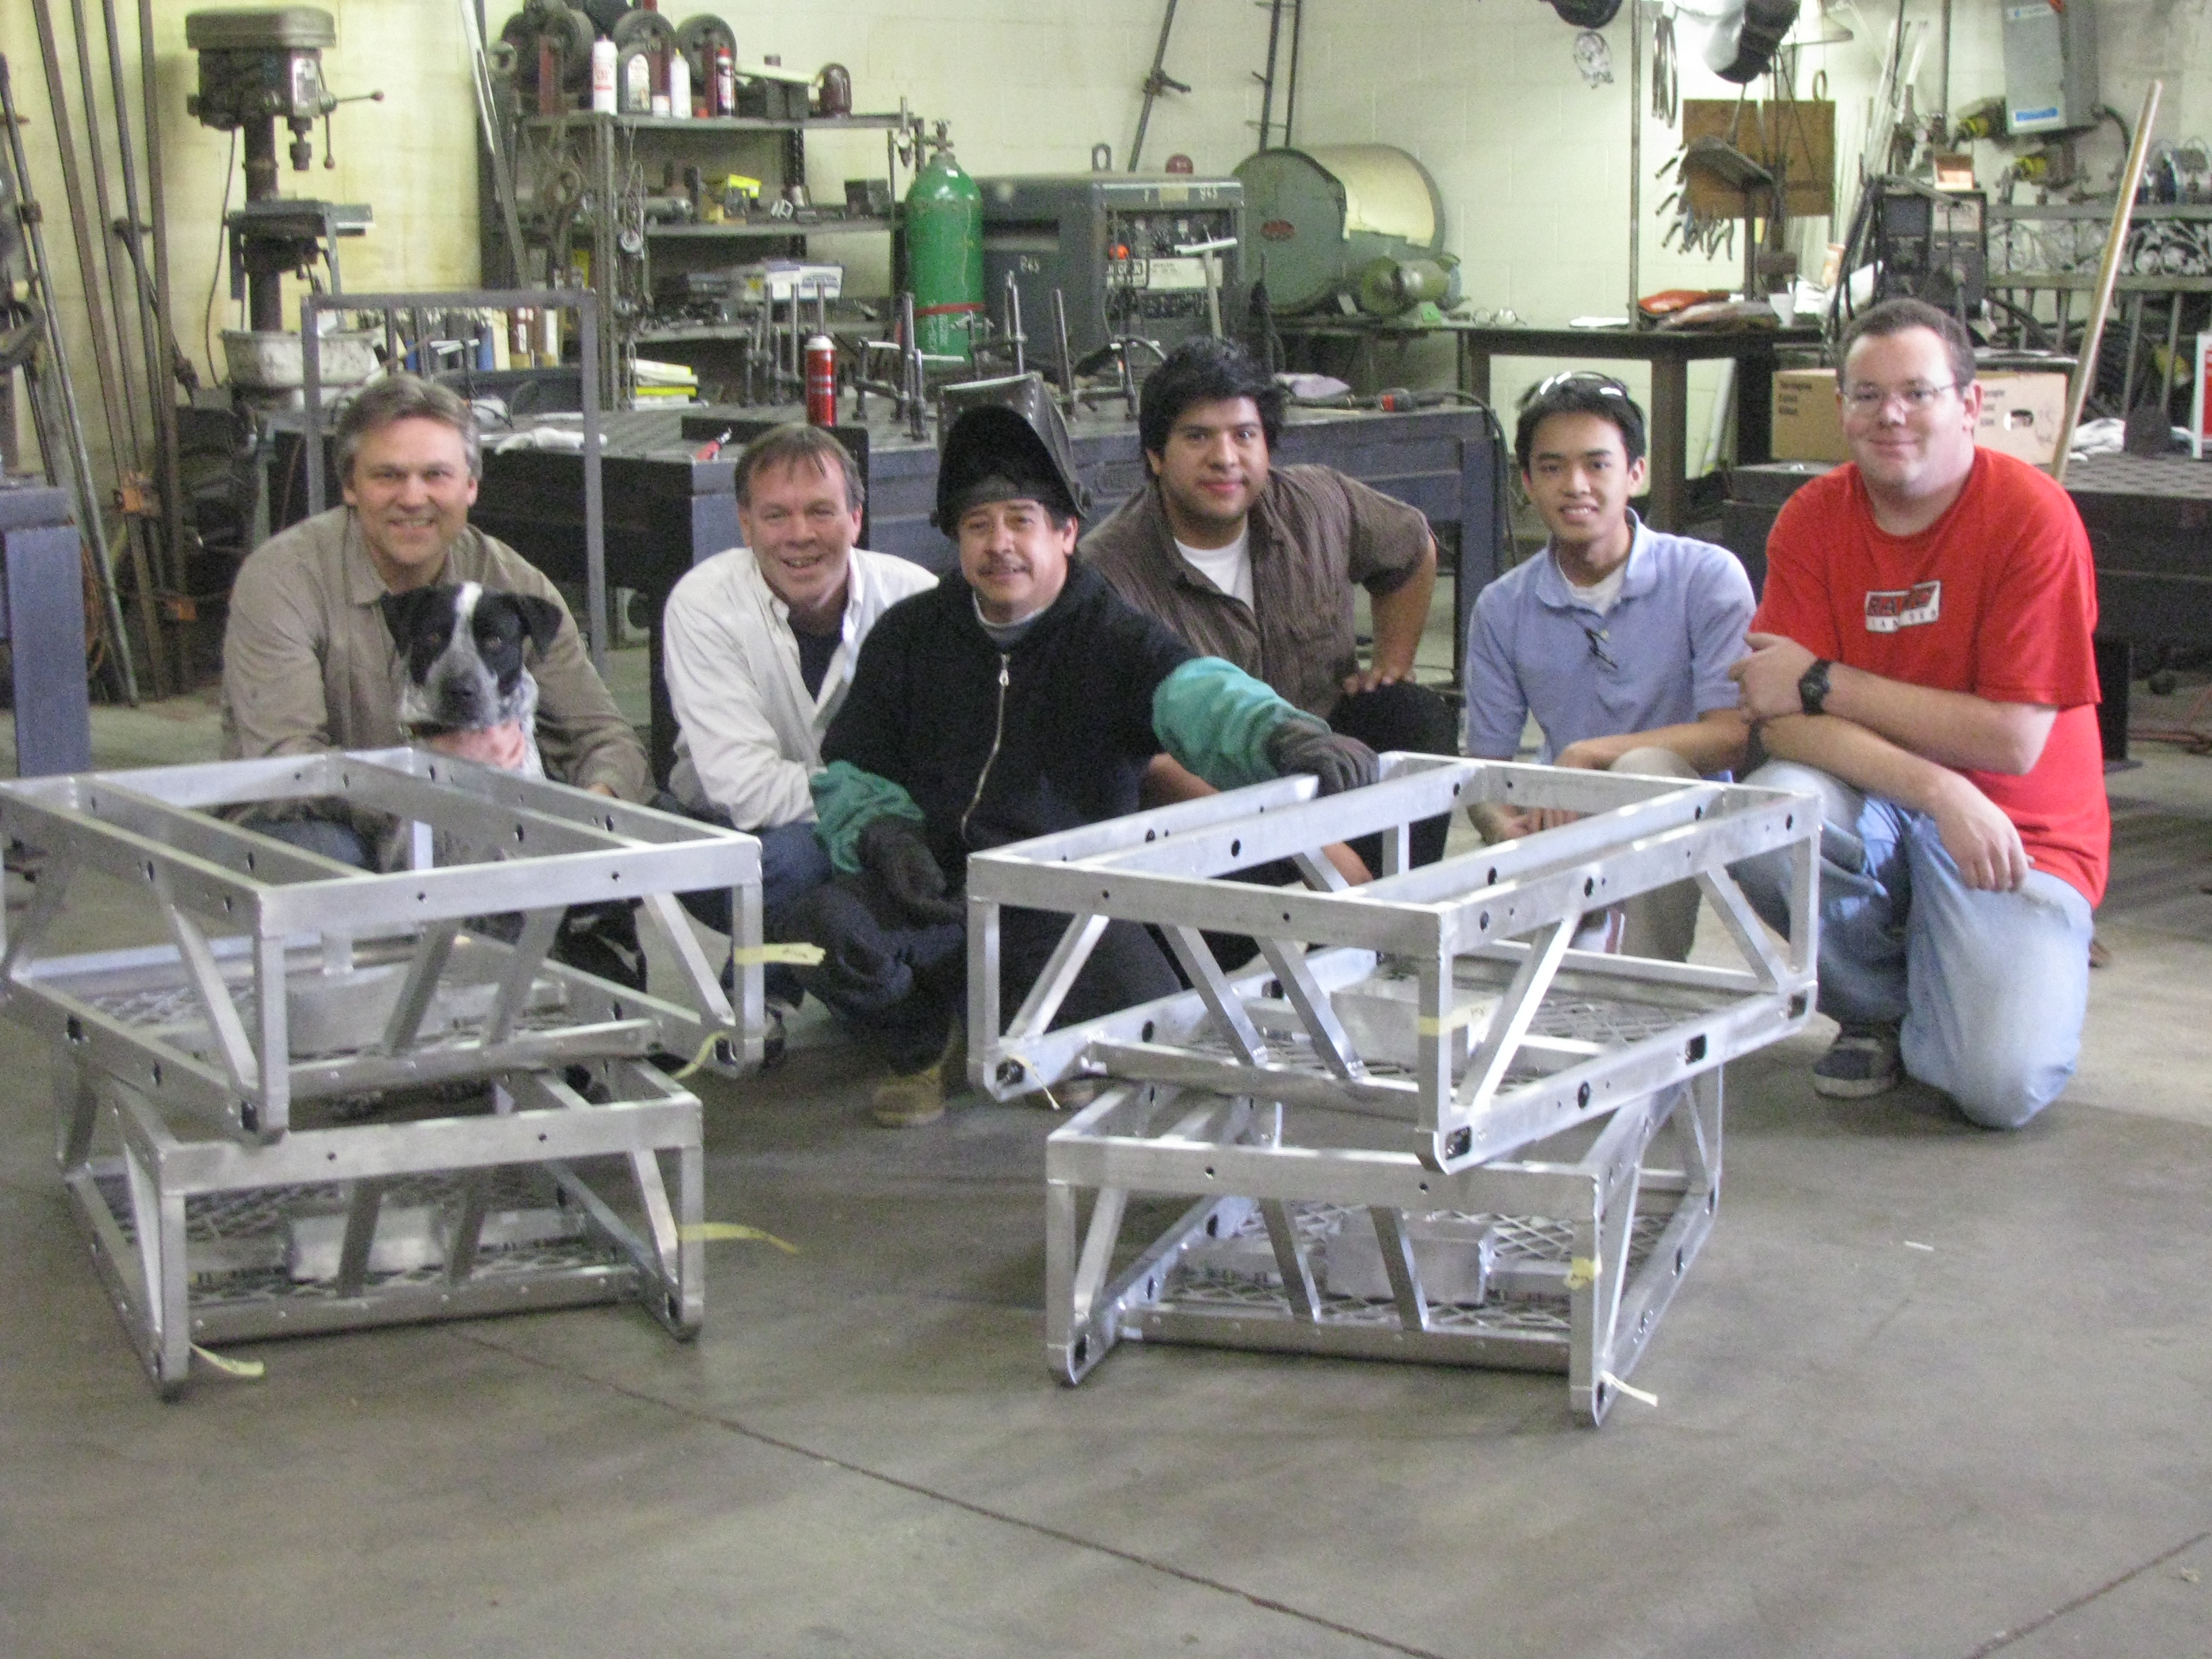
Today the welding was completed at Ride & Show Engineering, and the frames were delivered to Central Powder coating. The picture below shows us with the kind folks at Ride & Show.
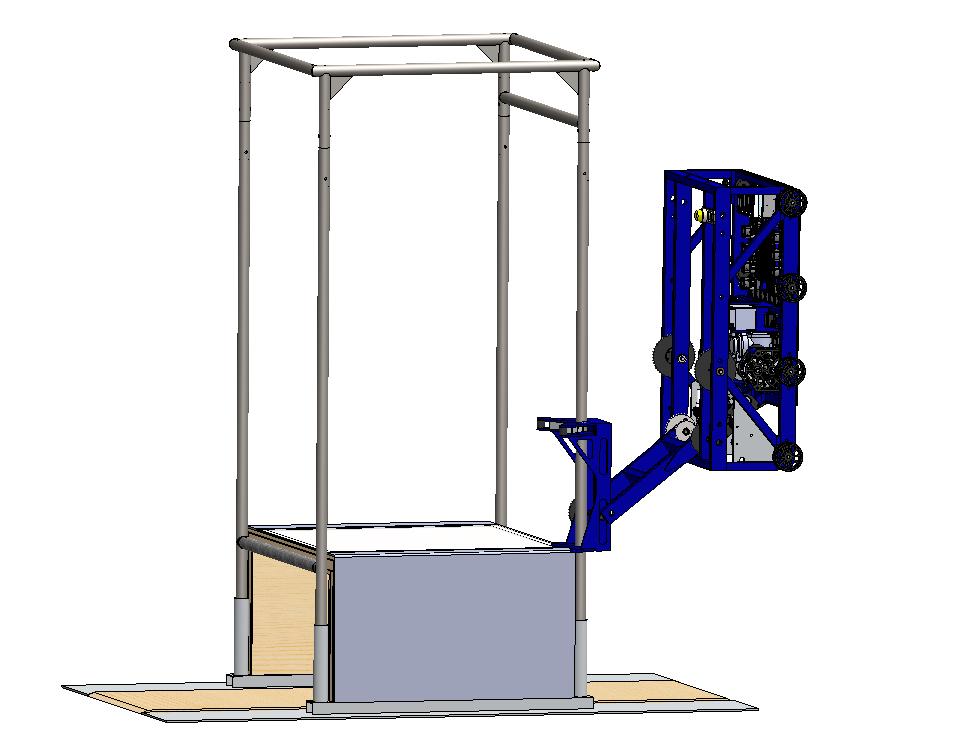
Today, we continued prototyping dual roller systems. We worked hard to emulate the drawings we had, but still found minimal success with the belt-driven systems. The faster the rollers were moving, the better the results. However, if the rollers were moving too fast, the window motors would stall and be damaged.
At the end of the evening, we strapped a Dewalt 3 Speed Drill onto the robot. With the shifter on middle or high speed and the clutch set very low, we were able to obtain and hold the ball extremely well. Videos of this system at work are below.
Original video unavailable.
Original video unavailable.
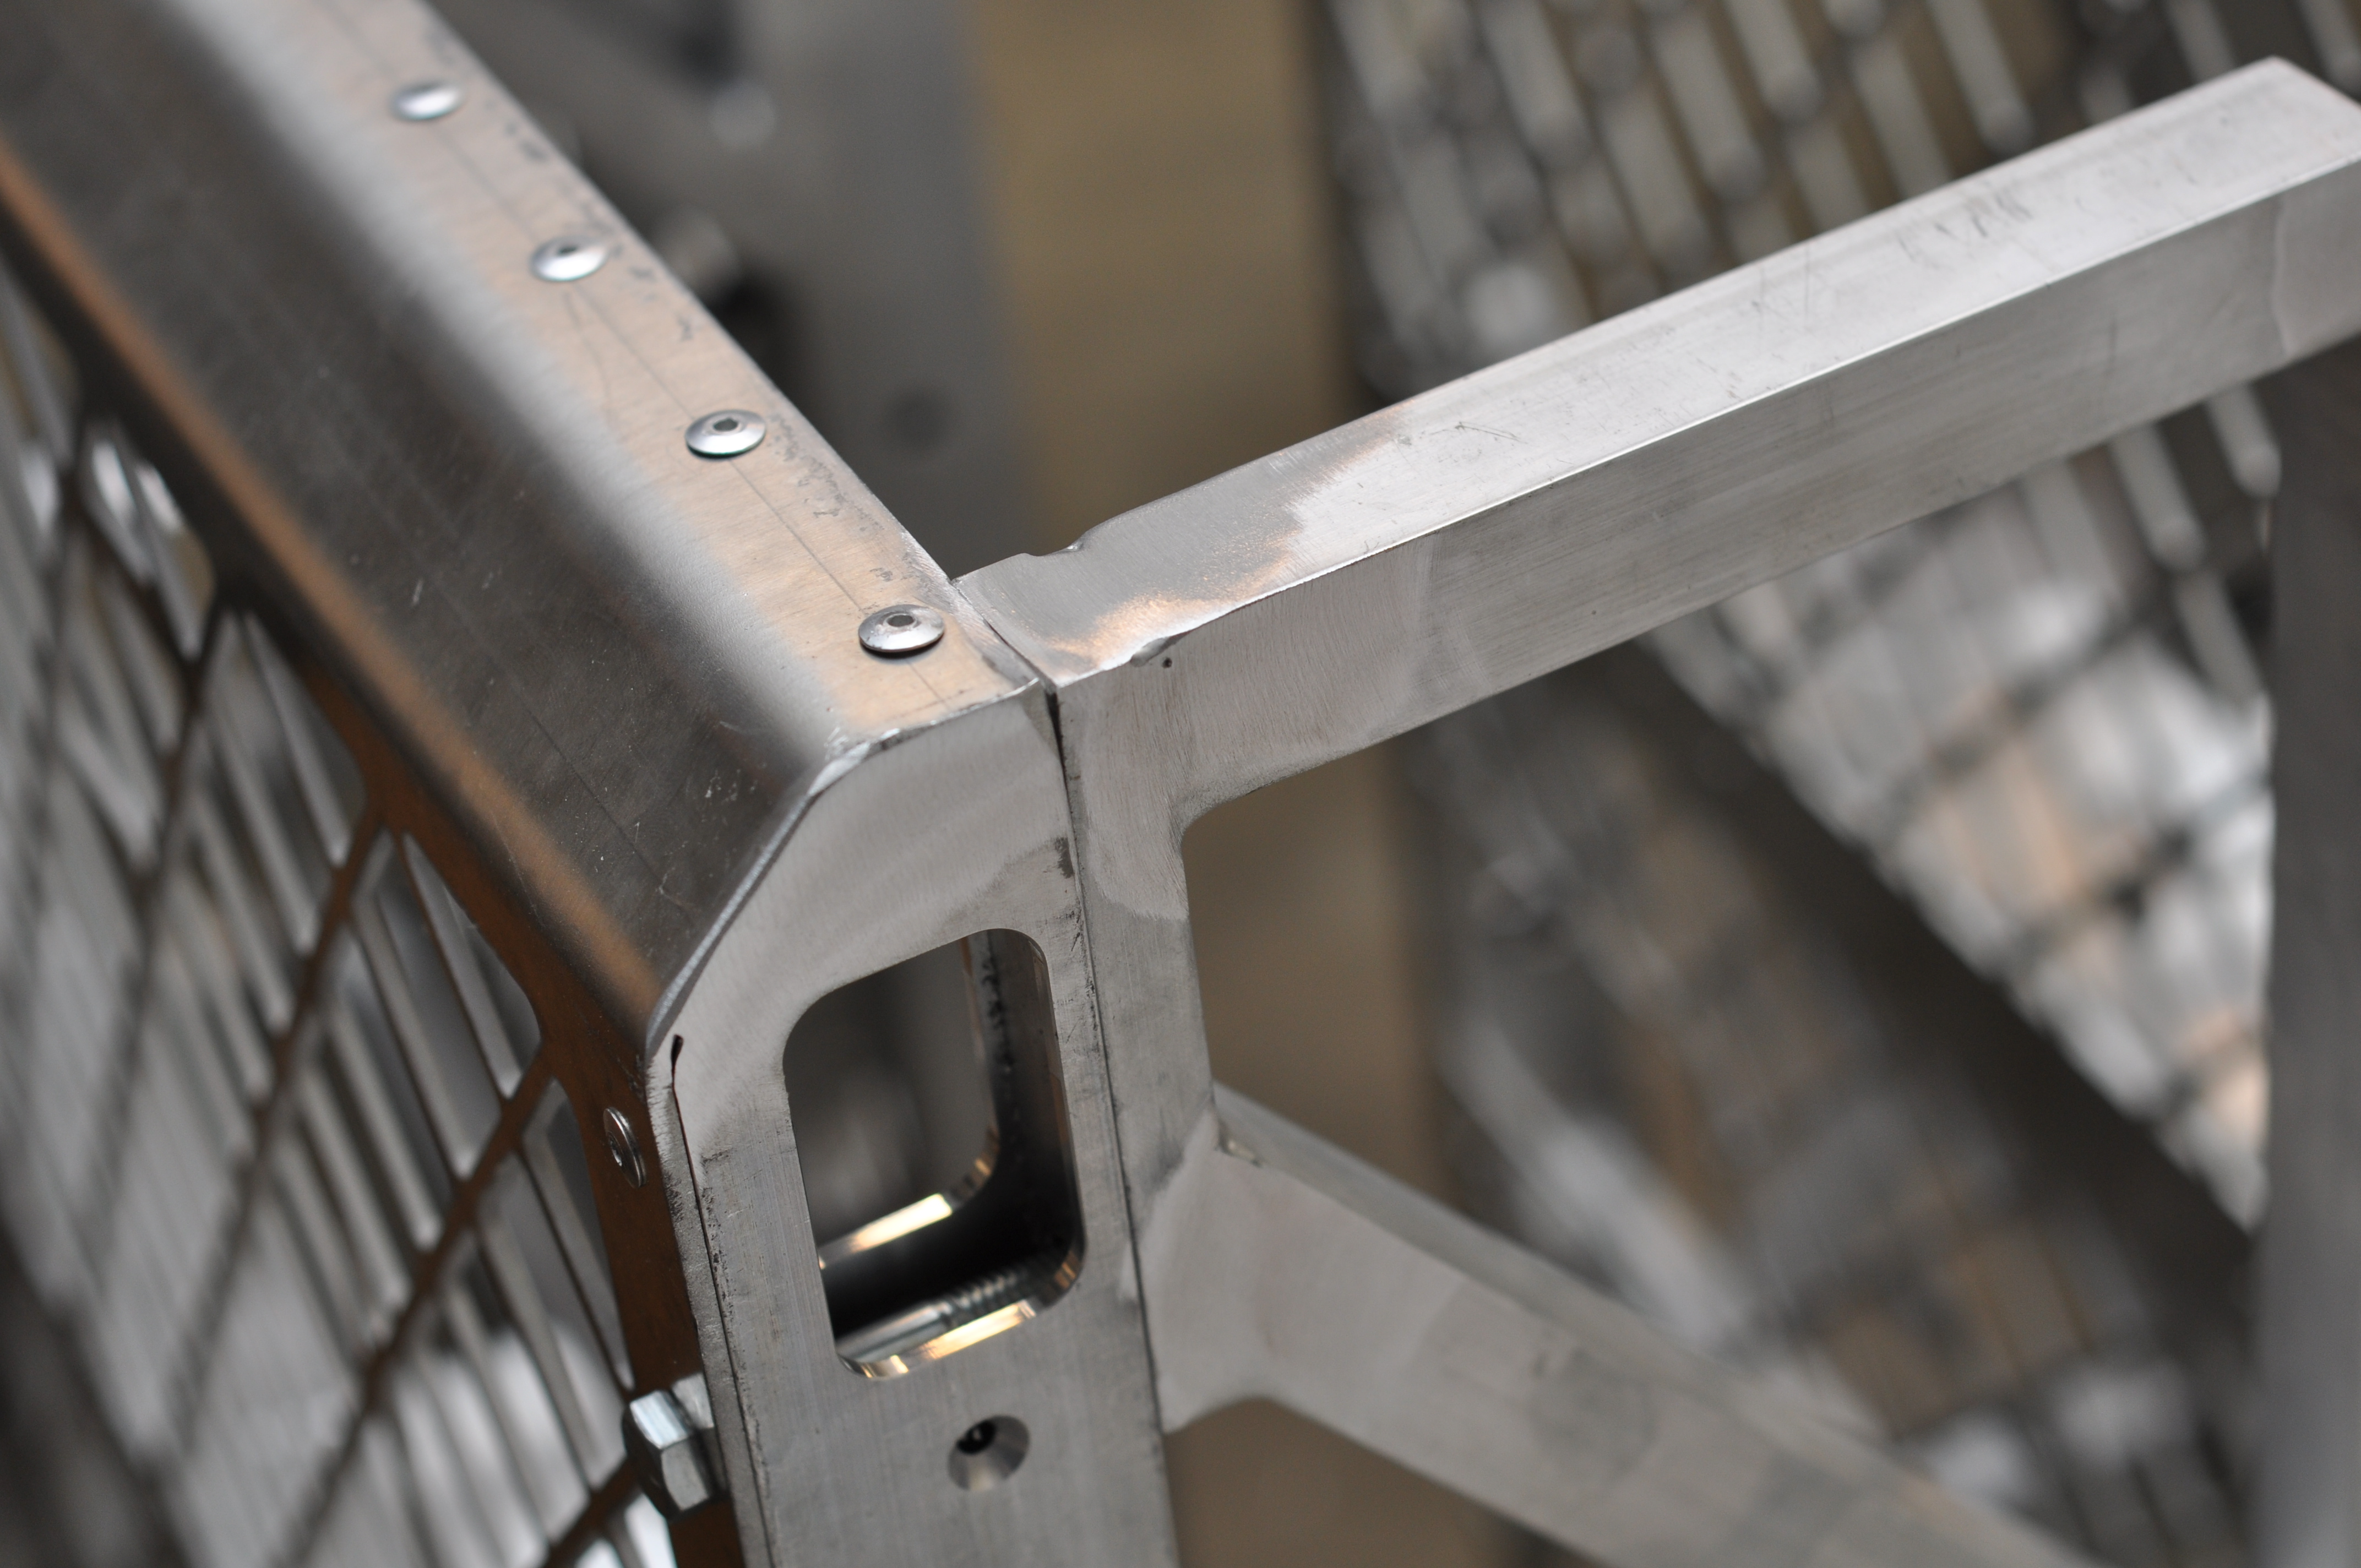
Here's a few shots of the welded base after having the welds ground flush.
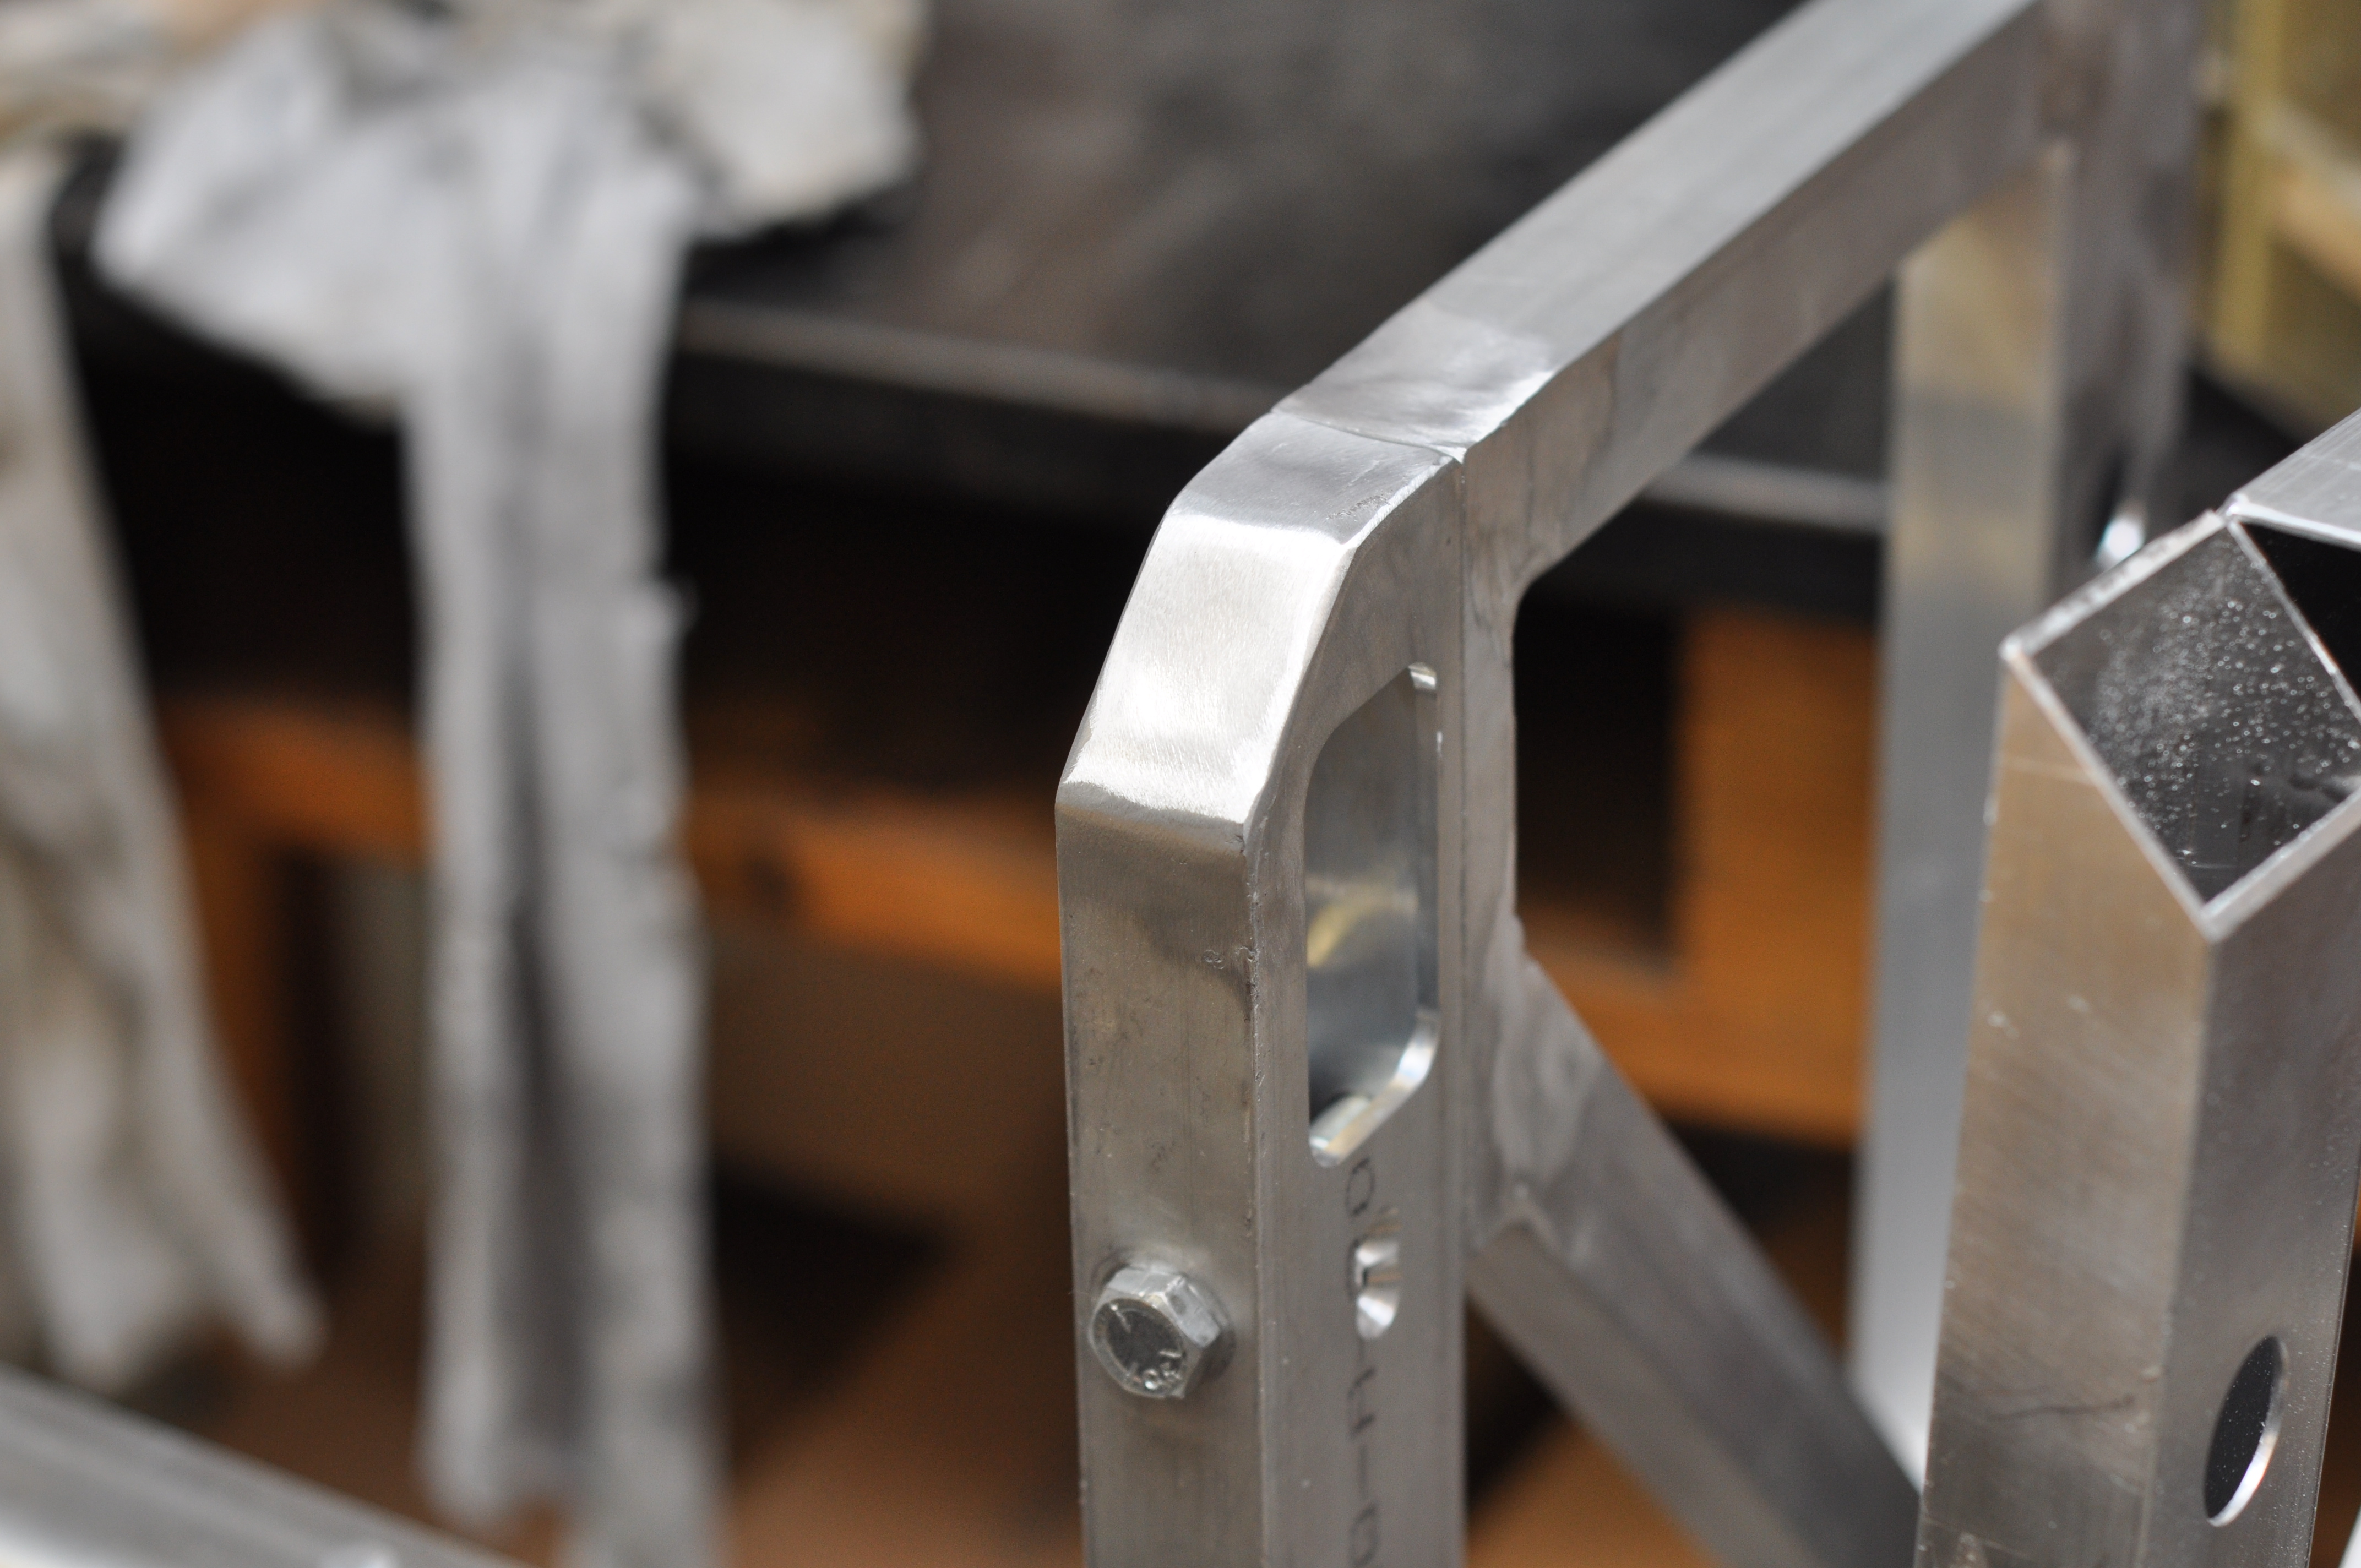
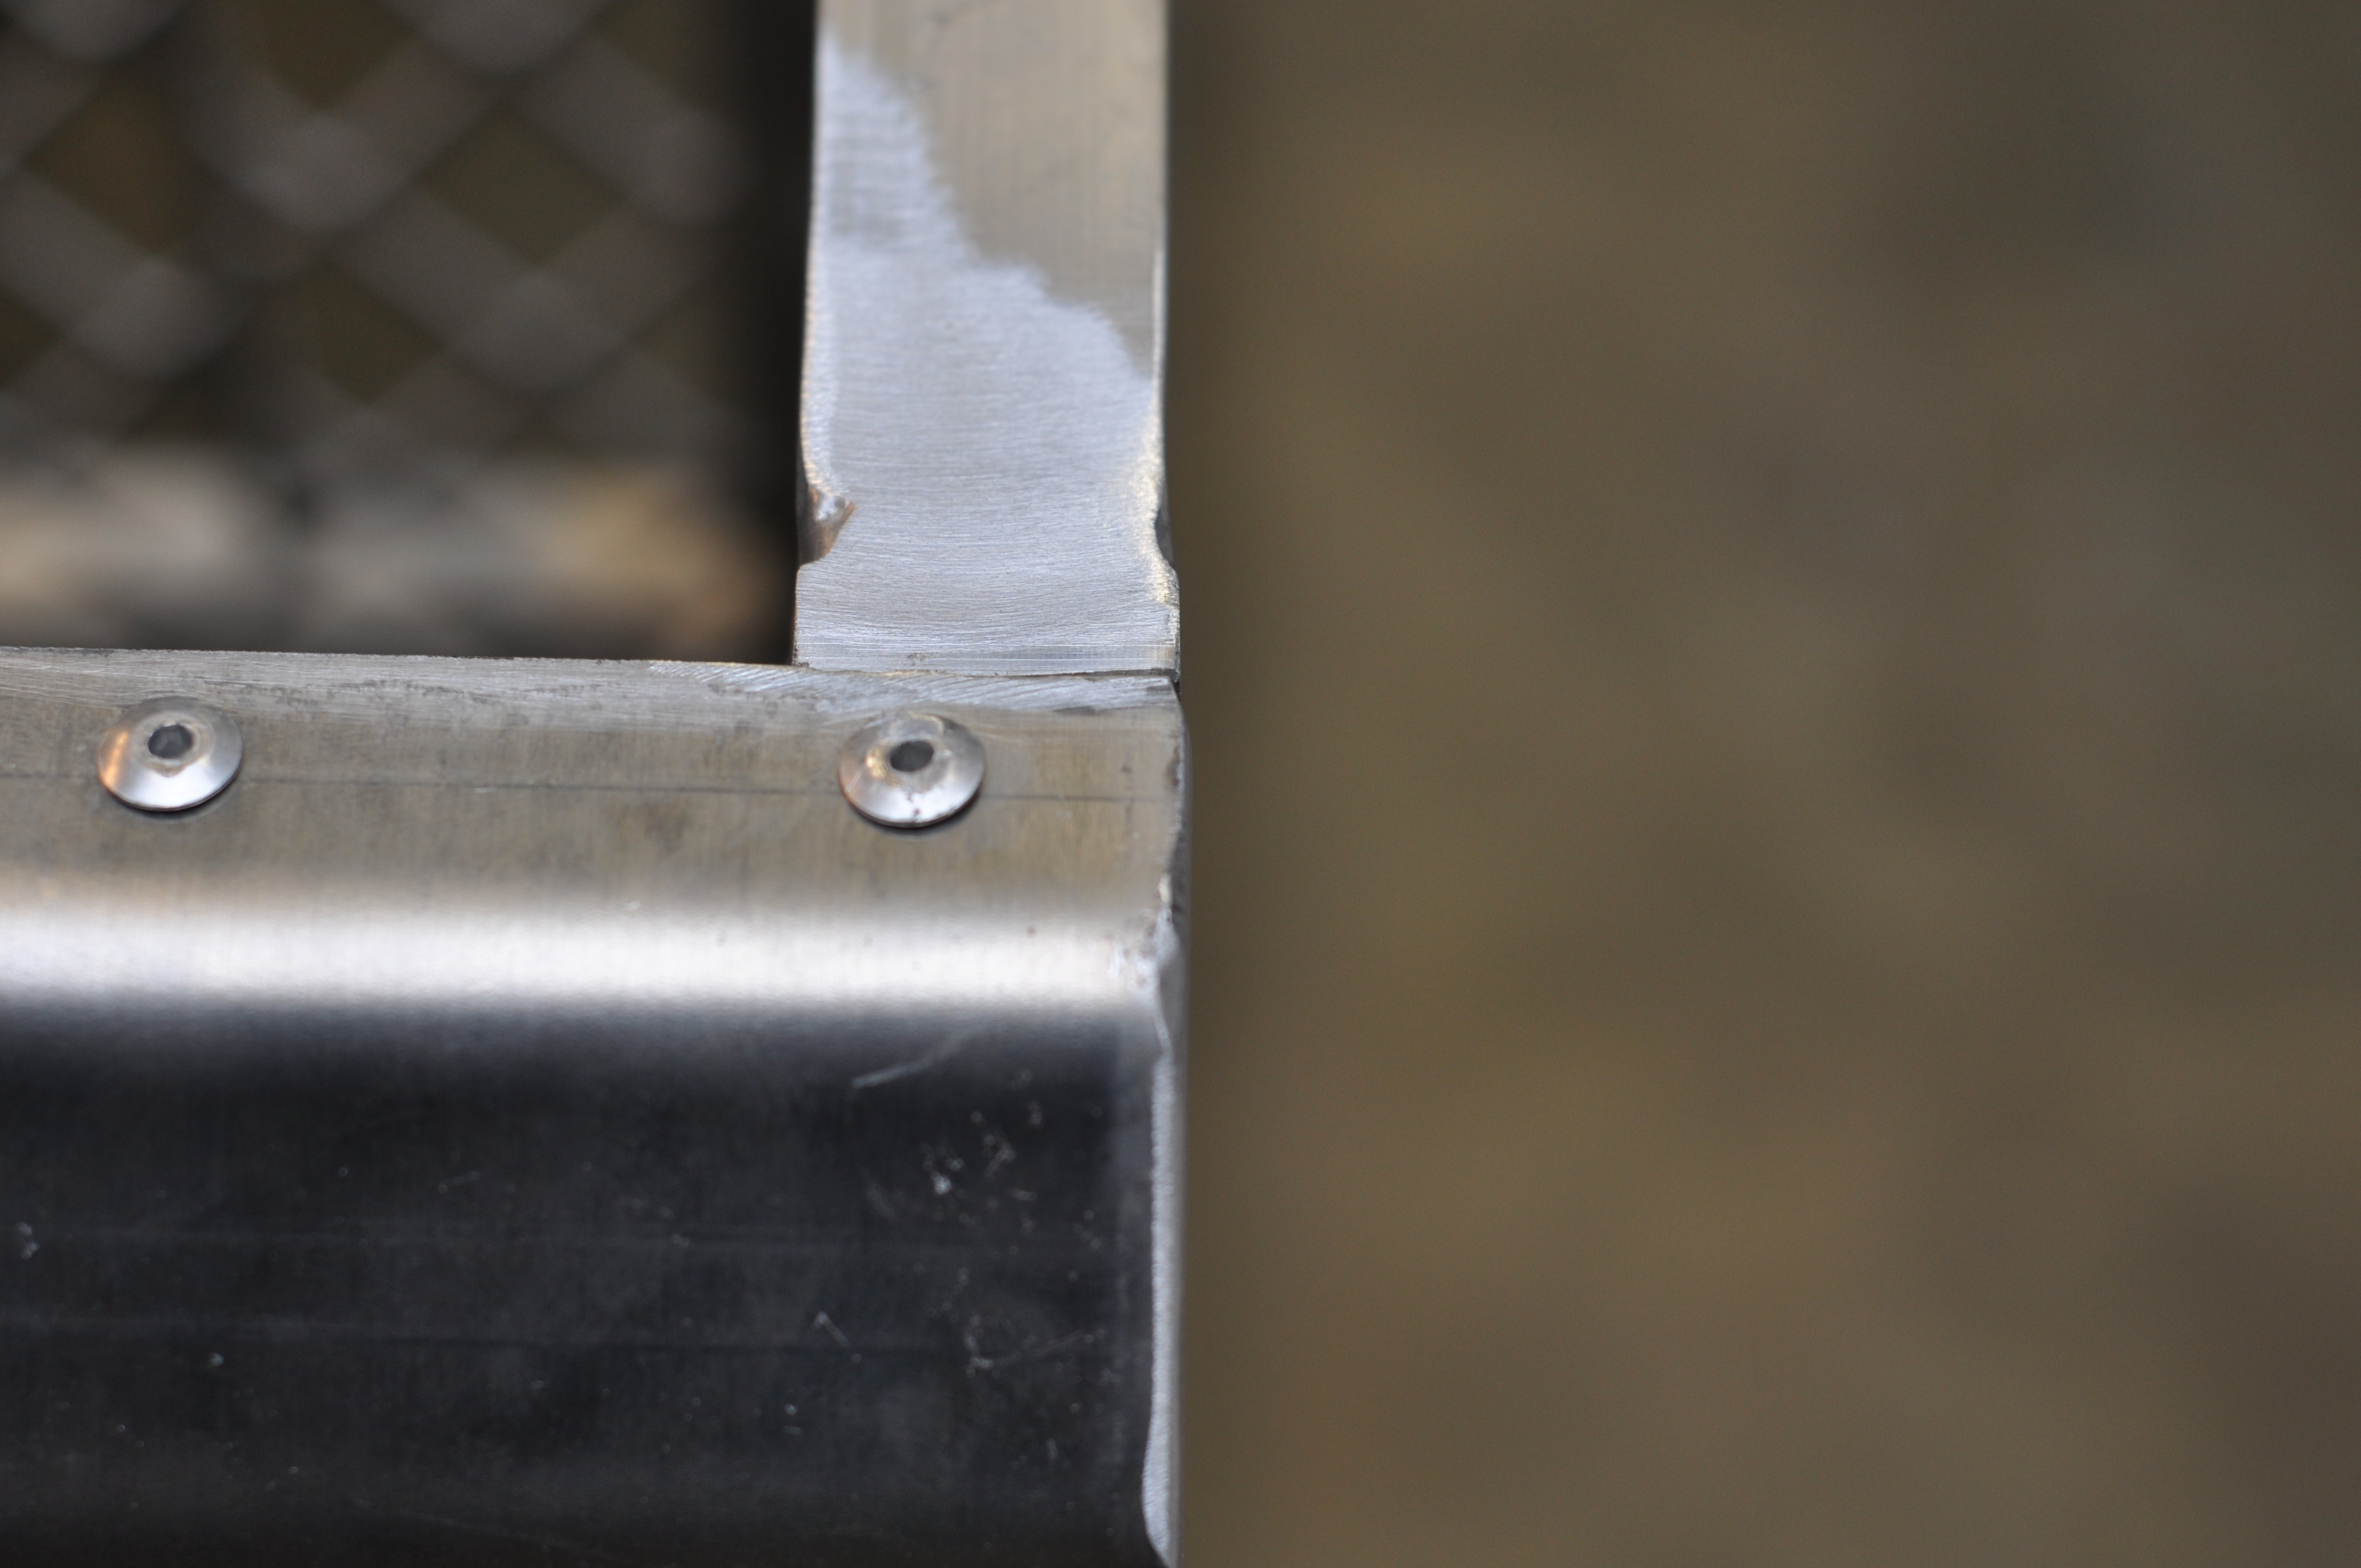
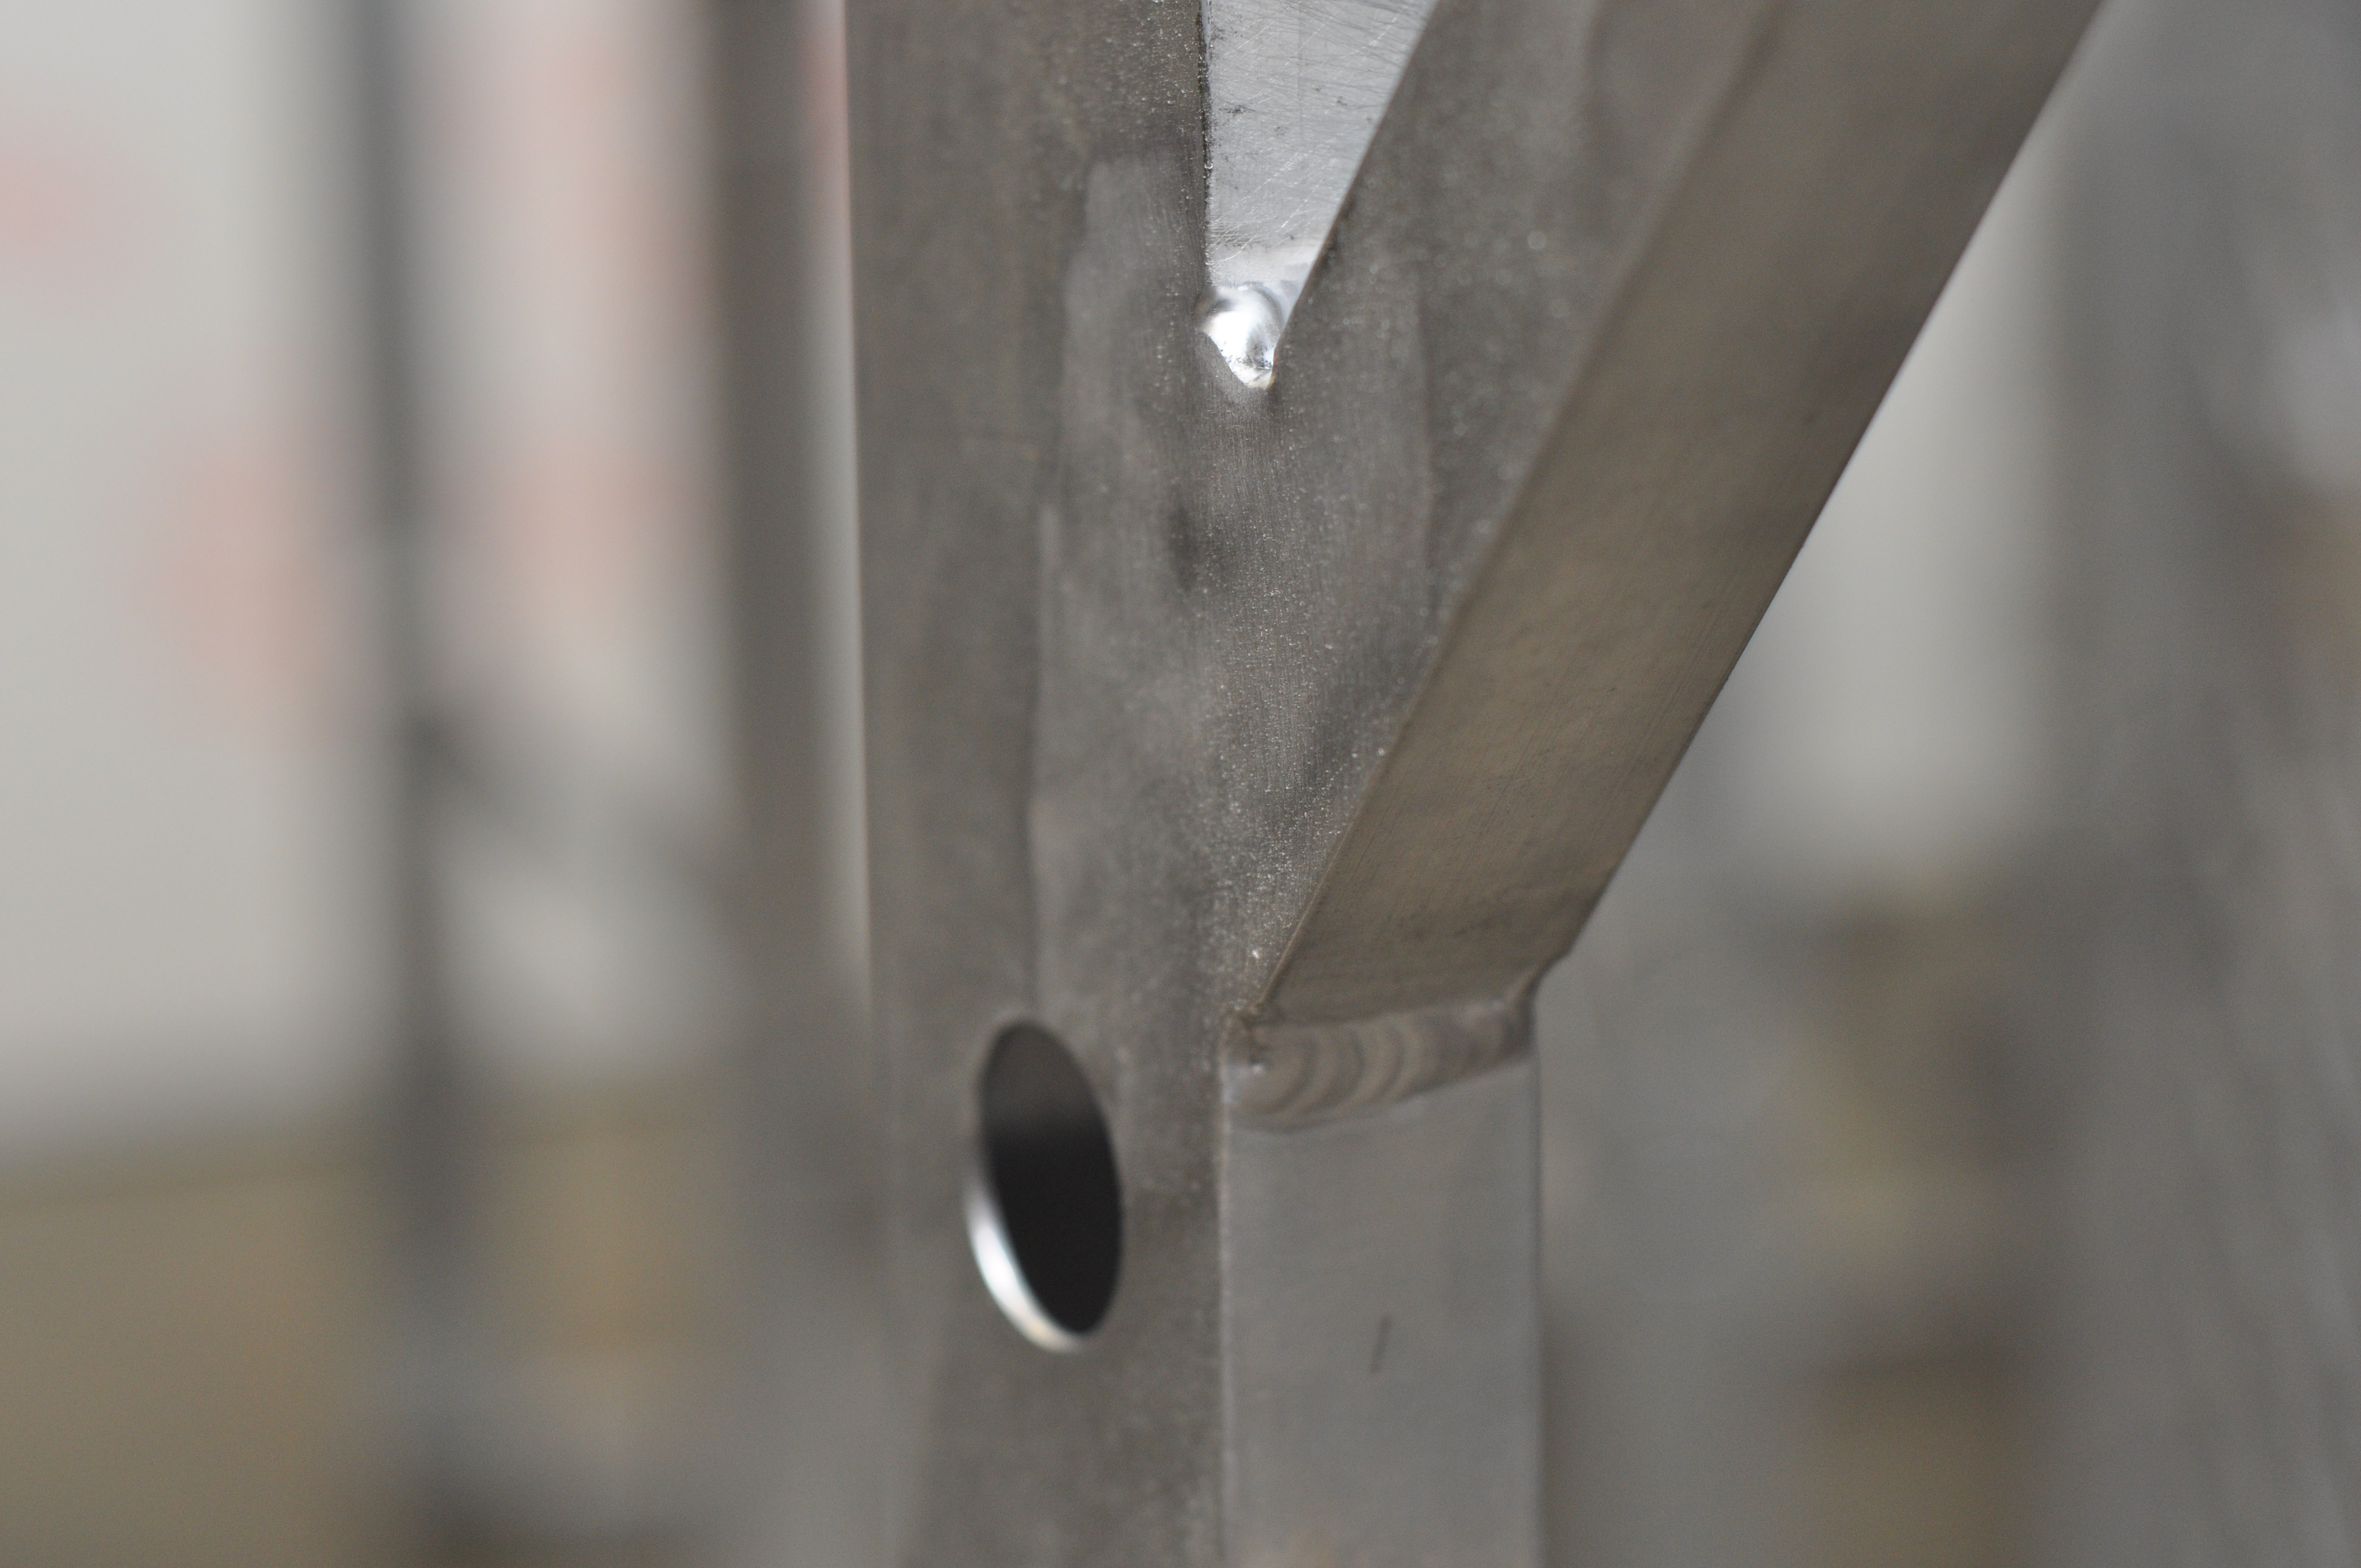
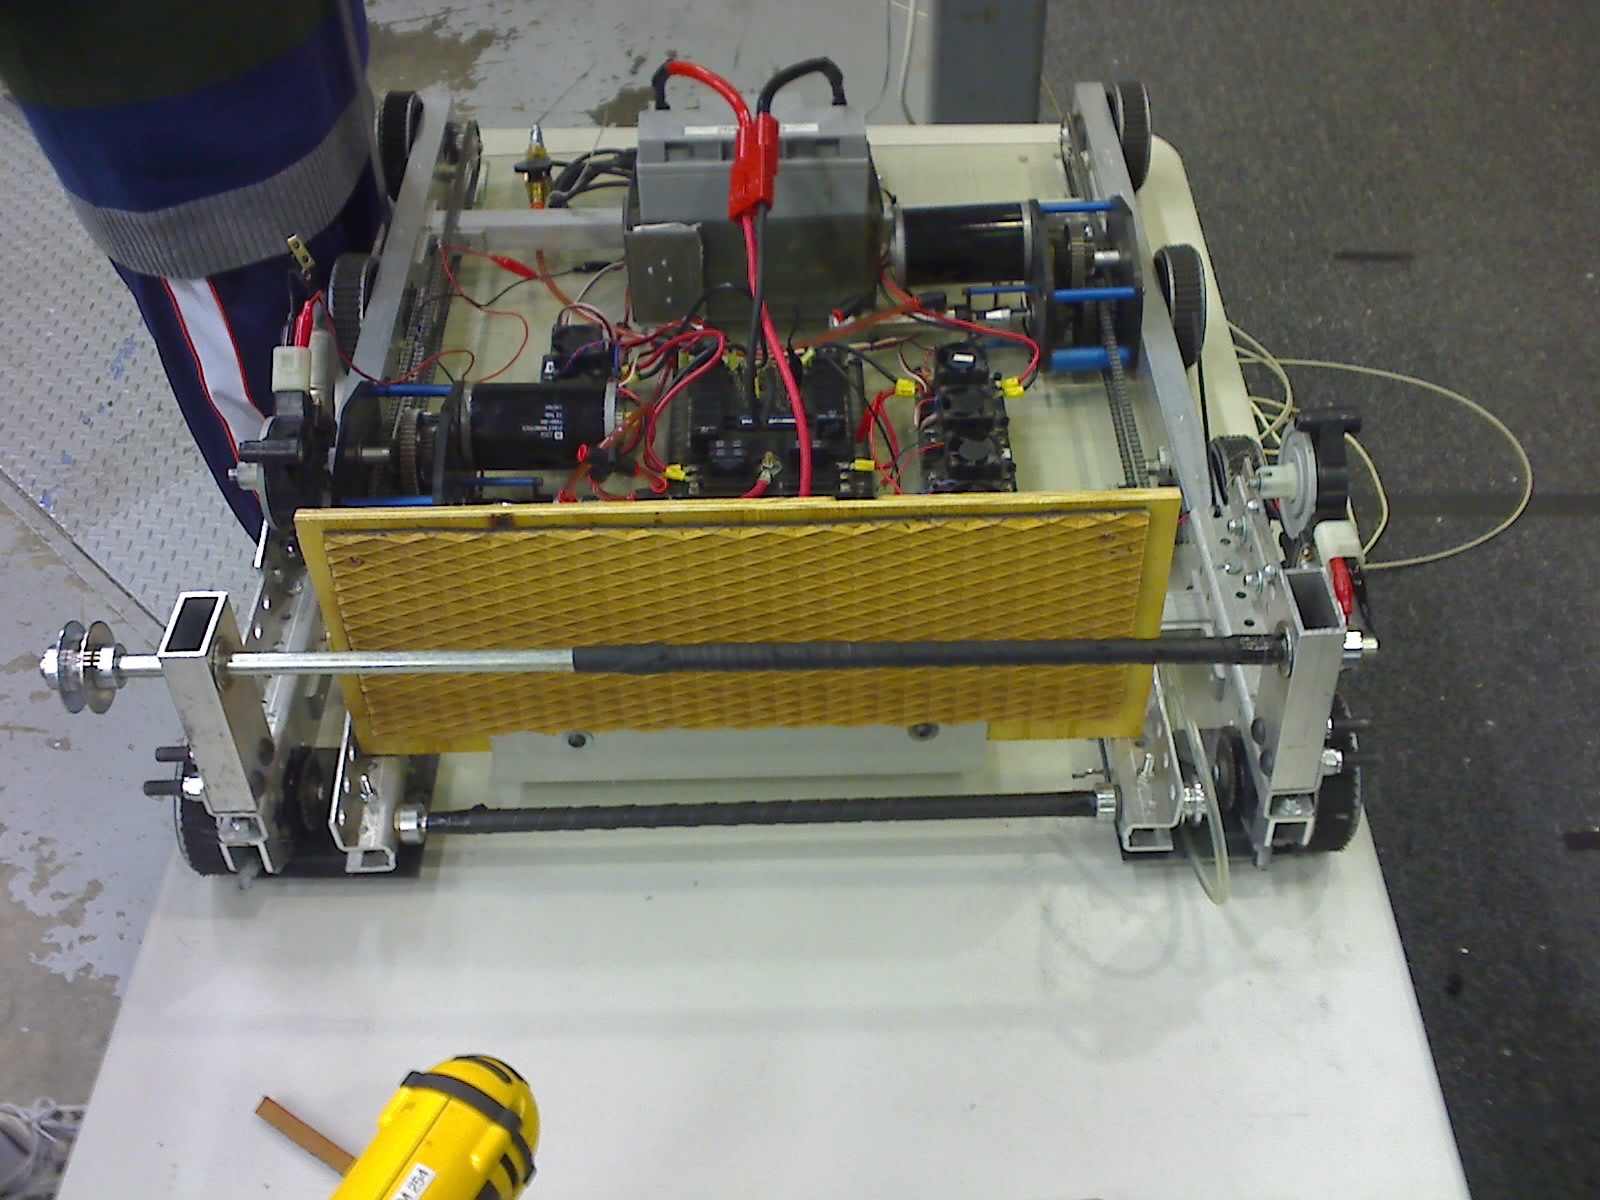
We continued to revise the two horizontal-rollers prototype so that it would be ready for proper implementation on the final design. Some of the most recent changes made include a stop, so that the ball is physically limited from entering more than 3 inches into our robot. Unfortunately in the earlier tests the ball actually entered 4 inches into our robot and roughly 1/16 inch off the ground. We also shifted the upper roller as forward as possible while retaining space for the bearing and moved the lower roller forward. The roller speed was also increased from the window motors with a 4 to 1 pulley reduction Videos should follow tommorrow after the design is perfected further.
Down in the shop we continued to pocket gears on the CNC and several sets for both the drive-train gearbox and the shooter winch gearbox have been manufactured already. Hopefully by the end of tommorrow we will be for the most part done pocketing the gears (at least the ones finalized on the design). They will be ready for ship by Monday or Tuesday.
Dual horizontal rollers with tennis racquet grip tape = money.
Team 254 finally finished the initial prototype for dual horizontal rollers this evening (Based on 148's prototype) and after much tweaking we found that the rollers held the ball securely and within the limits of the rules. The mechanism uses two small window motors running continuously (at least in this prototype), and it has little difficulty with picking up a ball on the go. For a final design, the rollers should spin faster to ensure that the ball is picked up 100% of the time, and actual placement of the rollers will need to be tweaked to perfection.

Original video unavailable.
Original video unavailable.