22 posts

Madtown Throwdown Offseason Tournament

2018 FRC Build Season

A Brief Summary

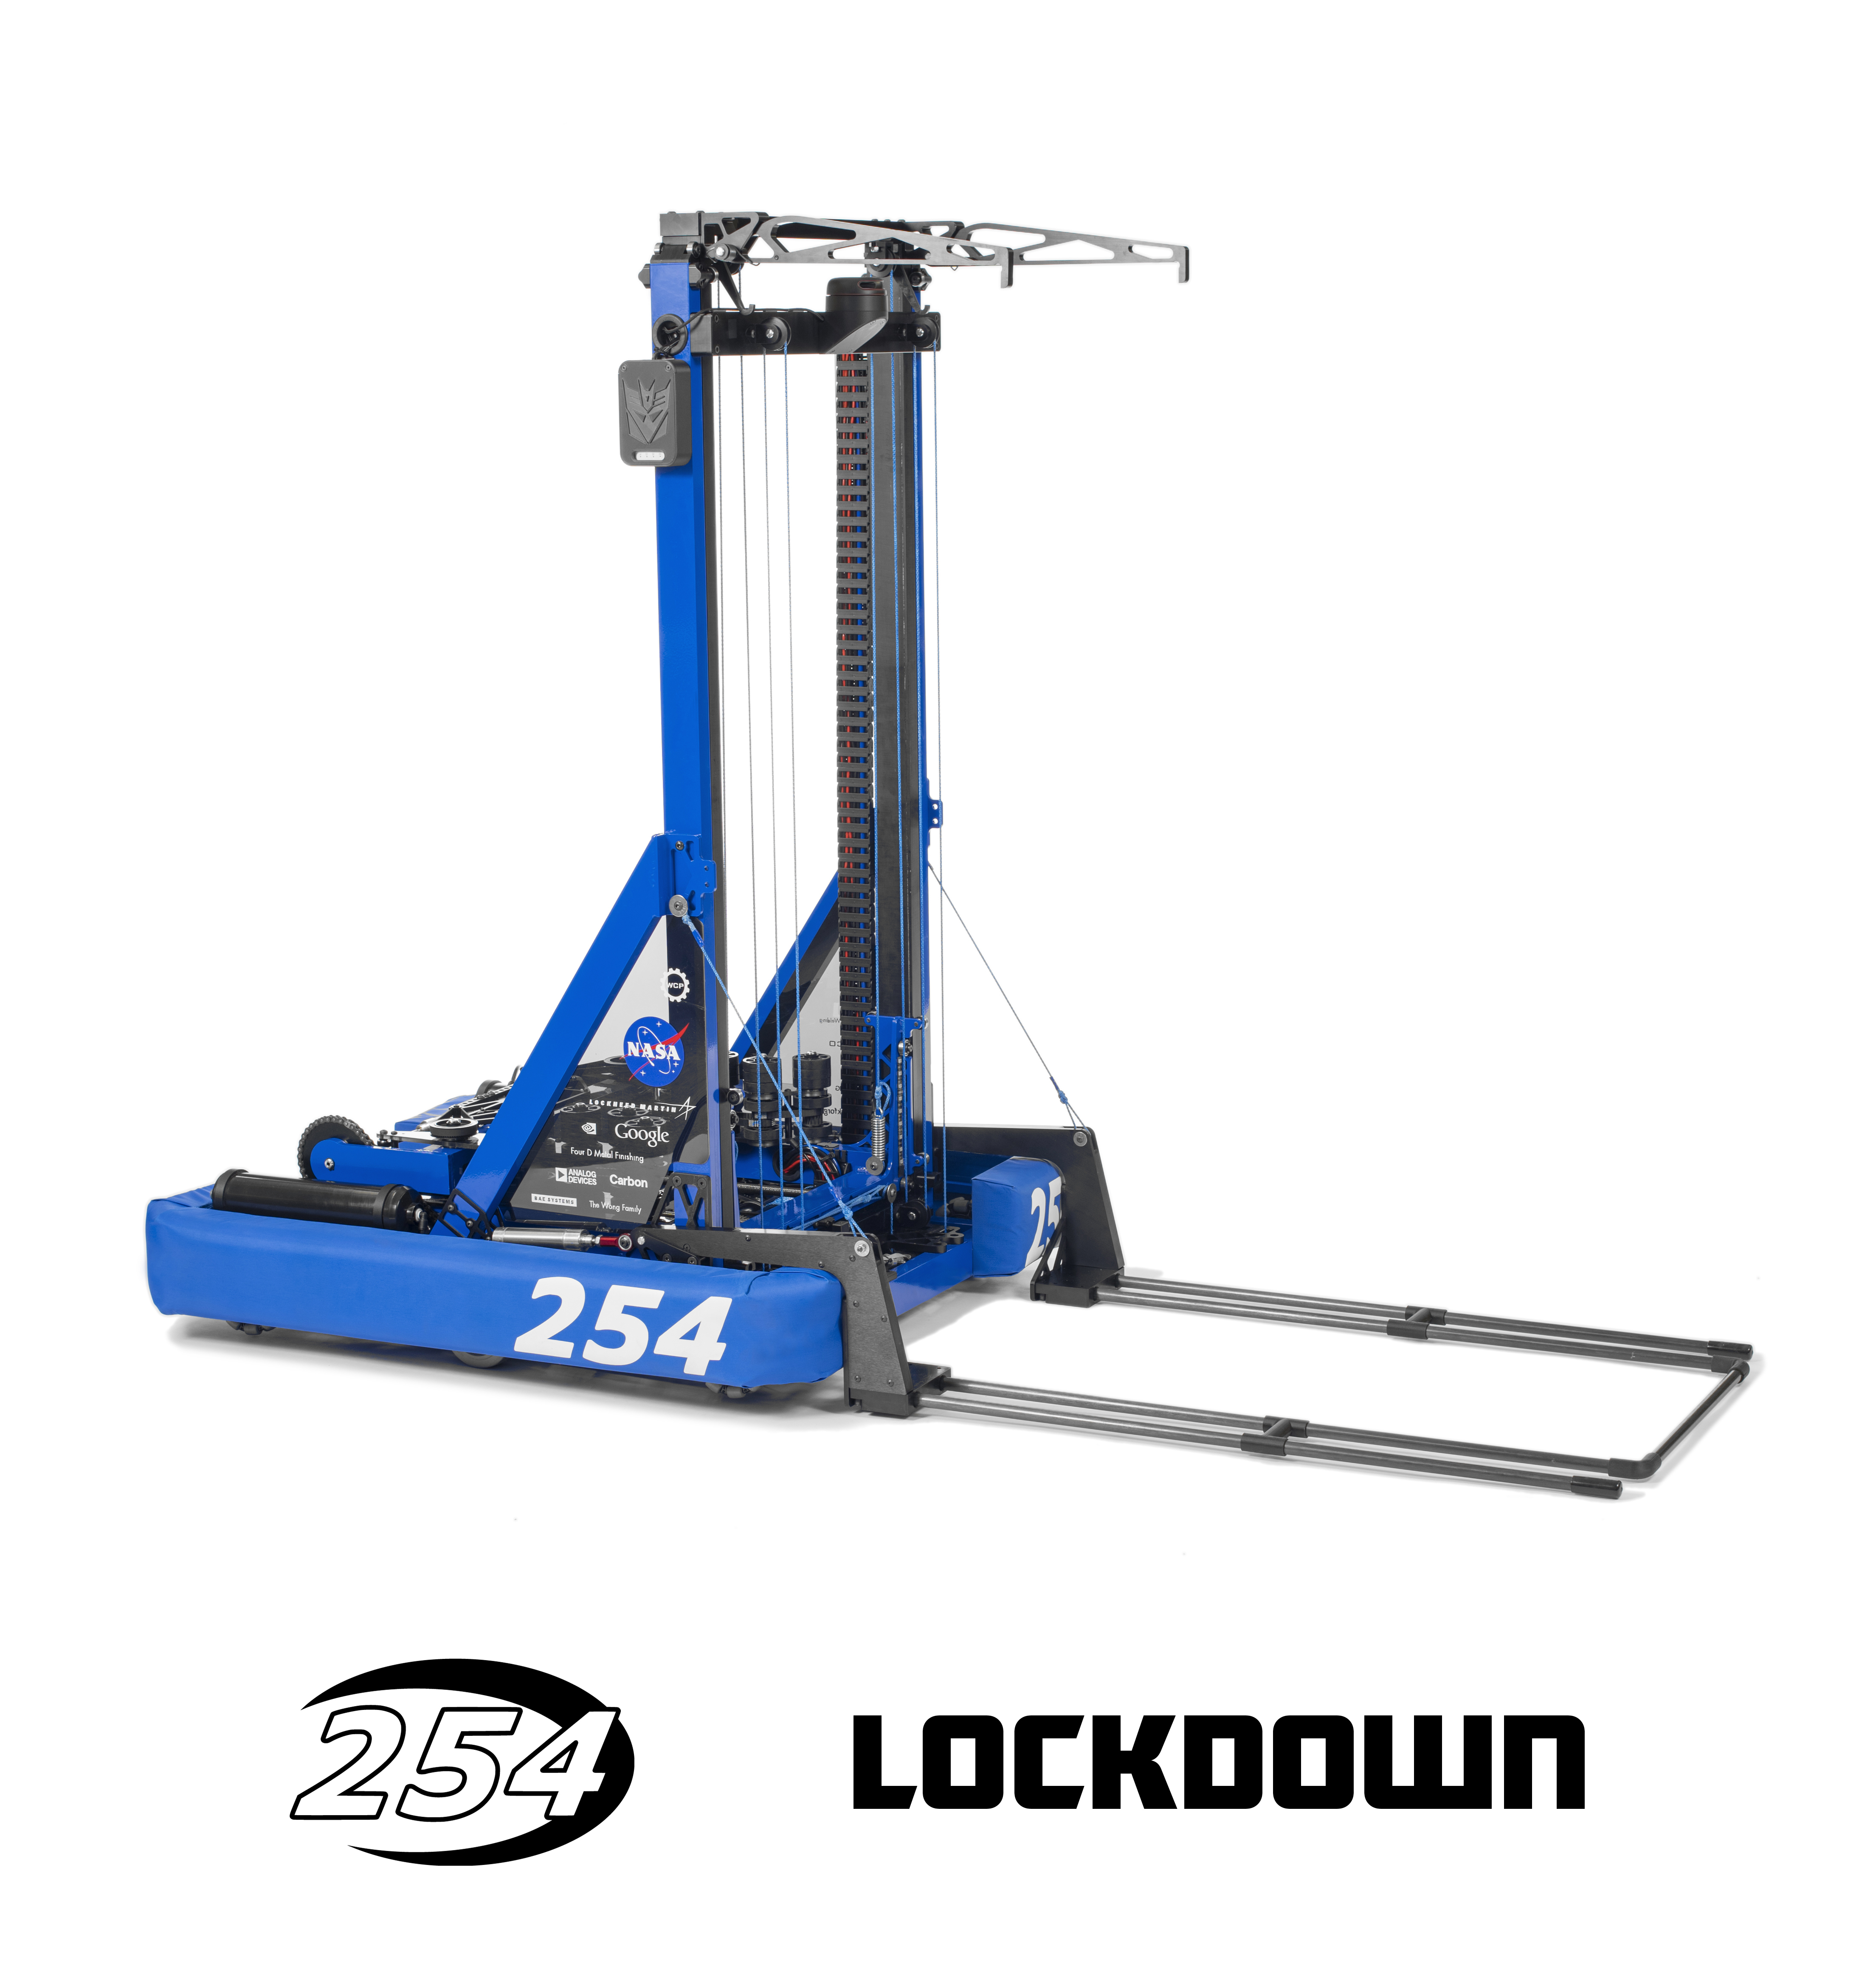
As part of an eventful weekend, we attended Madtown Throwdown, an annually hosted offseason tournament hosted by Team 1323 (Madtown Robotics), in Madera, CA. We had a great time jumping back into action with our robot, Lockdown, before the start of the 2019 FRC Season. Alongside, FRC Team 1323 MadTown Robotics, their offseason robot (9323), and our own programming robot (9254), we were able to win the tournament!
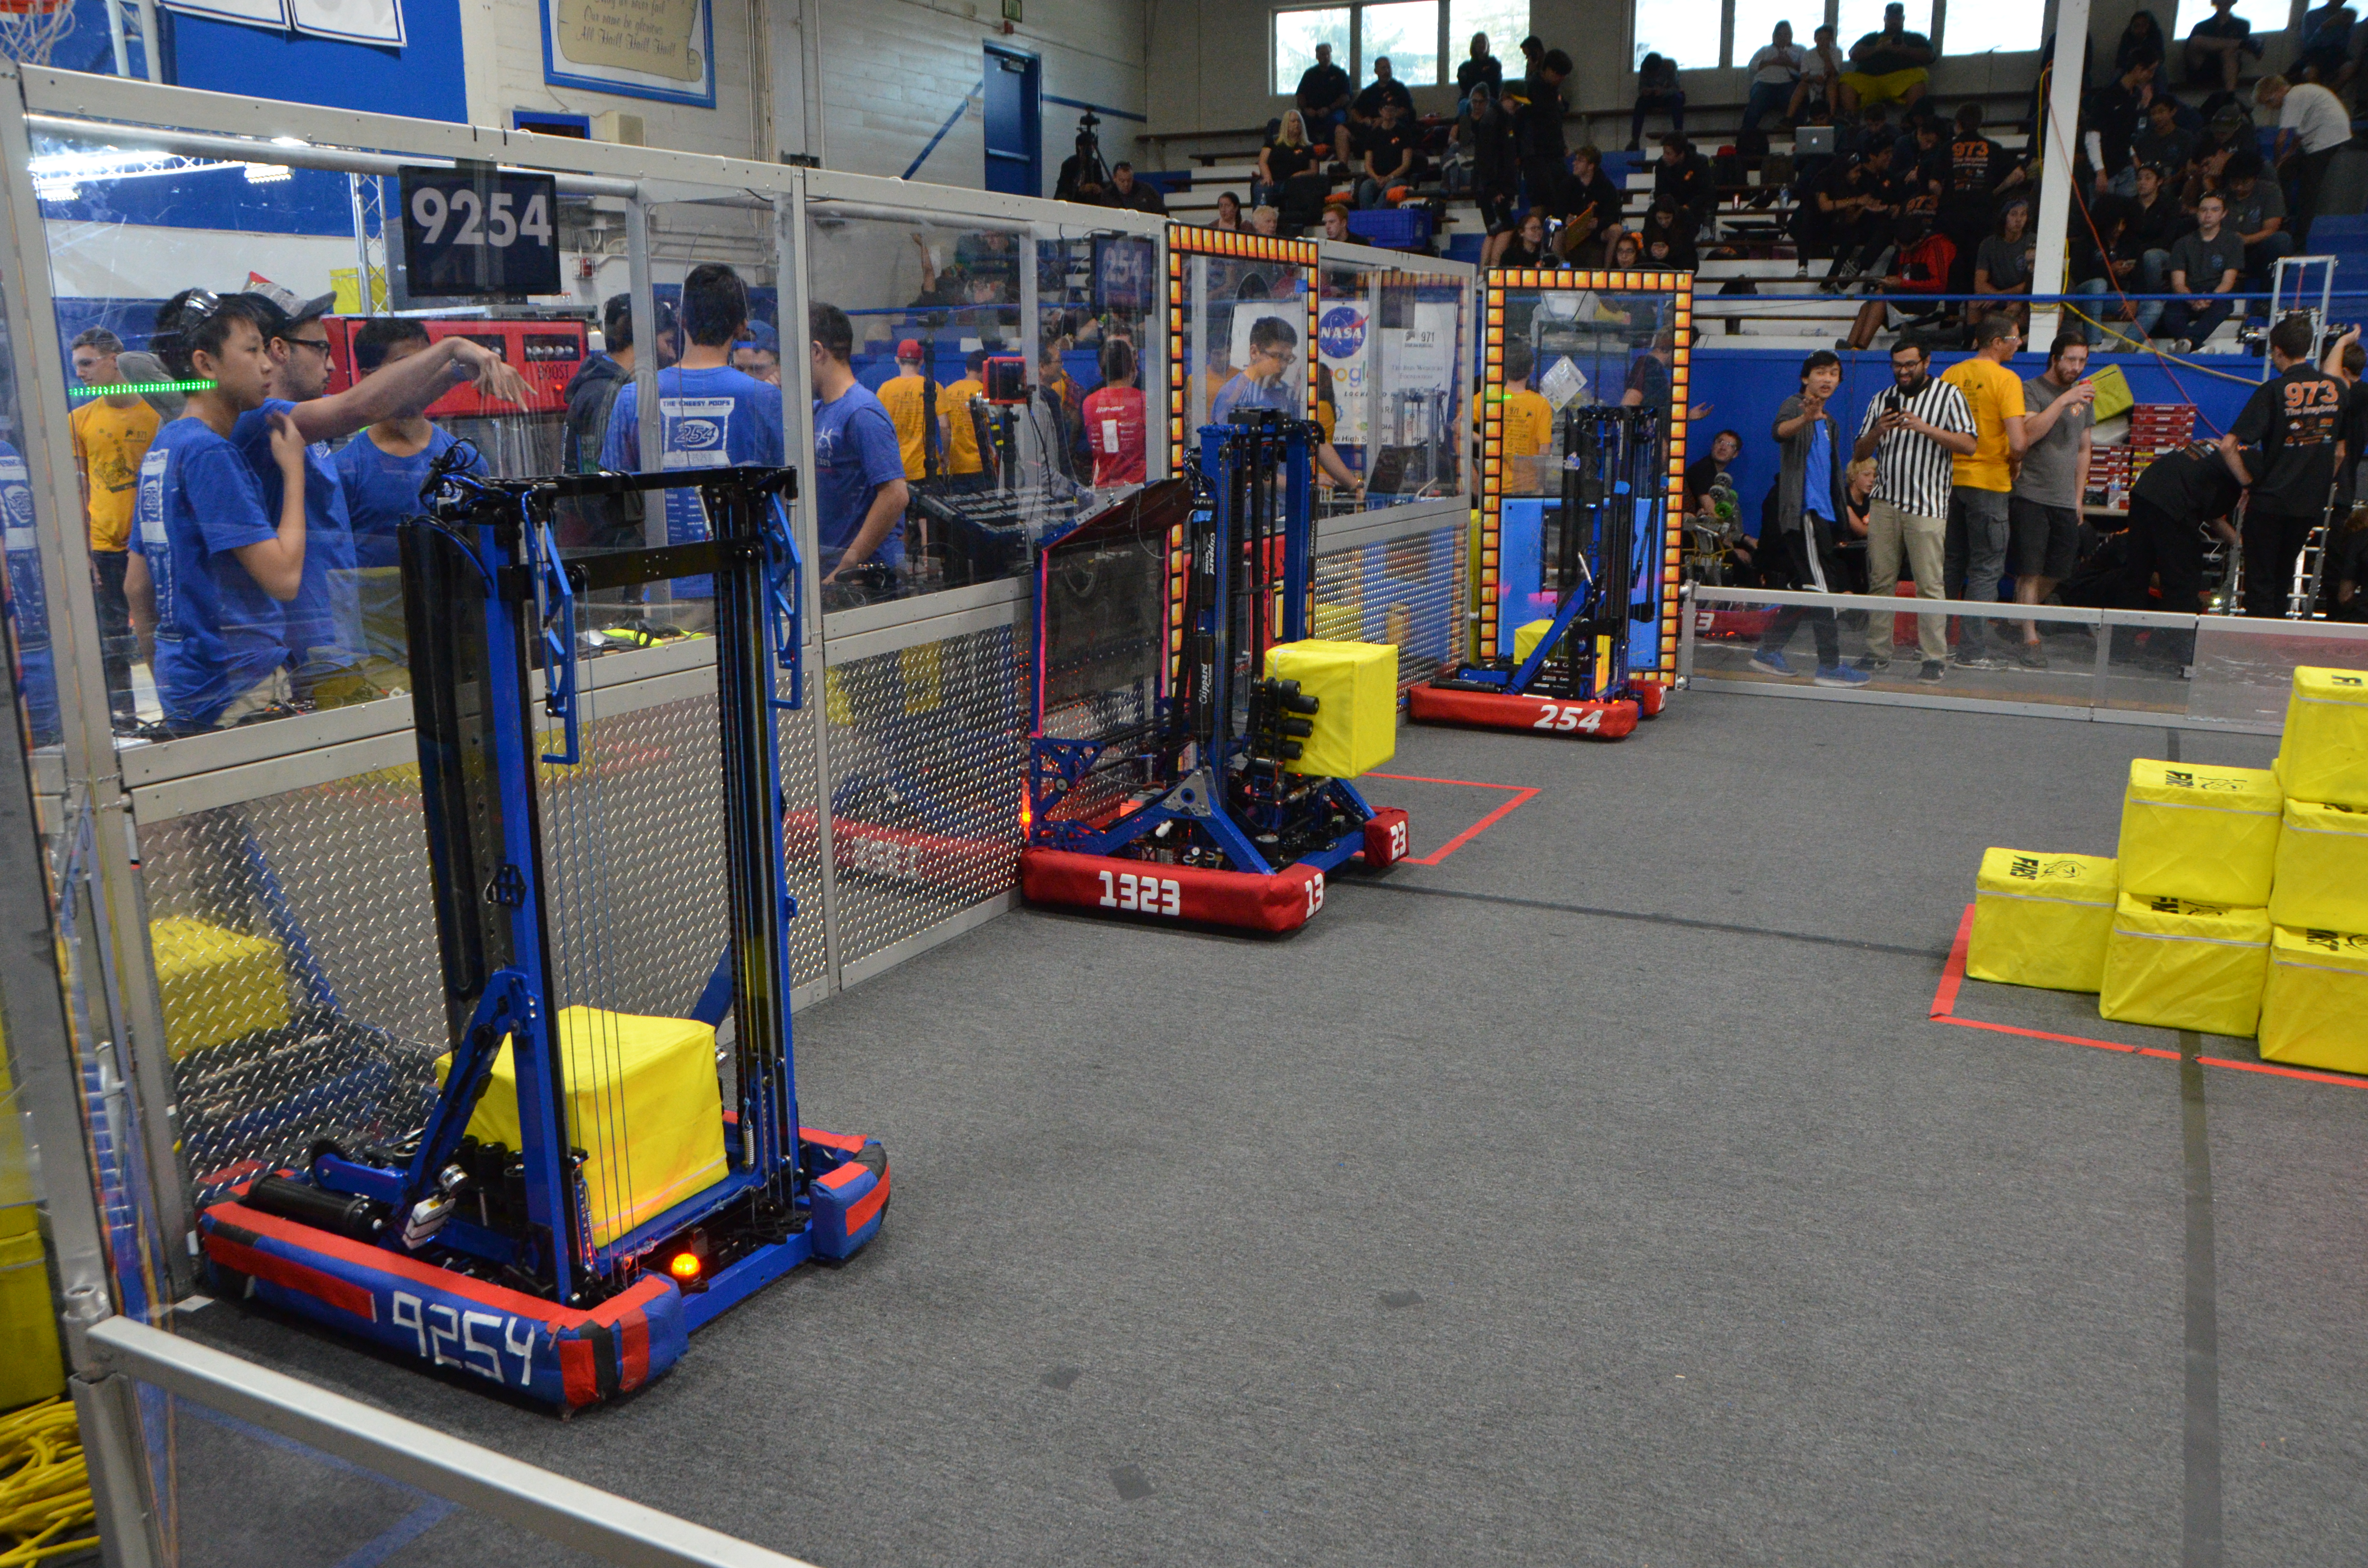
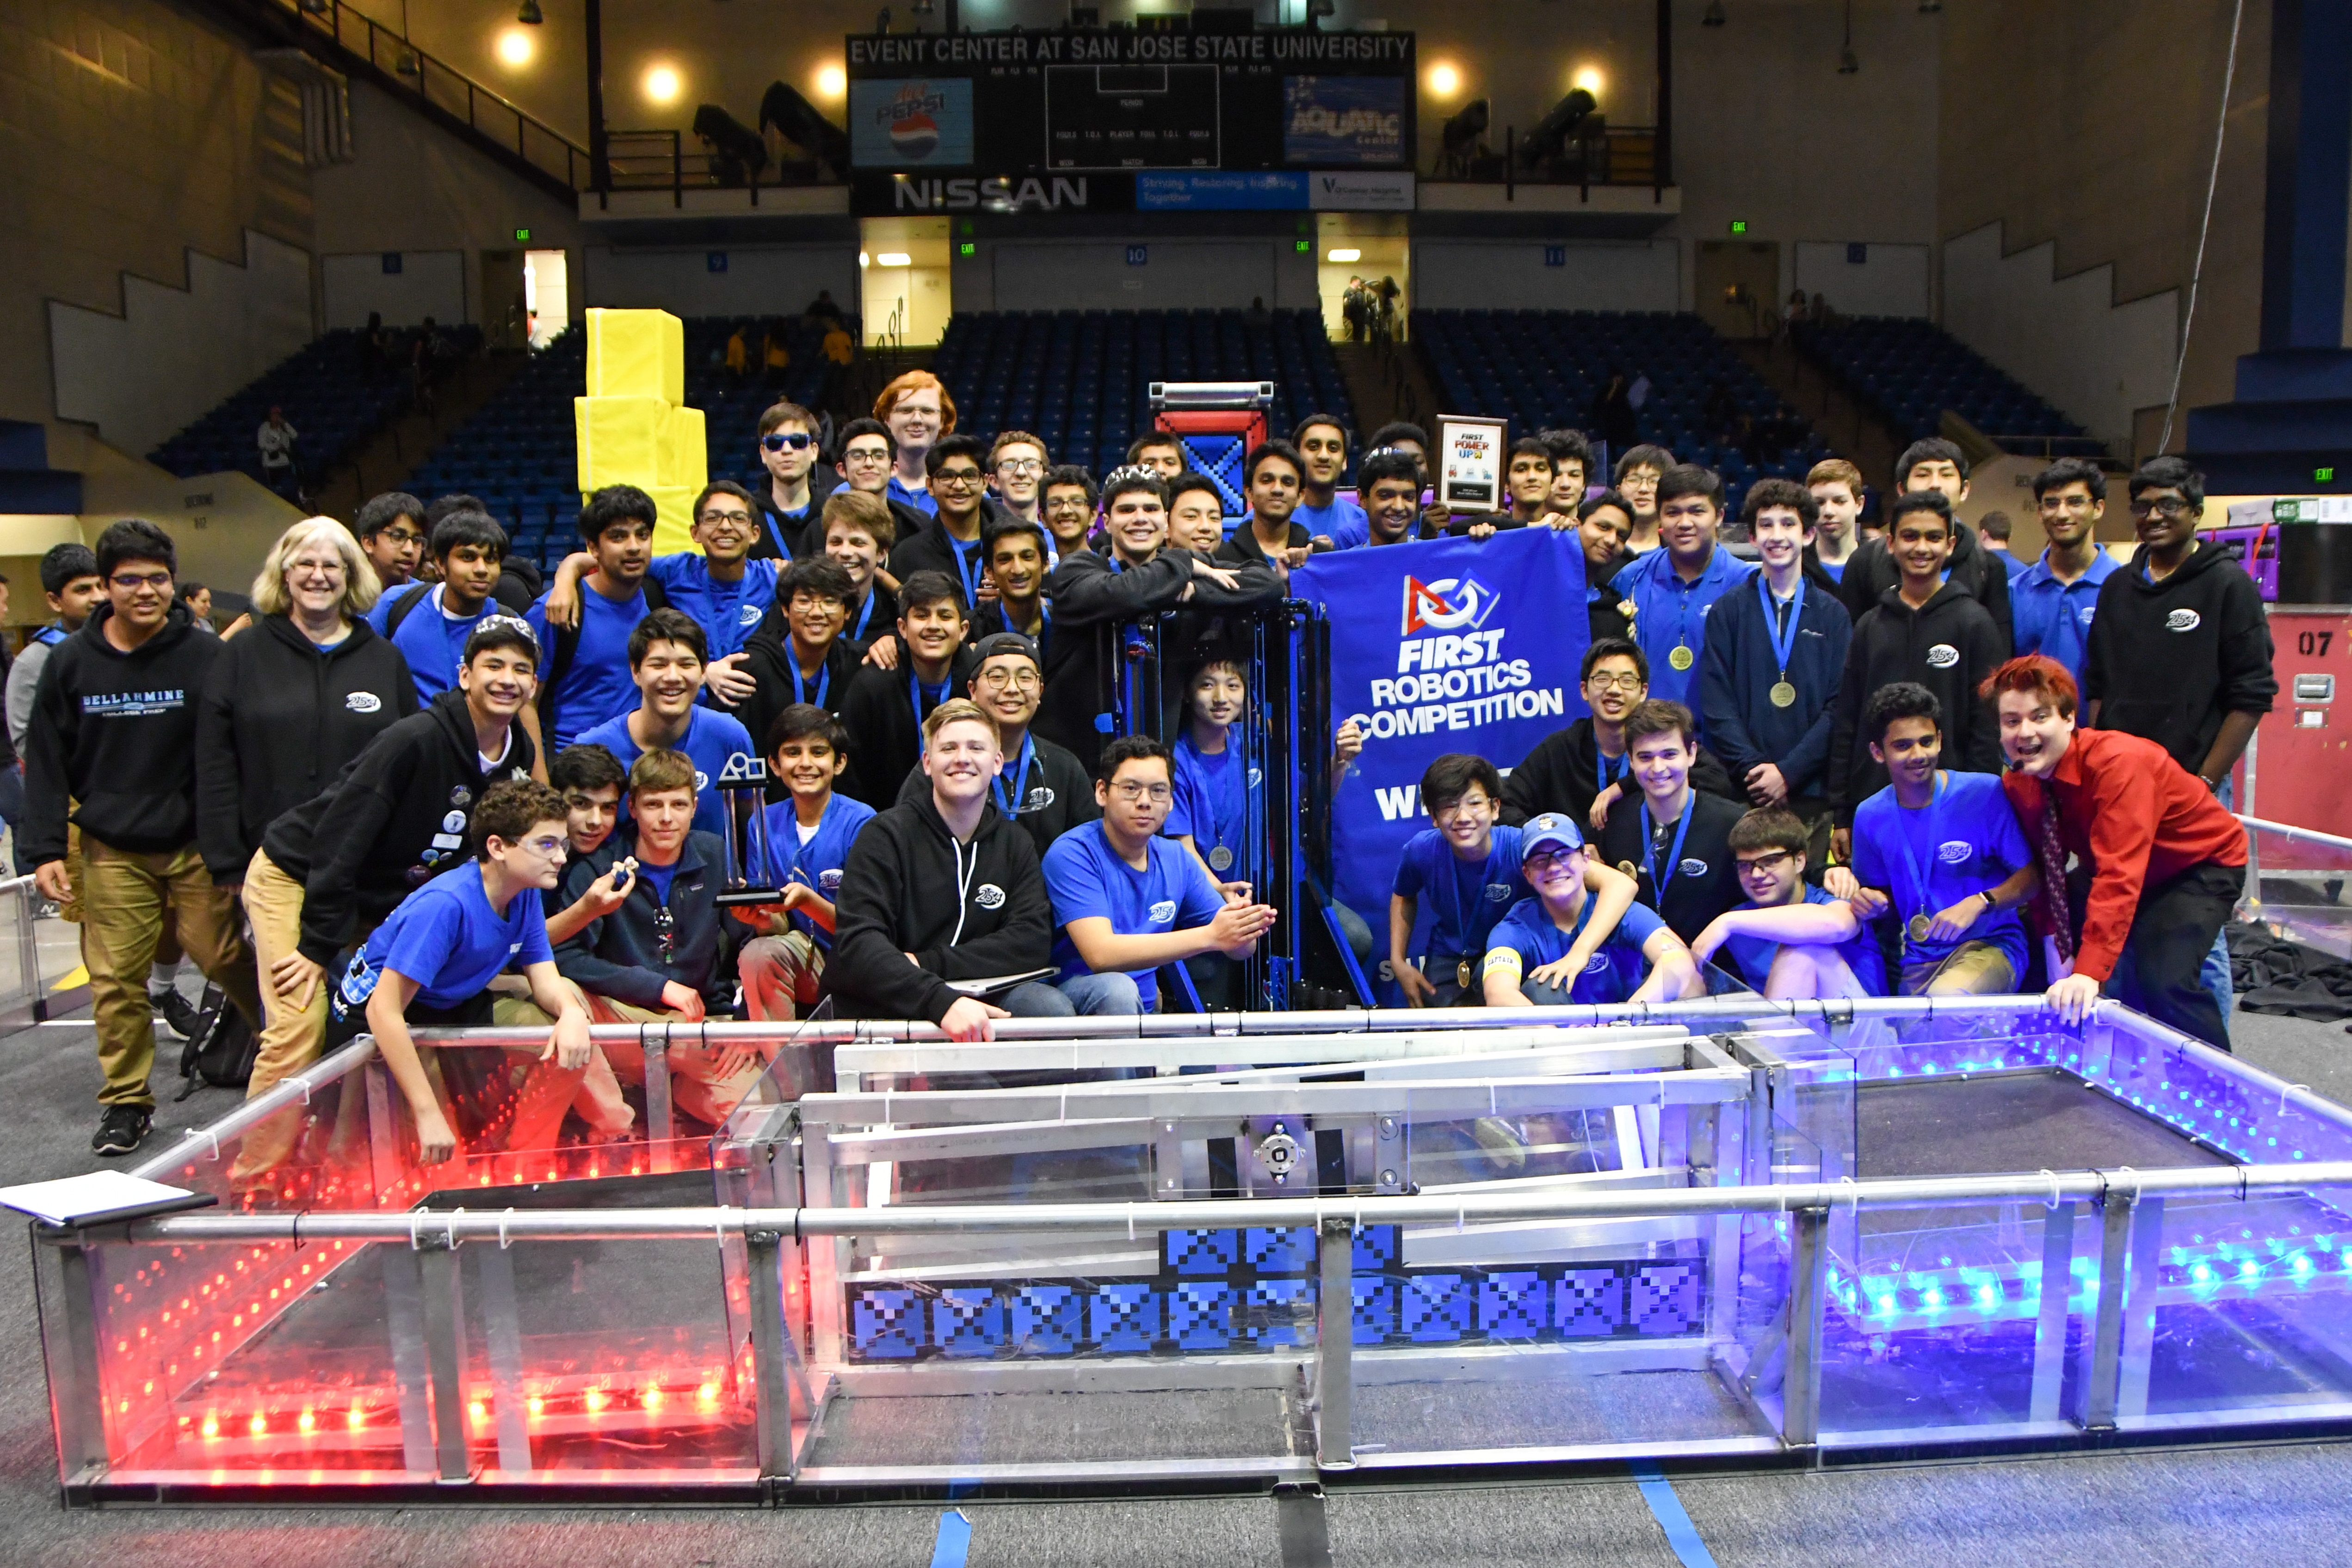
Team 254 and alliance partners Team 1323 and our programming robot 9254 in position before an elims match

Event Summary and Highlights

General Summary

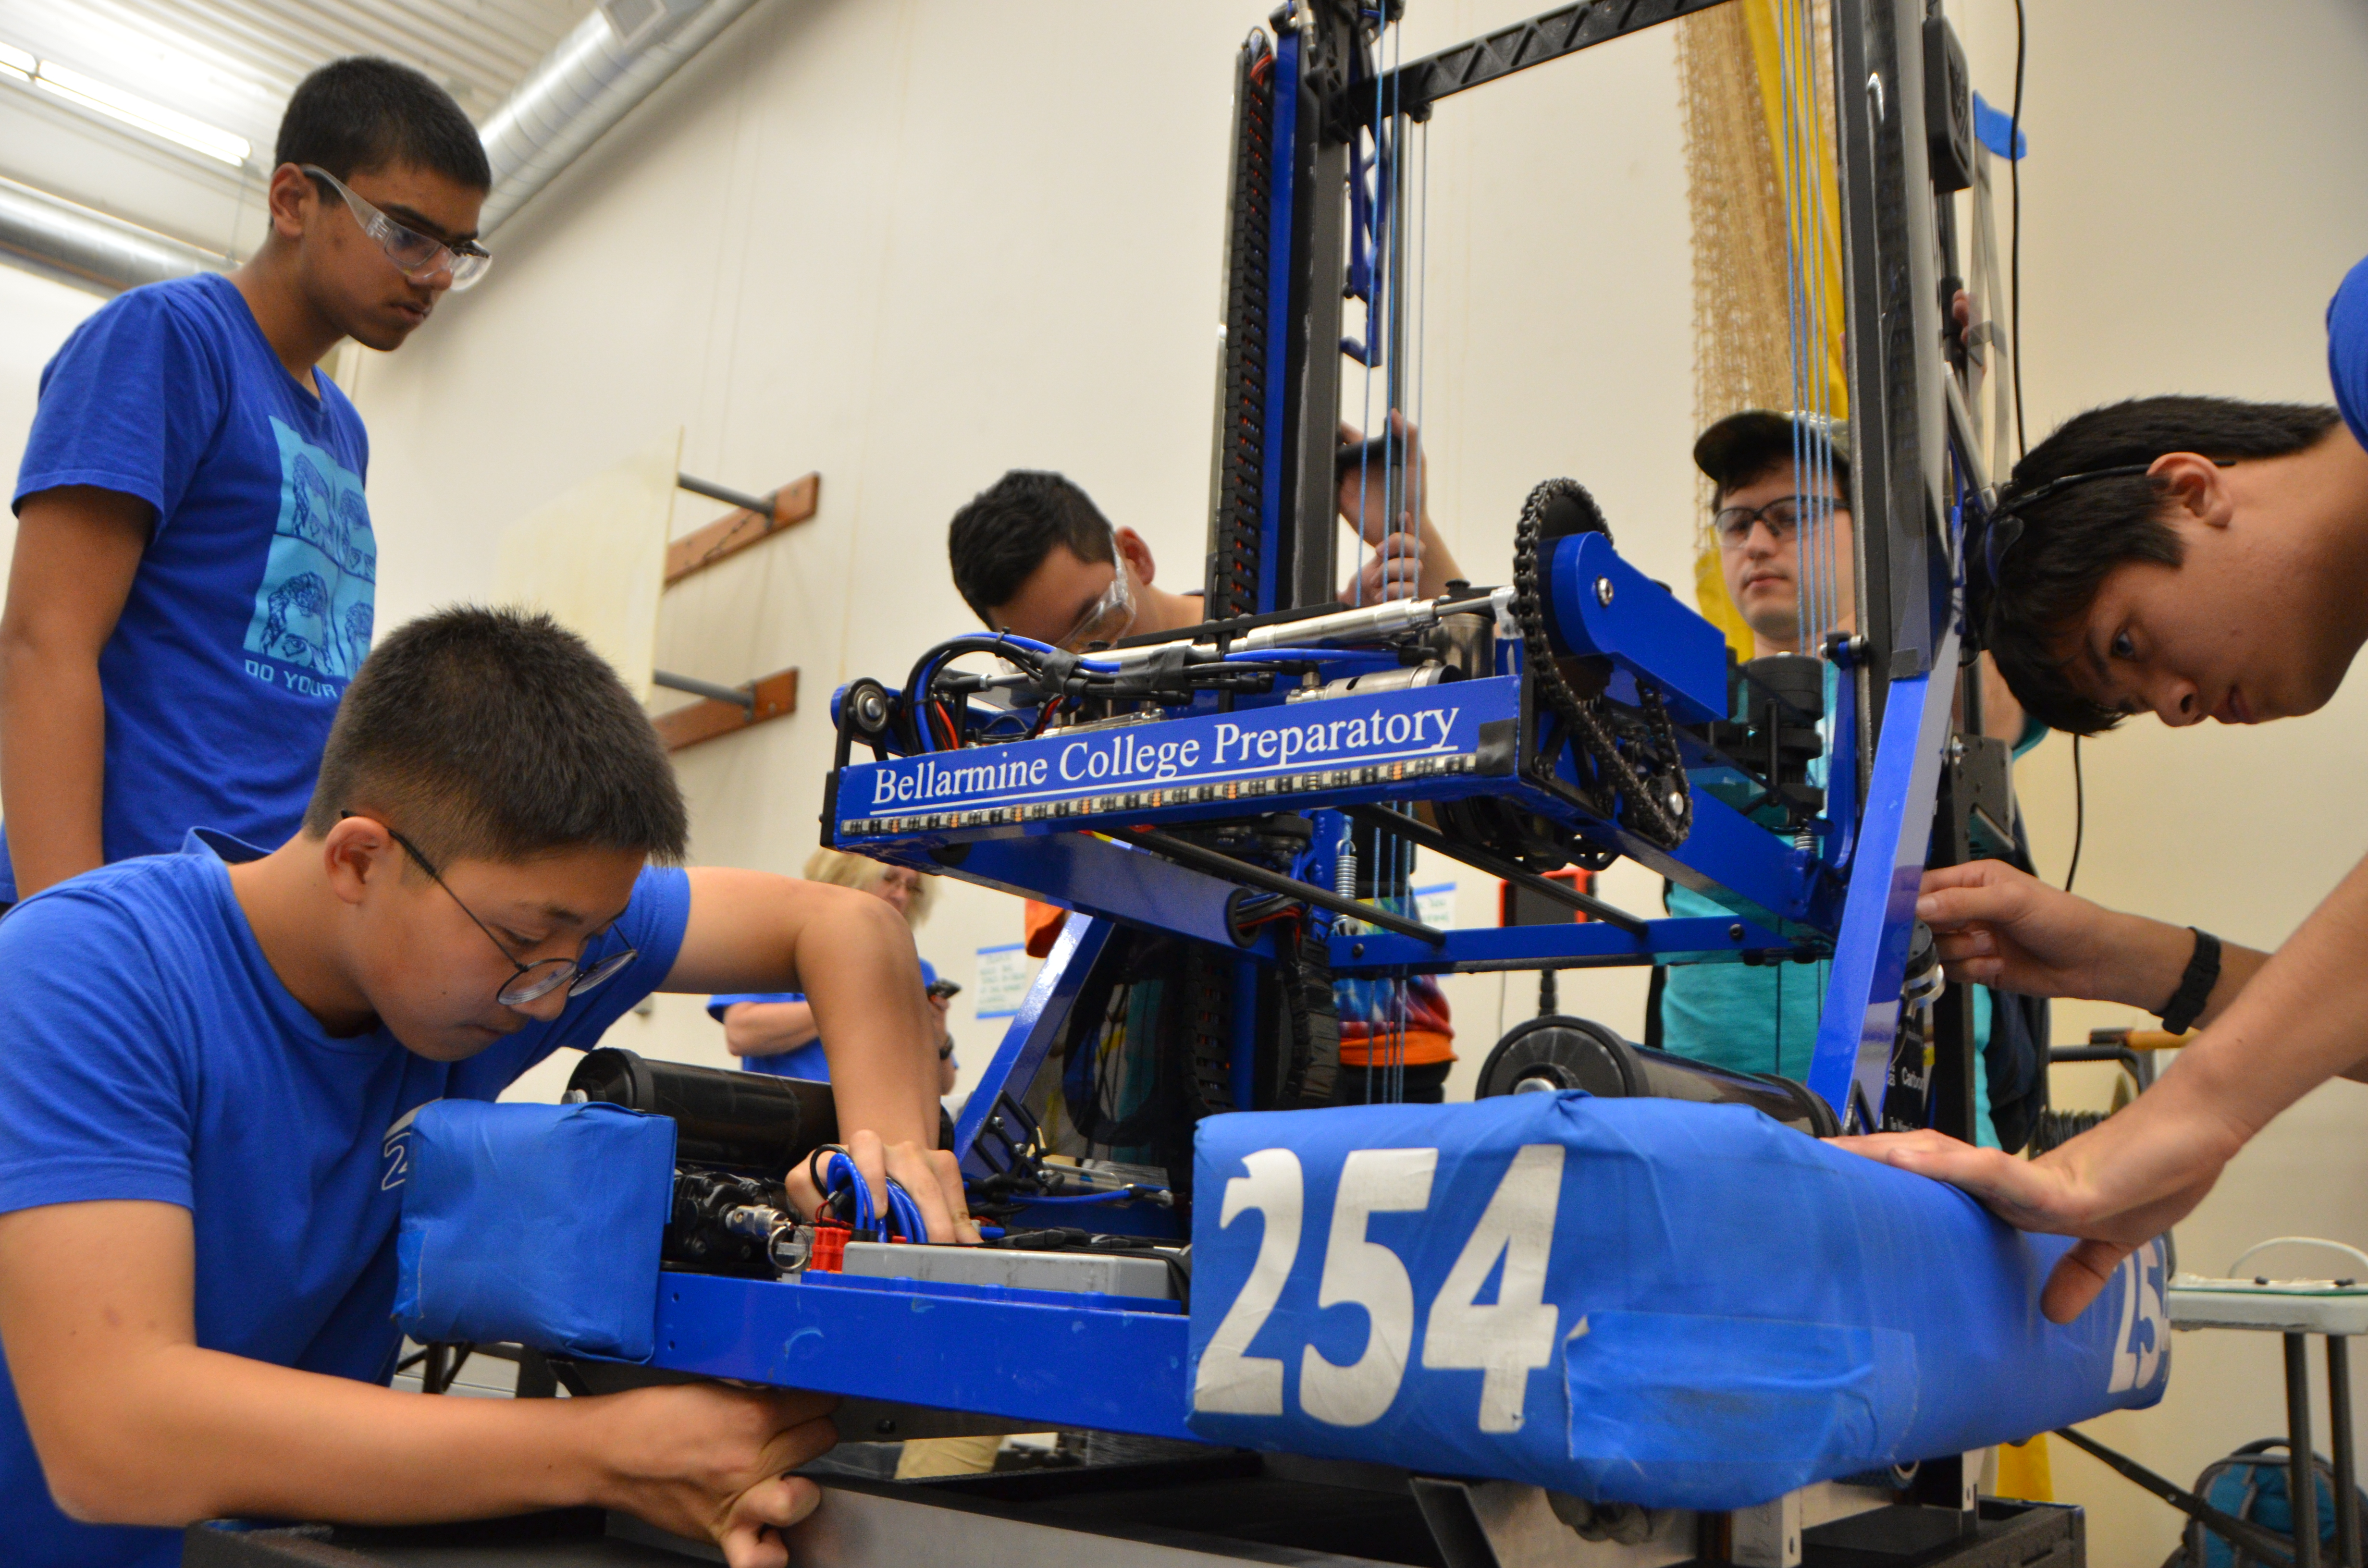
Overall, Madtown Throwdown was a great event for our team. Lockdown, our competition robot, went undefeated 15-0. Our programming robot, was run by an all-freshman pit crew and drive team to ensure that our new members gain a valuable experience before the 2019 FRC Season. The programming robot had a great qualifications match record and was lucky to join Lockdown in an alliance at the tournament. We also had a swerve robot, which we worked on all summer, with a 3-person pit crew, which finished 2nd to last place in the tournament. With rotating pit crews and drive teams, all team members were able to gain some valuable technical experience at the tournament.
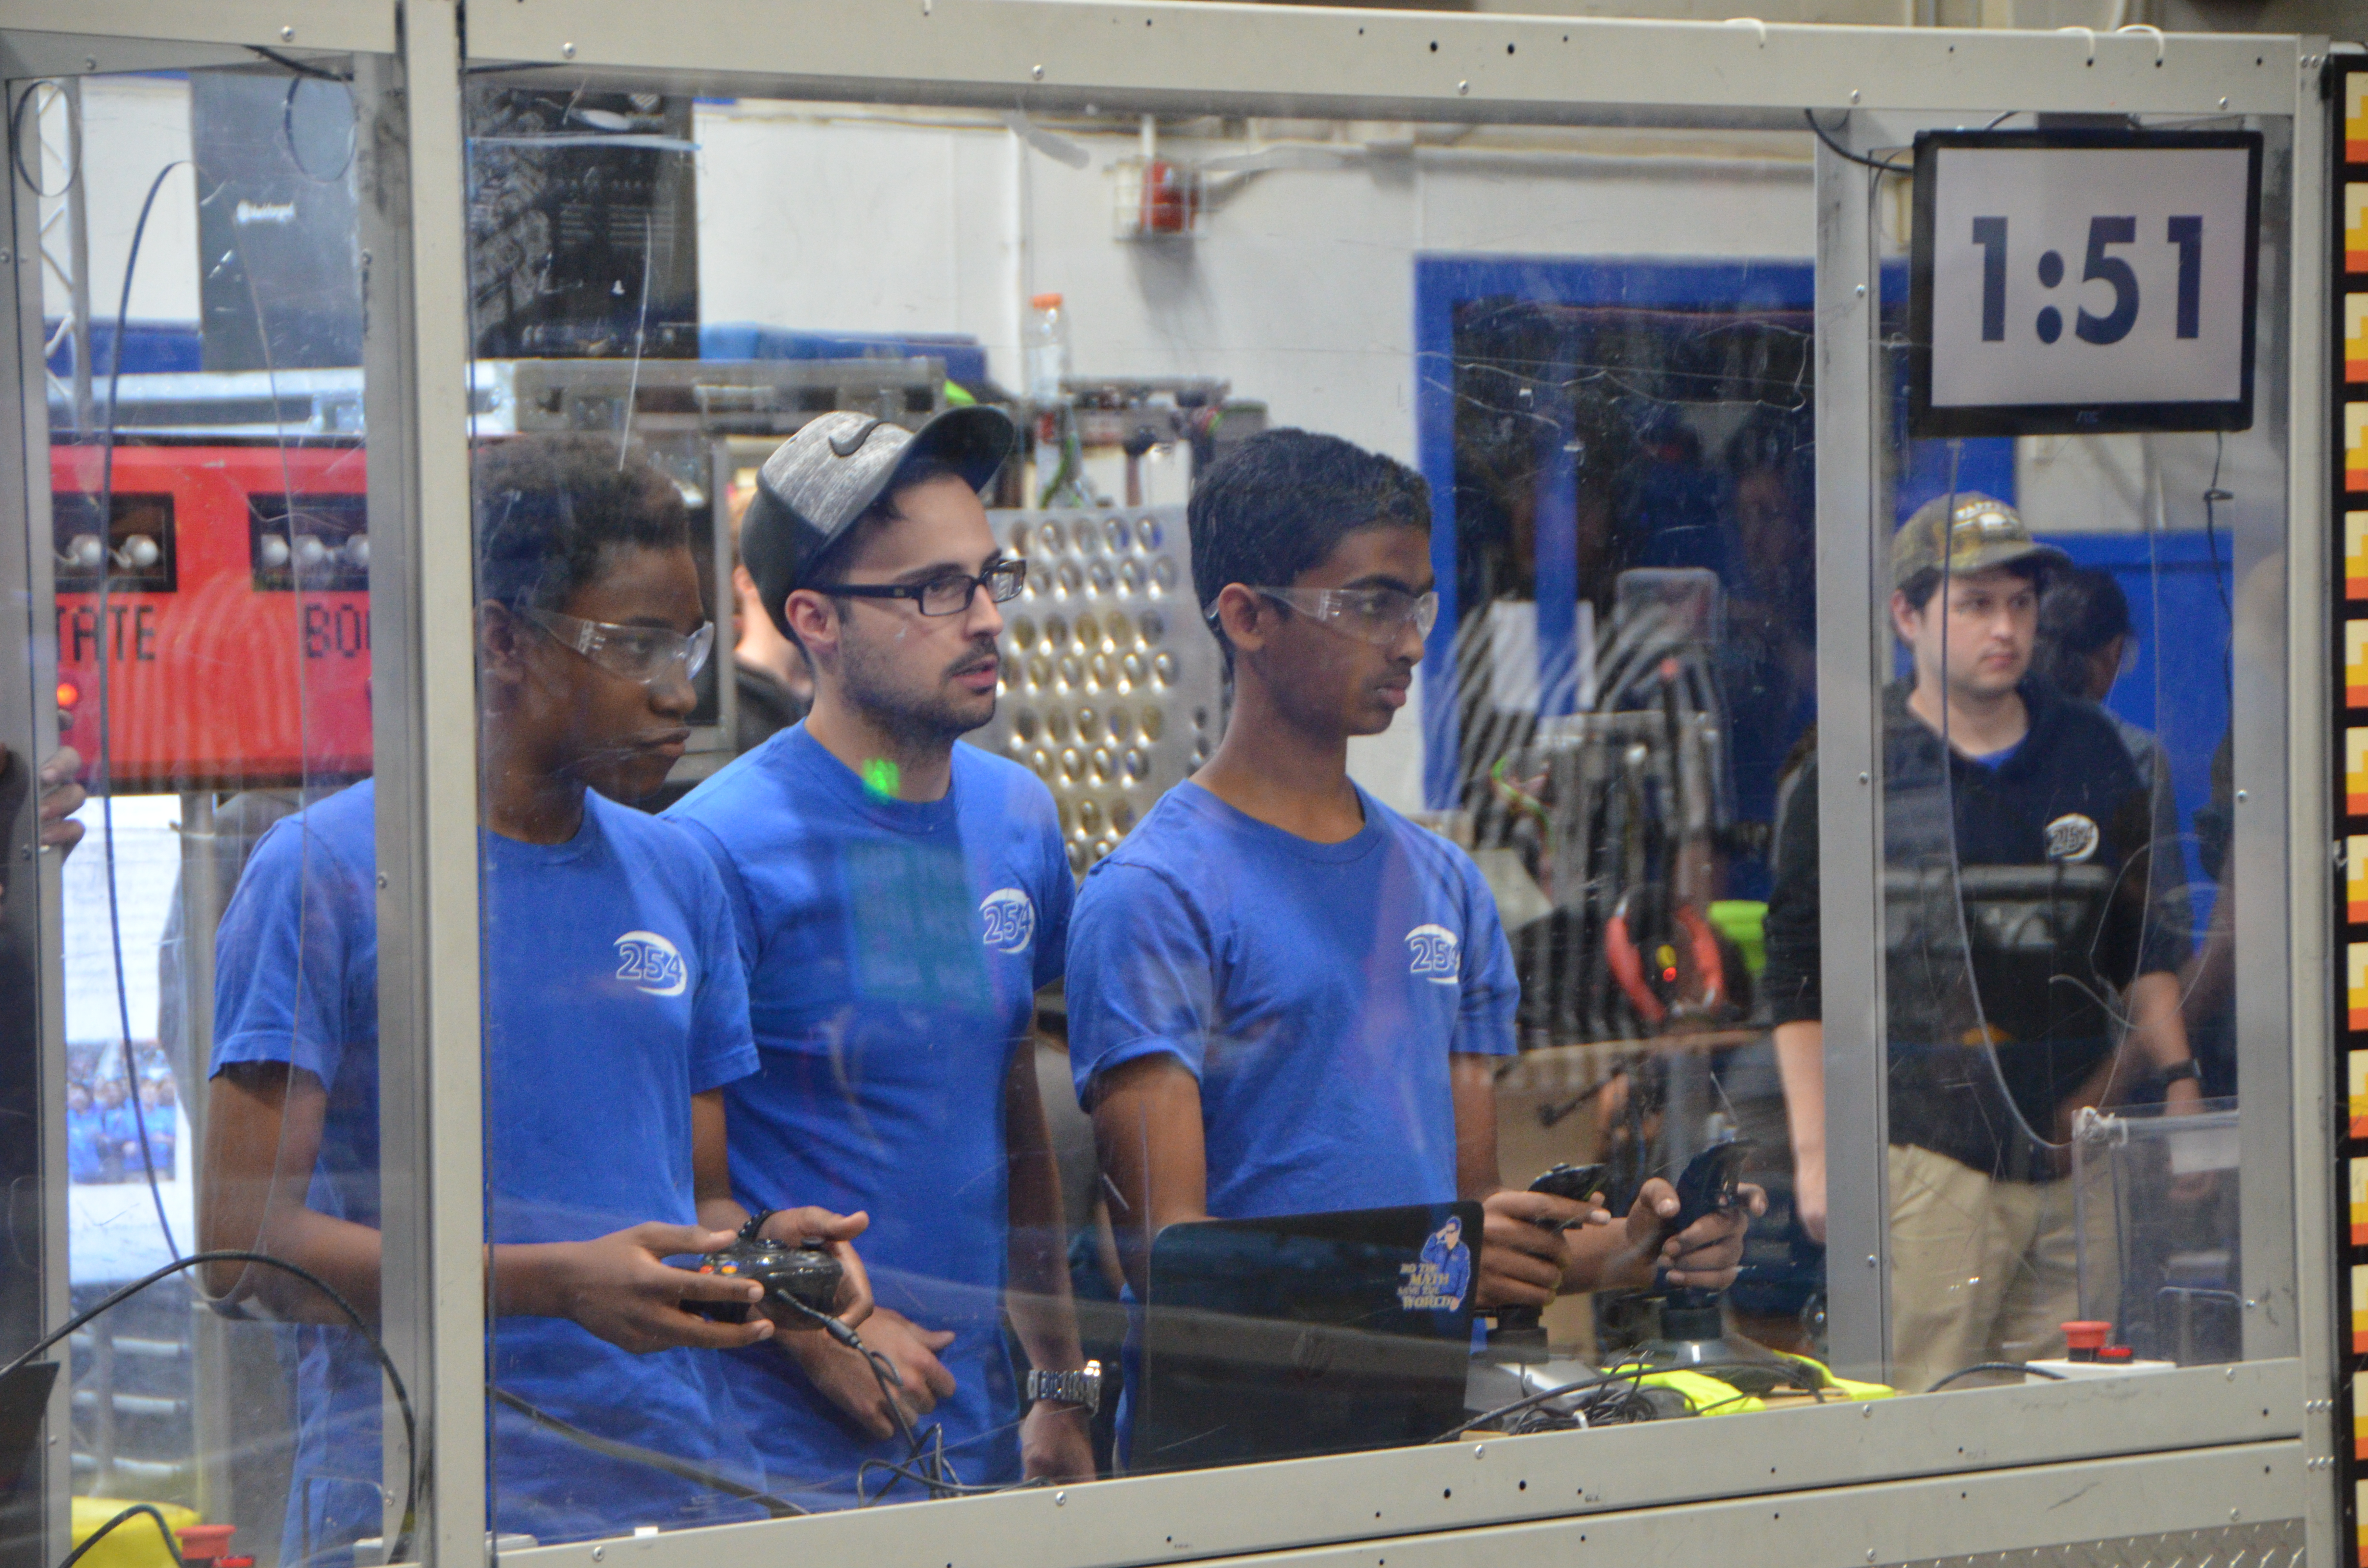
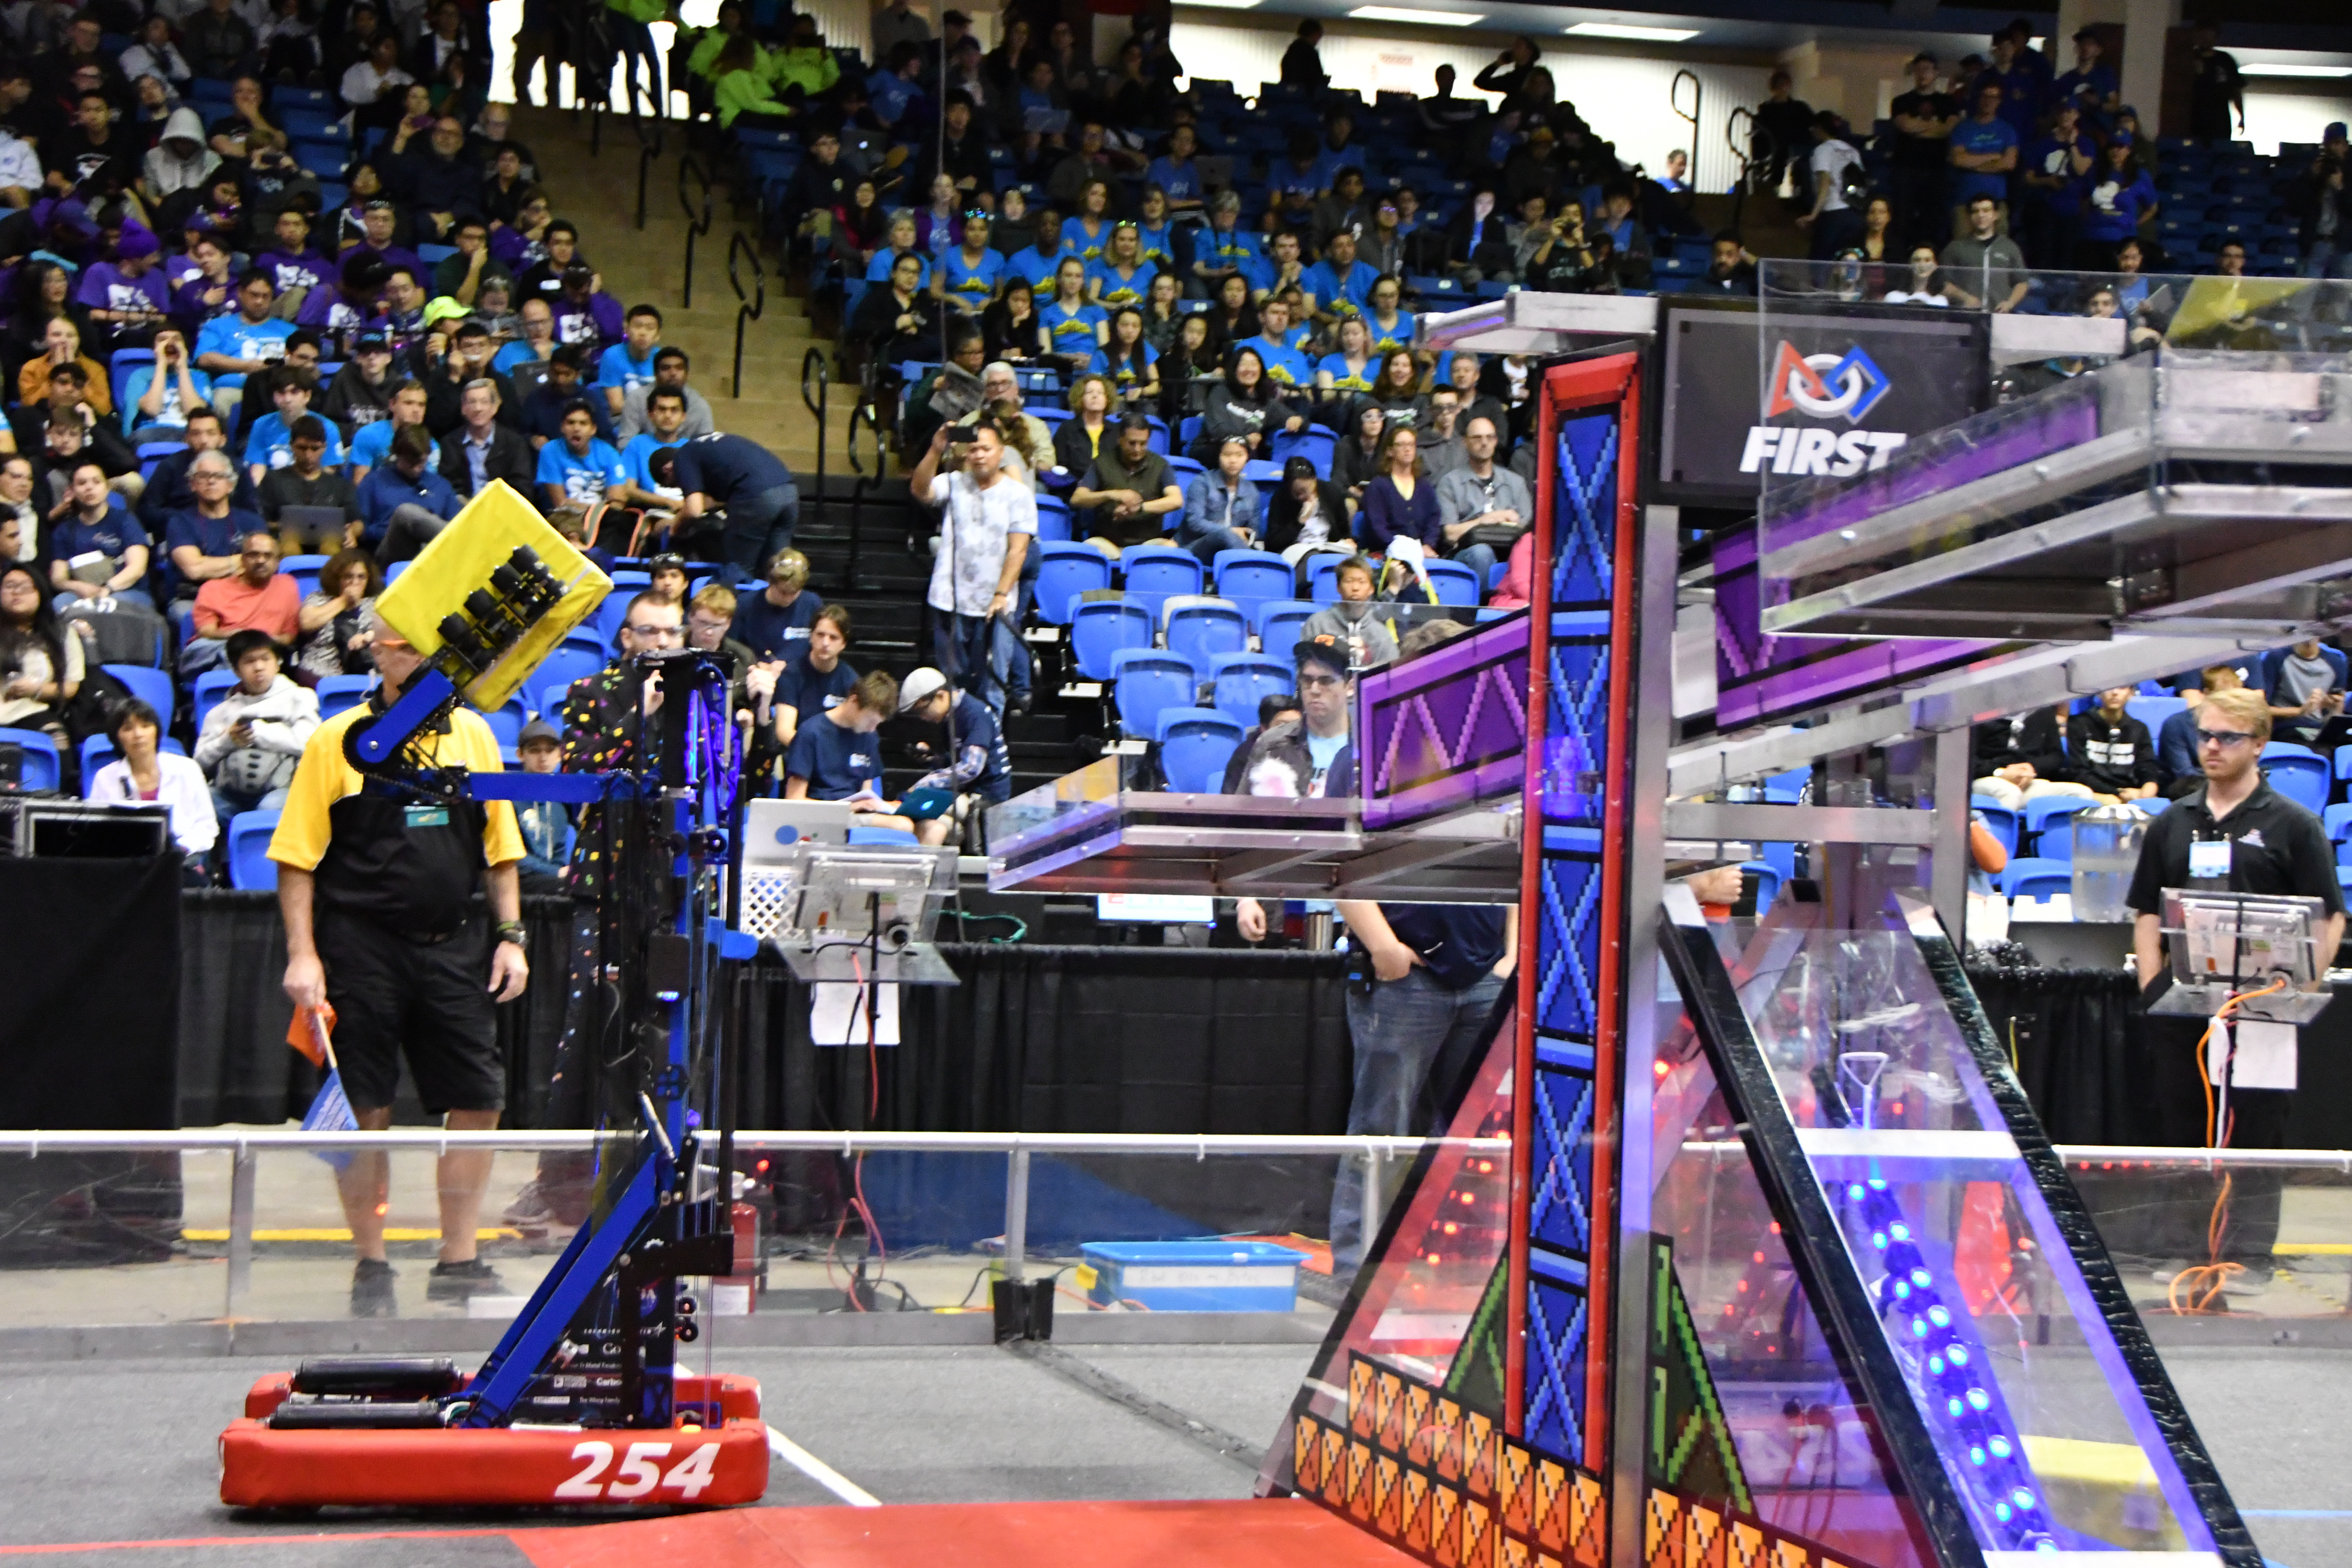
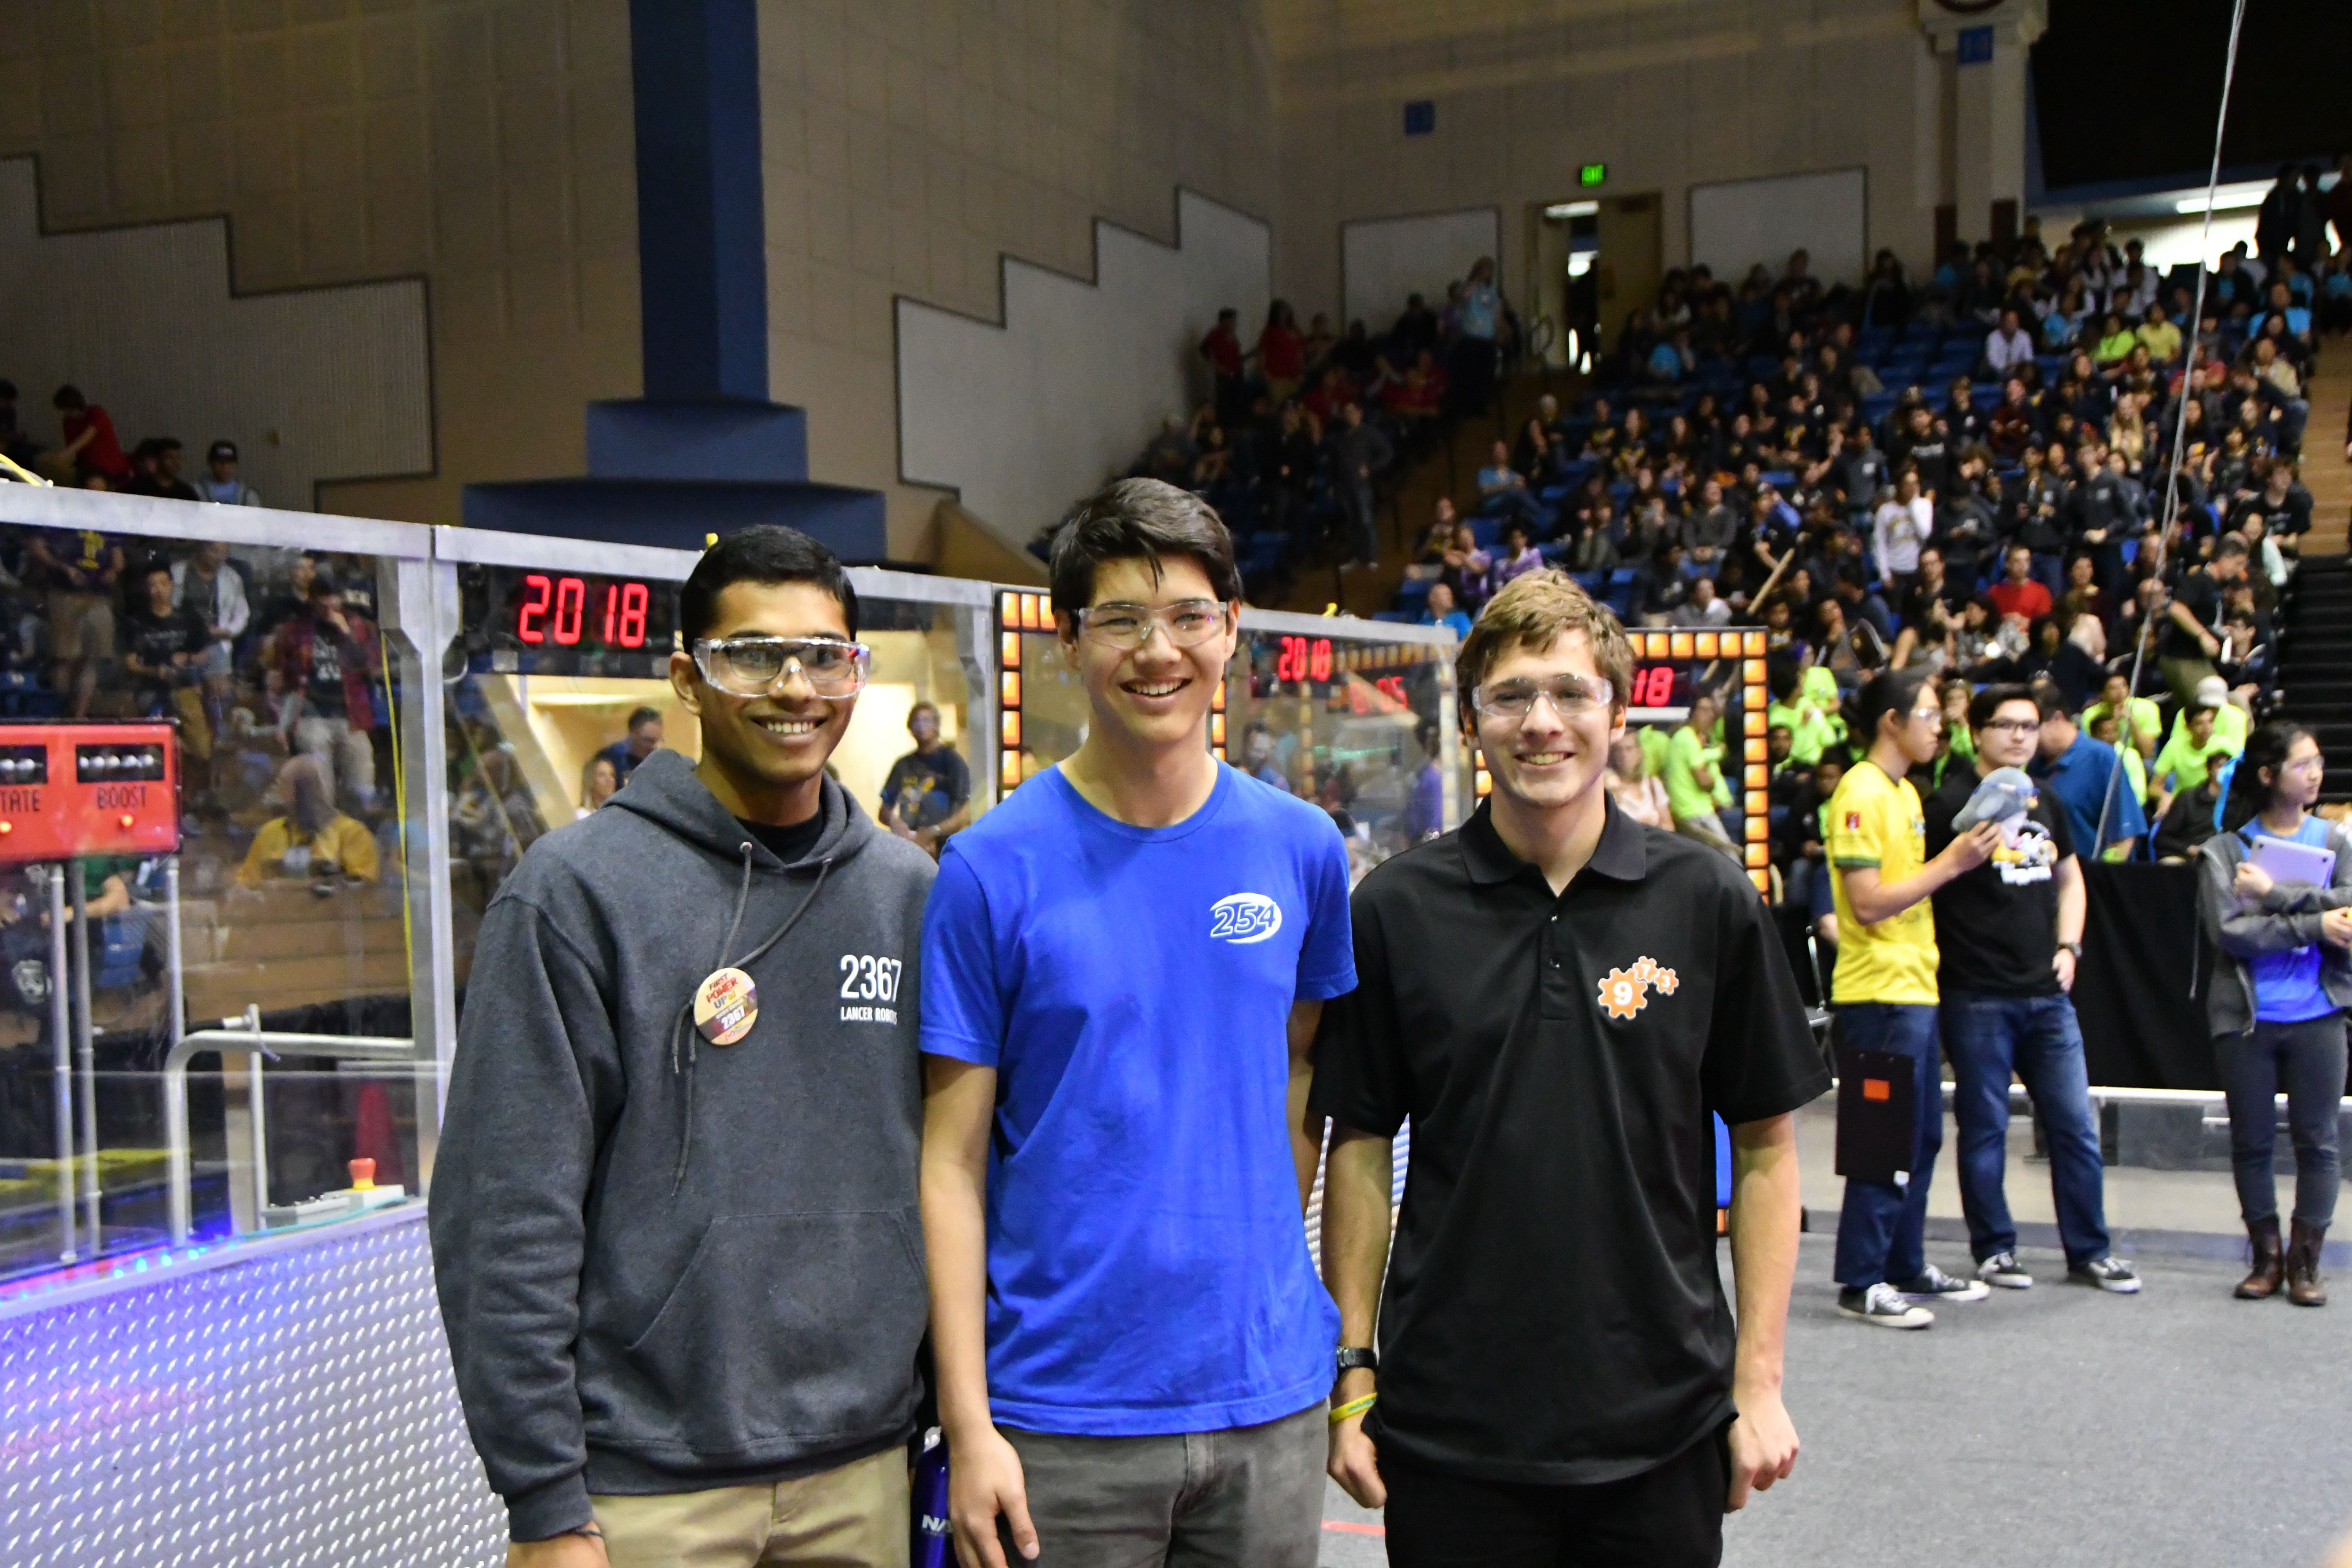
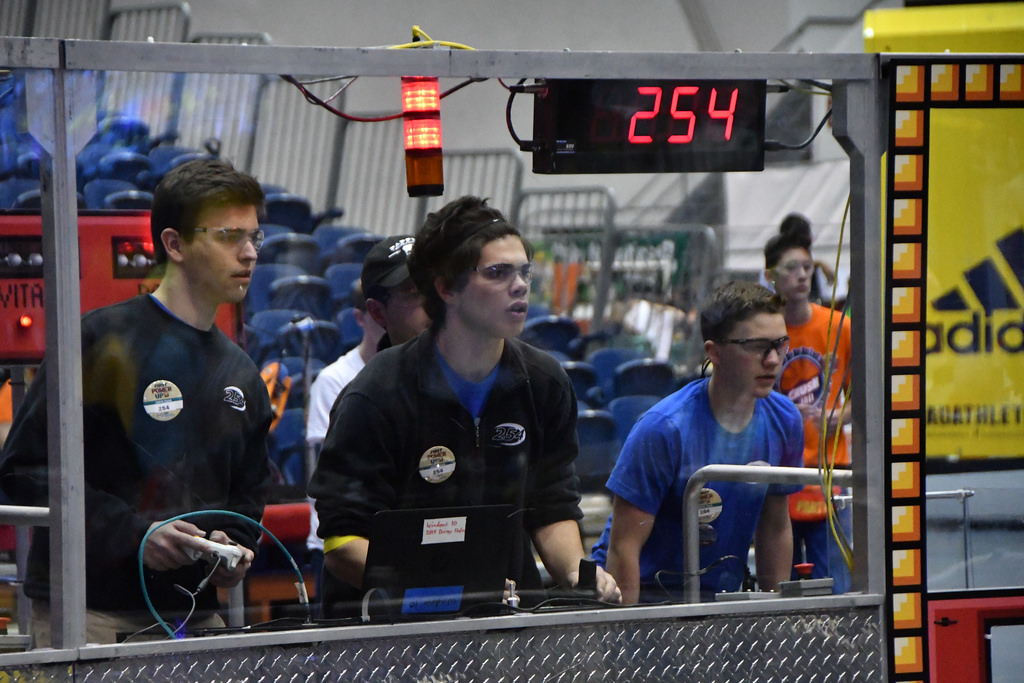
Programming Robot Drive Team Members, Abhinav Nallapa and Dylan Shumba, are seen in action

Robot Performance

Competition Robot Strategy

During qualification matches, we aimed to earn all 4 ranking points. In order to to reach this goal, we had to run our switch autonomous program. We also fought to achieve scale dominance as early as possible during the match to allow for time to shore up our own switch/exchange, attack the opposing alliance’s switch, and hang at the end of the match. We generally went for the scale first and peeled off to either our own switch or the opposing alliance’s switch whenever needed.
During alliance selection, we partnered with Team 1323 Madtown Robotics, their offseason robot (9323), and our own programming robot (9254). During the elimination matches, we worked with Team 1323 and ran our dual autonomous program to gain dominance over the scale, while ensuring ownership of our switch as well. Lockdown and 1323’s competition robot focused on scale ownership, and 1323’s competition robot would fall back for defense whenever necessary. When we had a headstart on the scale, Lockdown would attack the opponent switch, as seen during quarterfinals and semifinals. 1323’s competition robot hung at the end of the match, but we did not pursue a buddy climb since the other two robots were unable to climb onto our forks.

Programming Robot Strategy

During the qualification matches, our programming robot played a supportive role and generally tried to get a few cubes scored in its switch, scale, and exchange. However, during the elimination matches, our programming robot functioned as a switch/exchange robot to ensure that we had enough cubes to use the levitate powerup. We also chose to defend robots from the opposing alliance when given the opportunity.

Summer Project Robot Strategy

During the qualifications matches, our summer project robot functioned as a switch/exchange robot to defend our own switch and make sure there were cubes in our vault. Sometimes, we would also attack our opponent’s switch. Unfortunately, our swerve robot was not chosen during the elimination period.
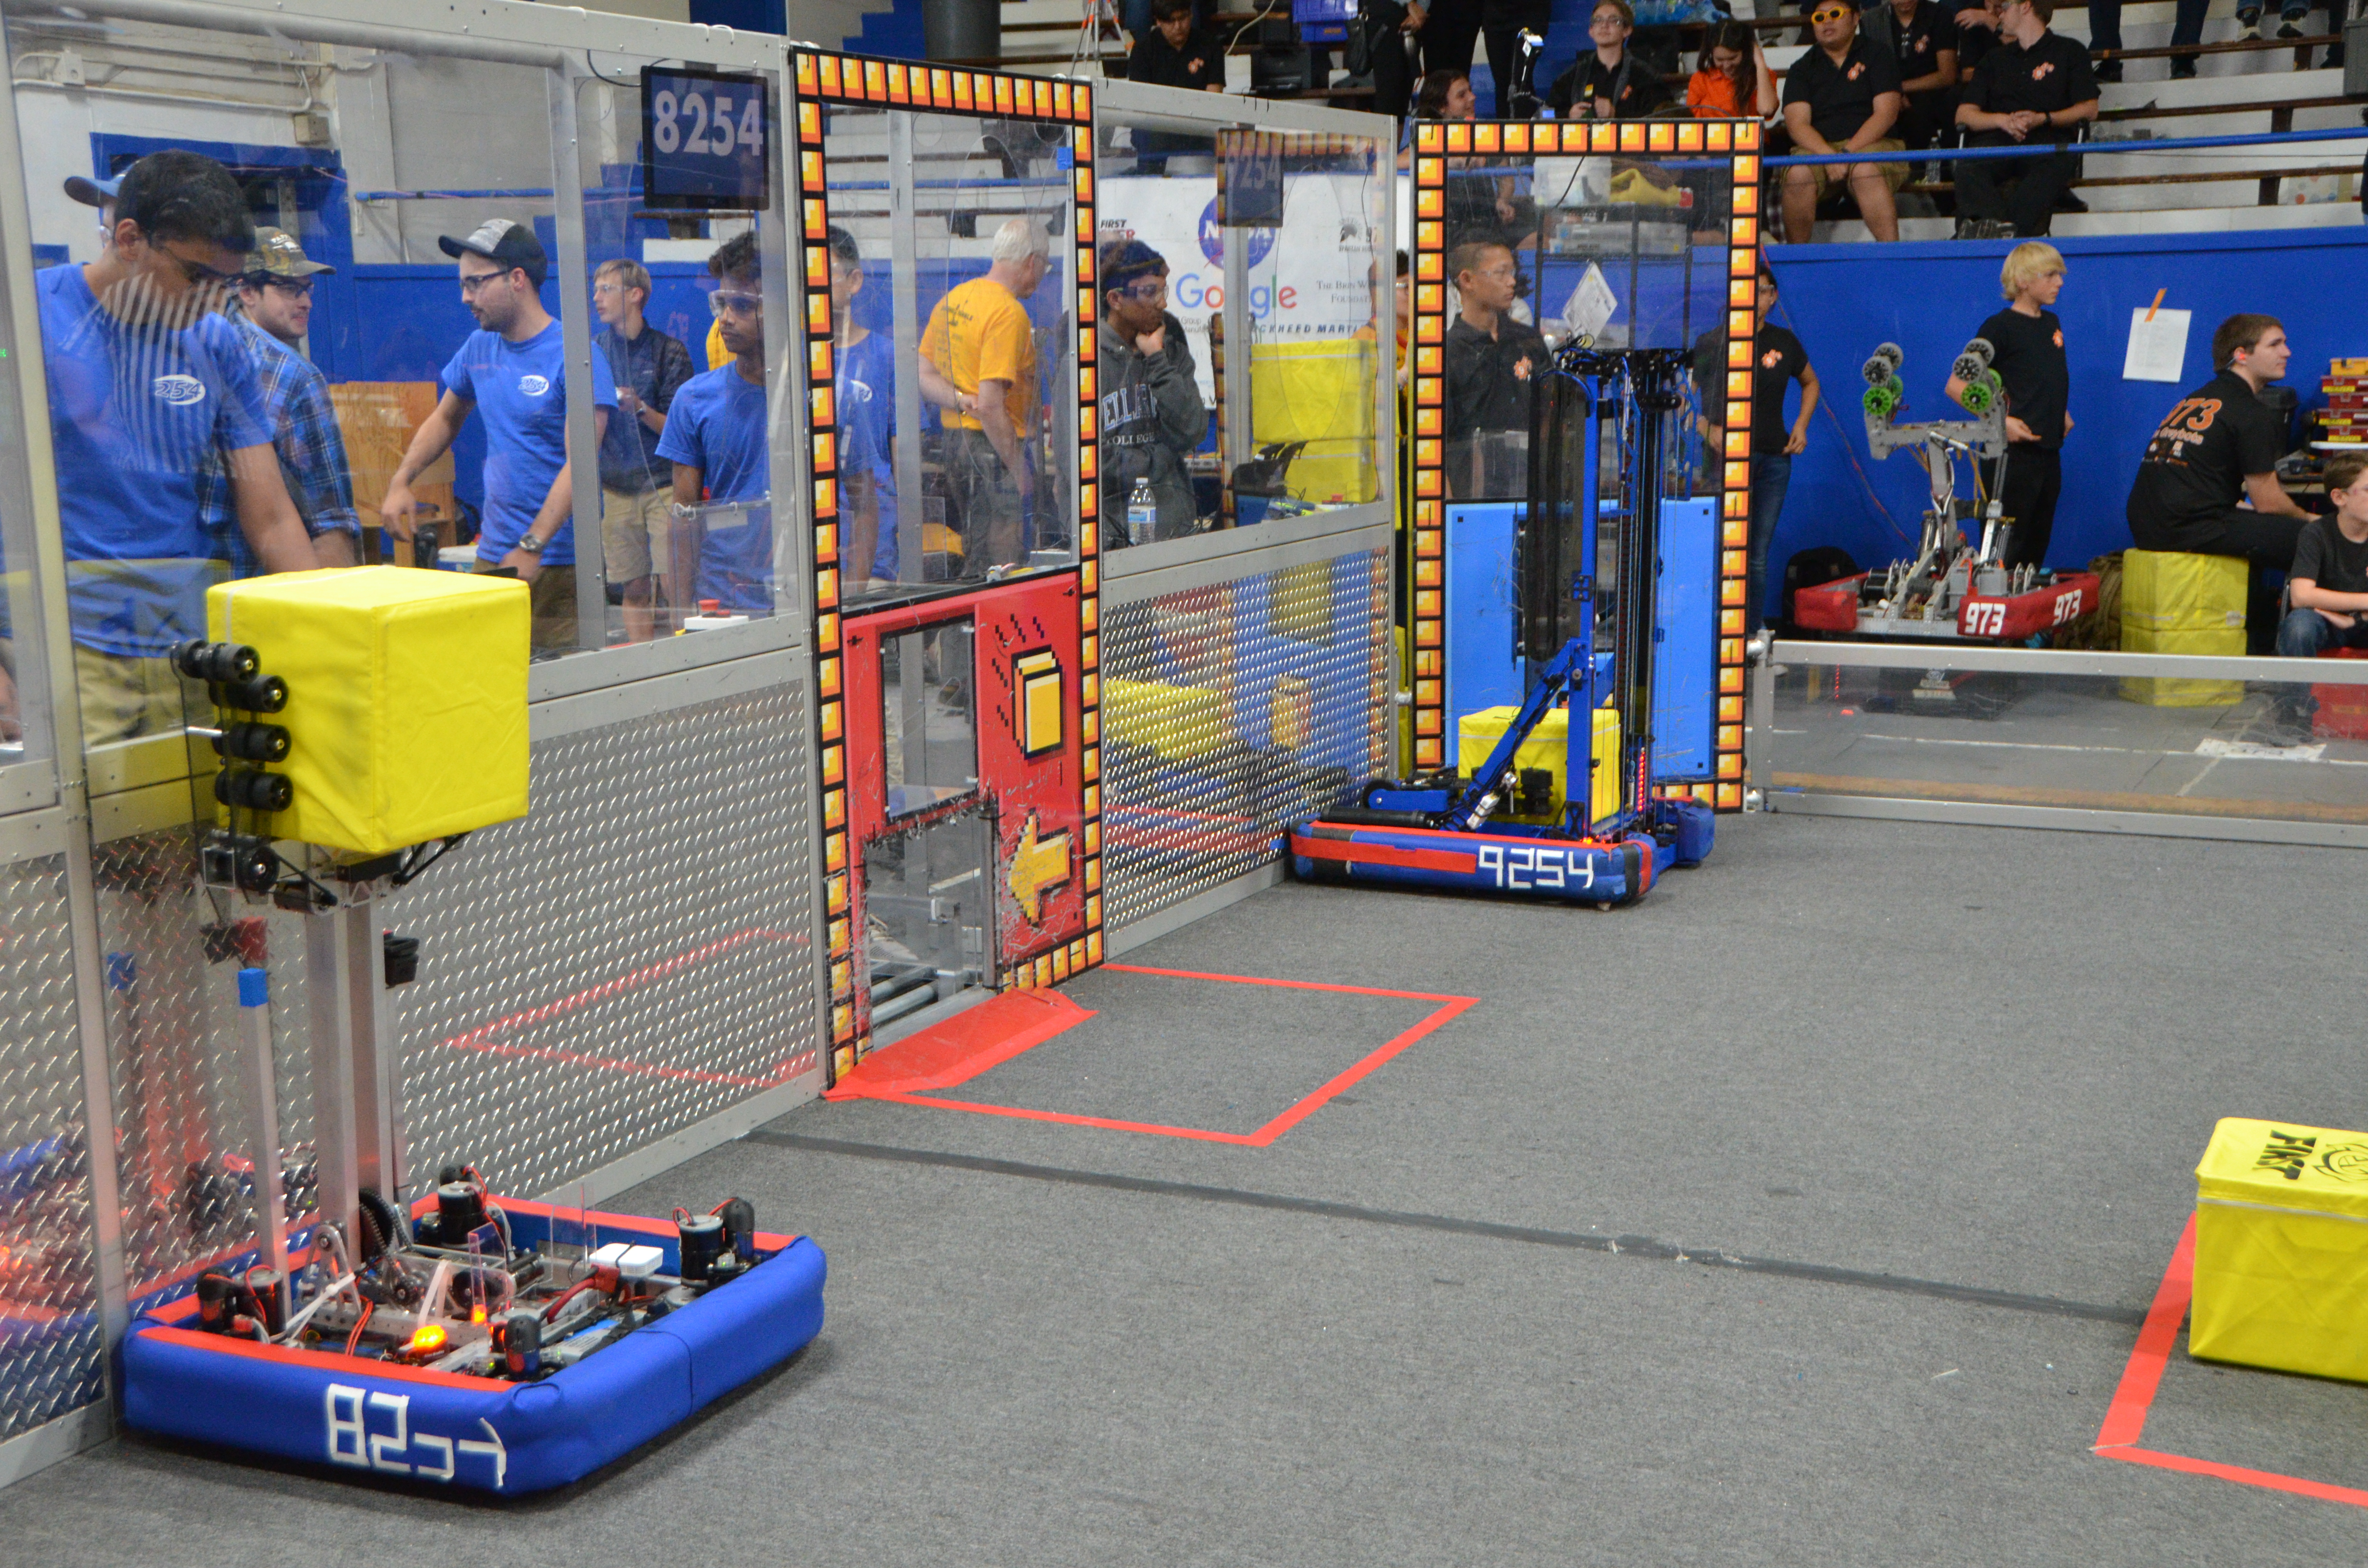
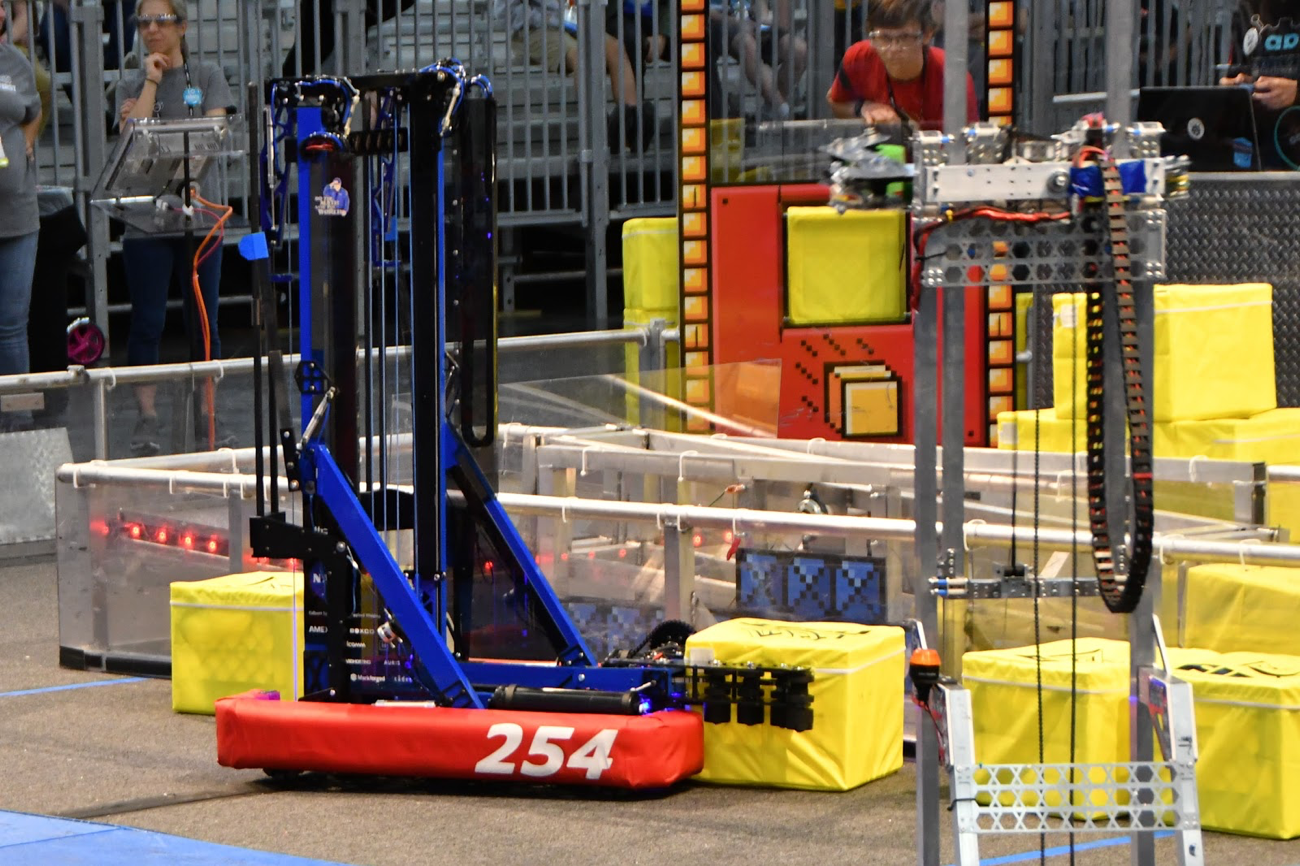
Lockdown and our Summer Project Robot in position before a qualification match

A Special Thanks

Since this was Team 254’s third time attending Madtown Throwdown, we would like to say thank you to Team 1323 (Madtown Robotics) for hosting the tournament and making us feel welcome!
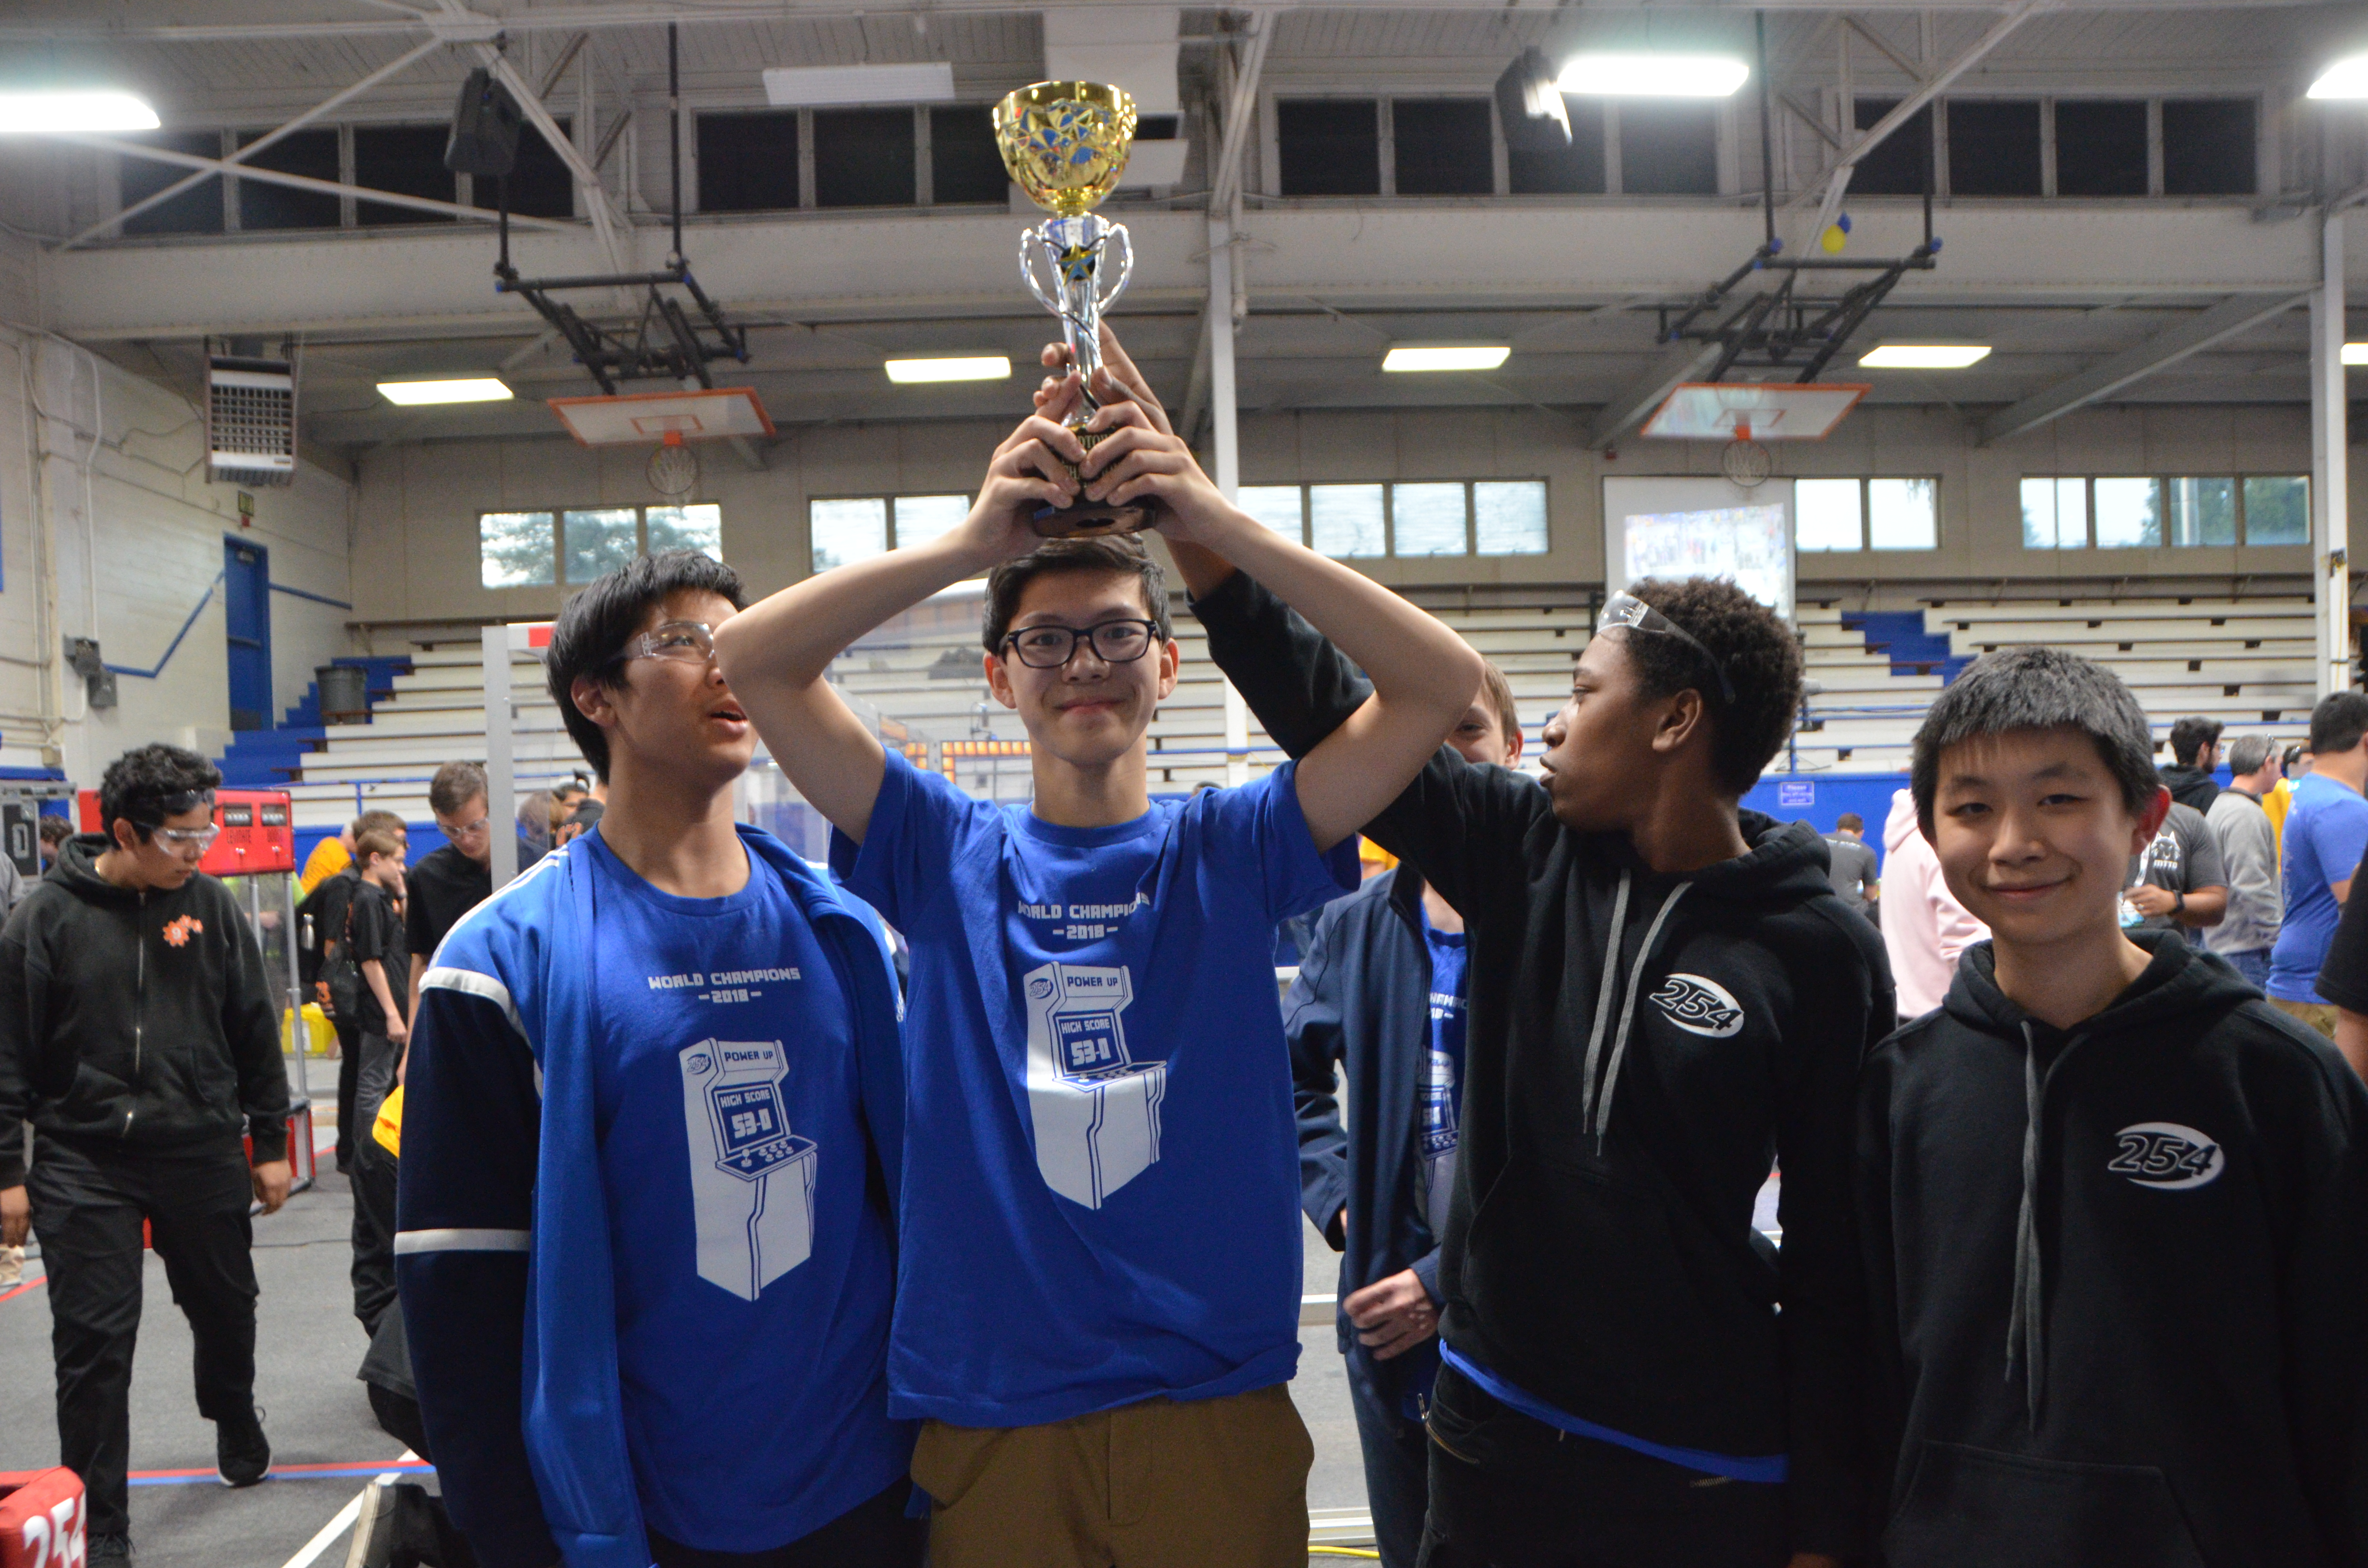
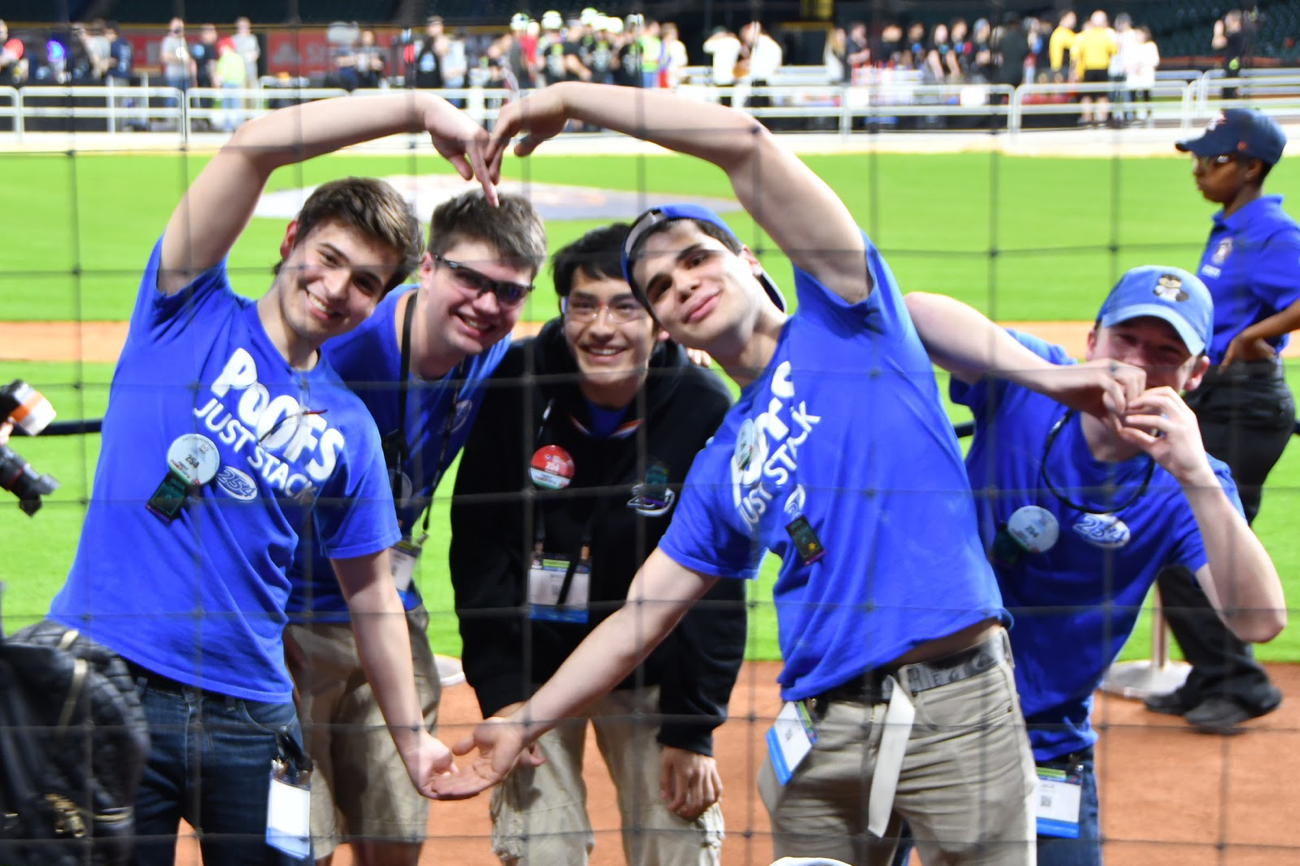
Some new members on Team 254 celebrate the team’s victory
Capital City Classic 2018

2018 FRC Build Season

A Brief Sumary

As part of an eventful weekend, we attended Capital City Classic, an annually hosted offseason tournament hosted by Team 1678 (Citrus Circuits), in Davis, CA. We had a great time jumping back into action with our robot, Lockdown, before the start of the 2019 FRC Season. Alongside, FRC Team 1323 MadTown Robotics, FRC Team 199 Deep Blue, and FRC Team 3859 Wolfpack Robotics, we were able to win the tournament!

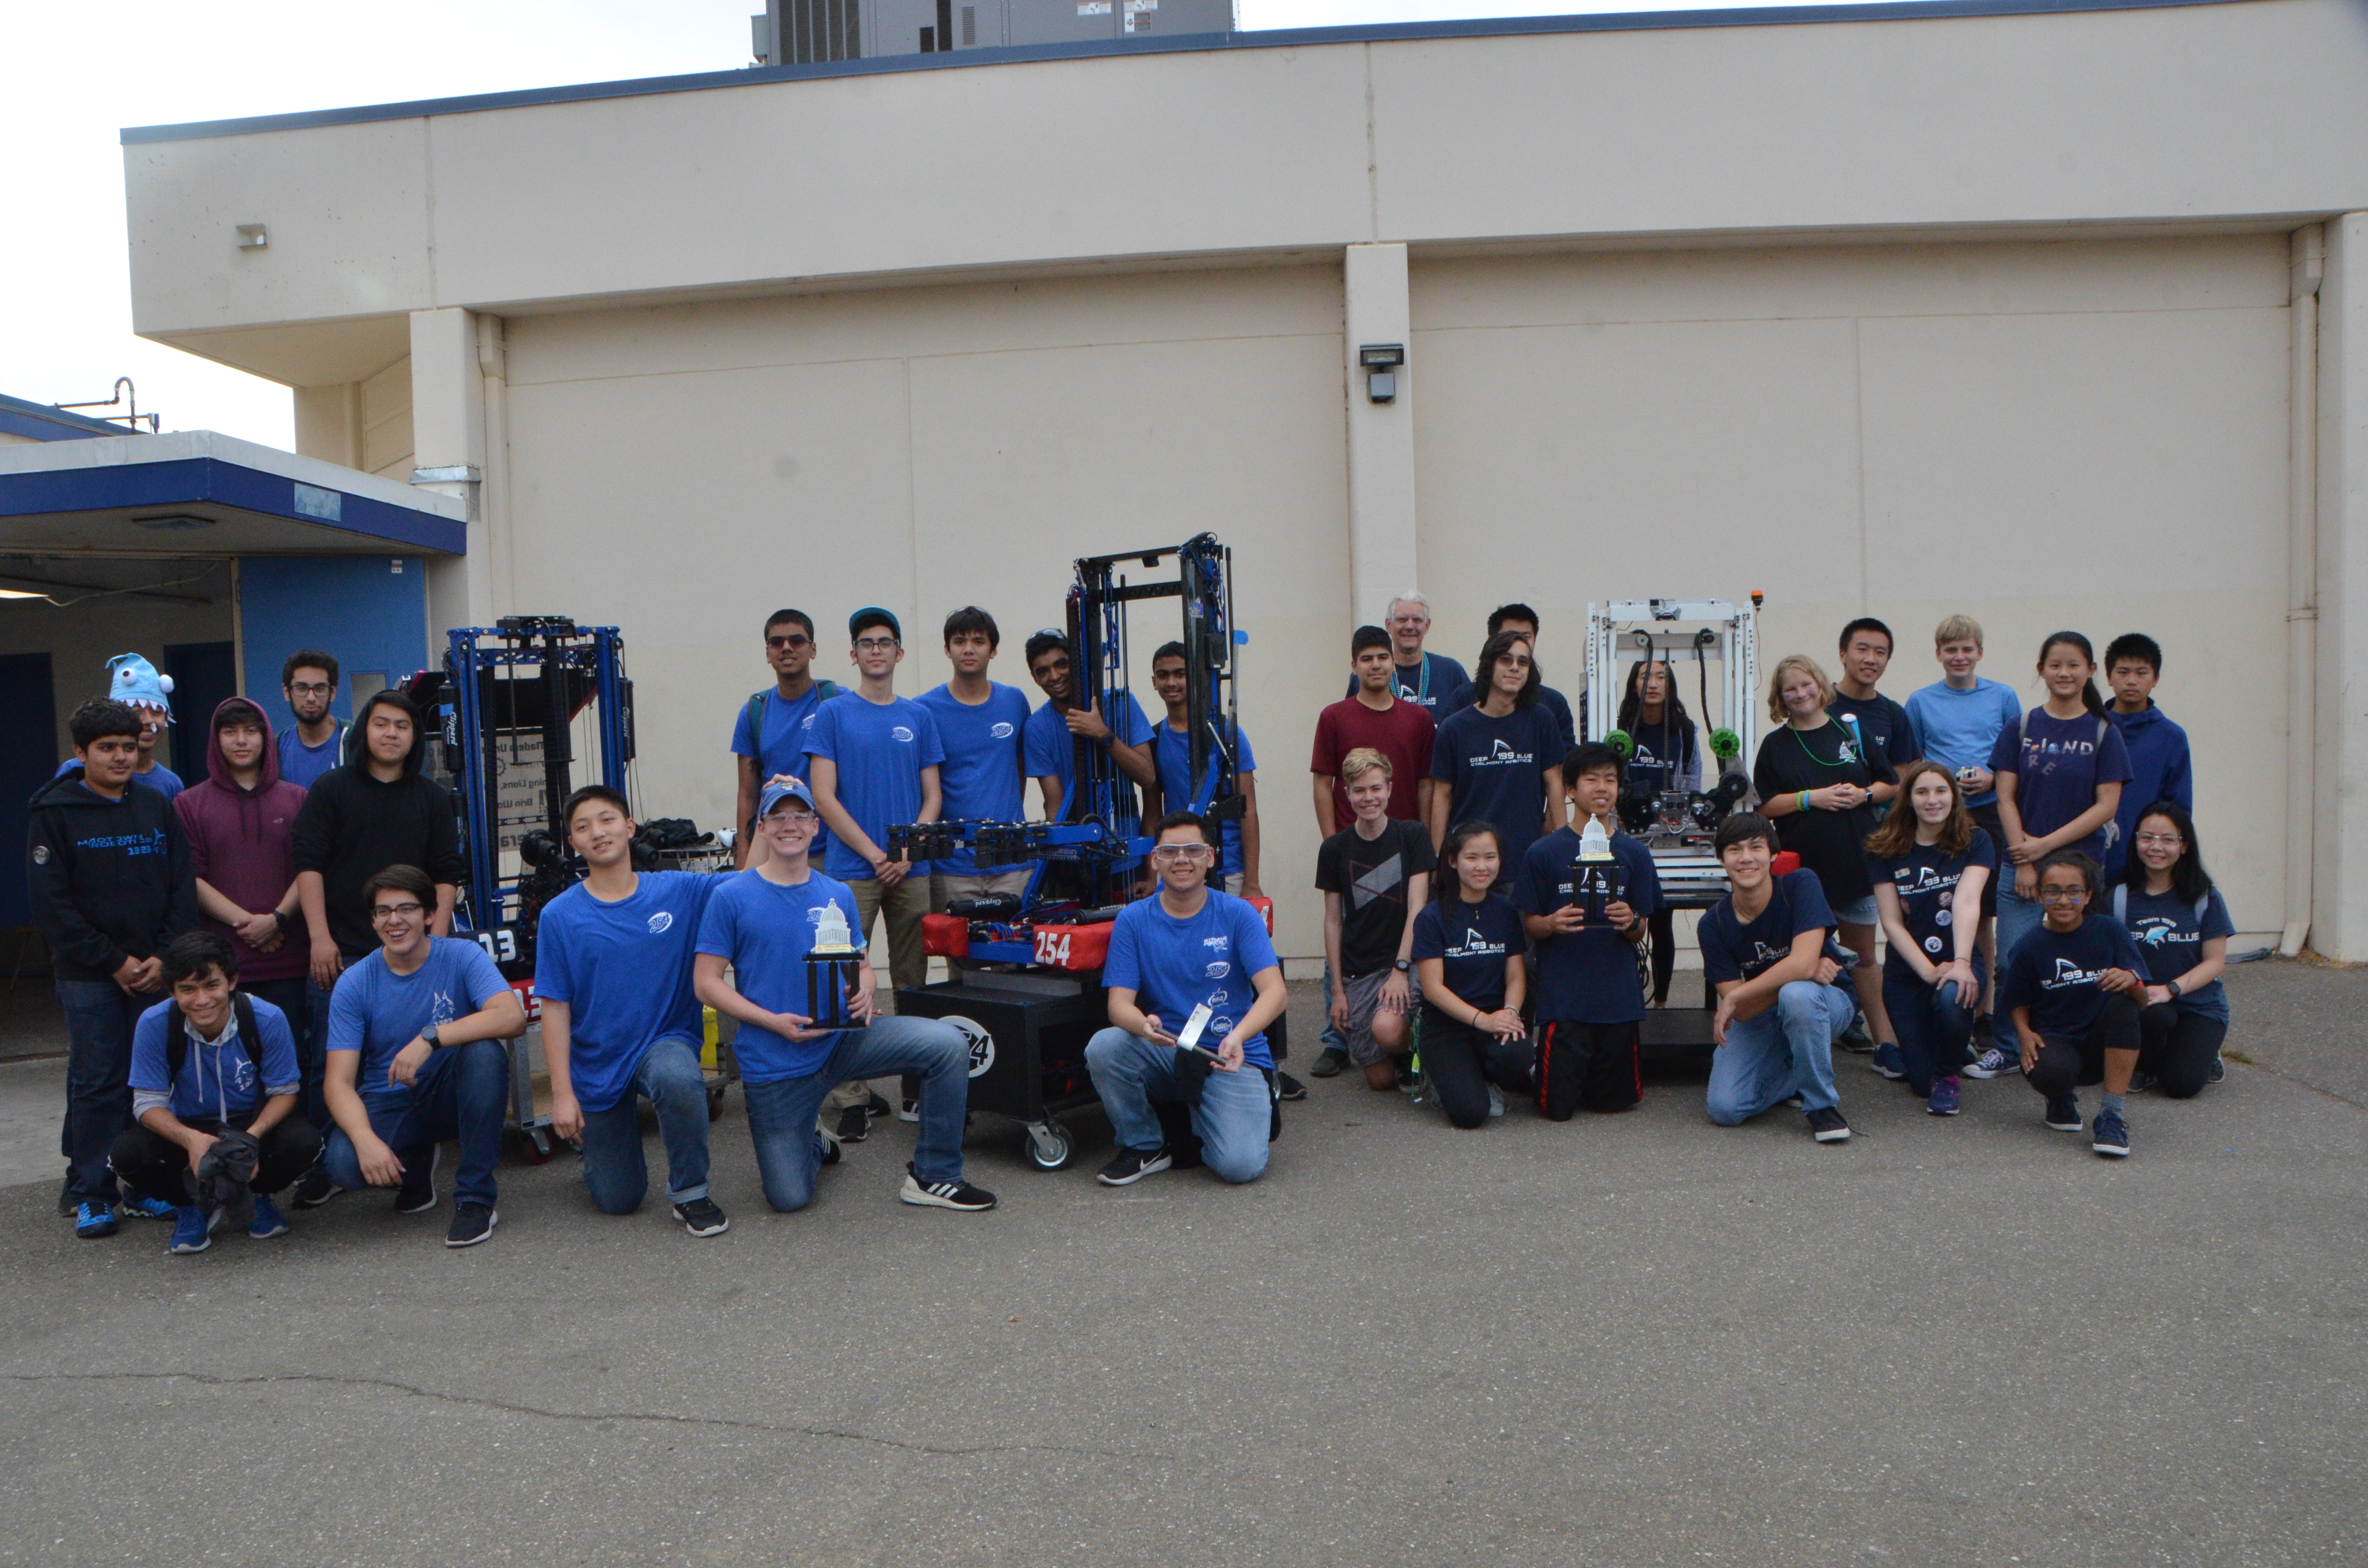
Team 254 Members pose with their alliance partners and fellow champions

Event Highlights

General Summary

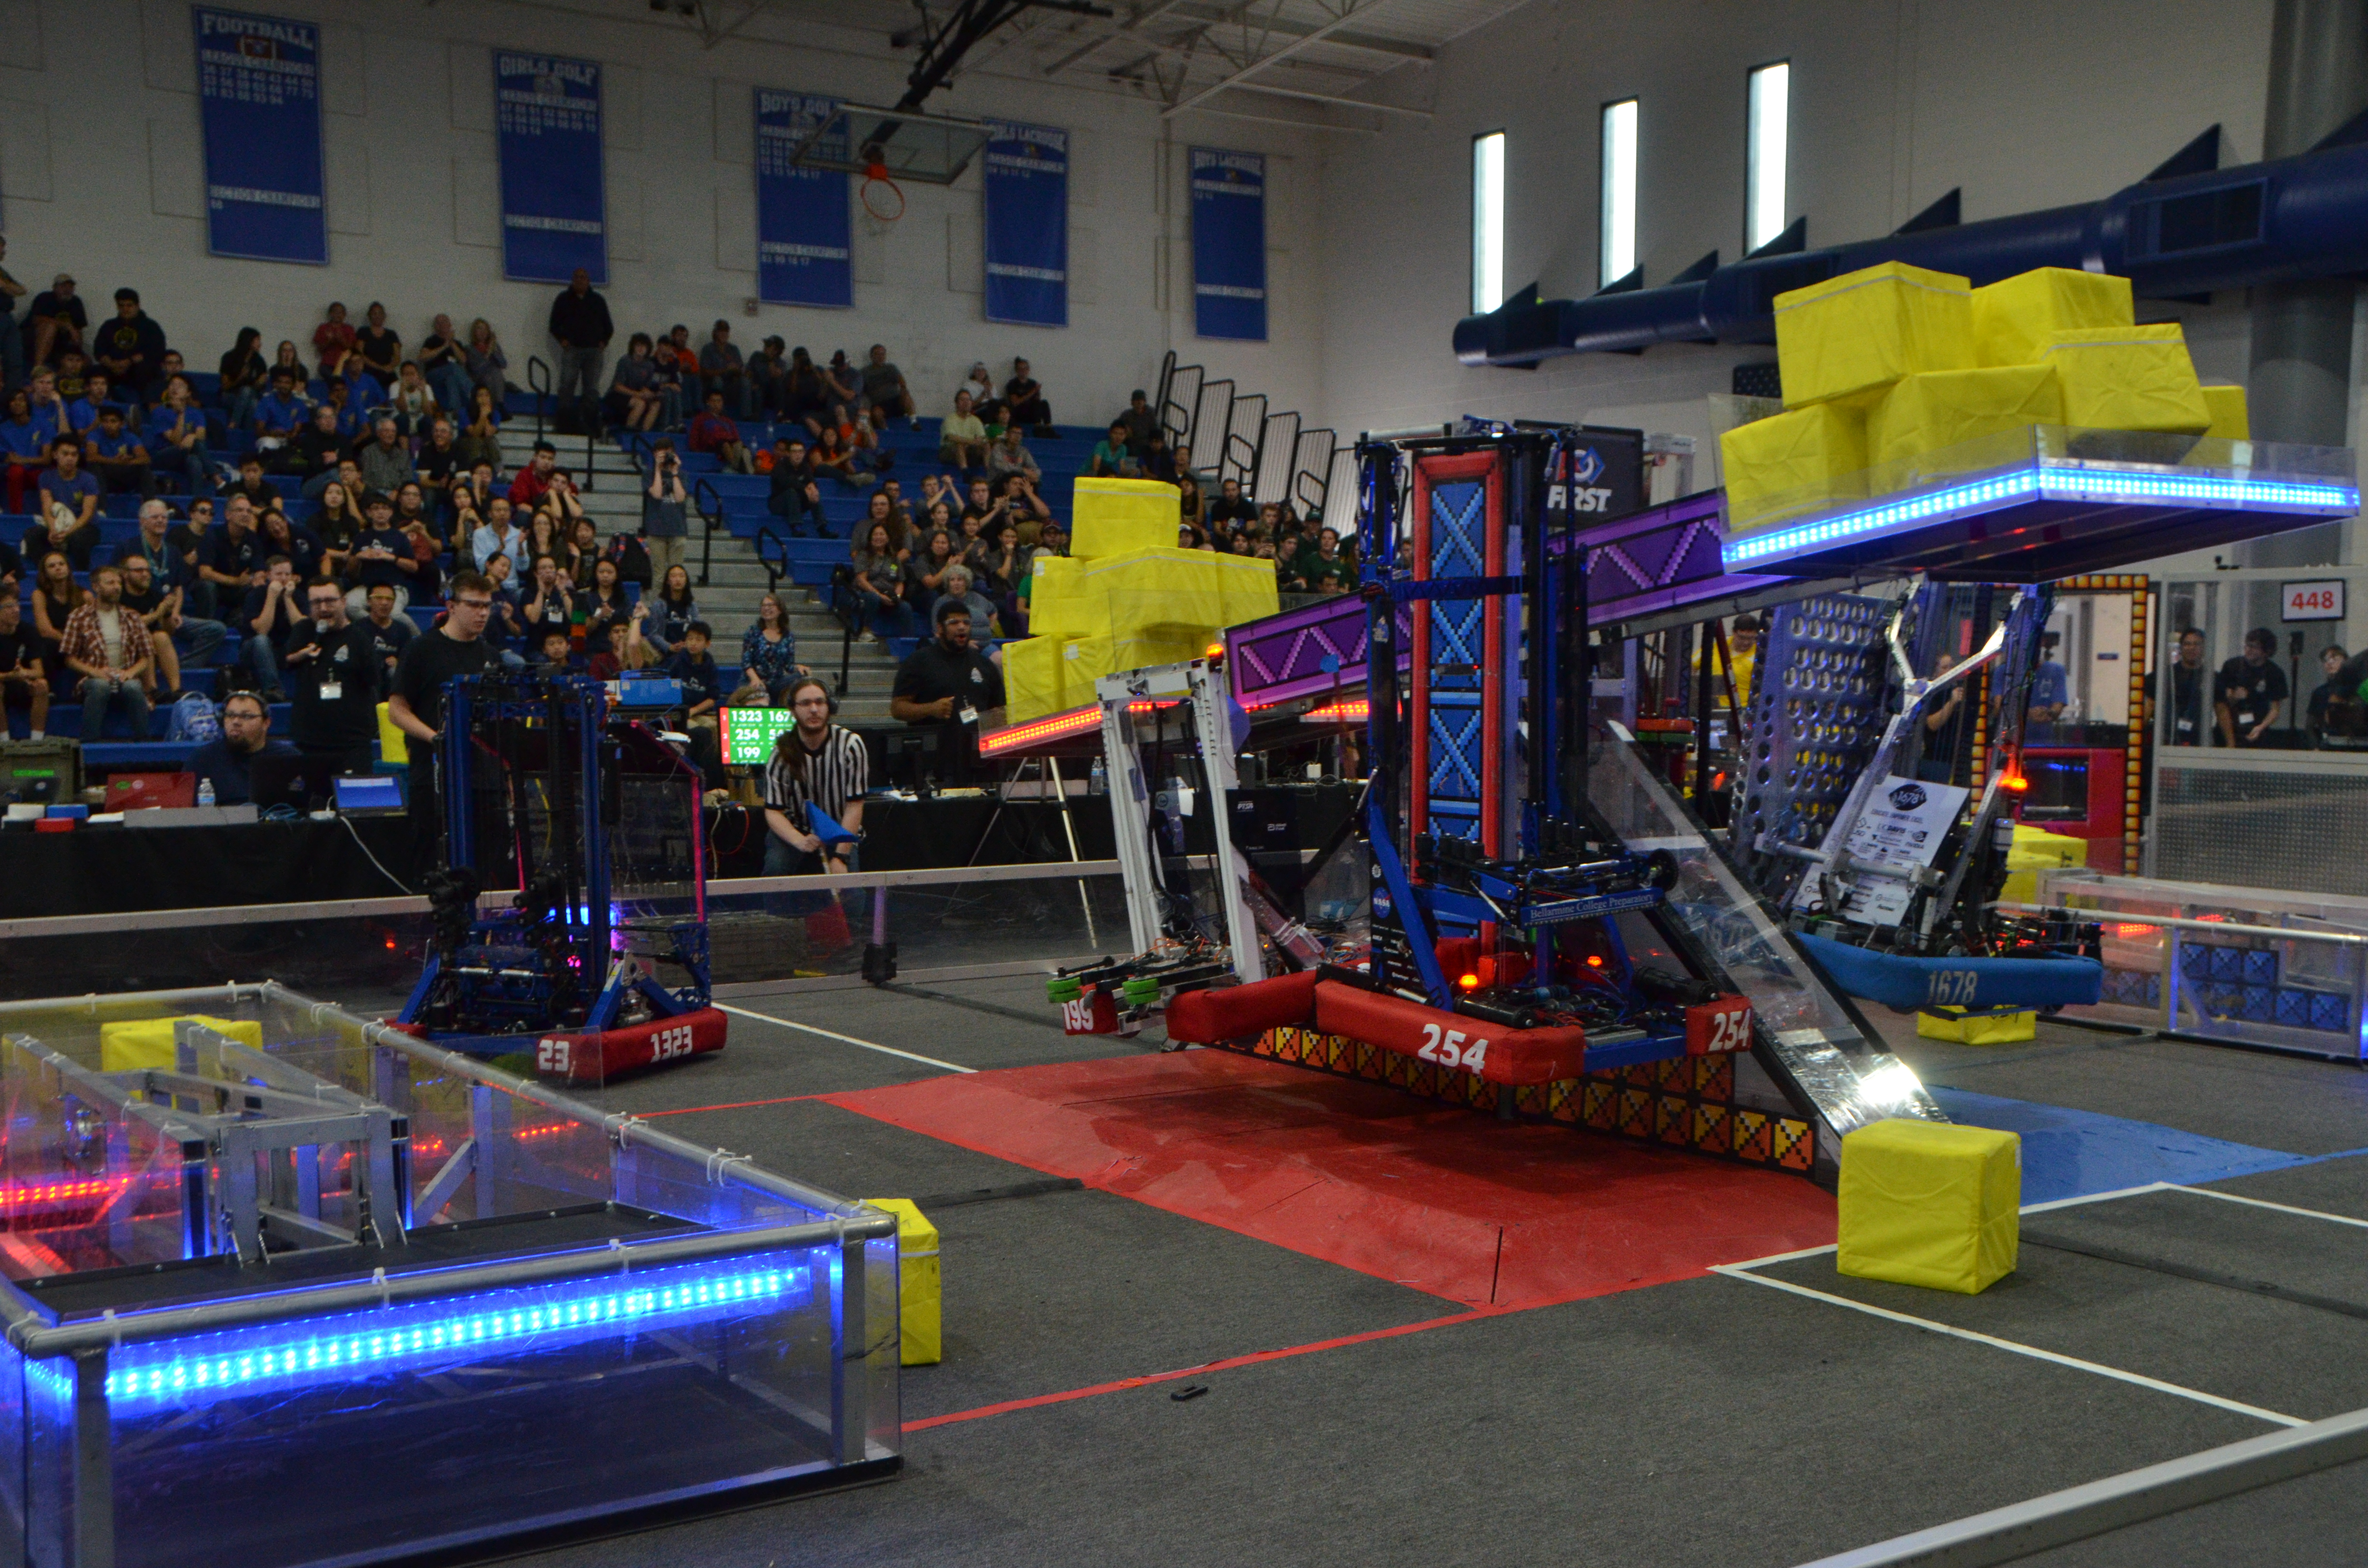
Team 254 hangs at the end of a quarterfinals match

Overall, Capital City Classic was a great event for our team. After ending with a record of 15-0, our team members were excited throughout the tournament. With an 8 person pit crew and drive team, we were very effective and made sure the rest of our team members were at home working on our summer project robot to prepare to Madtown in 2 weeks.

Robot Performance

In general, we prioritized ranking points throughout the event. Since many robots at the event did not focus on the scale, we adopted a strategy of aggressive offense where we would score on our opponent’s switch. We would also focus on maintaining ownership of the scale and climbing at the end of the match for the extra ranking point. We ended up seeding first with 31 ranking points over 9 matches.
During Alliance Selection, we chose to form an alliance with Team 1323 since they had a great scale robot that could really help us establish a lead during auton. To accompany two strong scale robots we looked for two robots skilled in locking down the switches and exchange, like Team 199 and Team 3859.
During elims, we worked with Team 1323 to lock down ownership of the scale during auton. If necessary, Team 1323 would focus on offense towards the opposing alliance’s switch. During finals, we did have some scale competition with team Team 1678 and Team 1425 on the opposing alliance. Thus, we played more conservatively and made sure we had a solid buffer on the scale before rotating to other tasks. We would also like to recognize the opposing alliance of Team 1678 (Citrus Circuits), Team 1425 (Error Code Xero), Team 5458 (Digital Minds), and Team 4171 (BayBots).

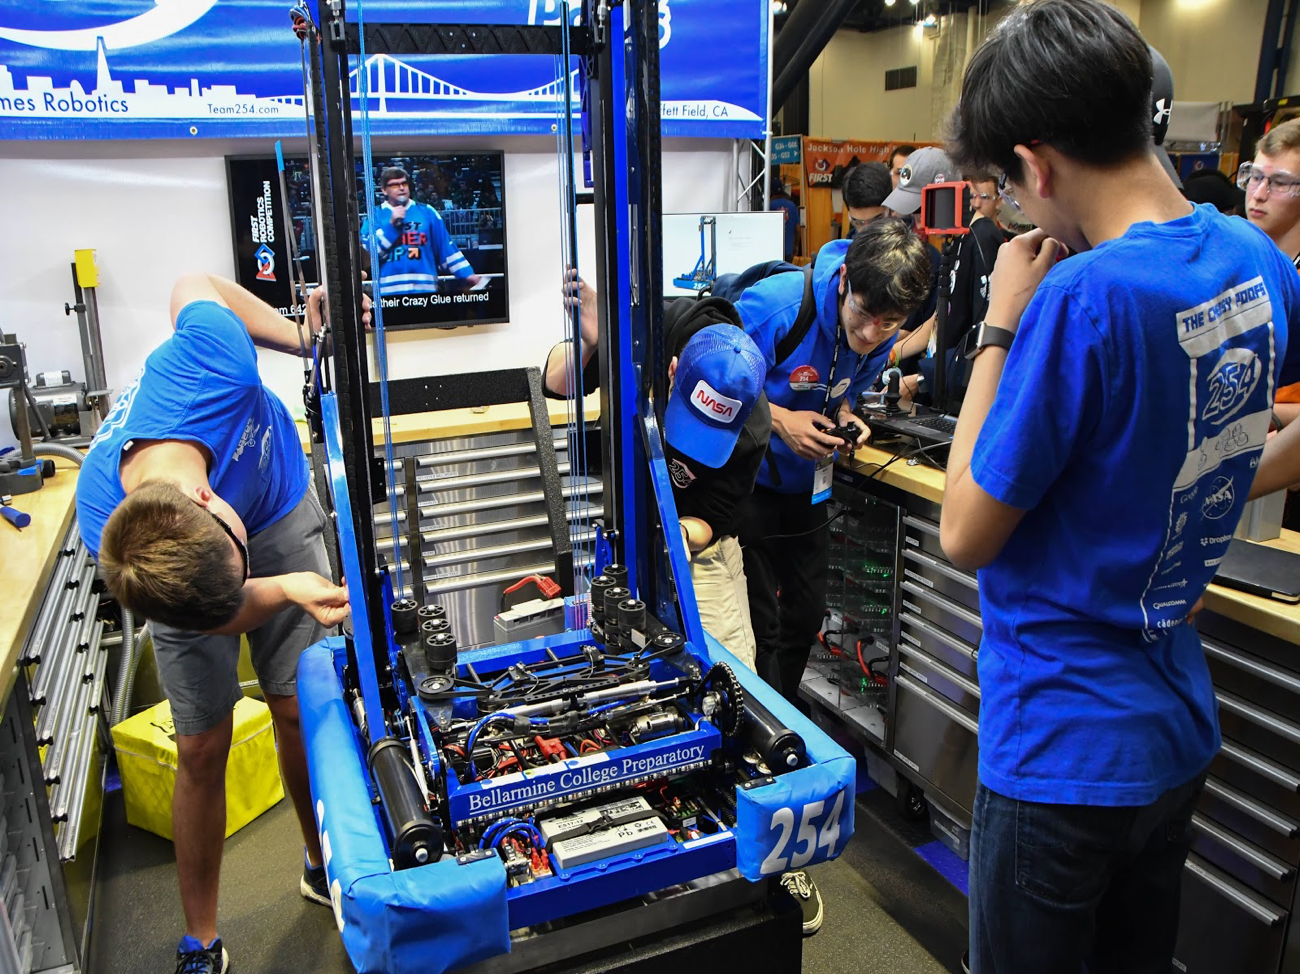
Members of the Team 254 Pit Crew repair Lockdown before an upcoming Finals Match

A Special Thanks

Since this was Team 254’s first time at Capital City Classic, we would like to say thank you to Team 1678 (Citrus Circuits) for hosting the tournament and making us feel welcome.

Chezy Champs 2018

2018 FRC Build Season

A Brief Sumary

As part of an eventful weekend, we hosted Chezy Champs, our annually hosted offseason FRC tournament at Bellarmine College Preparatory, in our hometown of San Jose, CA. We had a great time jumping back into action with our robot, Lockdown, before the start of the 2019 FRC Season. Alongside, FRC Team 1678 Team Citrus Circuits, FRC Team 649 M-SET Fish, and FRC Team 2557 SOTAbots, we were able to win the tournament!

Robot Performance

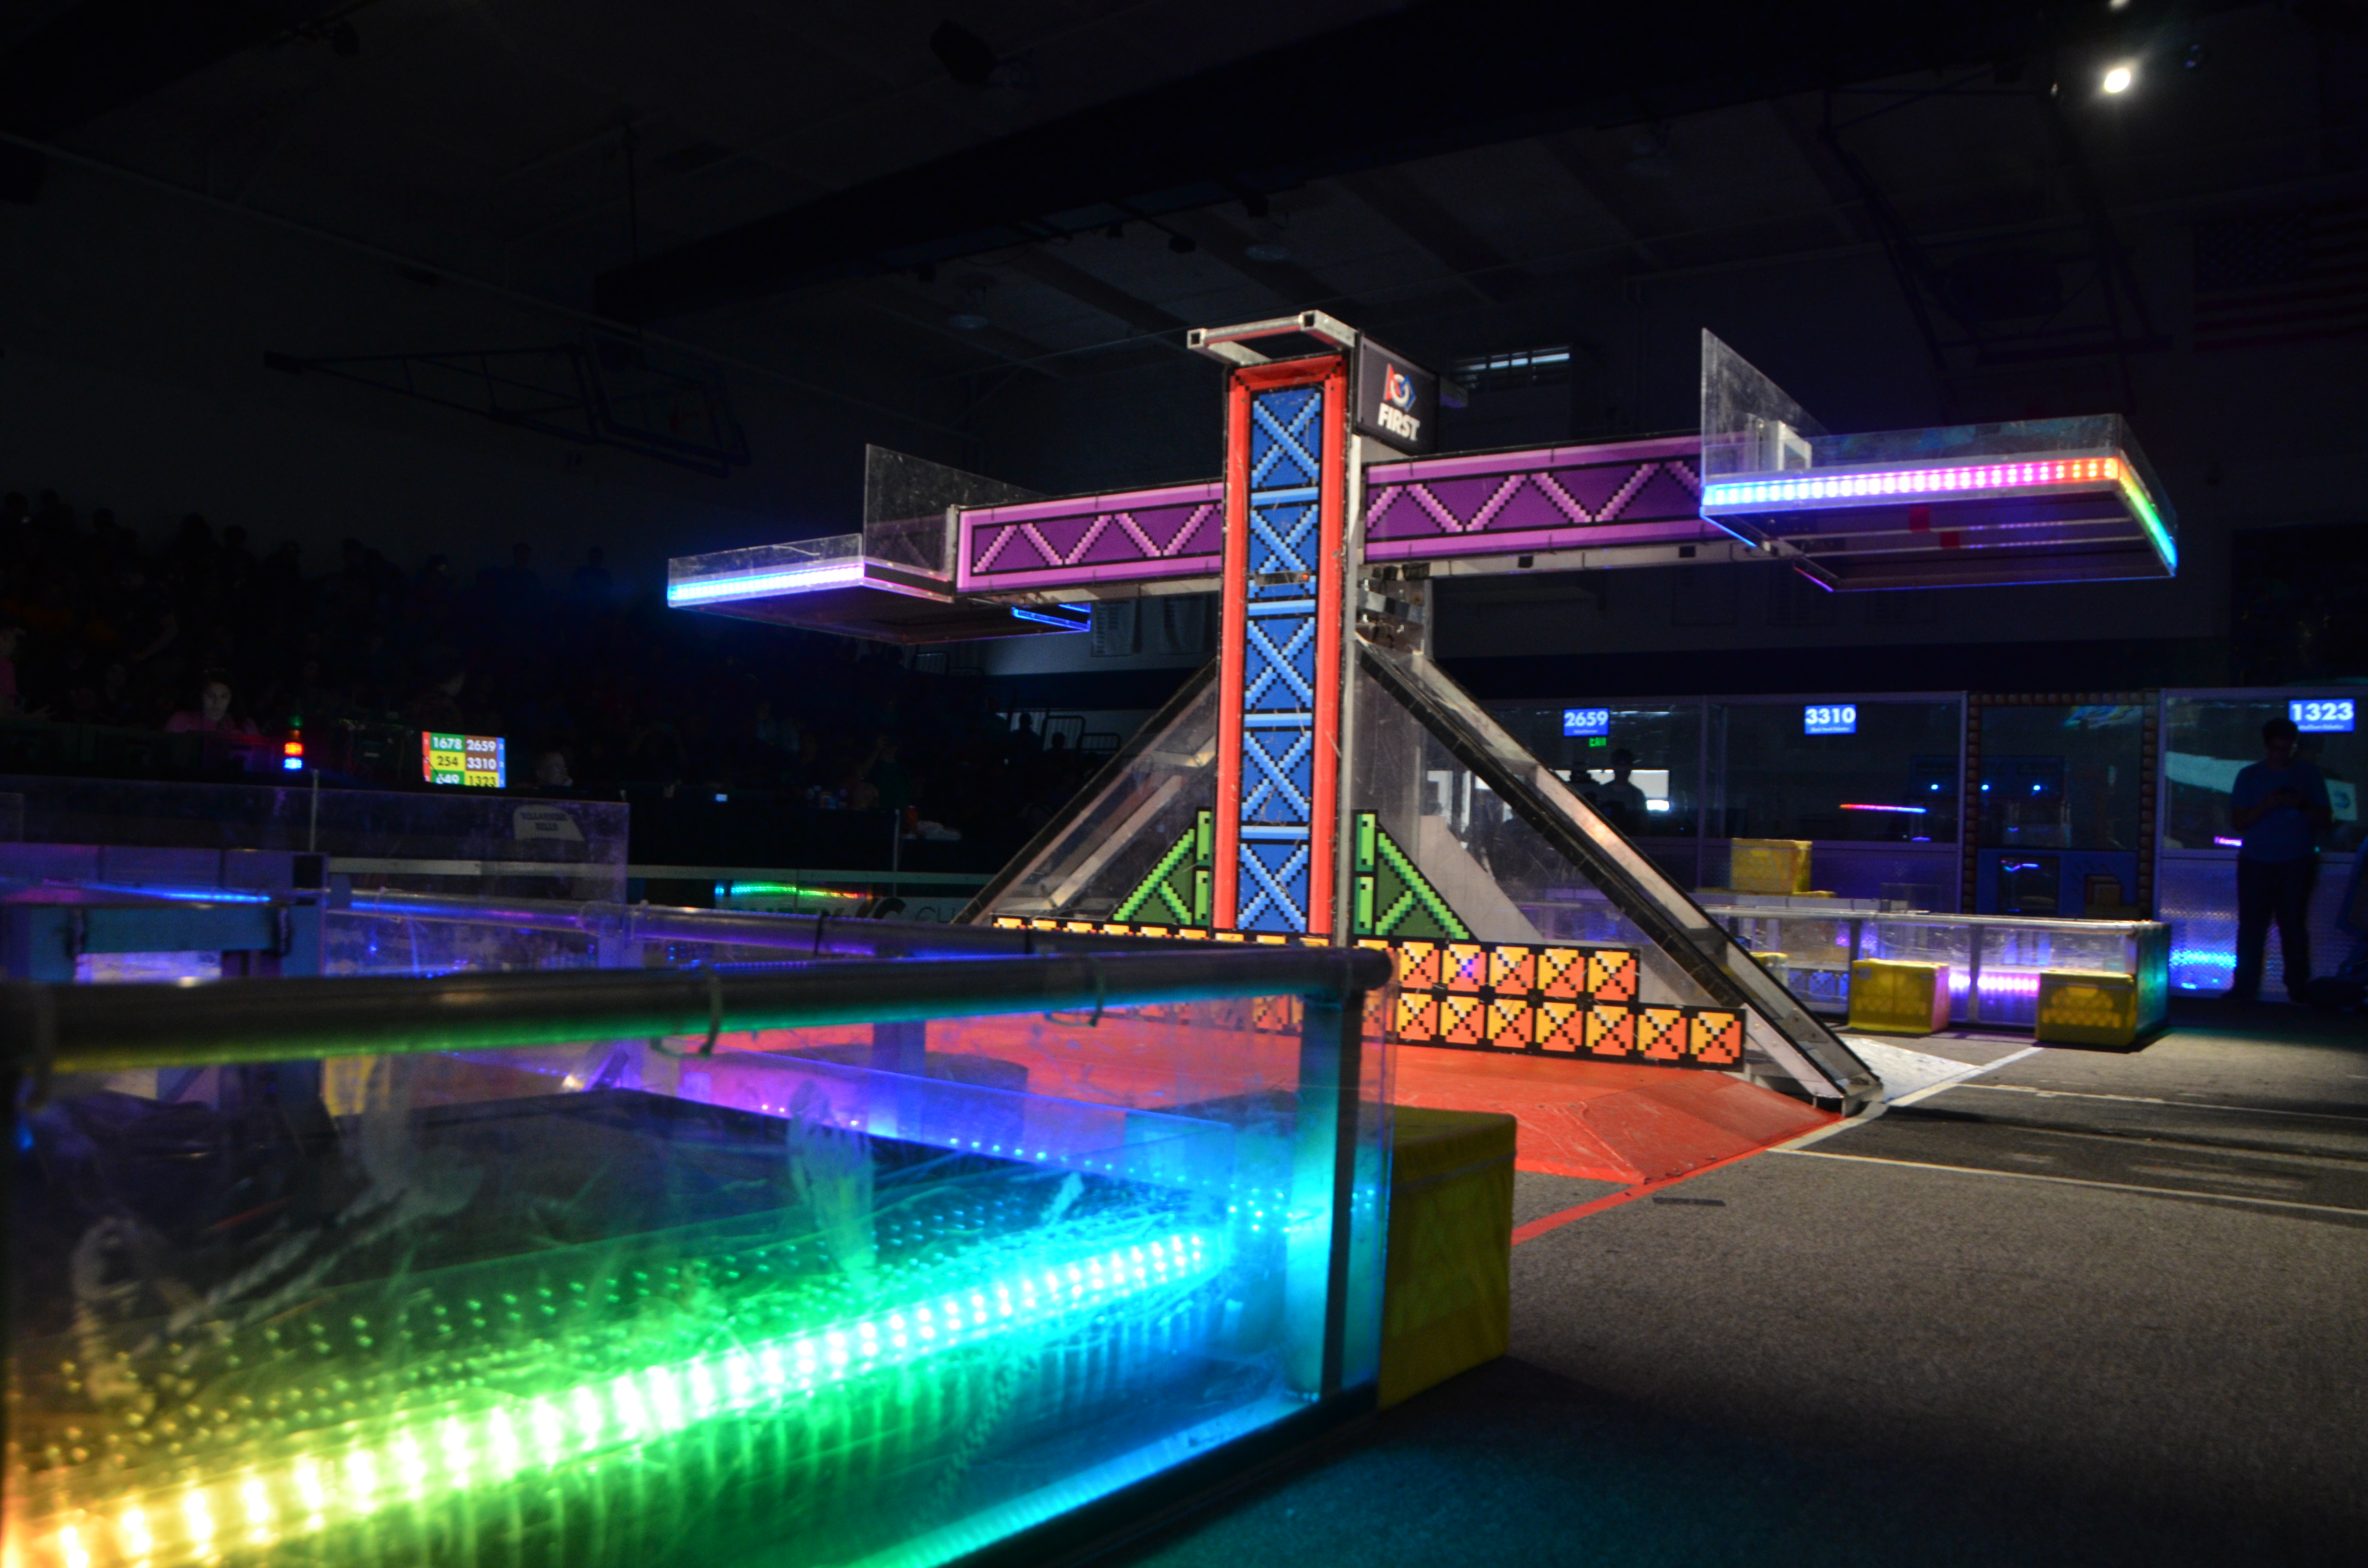
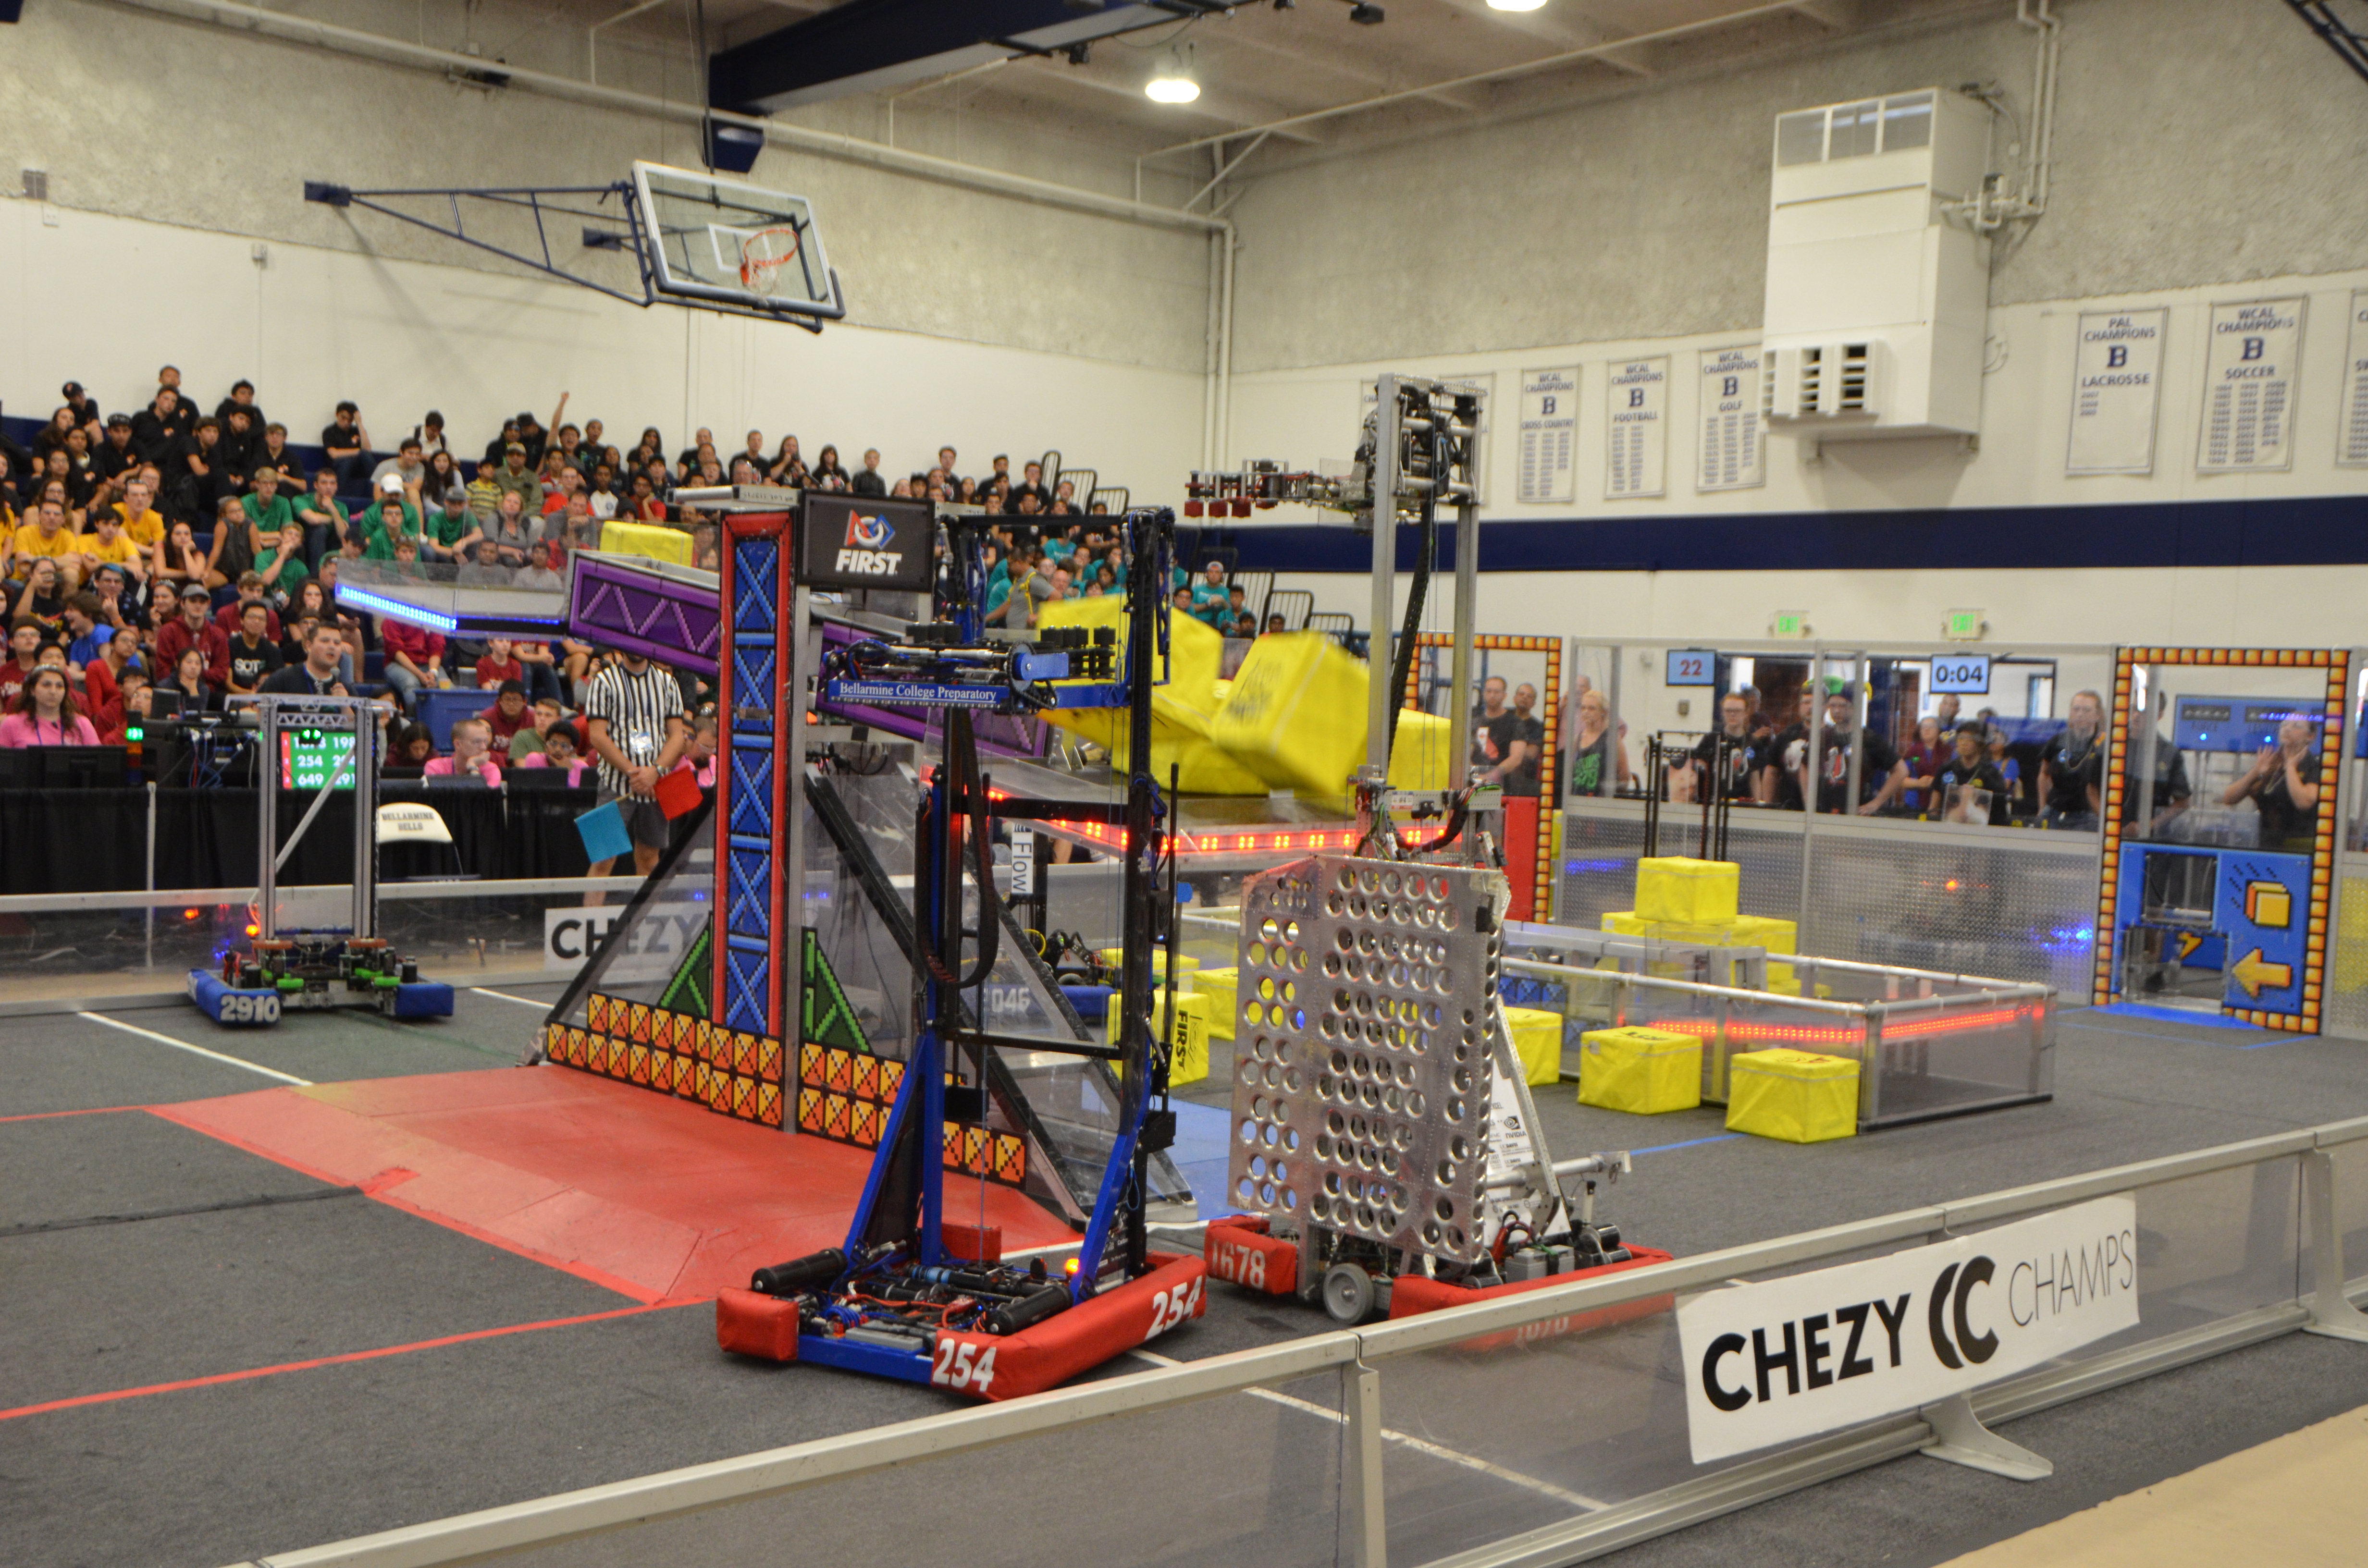
Lockdown faces some competition in scoring on the scale

Throughout the qualification matches, we had a very loose strategy. We had a new drive team for this year, so we were very relaxed in our approach to the game and generally focused scoring on the scale. Though we lost a few quals matches and did not seed first, we were chosen to join an alliance with generous Team 1678 (Citrus Circuits). During elims, we had scale-heavy matches and switch-heavy matches. During our scale-heavy matches, we worked with Team 1678 to score on the scale until we had a substantial lead. After focusing on the scale, we would divert our attention to our switch or attack our opponent’s switch of necessary. For finals, our objective was to build a solid lead after auto and then maintain ownership of the scale. We ensured that we completed this objective by placing all of the switch fence cubes on the scale. Whenever we had a lead on the scale, 1678 would maintain it and we would do our best to slow Team 1323 down by attacking opponent switch and disrupting their pyramid-scale cycles. We would like to congratulate the winning alliance of Team 3310 (Black Hawk Robotics), Team 1323 (MadTown Robotics), Team 2659 (RoboWarriors), and Team 1538 (The Holy Cows).

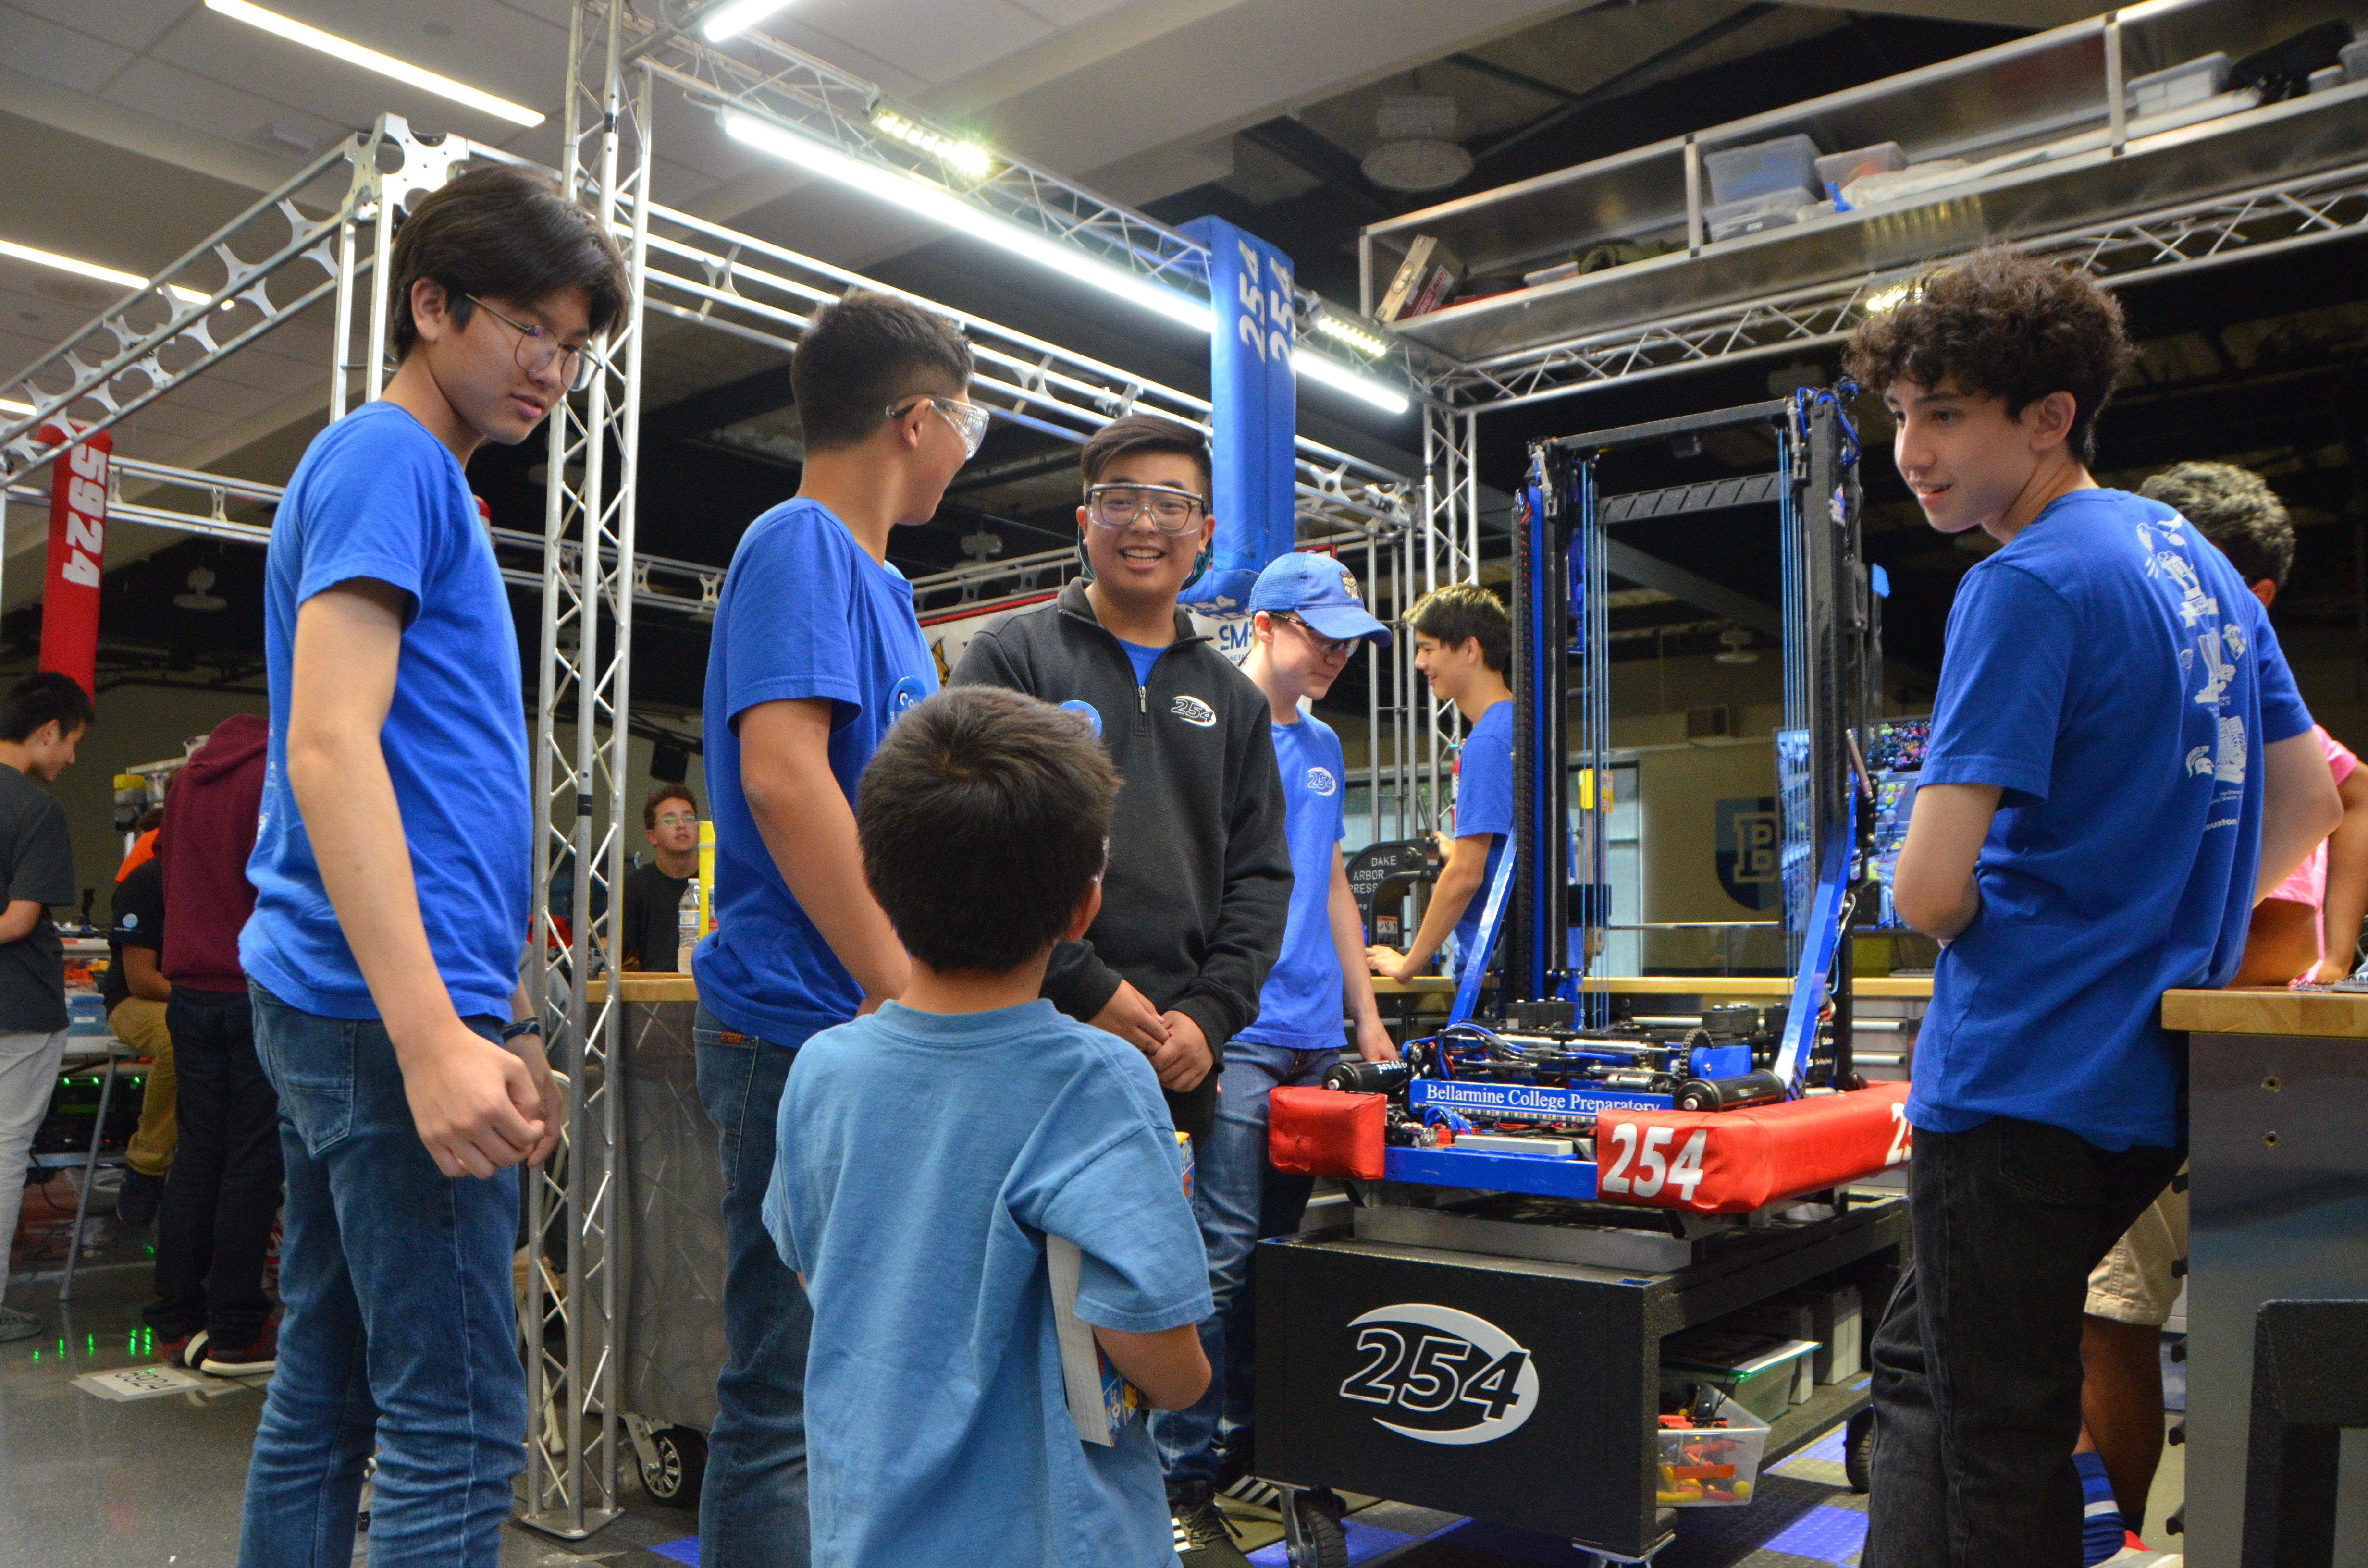
Team 254 Members show Lockdown to a visitor

A Special Thanks

Chezy Champs was very special this year due to the efforts of so many people and organizations. Team 254 would like to thank our friends from RoboSports Network (RSN) for providing our audience with such a great analysis of each match and team at the tournament. We would also like to thank all the volunteers, who helped make Chezy Champs possible. It was truly an incredible experience to host an offseason tournament attended by so many talented teams, even those who chose to attend from out of state, and to make new friends and catch up with old ones too!

2018 World Champions!

2018 FRC Build Season

A Brief Summary

As part of an eventful week, we attended the 2018 FIRST World Championship in Houston, Texas from April 18th to April 21st. Assigned to the Hopper Division, we won the Division Championship Award and the Autonomous Award sponsored by Ford, for our 4 cube scale autonomous program and scale detection software. After becoming the Hopper Division Champions, we executed a well-planned strategy alongside FRC Team 148 Robowranglers, FRC Team 2976 Spartabots, and FRC Team 3075 Ha-Dream Team, allowing us to win our 4th world championship and finish with an undefeated season!

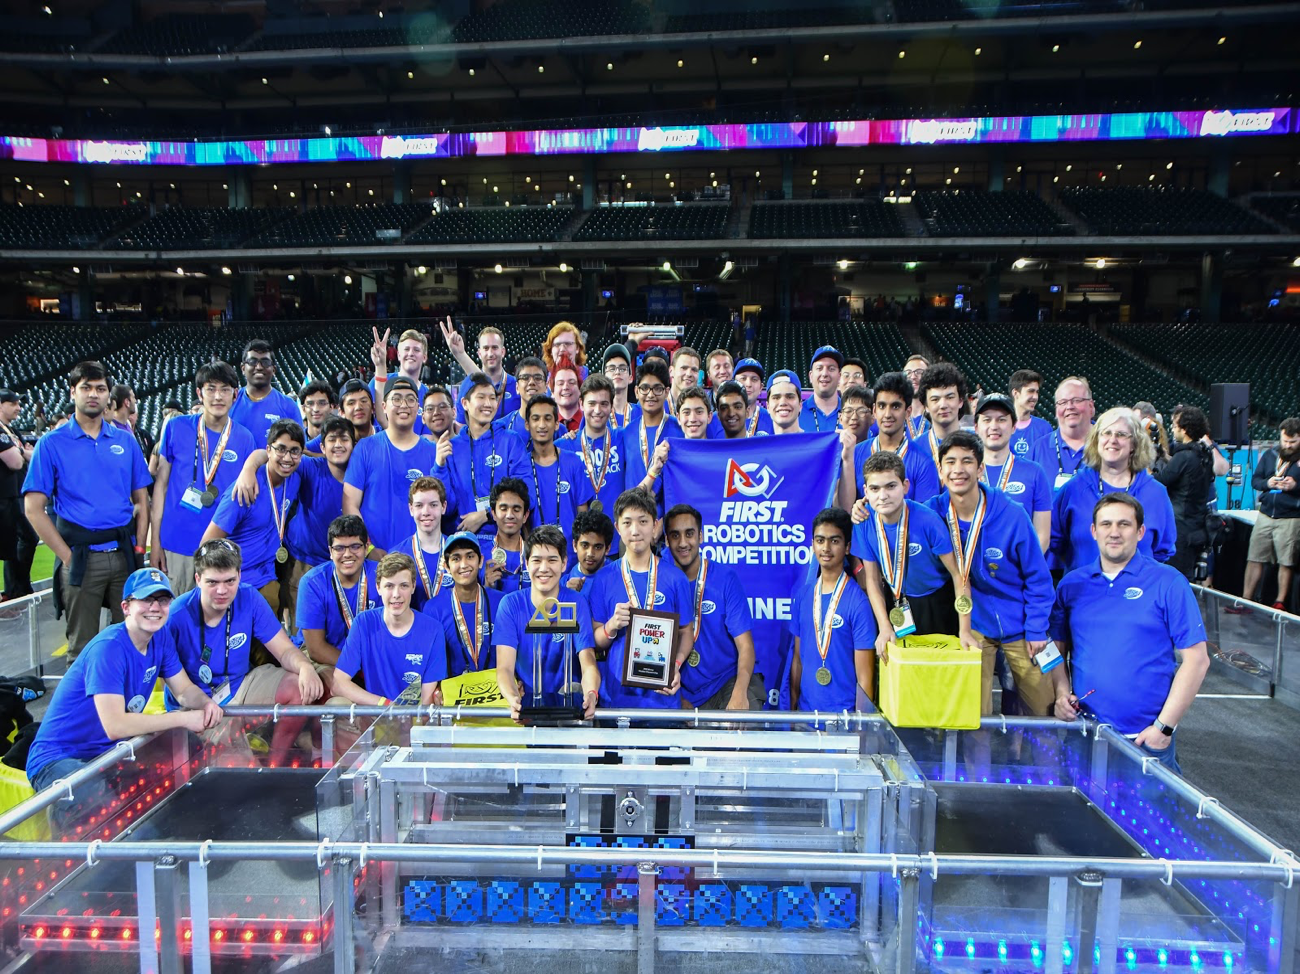
Team 254 poses for a picture after winning at the 2018 FIRST Championship in Minute Maid Park

Robot Performance

Qualification Matches (Hopper Division)

Throughout our qualification matches, we wanted to make sure that we secured 4 ranking points during every match, while still gaining control of our scale for as long as possible. In order to do this, we ran our scale autonomous program, which placed 3-4 cubes on our alliance’s scale or, when we were not confident with our alliance partners’ ability to place cubes on the switch, we executed our autonomous program which placed cubes on the switch and scale.

Alliance Selection

Going into the elimination period in the Hopper Division, we chose to form an alliance with FRC Team 148 Robowranglers, FRC Team 2976 Spartabots, and FRC Team 3075 Ha-Dream Team.

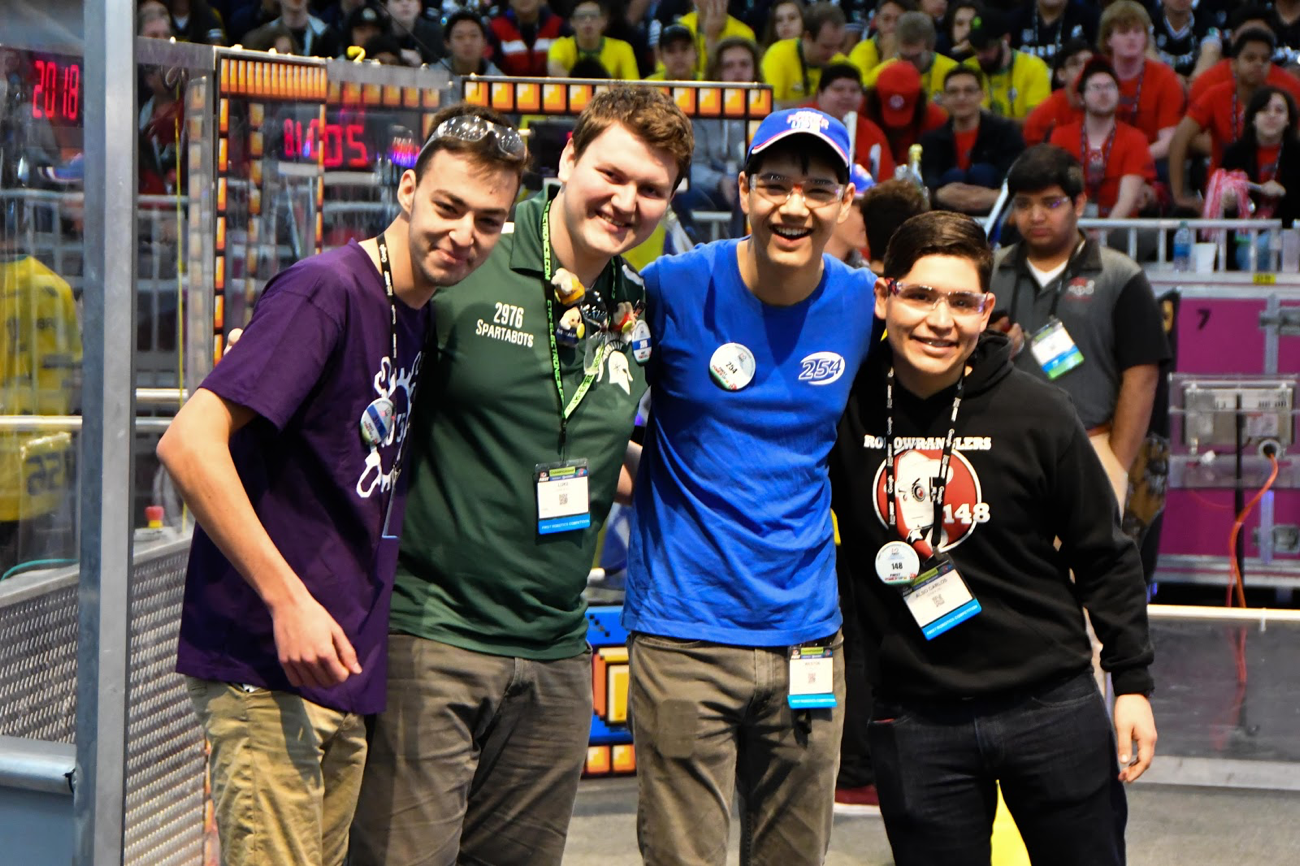
Team 254 representative, Weston White, poses with our chosen alliance partners

Elimination Matches (Hopper Division)

During the elimination matches in the Hopper Division, we maintained our undefeated record for the entire tournament. From a strategic perspective, we aimed to always have possession of the scale and our own switch while also placing cubes on our opponent’s switch. This strategy allowed us to gain a significant lead during each match and stopped the opposing alliance from being able to score from their own switch. We would also like to thank Team 3075 Ha-Dream Team for helping our alliance during Finals Match 2 in the Hopper Division, while Team 2976’s robot was undergoing some repairs. Through the efforts of our alliance partners, we were able to win the Hopper Division. We also won the Autonomous Award sponsored by Ford, for our unique 4 cube scale autonomous program and scale detection software!

Lockdown hangs with alliance partner, Team 2976, at the end of a match

On the Einstein Field

We generally maintained a similar strategy during the Einstein matches as in the Hopper Division elimination round, by placing cubes on both switches and keeping possession of the scale. Team 2976 Spartabots played awesome defense on the portals to slow down the opposing alliance’s cube flow after they used all the cubes from their switch fence. Team 148 Robowranglers attacked the opposing alliance’s switch to force them to cover their switch before attacking our switch or the scale. Our drive team chose not to prioritize powerups, by placing only 3-4 cubes in our exchange for the levitate or boost powerup. With this strategy, we placed first during the round robin matches, allowing us to move on to Finals, with the Carver Division winners. We would like to shout out FRC Team 2910 Jack In The Bot, FRC Team 4911 Cyberknights, FRC Team 4499 The Highlanders, and FRC Team 5006 Apophis, the Carver Division winners, for executing a great strategy while playing against us on the Einstein Field.

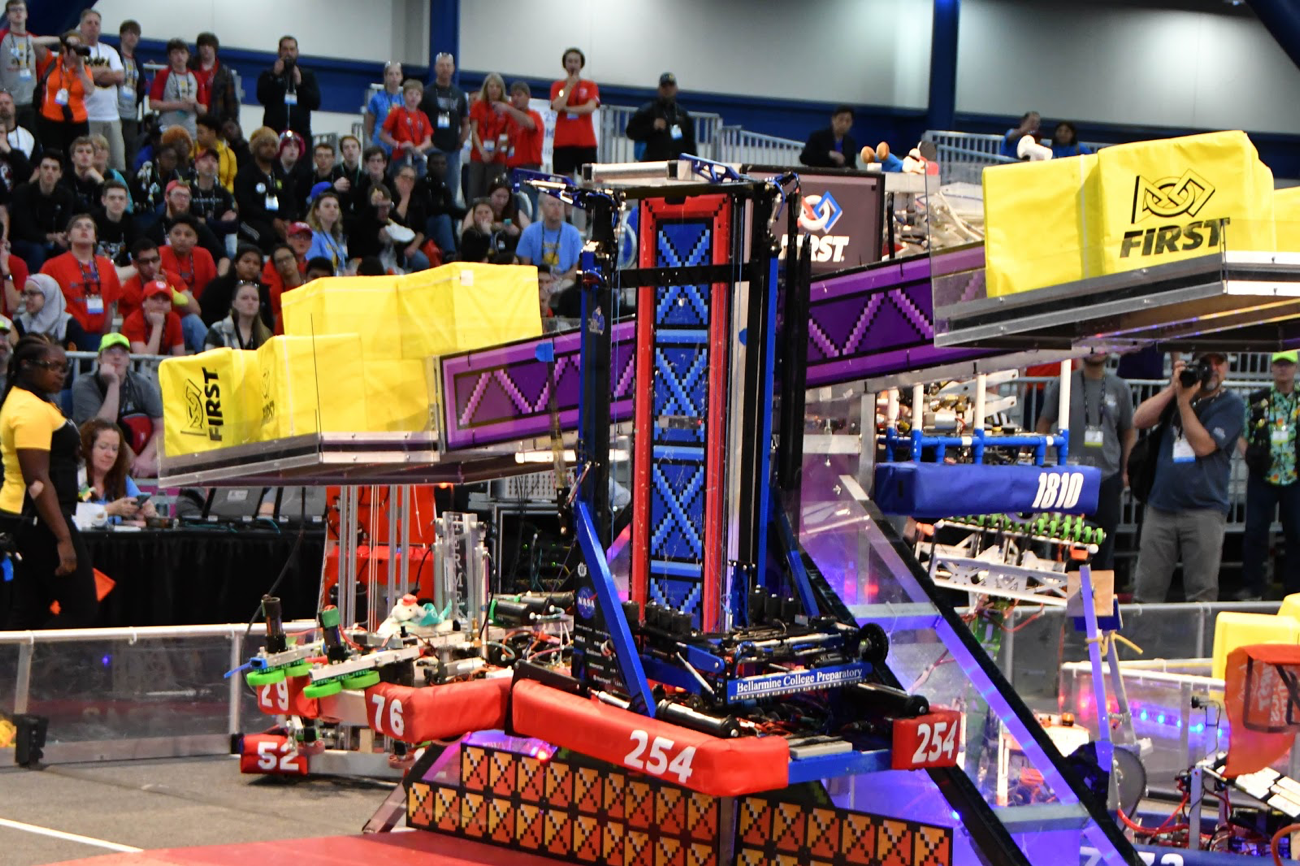
Lockdown works to place a cube on the opposing alliance’s switch

A Special Thanks

At the 2018 FIRST World Championship in Houston, we would not have been able to be so successful without the amazing teams that we were able to work with during our matches. Also a special shout out to our pit crew and drive team for properly maintaining our robot during the tournament. We would also like to highlight the efforts of our alliance readiness crew to keep our alliance partners ready throughout the tournament. Team 254 would also like to thank all the volunteers and judges that made this tournament an exciting experience, and all of our mentors, teachers, and parents who supported us and helped us succeed in this tournament.

Members of the Team 254 Pit Crew repair Lockdown before an upcoming match

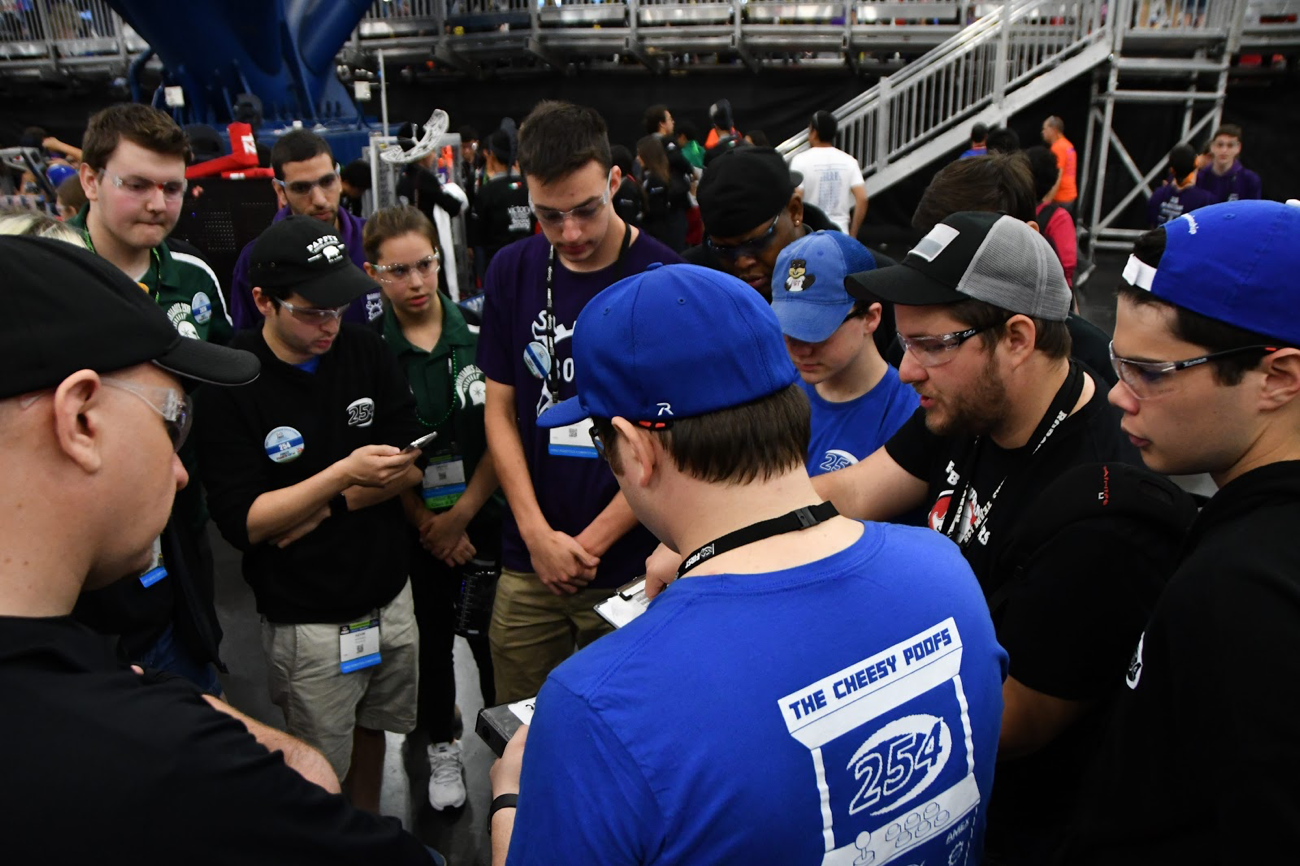
Members of the Team 254, 148, 2976, and 3075 drive team strategize before an upcoming match

Our drive team poses for a picture on the Einstein Field

Members of the Team 254 Alliance Readiness Crew assist Team 6014

2018 Silicon Valley Regional Champions!

2018 FRC Build Season

A Brief Summary

As part of an eventful weekend, we attended the the 20th Silicon Valley Regional, in San Jose, CA. We had a great time at our second tournament of the FIRST Power Up Season with our robot, Lockdown. We won the Innovation In Control Award sponsored by Rockwell Automation for our autonomous code. Congratulations to one of our mentors, Nick Hammes, for winning the Volunteer of the Year award, for his hard work emceeing and in planning this wonderful event! Alongside FRC Team 973 The Greybots and FRC Team 2367 Lancer Robotics, we were able to win the tournament, earning our 50th Blue Banner!

Team 254 poses for a picture with Lockdown after winning at the 2018 Silicon Valley Regional

Robot Performance

Qualification Matches

Throughout our qualification matches, we executed a variety of autonomous programs to ensure we were prepared for various situations. This allowed us to either place 3 cubes in the switch or place 3 cubes on the scale. When on an alliance with robots that were good at placing cubes on the scale, we had to make sure we maintained ownership of the scale before placing cubes on ours’ or our opponent’s switch. We always tried to position ourselves on the scale platform to have enough time for hanging. During the qualification match period, we gained 4 ranking points in each match.

Team 254 places a cube on the scale during the autonomous period

Alliance Selection

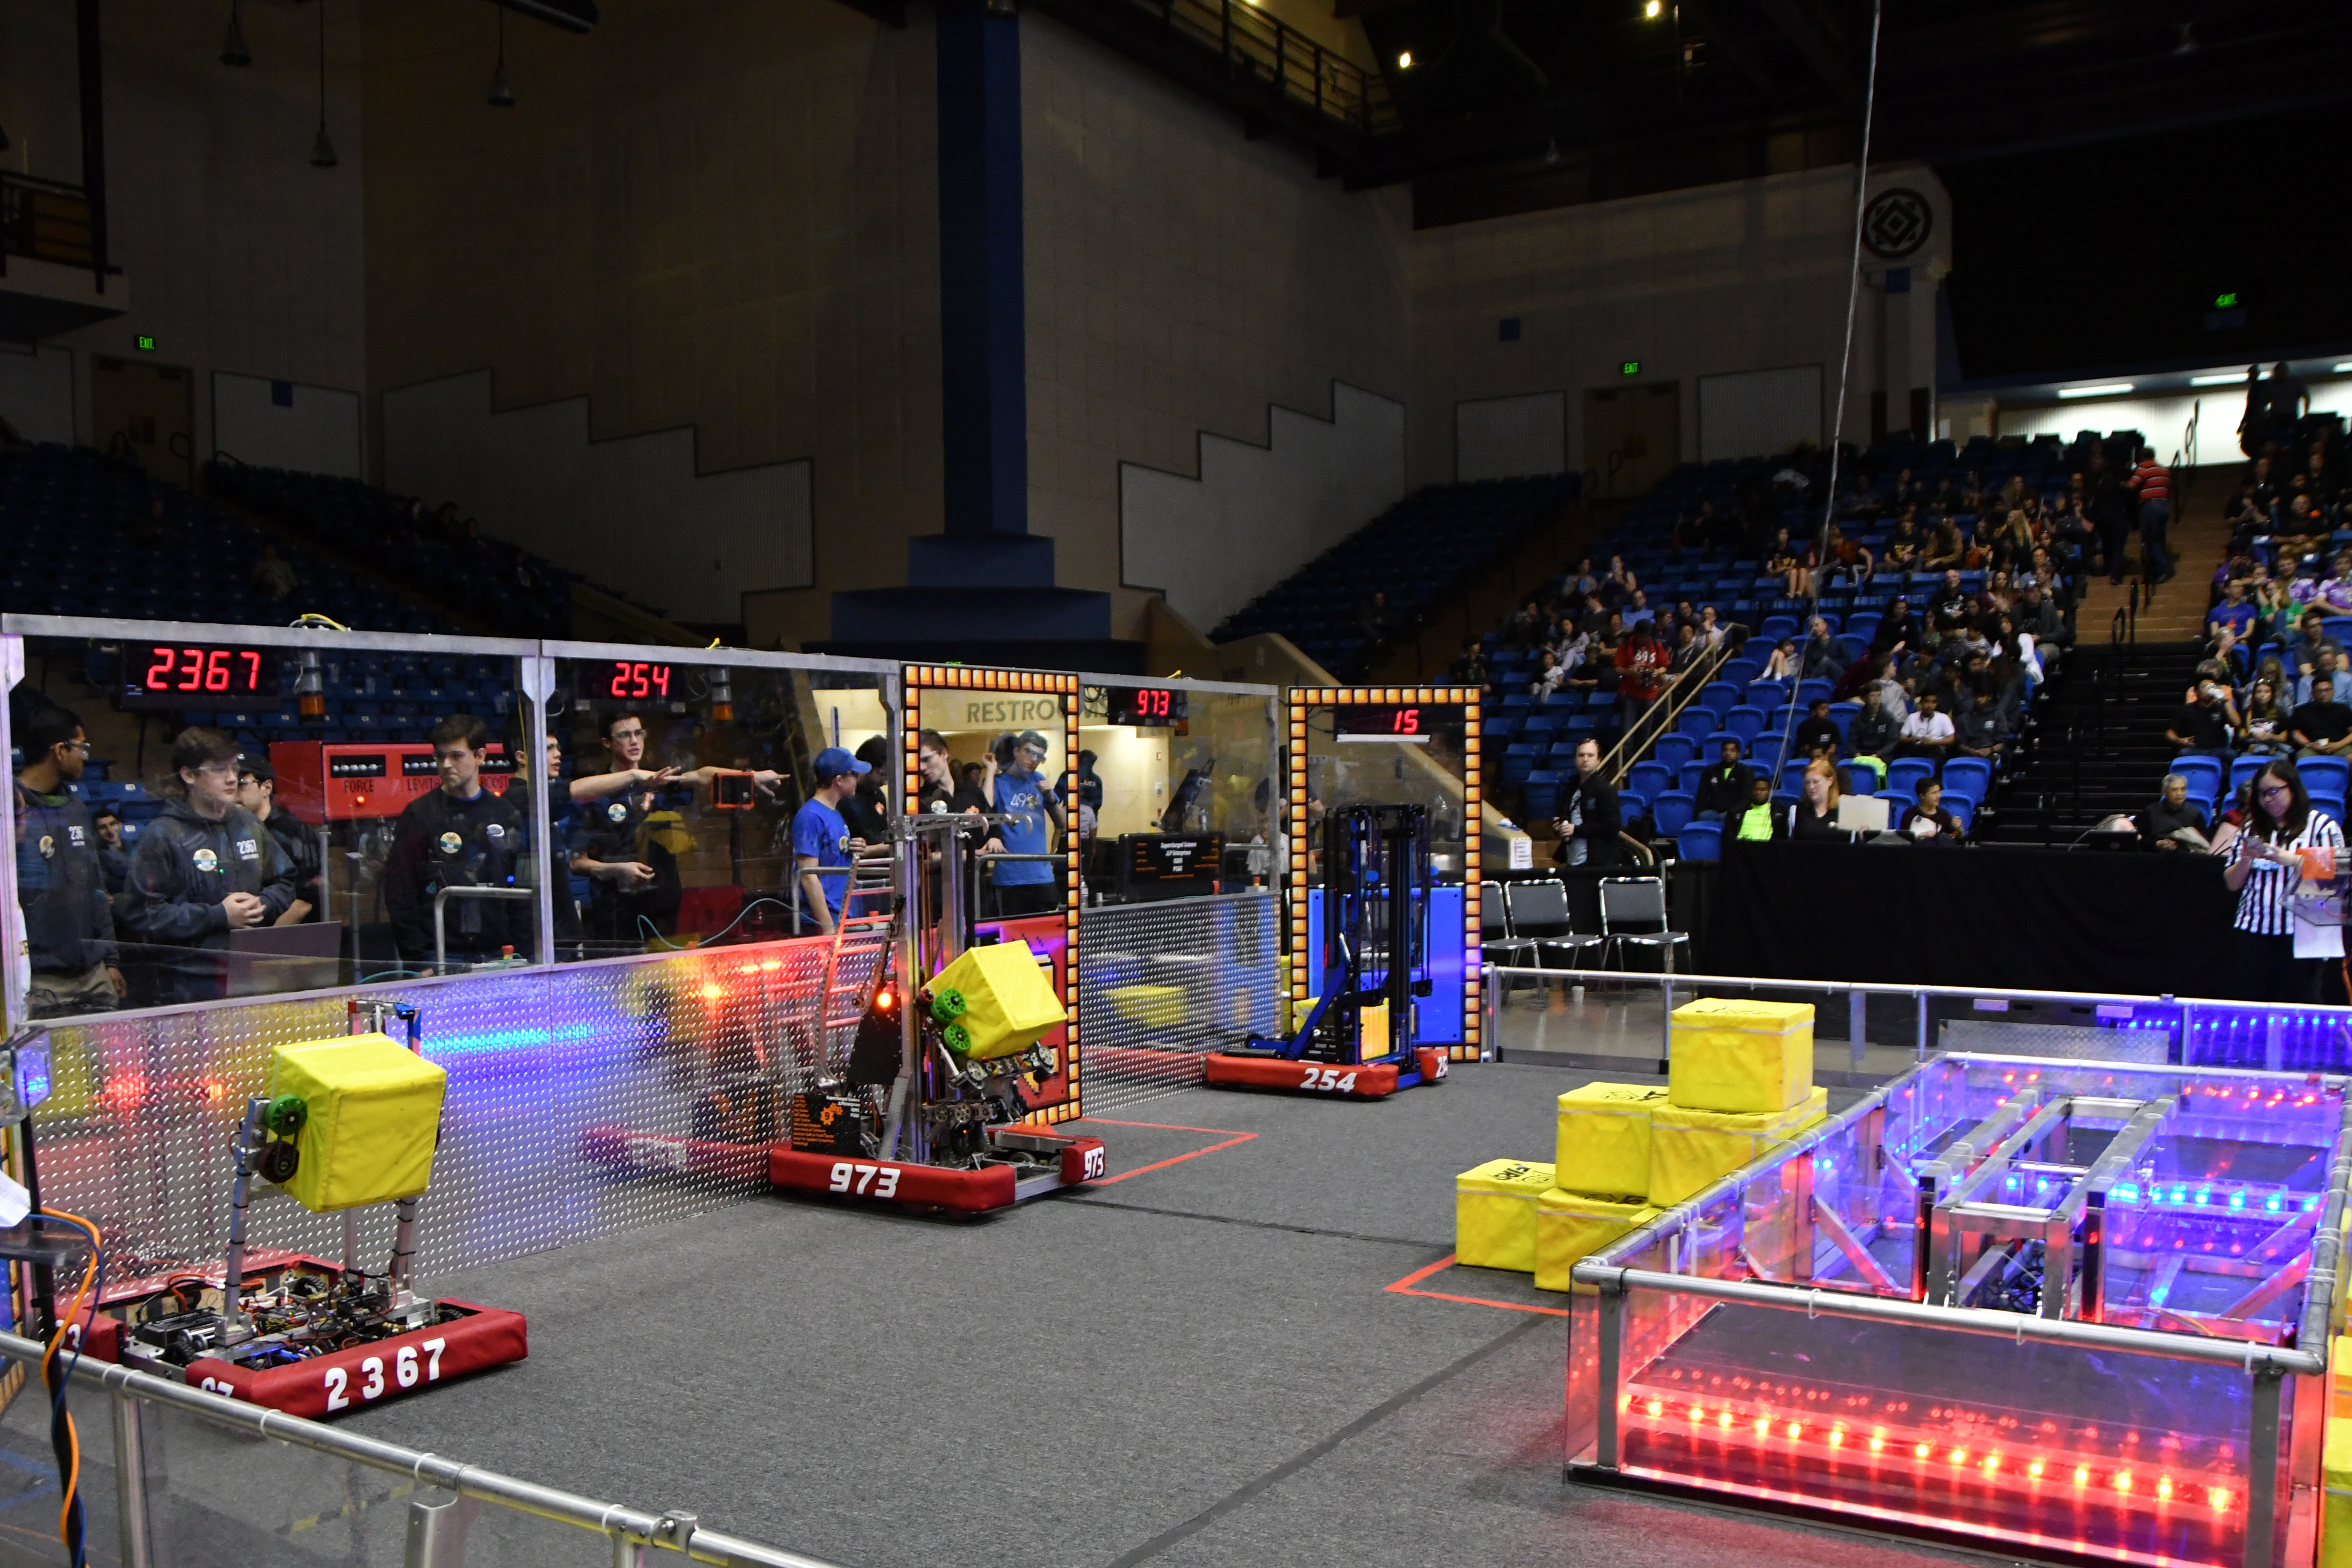
Going into the elimination period, we chose to form an alliance with FRC Team 973 The Greybots, FRC Team 2367 Lancer Robotics.

Team 254 representative, Weston White, stands with Team 973 and Team 2367 as they agree to join our alliance

Elimination Matches

By choosing Team 973, a great scale robot, and Team 2367, a great switch and exchange robot, we were able to follow a more flexible strategy. During the elimination matches, Team 973 worked with us to lock down the scale, while Team 2367 focused on keeping ownership of our switch and delivering cubes to our exchange station. To create a head start on scoring cubes onto the scale, we used our 3 cube scale autonomous program. If our opponents were good scoring on the scale, we joined 973 in maintaining ownership of the scale. When our autonomous program was successful, we worked on maintaining ownership of our opponent’s switch, using cubes from our portal. Team 2367 executed flawless and well-timed defense against the opposing alliance. With an organized strategy and great alliance partners, we remained undefeated for the season, allowing us to become the first-place alliance at the tournament and win our 50th blue banner!

Team 254 and alliance partners Team 973 and Team 2367 stand together during Semifinals Match 1

Helping Other Teams

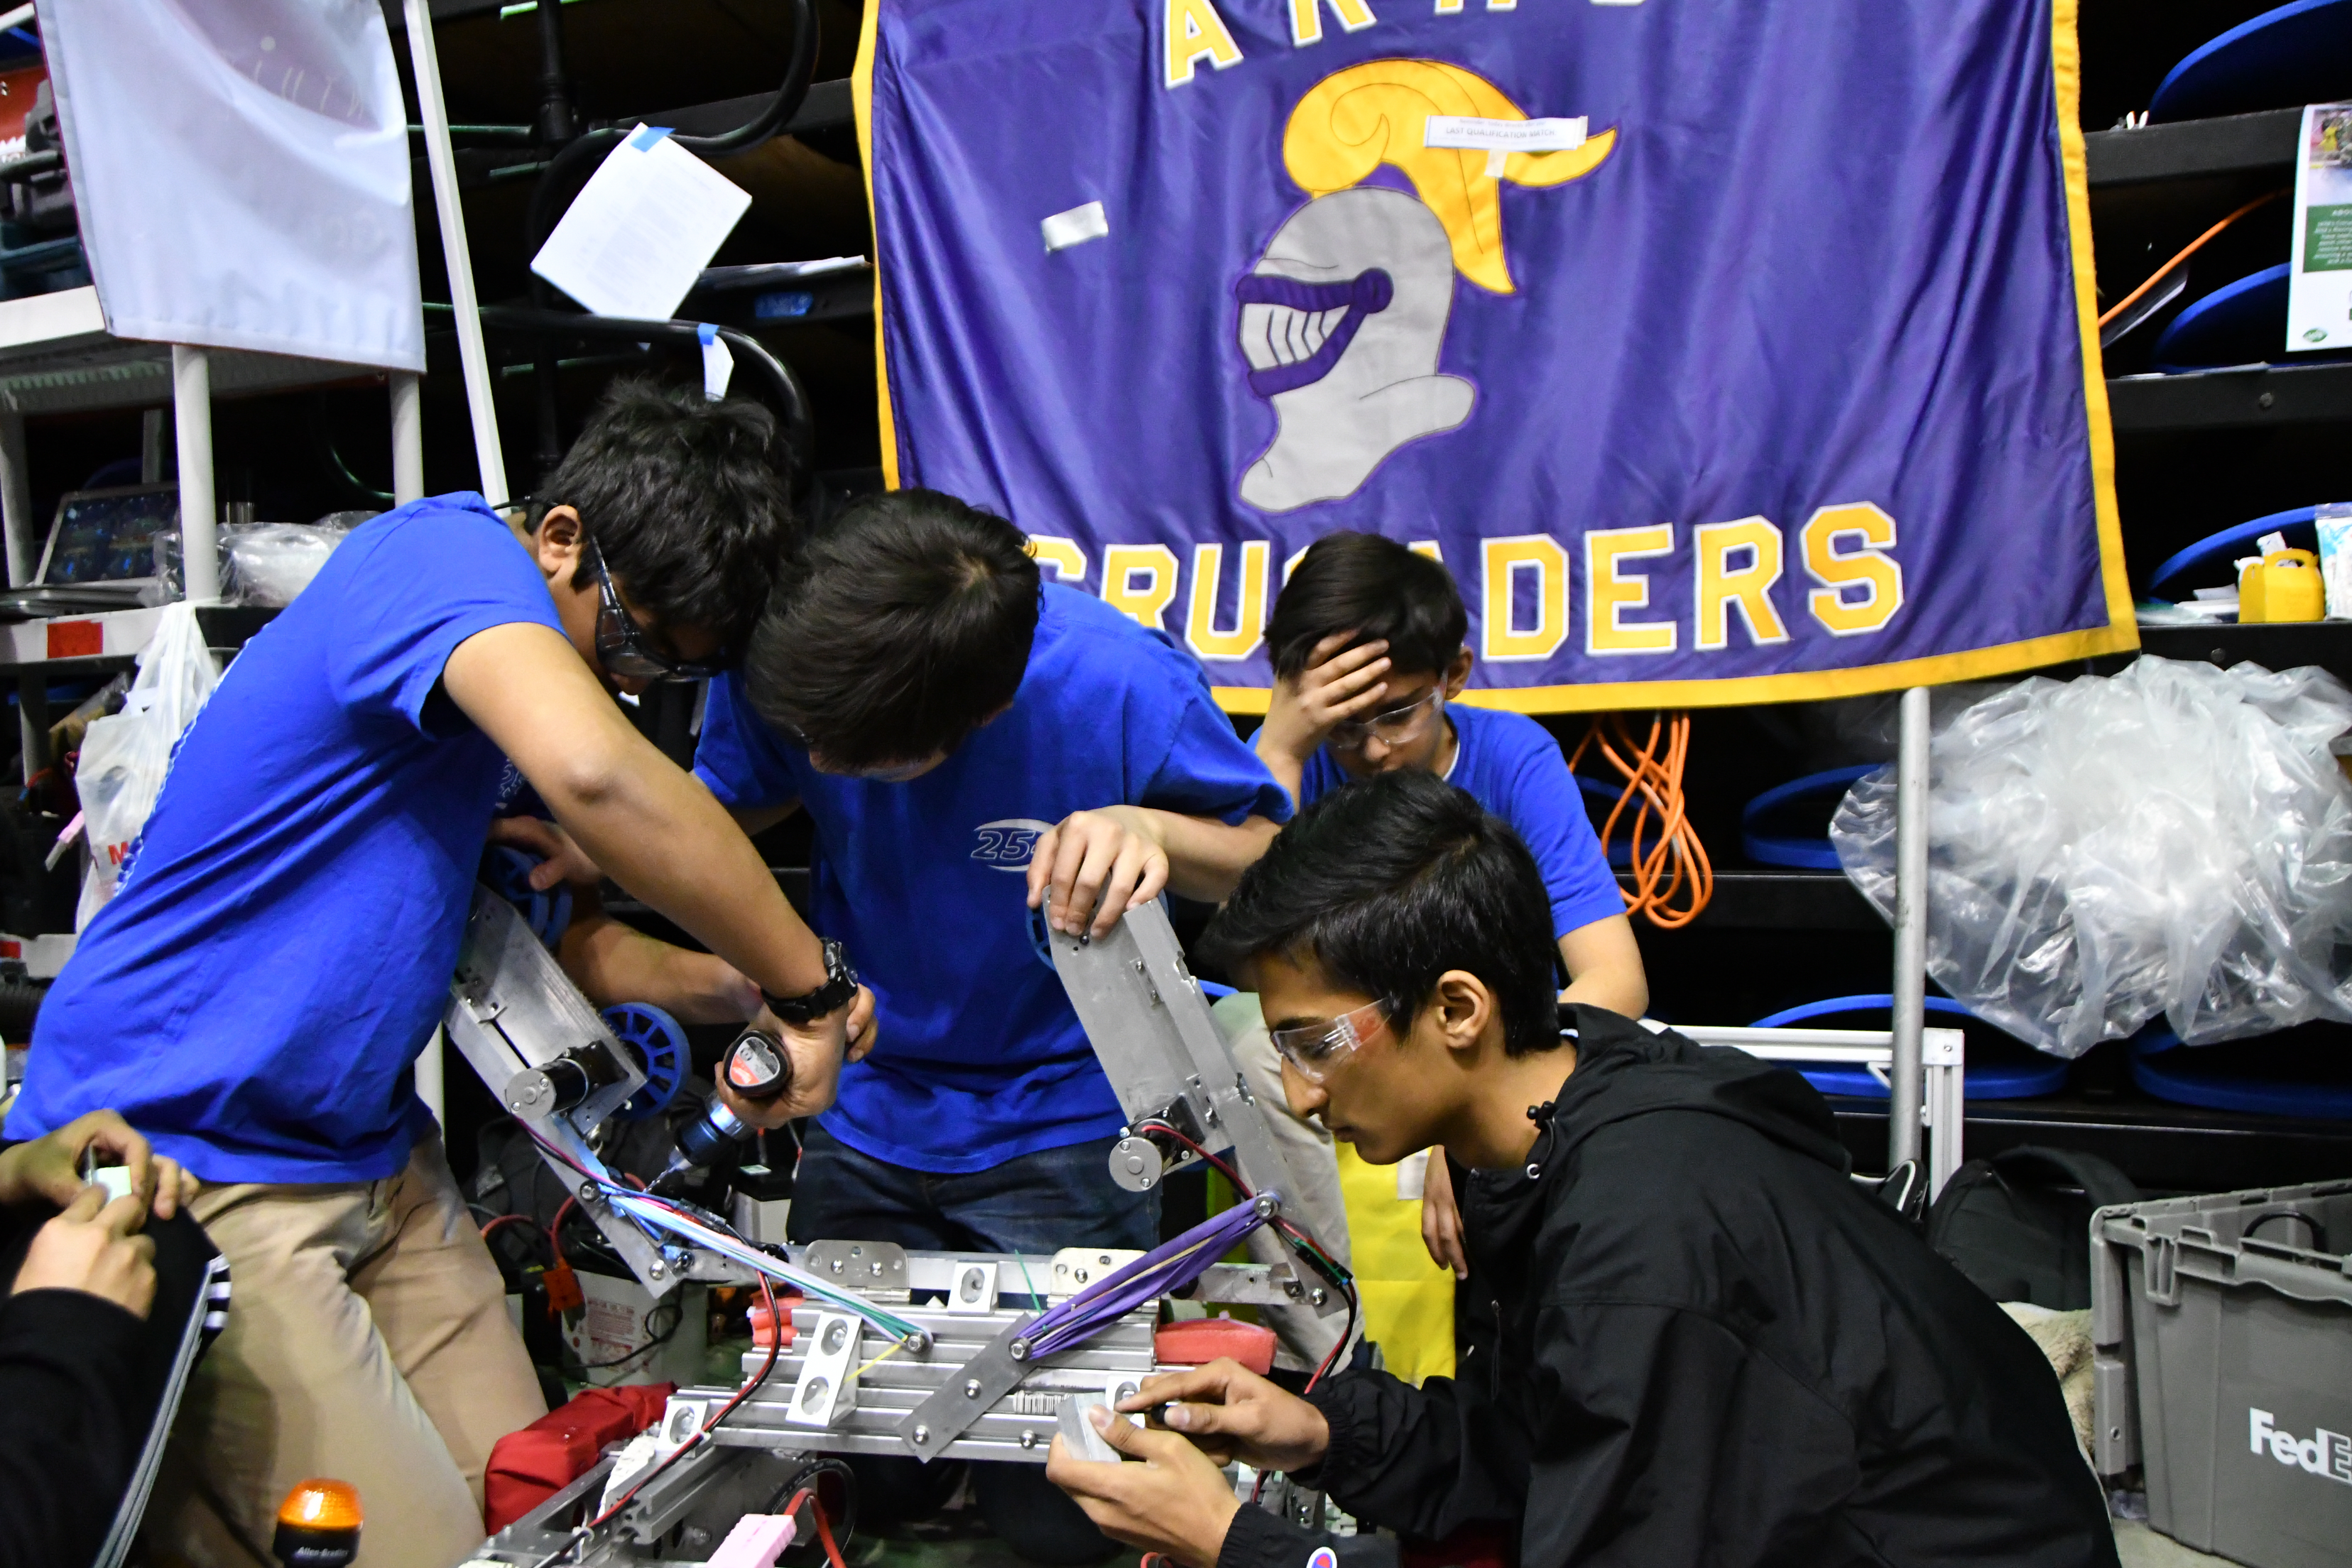
The Alliance Readiness Crew worked hard throughout the tournament to assist Team 6688 West Valley Middle College Robotics and Team 7317 Crusader Crew. Our crew helped improve the design of Team 6688’s exhaust system, used for delivering cubes to the switch, safely wire their control system, fix their pneumatics so that there were no leaks, and write an auto that could put cubes into the correct side switch. When Team 7317 needed help, our crew worked to create a new and improved intake system to collect and deliver cubes to the exchange. Through this experience, students were able to make friends and get more hands on with designing an actual robot.

Our alliance readiness crew assists Team 7317 in mounting hardstops for a newly designed intake

A Special Thanks

At the Silicon Valley Regional, we would not have been able to be so successful without the amazing teams that we were able to work with during our qualification and elimination matches. Also a special thanks for our pit crew and drive team for properly maintaining our robot during the tournament. A big thank you to the chairman’s presentation team for handling our team’s Chairman’s Presentation in front of a panel of FIRST Judges. Team 254 would also like to thank all the volunteers and judges that made this tournament an exciting experience, and all of our mentors, teachers, and parents who helped us succeed in this regional.

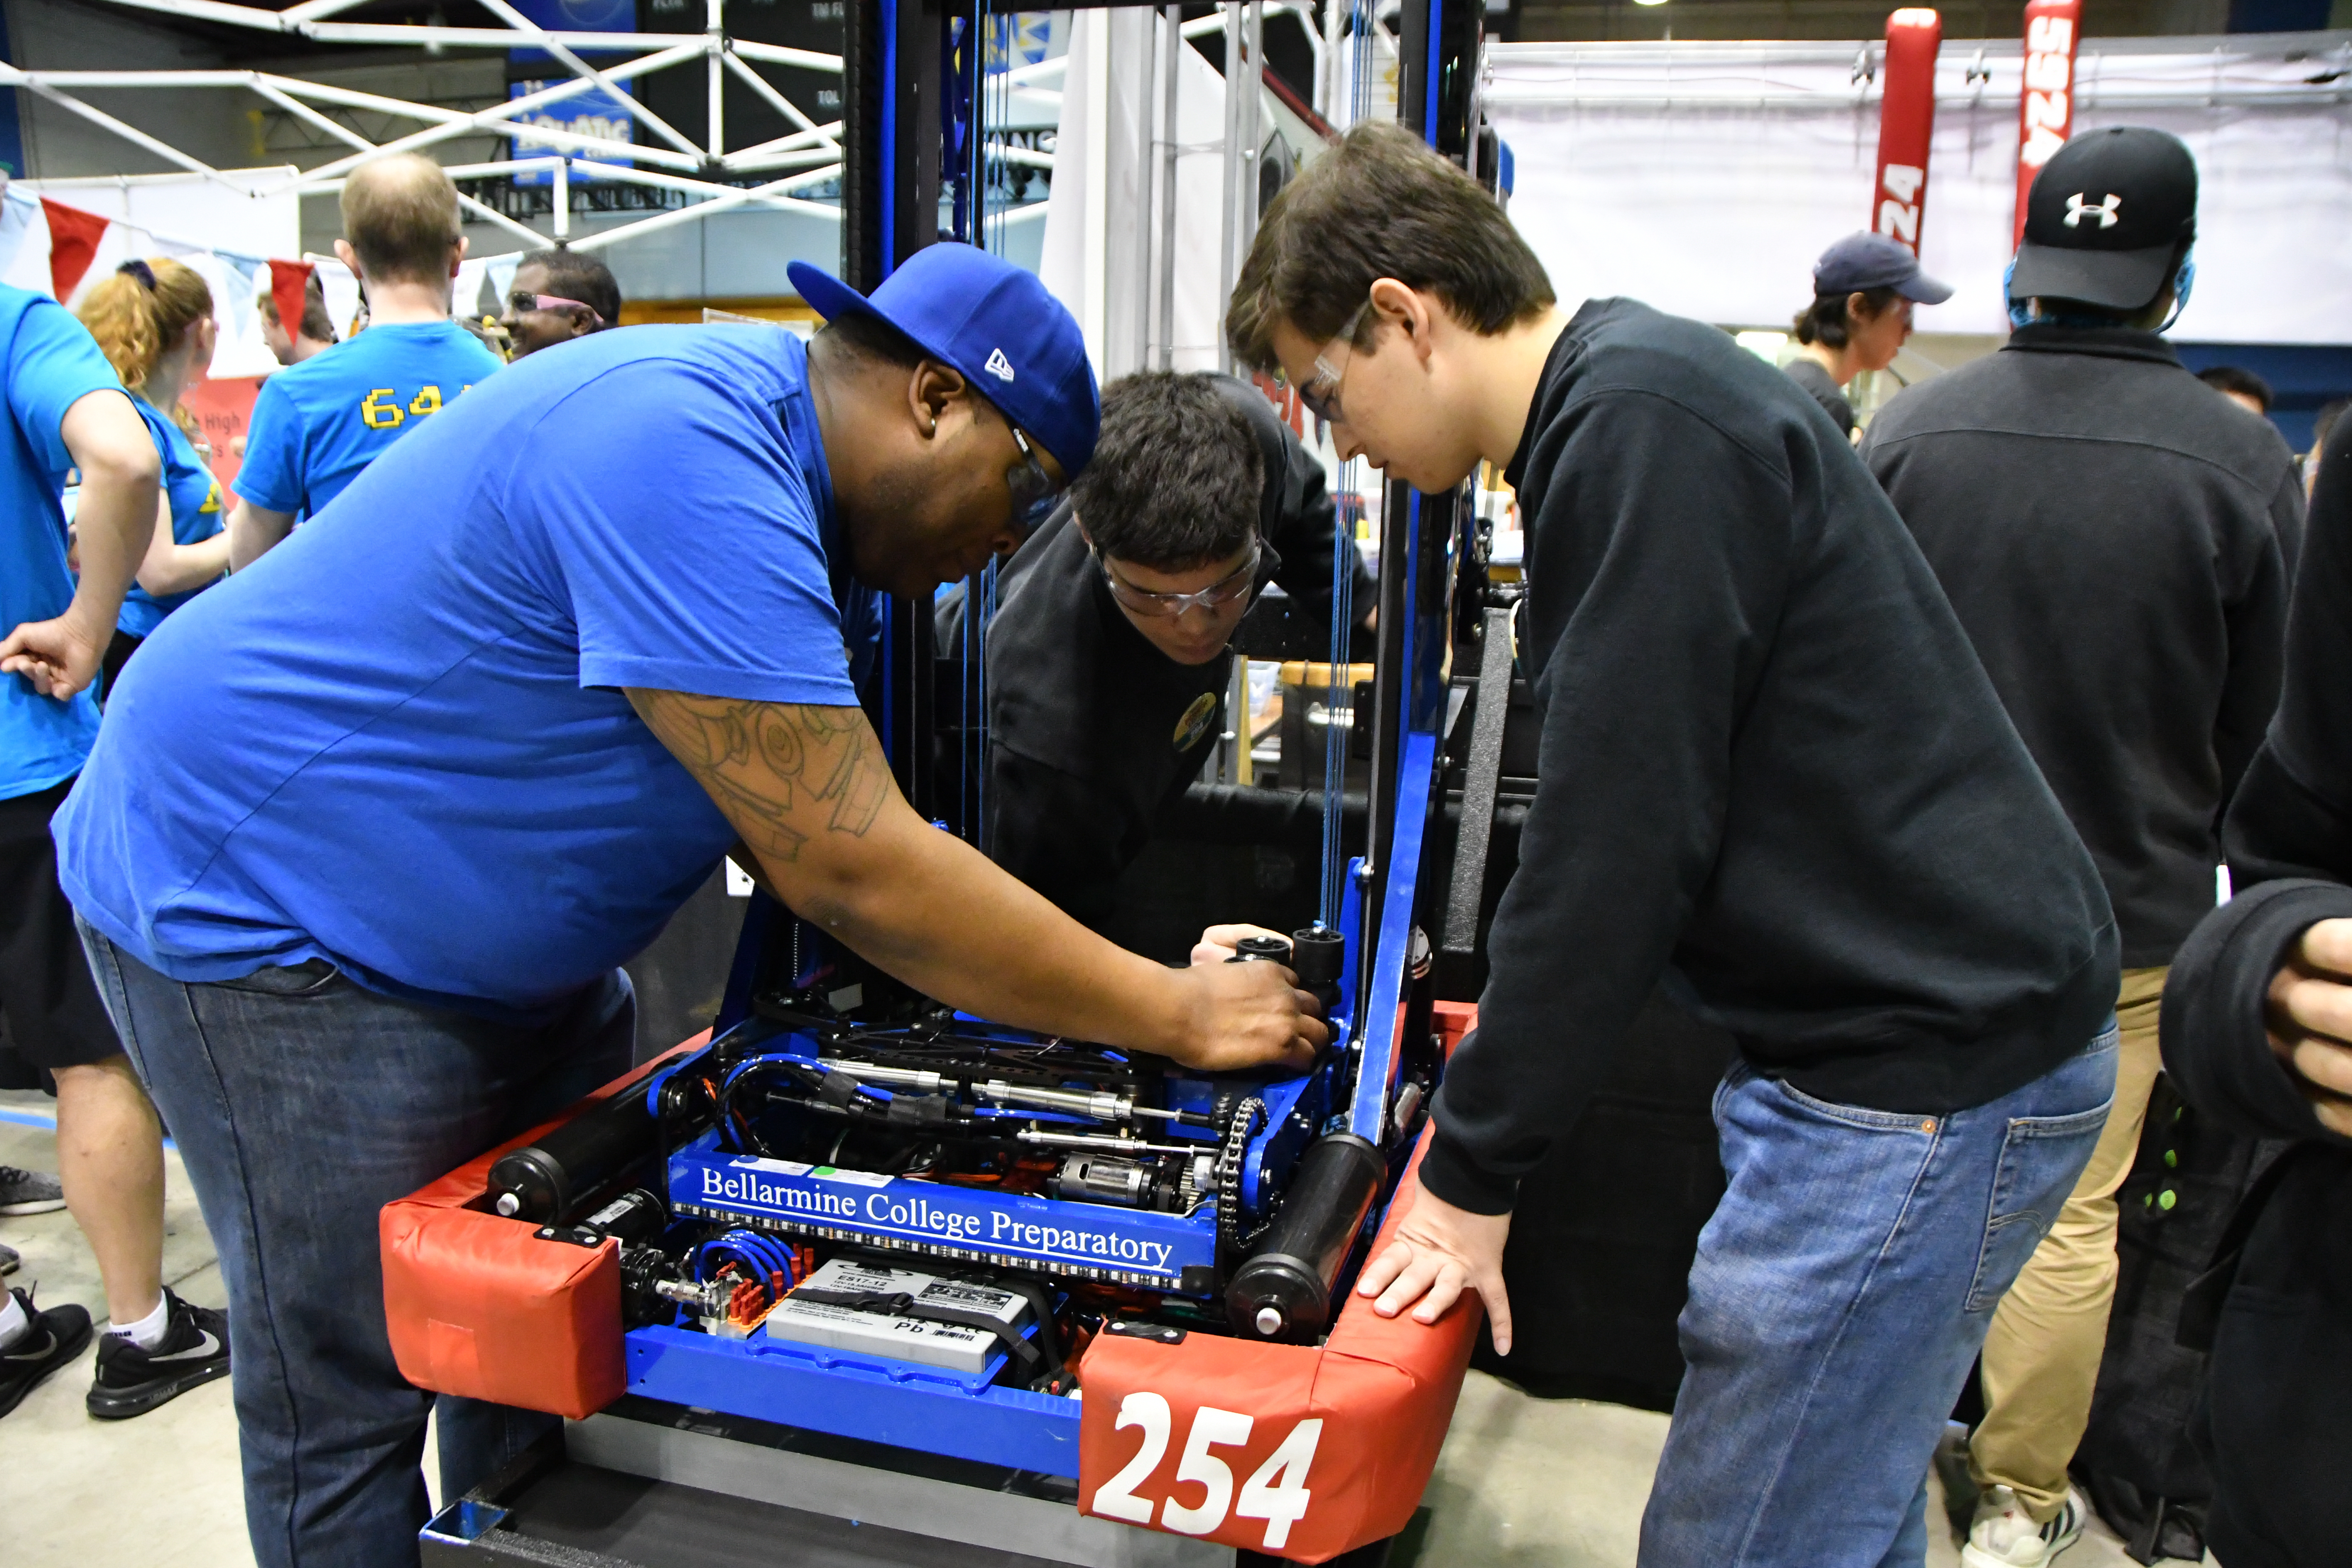
Members of the Team 254 Drive Team repair Lockdown with a mentor before an upcoming match

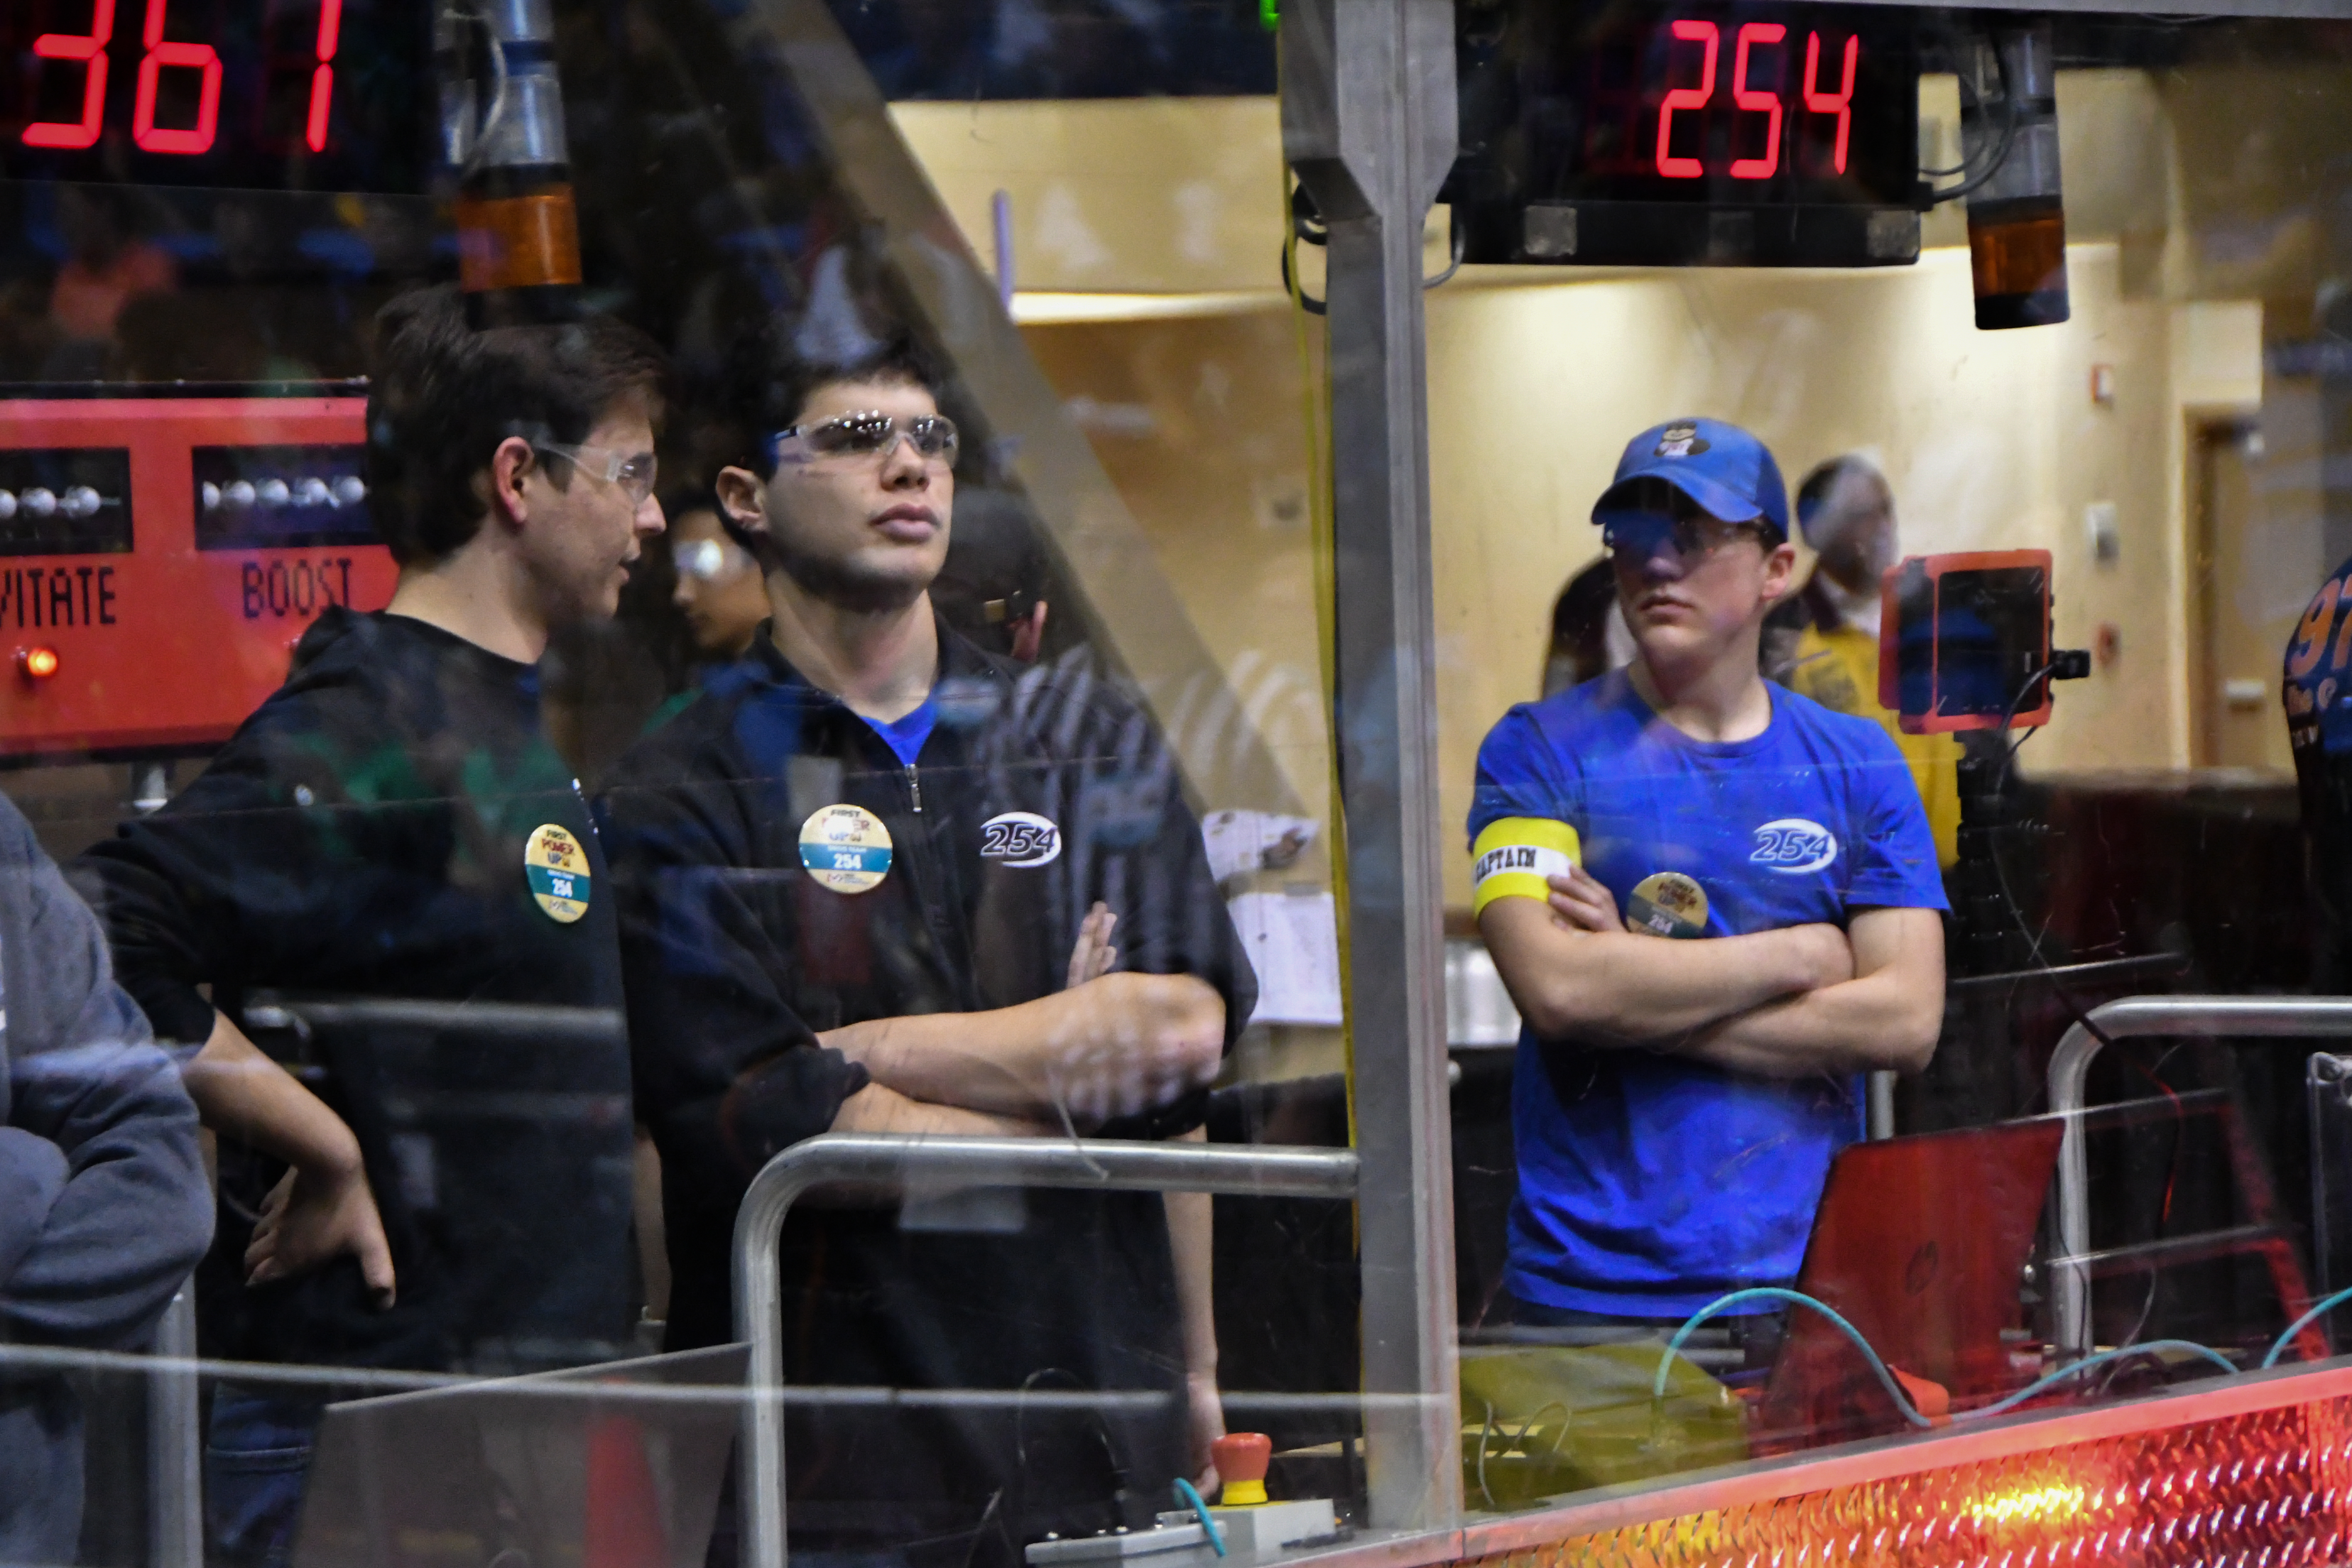
Our drive team discusses a possible strategy before a tense eliminations match

Excited Team 254 members receive the team’s 50th blue banner

2018 Arizona North Regional Champions!

2018 FRC Build Season

A Brief Summary

As part of an eventful weekend, we attended the Arizona North Regional, for the very first time, in Flagstaff, AZ. We had a great time starting off the FIRST Power Up Season with our robot, Lockdown. Alongside FRC Team 842 Falcon Robotics and FRC Team 2403 Plasma Robotics, we were able to win the tournament!

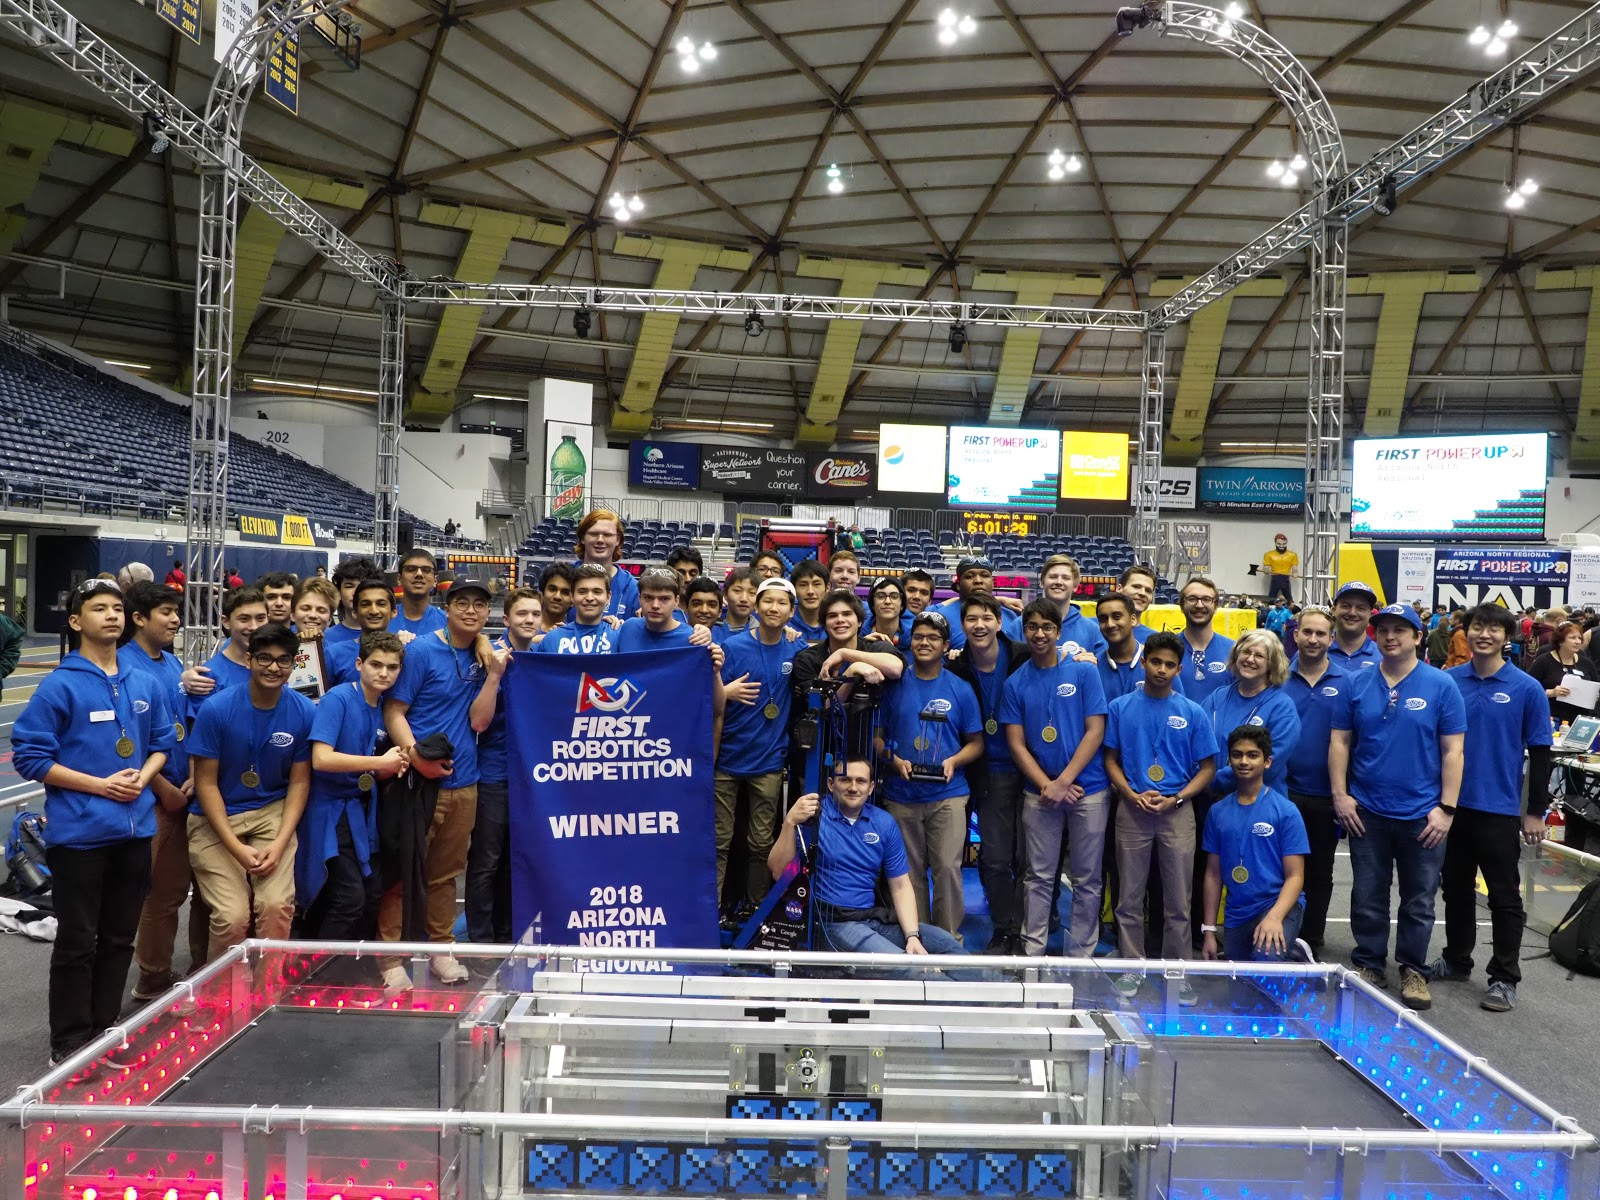
Team 254 poses for a picture with Lockdown after winning at the 2018 Arizona North Regional

Robot Performance

Qualification Matches

Throughout our qualification matches, we used an experimental strategy by testing out which of our autonomous programs worked best during a match. From this experimentation, we concluded that it would be best to use our autonomous program, which scored 2-3 cubes on the scale, to establish an early lead in a match. This autonomous program helped us gain ownership of the scale, but we had to focus more on maintaining ownership of the switches rather than the scale. Whenever we had alliance partners who could not secure the switch consistently, we ran our autonomous program for the switch to help our alliance partners before the tele-op period. During every match, we hung with our partners and used the levitate power up for an extra ranking point. By the end of the qualification match period, we were seeded first and had a undefeated record.

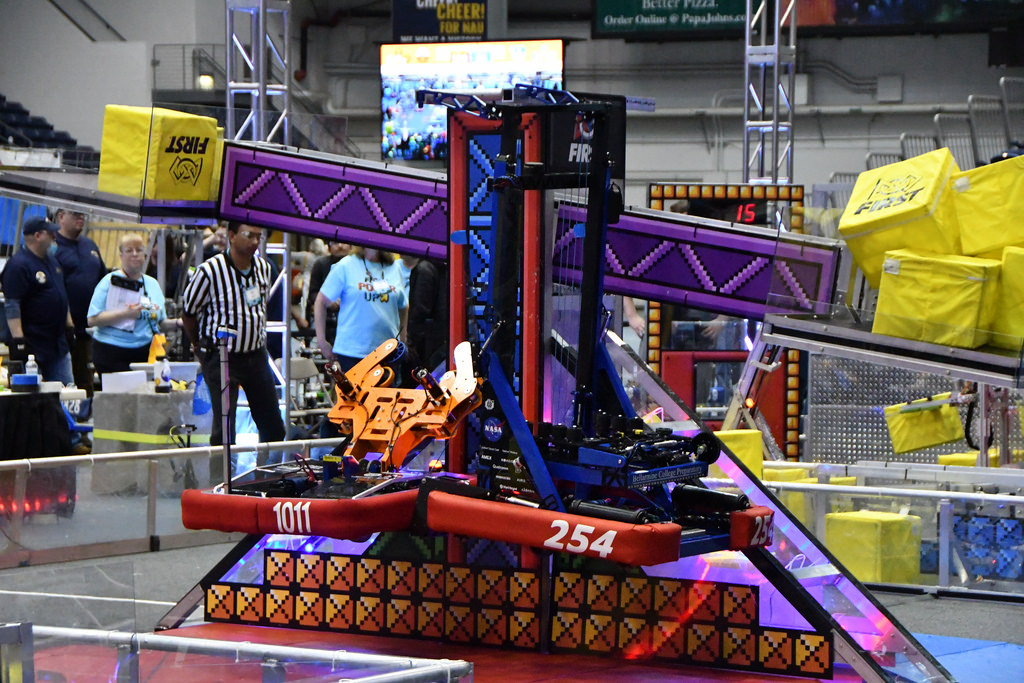
Team 254 and alliance partner Team 1011 work together to hang during Qualification Match 86

Alliance Selection

Going into the elimination period, we chose to form an alliance with FRC Team 842 Falcon Robotics, FRC Team 2403 Plasma Robotics.

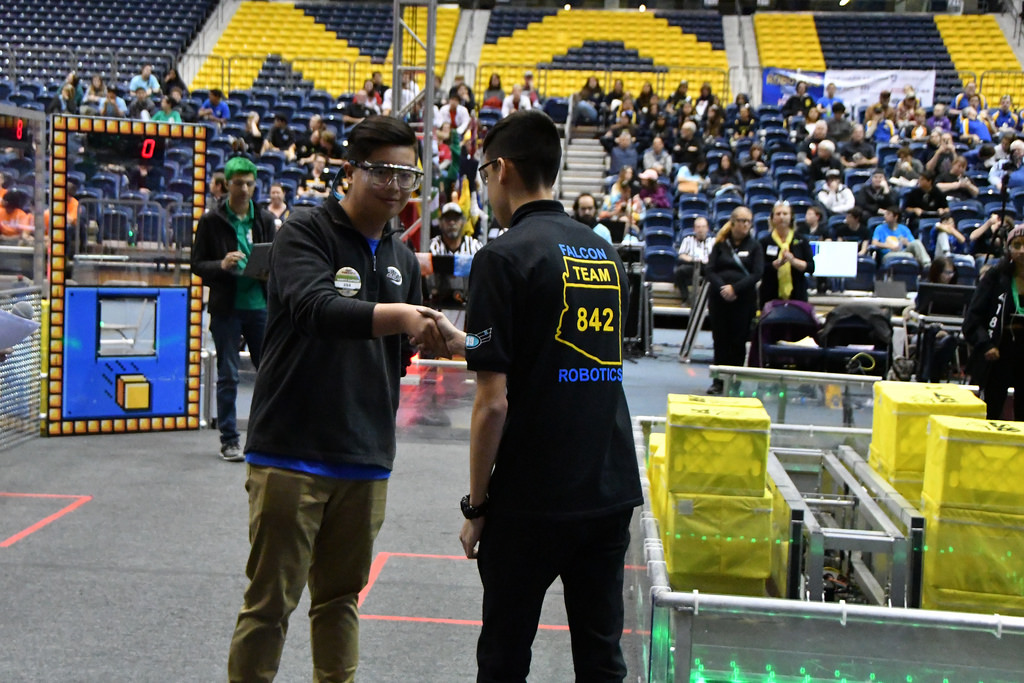
Team 254 representative, Brandon Chuang, greets Team 842 as they agree to join our alliance

Elimination Matches

During the elimination matches, we maintained our undefeated record for the entire tournament. Our autonomous program and Team 842’s robot, worked to score on the scale during each match. This allowed us to score on switches, while Team 842 covered the scale during the tele-op period. We also focused on stopping our opponents from gaining ownership of their own switch. If we had spare time during a match, we passed cubes through the exchange. Team 2403’s robot worked to gain ownership of our own switch and we also helped with scoring cubes in our switch. During finals, Team 2403 focused on switch, exchange, and defense against opponents who tried to take ownership of our switch. With an organized strategy and great alliance partners, we scored an all-time high of 594 points in Finals Match 2, allowing us to become the first-place alliance at the tournament!

Helping Other Teams

The Alliance Readiness Crew worked hard throughout the tournament to assist Team 6585 Hózhóogo Naasháa Doo and Team 6656 Ryu Botics. When Team 6656 needed an intake, our crew searched for the necessary parts and mounted a simple 2-wheel intake onto their robot. In addition, we helped them write an autonomous mode that crossed the auto line consistently. When Team 6585 needed a robot, our crew worked for 3 days to build and wire a drivebase, 2-wheel intake, and a polycarbonate box for collecting cubes from the portal. Through this experience, students were able to make friends and get more hands on with designing an actual robot.

Our alliance readiness crew assists Team 6585 in mounting a newly designed intake

A Special Thanks

At the Arizona North Regional, we would not have been able to be so successful without the amazing teams that we were able to work with during our qualification and elimination matches. Also a special thanks for our pit crew and drive team for properly maintaining our robot during the tournament. A big thank you to the chairman’s presentation team for handling our team’s Chairman’s Presentation in front of a panel of FIRST Judges. Team 254 would also like to thank all the volunteers and judges that made this tournament an exciting experience, and all of our mentors, teachers, and parents who helped us succeed in this regional.

Members of the Team 254 Pit Crew repair Lockdown before an upcoming match

Our drive team works together during a tense eliminations match

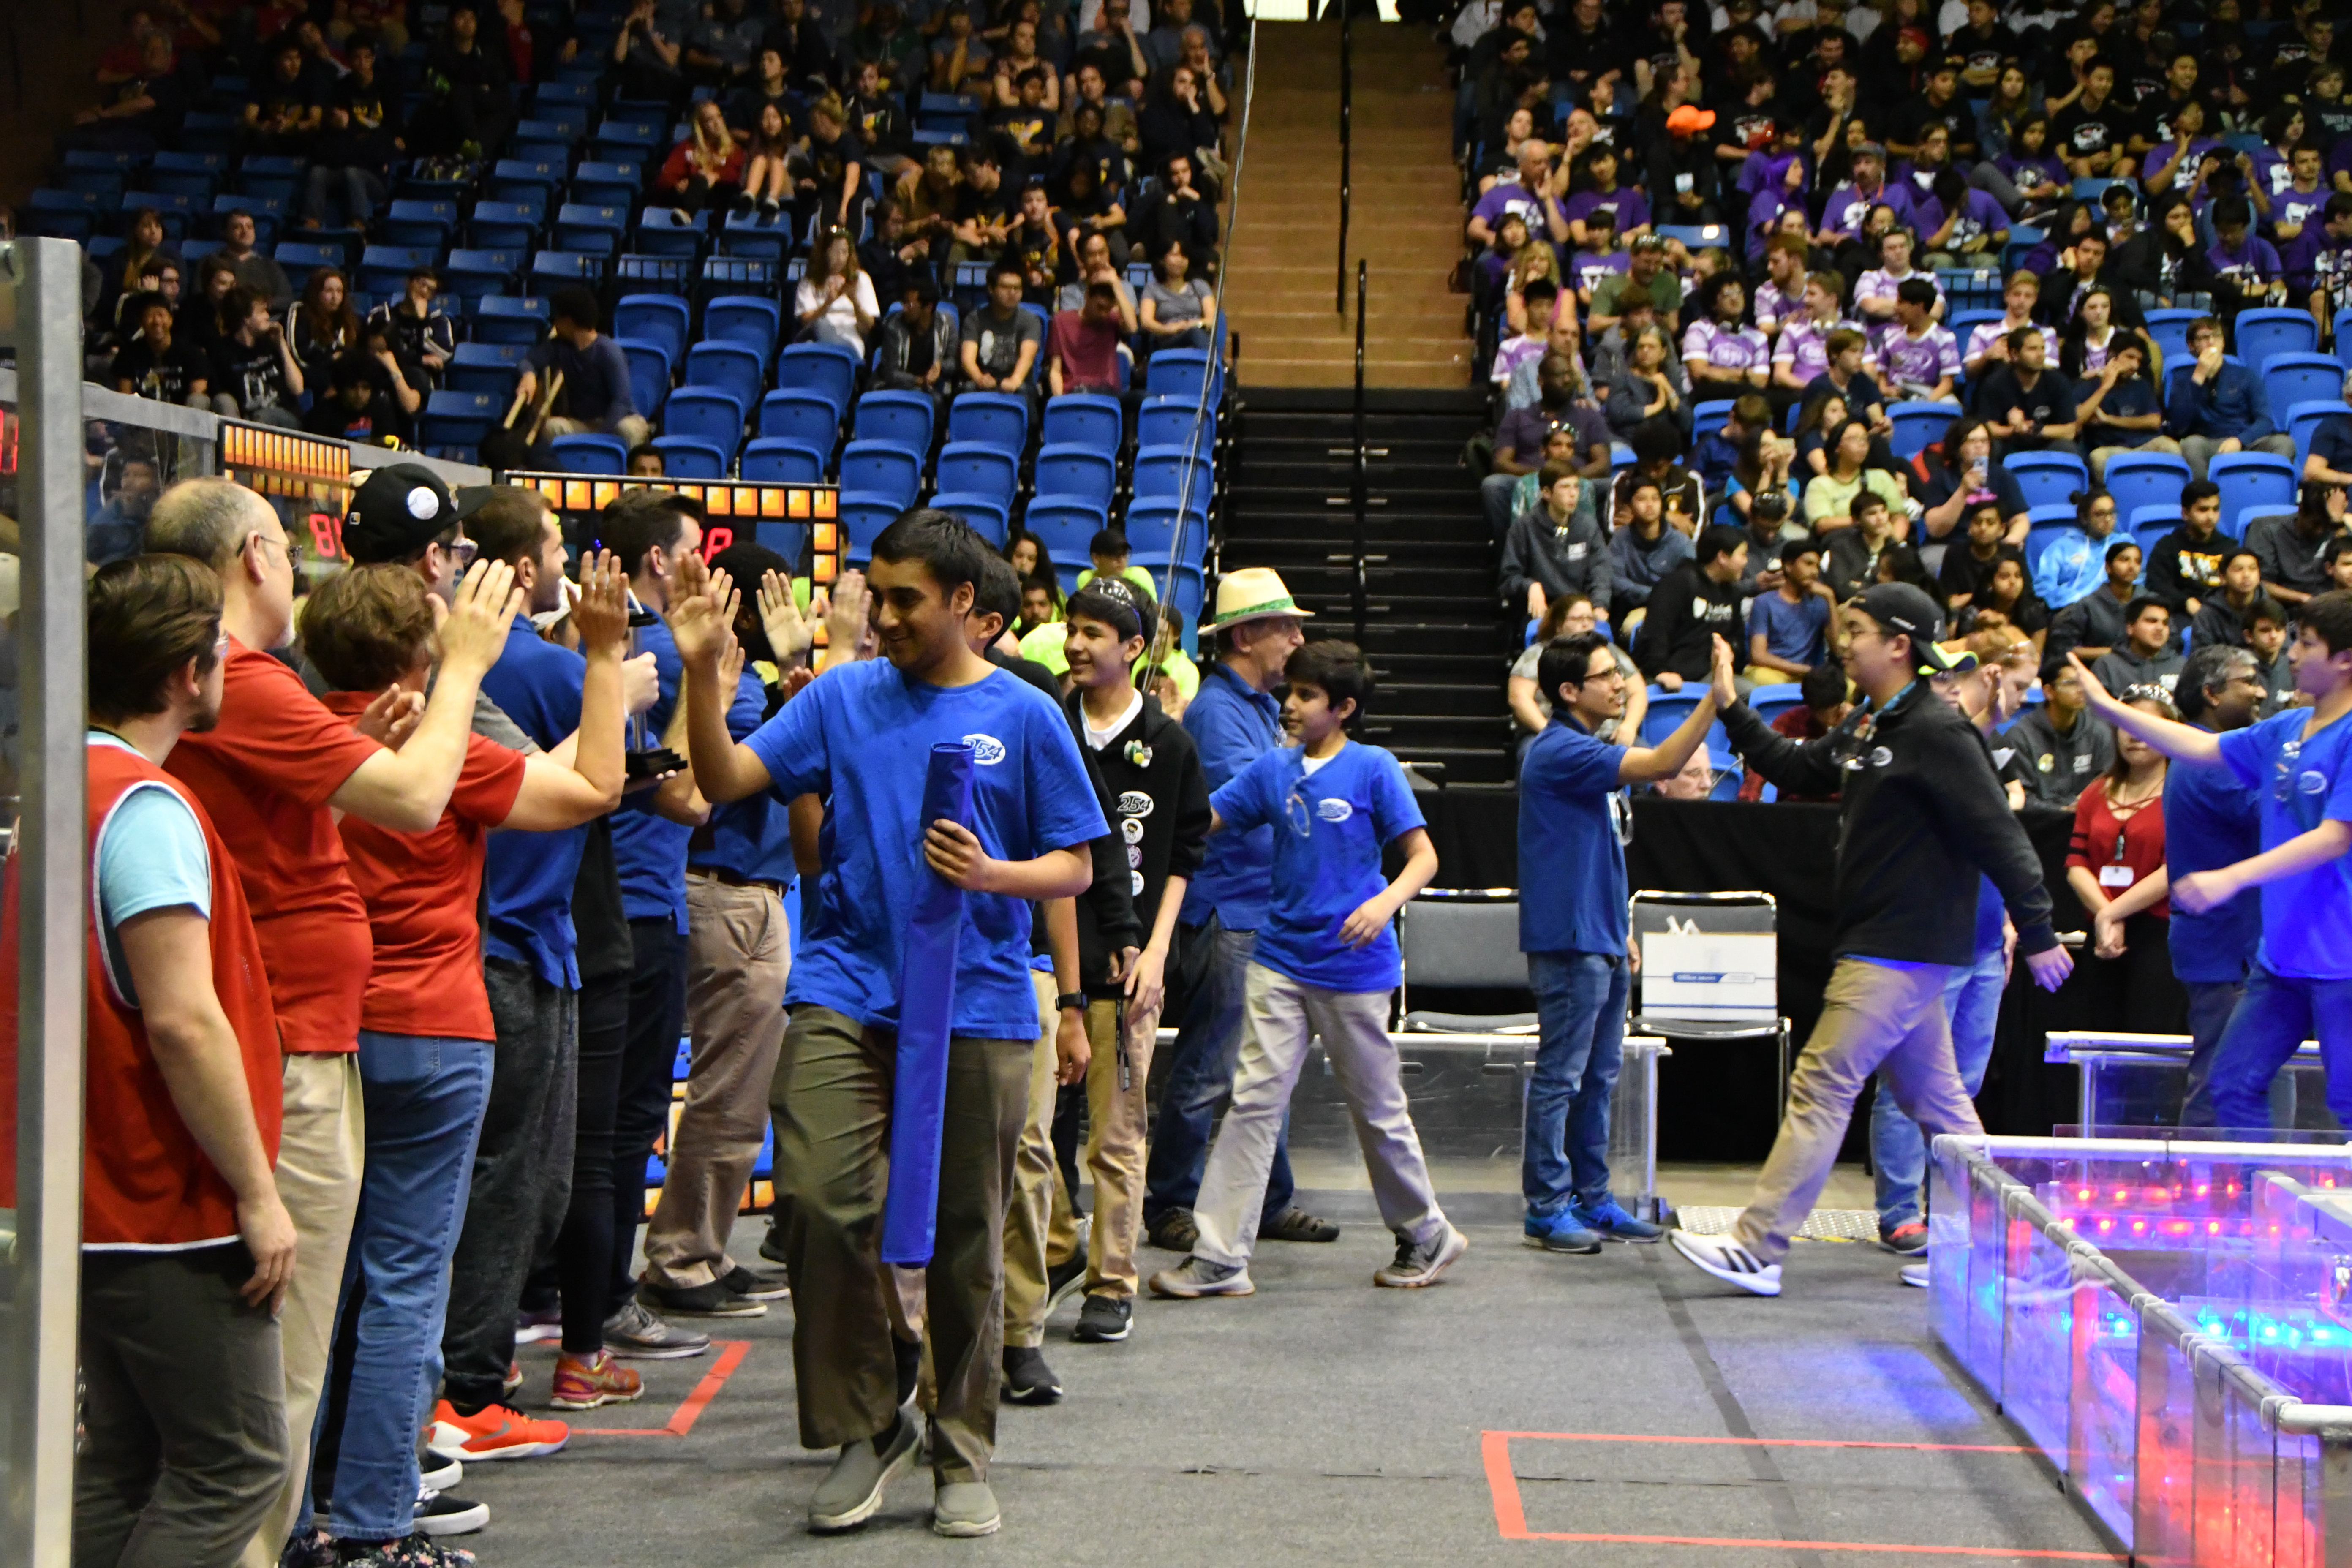
Spirited Team 254 members cheer excitedly for their alliance

Build Blog Days 28 and 29 (2/23/18 & 2/24/18)

2018 FRC Build Season

Programming

  • On Friday, 2/23, we handed off practice bot to the programmers to begin working on autonomous code. The programmers rewrote a large portion of our code to greatly simplify all our state machines and change the way operator controls work. They separated operator controls into wrist angle presets and height presets and experimented using an xbox controller rather than the button board. They also began working on some autonomous actions for intaking, setting superstructure position, and shooting/placing cubes.

Driver Tryouts

  • We had our first round of driver tryouts, where all 254 members interested in joining drive team participated in a written test. The purpose of the written test was to test one’s knowledge of the Game Rules and Drive Team Positions during a match. A few lucky students were chosen to move on to the second level of drive tryouts where they were able to drive Misfire, our robot from last year. Students were asked to pick up gears from the field and place them on a makeshift peg, using the controls on our driver station. After these two rounds of tryouts, we narrowed our choices for students on the drive team, and will finalize our choices over the course of this week.

Driver Practice

  • To facilitate driver practice this weekend, we rigged up the wooden lever arm of the scale we got from the SJSU kickoff onto the aluminum scale we are currently constructing. Our driveteam also practiced with Team 973 and Team 5499 throughout the day.

Working on Programming Bot

  • On Saturday, 2/24, we worked on getting programming bot to the same state as competition bot. This year, driving is an especially critical component of the game. Because our robot accelerates extremely quickly with the 6 MiniCIM drivetrain and has a high CG with the elevator, the driver needs to have confident control over the robot's motion to ensure it doesn't tip over and the operator needs to have confident control over the robot's operations to ensure our mechanisms are stowed unless needed and do not accidentally hit parts of the field.


Build Blog Days 18-27 (2/9/18 to 2/20/18)

2018 FRC Build Season

It's assembly time!

Part 1

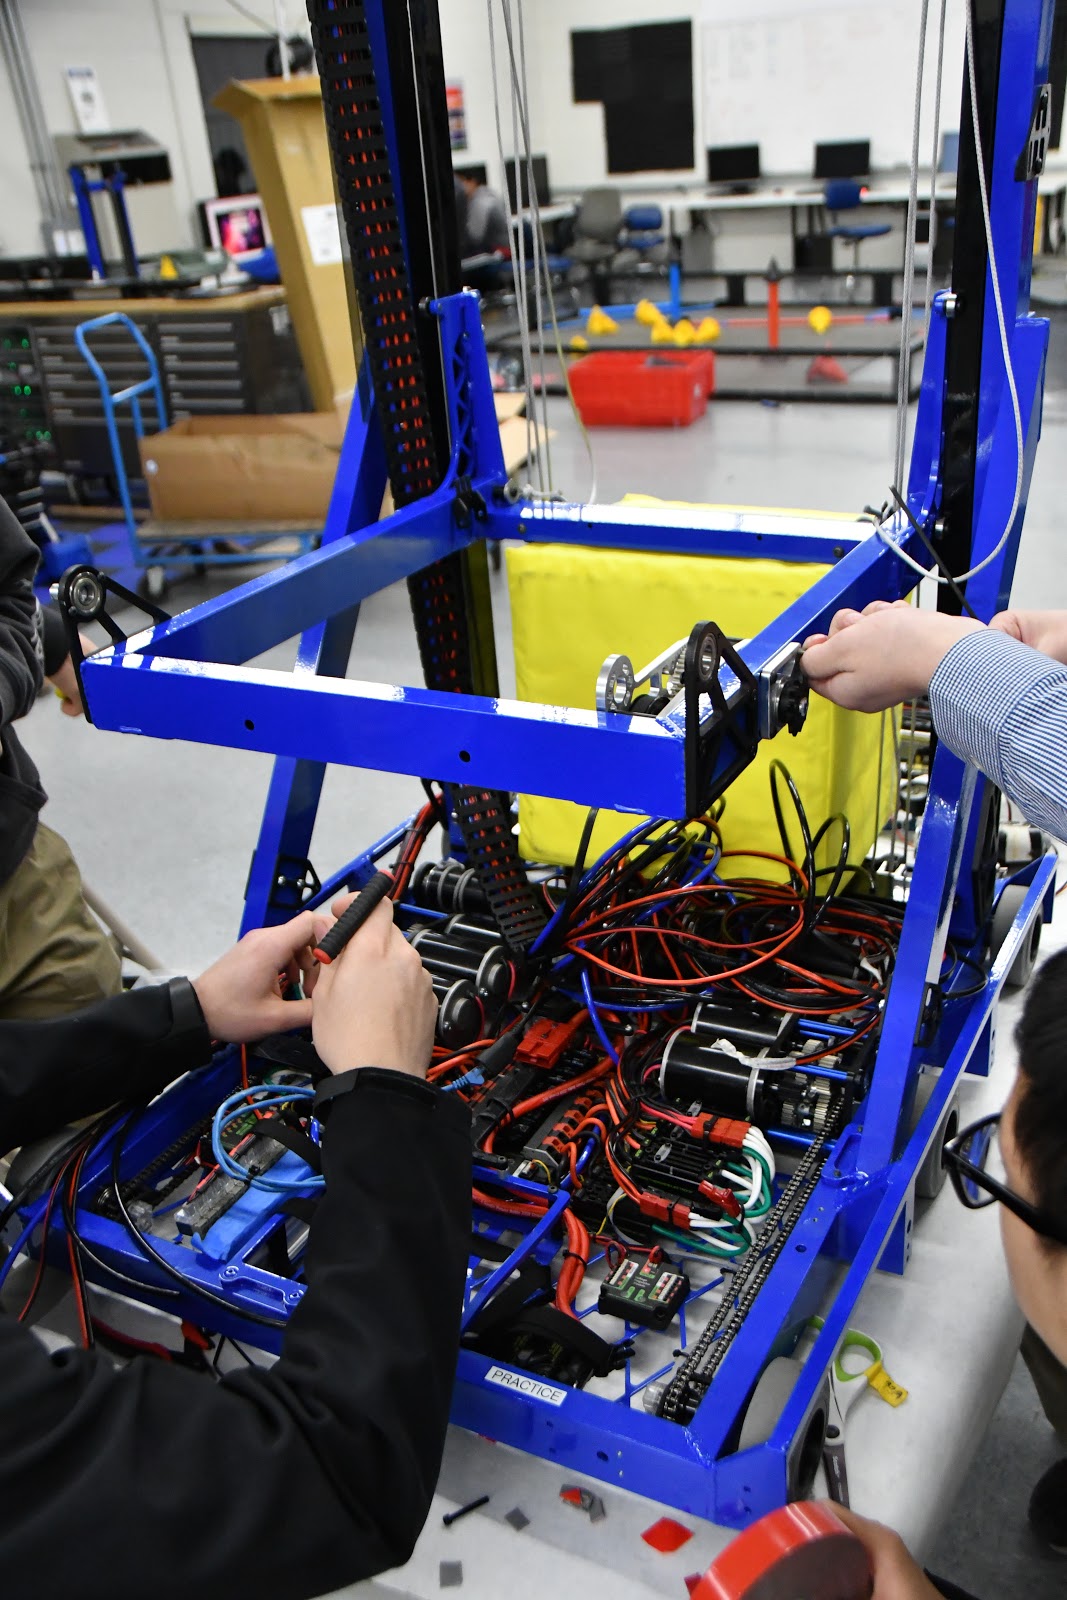
  • On Friday, 2/9, we assembled together the elevator on comp bot and tested out how wheel the intermediate stage and carriage slid with the bearing blocks. As we were sliding the stages, we noticed that the carriage was ripping off the powder-coating on the intermediate stage, so we decided to manufacture new inner stage uprights to be anodized for comp bot. We also assembled all 3 carriages and sanded down the welds. On Saturday, 2/10, we started putting everything together on all 3 robots. We installed all the bearing blocks and forklift brackets, and began wiring up the comp bot with the IGUS chain. We also decided to hook up a magnetic limit switch to the top of the horseshoe to detect the distance between it and the carriage. That switch will be connected to the encoder on the elevator gearbox. We also assembled an intake without the pivot arms and mounted it to programming bot to test out how well it works. On Sunday, 2/11, we worked on manufacturing more parts to send out for anodizing on Monday, 2/12, and we cabled up the elevator on practice bot and tested it out. We noticed that the elevator moves slower than we thought which may require a change in gearing, and we also noticed that the cable runs are too close together which may prove problematic for spitting the cube out the back.

  • On Wednesday, 2/14, we began assembling the programming bot and competition elevator gearboxes. After testing the elevator on Sunday night, we realized that it moved much slower than expected. To fix this, we swapped out the last stage gear reduction from an 18:50 to a 24:44 which theoretically allows us to climb 78.5" within 0.76 sec. We got back the intake pivot weldments from powder-coating and assembled them on practice bot.

  • On Thursday, 2/15, we continued work on assembling the intake. We wired up the CAN coming up from the PDP into the talon, then had the CAN daisy chain from the talon to the canifier, and then had the CAN terminate after the canifier with a 120 ohm resistor. The canifier will be used to breakout various DIO sensors we plan on placing on the intake such as magnetic limit switch sensors for soft stops for the intake pivot and beam break sensors for cube detection. We wired up the motors and pneumatics on the intake, and tested it out.


    • Part 2

      • After 4 intense days of early mornings and late nights, we bagged and tagged our completion robot last night! Thank you to all the students, mentors, and parents who made this build season possible!

      • Saturday, 2/17: We handed off the the practice bot to the programmers to begin tuning the wrist pivot and the elevator.

      • We wired up the carriage on competition bot by drilling in holes in the box tubing to channel the wires. We mounted the intake on the carriage and placed the magnetic limit switch sensor on the carriage pivot gearbox

      • Sunday, 2/18: The programming team continued tuning practice bot. We continued assembling and wiring competition bot.

      • Monday, 2/19: The programming team took competition bot to tune the mechanisms while the assembly team took practice bot to mount the forklift and hanger. We tested out both the forklift and hanger and saw that the sneaky hang with a partner was able to support two robots. While doing a solo sneaky hang, the robot did swing in which we expected to happen. We mounted a rollercoaster arm on practice bot hoping to counteract that swinging, but rather it only caused the robot to now pivot around where the rollercoaster arm contacted the scale. After all this testing, we decided to remove the partner hang and only mount the sneaky hang on competition bot.

      • Tuesday, 2/20: Stop build day! We finished up all the wiring and assembly on competition bot and took pictures of it. In the last hour, the programmers took the robot to test it, and we noticed a few issues arising with the intake, Omni followers, and sensors which will need to be corrected at competition. We bagged the robot at 115.9 lbs as well as a tote full of spare parts.


      • Our Final Robot